4 layers50 × 50 mm
 miodine/raspberry-pi-zero-flight-controller1
An open-source flight control shield for Raspberry Pi Zero. Use case: autonomous/intelligent drones.
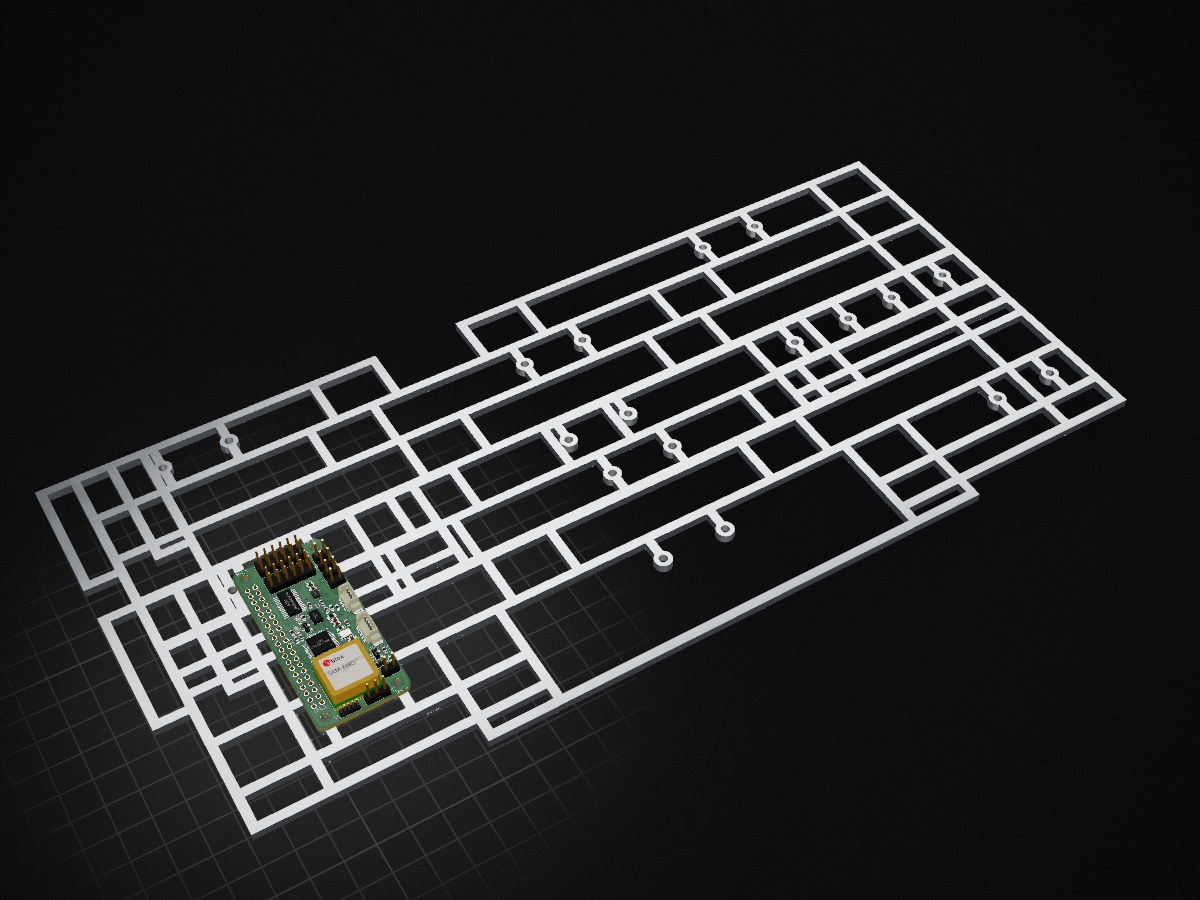
Board layout is an open-source printed circuit board by miodine, from the miodine/raspberry-pi-zero-flight-controller repository on GitHub. It is a 4-layer board of 30 × 65 mm with 51 parts on 104 nets, routed with 694 tracks and 92 vias.
It is built around the DPS310XTSA1, PCA9685PW and AP2112K-3.3, with the BMX055 and SI2319CDS among its other parts. Its parts include 16 capacitors, 12 connectors, 7 resistors, 6 ICs and 2 diodes. It belongs with the STM32 boards of this library.


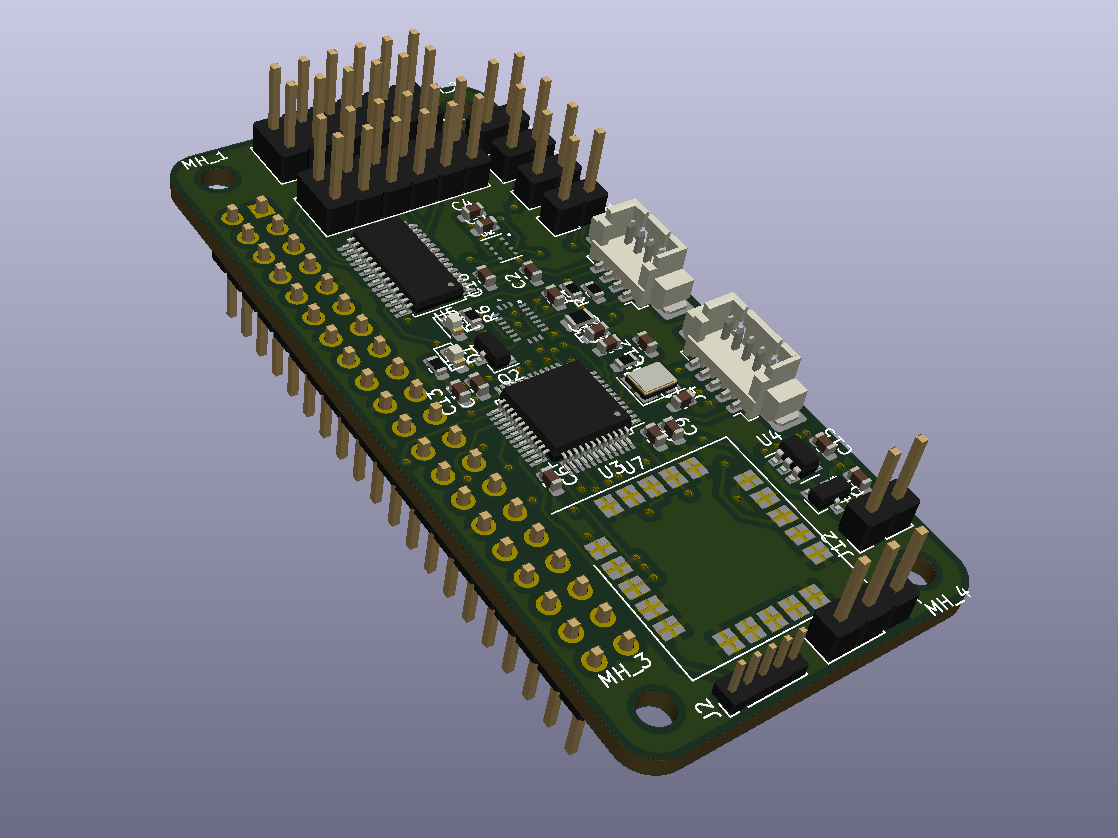
A small hobby electronics project - hardware interface for intelligent autonomous UAVs. The board is designed to be plugged into the Raspberry Pi Zero pin socket, to form a consistent flight control system. It is the same concept as Navio2 or the Navigator, but for a smaller board.
At the moment of designing (August 2022) these were all available on JLCPCB.
Not at this time :c Slightly tweaked ArduPilot (popular stuff, it is running on ChibiOS) will probably be a good fit.
Special thanks to TK for actually checking the commit tree!
Couple of cool links and reference projects from @pms67:
| Qty | Value | Footprint | References |
|---|---|---|---|
| 5 | 100n | Capacitor_SMD:C_0603_1608Metric | C5, C6, C9, C11, C16 |
| 5 | Conn_01x02_Female | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J8, J9, J10, J11, J12 |
| 4 | 100nF | Capacitor_SMD:C_0603_1608Metric | C1, C2, C3, C4 |
| 4 | MountingHole_2.7mm_M2.5_ISO7380 | MountingHole:MountingHole_2.7mm_M2.5_ISO7380 | MH_1, MH_2, MH_3, MH_4 |
| 3 | 1k | Resistor_SMD:R_0603_1608Metric | R5, R6, R7 |
| 3 | 1u | Capacitor_SMD:C_0603_1608Metric | C8, C14, C15 |
| 2 | 12p | Capacitor_SMD:C_0603_1608Metric | C7, C12 |
| 2 | 4.7k | Resistor_SMD:R_0603_1608Metric | R2, R4 |
| 2 | Conn_02x06_Odd_Even | Connector_PinHeader_2.54mm:PinHeader_2x06_P2.54mm_Vertical | J5, J6 |
| 2 | Si2319CDS | Package_TO_SOT_SMD:SOT-23 | Q1, Q2 |
| 1 | 10k | Resistor_SMD:R_0603_1608Metric | R1 |
| 1 | 10n | Capacitor_SMD:C_0603_1608Metric | C10 |
| 1 | 4.7u | Capacitor_SMD:C_0603_1608Metric | C13 |
| 1 | 47 | Resistor_SMD:R_0603_1608Metric | R3 |
| 1 | AP2112K-3.3 | Package_TO_SOT_SMD:SOT-23-5 | U4 |
| 1 | BLUE | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D2 |
| 1 | BMX055 | Sensor:BMX055 | U1 |
| 1 | BOOT_MDE | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J1 |
| 1 | Conn_01x04 | Connector_Molex:Molex_PicoBlade_53398-0471_1x04-1MP_P1.25mm_Vertical | J3 |
| 1 | Conn_01x05 | Connector_Molex:Molex_PicoBlade_53398-0571_1x05-1MP_P1.25mm_Vertical | J4 |
| 1 | Conn_02x20_Odd_Even | Connector_PinHeader_2.54mm:PinHeader_2x20_P2.54mm_Vertical | J7 |
| 1 | Crystal_GND24 | Crystal:Crystal_SMD_3225-4Pin_3.2x2.5mm | Y1 |
| 1 | DEBUG | Connector_PinHeader_1.27mm:PinHeader_1x05_P1.27mm_Vertical | J2 |
| 1 | DPS310XTSA1 | Sensor:XDCR_DPS310XTSA1 | U2 |
| 1 | Ferrite_Bead_Small | Resistor_SMD:R_0805_2012Metric | FB1 |
| 1 | PCA9685PW | Package_SO:TSSOP-28_4.4x9.7mm_P0.65mm | U5 |
| 1 | RED | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D1 |
| 1 | STM32F103CBTx | Package_QFP:LQFP-48_7x7mm_P0.5mm | U3 |
| 1 | ublox_SAM-M8Q | RF_GPS:ublox_SAM-M8Q | U7 |
It measures 30 × 65 mm and has 4 copper layers, 1.6 mm thick.
51 parts, built around the DPS310XTSA1, PCA9685PW, AP2112K-3.3 and BMX055. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the miodine/raspberry-pi-zero-flight-controller repository on GitHub, at the commit this page was made from: the board is src/board_layout.kicad_pcb and its schematic src/board_layout.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask miodine before reusing the design.

fkontiebo/flight-controller
Contrôleur de vol 4 layers basé sur STM32F405RGT6, conçu comme plateforme de navigation autonome avec bus CAN.

PhilipMcGaw/robot-NautiPi
NautiPi is the physical hardware and embedded-project repository for the robot projects. It contains electronics, PCB and KiCad work, Arduino projects, component records, mechanical references, photographs, and retained…

yvolodym/esp32-clock
Low-power round-display ESP32 desk clock built with Arduino/PlatformIO, with a companion KiCad PCB design

apertus-open-source-cinema/axiom-micro-mainboard
axiom micro mainboard containing the cmos sensor, headers for plugin modules and more


LulaUAV/Strelka-Flight-Computer
Strelka exists in the family of rocket dog flight computers. This flight computer is fully capable of deploying recovery events.

jackbrad1ey/water_jet_tvc
A water-propelled thrust vector control (TVC) testbed vehicle aiming to decrease the cost and time factors associated with developing TVC control algorithms