
2 layers43.2 × 88.3 mm

 mgrova/SLAM_Wheel-E6
SLAM using ROS with Wheel-E
Motor driver is an open-source printed circuit board by mgrova, from the mgrova/SLAM_Wheel-E repository on GitHub, published under the GPL-3.0 licence. It is a 2-layer board of 69.6 × 75.7 mm with 17 parts on 28 nets, routed with 187 tracks and 0 vias.
It is built around the L293D. Its parts include 14 connectors and 3 ICs. It belongs with the robots and motor control boards of this library.
Este es un proyecto en el cual se busca realizar una comparativa de diferentes técnicas de SLAM empleando un robot movil diferencial tipo Rover.
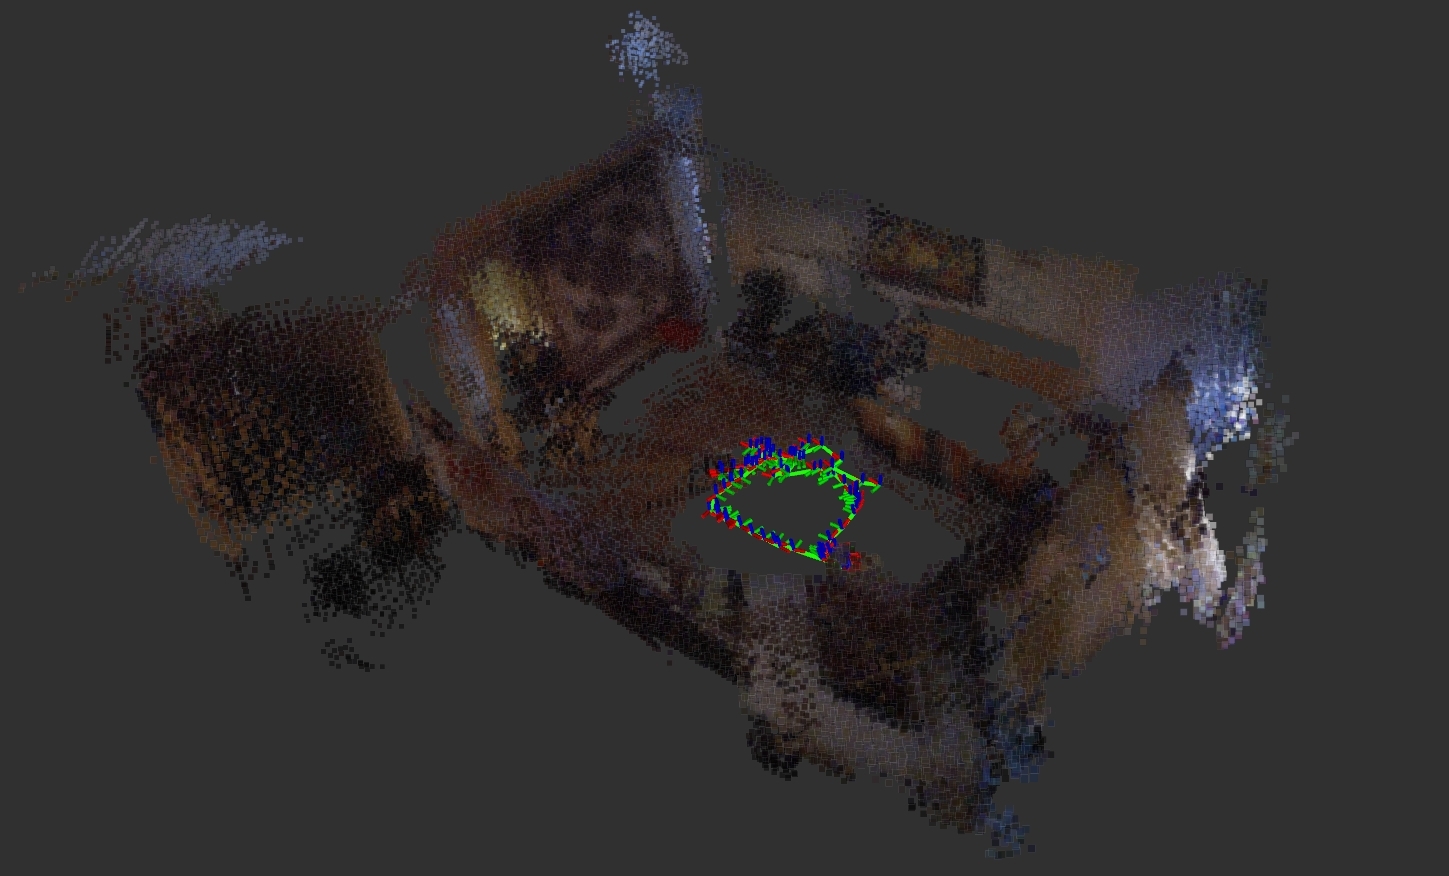
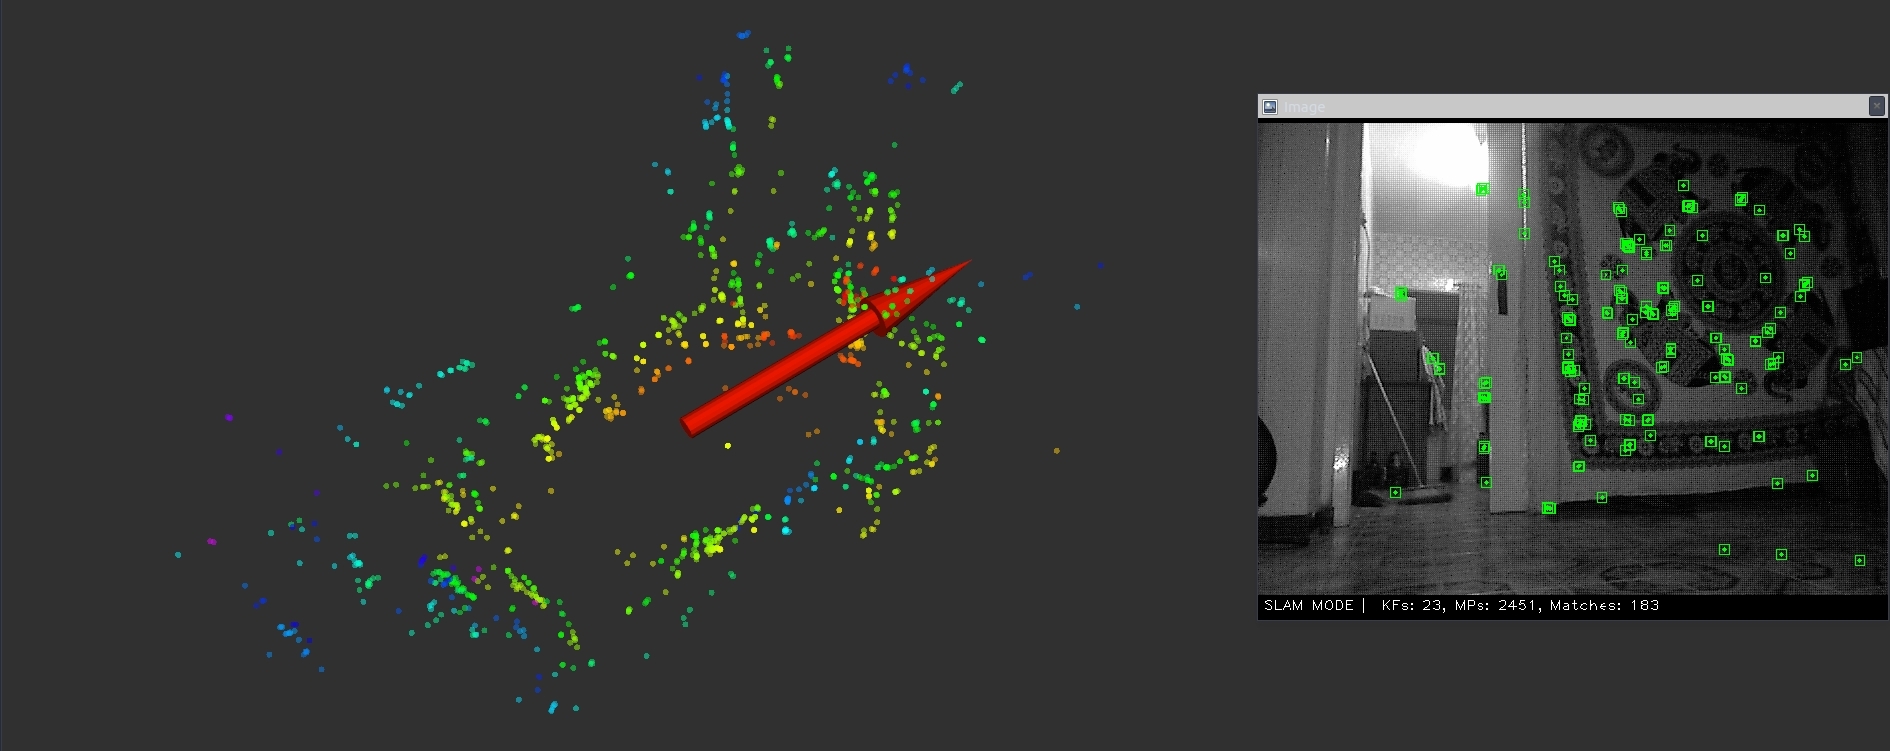
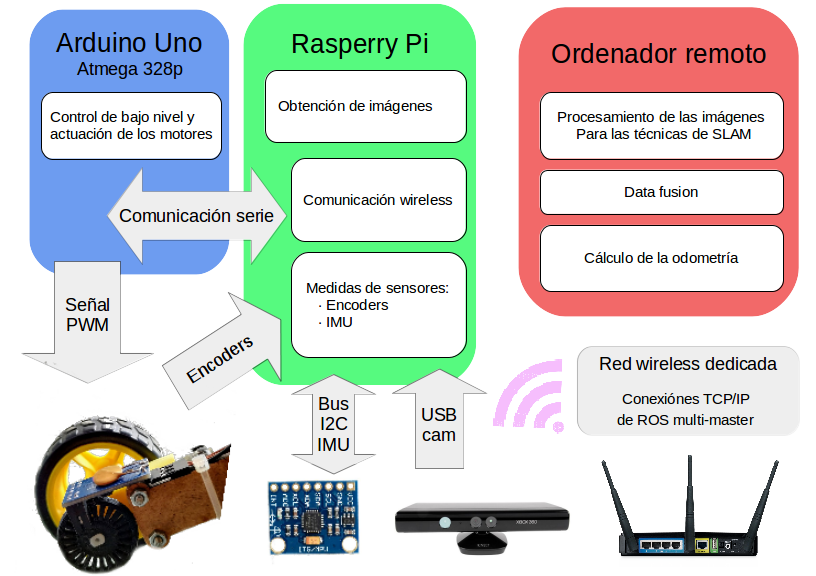
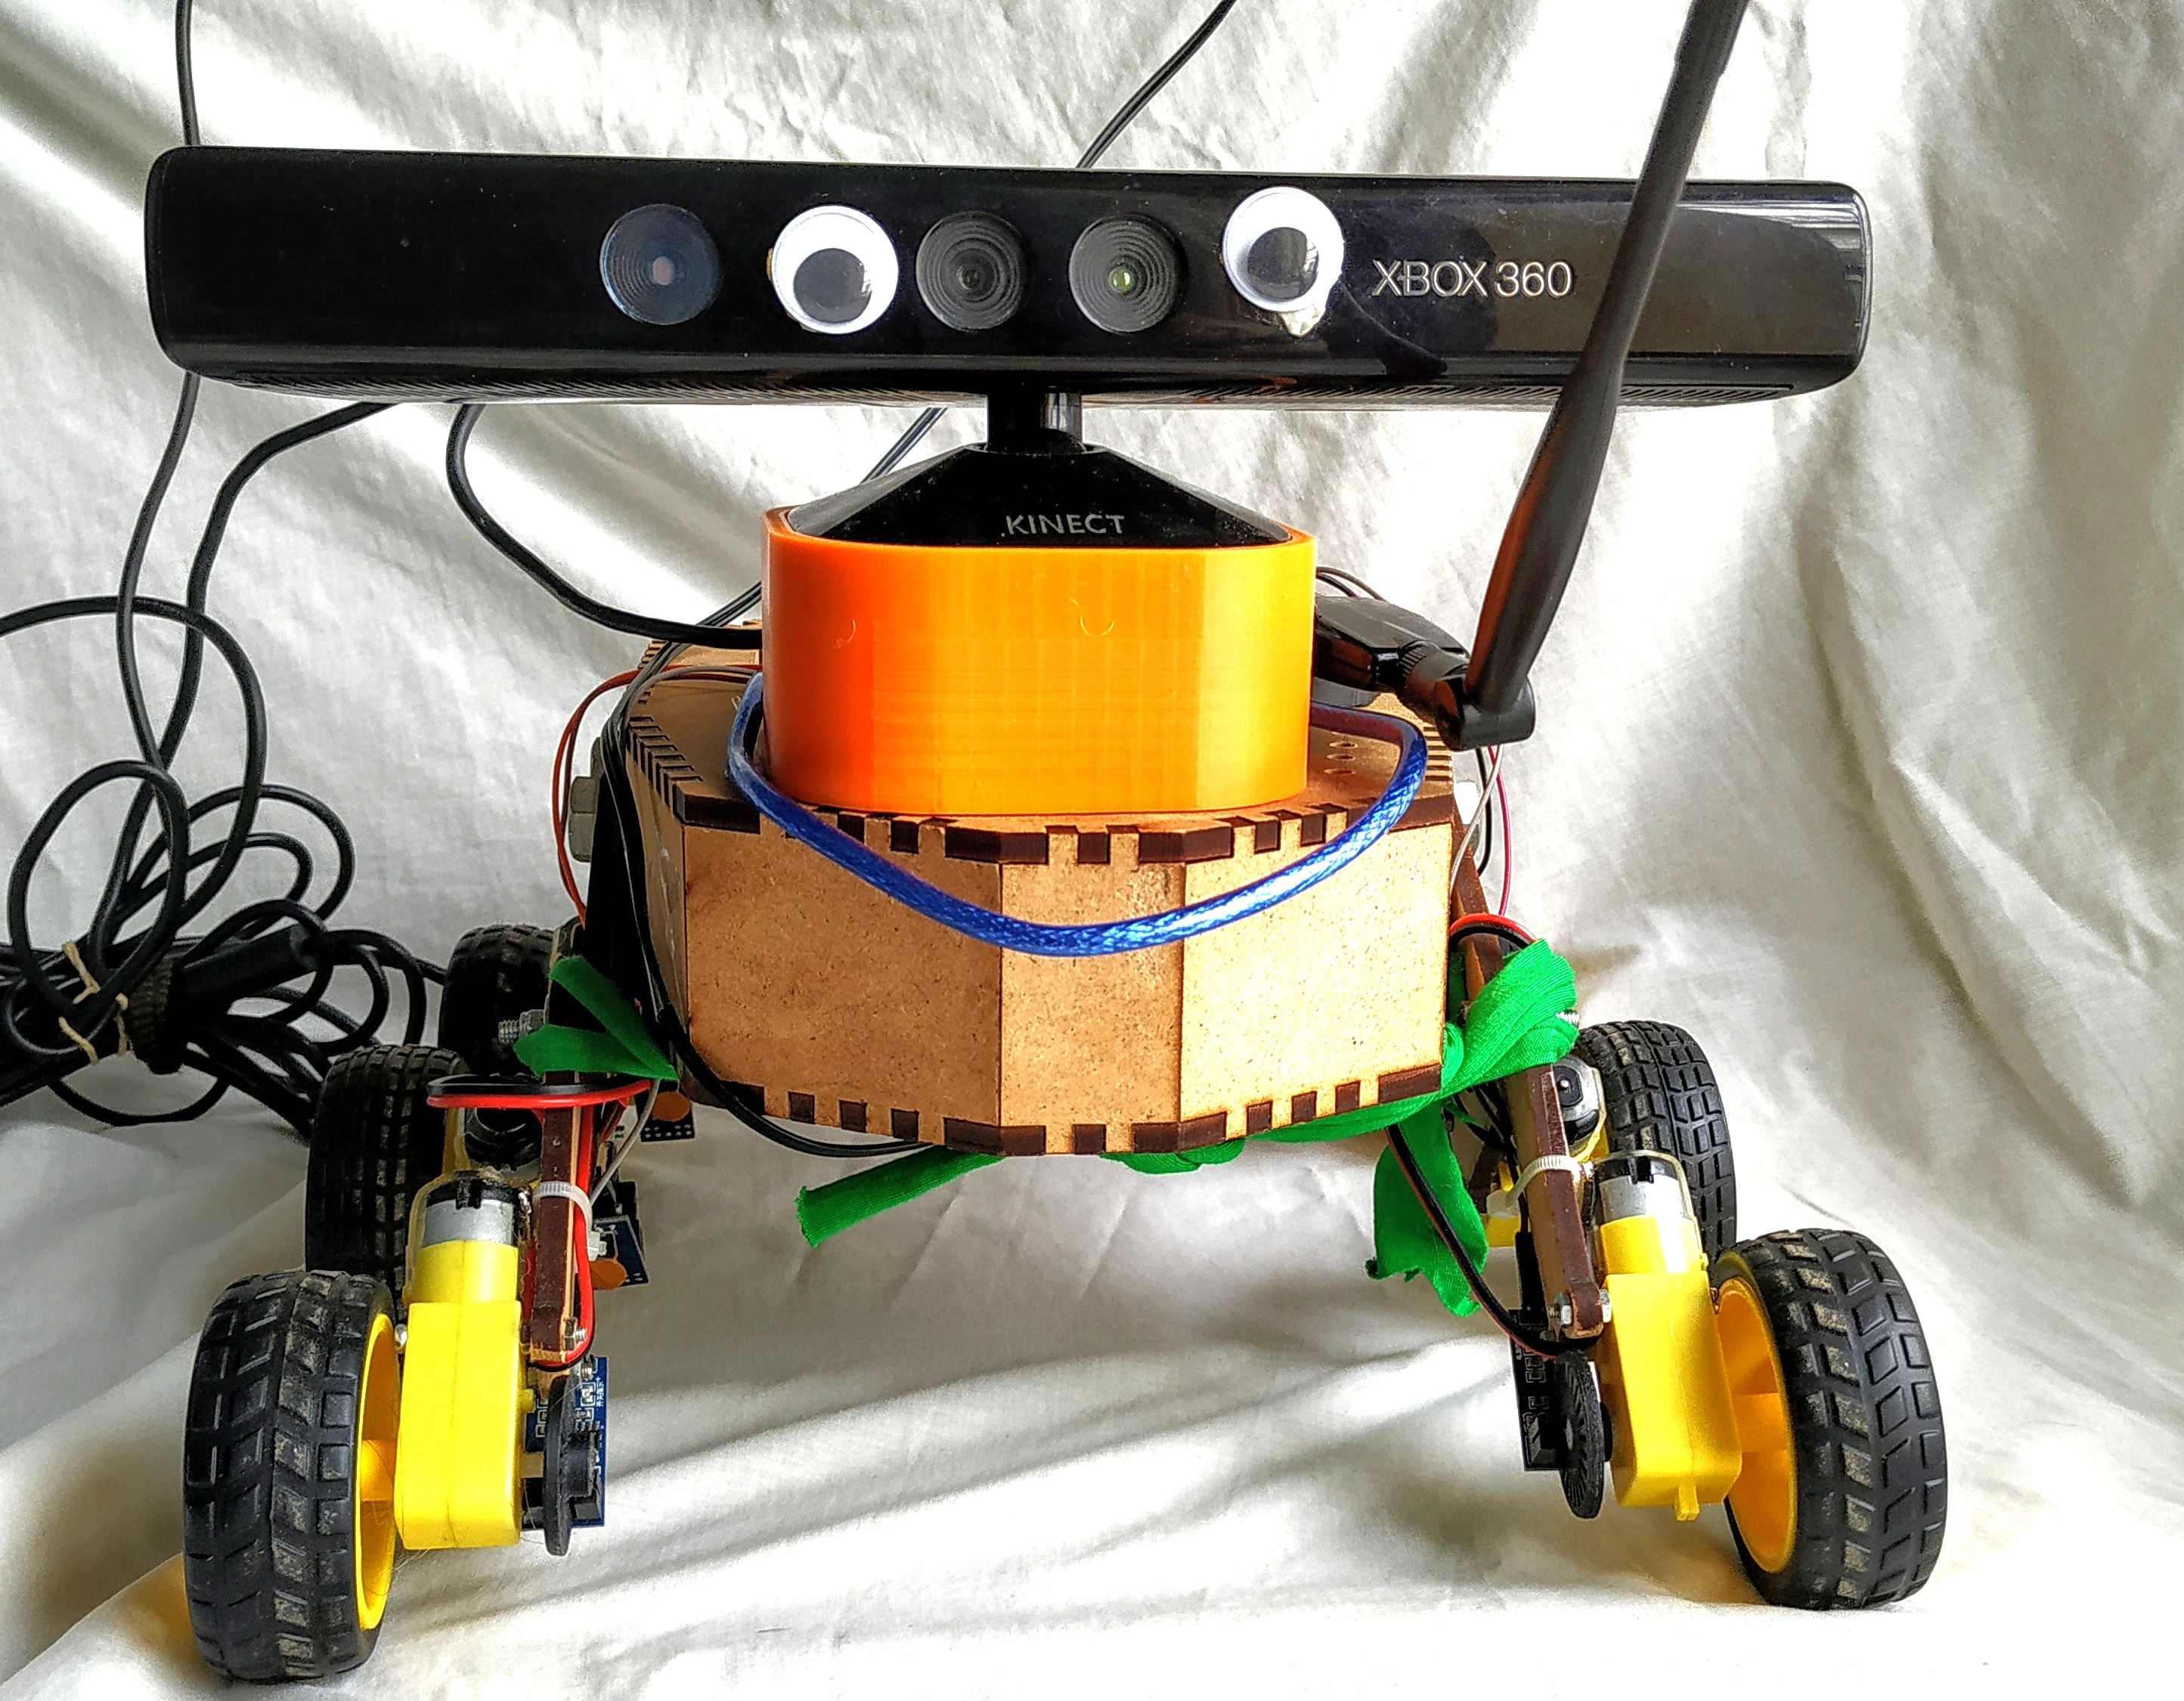
Un análisis en detalle de todo el proyecto, así como de sus resultados se encuentra (en español) aquí. Los recursos bibliográficos disponibles se pueden consultar en docs/.
Se hace uso de la libreria pigpio:(http://abyz.me.uk/rpi/pigpio/download.html)
wget abyz.me.uk/rpi/pigpio/pigpio.tar
tar xf pigpio.tar
cd PIGPIO
make
sudo make installSe hará uso de la librería de Python:
https://github.com/harmsm/PyCmdMessenger
Destacar que se emplará python2.7 y no python3.
Para comunicar la RPi y el PC, es necesario tener instalado el siguiente paquete:
sudo apt install ros-kinetic-multimaster-fkie
sudo apt install ros-kinetic-multimaster-launchSe emplearán tanto los driver necesarios para leer la IMU de la cámara y mover su motor cómo los que permiten que se pueda correr la cámara.
sudo apt install ros-kinetic-freenect-stack<sudo apt-get install libusb-1.0-0 libusb-1.0-0-devcd ~/catkin_ws/src
git clone https://github.com/muhrix/kinect_aux.git -b indigo
cd ~/catkin_ws
catkin_makeSe deberan tener instalados los siguientes paquetes de ros y sus respectivas dependencias:
sudo apt-get install ros-kinetic-rtabmap-ros
sudo apt-get install ros-kinetic-octomap-*Se enlaza directamente al repositorio original. https://github.com/appliedAI-Initiative/orb_slam_2_ros
| Qty | Value | Footprint | References |
|---|---|---|---|
| 6 | Conn_01x02 | Pin_Headers:Pin_Header_Straight_1x02_Pitch2.00mm | J1, J2, J3, J4, J5, J6 |
| 3 | L293D | Housings_DIP:DIP-16_W7.62mm_Socket_LongPads | U1, U2, U3 |
| 1 | Conn_01x03 | Pin_Headers:Pin_Header_Straight_1x03_Pitch2.00mm | J13 |
| 1 | m1 | Connectors_Terminal_Blocks:TerminalBlock_Altech_AK300-2_P5.00mm | J7 |
| 1 | m2 | Connectors_Terminal_Blocks:TerminalBlock_Altech_AK300-2_P5.00mm | J8 |
| 1 | m3 | Connectors_Terminal_Blocks:TerminalBlock_Altech_AK300-2_P5.00mm | J9 |
| 1 | m4 | Connectors_Terminal_Blocks:TerminalBlock_Altech_AK300-2_P5.00mm | J10 |
| 1 | m5 | Connectors_Terminal_Blocks:TerminalBlock_Altech_AK300-2_P5.00mm | J11 |
| 1 | m6 | Connectors_Terminal_Blocks:TerminalBlock_Altech_AK300-2_P5.00mm | J12 |
| 1 | power12v | Connectors_Terminal_Blocks:TerminalBlock_Altech_AK300-2_P5.00mm | J14 |

ExploreEmbedded/8051_DevelopmentBoard
Design files and sample code for 8051 development Ultra Boards

NikodemBartnik/Small-Projects
All of smaller projects (Arduino, PCBs, electronics, code)

geno543/Redropi_highway
the project aims to detect asteroids and meteor movement using high-quality cameras and radar detection methods using an AI model for accurate analysis, and it classifies bodies be in three categories: non-meteor…


harrislab-brown/DropGen
DropGen uses a fluid reservoir and a piezoelectric buzzer to precisely and repeatably dispense small droplets on demand.


It measures 69.6 × 75.7 mm and has 2 copper layers, 1.6 mm thick.
17 parts, built around the L293D. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the mgrova/SLAM_Wheel-E repository on GitHub, at the commit this page was made from: the board is Hardware/motor_driver_mk1/motor_driver.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).