
4 layers90 × 90 mm
Power distribution
menloresearch/asimov-1
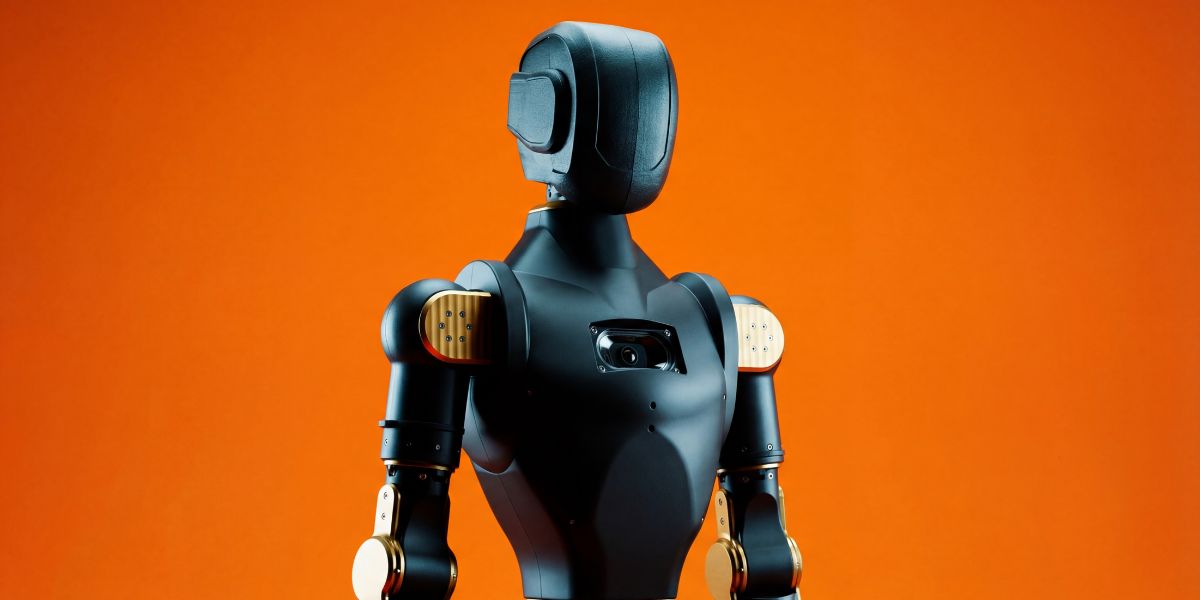
v1 of Asimov, an open-source humanoid robot
25 parts1.4kCERN-OHL-S-2.0

 menloresearch/asimov-11.4k
v1 of Asimov, an open-source humanoid robot
Motion control is an open-source printed circuit board by menloresearch, from the menloresearch/asimov-1 repository on GitHub, published under the CERN-OHL-S-2.0 licence. It is a 4-layer board of 106 × 98 mm with 76 parts on 339 nets, routed with 1,380 tracks and 256 vias.
It is built around the SN65HVD230D, TXB0104PW and ADM7172ACPZ-3.3-R7, with the HR963380AE and TS50810-411-02528 among its other parts. Its parts include 28 capacitors, 22 ICs, 14 resistors, 6 crystals and 3 connectors. It belongs with the robots and motor control boards of this library.


Asimov is an open-source humanoid robot that you can build, train and customize.
Website · Manual · DIY Kit · 3D Model · Discord · X · Forum
Asimov 1 is a 1.2 m, 35 kg biped with 25 actuated degrees of freedom. This repository contains the mechanical CAD, electrical CAD, simulation model, and onboard software to build, simulate, and customize Asimov 1.
| Spec | Value |
|---|---|
| Height | 1.2 m |
| Weight | 35 kg |
| Degrees of Freedom | 25 actuated |
| Legs | 6 DOF x 2 |
| Arms | 5 DOF x 2 (shoulder pitch/roll/yaw, elbow, wrist yaw) |
| Torso | 1 DOF waist yaw, 10 W 4 ohm speaker, 6 DOF IMU |
| Head | 2 DOF neck (neck yaw, neck pitch), stereo microphone array, 2MP monocular camera |
| CAN Bus | 5 @ 1Mbps + 1 @ 500kbps |
| Onboard Compute | Raspberry Pi 5 (media + network) + Radxa CM5 (motion control) |
| Structural Materials | 7075 aluminium, MJF PA12 nylon |
| Activity | Rated Load | Peak Load |
|---|---|---|
| Squat | 5 kg | - |
| Bicep curl | 5 kg each arm | 15 kg each arm |
| Front raise | 5 kg each arm | 15 kg each arm |
| Lateral raise | 6 kg each arm | 18 kg each arm |
[!TIP] Option 1: DIY Kit: Everything you need to build Asimov 1, unassembled. Shipping now for $20,000. Order now →
[!NOTE] Option 2: Self-source: Pull the BOM and fabricate everything yourself. Assembly Manual →
| Category | Included | Not Included |
|---|---|---|
| Hardware | All BOM components (unassembled), power supply & cabling, spare parts | Tools, hands |
| Compute | RPi edge board, motion control board, network board, power distribution board | 4G/5G modules |
| Sensors | Monocular camera, IMUs, mic, speaker, motor joint states | Lidar, 360 cam |
| Docs | Quick start guide, manual, DIY build videos | — |
Pre-order the Asimov 1 DIY Kit →
Start with the repo-local fabrication manifest for the CAD-derived part inventory, then cross-reference the BOM and assembly manual for procurement details, sourcing, and fabrication notes.
The shoe accessory is supplied as a single ASV1_Shoes.STL. The shoes are symmetric and the same geometry fits either foot: print two identical copies in TPU 95A using FDM, one per foot.
The dummy hands are supplied as ASV1_DUMMY_HANDS.3mf, a Bambu Studio project with embedded printing settings. See the mechanical fabrication guide for the part-naming chart and material/process classes, and the stool accessory for its CAD, BOM, and fabrication specifications.
The fabrication manifest inventories STEP and STL files under mechanical/ASV1/*/FABRICATION. Accessories have their own documentation under mechanical/accessories. Regenerate the manifest after changing the robot fabrication files, then verify it:
python3 scripts/generate_fabrication_manifest.py
python3 scripts/generate_fabrication_manifest.py --check| Status | Item |
|---|---|
| ✅ | Mechanical CAD — 7 subassemblies |
| ✅ | MuJoCo simulation model |
| ✅ | Electrical wiring harness |
| ✅ | Electrical schematics & PCB files |
| 🔜 | Asimov Edge |
| 🔜 | Locomotion policy |
| Qty | Value | Footprint | References |
|---|---|---|---|
| 12 | 100n | Capacitor_SMD:C_0402_1005Metric | C201, C202, C204, C205, C501, C502, C503, C504, C505, C506, C507, C508 |
| 12 | 20p | Capacitor_SMD:C_0603_1608Metric | C601, C602, C603, C604, C605, C606, C607, C608, C609, C610, C611, C612 |
| 6 | 120 | Resistor_SMD:R_0402_1005Metric | R601, R602, R603, R604, R605, R606 |
| 6 | 40M | Crystal:Crystal_SMD_3225-4Pin_3.2x2.5mm | Y601, Y602, Y603, Y604, Y605, Y606 |
| 6 | MCP2518FD-xQBB | Package_SO:SOIC-14_3.9x8.7mm_P1.27mm | U601, U602, U603, U607, U608, U609 |
| 6 | SN65HVD230 | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U604, U605, U606, U610, U611, U612 |
| 4 | 10k | Resistor_SMD:R_0402_1005Metric | R501, R502, R503, R504 |
| 4 | TXB0104PW | Package_SO:TSSOP-14_4.4x5mm_P0.65mm | U501, U502, U503, U504 |
| 2 | 4.7u | Capacitor_SMD:C_0402_1005Metric | C101, C103 |
| 2 | 5.1k | Resistor_SMD:R_0402_1005Metric | R301, R302 |
| 1 | 100 | Resistor_SMD:R_0402_1005Metric | R202 |
| 1 | 1M | Resistor_SMD:R_2010_5025Metric | R201 |
| 1 | 1n | Capacitor_SMD:C_0402_1005Metric | C102 |
| 1 | 1n | Capacitor_SMD:C_1206_3216Metric | C203 |
| 1 | ADM7172ACPZ-3.3-R7 | lcsc_lib:DFN-8_L3.0-W3.0-P0.50-BL-EP | U101 |
| 1 | ETH | lcsc_lib:RJ45-SMD_HR963380AE | U202 |
| 1 | HEADER_BOTTOM | Connector_PinHeader_2.54mm:PinHeader_2x08_P2.54mm_Vertical | J102 |
| 1 | HEADER_LEFT | Connector_PinHeader_2.54mm:PinHeader_2x08_P2.54mm_Vertical | J101 |
| 1 | HEADER_RIGHT | Connector_PinHeader_2.54mm:PinHeader_2x08_P2.54mm_Vertical | J103 |
| 1 | Hirose DF40C-100DS-0.4V | radxa:radxa_cm5_2 | U301 |
| 1 | Hirose DF40C-100DS-0.4V | radxa:radxa_cm5_3 | U401 |
| 1 | Hirose DF40C-100DS-0.4V | radxa:radxa_cm5_1 | U201 |
| 1 | LOGO | LOGO | G*** |
| 1 | LSM6DSVTR | lcsc_lib:LGA-14_L3.0-W2.5-P0.50-TL | U203 |
| 1 | TS50810-411-02528 | lcsc_lib:SW-SMD_L6.2-W3.7-LS8.0 | SW201 |
| 1 | TYPE-C 16PIN 2MD | lcsc_lib:USB-C-SMD_TYPE-C-16PIN-2MD-073 | USB301 |
menloresearch/asimov-1
v1 of Asimov, an open-source humanoid robot


clawdsolana/OpenClawd
OpenClawd is a Solana-native financial AI agent stack.

andykarpov/karabas-pro
FPGA based retrocomputer with FDD and HDD controllers


NarodniySputnik/Gladiolus-1
Gladiolus-1 - автономный модуль для приема и передачи изображений в формате SSTV (Slow Scan TeleVision) на малом космическом аппарате (МКА) формата CubeSat

SushiBits/Gowinduino
Arduino-compatible evaluation board with Gowin GW1NSR-4C FPGA

Millisman/Quectel-BG95-LPWA-Module
Quectel BG95 LPWA Module board with integrated GPS & GSM
It measures 106 × 98 mm and has 4 copper layers, 1.63 mm thick.
76 parts, built around the SN65HVD230D, TXB0104PW, ADM7172ACPZ-3.3-R7 and HR963380AE. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the menloresearch/asimov-1 repository on GitHub, at the commit this page was made from: the board is electrical/rpu/motion_control/board/board.kicad_pcb and its schematic electrical/media/hat/board/board.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the CERN-OHL-S-2.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).