6 layers98 × 30 mm
Kvio core
korken89/kvio_core
KVision core is an FPGA based Visual Inertial Odometry accelerator.
287 parts1

 korken89/ovio_core30
Work in progress. PCB have arrived for v1.0 of the board and bring-up has started.
Ovio core is an open-source printed circuit board by korken89, from the korken89/ovio_core repository on GitHub. It is a 6-layer board of 98 × 27.5 mm with 196 parts on 326 nets, routed with 5,830 tracks and 552 vias.
It is built around the TLV62569DRL, FT600Q-B-T and W25Q128JVPIQ, with the IP4254CZ8-4-TTL,13, ISM330DHCX and MT41J128M16JT-125:K among its other parts. Its parts include 94 capacitors, 52 resistors, 14 ICs, 6 diodes and 4 inductors. It belongs with the FPGA and CPLD boards of this library.


Work in progress. PCB have arrived for v1.0 of the board and bring-up has started.
Images from the assembly and results here: https://twitter.com/korken89/status/1341126909485342721
Aim: A "low cost" Visual Inertial Odometry accelerator.
A project to try out different vision processing pipelines, for Visual Inertial Odometry (VIO), on the ECP5 FPGA. As far as I know, the open hardware landscape of VIO cameras is slim to non-existent. Especially for systems which perform a majority of the pre-processing in the camera.
Things such as image convolutions, FAST corners, multi-scale images, non-maximum suppression, image gradients, etc, are extremely well suited for FPGA implementation.
Why do it on a PC? Let it run the actual Kalman Filter / MHE / nonlinear optimizer, which the FPGA is not well suited for.
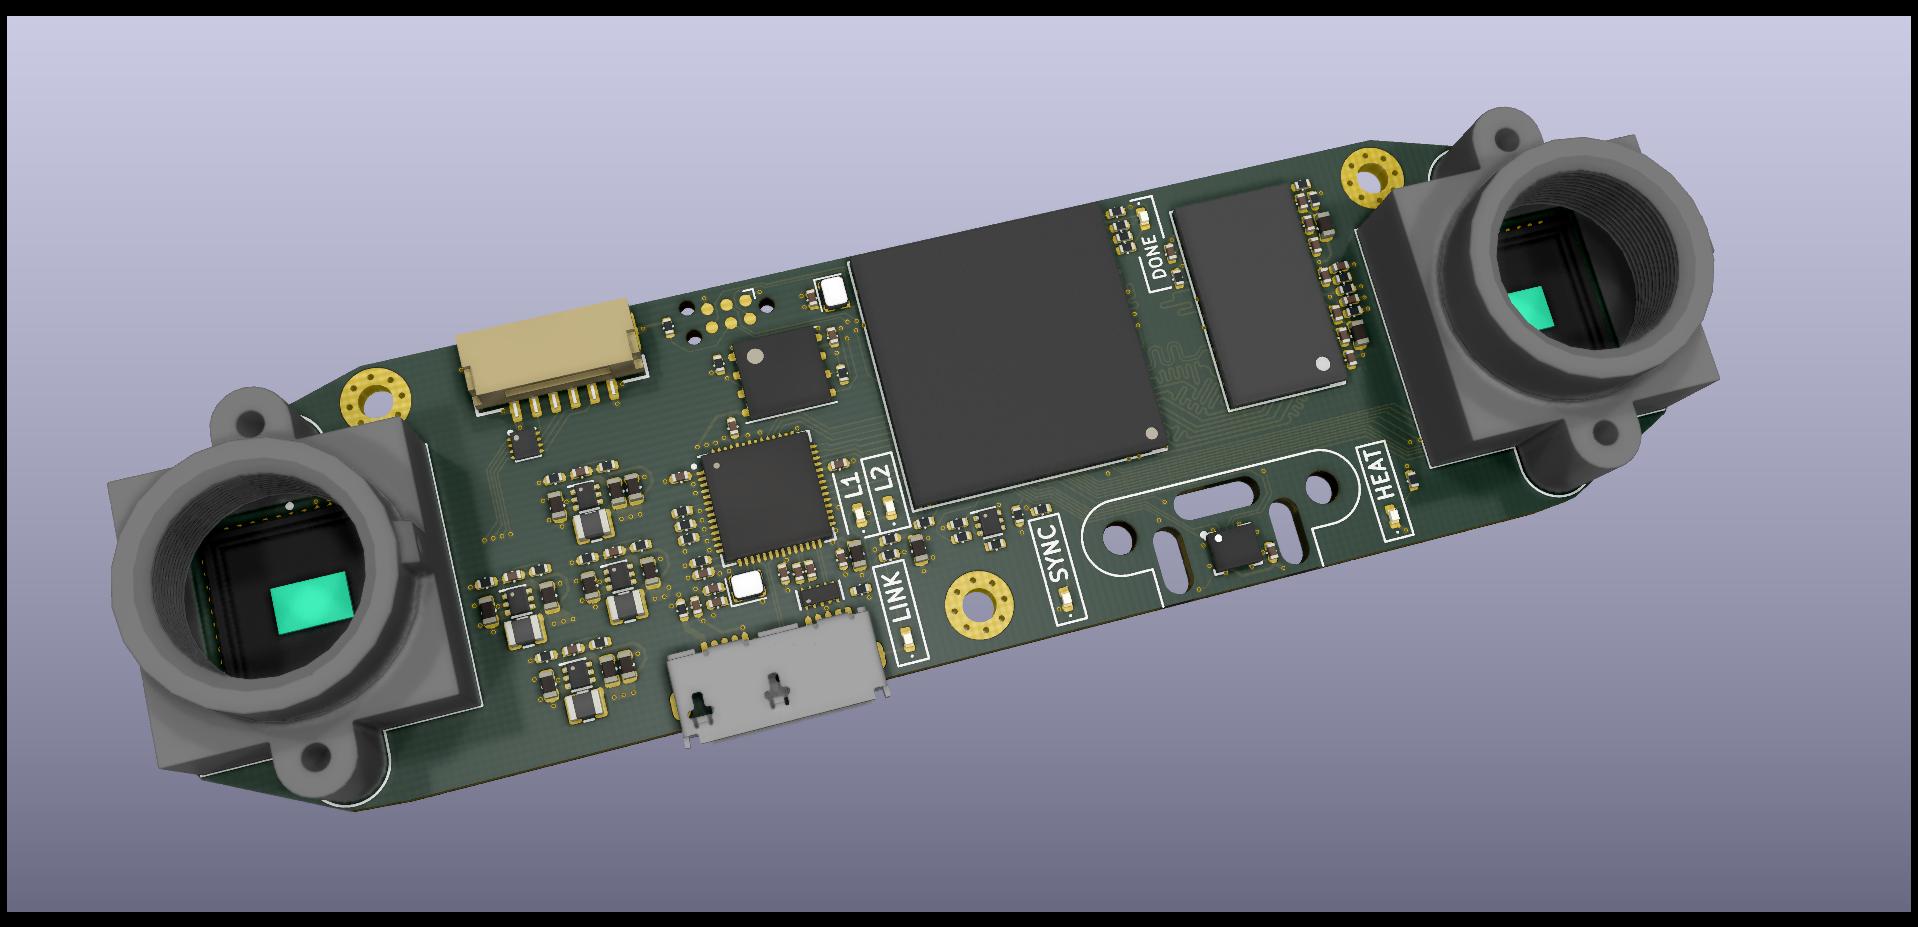
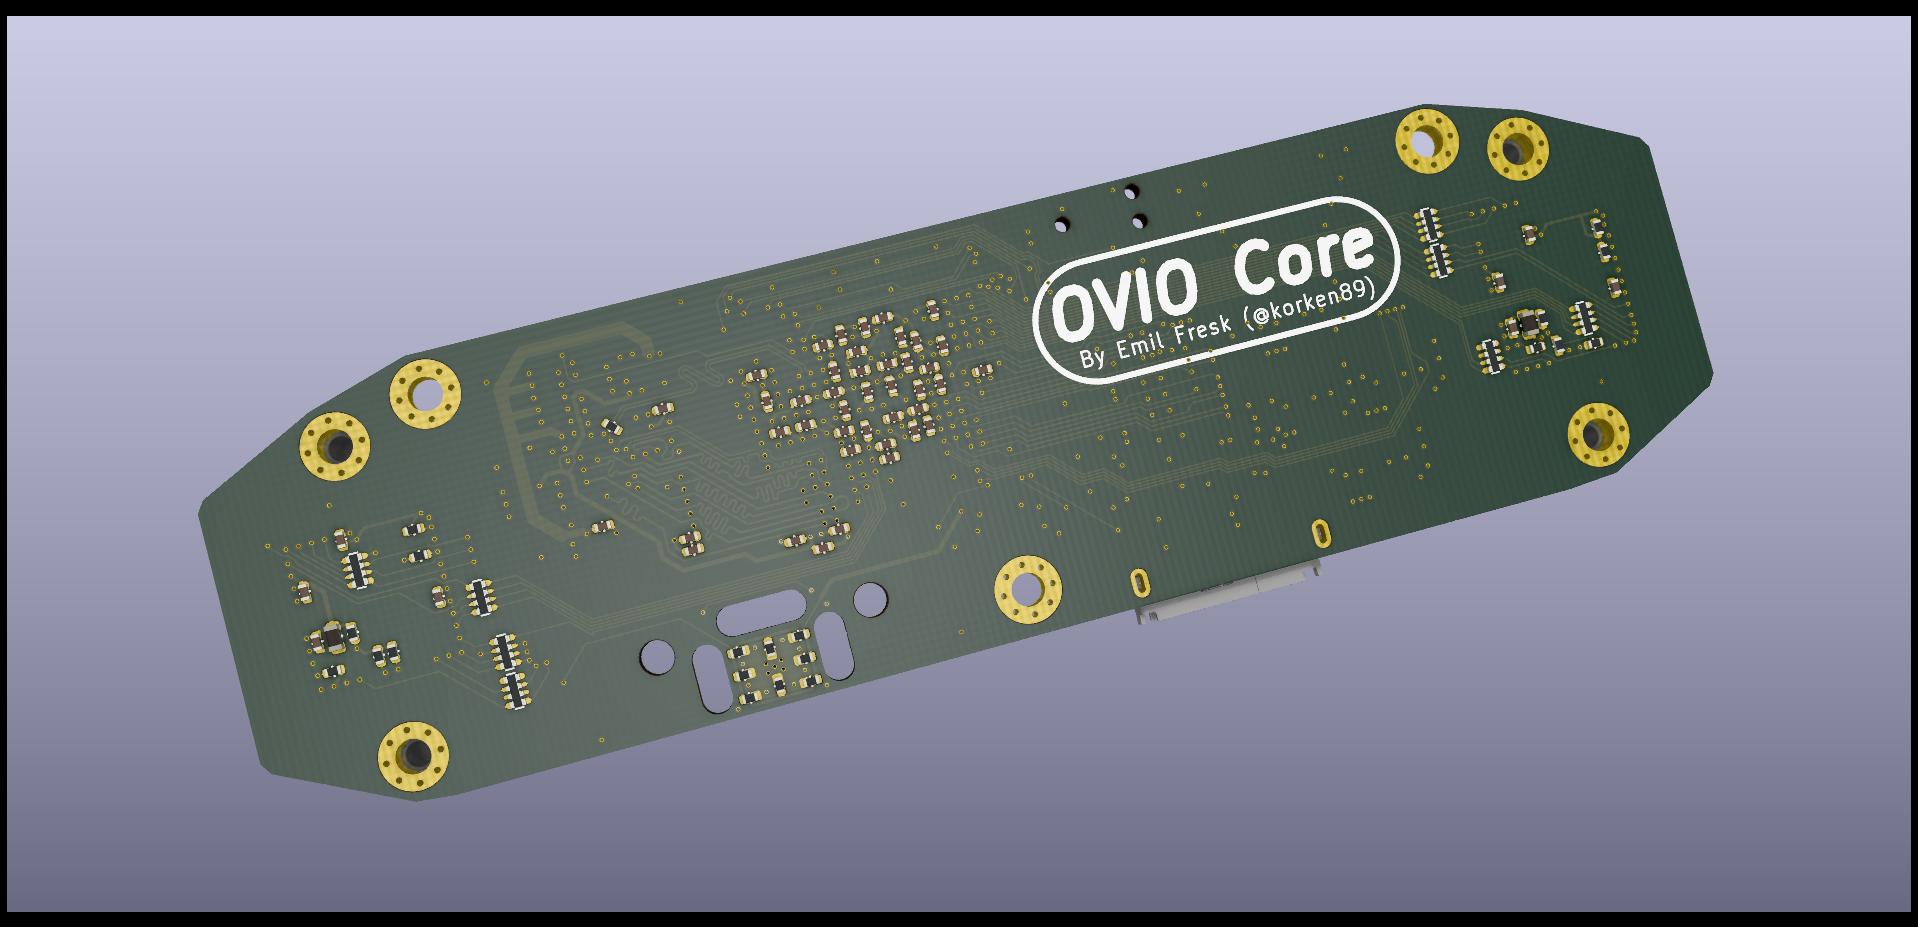
Previous projects has been made on Xilinx FPGAs, however the high cost of their FPGAs never allowed for trying to distribute a camera. Now it is expected that the hardware cost for this system should be sub 100 Euros, even with the largest ECP5 FPGA.
If there is interest for acquiring a camera, contact me (via any medium) and we'll figure something out.
This hardware is open source.
TODO: Find a proper license
| Qty | Value | Footprint | References |
|---|---|---|---|
| 47 | 0.1u | passive:C_0402 | C101, C103, C210, C211, C214, C215, C218, C301, C303, C403, C404, C405, C406, C407, C408, C409 +31 |
| 25 | 10n | passive:C_0402 | C102, C104, C212, C213, C216, C217, C219, C302, C413, C414, C418, C602, C604, C606, C609, C610 +9 |
| 16 | 1k | passive:R_0402 | R101, R102, R103, R104, R301, R302, R303, R304, R306, R407, R408, R409, R410, R513, R601, R602 |
| 11 | 10k | passive:R_0402 | R305, R307, R403, R404, R502, R503, R508, R604, R701, R702, R703 |
| 9 | 180 | passive:R_0402 | R501, R504, R505, R506, R507, R509, R510, R511, R512 |
| 8 | 22 | passive:R_Array_Convex_4x0402 | RN401, RN402, RN403, RN404, RN406, RN407, RN408, RN409 |
| 8 | 22u | passive:C_0603 | C205, C206, C207, C208, C209, C220, C613, C614 |
| 8 | 4.7u | passive:C_0603 | C201, C202, C203, C204, C401, C402, C501, C716 |
| 6 | 10p | passive:C_0402 | C221, C222, C223, C224, C710, C711 |
| 6 | Ferrite_Bead_Small | passive:R_0402 | FB401, FB402, FB501, FB601, FB602, FB701 |
| 6 | LED_Small | LED_SMD:LED_0402_1005Metric | D101, D102, D103, D104, D301, D501 |
| 5 | 1.6k | passive:R_0402 | R401, R402, R405, R406, R704 |
| 4 | 2.2u | inductor:L_0806_2016Metric | L201, L202, L203, L204 |
| 4 | TLV62569DRL | sot:SOT-563 | U201, U202, U203, U204 |
| 3 | MountingHole_Pad | MountingHole:MountingHole_2.2mm_M2_Pad_Via | H101, H102, H103 |
| 2 | 100k | passive:R_0402 | R201, R204 |
| 2 | 82k | passive:R_0402 | R206, R208 |
| 2 | MT9V034 | cameras:MT9V034 | U401, U402 |
| 2 | MountingHole | MountingHole:MountingHole_2.2mm_M2 | H501, H502 |
| 2 | lens_holder | lensholders:m12_20mm | LH401, LH402 |
| 1 | 0 | passive:R_0402 | R308 |
| 1 | 100 | passive:R_0402 | R603 |
| 1 | 120k | passive:R_0402 | R202 |
| 1 | 150k | passive:R_0402 | R203 |
| 1 | 240 | passive:R_0402 | R605 |
| 1 | 25 MHz | crystals:Crystal_4Pin_2.0x1.6mm | U403 |
| 1 | 261k | passive:R_0402 | R205 |
| 1 | 30 MHz | crystals:Crystal_4Pin_2.0x1.6mm | Y701 |
| 1 | 365k | passive:R_0402 | R207 |
| 1 | Conn_01x06 | connectors:SM06B-GHS-TB | J101 |
| 1 | ECP5U_85_CABGA381 | bga:caBGA_381_17x17 | U102 |
| 1 | FT600Q | qfn:QFN-56-1EP_7x7mm_P0.4mm_EP5.7x5.7mm_FT600 | U701 |
| 1 | IP4254CZ8-4-TTL | dfn:UDFN-8-1EP_1.7x1.35mm_P0.4mm_EP0.4x1.2mm | U101 |
| 1 | ISM330DHC | lga:LGA-14-2.5x3 | U501 |
| 1 | MT41J128M16JT-125:K | bga:BGA-96_8.0x14.0mm_DDR16 | U601 |
| 1 | NTZD3155C | sot:SOT-563 | Q501 |
| 1 | PUSB3FR4Z | dfn:DFN-10-1.0x2.5mm_P0.5mm | U702 |
| 1 | TC2050 | Connector:Tag-Connect_TC2050-IDC-NL_2x05_P1.27mm_Vertical | J301 |
| 1 | USB3_B_Micro | usb:AMPHENOL-GSB343K33HR | J701 |
| 1 | W25Q128JVP | Package_SON:WSON-8-1EP_6x5mm_P1.27mm_EP3.4x4.3mm | U302 |
korken89/kvio_core
KVision core is an FPGA based Visual Inertial Odometry accelerator.


kbeckmann/Kilsyth
Errata: - C9 is not a GPIO on ECP5 F12 and some other variants. To get the LED working put a jumper on pin 31 and 33 on the Wide connector. - FTCLK is not routed to a clock pin.


It measures 98 × 27.5 mm and has 6 copper layers, 1.6 mm thick.
196 parts, built around the TLV62569DRL, FT600Q-B-T, W25Q128JVPIQ and IP4254CZ8-4-TTL,13. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the korken89/ovio_core repository on GitHub, at the commit this page was made from: the board is ovio_core.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask korken89 before reusing the design.