2 layers70 × 54.5 mm
ErgoWarrior Testbed v0
kinpro1024/ErgoWarrior
A completely open source Ergonomic Hitbox-Style Leverless Fighting game controller.
13 parts18MIT

 kinpro1024/ErgoWarrior18
A completely open source Ergonomic Hitbox-Style Leverless Fighting game controller.
ErgoWarrior Final is an open-source printed circuit board by kinpro1024, from the kinpro1024/ErgoWarrior repository on GitHub, published under the MIT licence. It is a 2-layer board of 76 × 57.5 mm with 26 parts on 33 nets, routed with 104 tracks and 13 vias.
Its parts include 2 ICs and 2 switches. It belongs with the RP2040 boards of this library.
ErgoWarrior is a completely open-source, ergonomic hitbox-style leverless controller. It was born out of a complete lack of contoured open-source ergonomic hitbox designs.
To the best of my knowledge, this is the first open-source Contoured Ergonomic Hitbox on a public platform.
I had the Handle Fail and Break in my flight luggage as it was being thrown around. ErgoWarrior was designed to be robust, and this result was not good enough. The overhaul will also address the inability to completely remove cables once assembled, enhancing repairability.
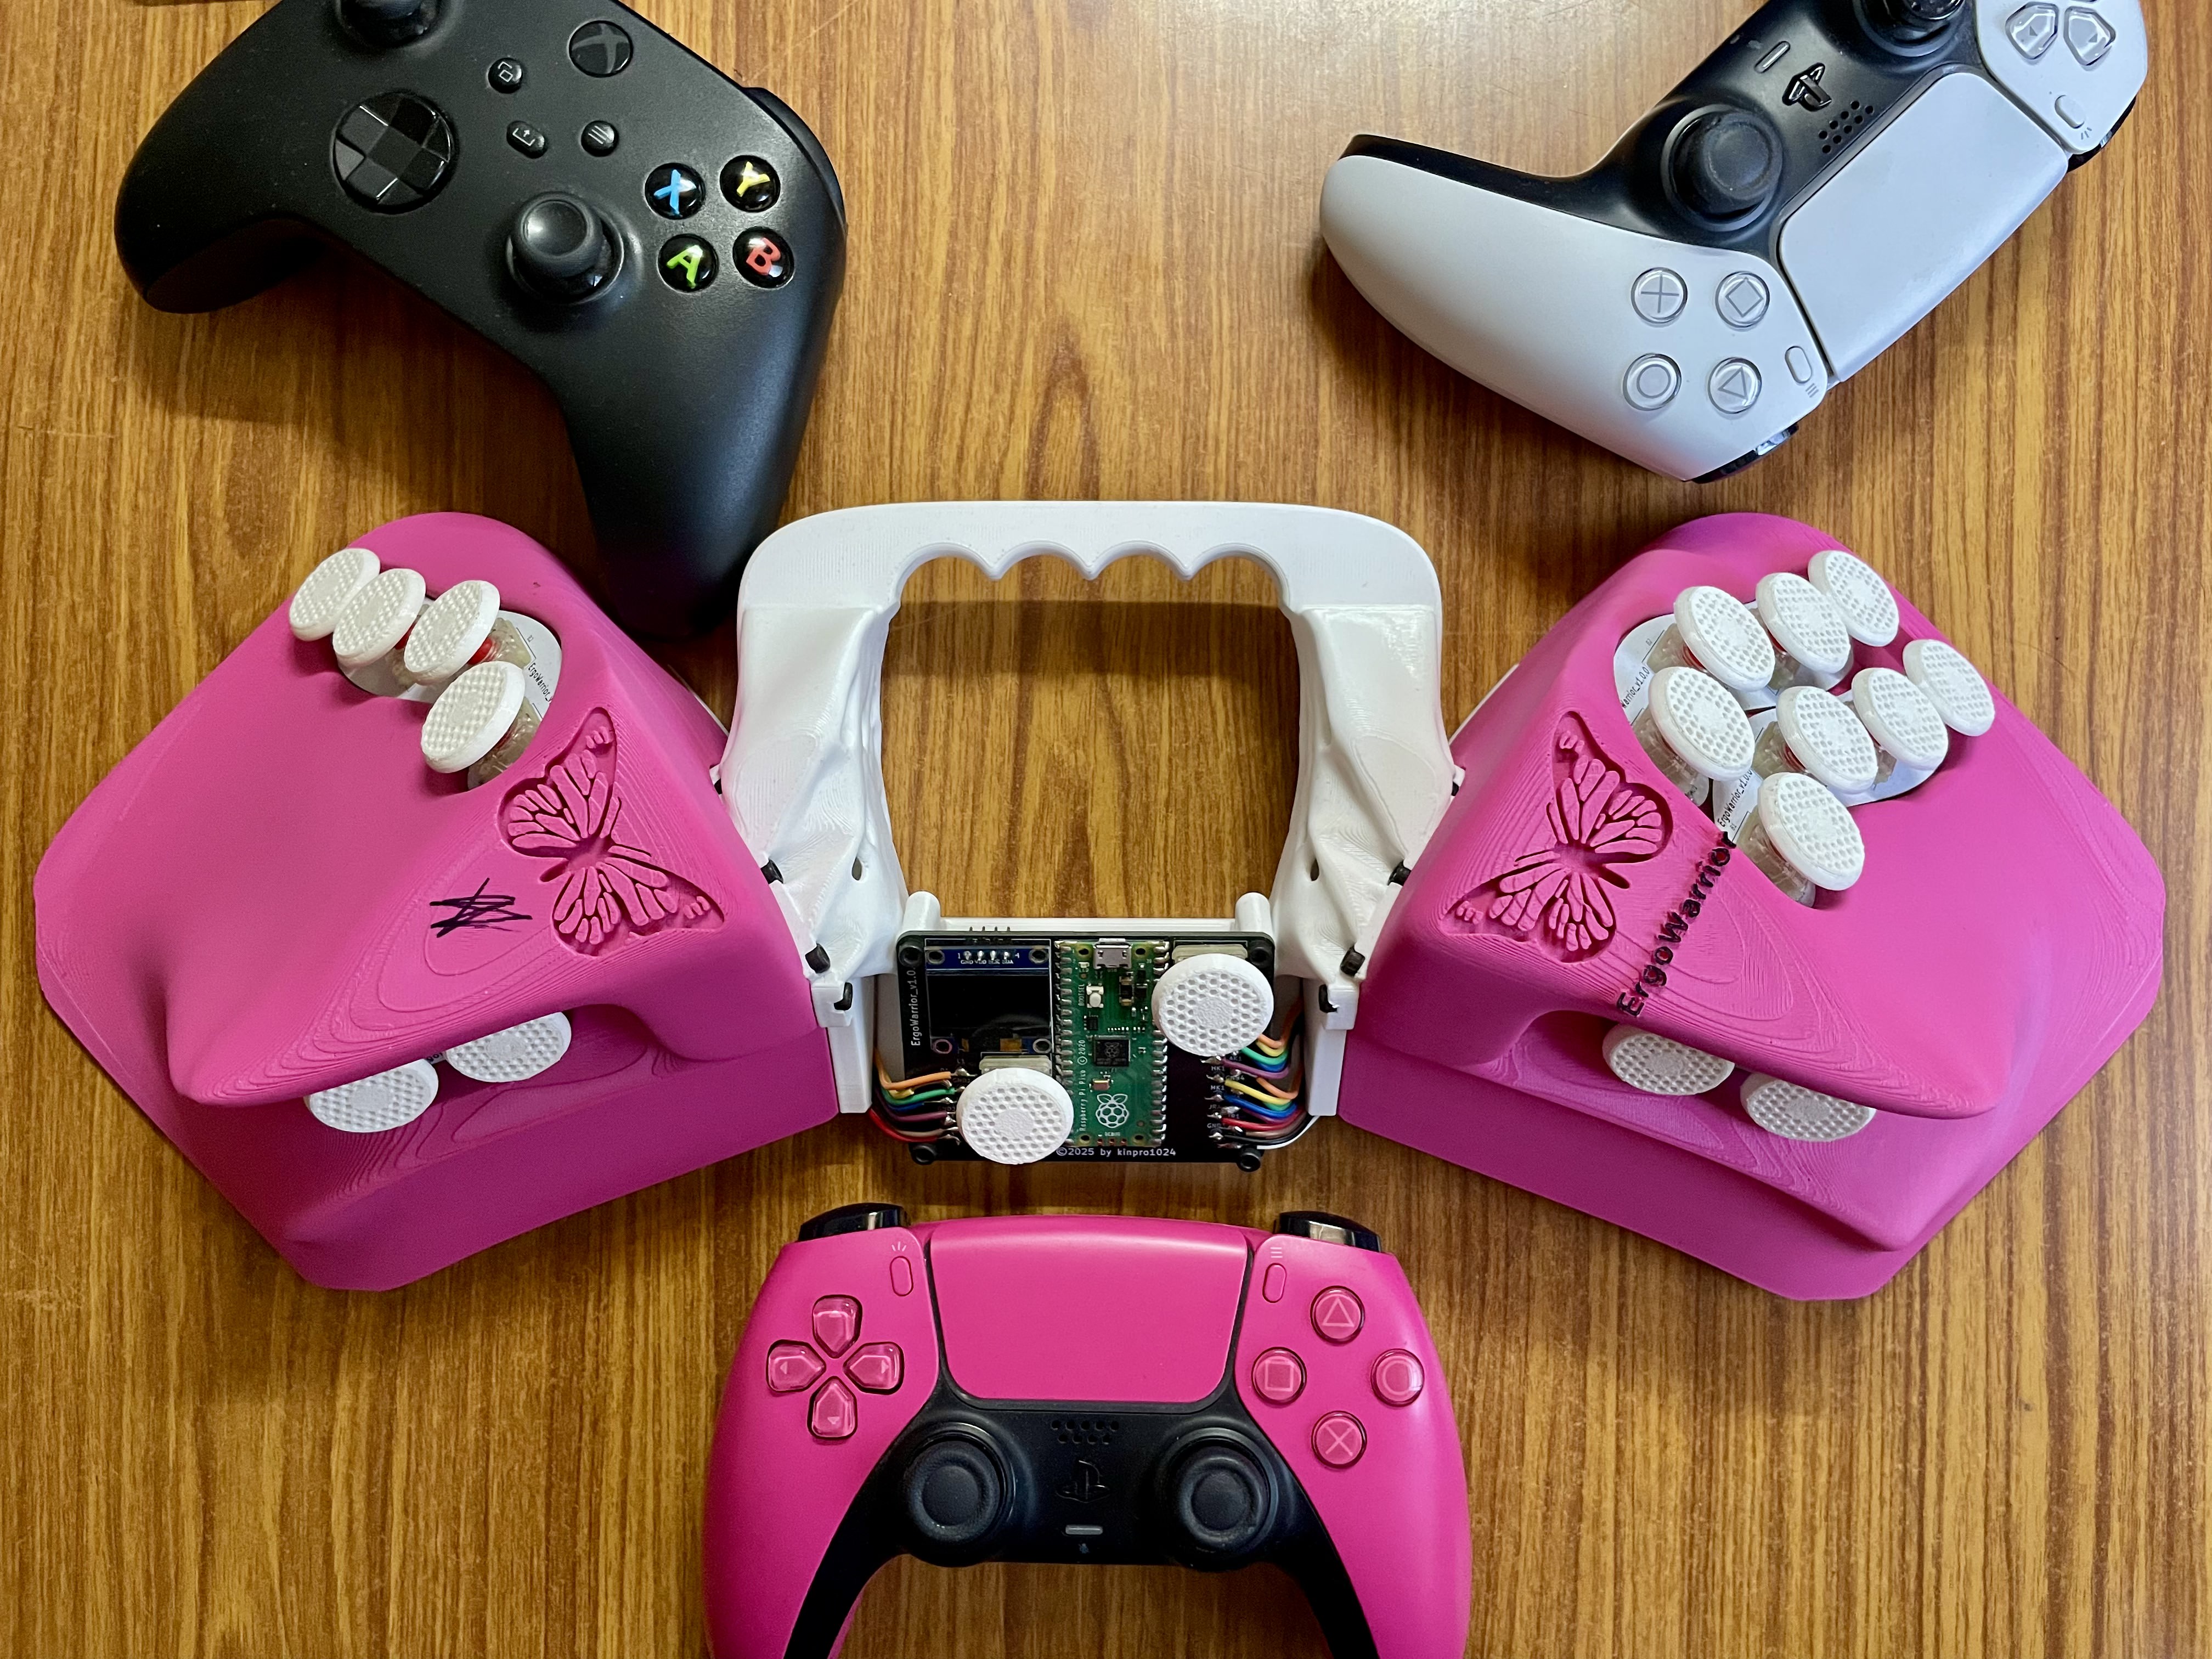 ErgoWarrior v1.1.0 Mechanical Design.
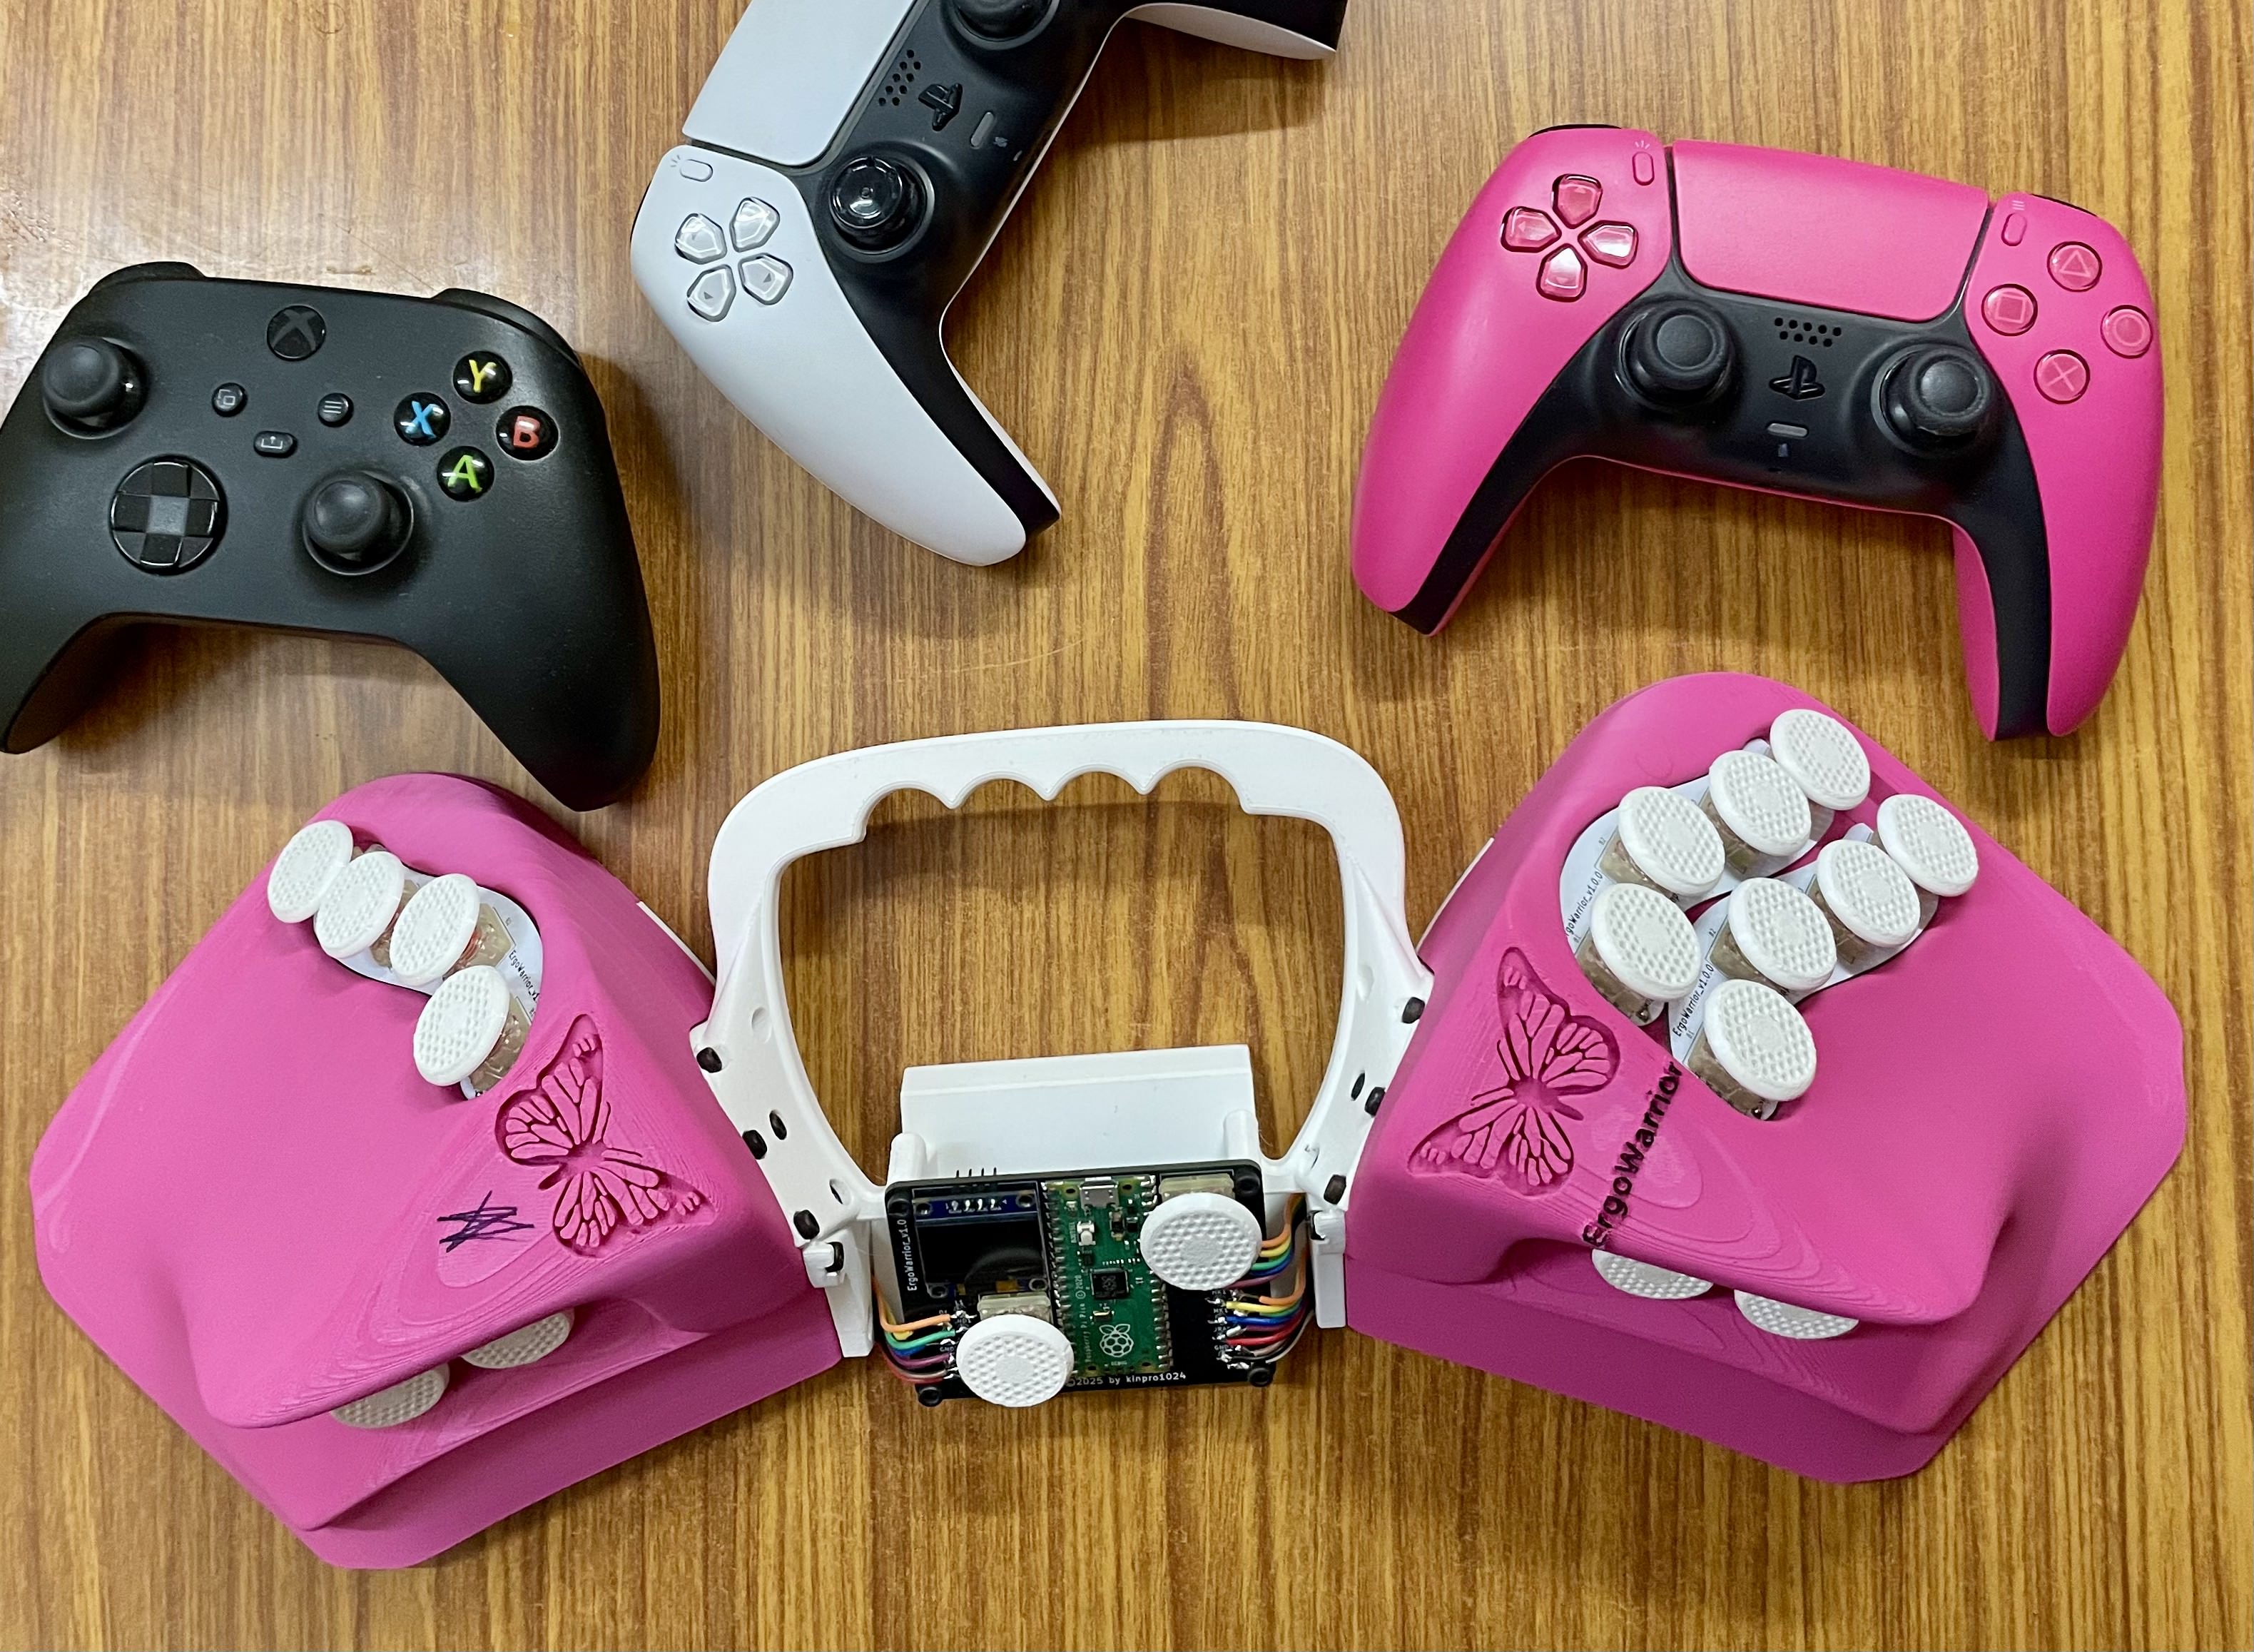 ErgoWarrior v1.0.0 Mechanical Design.
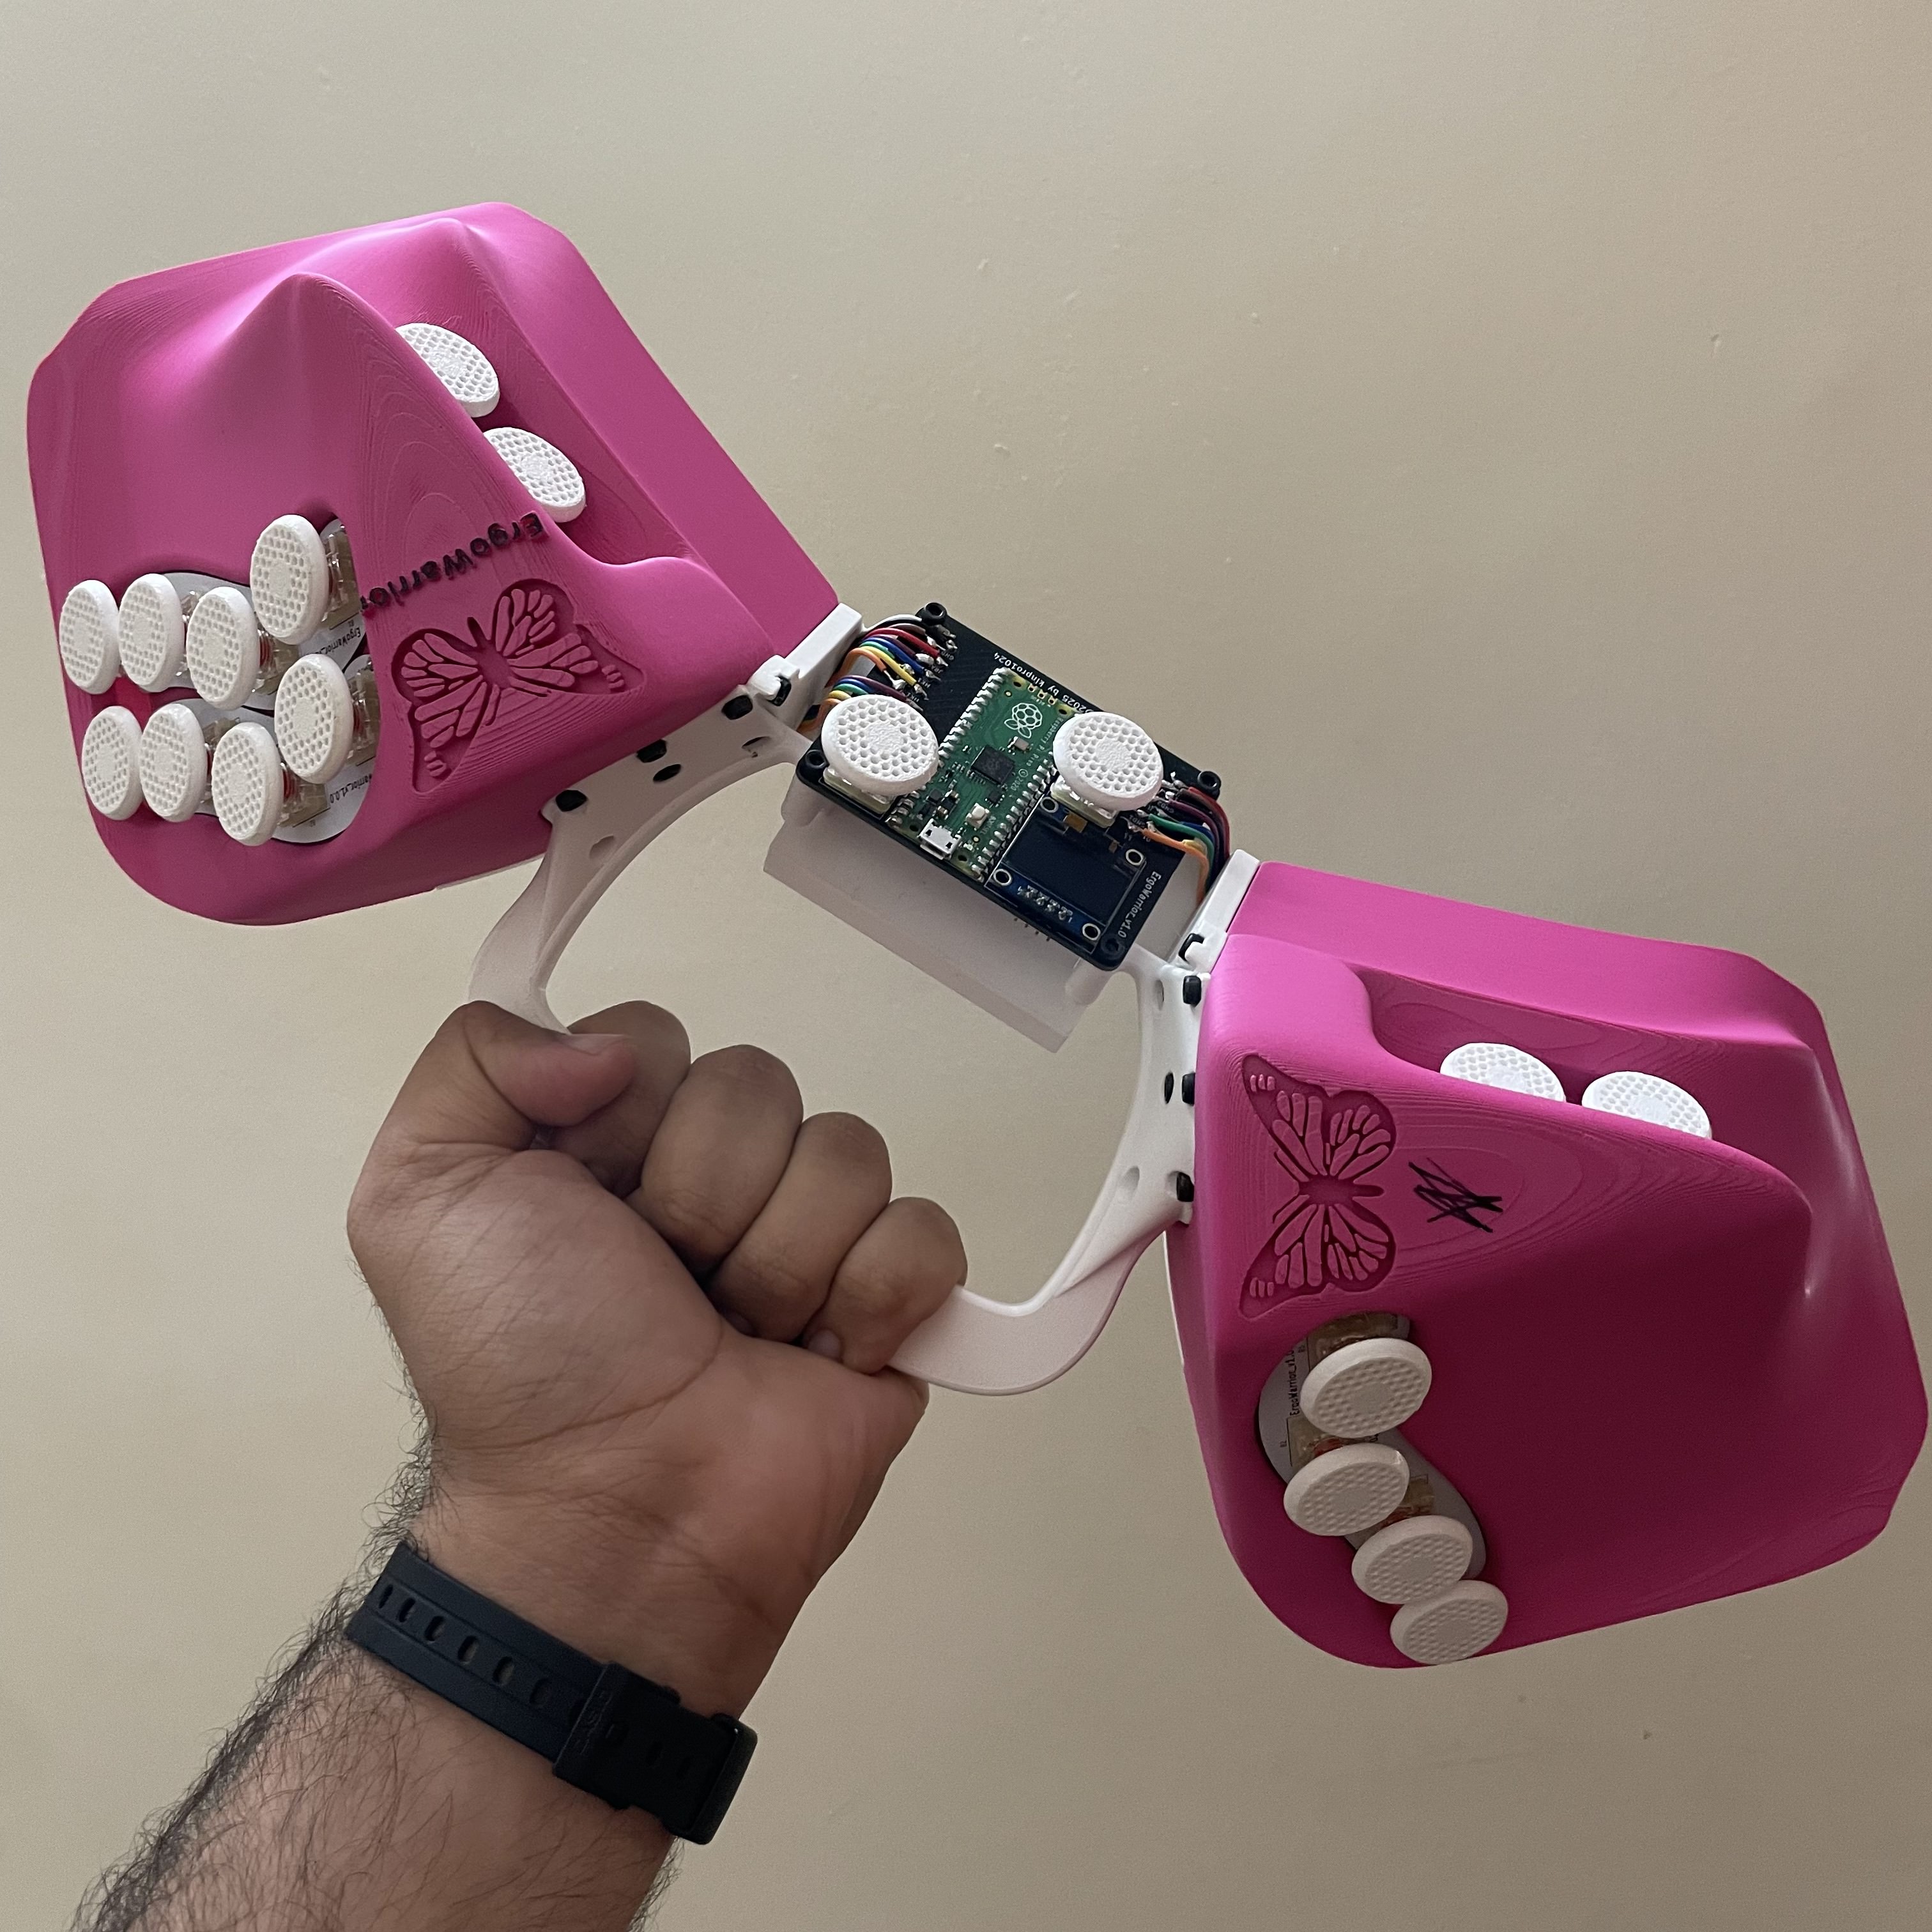 ErgoWarrior v1.0.0 has a robust handle. (It did not, that has been fixed.)
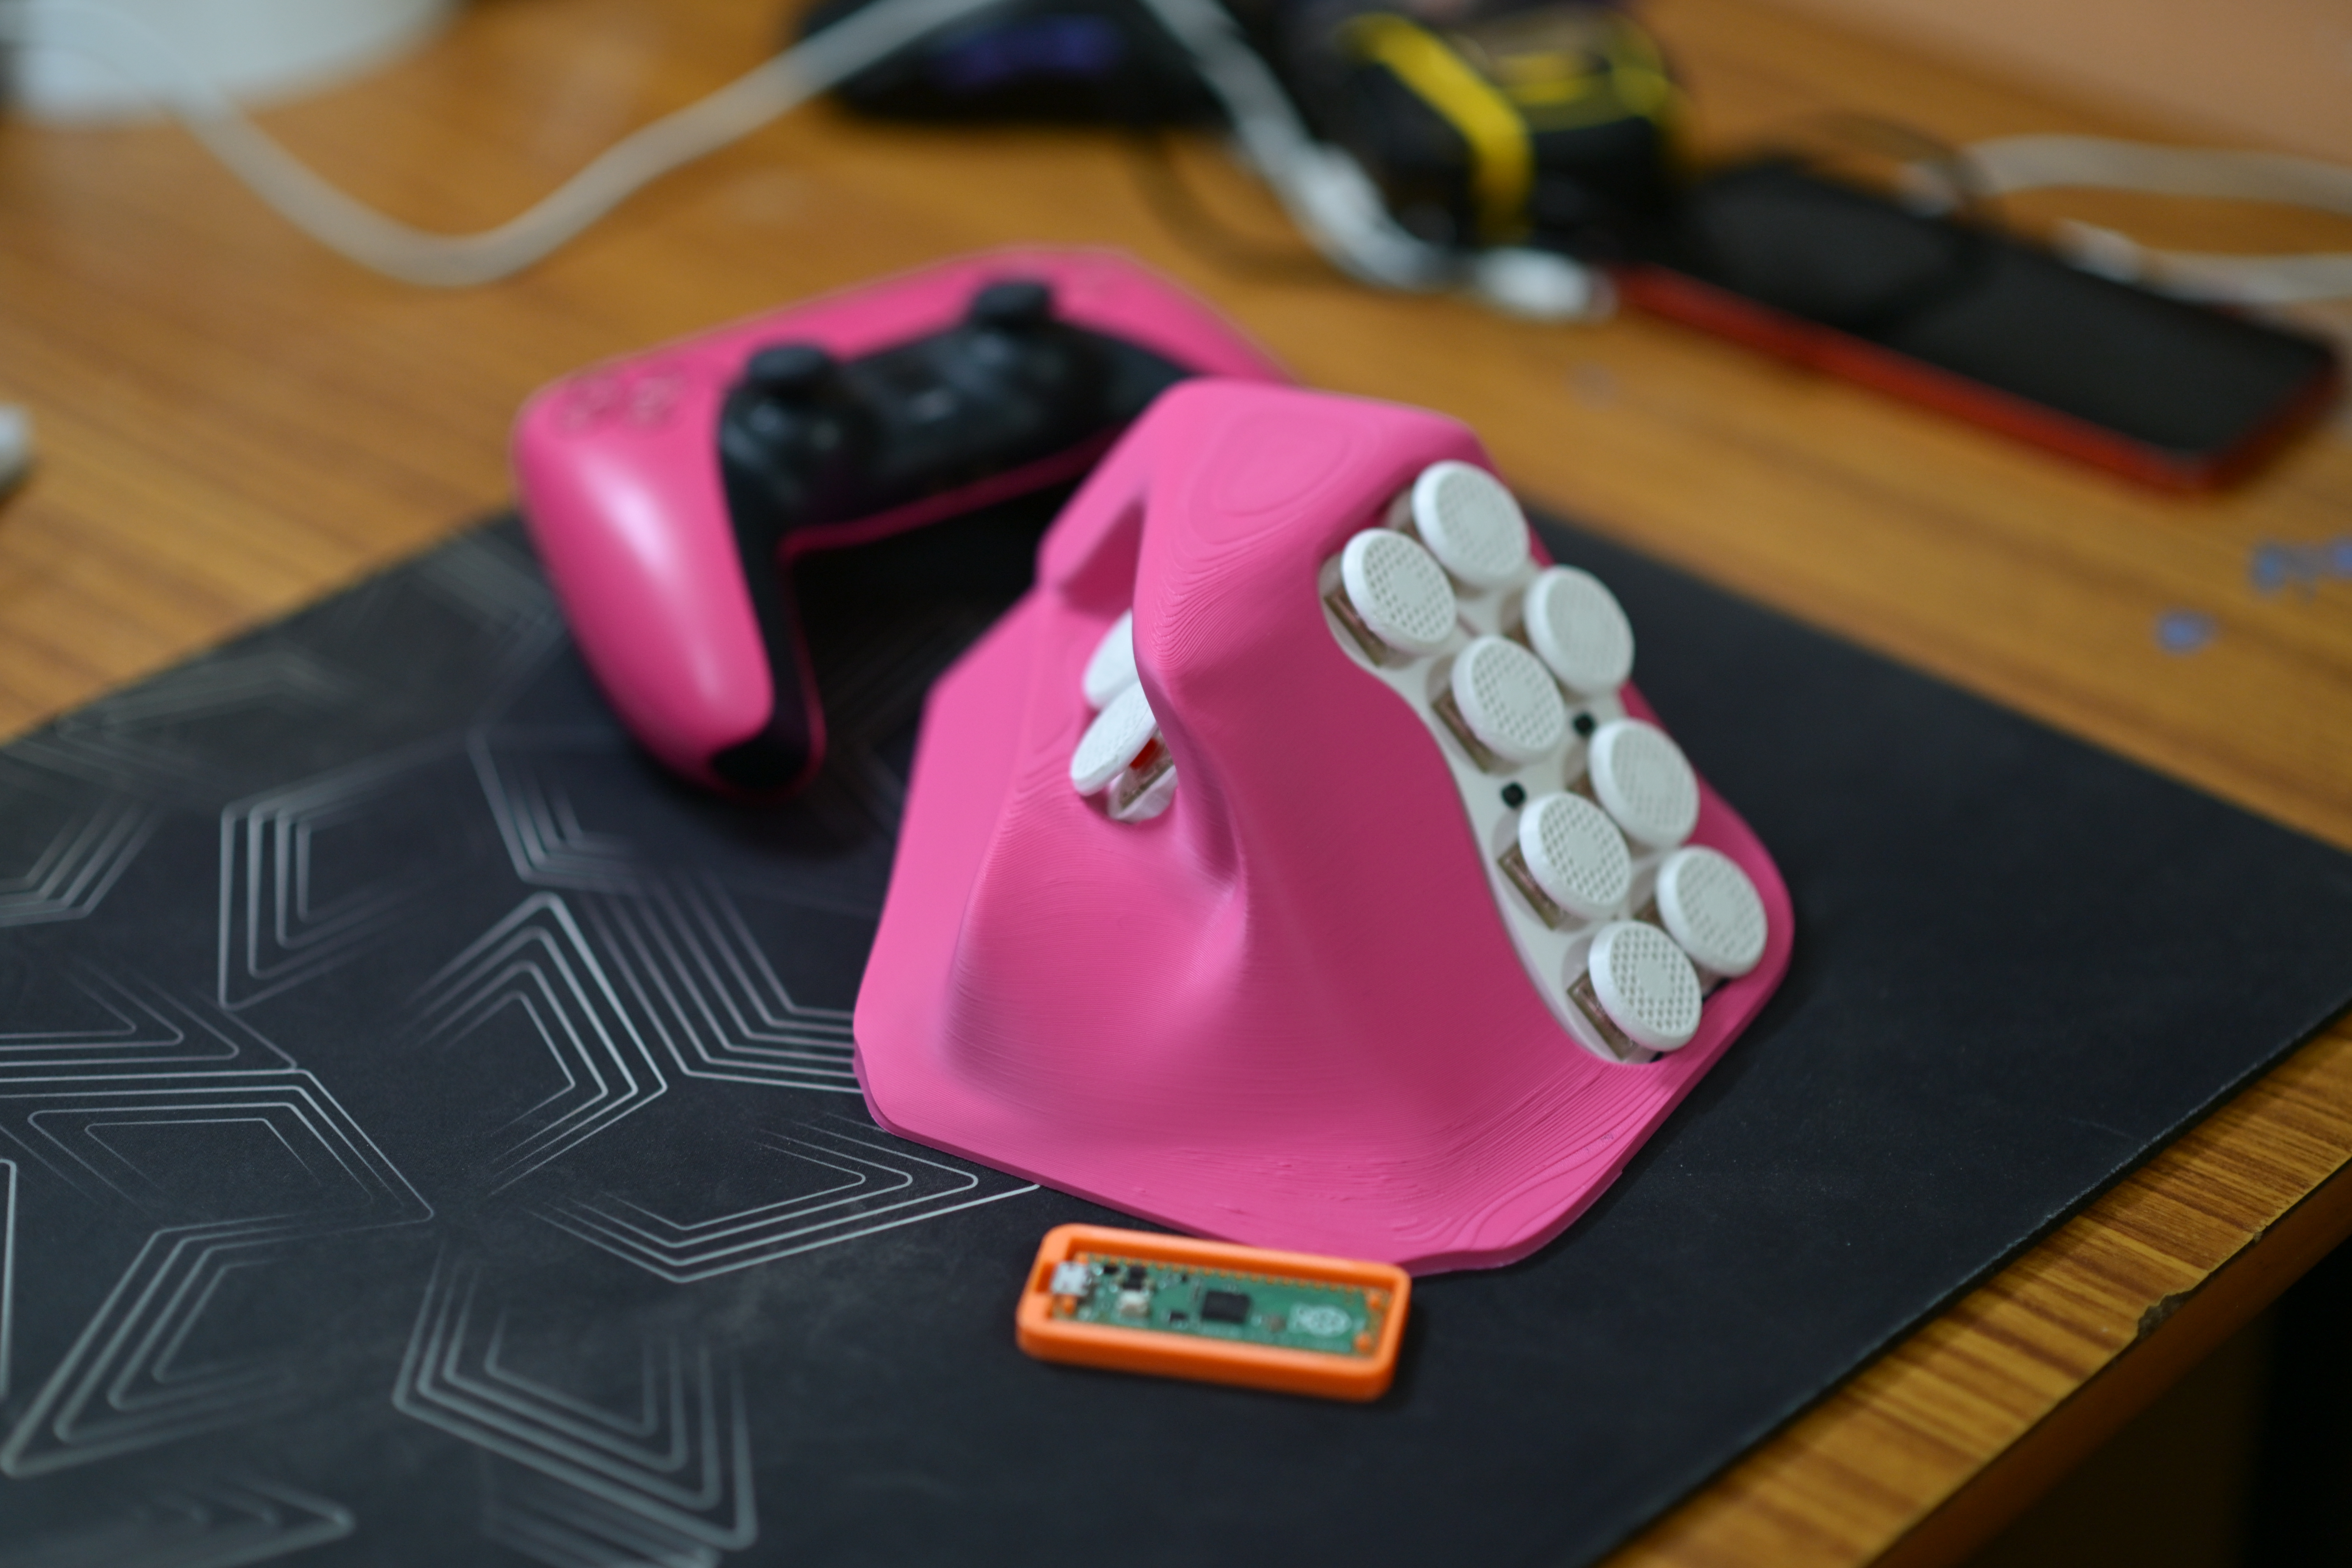 Right Half of ErgoWarrior's Pre-Alpha Build.
Traditional flat controllers force the wrists and fingers into unnatural positions. Over time, this can lead to discomfort, fatigue, and even injuries such as Repetitive Strain Injury (RSI) or Carpal Tunnel Syndrome.
An ergo-design, like ErgoWarrior, is built to keep your hands and wrists in a natural, relaxed posture. This brings several benefits:
In short, ergonomic designs are not just about comfort, they improve performance and intend to protect your hands over the long term.
Raspberry Pi Pico is the main dev-board platform for ErgoWarrior. May change to a custom dev-board in the future.
Cherry MX Low Profile switches are the switches used throughtout all forseen generations of Ergowarrior.
ErgoWarrior is designed to go with M3 Hex Socket 10mm Screws and 8mm M3 Injection Molding Brass Inserts.
Refer to Instructions.md for full instructions in assembly.
Print Settings: All Prints except the ultralight arcade button are done at 0.2mm layer height with the latter at 0.08mm LH. Refer to 3mf files for full details. Note: Some Sanding is required on the jump buttons for optimal fit.
Firmware used for ErgoWarrior is a tweaked build of GP2040-CE. Plug-and-Play firmware will drop soon. Until then stock GP2040-CE for the Raspberry Pi Pico must be used. Keybinds as below:
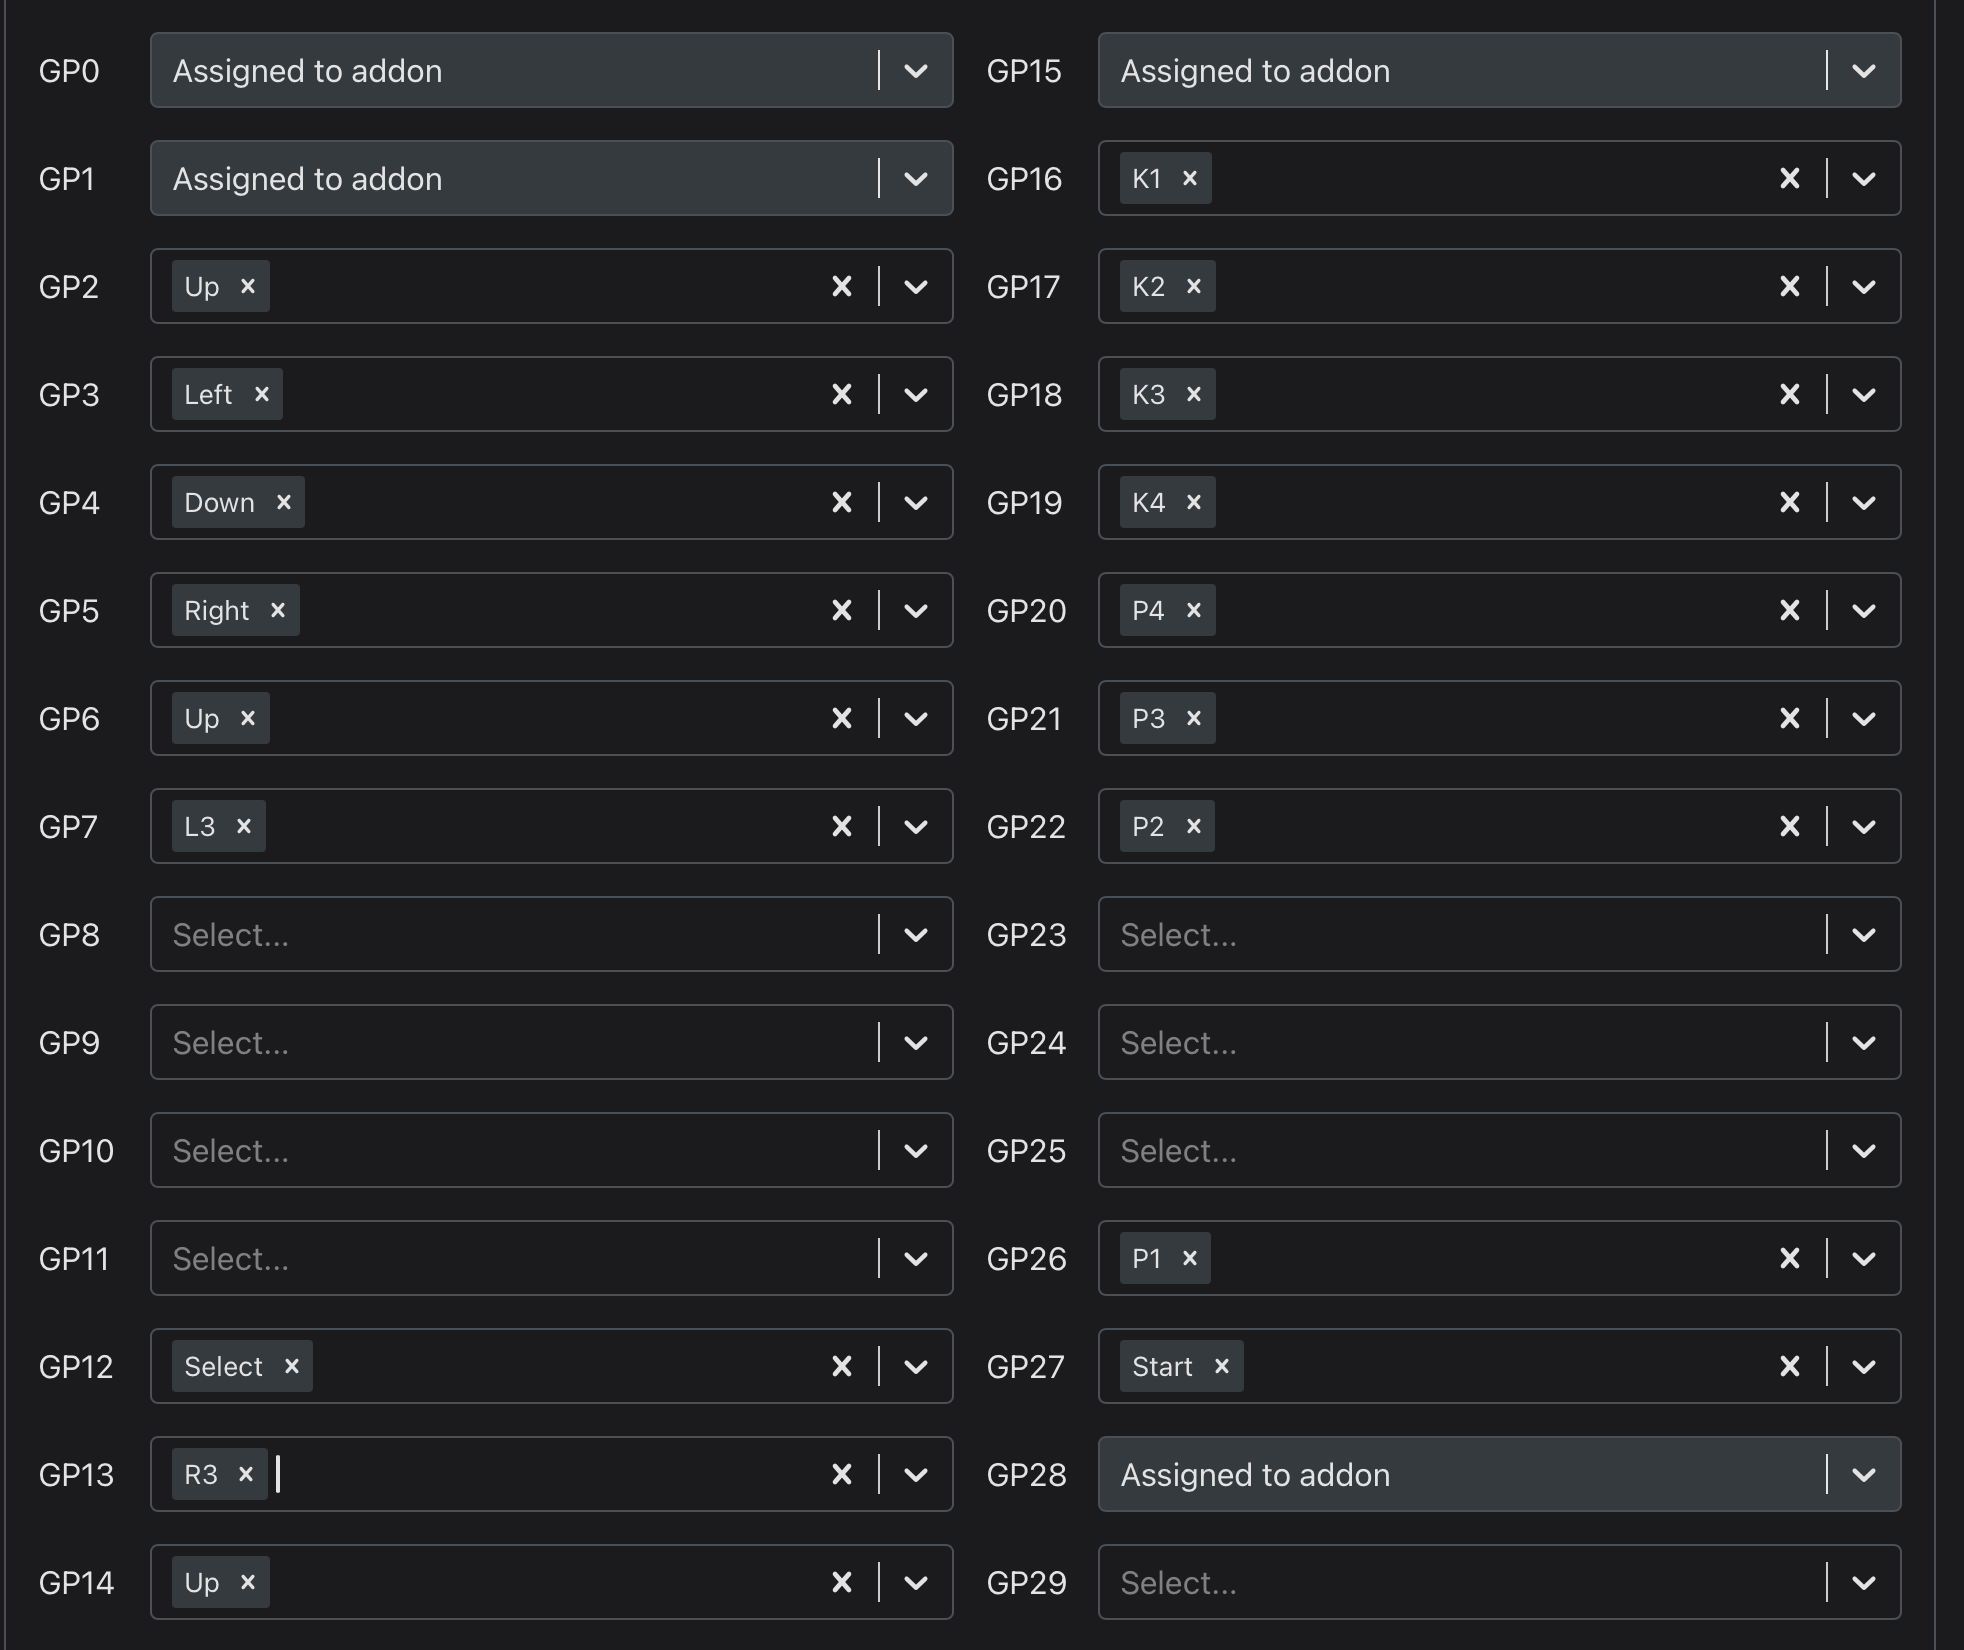
The ErgoWarrior is currently available in only one size, which corresponds to my personal hand size.
If you need a different size, you may scale and modify the model yourself with the step files to better fit your requirements.
If you're unsure how to do that, feel free to open an issue thread in the repository. I’m not making any promises at the moment, but I will look into it if possible.
A kof style 4+4 (L+R) controller was released as Alpha Build by mid-October with a beta build arriving on the same platform in late October. (Alpha Build out.) (Beta build cancelled, changes merged with v1.)
A Third-Strike style controller with a (6+10)* (L+R) layout was slated for release in mid-November late-November (Delay in arrival of PCBs).
This was not a a release I had planned, however as the ErgoWarrior handle failed in what I would call abnormal but expected load conditions, I have completely reworked the handle, this time using Topology Optimisation to make it absolutely sure it does not fail like that again.
* Tentative, may change.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 22 | TestPoint | TestPoint:TestPoint_Pad_D2.0mm | AK1, AP1, D1, GND1, GND2, GND3, GND4, GND5, HK1, HP1, JL1, JLA1, JLA2, JR1, JRA1, JRA2 +6 |
| 1 | Pi Pico | Raspberry_Pi_Pico_for_ErgoWarrior:Pico_SMT | U1 |
| 1 | Select | Keyboard_Switches:Cherry_MX_LP | S2 |
| 1 | Start | Keyboard_Switches:Cherry_MX_LP | S1 |
| 1 | ~ | Display:SSD1306_i2c_Generic | U2 |
kinpro1024/ErgoWarrior
A completely open source Ergonomic Hitbox-Style Leverless Fighting game controller.

kinpro1024/ErgoWarrior
A completely open source Ergonomic Hitbox-Style Leverless Fighting game controller.

kinpro1024/ErgoWarrior
A completely open source Ergonomic Hitbox-Style Leverless Fighting game controller.


hackclub/OnBoard
💡 Join 1,000 teenagers and make your first PCB with a $100 grant!


harbaum/galagino
A Galaga, Pac-Man and Donkey Kong arcade emulator for the ESP32

Luos-io/luos_engine
Open-source and real-time orchestrator for cyber-physical-systems, to easily design, test and deploy embedded applications and digital twins.

google/walt
A device for measuring latency of physical sensors and outputs on phones and computers

It measures 76 × 57.5 mm and has 2 copper layers, 1.6 mm thick.
26 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the kinpro1024/ErgoWarrior repository on GitHub, at the commit this page was made from: the board is PCBs/v1/References/ErgoWarrior_Final/ErgoWarrior_Final.kicad_pcb and its schematic PCBs/v0/References/ErgoWarrior_Testbed_v0.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).