2 layers

 jnavarro7/linux-based-scout-uav
Linux based scout UAV
Linux based scout uav is an open-source printed circuit board by jnavarro7, from the jnavarro7/linux-based-scout-uav repository on GitHub. It is a 2-layer board of 70 × 100 mm with 51 parts on 482 nets.
It is built around the OSD32MP157C-512M-IAA, EMMC04G-W627-M06U and AMG8833, with the CYPD3177-24LQXQ, G313-06329-00 and LC76G among its other parts. Its parts include 19 resistors, 11 ICs, 6 connectors, 5 capacitors and 2 transistors. It belongs with the computers and single-board computers boards of this library.


Linux based scout UAV
LinuxベースのスカウトUAV
Hobby project to create a UAV (Unmanned aerial vehicle) in a quadcopter drone format, based on the OSD32MP1 SiP which is a Linux capable system.
Linux 対応システムである OSD32MP1 SiP をベースに、クアッドコプター ドローン形式の UAV (無人航空機) を作成する趣味のプロジェクト。
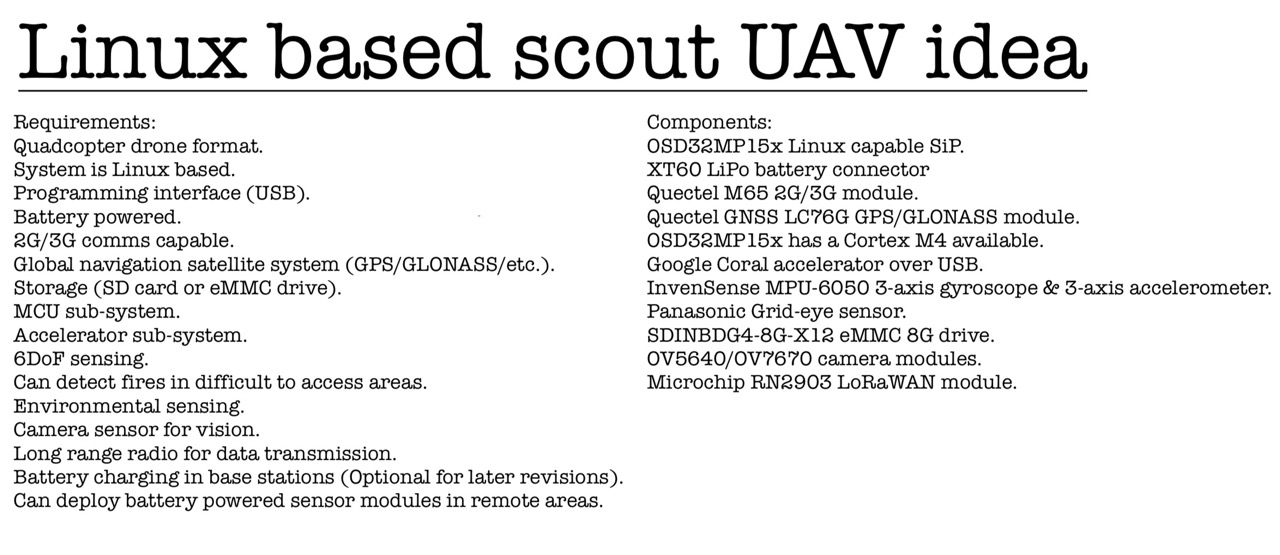
The system block diagram is still a work in progress. Still looking for a good option on ESC (electronic speed controller) for the drone. Maybe CAN bus based systems can be used as there is a CAN bus available in the OSD32MP1 SiP.
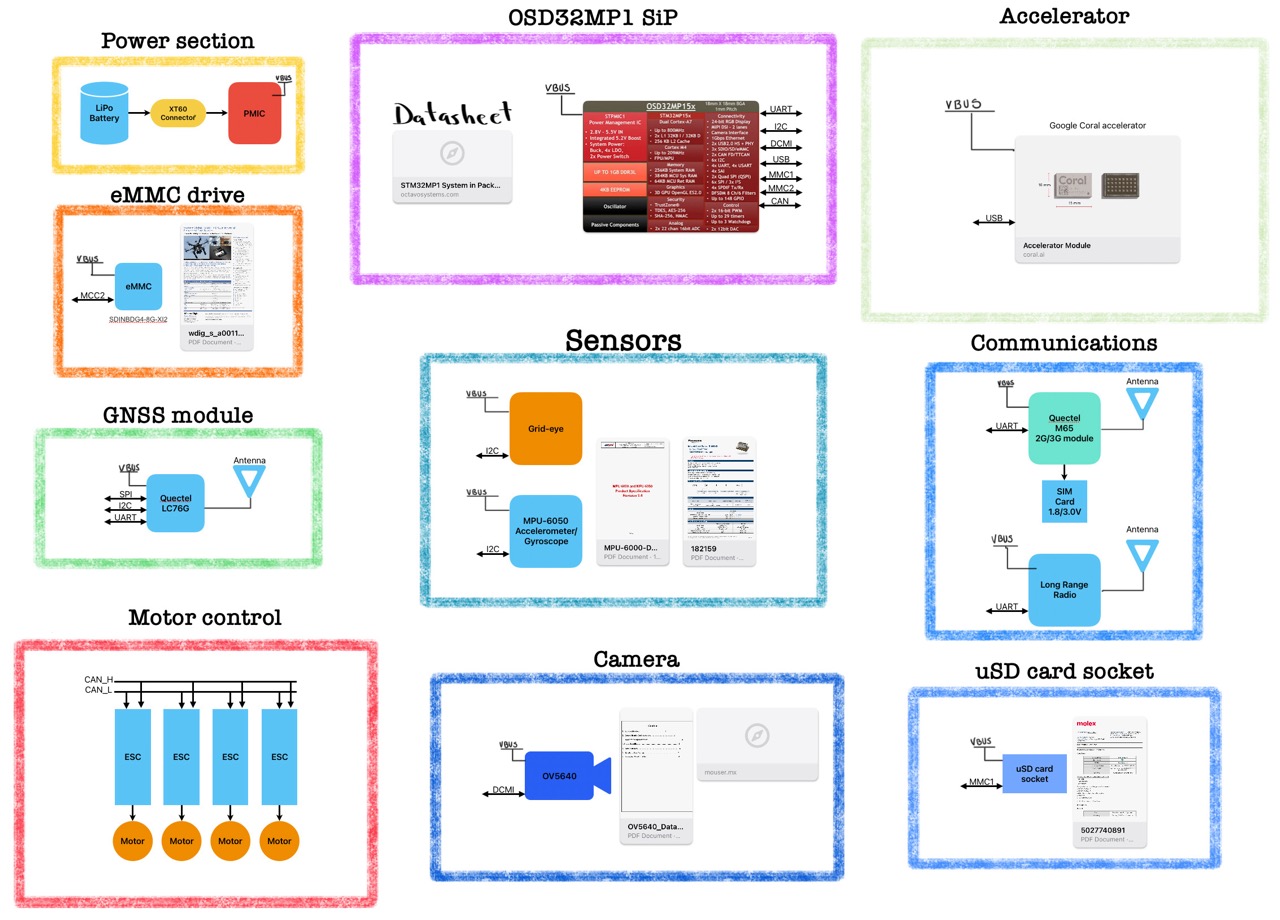
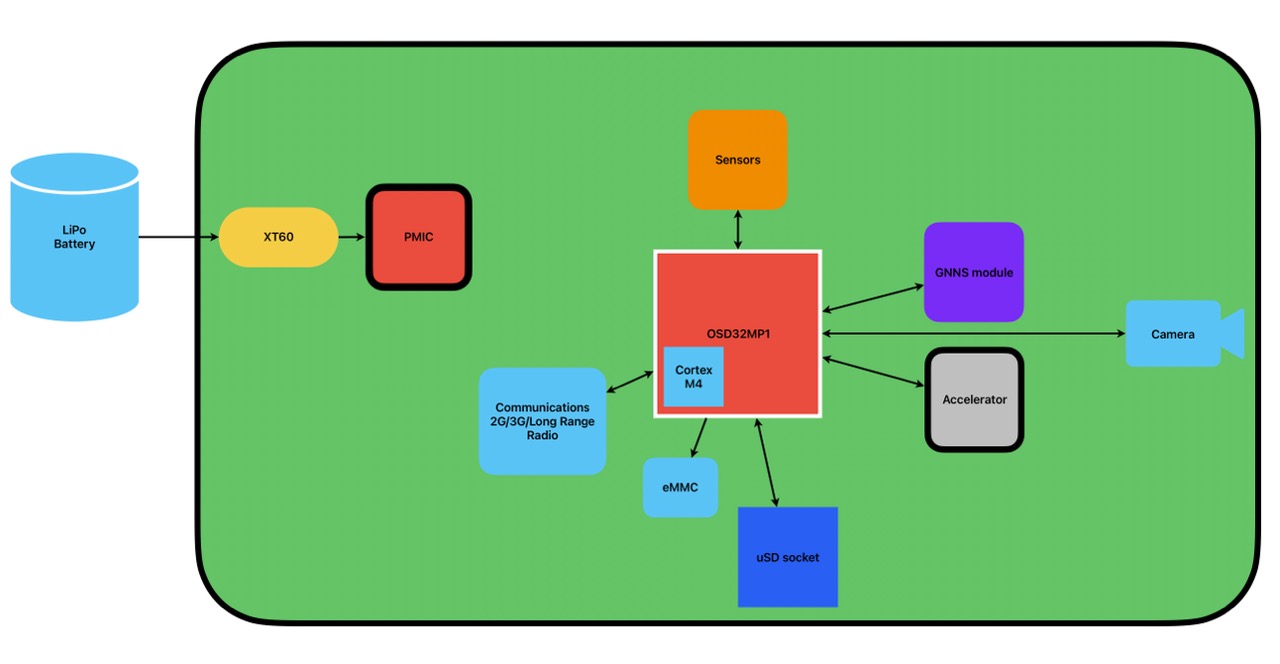
System block diagram
Octavo develops and mantains a Debian based image that supports their development boards. I plan to start prototyping with this image.
I will base my work on Octavo's OSD32MP1-BRK device tree and modify it as needed.
Based on the OSD32MP1:
ST32MP15x Features:
Arm® Cortex®-A7 up to 800MHz x2
Arm® Cortex®-M4 up to 209MHz
NEON™SIMD Coprocessor x2
USB 2.0 HS + PHY x2
Ethernet 10/100/1000
CAN FD/TTCAN x2, UART x4, USART x4,SPI x6, I2C x6, SAI x4, QSPI, SPDIF, I2S x3
eMMC/SD/SDIO Ports x3
GPIO x148
24-bit RGB Display, MIPI DSI
Camera Interface
22 Channel 16-bit ADC x2, 12-bit DAC x2
The SiP has an embedded ARM Cortex M4 sub-system which can be used by creating firmware in ST Cube IDE.
Started working on the schematic capture, schematic in PDF format will be added as it is updated.
Started work on board by trying board shapes and importing the DXF files. Already placed the initial components available, will update as needed.
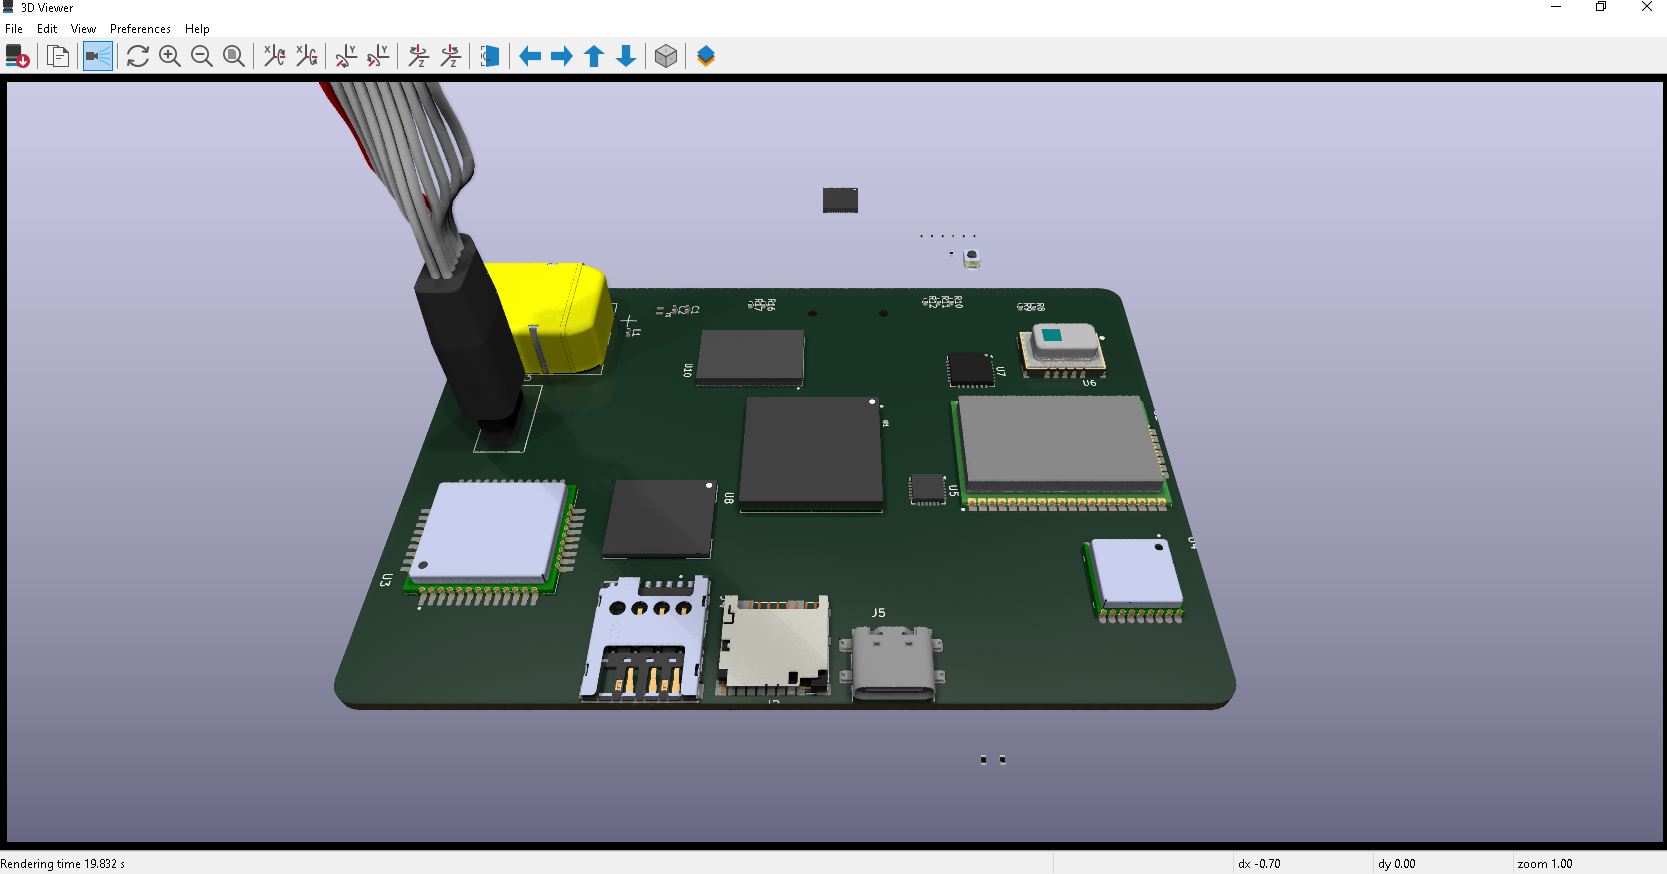
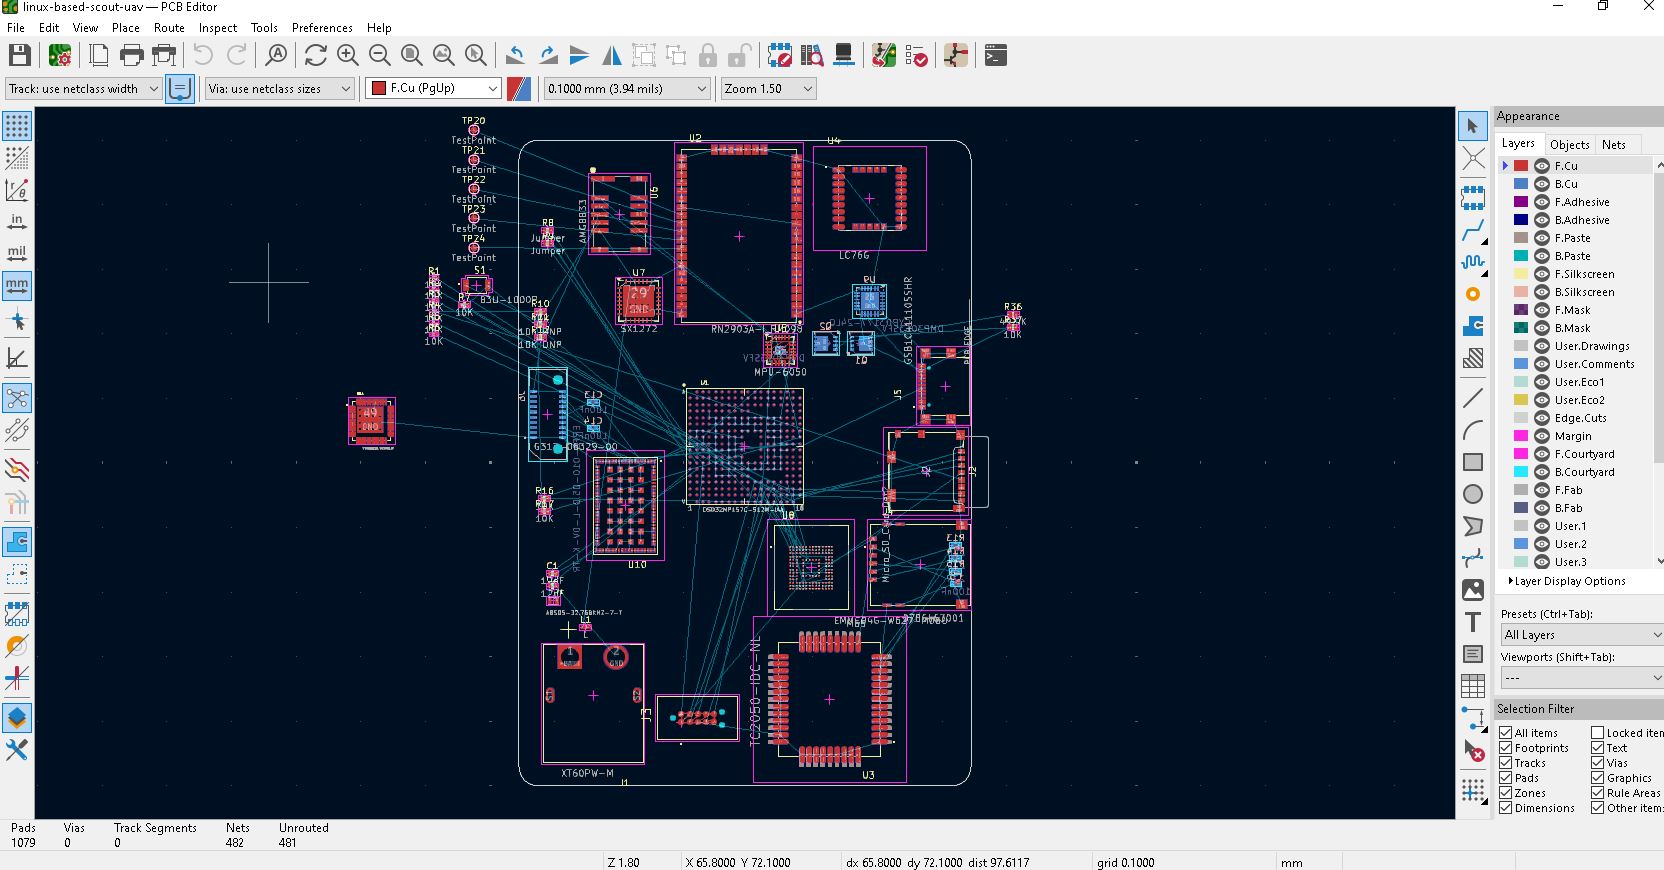
Hardware being designed in KiCad 9.0
Released under the Creative Commons Attribution 4.0 License https://creativecommons.org/licenses/by/4.0/
| Qty | Value | Footprint | References |
|---|---|---|---|
| 6 | 10K | Resistor_SMD:R_0201_0603Metric | R1, R2, R3, R4, R5, R6 |
| 5 | 10K | Resistor_SMD:R_0402_1005Metric | R7, R10, R16, R17, R37 |
| 5 | TestPoint | TestPoint:TestPoint_Pad_D1.0mm | TP20, TP21, TP22, TP23, TP24 |
| 3 | 100nF | Capacitor_SMD:C_0402_1005Metric | C3, C13, C14 |
| 3 | 22R | Resistor_SMD:R_0402_1005Metric | R13, R14, R15 |
| 2 | 10K DNP | Resistor_SMD:R_0402_1005Metric | R11, R12 |
| 2 | 12pF | Capacitor_SMD:C_0402_1005Metric | C1, C2 |
| 2 | DMP3013SFV | Package_SON:Diodes_PowerDI3333-8 | Q1, Q2 |
| 2 | Jumper | Resistor_SMD:R_0402_1005Metric | R8, R9 |
| 1 | 0786463001 | 0786463001:MOLEX_0786463001 | J4 |
| 1 | 49.9K | Resistor_SMD:R_0402_1005Metric | R36 |
| 1 | ABS05-32.768KHZ-7-T | ABS05-32.768KHZ-7-T:XTAL_ABS05-32.768KHZ-7-T | Y1 |
| 1 | AMG8833 | AMG8833:XDCR_AMG8833 | U6 |
| 1 | B3U-1000P | B3U-1000P:SW_B3U-1000P | S1 |
| 1 | CYPD3177-24LQ | Package_DFN_QFN:QFN-24-1EP_4x4mm_P0.5mm_EP2.75x2.75mm | U9 |
| 1 | EMMC04G-W627-M06U | EMMC04G-W627-M06U:BGA153N50P14X14_1300X1150X100N | U8 |
| 1 | ERF8-010-05.0-L-DV-K-TR | ERF8-010-05.0-L-DV-K-TR:SAMTEC_ERF8-010-05.0-L-DV-K-TR | J6 |
| 1 | G313-06329-00 | G313-06329-00:MODULE_G313-06329-00 | U10 |
| 1 | GSB1C41110SSHR | GSB1C41110SSHR:AMPHENOL_GSB1C41110SSHR | J5 |
| 1 | L | Inductor_SMD:L_0402_1005Metric | L1 |
| 1 | LC76G | LC76G:XCVR_LC76G | U4 |
| 1 | M65 | M65:XCVR_M65 | U3 |
| 1 | MPU-6050 | Sensor_Motion:InvenSense_QFN-24_4x4mm_P0.5mm | U5 |
| 1 | Micro_SD_Card_Det2 | Connector_Card:microSD_HC_Molex_104031-0811 | J2 |
| 1 | OSD32MP157C-512M-IAA | OSD32MP157C-512M-IAA:OSD32MP15X-BGA-324 | U1 |
| 1 | RN2903A-I_RM098 | RN2903A-I_RM098:XCVR_RN2903A-I_RM098 | U2 |
| 1 | SX1272 | Package_DFN_QFN:QFN-28-1EP_6x6mm_P0.65mm_EP4.8x4.8mm_ThermalVias | U7 |
| 1 | TC2050-IDC-NL | TC2050-IDC-NL:TAG-CONNECT_TC2050-IDC-NL | J3 |
| 1 | TPS65217CRSLR | TPS65217CRSLR:IC_TPS65217CRSLR | U11 |
| 1 | XT60PW-M | XT60PW-M:AMASS_XT60PW-M | J1 |
It measures 70 × 100 mm and has 2 copper layers, 1.6 mm thick.
51 parts, built around the OSD32MP157C-512M-IAA, EMMC04G-W627-M06U, AMG8833 and CYPD3177-24LQXQ. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the jnavarro7/linux-based-scout-uav repository on GitHub, at the commit this page was made from: the board is hardware/linux-based-scout-uav/linux-based-scout-uav.kicad_pcb and its schematic hardware/linux-based-scout-uav/battery-power.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask jnavarro7 before reusing the design.


beam-ttm/simulaciones
Simulaciones electromagnéticas Full-Wave (Sonnet EM) y diseño final de antena patch ADS-B 1090 MHz RHCP — Proyecto CubeSat BEAM (UNLaM)


CarloMara/usbc-esp32-pump-controller
USB C PD pump controller for small plants

antmicro/m2-smart-iot-module
https://antmicro.com/blog/2021/08/open-hardware-smart-m2-radio-module-for-iot/

