2 layers
Bbesc kiCad 1stAttempt
jakeread/tesc
in-progress motor controller, towards accessible closed-loop control
59 parts16
 jakeread/tesc16
in-progress motor controller, towards accessible closed-loop control
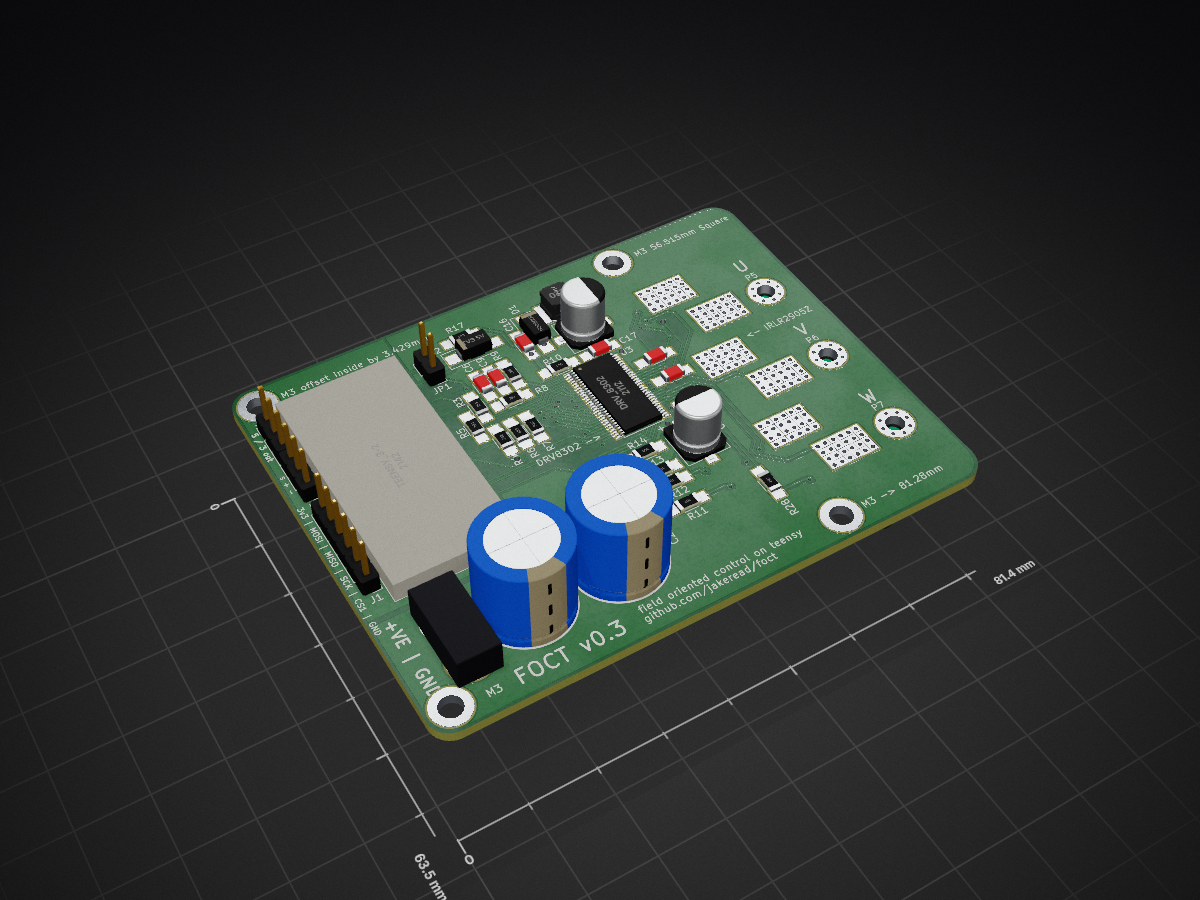
Bbesc kiCad is an open-source printed circuit board by jakeread, from the jakeread/tesc repository on GitHub. It is a 2-layer board of 81.4 × 63.5 mm with 82 parts on 82 nets, routed with 639 tracks and 59 vias.
It is built around the DRV8302 and JUMPER3. Its parts include 31 capacitors, 28 resistors, 6 transistors, 6 connectors and 2 ICs. It belongs with the robots and motor control boards and the NXP (LPC, Kinetis, i.MX RT) boards of this library.
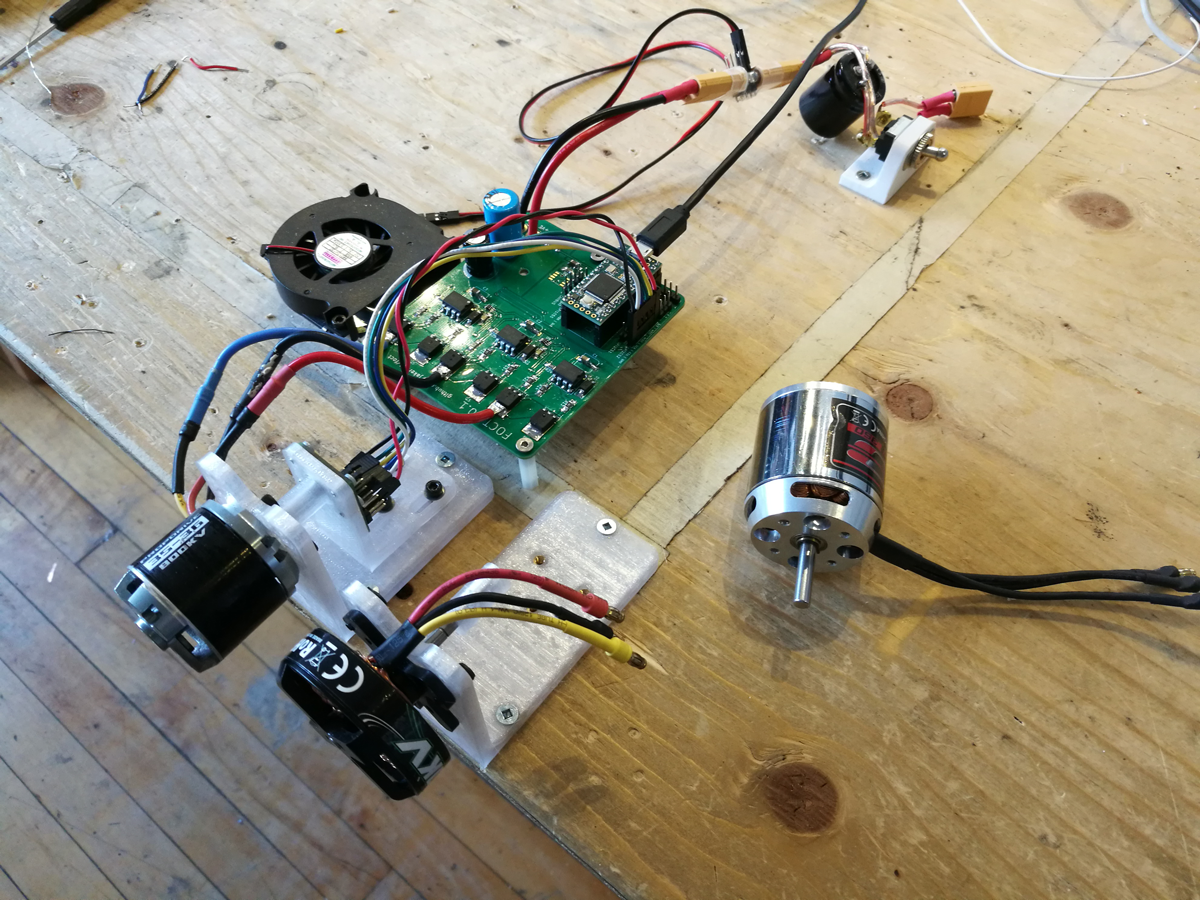
FOCT does closed-loop control of brushless dc (BLDC) motors: the type normally found in RC Cars, Airplanes, Drones etc. These motors are incredibly power-dense, making them an excellent candidate for Robotics applications. However, it's very difficult to control them at low speeds and in small position intervals.
FOCT implements 'all the bells and whistles' found in high-end robotics motor controllers (encoder feedback, BEMF & current sensing, etc) in a relatively low-cost solution. Code is written in Arduino for the Teensy Microcontroller, and is meant to be easily extensible and pick-through-able.
FOCT is in development! So is it's documentation!
FOCT uses a Teensy 3.2 to control Three H-Bridges, which each drive one phase of a three-phase brushless motor. The H-Bridge gates are driven with a DRV8302, a wunderkid IC that is also home to a 5V Buck Converter (for your peripheral needs) and two differential Op-Amps, used to measure phase current. The board also has simple voltage-dividers connected to Teensy ADCs for measuring phase voltage, and includes an SPI out connector used to interface with an AS5047 encoder for absolute position sensing. For now, input is done over Teensy's blazing-fast serial port.
Up to ~24v supply
Up to 30A without a heatsink, 42 with good cooling, peaks of 60
Planned PWM in, SPI slave modes for control. Serial over USB Config / testing.
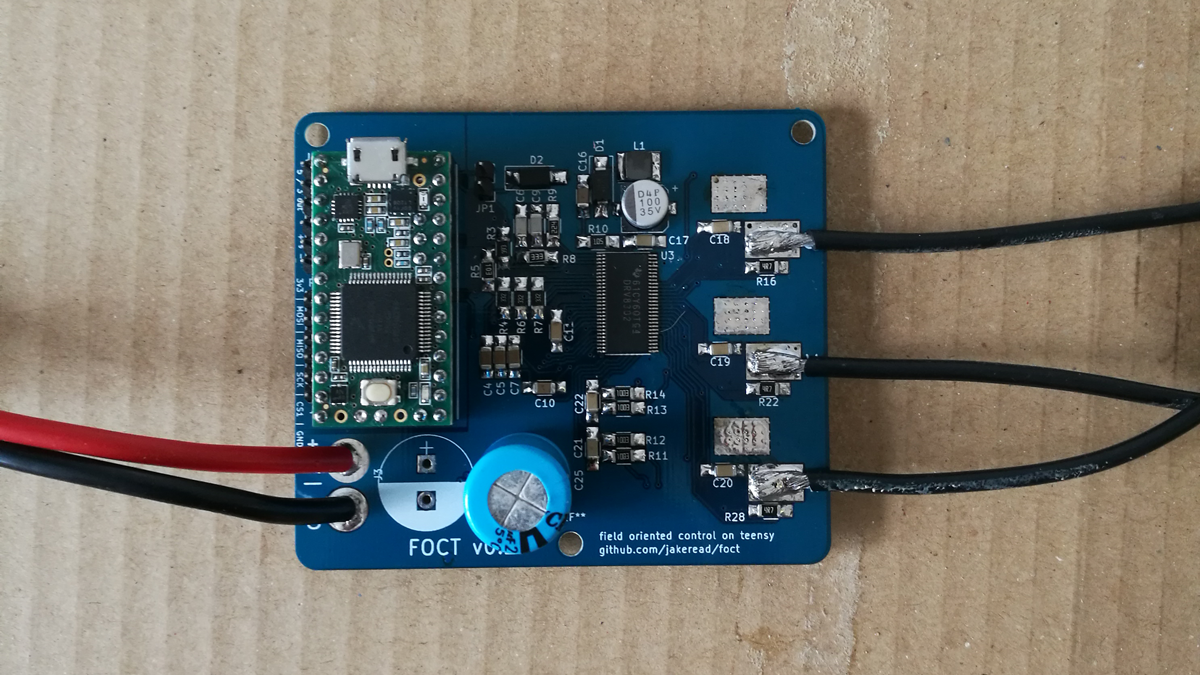
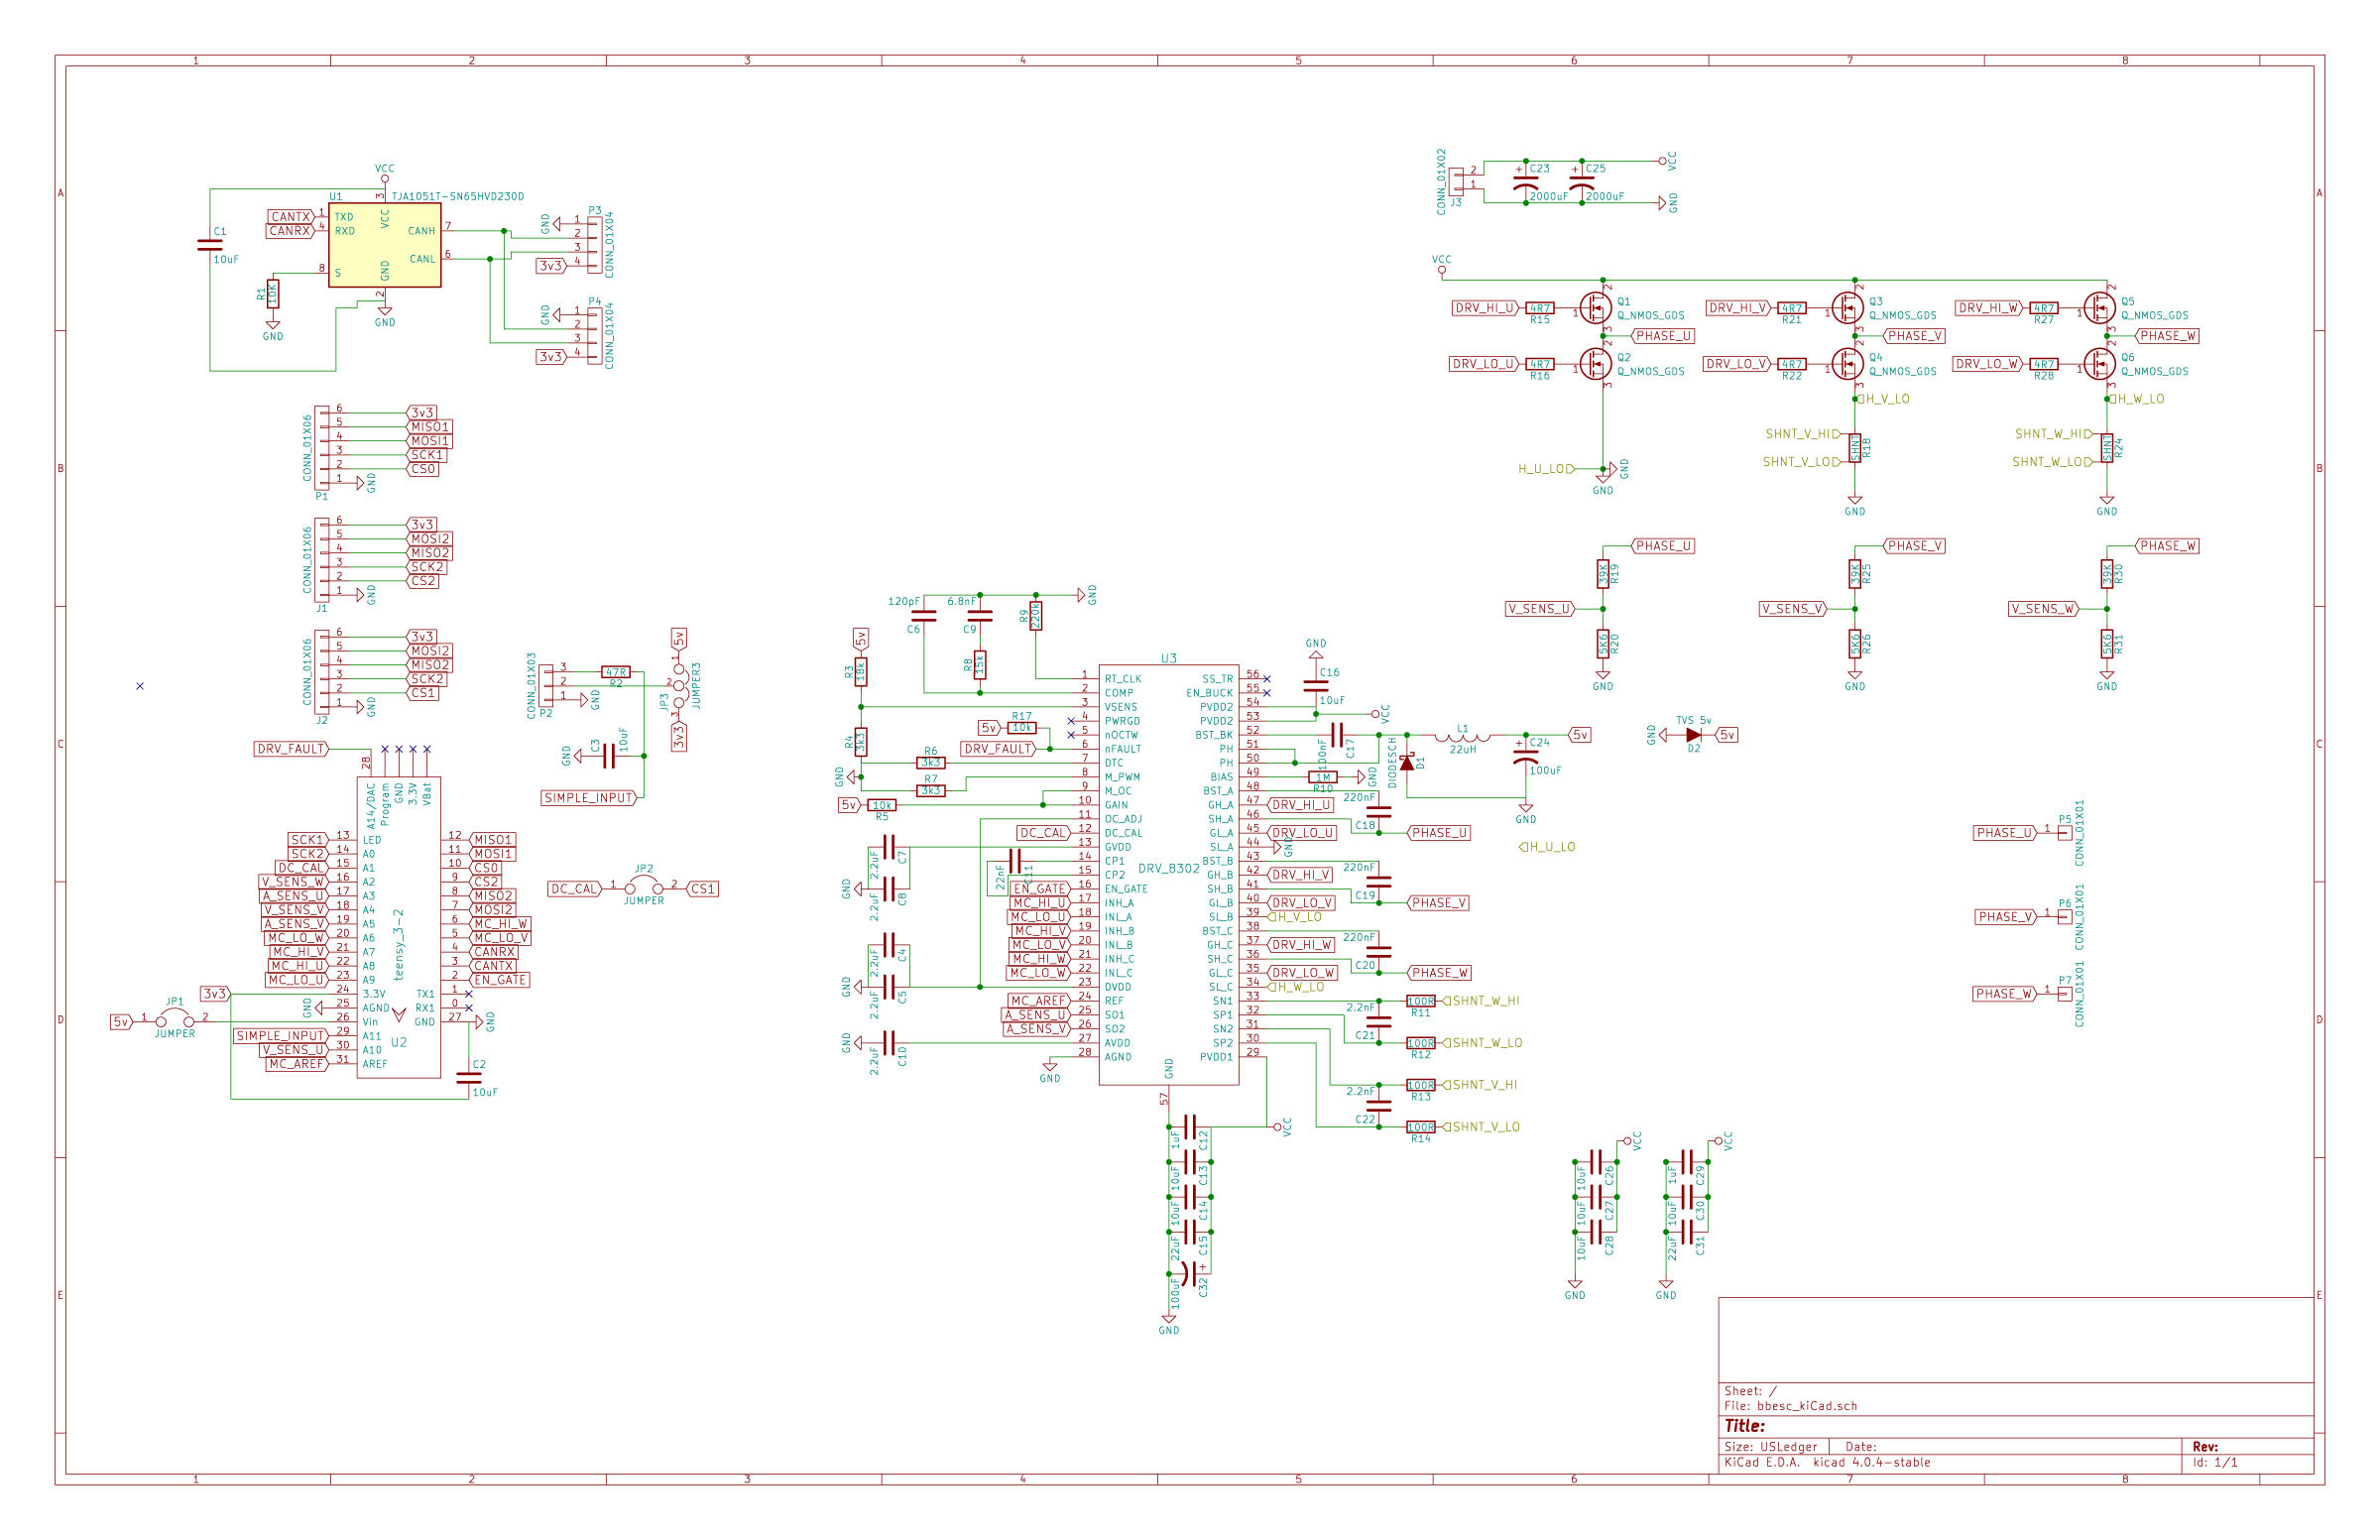
FOCT runs on Arduino! It uses Teensy's built interval timers to handle fast-loop-insurance, and only occasionally reaches into the chip's registers to make PWM work properly. Code will be well commented, I hope / promise...
// 6-step commutation w/ position reference
// FOC ! Transforms, current measurement, UVW || AB || IQ frames
| Qty | Value | Footprint | References |
|---|---|---|---|
| 11 | 10uF | Capacitors_SMD:C_1206_HandSoldering | C2, C3, C13, C14, C16, C26, C27, C28, C29, C30, C31 |
| 6 | 4R7 | Resistors_SMD:R_1206_HandSoldering | R15, R16, R21, R22, R27, R28 |
| 6 | Q_NMOS_GDS | HTO-252:TO-252-2 | Q1, Q2, Q3, Q4, Q5, Q6 |
| 5 | 2.2uF | Capacitors_SMD:C_1206_HandSoldering | C4, C5, C7, C8, C10 |
| 4 | 100R | Resistors_SMD:R_1206_HandSoldering | R11, R12, R13, R14 |
| 4 | MountingHole_3.2mm_M3_DIN965_Pad | Mounting_Holes:MountingHole_3.2mm_M3_DIN965_Pad | M3, M3 -> 81.28mm, M3 56.515mm Square, M3 offset inside by 3.429mm |
| 3 | 220nF | Capacitors_SMD:C_1206_HandSoldering | C18, C19, C20 |
| 3 | 39K | Resistors_SMD:R_1206_HandSoldering | R19, R25, R30 |
| 3 | 3k3 | Resistors_SMD:R_1206_HandSoldering | R4, R6, R7 |
| 3 | 5K6 | Resistors_SMD:R_1206_HandSoldering | R20, R26, R31 |
| 3 | CONN_01X01 | Mounting_Holes:MountingHole_2.7mm_Pad_Via | P5, P6, P7 |
| 2 | 100uF | Capacitors_SMD:CP_Elec_6.3x7.7 | C24, C32 |
| 2 | 10k | Resistors_SMD:R_1206_HandSoldering | R5, R17 |
| 2 | 2.2nF | Capacitors_SMD:C_1206_HandSoldering | C21, C22 |
| 2 | 2000uF | Capacitors_ThroughHole:CP_Radial_D13.0mm_P5.00mm | C23, C25 |
| 2 | SHNT | R_SHUNT_3920:R_SHUNT_3920 | R18, R24 |
| 1 | 100nF | Capacitors_SMD:C_1206_HandSoldering | C17 |
| 1 | 120pF | Capacitors_SMD:C_1206_HandSoldering | C6 |
| 1 | 15k | Resistors_SMD:R_1206_HandSoldering | R8 |
| 1 | 15uF | Capacitors_SMD:C_1206_HandSoldering | C15 |
| 1 | 18k | Resistors_SMD:R_1206_HandSoldering | R3 |
| 1 | 1M | Resistors_SMD:R_1206_HandSoldering | R10 |
| 1 | 1uF | Capacitors_SMD:C_1206_HandSoldering | C12 |
| 1 | 220k | Resistors_SMD:R_1206_HandSoldering | R9 |
| 1 | 22nF | Capacitors_SMD:C_1206_HandSoldering | C11 |
| 1 | 22uH | Inductors:Inductor_Taiyo-Yuden_NR-40xx_HandSoldering | L1 |
| 1 | 47R | Resistors_SMD:R_1206_HandSoldering | R2 |
| 1 | 6.8nF | Capacitors_SMD:C_1206_HandSoldering | C9 |
| 1 | CONN_01X02 | Wire_Connections_Bridges:WireConnection_2.50mmDrill_LargePad | J3 |
| 1 | CONN_01X03 | Pin_Headers:Pin_Header_Straight_1x03_Pitch2.54mm | P2 |
| 1 | CONN_01X06 | Pin_Headers:Pin_Header_Straight_1x06_Pitch2.54mm | J1 |
| 1 | DIODESCH | Diodes_SMD:D_SMA_Handsoldering | D1 |
| 1 | DRV_8302 | HTSSOP-56:TSSOP-56_6.1x14mm_Pitch0.5mm | U3 |
| 1 | JUMPER | Pin_Headers:Pin_Header_Straight_1x02_Pitch2.54mm | JP1 |
| 1 | JUMPER3 | Pin_Headers:Pin_Header_Straight_1x03_Pitch2.54mm | JP3 |
| 1 | TVS 5v | Diodes_SMD:D_SMA_Handsoldering | D2 |
| 1 | teensy_3-2 | teensy_3-2_bottomLess:Teensy3.2-bottomLess | U2 |
jakeread/tesc
in-progress motor controller, towards accessible closed-loop control

ansh1113/e-bike-conversion-kit
A 4-layer PCB-based e-bike conversion kit featuring an STM32-based VESC ESC, power management circuits, wireless throttle, GSM, GPS, and more.


KoJZz/Control-Rakatuy
bash git pull origin main # pull updatean terbaru dari repo git add . # add file terbaru yang udah dibuat git commit -m "Update: [Component Name] - Added power stage layout" # commiting git push origin main # push ke…

koson/bldc_hardware-1
This is a fork of Benjamin Vedders Open Source VESC project: https://github.com/vedderb/bldc-hardware

niksrajendra/stm8-bootloader-extended
STM8 bootloader designed to work with any available communication interface and configure for different feature like secure, unsecure bootloader.
It measures 81.4 × 63.5 mm and has 2 copper layers, 1.6 mm thick.
82 parts, built around the DRV8302 and JUMPER3. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the jakeread/tesc repository on GitHub, at the commit this page was made from: the board is Circuit/bbesc_kiCad.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask jakeread before reusing the design.