4 layers140 × 97 mm
MainBoard
Immortals-Robotics/MainBoard
Immortals main electronics for the Robocup Soccer Small-Size League
137 parts

 FBIopeningUPP/LeanLine
A.T.L.A.S. is a bare-metal system it revolves around track-day with ur superbikes. It calculates ur lean angles, track positioning using GPS, and lap times at a frequency of 100Hz, it logs the data directly to your…
LeanLine is an open-source printed circuit board by FBIopeningUPP, from the FBIopeningUPP/LeanLine repository on GitHub. It is a 2-layer board of 39.4 × 42.5 mm with 55 parts on 62 nets, routed with 304 tracks and 29 vias.
It is built around the RP2040, W25Q128JVPIQ and MIC5219-3.3YM5, with the AMS1117-5.0, ICM-42688-P and S4B-XH-SM4-TB(LF)(SN) among its other parts. Its parts include 31 capacitors, 8 resistors, 7 ICs, 1 connector and 1 crystal. It belongs with the RP2040 boards of this library.


A.T.L.A.S. is a bare-metal system it revolves around track-day with ur superbikes. It calculates ur lean angles, track positioning using GPS, and lap times at a frequency of 100Hz, it logs the data directly to your MicroSD card and visualizes the daya in custom PyQt5 Dashboard.
This project is divided into 3 nodes:
A custom pcb designed around the Raspberry Pi RP2040 microcontroller.
The firmware is purely written in C++
A simple Desktop application built with PyQt5 and PyQtGraph
A complete, itemized BOM is generated by kicad It can be viewed: hardware/bom.csv
RP2040 bare-metal is pretty easy to program not that hard
mkdir build && cd build
cmake -G "Ninja" -DPICO_SDK_DETCH_FROM_GIT=ON ..
ninjaCopy the telemetry.dat file from the MicroSd card
Install the python libraries: pip install PyQt5 pyqtgraph
Run the Digital Twin Dashboard: python dashboard/main.py
Click Load Telemetry Binary and select the MicroSd card data
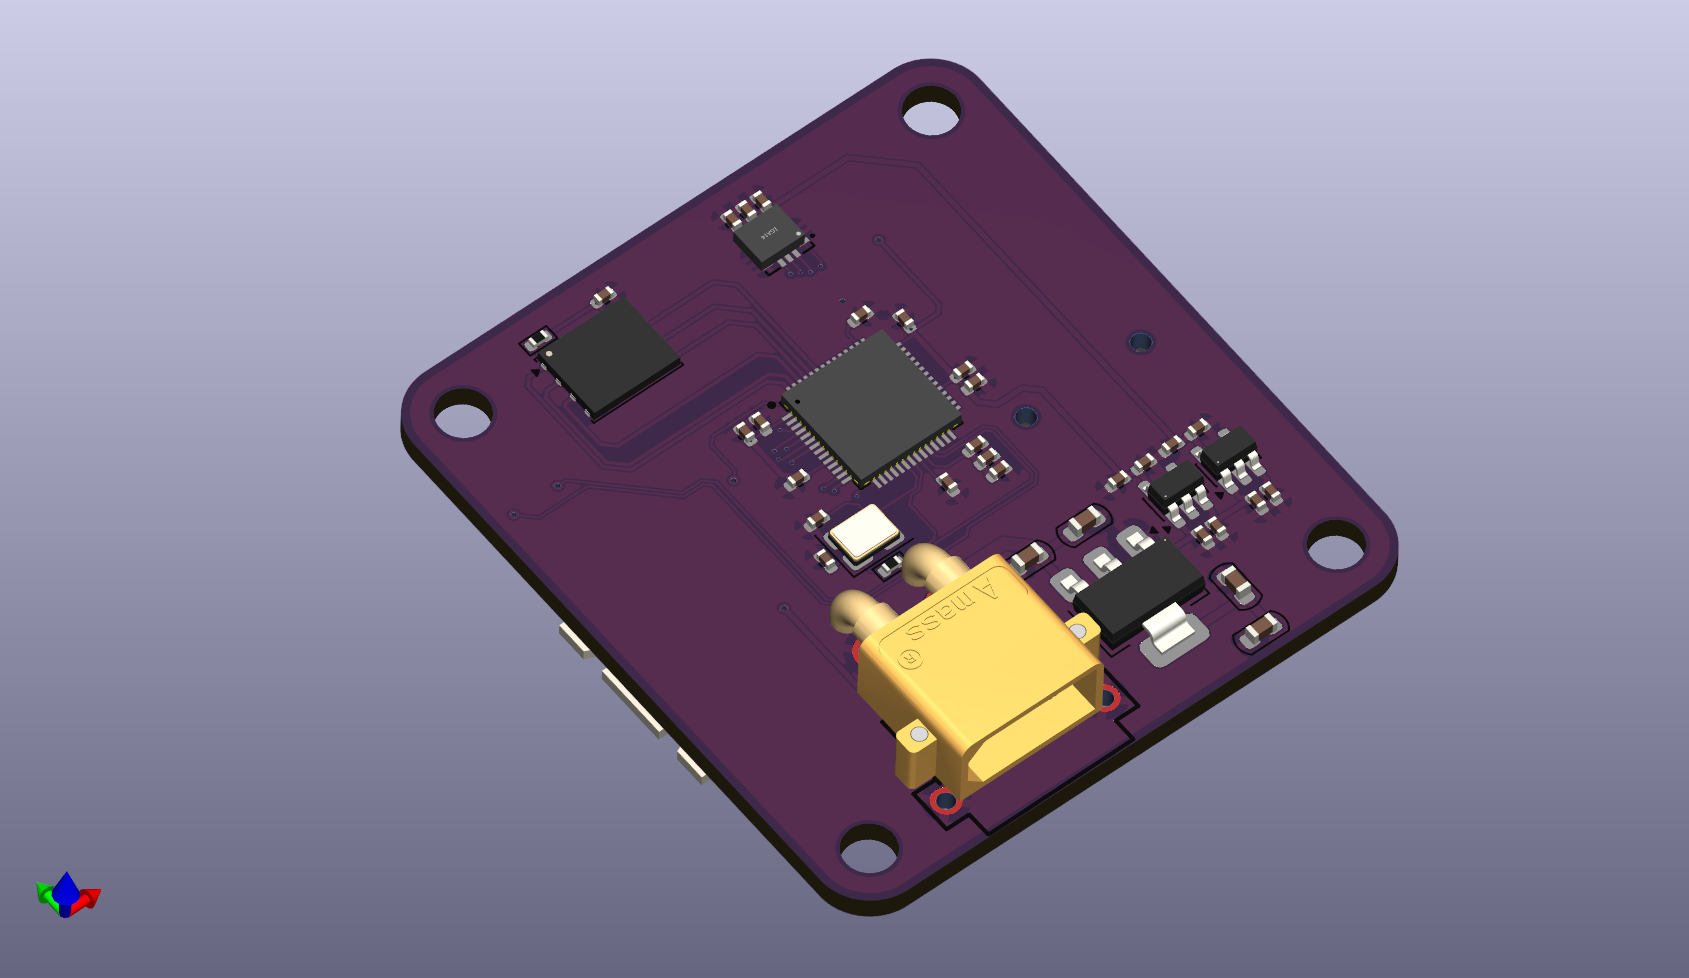
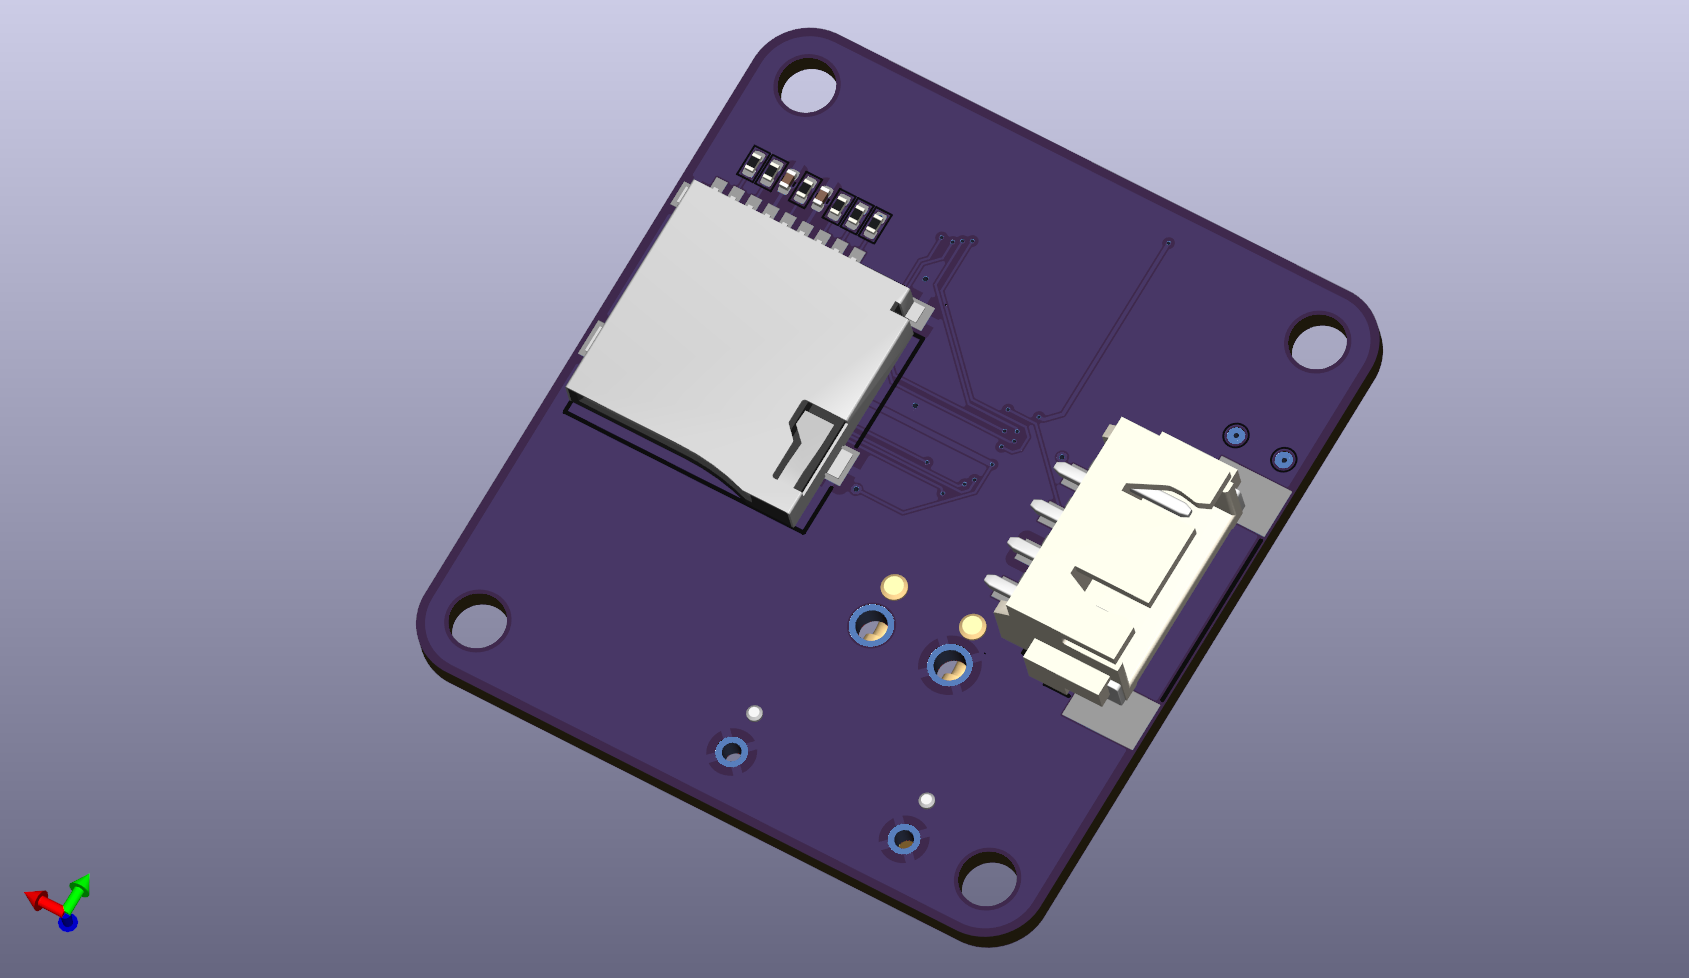
the usage of ai was done to figure out the pinout and the project structure of how everything will be done
| Qty | Value | Footprint | References |
|---|---|---|---|
| 16 | 100nF | Capacitor_SMD:C_0402_1005Metric | C103, C105, C106, C107, C108, C109, C110, C111, C112, C113, C115, C117, C119, C121, C123, C126 |
| 7 | 1uF | Capacitor_SMD:C_0402_1005Metric | C104, C114, C116, C118, C120, C122, C127 |
| 6 | 10k | PCM_Resistor_SMD_AKL:R_0402_1005Metric | R104, R105, R106, R107, R108, R109 |
| 4 | MountingHole | MountingHole:MountingHole_3.2mm_M3_DIN965 | H101, H102, H103, H104 |
| 2 | 100nF | PCM_Capacitor_SMD_AKL:C_0603_1608Metric | C128, C132 |
| 2 | 15pF | Capacitor_SMD:C_0402_1005Metric | C101, C102 |
| 2 | 1uF | PCM_Capacitor_SMD_AKL:C_0603_1608Metric | C129, C133 |
| 2 | MIC5219-3.3YM5 | Package_TO_SOT_SMD:SOT-23-5 | U104, U105 |
| 1 | 10nF | Capacitor_SMD:C_0402_1005Metric | C125 |
| 1 | 12MHz | Crystal:Crystal_SMD_3225-4Pin_3.2x2.5mm | Y101 |
| 1 | 1k | PCM_Resistor_SMD_AKL:R_0402_1005Metric | R101 |
| 1 | 2.2uF | Capacitor_SMD:C_0402_1005Metric | C124 |
| 1 | AMS1117-5.0 | Package_TO_SOT_SMD:SOT-223-3_TabPin2 | U106 |
| 1 | DNF | PCM_Resistor_SMD_AKL:R_0402_1005Metric | R102 |
| 1 | ICM-42688-P | easyeda2kicad:LGA-14_L3.0-W2.5-P0.50-TL | U103 |
| 1 | RP2040 | easyeda2kicad:LQFN-56_L7.0-W7.0-P0.4-EP | U101 |
| 1 | S4B-XH-SM4-TB- | easyeda2kicad:CONN-SMD_S4B-XH-SM4-TB-LF-SN | U107 |
| 1 | SWCLK | TestPoint:TestPoint_Pad_D1.0mm | TP101 |
| 1 | SWD | TestPoint:TestPoint_Pad_D1.0mm | TP102 |
| 1 | TF PUSH | easyeda2kicad:TF-SMD_TF-PUSH | Card101 |
| 1 | W25Q128JVP | Package_SON:WSON-8-1EP_6x5mm_P1.27mm_EP3.4x4.3mm | U102 |
| 1 | XT30PW-M | easyeda2kicad:CONN-TH_XT30PW-M | CN101 |
It measures 39.4 × 42.5 mm and has 2 copper layers, 1.6 mm thick.
55 parts, built around the RP2040, W25Q128JVPIQ, MIC5219-3.3YM5 and AMS1117-5.0. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the FBIopeningUPP/LeanLine repository on GitHub, at the commit this page was made from: the board is hardware/pcb/pcb.kicad_pcb and its schematic hardware/pcb/pcb.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask FBIopeningUPP before reusing the design.
Immortals-Robotics/MainBoard
Immortals main electronics for the Robocup Soccer Small-Size League

makerspacelt/wiscale-hw
This is ESP8266 (ESP-12F) and HX711 based weight monitoring device.

Robast-GmbH/PCB_Designs
This repository contains all the necessary files and instructions for the PCBs that are designed using KiCad. Here is an overview of the main components: - .github: Contains Github-specific configurations, including…


FBIopeningUPP/ChromaDeck
ChromaDeck is a massive, open-source, fully custom USB MIDI Control Surface designed for streaming, video editing, and live audio mixing.

nasheed-x/aether
Aether is a versatile flight computer for testing flight hardware and software, focusing on sensor fusion to monitor rocket states and interface with on-board systems.

BenjaminMeyerEE/Two-Axis_Balancing_Robot
A robot that balances in pitch and roll. The two axes use different hardware: pitch runs a brushless motor through a VESC over CAN, roll runs a brushed motor through an H-bridge on a custom power board.
