2 layers57.2 × 57.2 mm
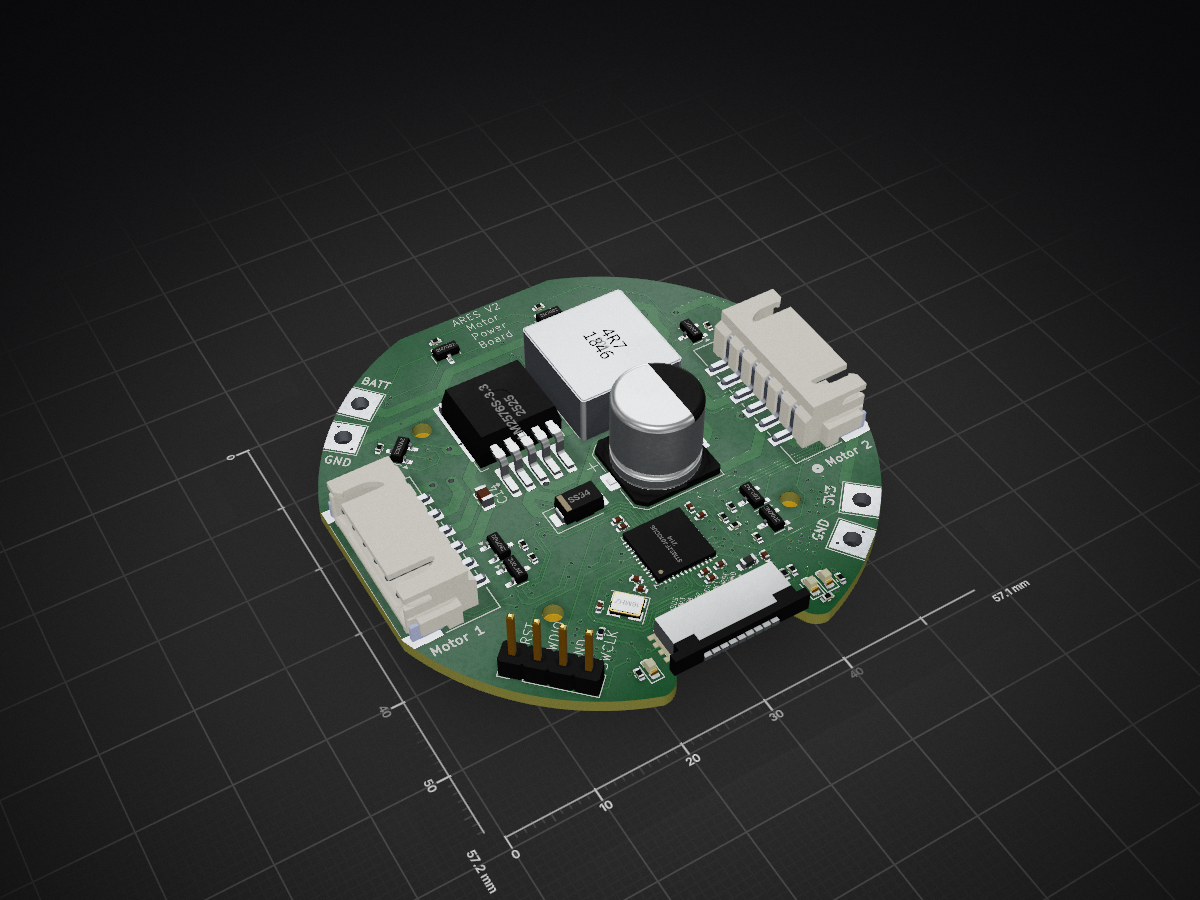
 explosion33/ARES1
SARP Payload ARES 2024-2025
Motor control design is an open-source printed circuit board by explosion33, from the explosion33/ARES repository on GitHub, published under the MIT licence. It is a 2-layer board of 57.1 × 57.2 mm with 83 parts on 61 nets, routed with 861 tracks and 179 vias.
It is built around the STM32F401CCU6, LM2576S-3.3 and SS34. Its parts include 24 resistors, 16 transistors, 13 capacitors, 12 diodes and 8 connectors. It belongs with the robots and motor control boards and the STM32 boards of this library.


SARP 2023 RCS Flight Controller KiCAD project

| Qty | Value | Footprint | References |
|---|---|---|---|
| 19 | 1k | Resistor_SMD:R_0402_1005Metric | R4, R5, R6, R10, R13, R14, R15, R16, R17, R18, R19, R20, R21, R22, R23, R24 +3 |
| 9 | SS34 | Diode_SMD:D_SMA | D4, D5, D6, D7, D8, D9, D10, D11, D12 |
| 8 | 2N7002 | Package_TO_SOT_SMD:SOT-23 | Q4, Q5, Q8, Q10, Q11, Q12, Q13, Q16 |
| 4 | , , , | ||
| 4 | 100nF | Capacitor_SMD:C_0402_1005Metric | C3, C4, C6, C8 |
| 4 | IRLZ44NS | Package_TO_SOT_SMD:TO-263-2 | Q3, Q7, Q9, Q15 |
| 4 | RF1S9540SM | Package_TO_SOT_SMD:TO-263-2 | Q1, Q2, Q6, Q14 |
| 3 | LED | LED_SMD:LED_0603_1608Metric | D1, D2, D3 |
| 2 | 10k | Resistor_SMD:R_0402_1005Metric | R3, R12 |
| 2 | 10pF | Capacitor_SMD:C_0402_1005Metric | C2, C5 |
| 2 | 1uF | Capacitor_SMD:C_0402_1005Metric | C10, C11 |
| 2 | 4.7k | Resistor_SMD:R_0402_1005Metric | R1, R2 |
| 2 | Conn_01x06 | JST-XH-SMD:CONN_S6B-XH-SM4-TB_JST | J6, J8 |
| 2 | GND | TestPoint:TestPoint_THTPad_4.0x4.0mm_Drill2.0mm | J4, J9 |
| 1 | 1000uF | Capacitor_SMD:CP_Elec_10x10.5 | C15 |
| 1 | 100uF | Capacitor_SMD:C_0805_2012Metric | C14 |
| 1 | 100uH | Inductor_SMD:L_TaiTech_TMPC1265_13.5x12.5mm | L1 |
| 1 | 10nF | Capacitor_SMD:C_0402_1005Metric | C9 |
| 1 | 10uF | Capacitor_SMD:C_0402_1005Metric | C1 |
| 1 | 120R | Inductor_SMD:L_0603_1608Metric | FB1 |
| 1 | 16MHz | Crystal:Crystal_SMD_3225-4Pin_3.2x2.5mm | Y1 |
| 1 | 2.2uF | Capacitor_SMD:C_0402_1005Metric | C7 |
| 1 | 29.4k | Resistor_SMD:R_0402_1005Metric | R11 |
| 1 | 3V3 | TestPoint:TestPoint_THTPad_4.0x4.0mm_Drill2.0mm | J10 |
| 1 | FC_M/P | Connector_FFC-FPC:Molex_200528-0080_1x08-1MP_P1.00mm_Horizontal | J5 |
| 1 | LM2576S-3.3 | Package_TO_SOT_SMD:TO-263-5_TabPin3 | U3 |
| 1 | LOGO | LOGO | G*** |
| 1 | STM32F401CCU6 | Package_DFN_QFN:QFN-48-1EP_7x7mm_P0.5mm_EP5.6x5.6mm | U1 |
| 1 | SWD | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J2 |
| 1 | VBAT | TestPoint:TestPoint_THTPad_4.0x4.0mm_Drill2.0mm | J3 |


nmduc9624/fruit-quality-detection-and-sorting-system
A complete personal engineering project built and validated from February to May 2026. The system combines edge computer vision, embedded firmware, custom electronics, a real conveyor and a Flutter monitoring…

Riskerx/QUADCOPTER
QuadCopter Rev B: STM32F401 four-layer flight-controller PCB, manufacturing files, hardware documentation and firmware integration plan.

jayis1/hacker-devices
Full-cycle hardware designs for security research devices — each device is a subfolder with its own README, schematics, PCB layout, and software stack
It measures 57.1 × 57.2 mm and has 2 copper layers, 1.6 mm thick.
83 parts, built around the STM32F401CCU6, LM2576S-3.3 and SS34. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the explosion33/ARES repository on GitHub, at the commit this page was made from: the board is Hardware/motor_control_design/motor_control_design.kicad_pcb and its schematic Hardware/Flight_Computer/ARES_FC.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
