4 layers88.1 × 59.4 mm
Chromapi motherboard v1
Mowibox/chromapi_motherboard
Raspberry Pi control HAT dedicated to the quadruped robot Chromapi.
139 parts2Apache-2.0
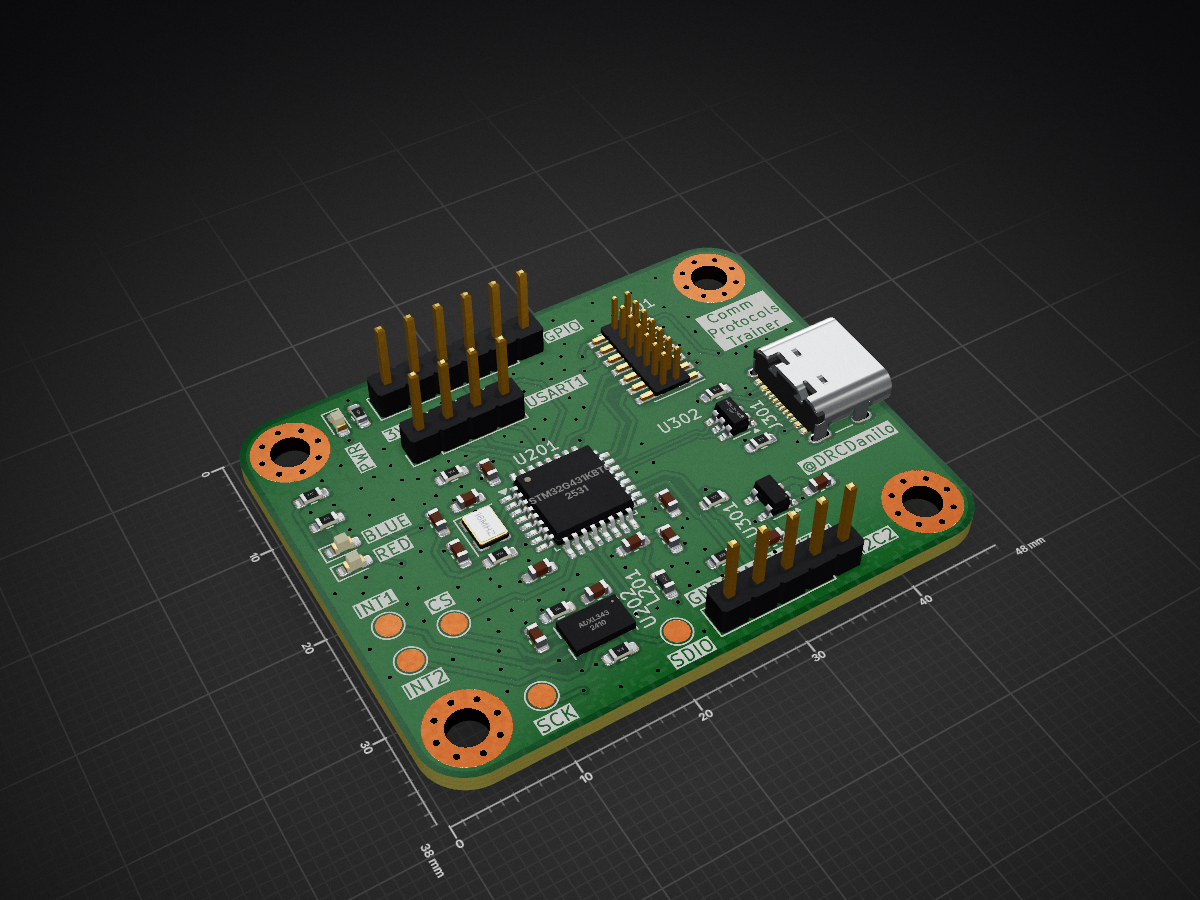
 DRCDanilo/CommTrainer_PCB
PCB with STM32G431KBT6 microcontroller and ADXL343 accelerometer, to work with USB, SPI, I2C and UART communication protocols.
Tuto kicad is an open-source printed circuit board by DRCDanilo, from the DRCDanilo/CommTrainer_PCB repository on GitHub. It is a 4-layer board of 48 × 38 mm with 46 parts on 50 nets, routed with 374 tracks and 149 vias.
It is built around the STM32G431KBT6, ADXL343BCC and MIC5317-3.3YM5-TR, with the USBLC6-2SC6 among its other parts. Its parts include 12 capacitors, 11 resistors, 4 ICs, 3 diodes and 3 connectors. It belongs with the STM32 boards of this library.


| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | 1uF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C205, C206, C301, C302 |
| 4 | MountingHole_Pad | MountingHole:MountingHole_3.2mm_M3_Pad_Via | H101, H102, H103, H104 |
| 3 | 1k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R206, R207, R208 |
| 2 | 100nF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C202, C203 |
| 2 | 10pF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C207, C208 |
| 2 | 2K2 | Resistor_SMD:R_0603_1608Metric | R203, R204 |
| 2 | 5k1 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R301, R302 |
| 1 | 100 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R205 |
| 1 | 100k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R202 |
| 1 | 100nF | Capacitor_SMD:C_0603_1608Metric | C210 |
| 1 | 10R | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R201 |
| 1 | 10k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R209 |
| 1 | 10nF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C204 |
| 1 | 10uF | Capacitor_SMD:C_0603_1608Metric | C209 |
| 1 | 16MHz | Crystal:Crystal_SMD_EuroQuartz_MT-4Pin_3.2x2.5mm | Y201 |
| 1 | 4n9 | Inductor_SMD:L_0603_1608Metric_Pad1.05x0.95mm_HandSolder | L201 |
| 1 | 4u7F | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C201 |
| 1 | ADXL343 | Package_LGA:LGA-14_3x5mm_P0.8mm_LayoutBorder1x6y | U202 |
| 1 | BLUE | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D203 |
| 1 | CS | TestPoint:TestPoint_Pad_D2.0mm | CS201 |
| 1 | Conn_ST_STDC14 | Connector_PinHeader_1.27mm:PinHeader_2x07_P1.27mm_Vertical_SMD | J201 |
| 1 | GPIO | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | J202 |
| 1 | GREEN | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D201 |
| 1 | I2C2 | Connector_PinHeader_2.54mm:PinHeader_1x05_P2.54mm_Vertical | I2C2 |
| 1 | INT1 | TestPoint:TestPoint_Pad_D2.0mm | INT201 |
| 1 | INT2 | TestPoint:TestPoint_Pad_D2.0mm | INT202 |
| 1 | MIC5317-3.3YM5-TR | Package_TO_SOT_SMD:SOT-23-5 | U301 |
| 1 | RED | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D202 |
| 1 | SCK | TestPoint:TestPoint_Pad_D2.0mm | SCK201 |
| 1 | SDIO | TestPoint:TestPoint_Pad_D2.0mm | SDIO201 |
| 1 | STM32G431KBT6 | Package_QFP:LQFP-32_7x7mm_P0.8mm | U201 |
| 1 | UART1 | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | USART1 |
| 1 | USBLC6-2SC6 | Package_TO_SOT_SMD:SOT-23-6 | U302 |
| 1 | USB_C_Receptacle_USB2.0_16P | Connector_USB:USB_C_Receptacle_GCT_USB4105-xx-A_16P_TopMnt_Horizontal | J301 |
It measures 48 × 38 mm and has 4 copper layers, 1.6 mm thick.
46 parts, built around the STM32G431KBT6, ADXL343BCC, MIC5317-3.3YM5-TR and USBLC6-2SC6. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the DRCDanilo/CommTrainer_PCB repository on GitHub, at the commit this page was made from: the board is tuto_kicad.kicad_pcb and its schematic stm32.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask DRCDanilo before reusing the design.
Mowibox/chromapi_motherboard
Raspberry Pi control HAT dedicated to the quadruped robot Chromapi.


enkhbold470/spinner
12-24 V FOC BLDC motor controller: STM32G431, three IR2104 half bridges with 60 V MOSFETs, MT6701 encoder, CAN FD. 4-layer KiCad 10 board.

frangipp/TANK-PCB
Projet étudiant réalisé en binôme à l’ESEO Angers, ce TANK est un robot mobile à entraînement différentiel, piloté en Bluetooth via une application Android.


theocond48/2526_Projet1A_PcBot_G5
Le schéma ci-dessous illustre l'organisation du système. Le microcontrôleur (MCU) agit comme le cerveau central, coordonnant les capteurs (entrées), les actionneurs (sorties) et la communication.