2 layers127 × 110 mm
UNICON board
dodotronix/RobotClaire
This project is focused on a design of an autonomous robot including its electronics and basic software to present robot's features
132 parts

 dodotronix/RobotClaire
This project is focused on a design of an autonomous robot including its electronics and basic software to present robot's features
ROBarm is an open-source printed circuit board by dodotronix, from the dodotronix/RobotClaire repository on GitHub. It is a 2-layer board of 46 × 52 mm with 14 parts on 16 nets, routed with 68 tracks and 0 vias.
Its parts include 6 connectors, 3 switches, 1 resistor and 1 diode. It belongs with the robots and motor control and sensors and measurement boards of this library.
This project is the result of three years of development from my high school years. The main goal was to build my own robot from scratch, without using common construction parts that are readily available in many hobbyist shops today.
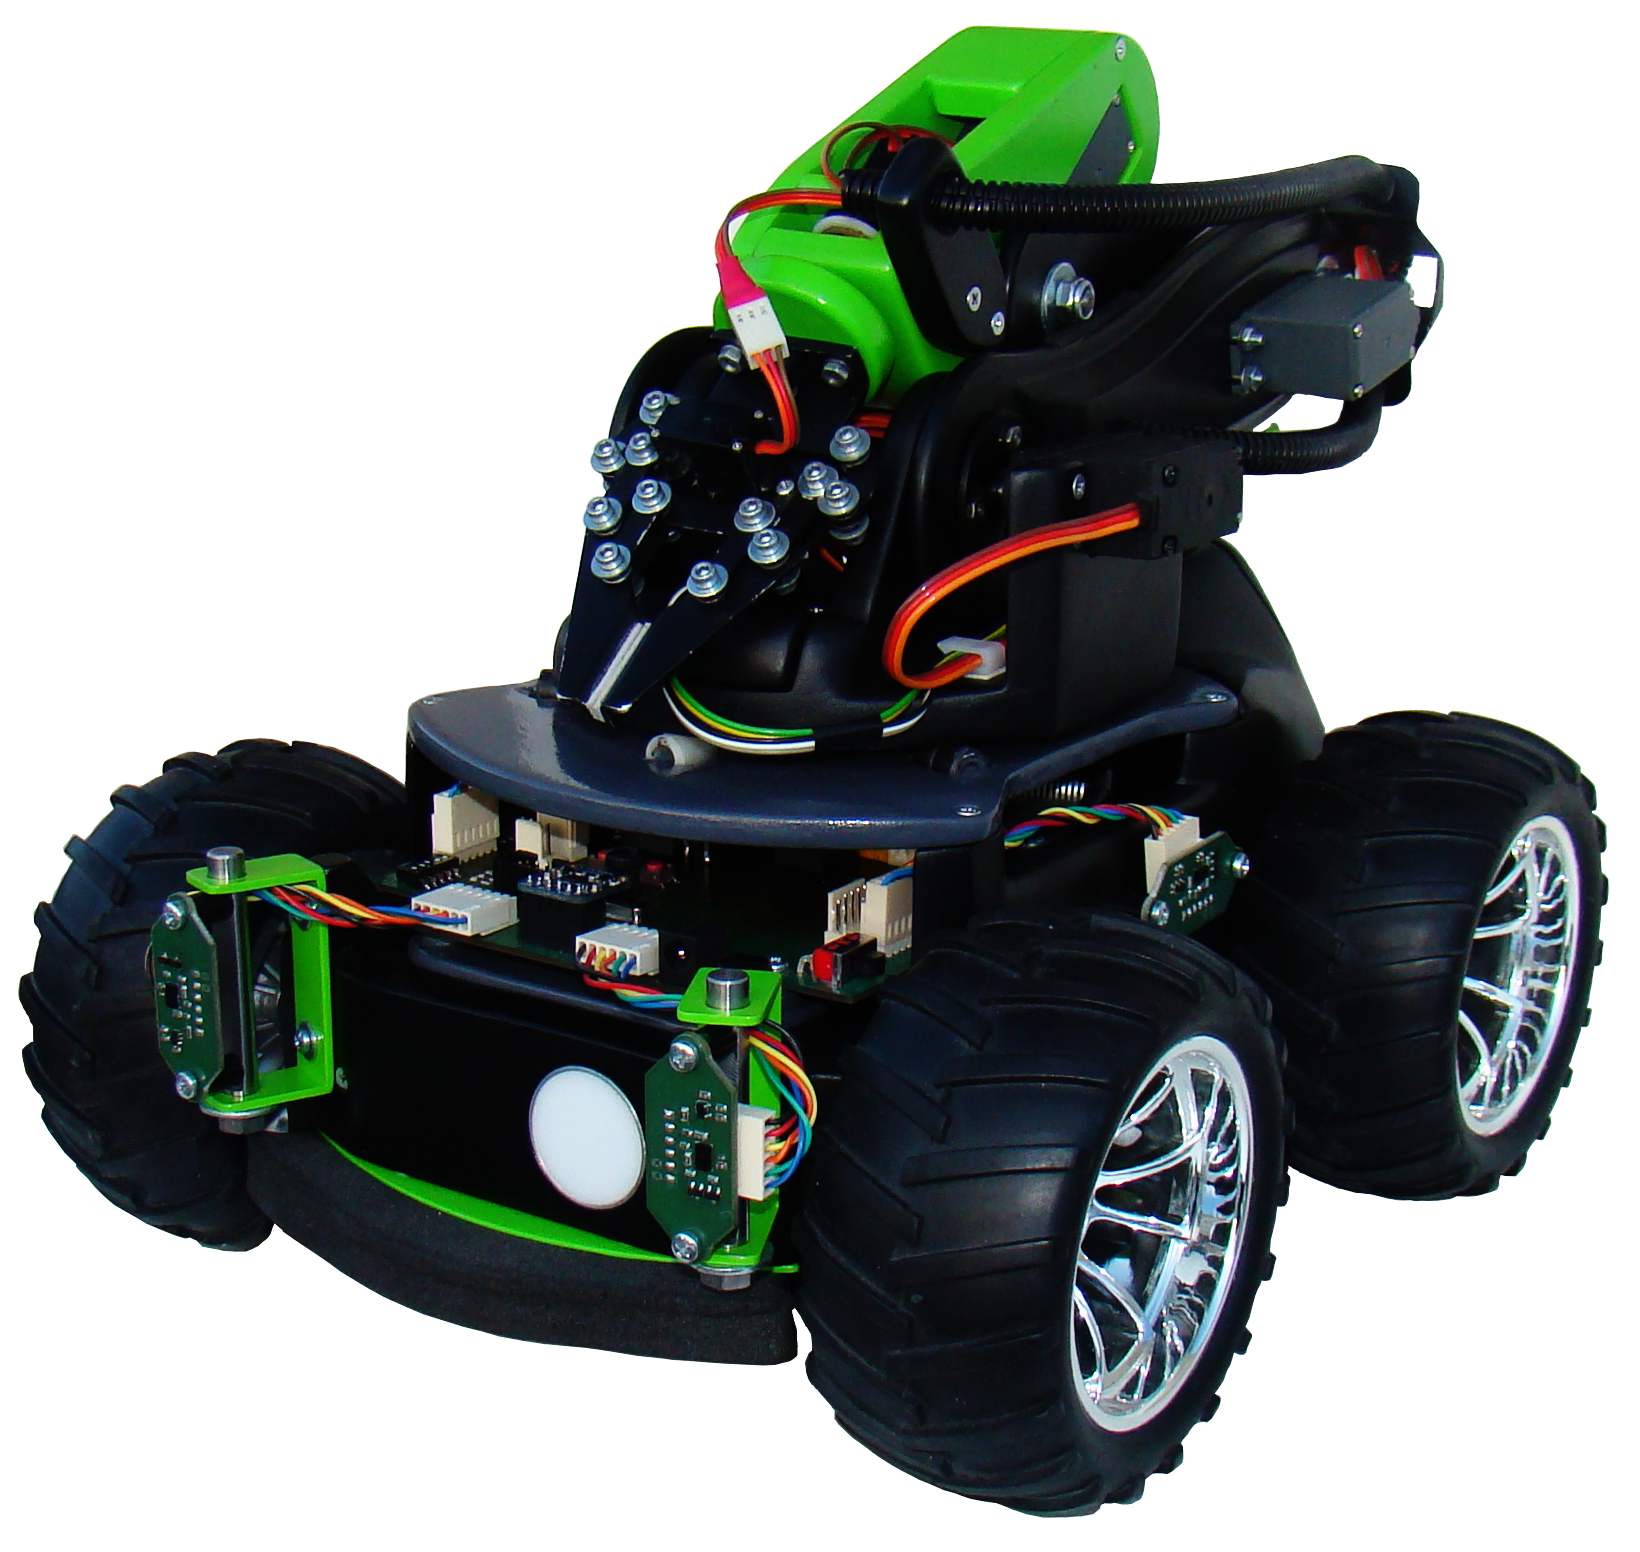 At the time when I was creating my robot, open-source CAD programs weren’t at a
sufficient level to design something that could be sent to a factory for
fabrication. For this reason, the mechanical design was created using Inventor
2013, while the electronic design was done using KiCad. The project has already
gone through three upgrades, but the first one wasn’t documented. However, I
did take some photos to capture the atmosphere of the very first steps in
development (claire-rev0).
In the following folders, you will find README.md files with more detailed descriptions of the content. Some folders also include additional information, such as installation and execution instructions, particularly in directories containing software. Please note that this repository is still under development, and not all folders have been fully uploaded yet.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 5 | CONN_6 | w_pin_strip:pin_strip_6 | P2, P3, P4, P5, P6 |
| 2 | CONN_3 | w_pin_strip:pin_strip_3 | K2, K3 |
| 1 | CONN_2 | w_pin_strip:pin_strip_2-90 | P1 |
| 1 | CONN_3 | w_pin_strip:pin_strip_3-90 | K1 |
| 1 | LED | w_smd_leds:Led_0603 | D1 |
| 1 | R | libcms:SM0805 | R1 |
The 11 most common of 14 parts.
dodotronix/RobotClaire
This project is focused on a design of an autonomous robot including its electronics and basic software to present robot's features

dodotronix/RobotClaire
This project is focused on a design of an autonomous robot including its electronics and basic software to present robot's features

dodotronix/RobotClaire
This project is focused on a design of an autonomous robot including its electronics and basic software to present robot's features

dodotronix/RobotClaire
This project is focused on a design of an autonomous robot including its electronics and basic software to present robot's features

google/mozc-devices
Circuit diagrams and firmware source code for Gboard DIY keyboards


hackclub/OnBoard
💡 Join 1,000 teenagers and make your first PCB with a $100 grant!


Twotoz/C5VRX
Ultra-minimal, zero-CPU 5.8 GHz analog FPV video receiver using ESP32-C5 Wi-Fi 6 PHY MODEM_DIAG, BitScrambler WBFM demodulation & resistor DAC CVBS


It measures 46 × 52 mm and has 2 copper layers, 1.6 mm thick.
14 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the dodotronix/RobotClaire repository on GitHub, at the commit this page was made from: the board is electronics/roboarm/ROBarm.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask dodotronix before reusing the design.