
4 layers106 × 98 mm
Motion control
menloresearch/asimov-1
v1 of Asimov, an open-source humanoid robot
76 parts1.4kCERN-OHL-S-2.0

 disdi/canpmod
CAN PMOD is a 3.3 V SN65HVD230 CAN transceiver module, based on the Waveshare SN65HVD230 CAN board. The host must provide the CAN protocol controller.
Canpmod is an open-source printed circuit board by disdi, from the disdi/canpmod repository on GitHub, published under the MIT licence. It is a 2-layer board of 37.6 × 18.5 mm with 12 parts on 17 nets, routed with 41 tracks and 1 via.
It is built around the SN65HVD230D. Its parts include 5 resistors, 3 capacitors, 2 connectors and 1 IC.
CAN PMOD is a 3.3 V SN65HVD230 CAN transceiver module, based on the Waveshare SN65HVD230 CAN board. The host must provide the CAN protocol controller.
The project is KiCad 9.0.8. Open kicad/canpmod.kicad_pro. The two-layer, 1.6 mm board has 12 components and keeps its original outline and component placement.
This revision corrects the PMOD footprint's physical numbering, reroutes the affected nets, adds local connector footprints, and refreshes silkscreen and library symbols. ERC reports 0 errors and 0 warnings. DRC with schematic parity reports 0 violations and 0 unconnected items.
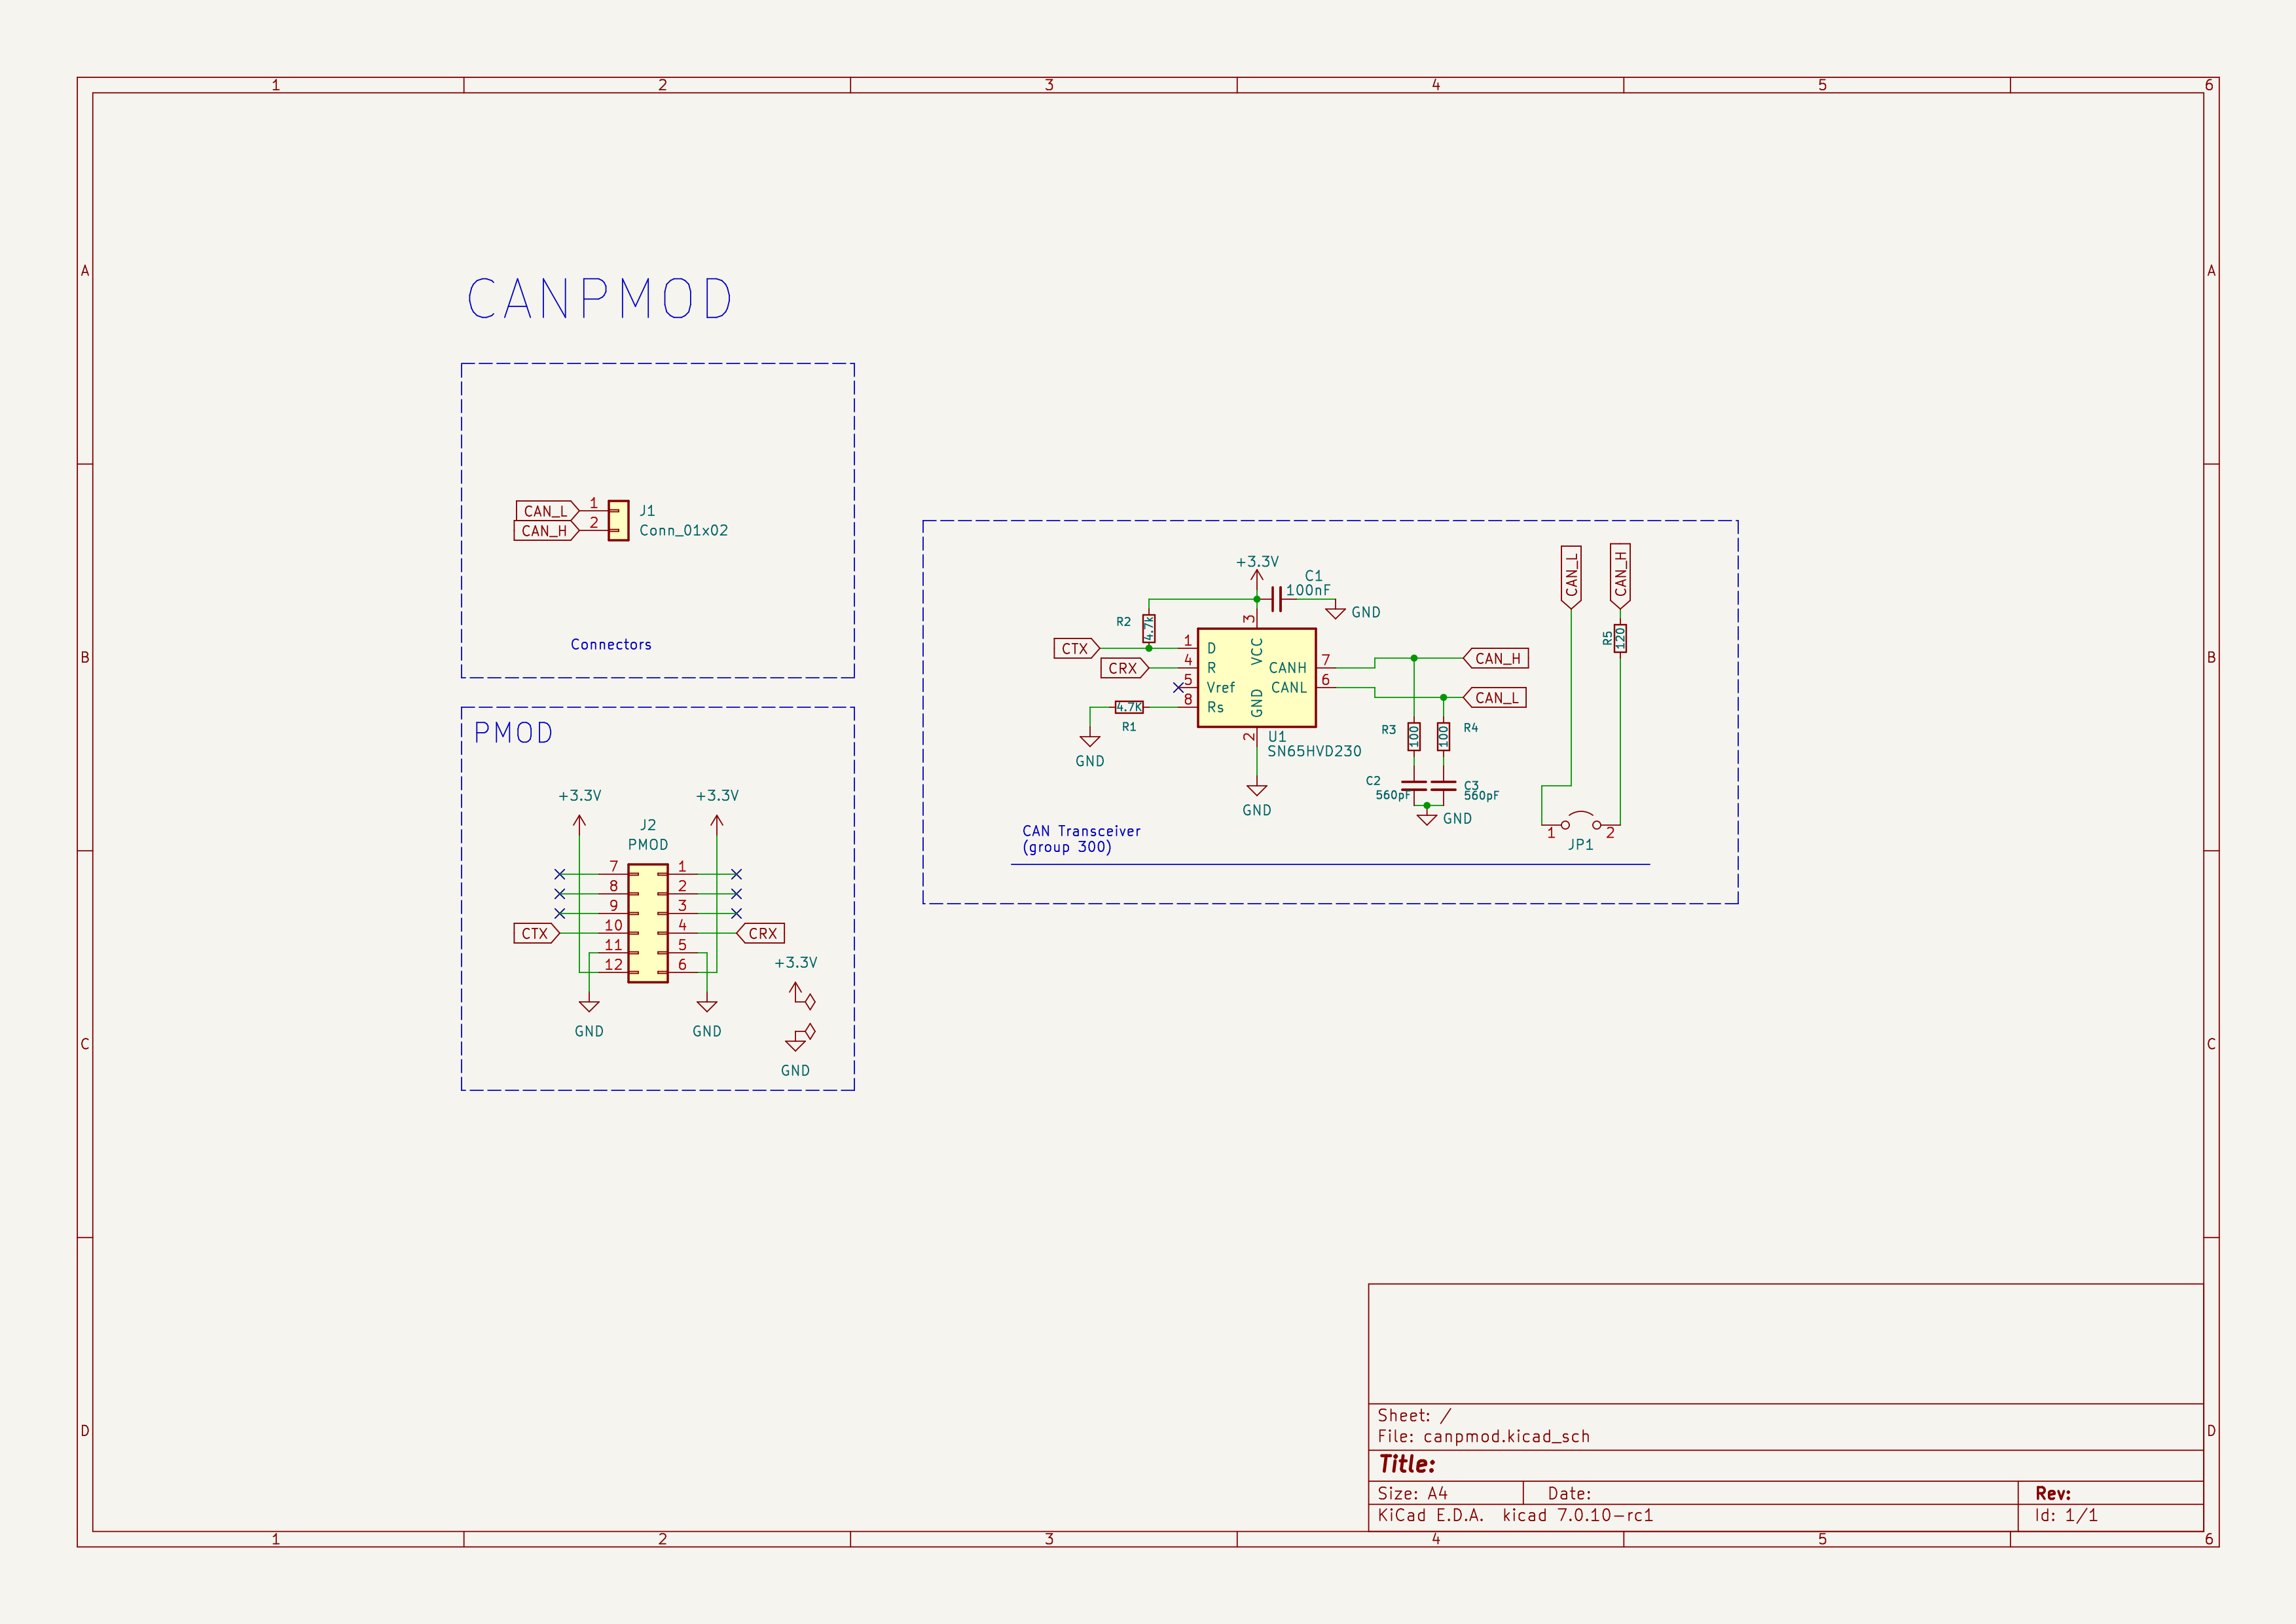
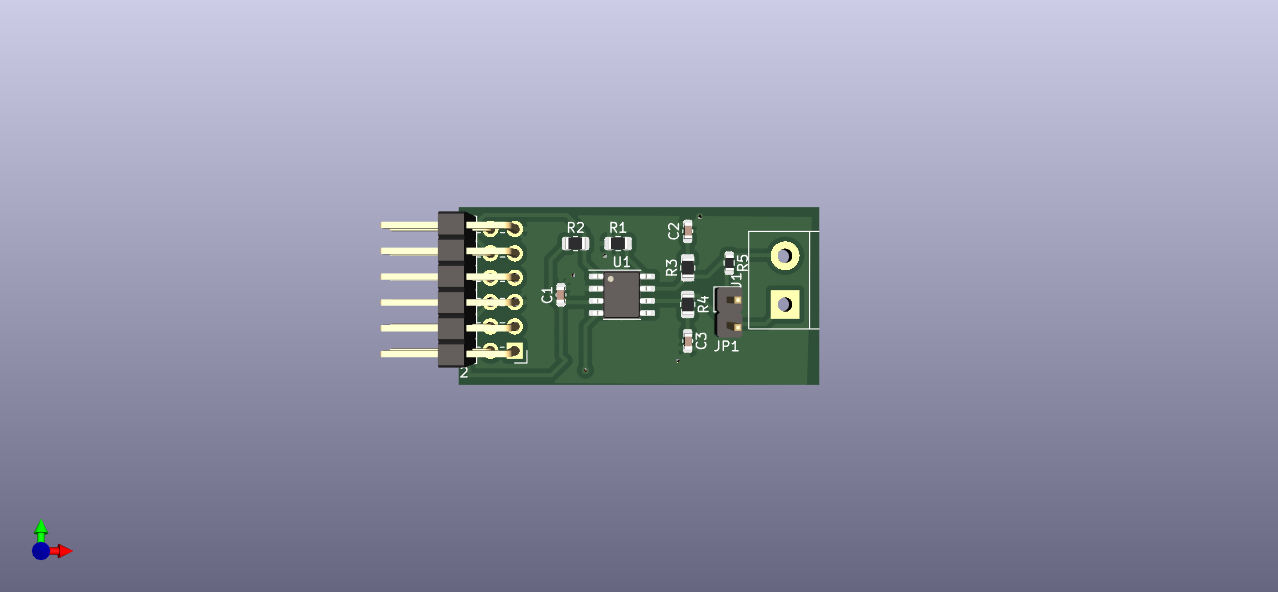
The photographs above show the original board. They remain in img/ as
historical images.
J2 is the right-angle male PMOD header. Viewed from the PCB top with its plug pointing left, pins 1–6 run top to bottom in the inboard row; pins 7–12 run top to bottom in the outboard row. Pin 1 is square and marked on silkscreen.
| PMOD pin | Signal | Function |
|---|---|---|
| 1 | NC | Unconnected |
| 2 | NC | Unconnected |
| 3 | NC | Unconnected |
| 4 | CAN RX | CAN receive (input to host) |
| 5 | GND | Ground |
| 6 | 3.3 V | Supply from host |
| 7 | NC | Unconnected |
| 8 | NC | Unconnected |
| 9 | NC | Unconnected |
| 10 | CAN TX | CAN transmit (output from host) |
| 11 | GND | Ground |
| 12 | 3.3 V | Supply from host |
J1 is the 5.08 mm-pitch CAN terminal: pin 1 CAN_L, pin 2 CAN_H. JP1 enables the 120 Ω termination when a shunt is fitted.
R1 is the 4.7 kΩ slope-control resistor. R2 pulls TX high. C1 is the 100 nF supply bypass. R3/C2 and R4/C3 are 100 Ω / 560 pF series RC branches from each bus line to ground.
| Path | Role |
|---|---|
| kicad/canpmod.kicad_pro | KiCad 9 project |
| kicad/canpmod.kicad_sch | Schematic |
| kicad/canpmod.kicad_pcb | Board |
| kicad/fp-lib-table | Local footprint table (${KIPRJMOD}) |
| kicad/libs/canpmod.pretty/PMOD_2x06_Horizontal.kicad_mod | Corrected PMOD 2×6 land |
| kicad/libs/canpmod.pretty/TerminalBlock_bornier-2_P5.08mm.kicad_mod | 5.08 mm CAN terminal land |
| kicad/output_files/BOM-canpmod.csv | BOM, 12 components |
| kicad/output_files/CPL-canpmod.csv | Pick-and-place |
| kicad/output_files/gerbers/ | Gerbers and drill for this board |
kicad/output_files/GERBER-canpmod.zip is the earlier KiCad 7 Gerber package.
Use the gerbers/ directory for the KiCad 9 board.
J2 needs a manufactured right-angle 2×6 header matched to the footprint. Exact connector MPNs, passive ratings, assembler acceptance, and bench validation remain open. Clean ERC/DRC is not fabrication approval.
License: MIT, copyright 2024 disdi.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 2 | 100 | Resistor_SMD:R_0805_2012Metric | R3, R4 |
| 2 | 560pF | Capacitor_SMD:C_0603_1608Metric | C2, C3 |
| 1 | 100nF | Capacitor_SMD:C_0603_1608Metric | C1 |
| 1 | 120 | Resistor_SMD:R_0603_1608Metric | R5 |
| 1 | 4.7K | Resistor_SMD:R_0805_2012Metric | R1 |
| 1 | 4.7k | Resistor_SMD:R_0805_2012Metric | R2 |
| 1 | Conn_01x02 | canpmod:TerminalBlock_bornier-2_P5.08mm | J1 |
| 1 | Jumper_2_Open | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | JP1 |
| 1 | PMOD | canpmod:PMOD_2x06_Horizontal | J2 |
| 1 | SN65HVD230 | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U1 |
It measures 37.6 × 18.5 mm and has 2 copper layers, 1.6 mm thick.
12 parts, built around the SN65HVD230D. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the disdi/canpmod repository on GitHub, at the commit this page was made from: the board is kicad/canpmod.kicad_pcb and its schematic kicad/canpmod.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
menloresearch/asimov-1
v1 of Asimov, an open-source humanoid robot

tenderlove/initial-v
It's a BMW shifter converted to a Bluetooth Keyboard that you use with Vim


hirakuni45/RX
Renesas RX Microcontroller, C++ framework, Library, Sample

henrikssn/TurboCAN
This is the official repository for the TurboCAN controller board, designed specifically for the Voron AfterBurner toolhead but can also be used on similar toolheads using NEMA17 steppers.

VIPQualityPost/lemon-pepper-stepper
simplefoc all-in-one 50W hybrid stepper + bldc driver

luftaquila/monolith
DIY wireless real-time datalogging platform for Student Formula and Baja.