2 layers216.9 × 86.8 mm
Sweepv2
davidphilipbarr/Sweep
Sweep - a small promicro based keyboard inspired by the Ferris.
51 parts2.1k

 Diegolox/TheBUG011
This project is a custom all-in-one PCB for a two-wheel differential drive robot, designed to be plug-and-play and easy to integrate into new robotics prototypes. The board brings together the key building blocks needed for motion control and autonomous navigation, so you can focus on software and algorithms instead of wiring and power integration.
TheBUG01 is an open-source printed circuit board by Diegolox, from the Diegolox/TheBUG01 repository on GitHub. It is a 2-layer board of 100 × 94 mm with 51 parts on 53 nets, routed with 215 tracks and 157 vias.
Its parts include 11 diodes, 9 connectors, 7 resistors and 5 capacitors. It belongs with the robots and motor control boards and the ESP32 boards of this library.
This project is a custom all-in-one PCB for a two-wheel differential drive robot, designed to be plug-and-play and easy to integrate into new robotics prototypes. The board brings together the key building blocks needed for motion control and autonomous navigation, so you can focus on software and algorithms instead of wiring and power integration.
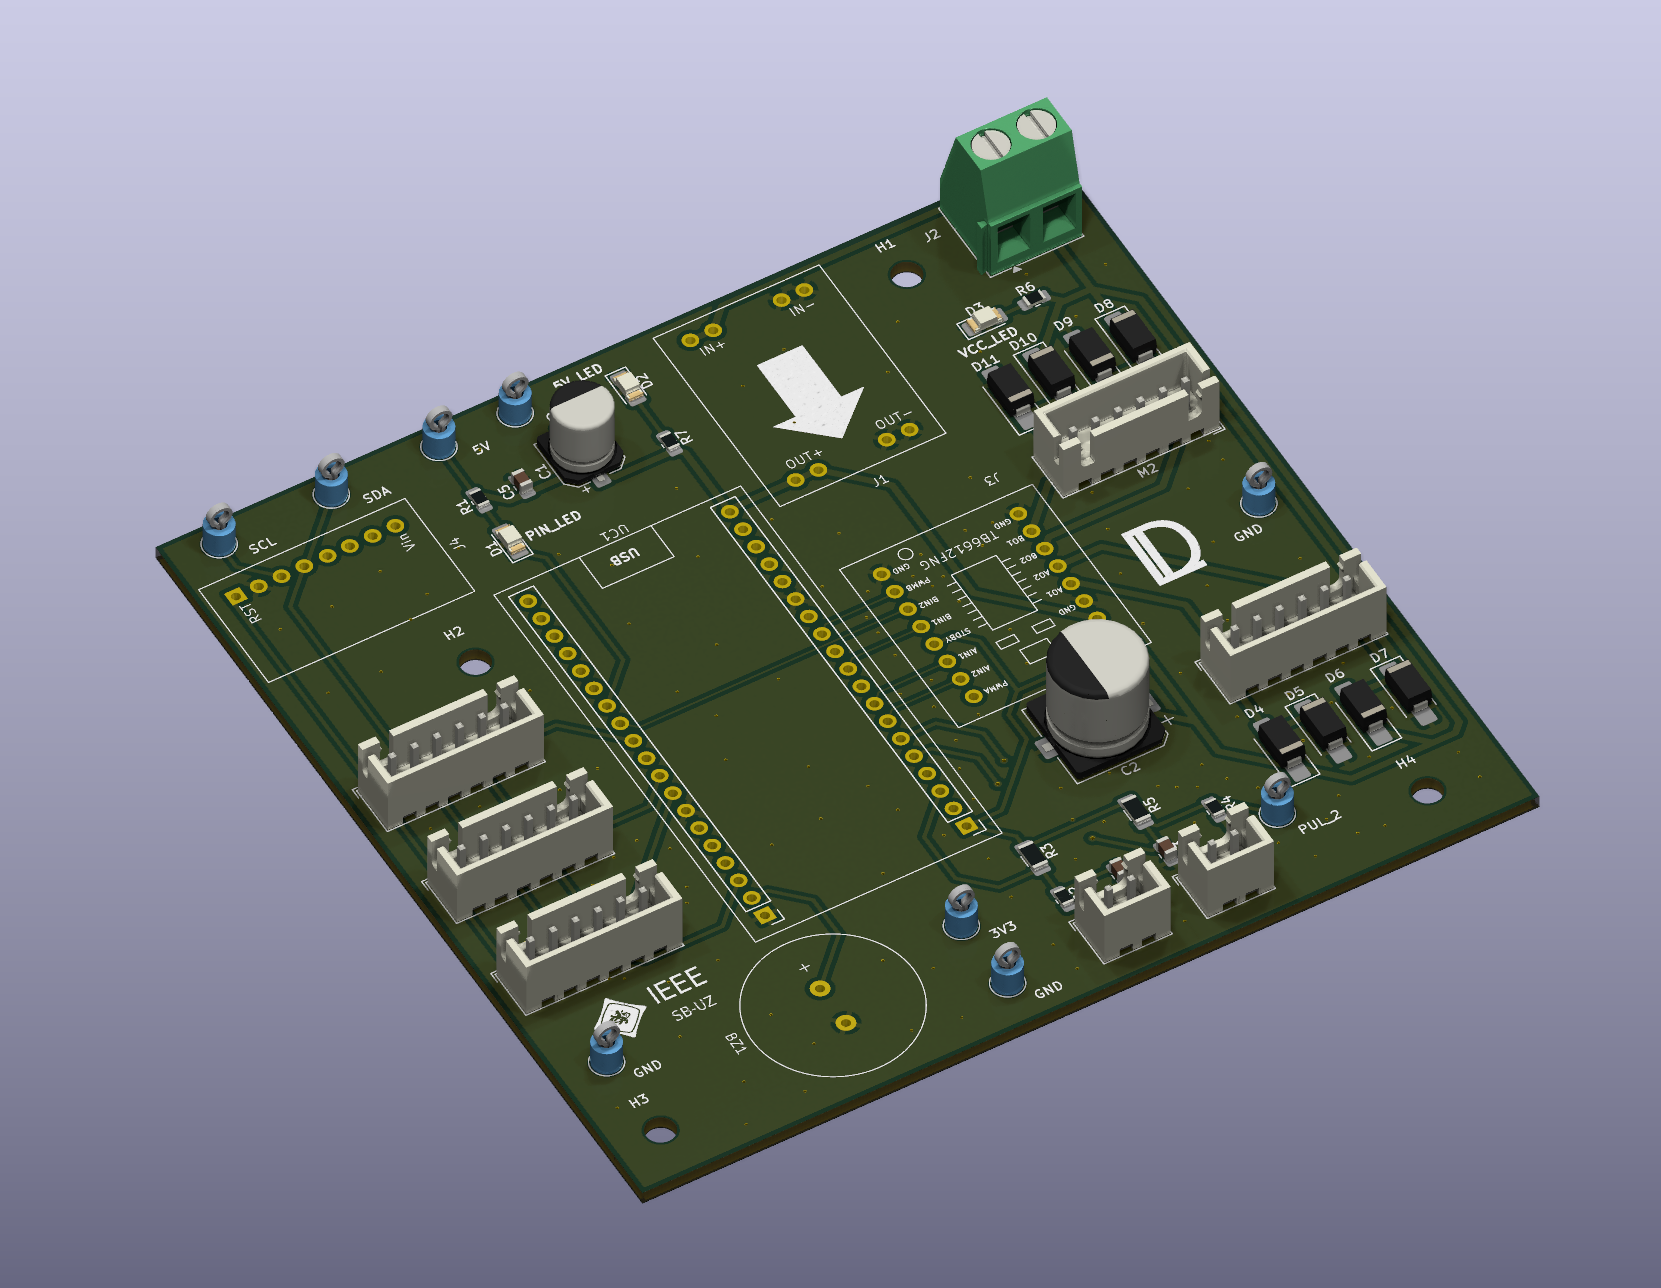
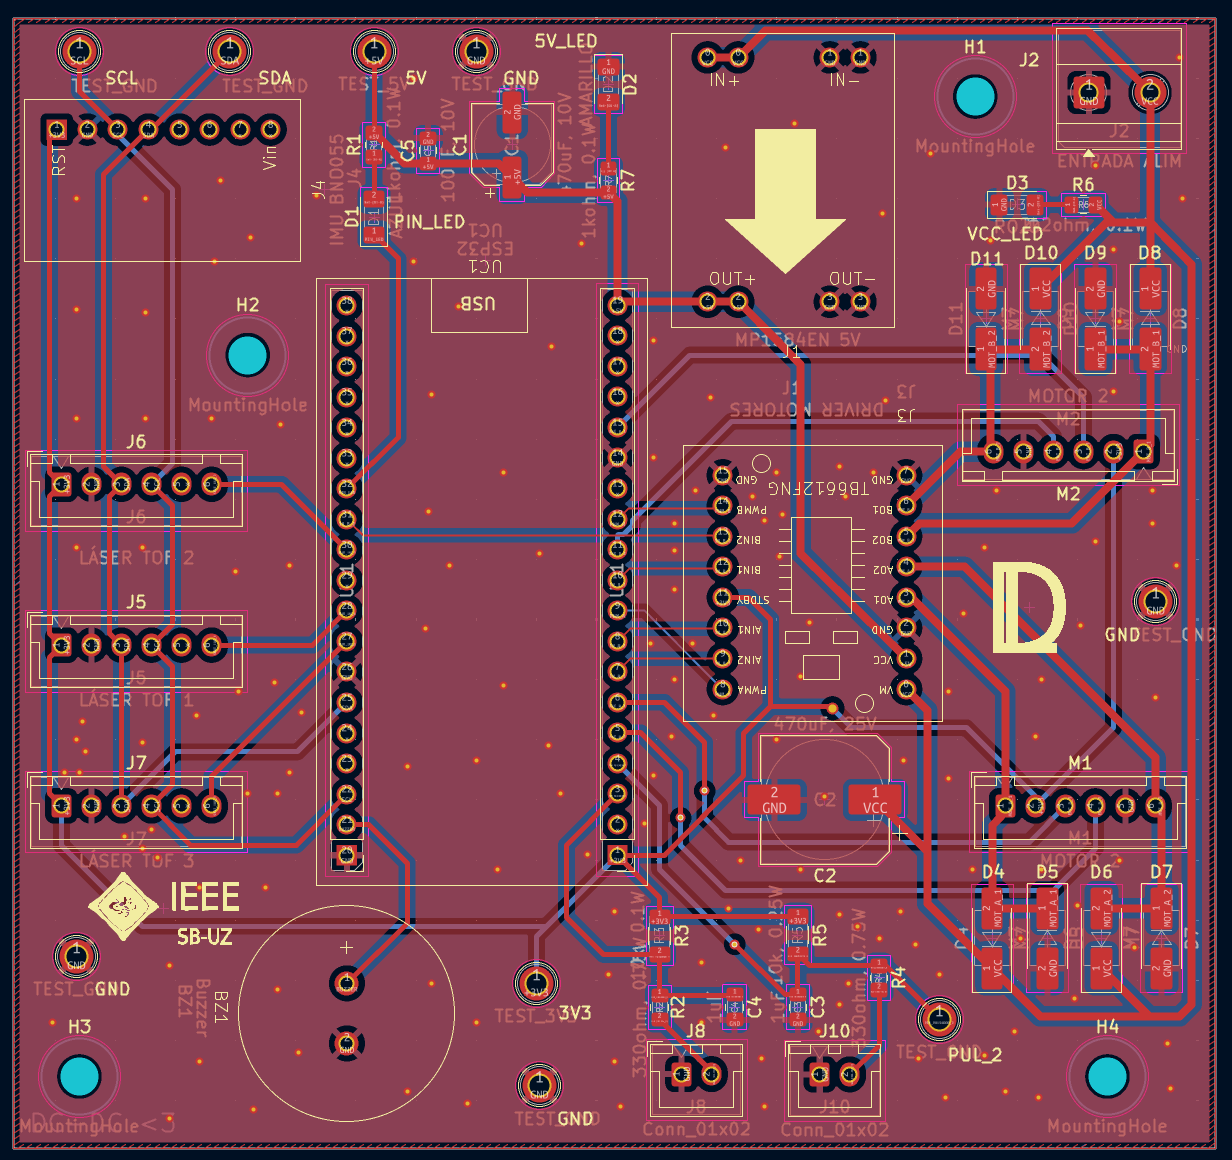
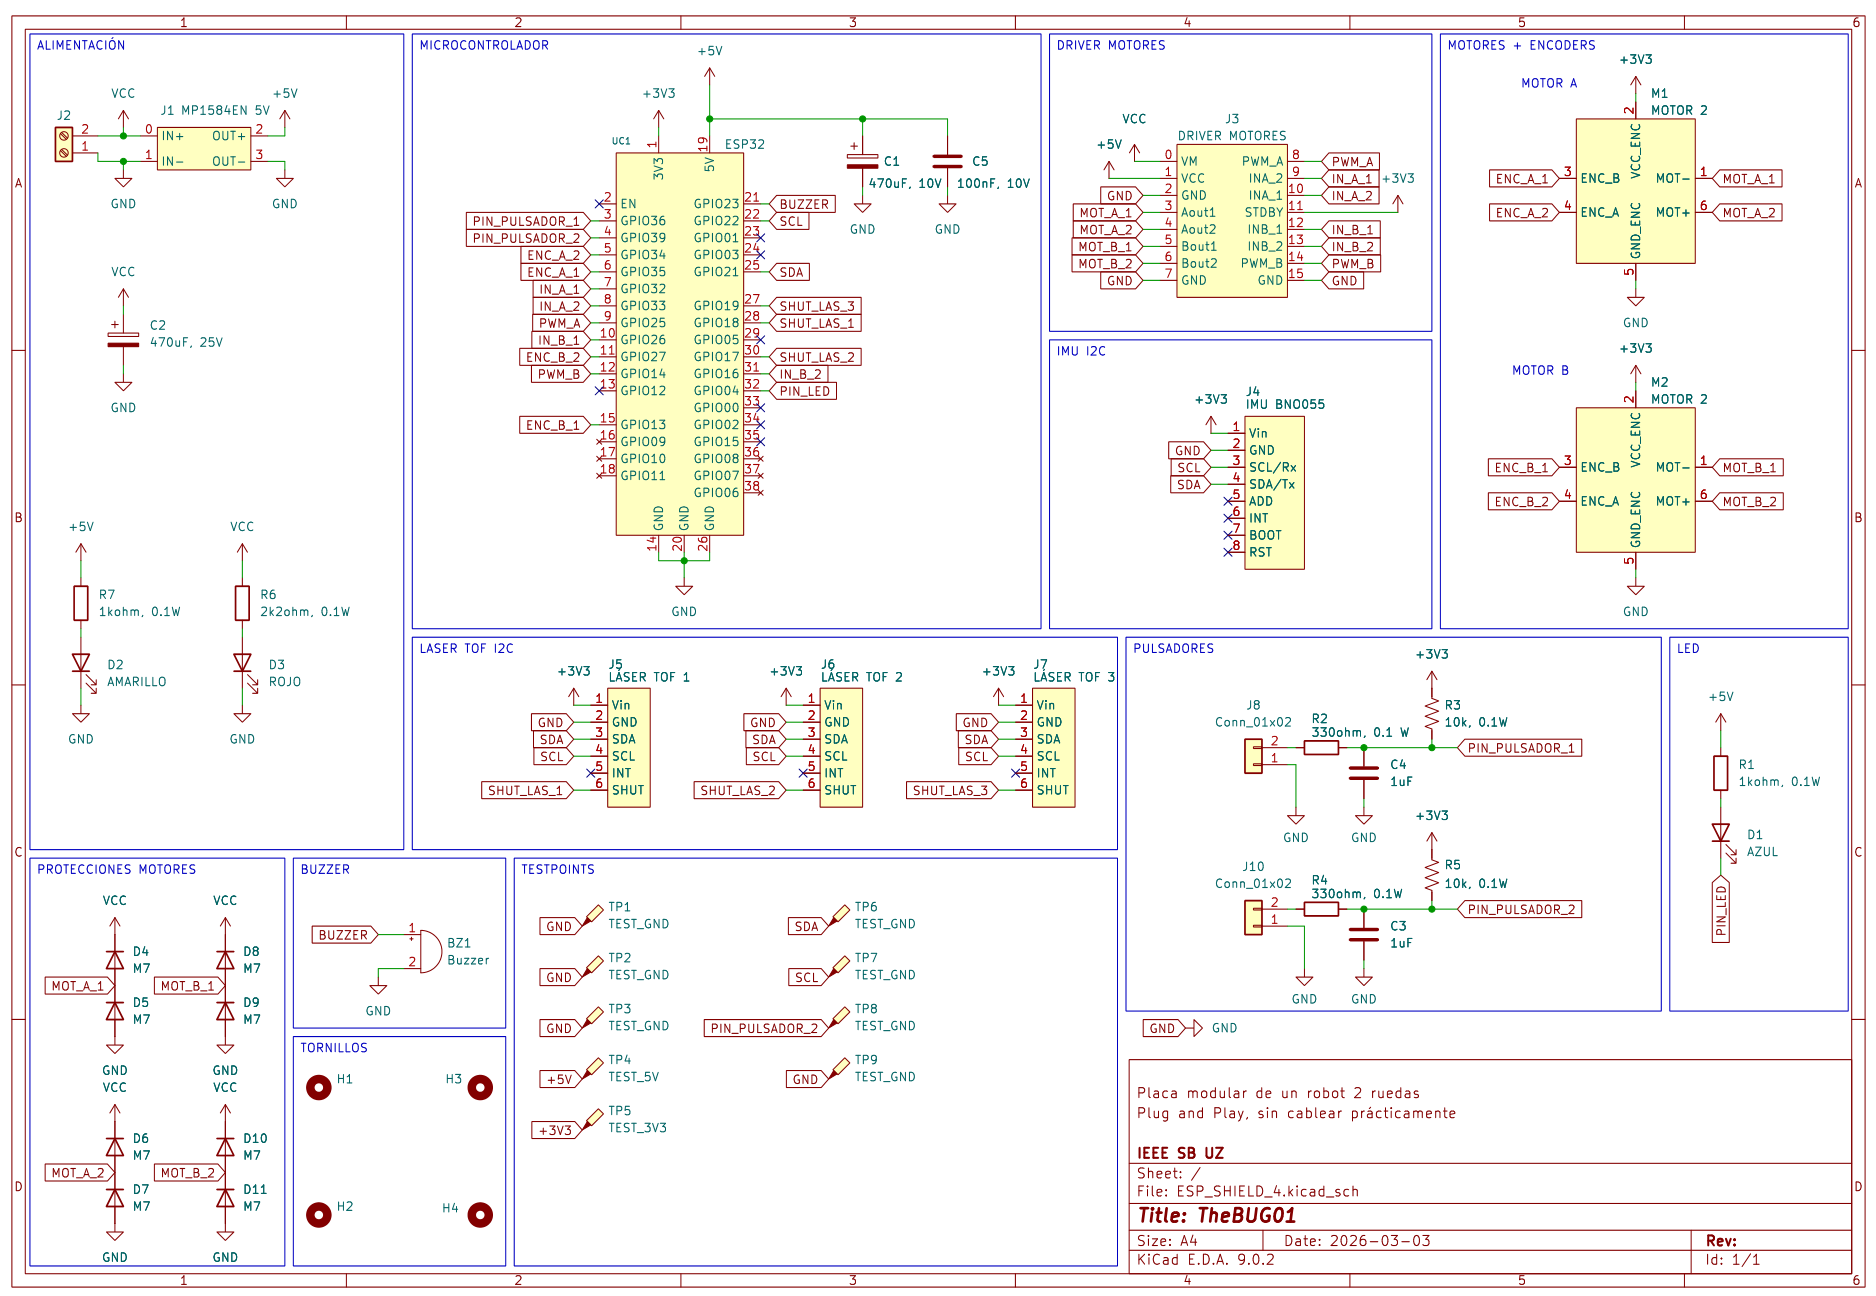
The goal of this PCB is to provide a compact robotics platform with everything integrated: power regulation, sensing, motor driving, and basic user I/O. With this hardware, you can quickly implement and iterate on:
Este proyecto es una PCB todo-en-uno para un robot diferencial de dos ruedas, pensada para ser plug-and-play y facilitar el desarrollo rápido de prototipos. La placa integra los bloques principales necesarios para control de movimiento y navegación autónoma, evitando cableado extra y problemas de integración de potencia.
El objetivo es ofrecer una plataforma compacta con todo integrado: regulación de potencia, sensórica, driver de motores y E/S básica. Con este hardware se pueden implementar de forma rápida:
| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | M7 | Diode_SMD:D_SMA_Handsoldering | D4, D5, D6, D7, D8, D9, D10, D11 |
| 7 | TEST_GND | TestPoint:TestPoint_Keystone_5005-5009_Compact | GND, GND, GND, GND, PUL_2, SCL, SDA |
| 4 | MountingHole | MountingHole:MountingHole_3.2mm_M3 | H1, H2, H3, H4 |
| 2 | 1kohm, 0.1W | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R1, R7 |
| 2 | 1uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C3, C4 |
| 2 | 330ohm, 0.75W | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R2, R4 |
| 2 | Conn_01x02 | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J8, J10 |
| 2 | MOTOR 2 | Connector_JST:JST_XH_B6B-XH-A_1x06_P2.50mm_Vertical | M1, M2 |
| 1 | 100nF, 10V | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C5 |
| 1 | 10k, 0.1W | Resistor_SMD:R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R3 |
| 1 | 10k, 0.25W | Resistor_SMD:R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R5 |
| 1 | 2k2ohm, 0.1W | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R6 |
| 1 | 470uF, 10V | Capacitor_SMD:CP_Elec_6.3x7.7 | C1 |
| 1 | 470uF, 25V | Capacitor_SMD:CP_Elec_10x10.5 | C2 |
| 1 | AMARILLO | LED_SMD:LED_1206_3216Metric_Pad1.42x1.75mm_HandSolder | D2 |
| 1 | AZUL | LED_SMD:LED_1206_3216Metric_Pad1.42x1.75mm_HandSolder | D1 |
| 1 | Buzzer | TOOLS_DIEGO:BUZZER | BZ1 |
| 1 | DRIVER MOTORES | TOOLS_DIEGO:TB6612FNG | J3 |
| 1 | ENTRADA ALIM | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-2-5.08_1x02_P5.08mm_Horizontal | J2 |
| 1 | ESP32 | ESP32_TOOLS_DIEGO:ESP32_WROOM32_SHIELD_V01 | UC1 |
| 1 | IMU BNO055 | TOOLS_DIEGO:BNO055 | J4 |
| 1 | LOGO | LOGO_DL:LOGO_IEEE_SB_UZ_PCB_6mm | G*** |
| 1 | LOGO | LOGO_DL:LOGO_DL_6mm.pretty | G*** |
| 1 | LÁSER TOF 1 | Connector_JST:JST_XH_B6B-XH-A_1x06_P2.50mm_Vertical | J5 |
| 1 | LÁSER TOF 2 | Connector_JST:JST_XH_B6B-XH-A_1x06_P2.50mm_Vertical | J6 |
| 1 | LÁSER TOF 3 | Connector_JST:JST_XH_B6B-XH-A_1x06_P2.50mm_Vertical | J7 |
| 1 | MP1584EN 5V | TOOLS_DIEGO:MP1584 | J1 |
| 1 | ROJO | LED_SMD:LED_1206_3216Metric_Pad1.42x1.75mm_HandSolder | D3 |
| 1 | TEST_3V3 | TestPoint:TestPoint_Keystone_5005-5009_Compact | 3V3 |
| 1 | TEST_5V | TestPoint:TestPoint_Keystone_5005-5009_Compact | 5V |
It measures 100 × 94 mm and has 2 copper layers, 1.6 mm thick.
51 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Diegolox/TheBUG01 repository on GitHub, at the commit this page was made from: the board is TheBUG01_PCB/TheBUG01.kicad_pcb and its schematic TheBUG01_PCB/TheBUG01.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask Diegolox before reusing the design.
davidphilipbarr/Sweep
Sweep - a small promicro based keyboard inspired by the Ferris.


W0rthlessS0ul/nRF24_jammer
The nRF24 jammer is a powerful tool that requires an ESP32 and configurable numbers of NRF24 modules to assemble.

hackclub/OnBoard
💡 Join 1,000 teenagers and make your first PCB with a $100 grant!


Neumi/open_echo
Open Source echo sounder / depth sounder / SONAR for bathymetry and research. Arduino based and compatible.


vsfteam/vsf
Versaloon Software Framework -- a tiny preemptive-capable event-driven incremental software framework for embedded systems