
2 layers200 × 70 mm
FRL RFiD Box
FREILab/easyVerwaltungHardware
Hardware und Firmware für alle Geräte im Bezug zu easyVerwaltung
65 parts2

 devbotas/pcb-voron-pmu
Power management unit for my Voron 2.4 printer to handle blackouts.
Voron pmu is an open-source printed circuit board by devbotas, from the devbotas/pcb-voron-pmu repository on GitHub, published under the CERN-OHL-S-2.0 licence. It is a 2-layer board of 107 × 72 mm with 19 parts on 26 nets, routed with 137 tracks and 1 via.
It is built around the RAC05-24SK. Its parts include 8 connectors and 6 switches.
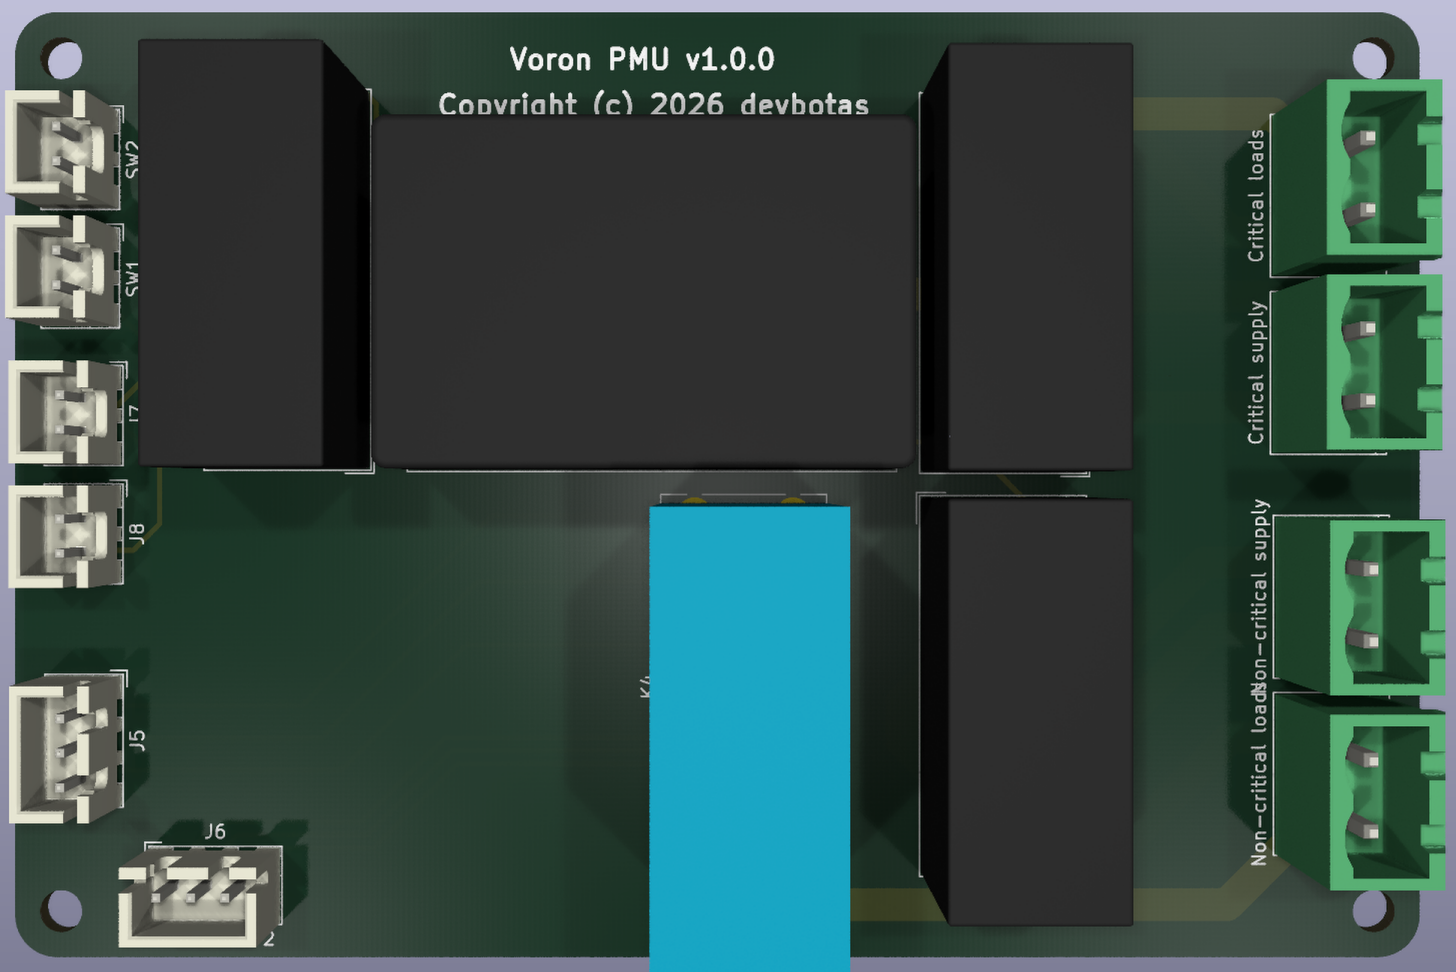
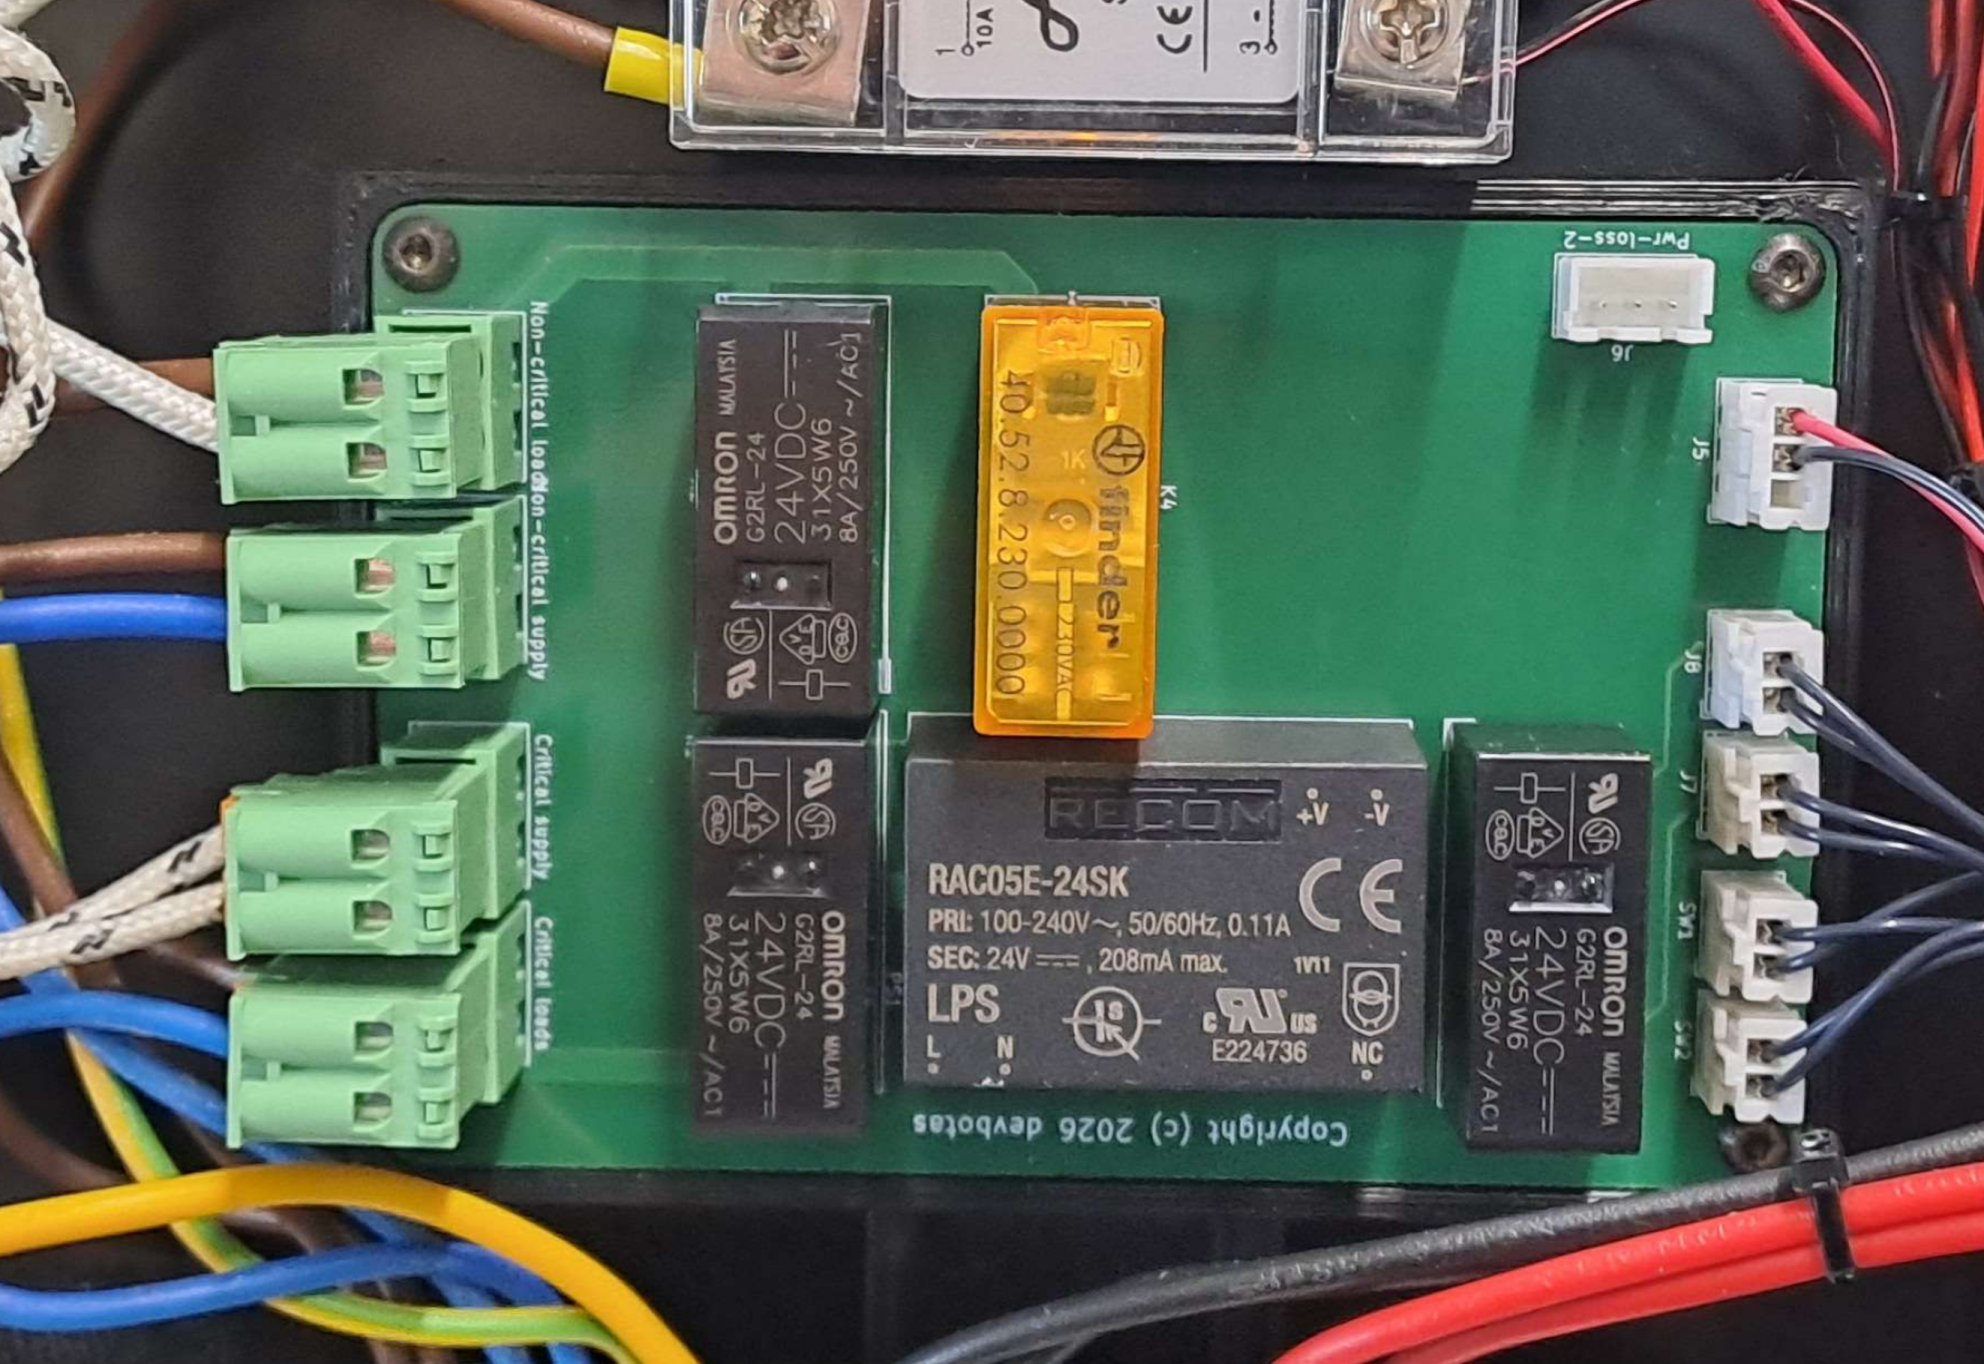
Loss of power. Smaller printers can be powered through a UPS, however, this hardly works for more power hungry ones, especially with chamber heaters. They would require massive and expensive UPSes that make no sense for a casual printer hobbyist.
Very ofthen, though, power loss is short-lived: 10 minutes (when one, for example, accidentally disengages the wrong circuit breaker).
There are a few sides of this problem:
The solution is to split the the power lines: essential parts run on a simple UPS (Raspberry Pi, controller boards, motors), while heaters get the power directly from the mains. When power loss occurs, this PMU board detects it, and trigger Klipper macroses which pause the print, park the printhead to a safe position and waits for the power to be restored. Once power is back, another set of macroses unsure proper printing temperatures and resumes the print.
Soft on/off: once plugged into the mains, printer will start in "Standby" mode, waiting for user to press the Power On button. This is more relevant to printfarms, where restoring power to a large amount of devices at once may trigger a huge mains inrush current, tripping the main breaker.
Power Off button can also be connected, acting also as an Emergency Stop.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | MountingHole | MountingHole:MountingHole_3.2mm_M3 | H1, H2, H3, H4 |
| 3 | G2RL-2 | Relay_THT:Relay_DPDT_Omron_G2RL-2 | K1, K2, K3 |
| 1 | Critical loads | Connector_Phoenix_MSTB:PhoenixContact_MSTBVA_2,5_2-G-5,08_1x02_P5.08mm_Vertical | J1 |
| 1 | Critical supply | Connector_Phoenix_MSTB:PhoenixContact_MSTBVA_2,5_2-G-5,08_1x02_P5.08mm_Vertical | J3 |
| 1 | FINDER-40.52 | Relay_THT:Relay_DPDT_Finder_40.52 | K4 |
| 1 | Non-critical loads | Connector_Phoenix_MSTB:PhoenixContact_MSTBVA_2,5_2-G-5,08_1x02_P5.08mm_Vertical | J2 |
| 1 | Non-critical supply | Connector_Phoenix_MSTB:PhoenixContact_MSTBVA_2,5_2-G-5,08_1x02_P5.08mm_Vertical | J4 |
| 1 | Pwr-loss-1 | Connector_JST:JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | J5 |
| 1 | Pwr-loss-2 | Connector_JST:JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | J6 |
| 1 | RAC05-24SK | Converter_ACDC:Converter_ACDC_RECOM_RAC04-xxSGx_THT | PS1 |
| 1 | pwr-on | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J7 |
| 1 | stby | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J8 |
| 1 | sw-off | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | SW2 |
| 1 | sw-on | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | SW1 |
It measures 107 × 72 mm and has 2 copper layers, 1.6 mm thick.
19 parts, built around the RAC05-24SK. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the devbotas/pcb-voron-pmu repository on GitHub, at the commit this page was made from: the board is pcb/voron-pmu.kicad_pcb and its schematic pcb/voron-pmu.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the CERN-OHL-S-2.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
FREILab/easyVerwaltungHardware
Hardware und Firmware für alle Geräte im Bezug zu easyVerwaltung


hackclub/OnBoard
💡 Join 1,000 teenagers and make your first PCB with a $100 grant!

polpo/picogus
Emulation of ISA sound cards and CD-ROM on Raspberry Pi Pico (GUS, SB/Adlib, MPU-401, Tandy, CMS, Panasonic CD-ROM) with USB mouse/joystick support


nkitanov/iaq_board
IAQ Board is a DIY (Do-It-Yourself) device for measuring internal air quality


Ardumower/ardumower
Develop an open source robotic lawn mower (HW+SW reference platform)