
2 layers61.9 × 76.2 mm
Digits pcb
justinlindh/digits
Encrypted retro phone network — private VoIP over vintage desk phones
77 parts4AGPL-3.0

 dbking77/robodrive_pcb
Dual brushed motor driver with wireless connectivity
Robodrive pcb is an open-source printed circuit board by dbking77, from the dbking77/robodrive_pcb repository on GitHub, published under the MIT licence. It is a 2-layer board of 44.5 × 23 mm with 24 parts on 27 nets, routed with 133 tracks and 45 vias.
It is built around the DRV8871DDARQ1. Its parts include 8 resistors, 6 capacitors, 6 connectors and 4 ICs. It belongs with the robots and motor control boards and the ESP32 and RISC-V boards of this library.
Dual brushed motor drive with wireless (BLE/Wifi) connectivity. 12V input, 2x 2Amp motor outputs, 2x servo PWM signals, and LED output
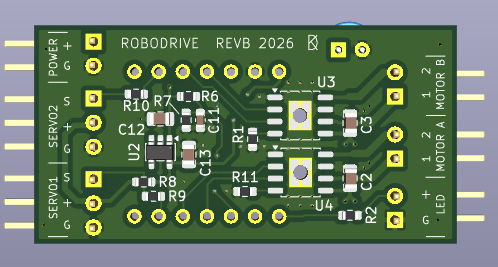
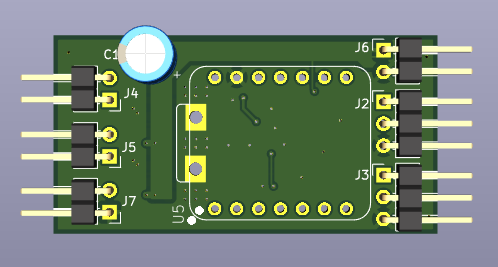
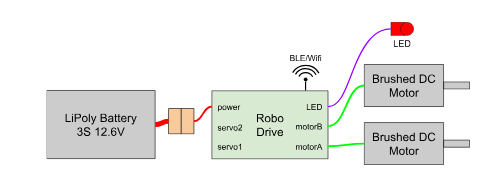
The basic robodrive setup has a 12V battery and 2 brushed motors. This is enough to build a differential-drive robot setup.
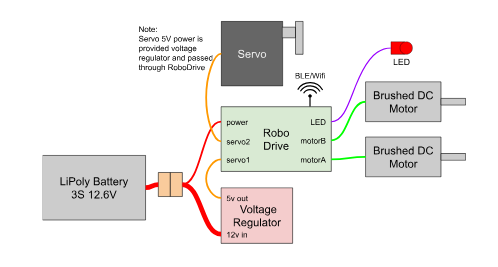
Combat robots often use a brushless motor to power a spinning weapon. Many brushless electronics speed controllers (ESC), have a battery elimination circuit (BEC). This BEC often produces a high-current 5V output that can be used to power a servo. The robodrive ties the 5V pin of the servo connectors together allowing the ESC to pass through 5V power to the servo.
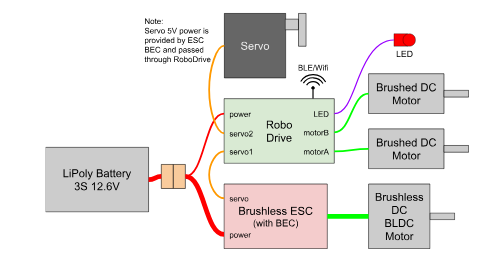
While the robodrive does have an internal 5V regulator, it cannot provide even close enough current to power a servo. One easy way to provide 5V power to servo is to use a 5V regulator. Connector the regulators input to the battery and its output to the unused servo connector on the robodrive. The robodrive ties the 5V pin of the servo connectors together allowing the 5V power pass between regulator the servo.
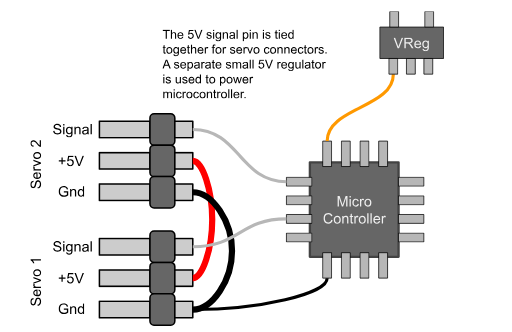
The servo 5V pins are tied together. Internally the robodrive uses separate 5V regulator to power the microcontroller.
| Description | Qty | Cost | Supplier | Supplier Part Num | Manuf | Manuf Part Num | Note |
|---|---|---|---|---|---|---|---|
| XIAO ESP32C6 | 1 | 5.38 | Digikey | 1597-113991254-ND | Seeed | 113991254 | Can get cheaper directly |
| Unipolar Motor Driver | 2 | 2.03 | Digikey | 296-43024-1-ND | Texas Instr | DRV8871DDAR | |
| VReg 5V 300MA SOT23-5 | 1 | 0.34 | Digikey | 296-TPS7B92050DBVRCT-ND | Texas Instr | TPS7B92050DBVR | |
| Capacitor 100uF 16V | 1 | 0.37 | Digikey | 478-RPA0609101M025KCT-ND | Kyocera | RPA0609101M025K | Maybe Buy Qty 10 |
| Capacitor 1uF 16V | 4 | 0.08 | Digikey | 1276-1029-1-ND | Samsung | CL21B105KBFNNNE | Maybe Buy Qty 10 |
| Resistor 10k 0603 | 1 | 0.01 | Digikey | 311-10.0KHRCT-ND | Yageo | RC0603FR-0710KL | Buy Qty 10 or 100 |
| Resistor 56.2k 0603 | 1 | 0.01 | Digikey | 311-56.2KHRCT-ND | Yageo | RC0603FR-0756K2L | Buy Qty 10 or 100 |
| Resistor 1k 0603 | 2 | 0.01 | Digikey | 311-1.00KHRCT-ND | Yageo | RC0603FR-071KL | Buy Qty 10 or 100 |
| Capacitor 10000pF 50V 0603 | 1 | 0.01 | Digikey | 399-C0603C103K5RACTUCT-ND | Kemet | C0603C103K5RACTU | Buy Qty 10 or 100 |
| Header R/A Breakaway 40pos | 1 | 0.78 | Digikey | S1111EC-40-ND | Sullins | PRPC040SBAN-M71RC | Break into 2x 6pos |
| Header Vert Breakaway | 1 | Digikey | TODO | ||||
| Female Socket 2pos | 4 | 0.27 | Digikey | S7035-ND | Sullins | PPPC021LFBN-RC | Used for motor/power wires |
| LED Red 30deg | 1 | 0.18 | Digikey | C503B-RCN-CW0Z0AA1-ND | Cree | C503B-RCN-CW0Z0AA1 | Indicator LED |
| LED Red 15deg | 1 | 0.18 | Digikey | C503B-RAN-CZ0C0AA1-ND | Cree | C503B-RAN-CZ0C0AA1 | Indicator LED |
Used to optionally low-pass filter and battery voltage signals, may not be needed.
Optional allows motor and power input wires to be connected to right angle headers more easily.
30mA * (12.6V - 5V) = 0.228W
LED output is used for indicating device power and mode of operation A high candela output LED should be used so only a few mA of current produces enough brightness
Motor (PZ22GR9120R-084BBH) max stall current 1.3Amp. This is probably continuous stall current, so peak is probably larger. Pick a current trip limit of 1.5Amp
Itrip = 1.5 Amp : RLim (kOhm) = 64 / ITrip = 42kOhm Itrip = 1.64 Amp : RLip (kOhm) = 64 / ITrip = 39kOhm Itrip = 2.0 Amp : RLim (kOhm) = 64 / ITrip = 36kOhm
| Description | Qty | Cost | Supplier | Supplier Part Num | Manuf | Manuf Part Num | Note |
|---|---|---|---|---|---|---|---|
| Resistor 36k 0603 | 1 | 0.01 | Digikey | RMCF0603FT36K0CT-ND | Stackpole | RMCF0603FT36K0 | Buy Qty 10 or 100 |
| Resistor 39k 0603 | 1 | 0.01 | Digikey | 311-39.0KHRCT-ND | YAGEO | RC0603FR-0739KL | Buy Qty 10 or 100 |
| Resistor 41.2k 0603 | 1 | 0.01 | Digikey | 311-41.2KHRCT-ND | YAGEO | RC0603FR-0741K2L | Buy Qty 10 or 100 |
TODO : Link to Firmware
| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | 1uF | Capacitor_SMD:C_0805_2012Metric | C2, C3, C12, C13 |
| 3 | 1k | Resistor_SMD:R_0603_1608Metric | R2, R9, R10 |
| 2 | Conn_01x03_Pin | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Horizontal | J2, J3 |
| 2 | DRV8871DDAR | DRV8871:hsop8_hole | U3, U4 |
| 2 | TBD | Resistor_SMD:R_0603_1608Metric | R1, R11 |
| 1 | 10000pf 16V | Capacitor_SMD:C_0603_1608Metric | C11 |
| 1 | 100uF | Custom:CP_Radial_D6.3mm_P2.50mm | C1 |
| 1 | 10k | Resistor_SMD:R_0603_1608Metric | R7 |
| 1 | 56.2k | Resistor_SMD:R_0603_1608Metric | R6 |
| 1 | JUMPER | Resistor_SMD:R_0603_1608Metric | R8 |
| 1 | LED | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Horizontal | J7 |
| 1 | MOTOR1 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Horizontal | J5 |
| 1 | MOTOR2 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Horizontal | J4 |
| 1 | POWER | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Horizontal | J6 |
| 1 | TPS7B92050DBVR | Package_TO_SOT_SMD:SOT-23-5 | U2 |
| 1 | XIAO-ESP32-C6-DIP | XIAO:XIAO-ESP32-C6-DIP-ONLY | U5 |
It measures 44.5 × 23 mm and has 2 copper layers, 1.6 mm thick.
24 parts, built around the DRV8871DDARQ1. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the dbking77/robodrive_pcb repository on GitHub, at the commit this page was made from: the board is robodrive_pcb.kicad_pcb and its schematic robodrive_pcb.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
justinlindh/digits
Encrypted retro phone network — private VoIP over vintage desk phones

shmuelzon/lowkey
Matter-over-Thread and/or BLE in-door smart lock controller based on the RBM1 lock body

choicebuilds/SumoBot-v2
A Robojackets robot (v2) built from scratch, featuring a custom 4-layer PCB, STM32-based (ARM Cortex-M3) firmware written in C (STM32CubeMX + CMake), and a 3D-printed chassis.

gonewx/quadcuber
本目录是 A1 电子源目录。打开 quadcuber.kicadpro,包含原生可编辑原理图和四层 PCB、本地符号/封装库。本设计为单块PCB,RP2040、QSPI Flash、晶振、USB-C、驱动和电源均直接焊接在板上;A0的Pico H插装已移除。马达使用EV3裸插座。接线定义仍从 ../wiring/spec.py 导入,固件未改动,也没有把 R/L 固件描述成已支持四臂控制。

ivanchairez01/indMotorControl
STM32-based industrial motor controller featuring FreeRTOS, CAN networking, closed-loop PID speed control, fault management, and real-time diagnostics.

Matthew-Bon/moon_child
A rocket flight computer to support CBJAMO's amoral interests.


mrwillson2u/propmesh
Open-source wireless control for Halloween and holiday props.