

2 layers100 × 100 mm
 cryptoAlgorithm/chess-printer3
A chess bot, but on steroids. Custom 3D printer control board with a few oddly specific features.
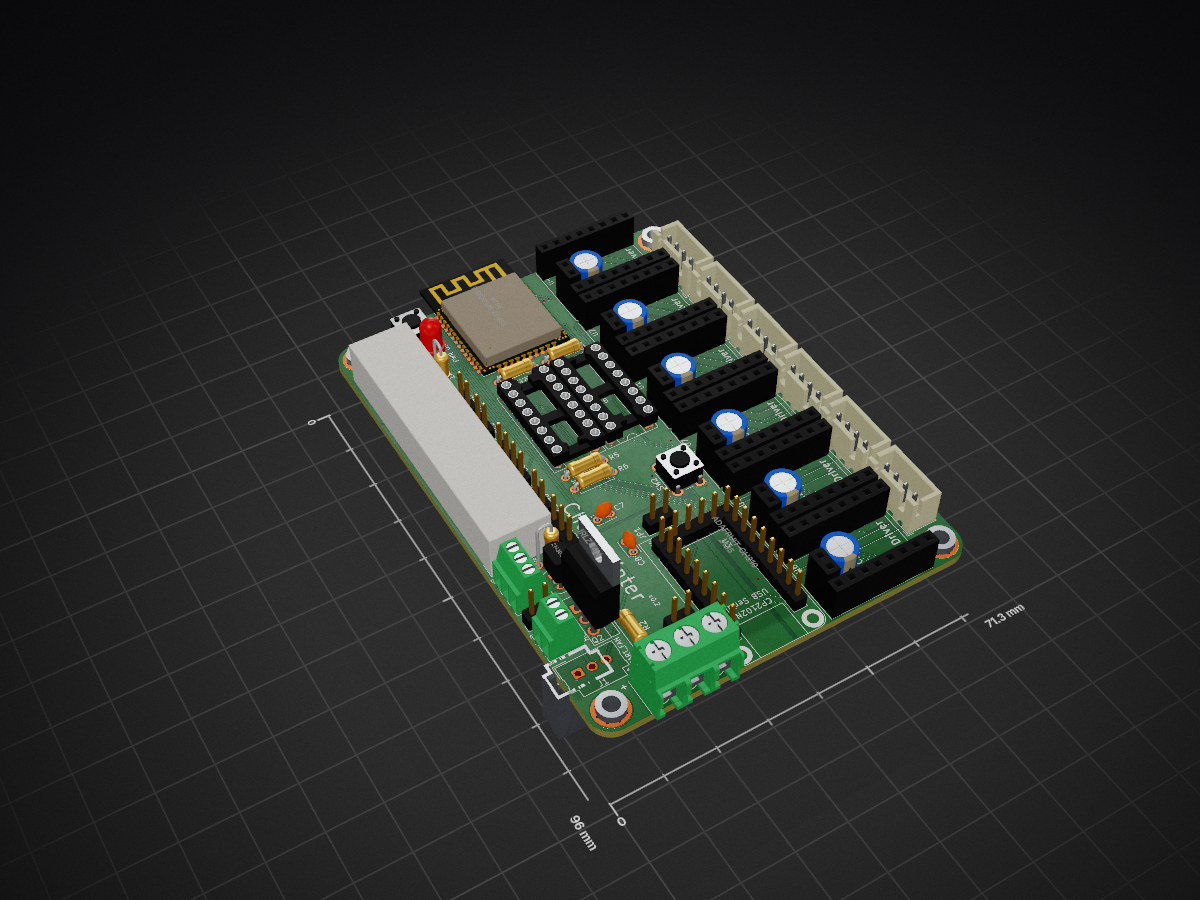
ChessBotController is an open-source printed circuit board by cryptoAlgorithm, from the cryptoAlgorithm/chess-printer repository on GitHub. It is a 4-layer board of 71.3 × 95.9 mm with 55 parts on 123 nets, routed with 380 tracks and 27 vias.
It is built around the 74HC595 and IRLZ44N. Its parts include 11 connectors, 10 ICs, 8 capacitors, 8 resistors and 2 transistors. It belongs with the robots and motor control boards and the ESP32 boards of this library.
A chess bot, but on steroids.
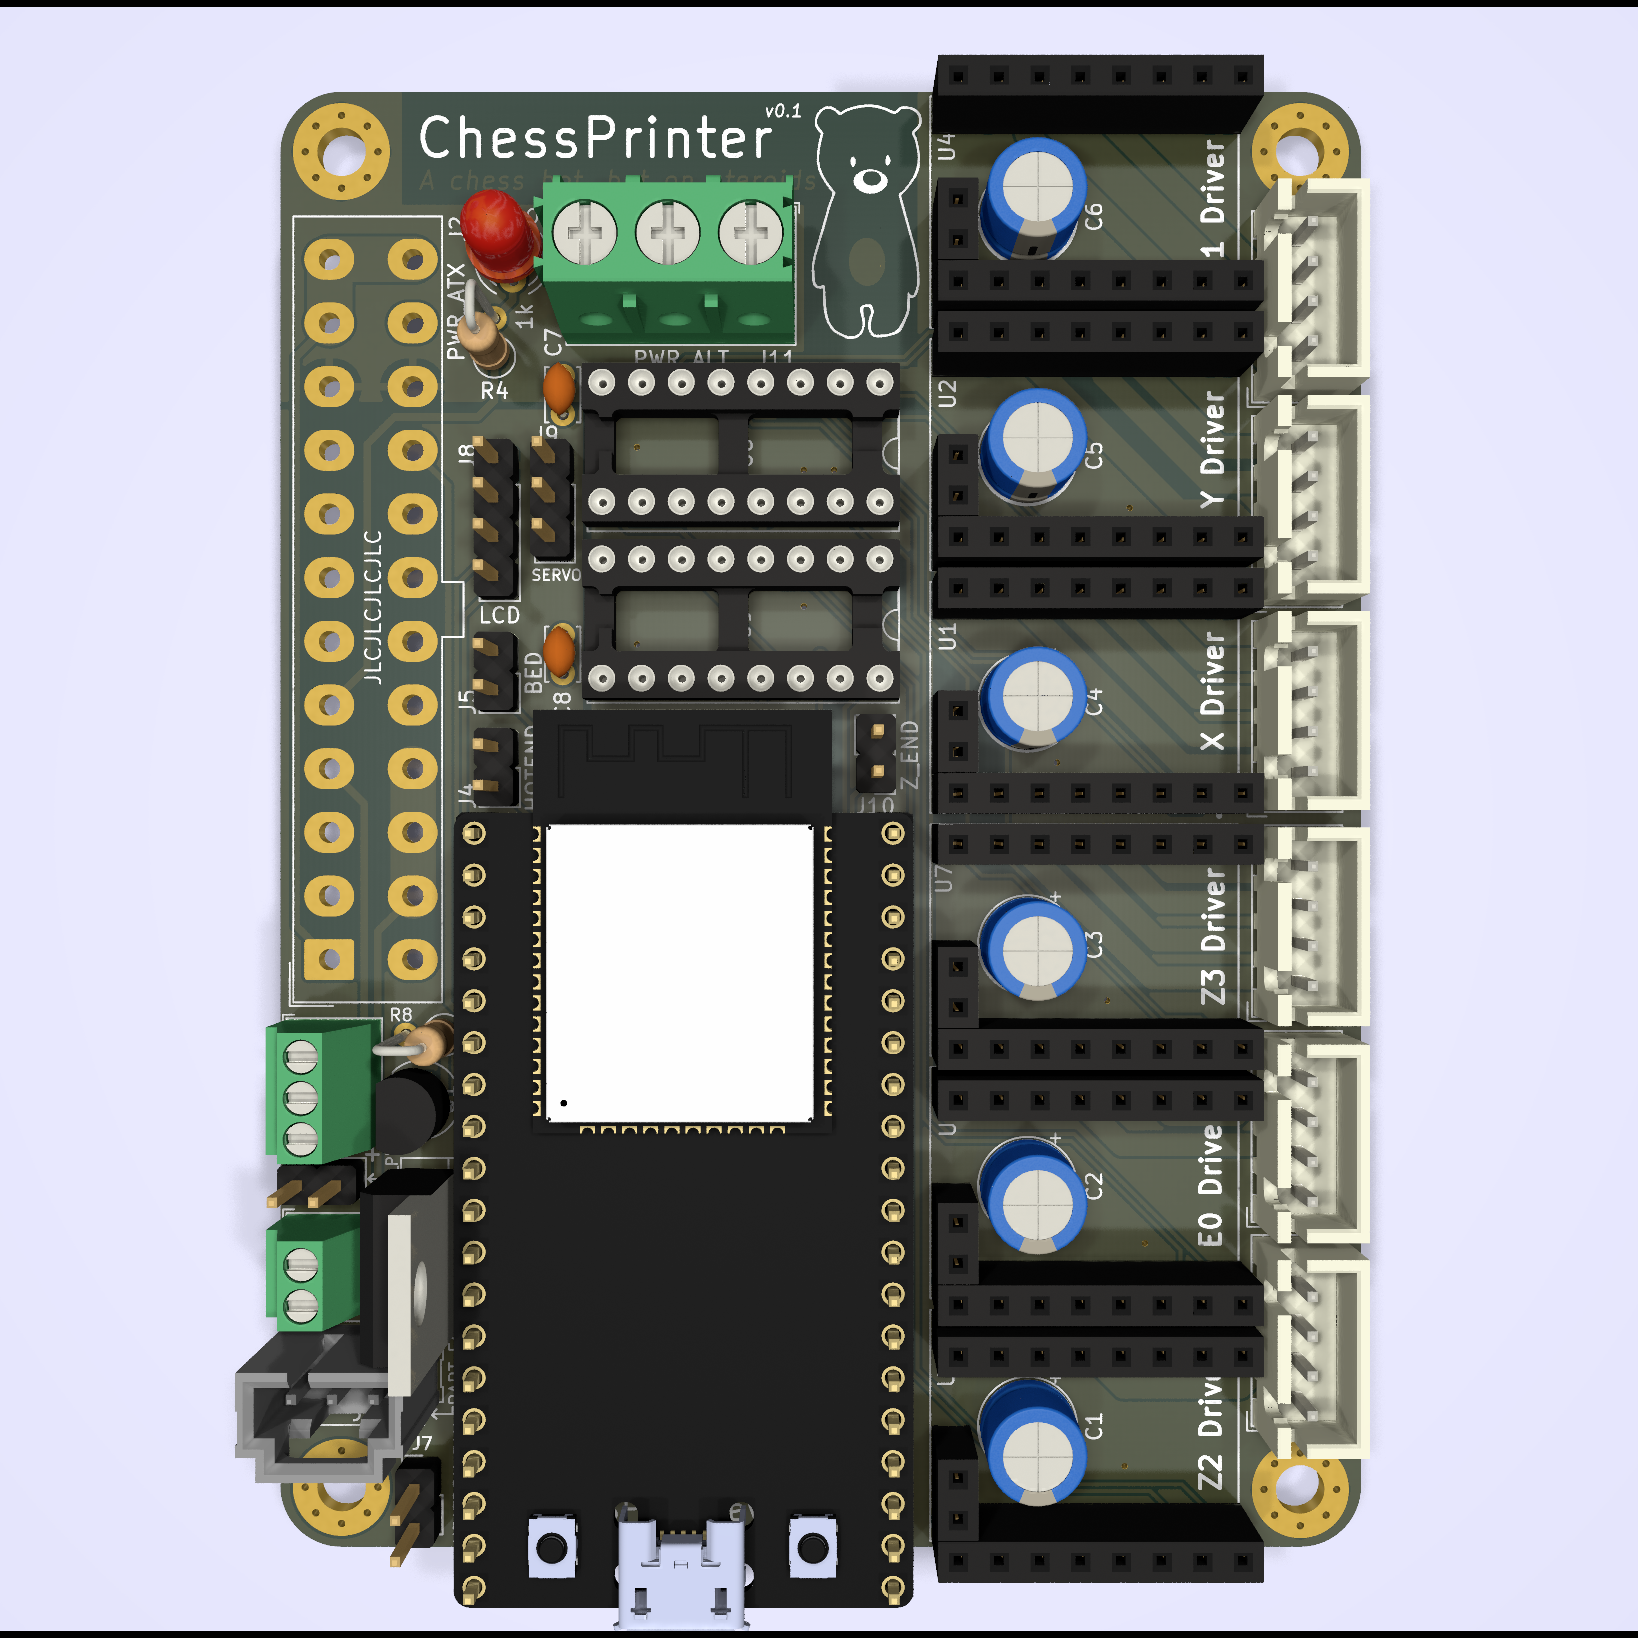
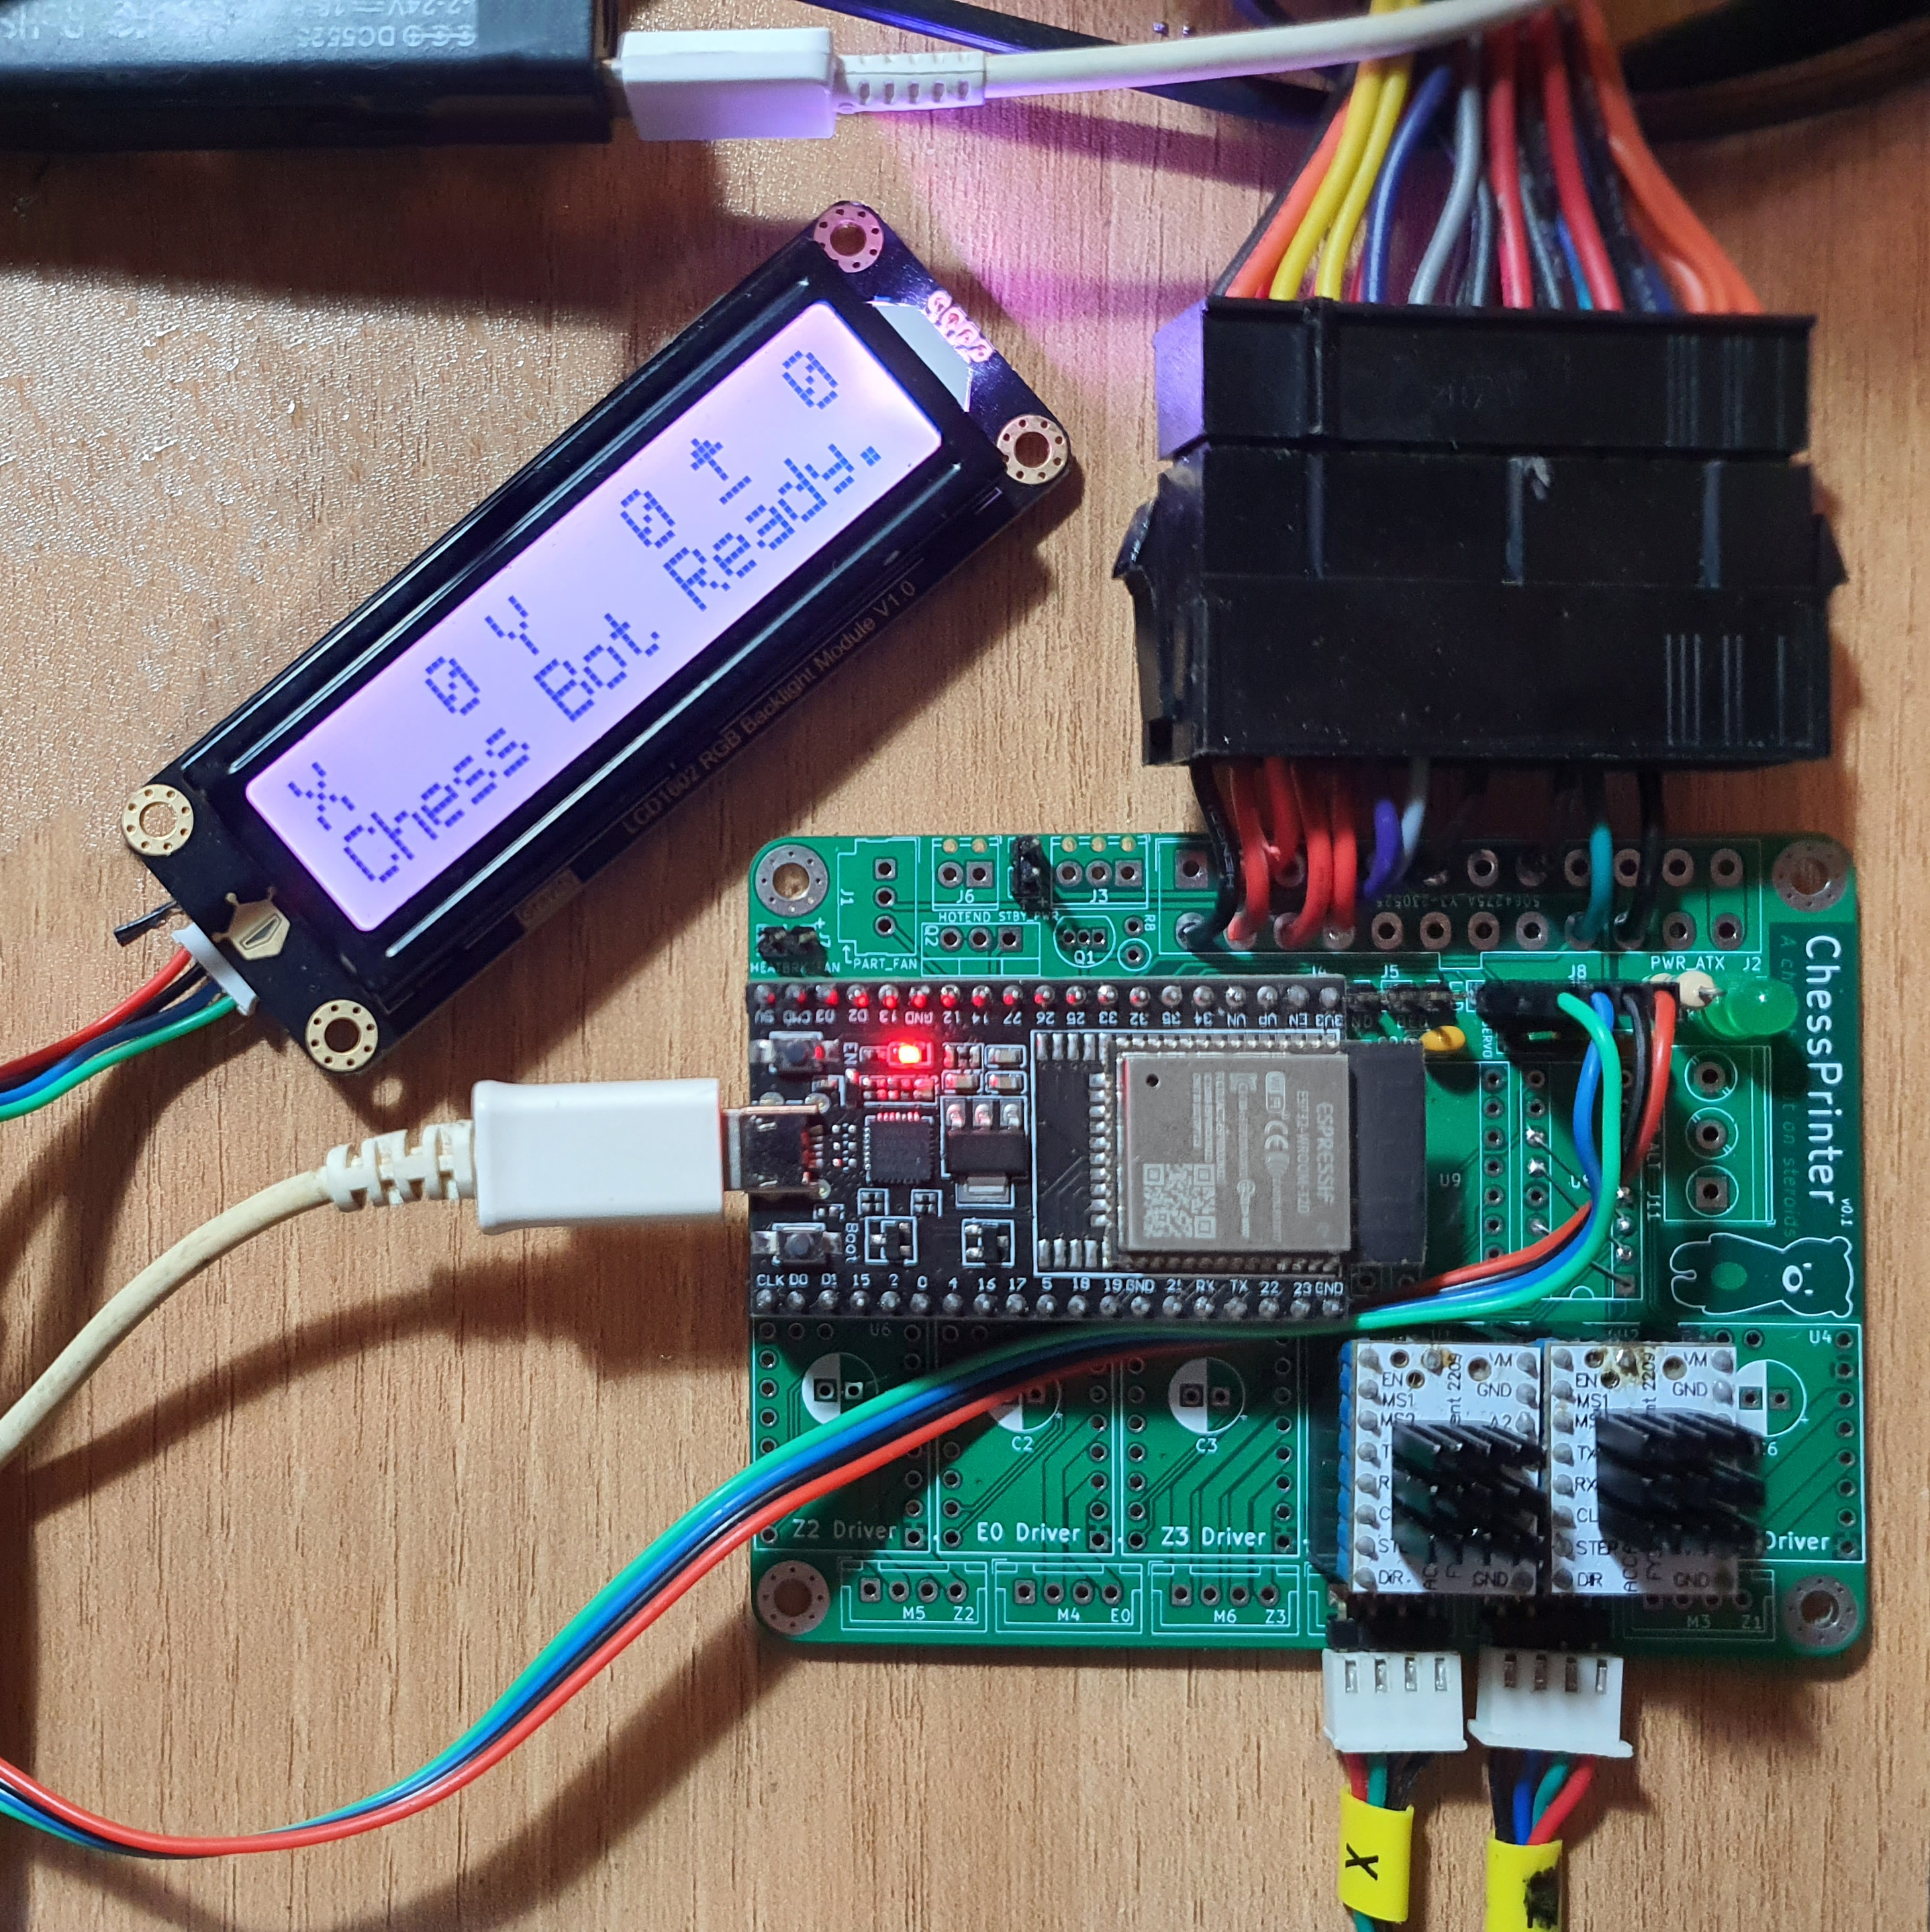
A completely custom-designed 3D printer control board with an ESP32 MCU. Designed to control a CoreXY printer, but can probably be adapted to any kinematic system.
Warning: This is an experimental project with no gurantees - use at your own risk and discretion!
PS-ON control (standby & emergency kill poweroff supported in Marlin)5VSB ATX power rail with jumper selection
(DO NOT power via USB and 5VSB concurrently - doing so will almost definitely damage something!)75HC595 shift registers| Qty | Value | Footprint | References |
|---|---|---|---|
| 6 | 100uF | Capacitor_THT:CP_Radial_D6.3mm_P2.50mm | C1, C2, C3, C4, C5, C6 |
| 6 | ~ | Motor_Trinamic:MODULE_TMC2209_SILENTSTEPSTICK | U1, U2, U4, U5, U6, U7 |
| 4 | MountingHole_Pad | MountingHole:MountingHole_3.2mm_M3_Pad_Via | H1, H2, H3, H4 |
| 2 | 0.1uF | Capacitor_THT:C_Disc_D3.4mm_W2.1mm_P2.50mm | C7, C8 |
| 2 | 10k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R2, R7 |
| 2 | 1k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R9, R10 |
| 2 | 4k7 | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R5, R6 |
| 2 | 74HC595 | Package_DIP:DIP-16_W7.62mm_Socket | U8, U9 |
| 2 | SW_Push | Button_Switch_THT:SW_PUSH_6mm | SW1, SW2 |
| 1 | 10K | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P2.54mm_Vertical | R8 |
| 1 | 1k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P2.54mm_Vertical | R4 |
| 1 | 2N3904 | Package_TO_SOT_THT:TO-92_Inline | Q1 |
| 1 | Adafruit-CH2102N-Friend | USB_to_Serial_Friend:Adafruit-CH2102N-Friend | U3 |
| 1 | BED | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J5 |
| 1 | E0 | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | M4 |
| 1 | ESP32-WROOM-E | Espressif:ESP32-WROOM-32E | U10 |
| 1 | HEATBED | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MPT-0,5-3-2.54_1x03_P2.54mm_Horizontal | J3 |
| 1 | HEATBRK_FAN | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J7 |
| 1 | HOTEND | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MPT-0,5-2-2.54_1x02_P2.54mm_Horizontal | J6 |
| 1 | HOTEND | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J4 |
| 1 | IRLZ44N | Package_TO_SOT_THT:TO-220-3_Vertical | Q2 |
| 1 | LCD | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J8 |
| 1 | PART_FAN | Connector_Molex:Molex_SL_171971-0003_1x03_P2.54mm_Vertical | J1 |
| 1 | PWR OK | LED_THT:LED_D4.0mm | D2 |
| 1 | PWR_ALT | TerminalBlock_Phoenix:TerminalBlock_Phoenix_PT-1,5-3-5.0-H_1x03_P5.00mm_Horizontal | J11 |
| 1 | PWR_ATX | Connector_Molex:Molex_Mini-Fit_Jr_ATX24 | J2 |
| 1 | SERVO | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J9 |
| 1 | STBY_PWR | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | JP2 |
| 1 | USB_PWR | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | JP1 |
| 1 | X | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | M1 |
| 1 | Y | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | M2 |
| 1 | Z1 | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | M3 |
| 1 | Z2 | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | M5 |
| 1 | Z3 | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | M6 |
| 1 | Z_END | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J10 |
The 54 most common of 55 parts.
It measures 71.3 × 95.9 mm and has 4 copper layers, 1.6 mm thick.
55 parts, built around the 74HC595 and IRLZ44N. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the cryptoAlgorithm/chess-printer repository on GitHub, at the commit this page was made from: the board is ChessBotController.kicad_pcb and its schematic ChessBotController.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask cryptoAlgorithm before reusing the design.


locokepler/Pipe_Organ
The repository of the pipe organ, over the different iterations of mechanical, electrical, and code design

24bec124-sketch/IROC-U-Charging-NMOS
Developed for Team Arrow as part of IRoC-U (ISRO Robotics Challenge - URSC), a national student competition hosted by the Indian Space Research Organization (ISRO).

Abdulsalam-Alsheikh/CircleOfLuck
This project was developed to provide an efficient and engaging way to randomly select winners in competitions or events where the order of winners needs to be determined fairly and without bias.

jboymel/piano-robot
Modular solenoid-based robotic piano actuator system — Northwestern SURG 2026

klein0r/pcb-rack-temperature-control
Control fans in your rack depending on current temperature

ProGenEDA/Public
This is ProGenEDA’s public engineering record. It makes the work behind the product inspectable—from circuit requests and qualification reports through to native files that open in Proteus, KiCad, EasyEDA Pro, and…