2 layers
CameraTriggerSensorNodeOnly
chrocket/RocketTrig
A camera controller for photographing high poweed model rockets
61 parts3GPL-3.0
 chrocket/RocketTrig3
A camera controller for photographing high poweed model rockets
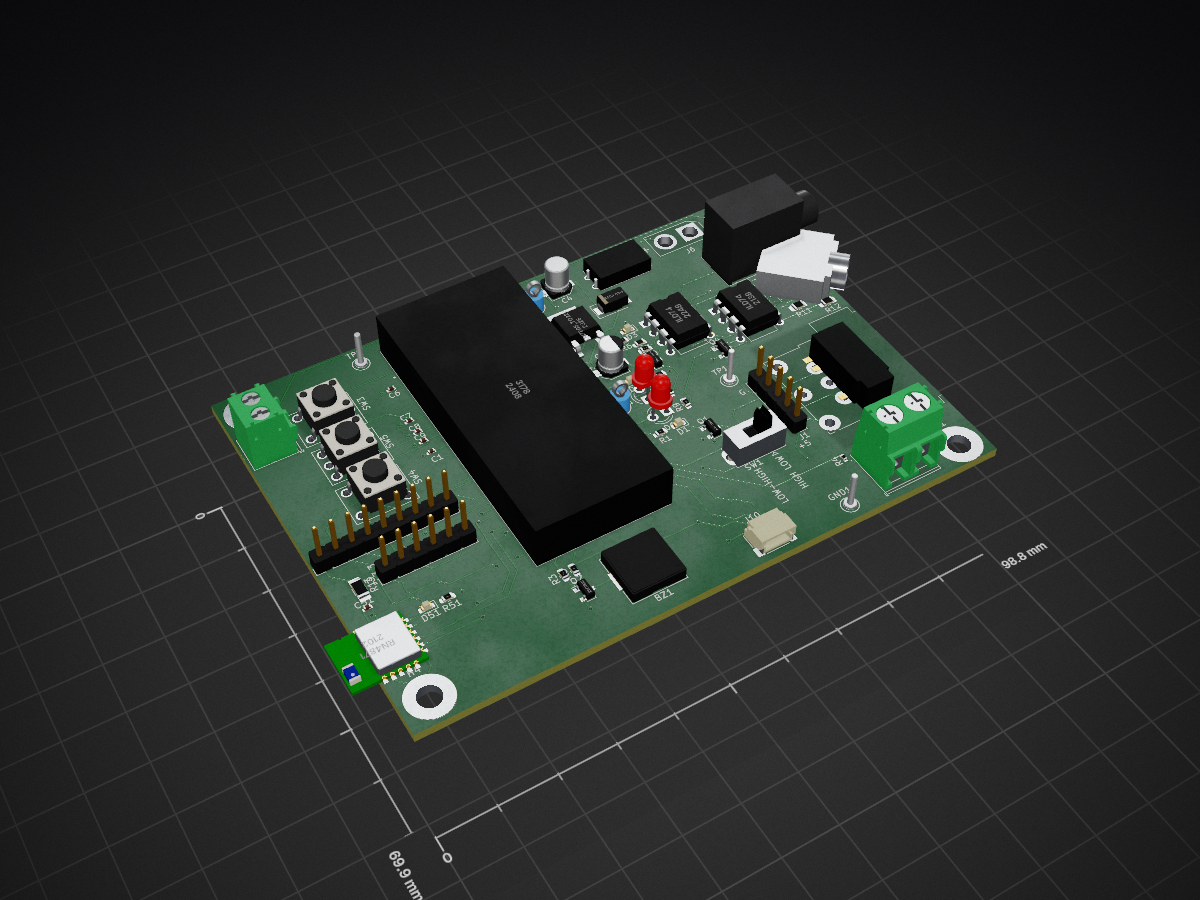
CameraTriggerSensorNodeOnly is an open-source printed circuit board by chrocket, from the chrocket/RocketTrig repository on GitHub, published under the GPL-3.0 licence. It is a 2-layer board of 98.8 × 69.9 mm with 65 parts on 75 nets, routed with 611 tracks and 53 vias.
It is built around the ILD74, MMBT3904 and 2SC1815, with the AS11CB and B330A-13-F-MS among its other parts. Its parts include 14 resistors, 10 capacitors, 10 connectors, 7 diodes and 5 ICs.


A camera controller for photographing high poweed model rockets

This is a camera controller. Each "node" contains outputs to control one or two cameras. Camera nodes can communicate to each others over an RF link. Two nodes make up a system, say one at the flight line and one up close to the rocket. Liftoffs can be triggered by a variety of sensors to detect lift-off, or manually via a foot switch.
Schematic, BOM, JLBPCB files and firmware are all included. Note: Even those some files are labelled "CameraTriggerSensorNodeOnly" they are really Camera nodes.
This is based on the Adafruit Feather M0 LoRa board (Adafruit 3178). It also works with RFM65 radio version of that board, cheaper but less range (Adafruit 3176). There is a #define to select between the two, and the frequency of operation will have to be in the range of the chip.
To build firmware, you will need Arduino IDE. I'm using ver 1.8.19. You will need to set up the Adafruit boards in the boards manager (Add https://adafruit.github.io/arduino-board-index/package_adafruit_index.json to Additional boards URL under Preferences). Set "Adafruit Feather M0 (SAMD21)" Under Tools/Board.
I'm using dependencies (under library manager): CRC32 by Christopher Baker https://github.com/bakercp/CRC32/blob/master/examples/CRC32/CRC32.ino Requires RadioHead libs // https://www.airspayce.com/mikem/arduino/RadioHead/index.html // Download from Adafruit https://cdn-learn.adafruit.com/assets/assets/000/035/106/original/RadioHead-1.62.zip?1472068723 CCW MorseTX https://github.com/ridencww/cww_MorseTx
You will likely want to change the default 915.35 MHz operating frequency. This is done by a #define. This will deconfict different users who might want to simultaneously use the sytem.
In June 2023, I had Eureka moment. I realized that with virtuallly no changes, the RocketTrig board could be used as a wireless Launch controller and still trigger cameras. I modified the program to work with this and later worked up a separate board "Rev 4_1" that could better meet both remote launch and remote camera trigger functions.
(Remote launch can still trigger cameras both local and remote)
Here is the Rev 4_1 board

| Qty | Value | Footprint | References |
|---|---|---|---|
| 7 | 0.01 μF | Capacitor_SMD:C_0402_1005Metric | C1, C2, C5, C6, C7, C8, C9 |
| 7 | 1K | Resistor_SMD:R_0603_1608Metric | R1, R2, R3, R5, R6, R7, R9 |
| 4 | MountingHole:MountingHole_3.7mm_Pad | H1, H2, H3, H4 | |
| 3 | MMBT3904 | Package_TO_SOT_SMD:SOT-23 | Q1, Q3, Q4 |
| 2 | 0 | Resistor_SMD:R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R11, R12 |
| 2 | 51 | Resistor_SMD:R_0603_1608Metric | R8, R10 |
| 2 | ILD74 | Package_DIP:DIP-8_W7.62mm | U2, U3 |
| 1 | Connector_PinHeader_2.54mm:PinHeader_1x05_P2.54mm_Vertical | J1 | |
| 1 | Connector_AMASS:AMASS_XT30U-F_1x02_P5.0mm_Vertical | J6 | |
| 1 | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | J3 | |
| 1 | Button_Switch_THT:SW_Slide_1P2T_CK_OS102011MS2Q | SW1 | |
| 1 | Connector_PinHeader_2.54mm:PinHeader_1x09_P2.54mm_Vertical | J4 | |
| 1 | +5V | TestPoint:TestPoint_Keystone_5010-5014_Multipurpose | TP1+1 |
| 1 | 0 | Resistor_SMD:R_1206_3216Metric_Pad1.42x1.75mm_HandSolder | R13 |
| 1 | 100n | Capacitor_SMD:C_0402_1005Metric | C51 |
| 1 | 1k5 | Resistor_SMD:R_0603_1608Metric | R51 |
| 1 | 1uf | Capacitor_SMD:CP_Elec_4x5.4 | C3 |
| 1 | 25uf | Capacitor_SMD:C_Elec_4x5.4 | C4 |
| 1 | 2SC1815 | Package_TO_SOT_SMD:SOT-23 | Q2 |
| 1 | 3178 | SamacSys_Parts:3178 | IC1 |
| 1 | 5K | Resistor_SMD:R_0402_1005Metric | R4 |
| 1 | AS11CB | CameraTriggerPCB:AS11CB | SW2 |
| 1 | Aux out | TerminalBlock_Phoenix:TerminalBlock_Phoenix_PT-1,5-2-5.0-H_1x02_P5.00mm_Horizontal | J5 |
| 1 | B330A-13-F | Diode_SMD:D_SMA | D4 |
| 1 | BLUE | LED_SMD:LED_0603_1608Metric | D51 |
| 1 | Buzzer | Buzzer_Beeper:Buzzer_Murata_PKMCS0909E4000-R1 | BZ1 |
| 1 | Camera 2.5mm | CameraTriggerPCB:CUI_SJ1-2503A | J9 |
| 1 | Camera 3.5mm | Connector_Audio:Jack_3.5mm_CUI_SJ1-3533NG_Horizontal_CircularHoles | J8 |
| 1 | Fire | TestPoint:TestPoint_Keystone_5010-5014_Multipurpose | TP4Fire1 |
| 1 | Gnd | TestPoint:TestPoint_Keystone_5000-5004_Miniature | TP2 |
| 1 | LED Arm | LED_SMD:LED_0603_1608Metric | D1 |
| 1 | LED Focus | LED_THT:LED_D3.0mm | D6 |
| 1 | LED Trig | LED_THT:LED_D3.0mm | D5 |
| 1 | LED Trig | LED_SMD:LED_0603_1608Metric | D2 |
| 1 | LM7805_TO220 | Package_TO_SOT_SMD:TO-252-2 | U1 |
| 1 | PWR | LED_SMD:LED_0603_1608Metric | D3 |
| 1 | RN4871 | RF_Module:Microchip_RN4871 | U5 |
| 1 | SW_Arm | Button_Switch_THT:KSA_Tactile_SPST | SW5 |
| 1 | SW_Poll | Button_Switch_THT:KSA_Tactile_SPST | SW4 |
| 1 | SW_trig | Button_Switch_THT:KSA_Tactile_SPST | SW3 |
| 1 | Sensor | TestPoint:TestPoint_Keystone_5000-5004_Miniature | TP1 |
| 1 | TestPoint | TestPoint:TestPoint_Keystone_5000-5004_Miniature | GND1 |
| 1 | Trig in | TerminalBlock_Phoenix:TerminalBlock_Phoenix_PT-1,5-2-3.5-H_1x02_P3.50mm_Horizontal | J7 |
| 1 | XLR5 Male | SamacSys_Parts:Jack_XLR_Neutrik_NC5MBH_Horizontal | J2 |
| 1 | qwiic | Connector_JST:JST_SH_SM04B-SRSS-TB_1x04-1MP_P1.00mm_Horizontal | J10 |
chrocket/RocketTrig
A camera controller for photographing high poweed model rockets

chrocket/RocketTrig
A camera controller for photographing high poweed model rockets

chrocket/RocketTrig
A camera controller for photographing high poweed model rockets

chrocket/RocketTrig
A camera controller for photographing high poweed model rockets


mahdi-kh1265/780nm-ecdl-electronics
Control, interface, piezo-actuation, and power electronics for POSM's 780 nm Littrow external-cavity diode laser.

niksrajendra/stm8-bootloader-extended
STM8 bootloader designed to work with any available communication interface and configure for different feature like secure, unsecure bootloader.

amyleesterling/humanoid-robot
detailed specs to build a humanoid robot (with kids)

quezadaminter/CR101kc
The electrical schematics and PCB layout for the CR101 boards.

Strooom/SmartTherm
Controlling a Junkers heating (Eurostar ZWE24) with an IoT thermostat


It measures 98.8 × 69.9 mm and has 2 copper layers, 1.6 mm thick.
65 parts, built around the ILD74, MMBT3904, 2SC1815 and AS11CB. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the chrocket/RocketTrig repository on GitHub, at the commit this page was made from: the board is RocketTrigCameraNode/KiCad schematic and pcb/CameraTriggerSensorNodeOnly.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).