2 layers390 × 78.2 mm
MBO
shanteacontrols/OpenDeck
A platform for building interactive control and sensing devices using MIDI and OSC built with Zephyr RTOS.
61 parts960Apache-2.0

 bumahka/Robot4Workshop1
Roboter platform for workshops with pupils.
PCB Layout is an open-source printed circuit board by bumahka, from the bumahka/Robot4Workshop repository on GitHub. It is a 2-layer board of 149 × 113.9 mm with 61 parts on 150 nets, routed with 627 tracks and 269 vias.
Its parts include 28 resistors, 10 capacitors and 1 connector.
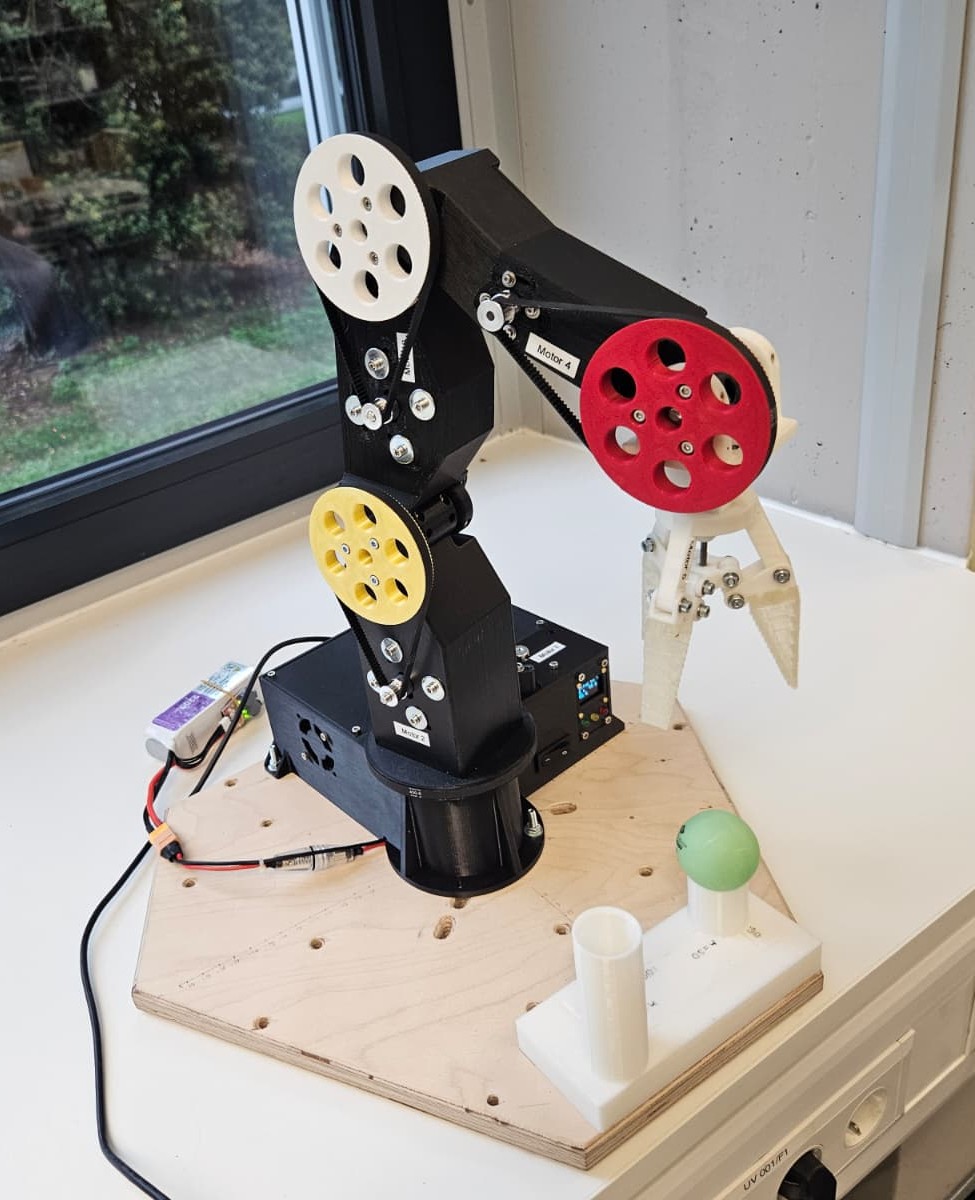
Dieses Projekt beschreibt den Aufbau und die Inbetriebnahme eines Roboterarms, der mithilfe von 3D-gedruckten Teilen, einer selbstgefertigten Platine und einem STM32F4-Mikrocontroller gesteuert wird.
3D-Druckteile
Bestellung von Bauteilen
Wenn alle 3D-Druckteile und Bauteile vorhanden sind, den Arm gemäß der Montageanleitung zusammenbauen.
Fertigung
Bestückung
Stromversorgung
Setup
Stromversorgung
Anpassung
main.c programmiert und alle aufzurufenden Funktionen sind in README beschrieben.Vor der ersten Inbetriebnahme ist eine Kalibrierung der StallGuard-Werte notwendig.
Empfohlen wird die Nutzung von STM32CubeMonitor, um Variablen in Echtzeit auszulesen.
Wichtige Parameter:
STALL_BUFFER_M_XLOW_COUNTER_THRESHOLD_M_XSTALL_MAX_M_XEinen Eindruck, wie der fertige Roboterarm aussehen kann, gibt es hier:
➡️ Video ansehen
| Qty | Value | Footprint | References |
|---|---|---|---|
| 15 | 10k | Resistor_SMD:R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R401, R402, R403, R404, R409, R410, R411, R412, R413, R414, R419, R420, R421, R422, R425 |
| 5 | 0 | Resistor_SMD:R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R407, R408, R416, R418, R424 |
| 5 | 10u | Capacitor_SMD:C_1206_3216Metric_Pad1.33x1.80mm_HandSolder | C402, C404, C406, C408, C410 |
| 5 | 1k | Resistor_SMD:R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R405, R406, R415, R417, R423 |
| 5 | 47u | Capacitor_SMD:C_1206_3216Metric_Pad1.33x1.80mm_HandSolder | C401, C403, C405, C407, C409 |
| 5 | Conn_01x02_Socket | Connector_PinSocket_2.54mm:PinSocket_1x02_P2.54mm_Vertical_SMD_Pin1Left | Bypass_C401, Bypass_C402, Bypass_C403, Bypass_C404, Bypass_C405 |
| 5 | Conn_01x04_Socket | Connector_PinSocket_2.54mm:PinSocket_1x04_P2.54mm_Vertical | Motor_Headerpin_401, Motor_Headerpin_402, Motor_Headerpin_403, Motor_Headerpin_404, Motor_Headerpin_405 |
| 3 | 180 | Resistor_SMD:R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R501, R502, R503 |
| 3 | LED | LED_THT:LED_D5.0mm | LED_green501, LED_red501, LED_yellow501 |
| 1 | Conn_01x02_Pin | Connector_AMASS:AMASS_XT60-M_1x02_P7.20mm_Vertical | PowerSupplyConnector301 |
| 1 | Conn_01x07_Pin | Connector_PinSocket_2.54mm:PinSocket_1x07_P2.54mm_Vertical | J501 |
| 1 | NUCLEO-F446RE | NUCLEO-F446RE:MODULE_NUCLEO-F446RE | MCU201 |
| 1 | Screw_Terminal_01x02 | my_custom_footprint:DC_DC_Converter_with_Screw_Terminal | DCDC_Output301 |
| 1 | Screw_Terminal_01x02 | TerminalBlock_Phoenix:TerminalBlock_Phoenix_PT-1,5-2-5.0-H_1x02_P5.00mm_Horizontal | DCDC_Input301 |
| 1 | TMC2209_Driver_1 | TMC2209_SILENTSTEPSTICK:MODULE_TMC2209_SILENTSTEPSTICK | Driver_401 |
| 1 | TMC2209_Driver_2 | TMC2209_SILENTSTEPSTICK:MODULE_TMC2209_SILENTSTEPSTICK | Driver_402 |
| 1 | TMC2209_Driver_3 | TMC2209_SILENTSTEPSTICK:MODULE_TMC2209_SILENTSTEPSTICK | Driver_403 |
| 1 | TMC2209_Driver_4 | TMC2209_SILENTSTEPSTICK:MODULE_TMC2209_SILENTSTEPSTICK | Driver_404 |
| 1 | TMC2209_Driver_5 | TMC2209_SILENTSTEPSTICK:MODULE_TMC2209_SILENTSTEPSTICK | Driver_405 |
It measures 149 × 113.9 mm and has 2 copper layers, 1.6 mm thick.
61 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the bumahka/Robot4Workshop repository on GitHub, at the commit this page was made from: the board is Elektronik/PCB_Layout_1_3/PCB_Layout.kicad_pcb and its schematic Elektronik/PCB_Layout/PCB_Layout.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask bumahka before reusing the design.
shanteacontrols/OpenDeck
A platform for building interactive control and sensing devices using MIDI and OSC built with Zephyr RTOS.

Neumi/open_echo
Open Source echo sounder / depth sounder / SONAR for bathymetry and research. Arduino based and compatible.

StuckAtPrototype/AirCube
Works standalone out of the box. Pairs with Home Assistant in minutes. Other platforms are supported through community-contributed extensions.

TeXitoi/keyseebee
KeySeeBee is a split ergo keyboard. It is only 2 PCB (so the name) with (almost) only SMD components on it. It's only a keyboard, no LED, no display, nothing more than keys and USB.


Jeija/esp8266-smartwatch
ESP8266 DIY WiFi Smartwatch with MPU-9250, RTC, OLED, FT232, ...

