4 layers72.4 × 45.7 mm
EasyBLDCV3 STM32
buckles3636/EasyBLDC
Please ensure your designs meet common standards and include necessary documentation and comments.
74 parts2MIT

 buckles3636/EasyBLDC2
Please ensure your designs meet common standards and include necessary documentation and comments.
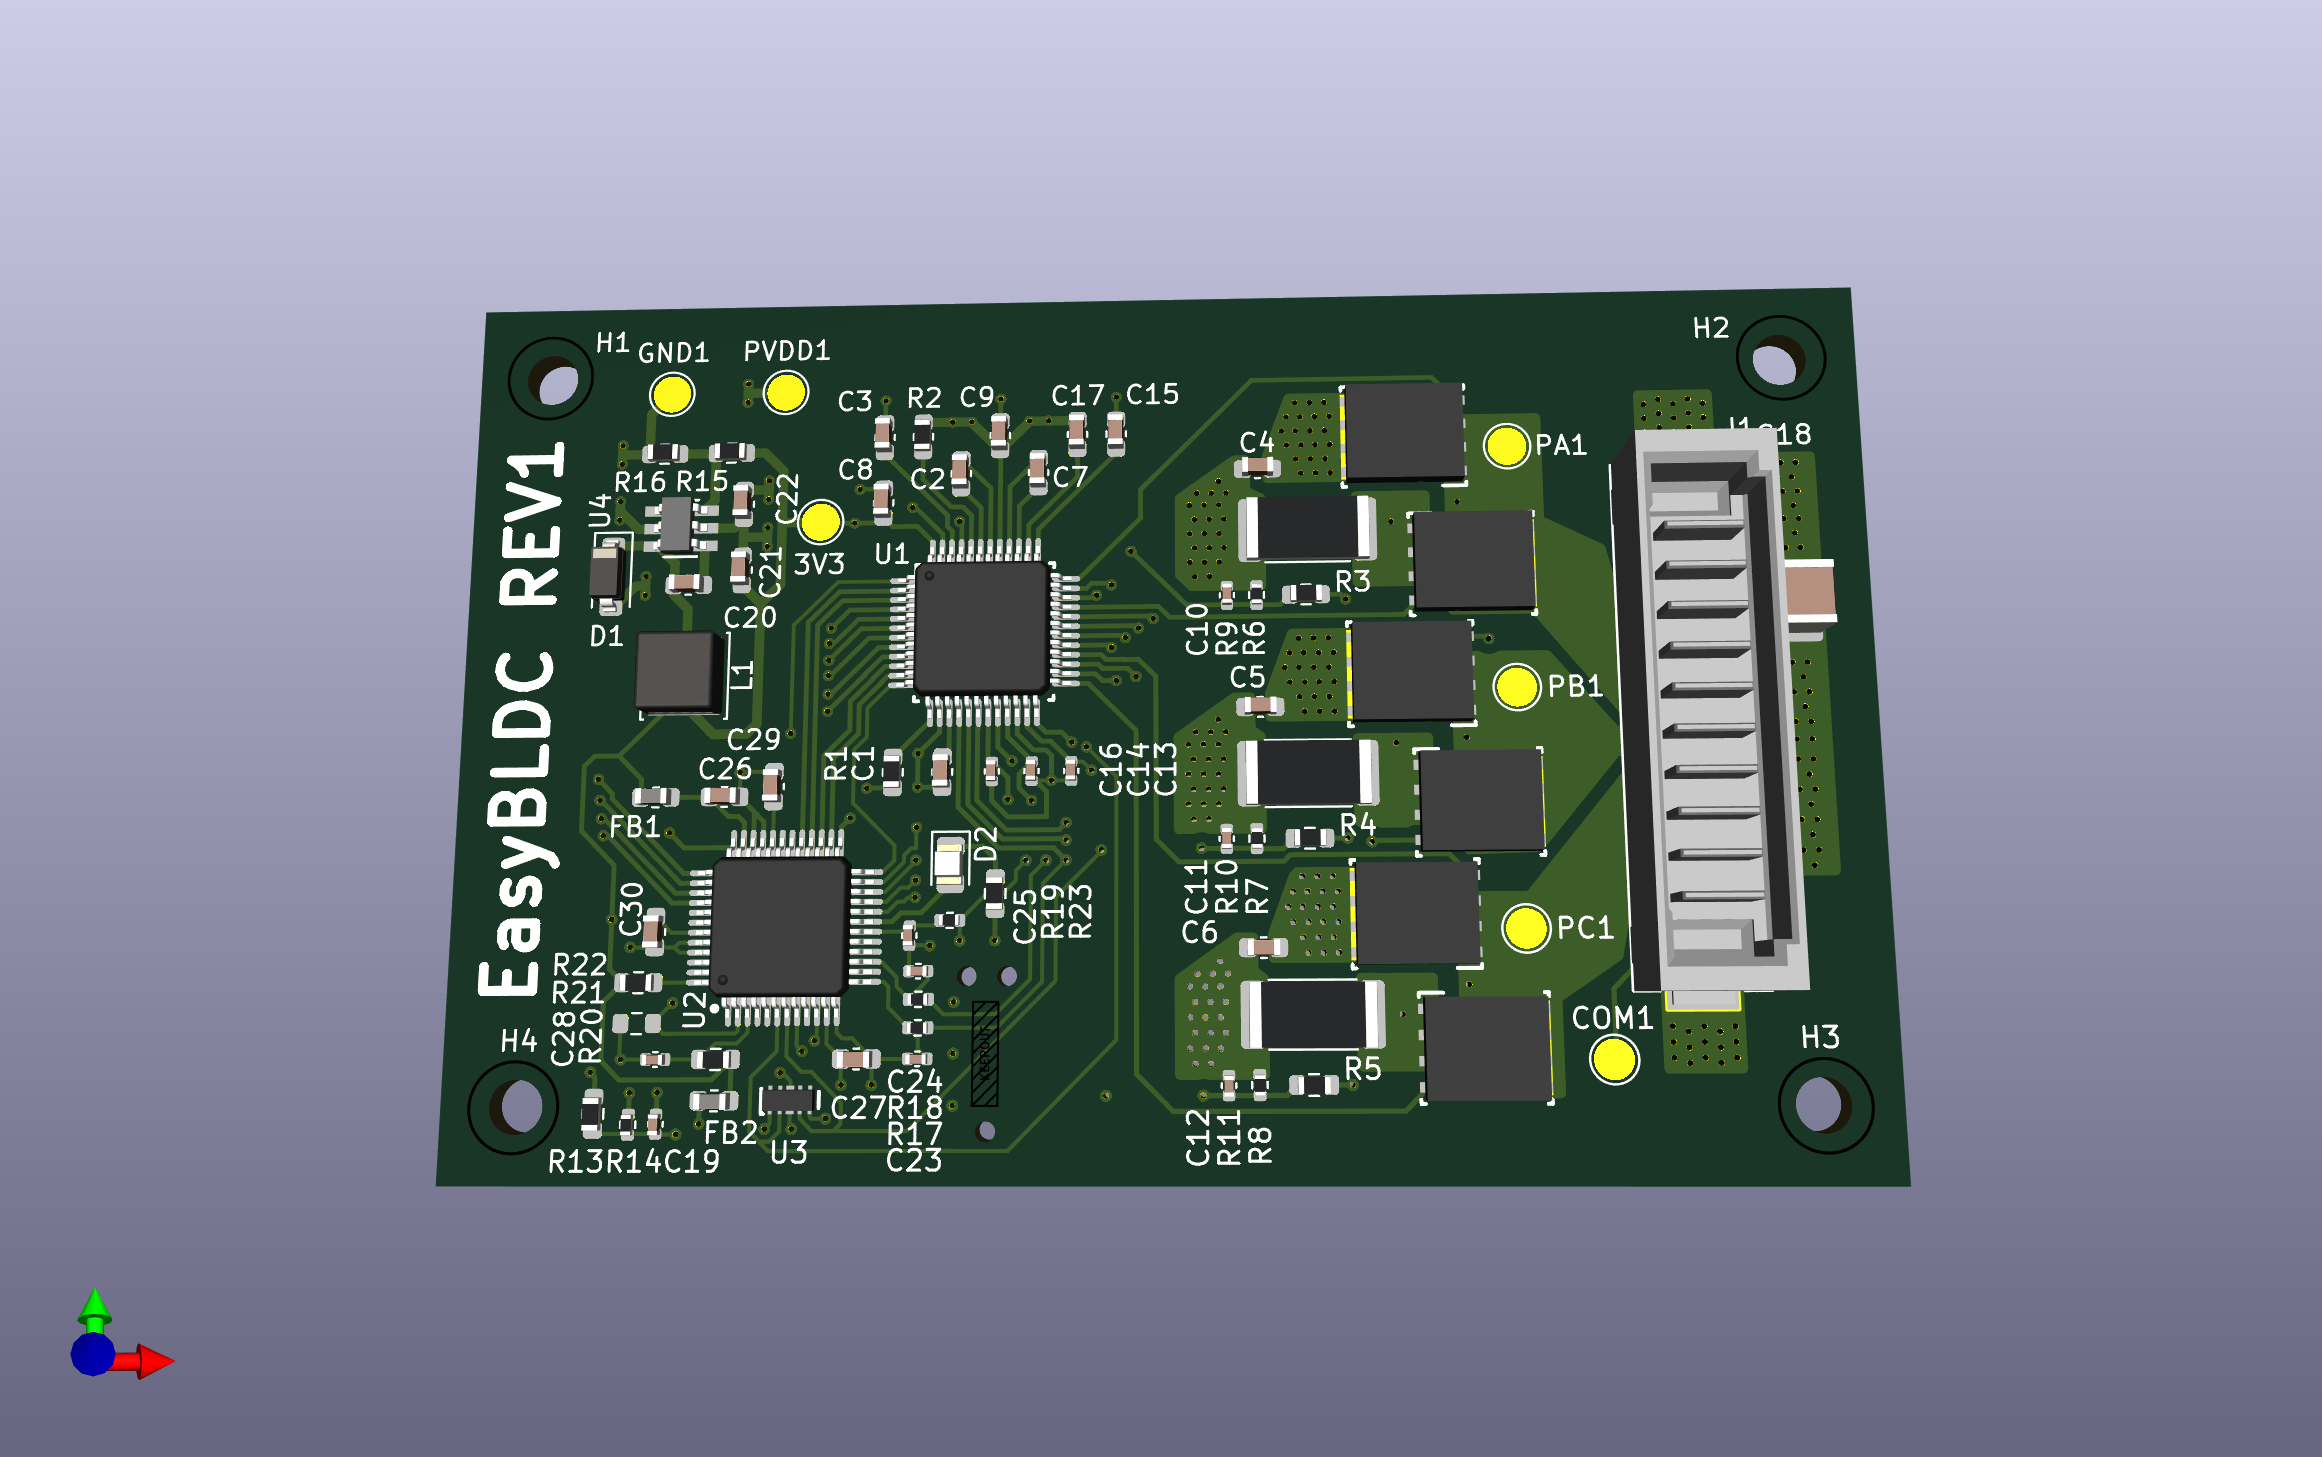
EasyBLDCV1 DRV8305 is an open-source printed circuit board by buckles3636, from the buckles3636/EasyBLDC repository on GitHub, published under the MIT licence. It is a 4-layer board of 72.4 × 45.7 mm with 79 parts on 81 nets, routed with 727 tracks and 370 vias.
It is built around the TMS320F28027FPTT, DRV83053PHP and LMR16006XDDCR, with the TPD4E05U06DQAR, CSD16556Q5B and M2.5 among its other parts. Its parts include 30 capacitors, 21 resistors, 6 transistors, 4 ICs and 2 diodes.


Easy BLDC is an open source sensorless FOC brushless dc motor driver designed for propeller thrust applications such as drones or underwater AUVS.
FOC is the most advanced of the three common algorithms. Unlike trapezoidal or sinusoidal control, which energize the motor’s phases based on predefined waveforms, FOC actively keeps tracks the stator position. This allows for precise control of both torque and speed by decoupling the motor’s magnetic field into two components: one that controls the motor's flux and the other that controls the torque. FOC is extremely efficient, especially at higher speeds, and results in smooth operation at lower speeds.
TODO:
TODO:
TODO:
We welcome contributions from the broader community. To contribute:
Please ensure your designs meet common standards and include necessary documentation and comments.
This project is licensed under the MIT License - see the LICENSE file for details.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | 1u | Capacitor_SMD:C_0603_1608Metric | C1, C3, C4, C5, C6, C8, C17, C22 |
| 7 | TestPoint | TestPoint:TestPoint_Pad_D2.0mm | 3V3, COM1, GND1, PA1, PB1, PC1, PVDD1 |
| 6 | CSD16556Q5B | EasyBLDC:DNK0008A | Q1, Q2, Q3, Q4, Q5, Q6 |
| 5 | 0.1u | Capacitor_SMD:C_0402_1005Metric | C10, C11, C12, C19, C28 |
| 5 | 2.2u | Capacitor_SMD:C_0603_1608Metric | C15, C26, C27, C29, C30 |
| 4 | 24.9K | Resistor_SMD:R_0603_1608Metric | R6, R7, R8, R13 |
| 4 | 4.99K | Resistor_SMD:R_0402_1005Metric | R9, R10, R11, R14 |
| 4 | M2.5 | MountingHole:MountingHole_2.7mm_M2.5_ISO7380 | H1, H2, H3, H4 |
| 3 | 0.007 | Resistor_SMD:R_2512_6332Metric | R3, R4, R5 |
| 3 | 1n | Capacitor_SMD:C_0402_1005Metric | C13, C14, C16 |
| 3 | 2.2n | Capacitor_SMD:C_0402_1005Metric | C23, C24, C25 |
| 3 | 56 | Resistor_SMD:R_0402_1005Metric | R17, R18, R19 |
| 2 | 47n | Capacitor_SMD:C_0603_1608Metric | C2, C7 |
| 2 | 600 | Inductor_SMD:L_0603_1608Metric | FB1, FB2 |
| 1 | 0.33u | Capacitor_SMD:C_0603_1608Metric | C20 |
| 1 | 100 | Fuse:Fuse_0603_1608Metric | R2 |
| 1 | 10159560-A00221RLF | EasyBLDC:AMPHENOL_10159560-A00221RLF | J1 |
| 1 | 10K | Resistor_SMD:R_0603_1608Metric | R22 |
| 1 | 10K | Fuse:Fuse_0603_1608Metric | R1 |
| 1 | 10u | Capacitor_SMD:C_1210_3225Metric | C18 |
| 1 | 20k | Resistor_SMD:R_0603_1608Metric | R16 |
| 1 | 22u | Capacitor_SMD:C_0603_1608Metric | C21 |
| 1 | 330 | Resistor_SMD:R_0603_1608Metric | R23 |
| 1 | 4.7u | Capacitor_SMD:C_0603_1608Metric | C9 |
| 1 | 47K | Resistor_SMD:R_0603_1608Metric | R20 |
| 1 | 68k | Resistor_SMD:R_0603_1608Metric | R15 |
| 1 | DRV83053PHP | EasyBLDC:PHP0048G_N | U1 |
| 1 | D_Schottky | Diode_SMD:D_SOD-123 | D1 |
| 1 | FTSH-105-01-F-DV-P-TR | EasyBLDC:SAMTEC_FTSH-105-01-F-DV-P-TR | J2 |
| 1 | GREEN | LED_SMD:LED_0805_2012Metric | D2 |
| 1 | LMR16006XDDCR | EasyBLDC:DDC0006A | U4 |
| 1 | SD53-120-R | Inductor_SMD:L_Changjiang_FNR4020S | L1 |
| 1 | TMS320F28027FPTT | EasyBLDC:PT0048A_N | U2 |
| 1 | TPD4E05U06DQAR | EasyBLDC:DQA0010A | U3 |
buckles3636/EasyBLDC
Please ensure your designs meet common standards and include necessary documentation and comments.

buckles3636/EasyBLDC
Please ensure your designs meet common standards and include necessary documentation and comments.

mark-belbin/motor-controller
Custom FOC motor controller designed for underwater robotics.


konrad1s/LineFollower-Kwark
Fast LineFollower Robot project. Build on STM32 F7 microcontroller with custom PCB. Software, Hardware and QT Application.


BigBroBob2/bat_tag_nrf5340dk
A custom-designed device to record free-flying bat kinematics, echos, and eye movement

zenglhardt/millimobile-platform
This repo contains the KiCad PCB design files for the development board verison of the MilliMobile. For more information on the platform, see the project page

Andreuxxx1977/esp32-p4
An open-hardware, actively cooled ESP32-P4 board for heavy multimedia work: a 2-lane MIPI camera, a 2-lane MIPI display, USB 2.0 High-Speed, 10/100 Ethernet, UHS-I microSD, 32 MB flash and 32 MB PSRAM.
It measures 72.4 × 45.7 mm and has 4 copper layers, 1.6 mm thick.
79 parts, built around the TMS320F28027FPTT, DRV83053PHP, LMR16006XDDCR and TPD4E05U06DQAR. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the buckles3636/EasyBLDC repository on GitHub, at the commit this page was made from: the board is PCB/EasyBLDCV1_DRV8305/EasyBLDCV1_DRV8305.kicad_pcb and its schematic PCB/EasyBLDCV1_DRV8305/DRV8305Breakout.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).