Skip to the content
2 layers121 × 70 mmPanzer PCB, the printed circuit board in 3D

Welcome to the RoboRacer project! This repository contains the full stack for the Omnix robot platform, including embedded firmware, Python-based visualization and configuration tools, and supporting documentation.

Size
121 × 70 mm
Copper layers
2
Thickness
1.6 mm
Parts
16
Nets
63
Pads
102
Tracks, vias
129, 7
Routed
Yes
KiCad
KiCad 9.0 (file 20241229)
Created
10 Jan 2025
Updated
4 Jul 2025

Overview

Panzer PCB is an open-source printed circuit board by brodenn, from the brodenn/RoboRacer repository on GitHub. It is a 2-layer board of 121 × 70 mm with 16 parts on 63 nets, routed with 129 tracks and 7 vias.

Its parts include 5 connectors and 2 resistors. It belongs with the ESP32 boards of this library.

README

README.md

RoboRacer

📄 Download the full report: Report ghost divsion.pdf

Welcome to the RoboRacer project! This repository contains the full stack for the Omnix robot platform, including embedded firmware, Python-based visualization and configuration tools, and supporting documentation.


Project Images

Robots
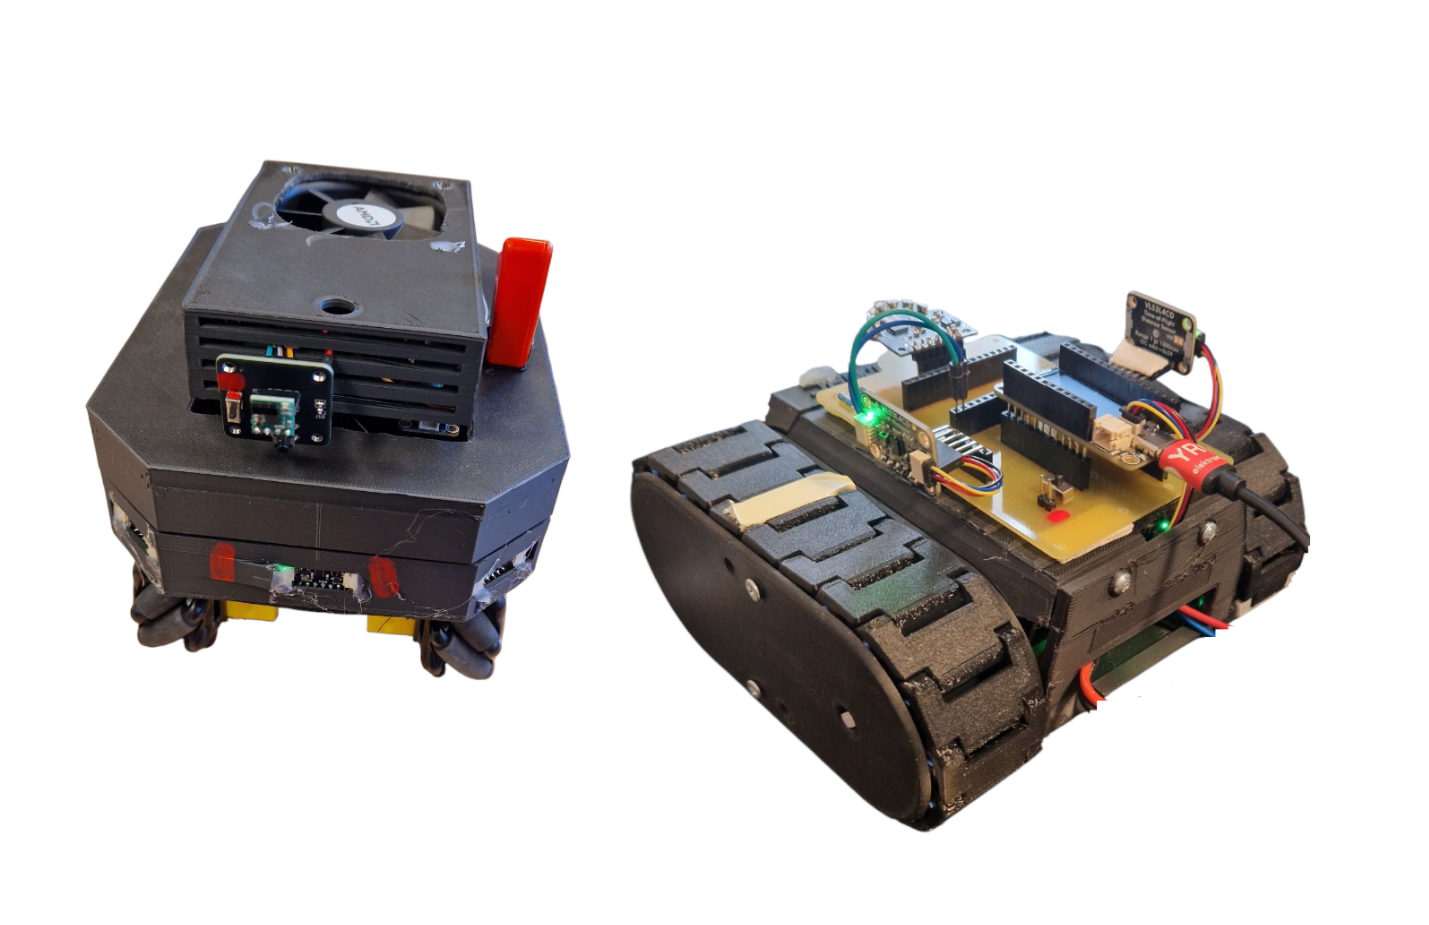
Robots


Omnix Overview

The omnix robot is a core vehicle in the RoboRacer project, equipped with omni wheels for enhanced maneuverability. It handles sensor management, motor control, AI steering, and wireless communication, and is supported by a Python toolkit for visualization and configuration.


Directory Structure

  • ai.cpp / ai.h: AI steering logic for autonomous navigation.
  • controller.cpp / controller.h: Gamepad/controller input management.
  • globals.cpp / globals.h: Global variables and constants.
  • imu.cpp / imu.h: IMU (Inertial Measurement Unit) initialization and data reading.
  • interrupts.cpp / interrupts.h: Sensor interrupt configuration and management.
  • motors.cpp / motors.h: Motor initialization and control.
  • mux.cpp / mux.h: I2C multiplexer for sensor communication.
  • params.cpp / params.h: Steering and sensor parameter management.
  • sensors.cpp / sensors.h: Sensor initialization, reading, and management.
  • tasks.cpp / tasks.h: FreeRTOS tasks for sensors, motors, and logic.
  • udp_handler.cpp / udp_comm.h: UDP communication for parameters and telemetry.
  • udp_sender.cpp: Telemetry data transmission over UDP.
  • wifi_setup.cpp / wifi_setup.h: WiFi and UDP setup.
  • xshut.cpp / xshut.h: Sensor power control via GPIO.
  • omnix_py/: Python scripts for visualization, configuration, and debugging.

Python Toolkit Overview

The omnix_py directory provides Python scripts that complement the robot's firmware:

  • main.py: Entry point for the Python tools (UI and visualizer).
  • udp_comm.py: UDP communication for telemetry and commands.
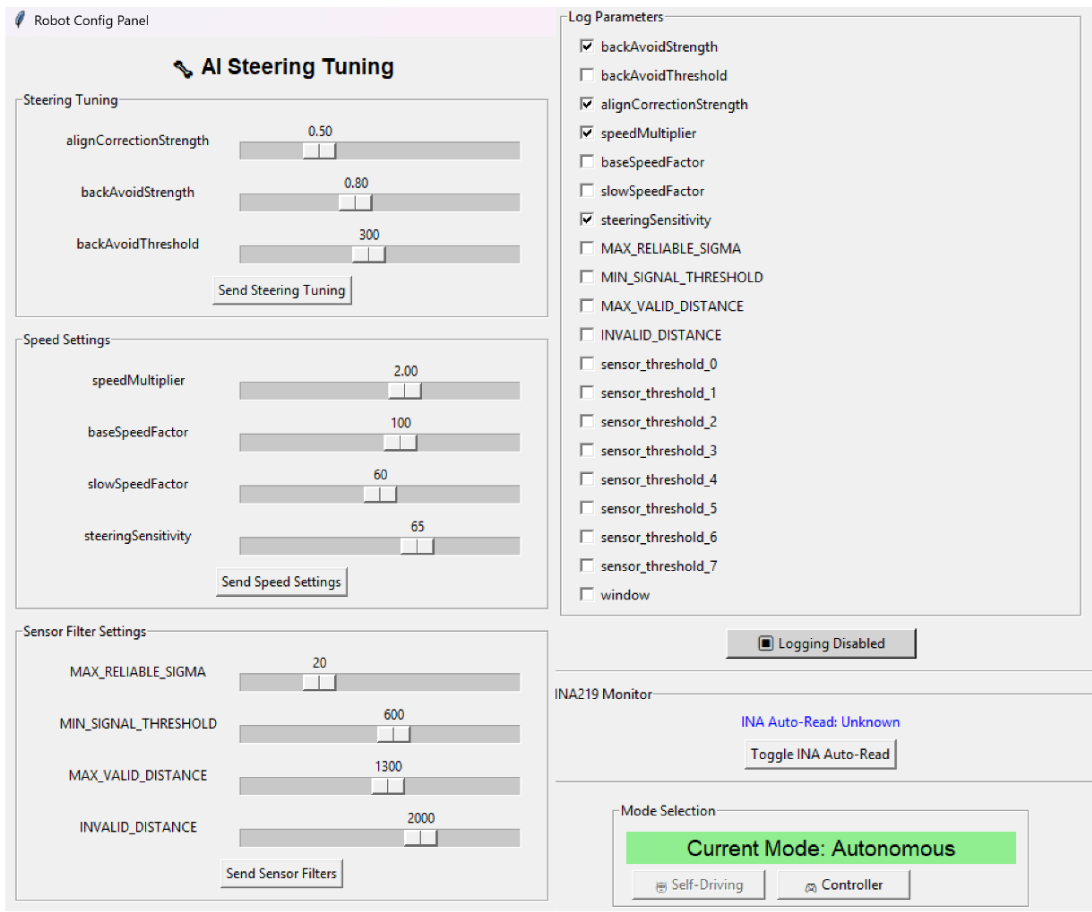
  • ui.py: Tkinter-based GUI for parameter tuning and monitoring.
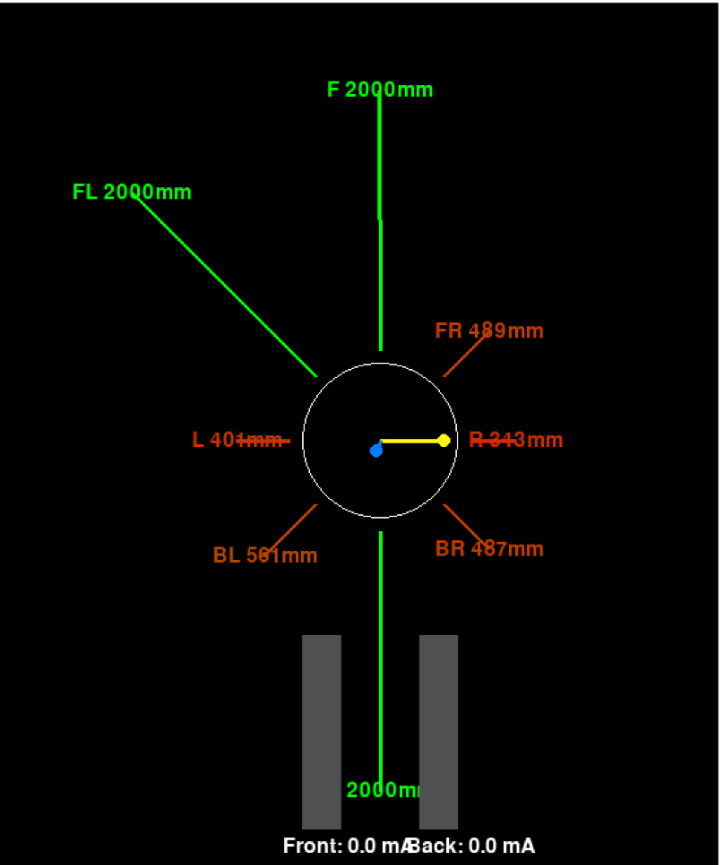
  • visualizer.py: Pygame-based visualization of sensor and IMU data.
  • config.py: Shared configuration (ports, IPs, parameters).
  • logger.py: Telemetry and sensor data logging to CSV.

Key Features

  • Omni Wheels: Smooth, precise movement in any direction.
  • Sensor Management: Multiple VL53L4CD sensors via I2C multiplexers.
  • Motor Control: Smooth updates and autonomous driving logic.
  • AI Steering: Wall centering, curve anticipation, and obstacle avoidance.
  • Wireless Communication: Real-time telemetry and parameter updates via UDP.
  • IMU Integration: Acceleration, gyroscope, and temperature data.
  • Python Tools: UI for parameter tuning and real-time telemetry visualization.

Setup Instructions

  1. Initialize the I2C buses and configure the multiplexer.
  2. Set up sensors, motors, and WiFi.
  3. Start FreeRTOS tasks for sensor reading, motor control, and auxiliary logic.
  4. Run the Python tools using python3 main.py in the omnix_py directory.

Usage

  • Autonomous Mode: AI steering logic controls the motors based on sensor data.
  • Controller Mode: Use a gamepad for manual control.
  • Python Tools: Tune parameters and monitor telemetry in real time.

Dependencies


Visualizer Example

Visualizer


Configuration GUI

GUI

Parts

16
QtyValueFootprintReferences
6, , , , ,
24,7KResistor_THT:R_Axial_DIN0414_L11.9mm_D4.5mm_P15.24mm_HorizontalR1, R2
1Adafruit-ESP32-S3-TFT-FeatherModule:Adafruit_Feather_WithMountingHolesA1
1Adafruit-MOTORSHIELDModule:Adafruit_Feather_WithMountingHolesA2
1Conn_01x07_SocketConnector_PinSocket_2.54mm:PinSocket_1x07_P2.54mm_VerticalJ2
1Kill_SwitchConnector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_VerticalJ4
1Li-Po ConnectConnector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_VerticalJ3
1SW_Wuerth_450301014042Button_Switch_THT:SW_Slide-03_Wuerth-WS-SLTV_10x2.5x6.4_P2.54mmM-C_MAINS
1VL53L4CD_LEFTConnector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_VerticalJ1
1VL53L4CD_RIGHTConnector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_VerticalJ5

More from brodenn/RoboRacer

1
  • 2 layers164.4 × 79 mmOmni X II PCB, the printed circuit board in 3D

    Omni X II PCB

    brodenn/RoboRacer

    Welcome to the RoboRacer project! This repository contains the full stack for the Omnix robot platform, including embedded firmware, Python-based visualization and configuration tools, and supporting documentation.

    23 parts

Similar boards

  • 2 layers140.5 × 30 mmType e, the printed circuit board in 3D

    Type e

    google/mozc-devices

    Circuit diagrams and firmware source code for Gboard DIY keyboards

    16 parts3kApache-2.0
  • 2 layers41.4 × 14.5 mmU2f zero, the printed circuit board in 3D

    U2f zero

    conorpp/u2f-zero

    U2F USB token optimized for physical security, affordability, and style

    16 parts2.4k
  • 2 layers122 × 37 mmV0-UmbilicalBoard, the printed circuit board in 3D

    V0-UmbilicalBoard

    VoronDesign/Voron-Hardware

    Cool Hardware designed by the Voron Design group

    16 parts1.1kGPL-3.0
  • 2 layers152 × 57.6 mmVideoslotadapter, the printed circuit board in 3D

    Videoslotadapter

    hoglet67/RGBtoHDMI

    Bare-metal Raspberry Pi project that provides pixel-perfect sampling of Retro Computer RGB/YUV video and conversion to HDMI

    16 parts1kGPL-3.0
  • 2 layers36 × 63.4 mmSmart ringfinal layout, the printed circuit board in 3D

    Smart ringfinal layout

    hackclub/OnBoard

    💡 Join 1,000 teenagers and make your first PCB with a $100 grant!

    16 parts915
  • 2 layers60 × 40 mmHASwitchPlate, the printed circuit board in 3D

    HASwitchPlate

    aderusha/HASwitchPlate

    LCD touchscreen for Home Automation

    16 parts738MIT
  • 2 layers21.1 × 26.9 mmDemo, the printed circuit board in 3D

    Demo

    easyw/kicadStepUpMod

    kicadStepUp: ECAD to MCAD FreeCAD WorkBench

    16 parts704

Questions

How big is the Panzer PCB PCB?

It measures 121 × 70 mm and has 2 copper layers, 1.6 mm thick.

What parts does the Panzer PCB use?

16 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.

Where can I download the Panzer PCB KiCad files?

From the brodenn/RoboRacer repository on GitHub, at the commit this page was made from: the board is Panzer/Panzer_PCB/Panzer_PCB/Panzer_PCB.kicad_pcb and its schematic Omni_X-PCB/Omni-X-II-PCB/Omni-X-II-PCB.kicad_sch. PCBKit opens the board in the browser, with nothing to install.

Can I use the Panzer PCB design in my own project?

Its repository states no licence, so its author keeps all rights: ask brodenn before reusing the design.