2 layers91.4 × 71.1 mm
Pico w rover
NikodemBartnik/Mini-Mars-Rover
Educational robotic platform made to look like a mini mars rover
20 parts143MIT
 bnahill/rf-controller1
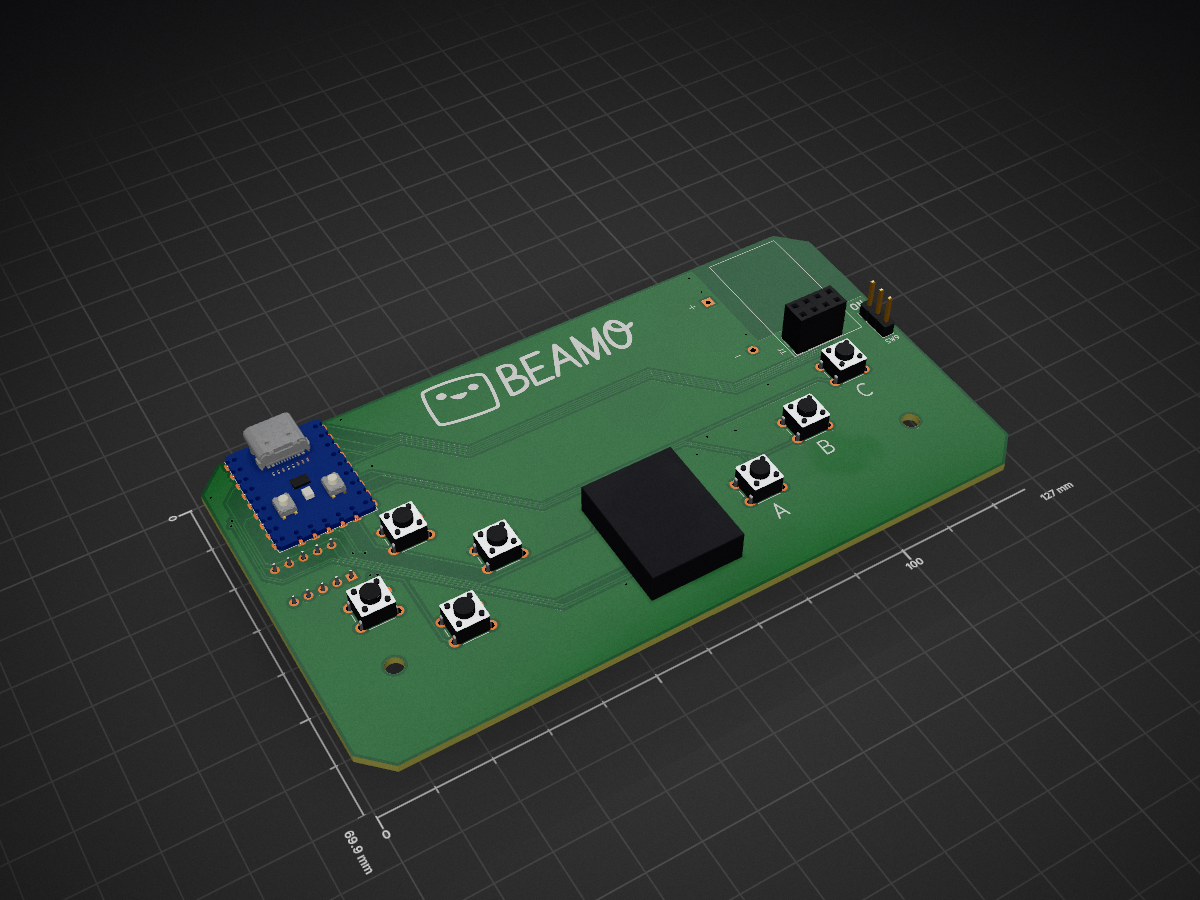
BEAMO is a simple, low-cost RF remote controller for robots and toys based on the common nRF24L01+ and its more ubiquitous counterfeits.
Rf controller hw is an open-source printed circuit board by bnahill, from the bnahill/rf-controller repository on GitHub. It is a 2-layer board of 127 × 69.9 mm with 16 parts on 26 nets, routed with 185 tracks and 19 vias.
It is built around the NRF24L01 and RP2040-ZERO. Its parts include 10 switches and 1 connector. It belongs with the radio and wireless boards and the RP2040 boards of this library.


BEAMO is a simple, low-cost RF remote controller for robots and toys based on the common nRF24L01+ and its more ubiquitous counterfeits. 32 may be operated in the same space by selecting different channels using the configuration DIP switch.
The board itself is a simple 2-layer PCB designed to be operated without an enclosure. There are mounting holes to allow attachment of a custom grip.
Example receiver code has been tested on an Arduino Uno using a matching nRF24L01+ module.
The remote is intended for real-time control of a vehicle. As such, it sends button updates at a minimum of every 100ms. When the data changes, it may send as frequently as every 10ms.
The remote firmware was built in PlatformIO (for Raspberry Pi Pico) but should also be portable to the Arduino IDE. The receiver example for Arduino Uno is built in the Arduino IDE.
| Reference | Name | Approx Cost | Description |
|---|---|---|---|
| RZ1 | RP2040-Zero | $3.25 | Inexpensive RP2040-based microcontroller board |
| J1 | nRF24L01+ module | $2.60/pair | RF module (affixed with 2x4 0.1" connector) |
| SW1-4, SW6-8 | TS02-66-50-BK-100-SCR-D | $0.56 per 7 | Pushbuttons (low-force) |
| SW10 | DS04-254-1L-05BK | $0.64 | 5-position DIP switch |
| SW5 | PS4 controller joystick | $1.30 | Generic PS4 joystick (ALPS TKJXV1224-like) |
| SW9 | 0.1" SPDT switch | $0.10 | Slide switch (for power) |
| BT1 | 2xAA battery holder | $0.75 | Battery holder (held on with double-sided tape) |
| Qty | Value | Footprint | References |
|---|---|---|---|
| 7 | SW_Push | Button_Switch_THT:SW_PUSH_6mm_H5mm | SW1, SW2, SW3, SW4, SW6, SW7, SW8 |
| 1 | Battery | rf_controller_hw:2AA_BATTERY | BT1 |
| 1 | JOYSTICK_BUTTON | rf_controller_hw:ALPS_RKJXV1224 | SW5 |
| 1 | LOGO | rf_controller_hw:beamo | G*** |
| 1 | NRF24L01 | rf_controller_hw:NRF24L01+ | J1 |
| 1 | RP2040-Zero | rf_controller_hw:RP2040-Zero | RZ1 |
| 1 | SW_DIP_x05 | Button_Switch_THT:SW_DIP_SPSTx05_Slide_9.78x14.88mm_W7.62mm_P2.54mm | SW10 |
| 1 | SW_SPDT | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | SW9 |
The 14 most common of 16 parts.
It measures 127 × 69.9 mm and has 2 copper layers, 1.6 mm thick.
16 parts, built around the NRF24L01 and RP2040-ZERO. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the bnahill/rf-controller repository on GitHub, at the commit this page was made from: the board is rf_controller_hw/rf_controller_hw.kicad_pcb and its schematic rf_controller_hw/rf_controller_hw.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask bnahill before reusing the design.
NikodemBartnik/Mini-Mars-Rover
Educational robotic platform made to look like a mini mars rover

DAlexis/caustic-lasertag-system
Caustic project is a full-featured indoor and outdoor lasertag system

CGrassin/biosignals
Board for the acquisition of bio-potentials (EMG, ECG, EEG, etc.).

microdynamics-robot-quadcopter/breeze_electronics_design
This project is created and managed by EDA softwares, which contains the breeze quadcopter's component library, footprint library, schematic, printed circuit boards, etc.


