2 layers83.8 × 63.5 mm

 bluecube/line_follower3
Simple line follower robot
Line follower is an open-source printed circuit board by bluecube, from the bluecube/line_follower repository on GitHub, published under the Unlicense licence. It is a 2-layer board of 83.5 × 93.3 mm with 48 parts on 37 nets, routed with 455 tracks and 36 vias.
It is built around the LF50CDT-TR, APT2012EC and XT30PW-M. Its parts include 11 capacitors, 7 resistors, 6 diodes, 5 transistors and 3 ICs. It belongs with the robots and motor control boards and the ESP32 boards of this library.


This is a robot I made to tinker with and to compete in the Robotic Day competition. (Actually the original goal was Robotic Day 2016, but stuff got delayed :) )
The design is an attempt to make a line follower with minimum effort on the hardware side and maximum versatility on the software side.
The robot body consists of a 8cm x 10cm double sided PCB, two geared N20 DC encoder motors with Pololu wheels and magnetic encoders and a few 3D printed bits. The most important electronic components are ESP32 development board for computing power and line sensor inspired by Ondřej Staněk's PocketBot, as a bonus the robot also carries an IR range sensor and MPU 6050 breakout board (accelerometer and gyro).
This repository should contain everything necessary to build and run the robot in the competition. Let me know if you decide to build it!
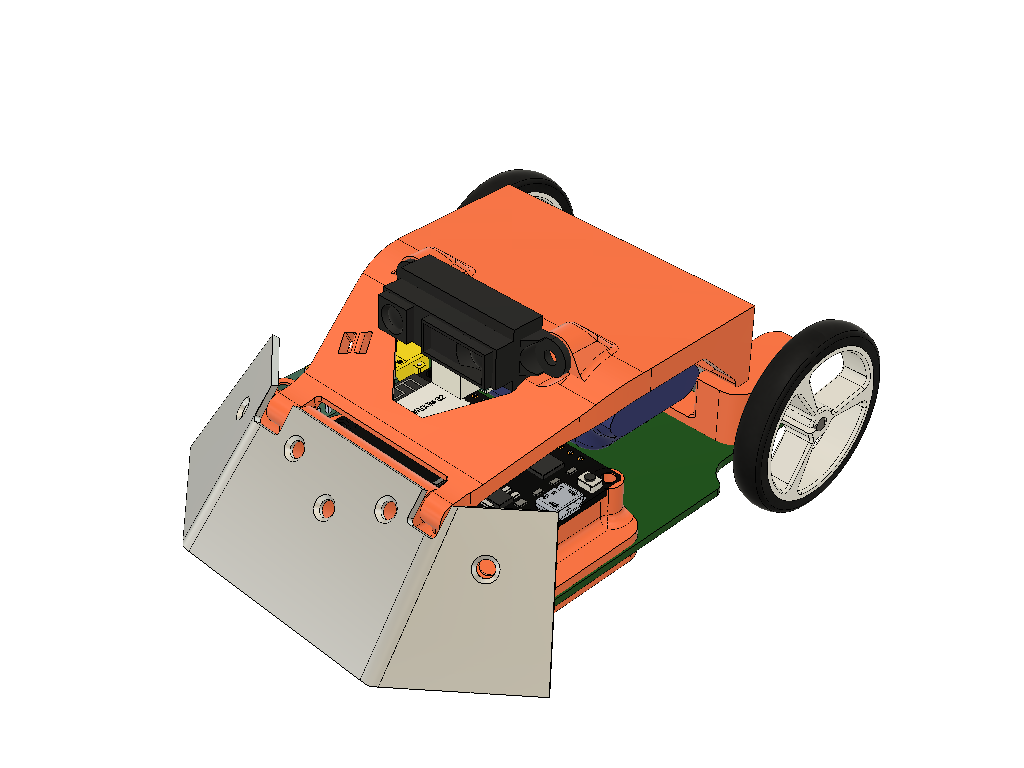
This is a v2, you can also check out the v1.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | 100nF | Capacitor_SMD:C_0805_2012Metric_Pad1.15x1.40mm_HandSolder | C1, C2, C3, C4, C5, C6, C7, C10 |
| 6 | APT2012EC | LED_SMD:LED_0805_2012Metric_Pad1.15x1.40mm_HandSolder | D1, D2, D3, D4, D5, D6 |
| 5 | 5k6 | Resistor_SMD:R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R1, R2, R3, R4, R5 |
| 5 | ALS-PT19-315C_L177_TR8 | cube-library:phototransistor-1.7mm | Q1, Q2, Q3, Q4, Q5 |
| 5 | MountingHole | MountingHole:MountingHole_3.2mm_M3 | H1, H2, H3, H4, H5 |
| 4 | Heatsink_Pad | cube-library:3x3_thermal_vias | HS1, HS2, HS3, HS4 |
| 2 | 100uF, 25V | Capacitor_SMD:CP_Elec_6.3x5.8 | C8, C9 |
| 2 | A4950E | cube-library:SOIC-8-1EP_3.9x4.9mm_P1.27mm_EP2.41x3.3mm_HandSolder | U1, U2 |
| 2 | MOTOR_ENC | cube-library:SolderWirePad2x3_p2.54_staggered | M1, M2 |
| 1 | 15k | Resistor_SMD:R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R7 |
| 1 | 22uF | Capacitor_SMD:C_0805_2012Metric_Pad1.15x1.40mm_HandSolder | C11 |
| 1 | 82k | Resistor_SMD:R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R6 |
| 1 | DISTANCE_SENSOR | cube-library:SolderWirePad1x3_p2.54 | X3 |
| 1 | ESP32_DEVKITV1 | cube-library:ESP32_DEVKITV1 | X1 |
| 1 | GY-521-module | cube-library:GY-521-module | X2 |
| 1 | LF50CDT | Package_TO_SOT_SMD:TO-252-2 | U3 |
| 1 | SW_Push | cube-library:4.5mm_tact_switch | SW1 |
| 1 | XT30PW-M | cube-library:XT30PW-M | J1 |
It measures 83.5 × 93.3 mm and has 2 copper layers, 1.6 mm thick.
48 parts, built around the LF50CDT-TR, APT2012EC and XT30PW-M. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the bluecube/line_follower repository on GitHub, at the commit this page was made from: the board is kicad/line_follower.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the Unlicense licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).

ODDepot/RAMPS-WiFi-Adapter
The RAMPS WiFi Adapter provides wireless networking for RepRap's RAMPS (Arduino Mega Pololu Shield) controller.


Soulboy420/BP_flappyBird
Eigenständiger KiCad-10-Entwurf für das HAW-Bachelorprojekt. Der ursprüngliche Entwurf unter hardware/ und absichtliche Benutzerlöschungen wurden nicht überschrieben. Es wurde nichts bestellt, committed oder gepusht.


nasheed-x/aether
Aether is a versatile flight computer for testing flight hardware and software, focusing on sensor fusion to monitor rocket states and interface with on-board systems.