

2 layers78 × 60 mm

Open Smart Motor Platform
MHC C is an open-source printed circuit board by bamboo-dynamics, from the bamboo-dynamics/OSMP repository on GitHub. It is a 2-layer board of 41.3 × 42 mm with 44 parts on 25 nets, routed with 81 tracks and 19 vias.
It is built around the AZRS3080E. Its parts include 12 connectors, 9 capacitors, 8 resistors, 6 ICs and 5 diodes. It belongs with the robots and motor control boards and the PIC boards of this library.
OSMP (Open Smart Motor Platform) is an open-source hardware and firmware ecosystem specifically optimized for Warehouse Conveyor Systems and automated material handling.
The platform provides a high-precision Hall-sensor interface and integrated memory storage, designed to be embedded within brushless motors used in conveyor rollers, sorters, and AGV/AMR peripheral modules.
The OSMP hardware is fully validated and optimized for use with Bamboo Dynamics TCN-20xZ series controllers. This combination enables high-reliability signal feedback and coordinated motion for synchronized multi-axis conveyor segments.
/Gerber: Industry-standard manufacturing files for PCB fabrication.MHC-C.kicad_sch / MHC-C.kicad_pcb: KiCad design files.MHC-C_V1.pdf: Complete circuit schematic.MHC-C_BOM.xlsx: Detailed Bill of Materials.MHC-C_production.hex: Compiled production firmware binary.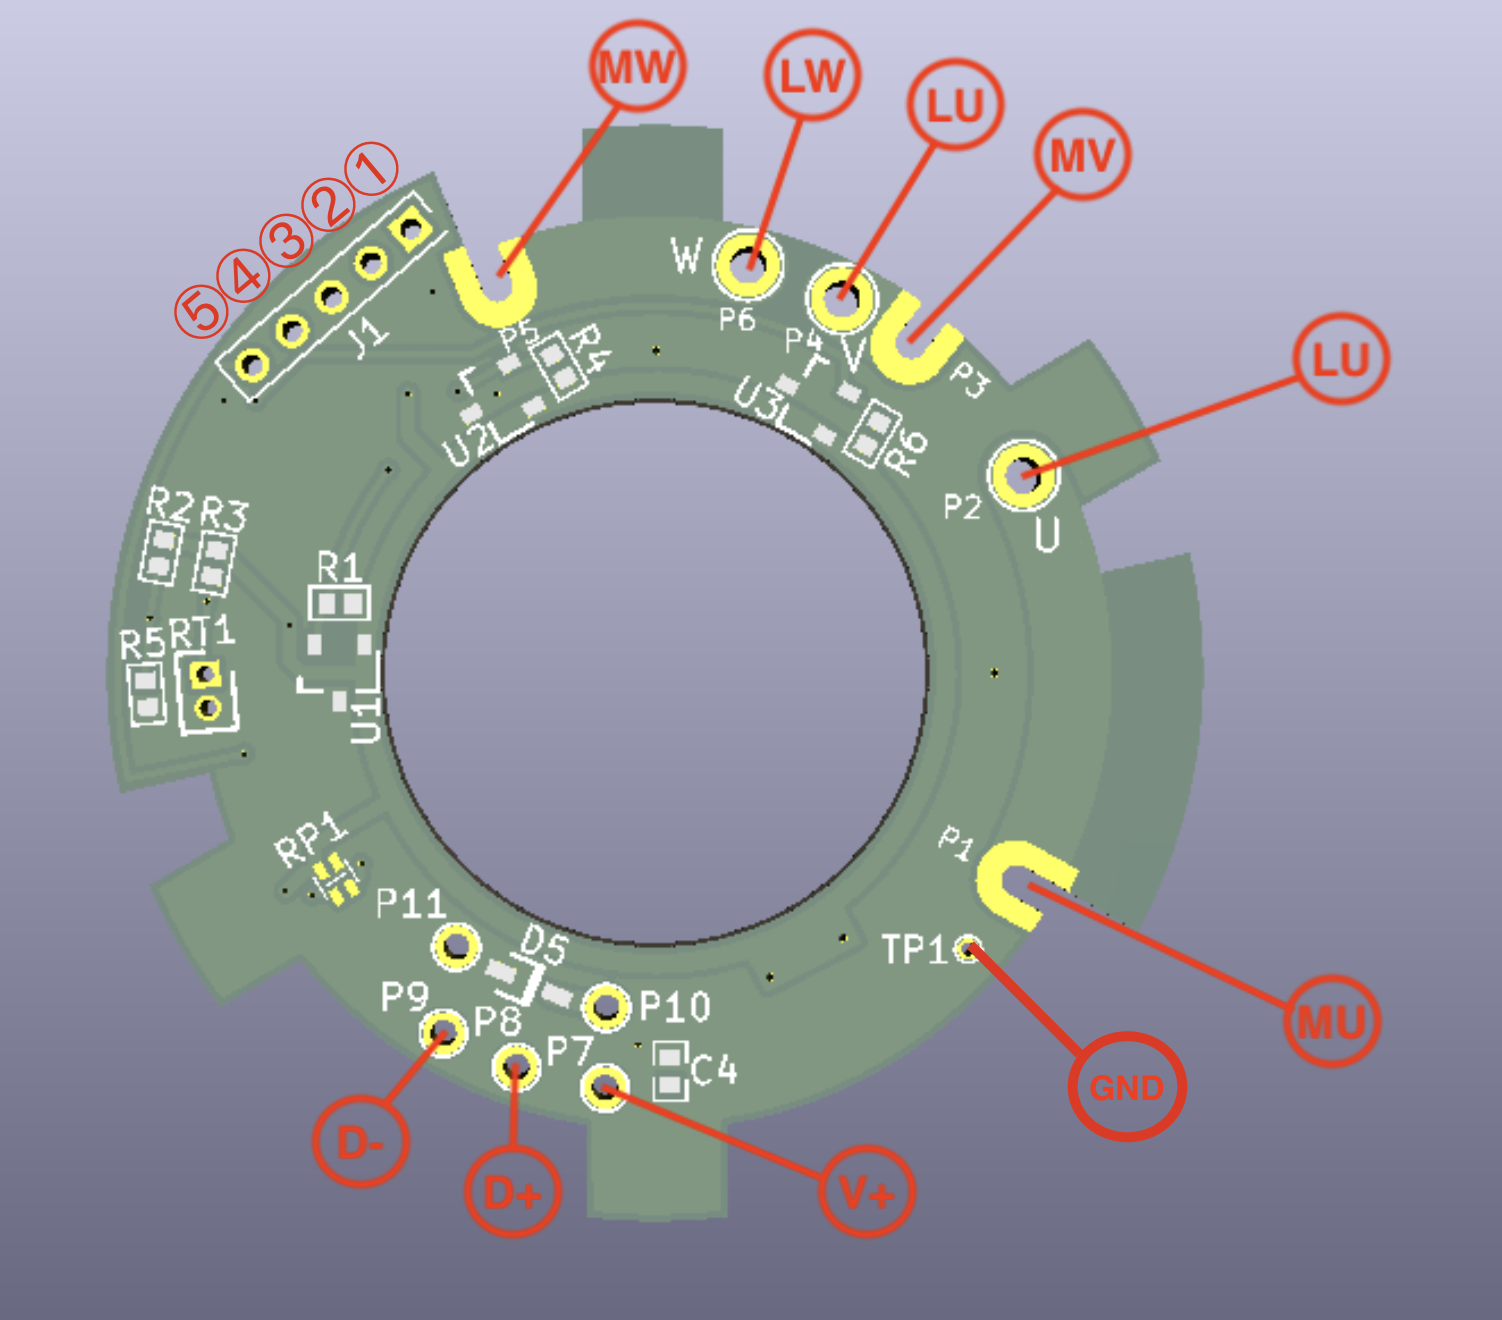
The OSMP board is designed to be adaptable to various motor mechanical designs.
MHC-C.kicad_pcb). Modify the PCB outline and sensor placement in the Gerber files to match the specific internal mounting points and dimensions of your motor housing.To flash the production firmware onto the MCU:
| Pin | Description | Board |
|---|---|---|
| 1 | MCLR/VPP | ① |
| 2 | VDD Target | ② |
| 3 | VSS (Ground) | ③ |
| 4 | PGD (ICSPDAT) | ④ |
| 5 | PGC (ICSPCLK) | ⑤ |
| 6 | PGM (LVP) |
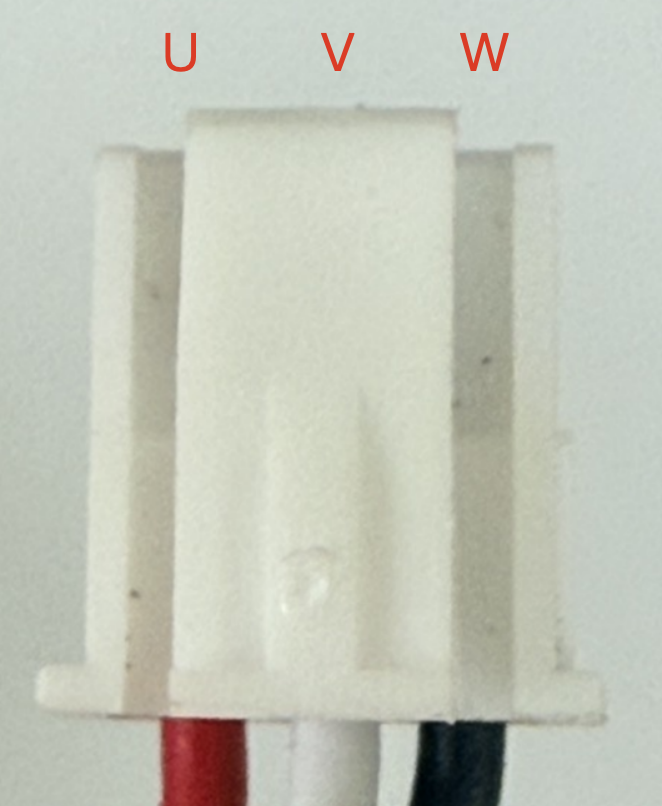
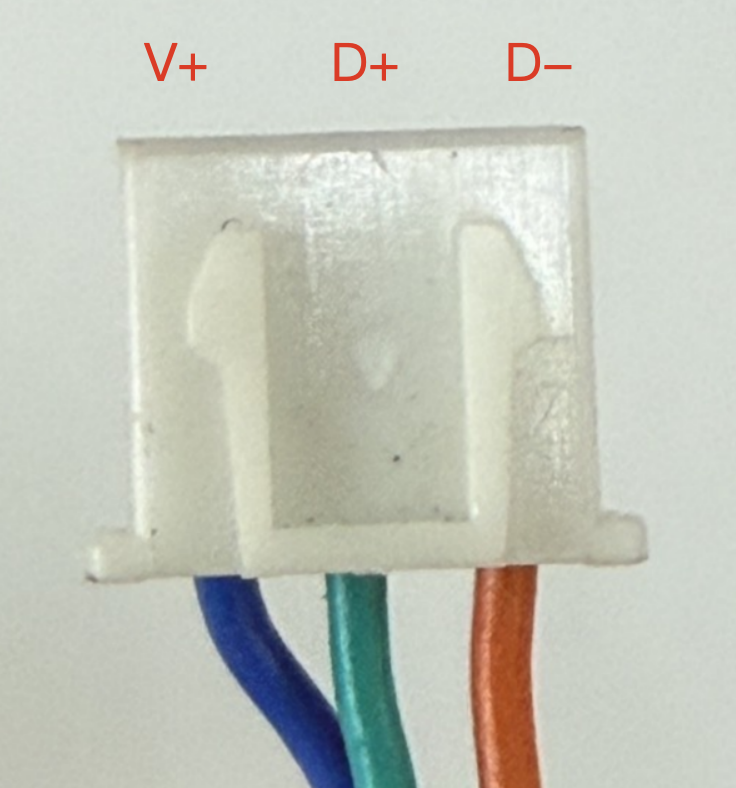
MHC-C_production.hex file.To ensure stable operation in warehouse conveyor environments, follow the wiring table below to connect the OSMP board to your power supply and motor components.
| Interface | Board | Signal | Description |
|---|---|---|---|
| U | LU | U Phase | TE 1744417-3 Line U Phase |
| V | LV | V Phase | TE 1744417-3 Line V Phase |
| W | LW | U Phase | TE 1744417-3 Line U Phase |
| V+ | V+ | VCC+ | XHP-3 VCC+ |
| D+ | D+ | Data+ | XHP-3 Data+ |
| D- | D- | Data- | XHP-3 Data- |
| Motor Coil U | MU | U Phase | Motor U Phase |
| Motor Coil V | MV | V Phase | Motor V Phase |
| Motor Coil W | MW | W Phase | Motor W Phase |
Copyright © 2026 Bamboo Dynamics Corporation., Ltd. | Developed by BlackBear TechHive.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 7 | 100nF/50V | Bamboo:C0402 | C1, C2, C4, C6, C7, C8, C9 |
| 7 | 10kΩ-1/16W | Bamboo:R0402 | R1, R2, R3, R4, R5, R6, R7 |
| 4 | 60V-1A | Bamboo:SOD323_1 | D1, D2, D3, D5 |
| 3 | DRV5011 | Bamboo:DRV5011 | U1, U2, U3 |
| 2 | 2.2uF/50V | Bamboo:C0805 | C3, C5 |
| 1 | 100Ω-1/16W | Bamboo:R0402 | R8 |
| 1 | 10kΩ-1/16W | Bamboo:RP_4P2R(0402X2)_1 | RP1 |
| 1 | 10kΩ-3435K | Bamboo:HEADER_1.27_2.54X2.1X(3X1X2.3)_1X2P | RT1 |
| 1 | 10Ω-1/16W | Bamboo:RP_4P2R(0402X2)_1 | RP2 |
| 1 | 15Vz-1W | Bamboo:SOD123_1 | D4 |
| 1 | 1x5P-2.0mm | Bamboo:HEADER_2.0MM_1X5P | J1 |
| 1 | AZRS3080 | Bamboo:SO8_1 | U6 |
| 1 | LM1117-5.0M3 | Bamboo:SOT-89 | U4 |
| 1 | PIC16F18325-xJQ | Package_DFN_QFN:UQFN-16-1EP_4x4mm_P0.65mm_EP2.6x2.6mm | U5 |
| 1 | TO Brake+ | Bamboo:PTH_1.0 | P10 |
| 1 | TO Brake- | Bamboo:PTH_1.0 | P11 |
| 1 | TO cable_12Vin | Bamboo:PTH_1.0 | P7 |
| 1 | TO cable_485+ | Bamboo:PTH_1.0 | P8 |
| 1 | TO cable_485- | Bamboo:PTH_1.0 | P9 |
| 1 | To stator_U | Bamboo:PAD_U_DIP | P1 |
| 1 | To stator_V | Bamboo:PAD_U_DIP | P3 |
| 1 | To stator_W | Bamboo:PAD_U_DIP | P5 |
| 1 | U | Bamboo:PTH_1.4 | P2 |
| 1 | V | Bamboo:PTH_1.4 | P4 |
| 1 | W | Bamboo:PTH_1.4 | P6 |
| 1 | ~ | Bamboo:TESTPOINT4 | TP1 |
It measures 41.3 × 42 mm and has 2 copper layers, 1 mm thick.
44 parts, built around the AZRS3080E. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the bamboo-dynamics/OSMP repository on GitHub, at the commit this page was made from: the board is MHC-C.kicad_pcb and its schematic MHC-C.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask bamboo-dynamics before reusing the design.


mudmin/AnotherMaker
This is where I will store code snippets for AnotherMaker Videos

qbancoffee/imac_g3_ivad_board_init
iMac G3 IVAD board initialization with an arduino

Stefan-Olt/MISRC
MISRC Is a multi channel RF capture device for FM RF, S-Video, CVBS RAW capture and anything else, but intended and supported for the decode family of projects vhs-decode, ld-decode, hifi-decode.
