

6 layers100 × 60 mm
Aether
nasheed-x/aether
Aether is a versatile flight computer for testing flight hardware and software, focusing on sensor fusion to monitor rocket states and interface with on-board systems.
180 parts10

 anchit92/Open-Source-RaceBox-mini-Emulator68
Open Source RaceBox mini emulator
Seeed studio GNSS is an open-source printed circuit board by anchit92, from the anchit92/Open-Source-RaceBox-mini-Emulator repository on GitHub, published under the GPL-3.0 licence. It is a 2-layer board of 47.5 × 21 mm with 11 parts on 31 nets, routed with 88 tracks and 13 vias.
It is built around the SAM-M10Q-00B and AO3401A. Its parts include 5 resistors, 2 ICs and 1 transistor. It belongs with the radio and wireless boards and the nRF52 and nRF5x boards of this library.
Disclaimer: This project is independent and open-source. It is not affiliated with, endorsed by, or officially connected to RaceBox. The name “RaceBox Mini” is used only to describe compatibility.
This project provides firmware for an ESP32-based device that acts as a high-performance GPS/IMU Bluetooth Low Energy (BLE) broadcaster. It integrates a U-blox GNSS module for precise position, velocity, and timing data at 25Hz, along with an MPU6050 accelerometer and gyroscope for motion sensing.
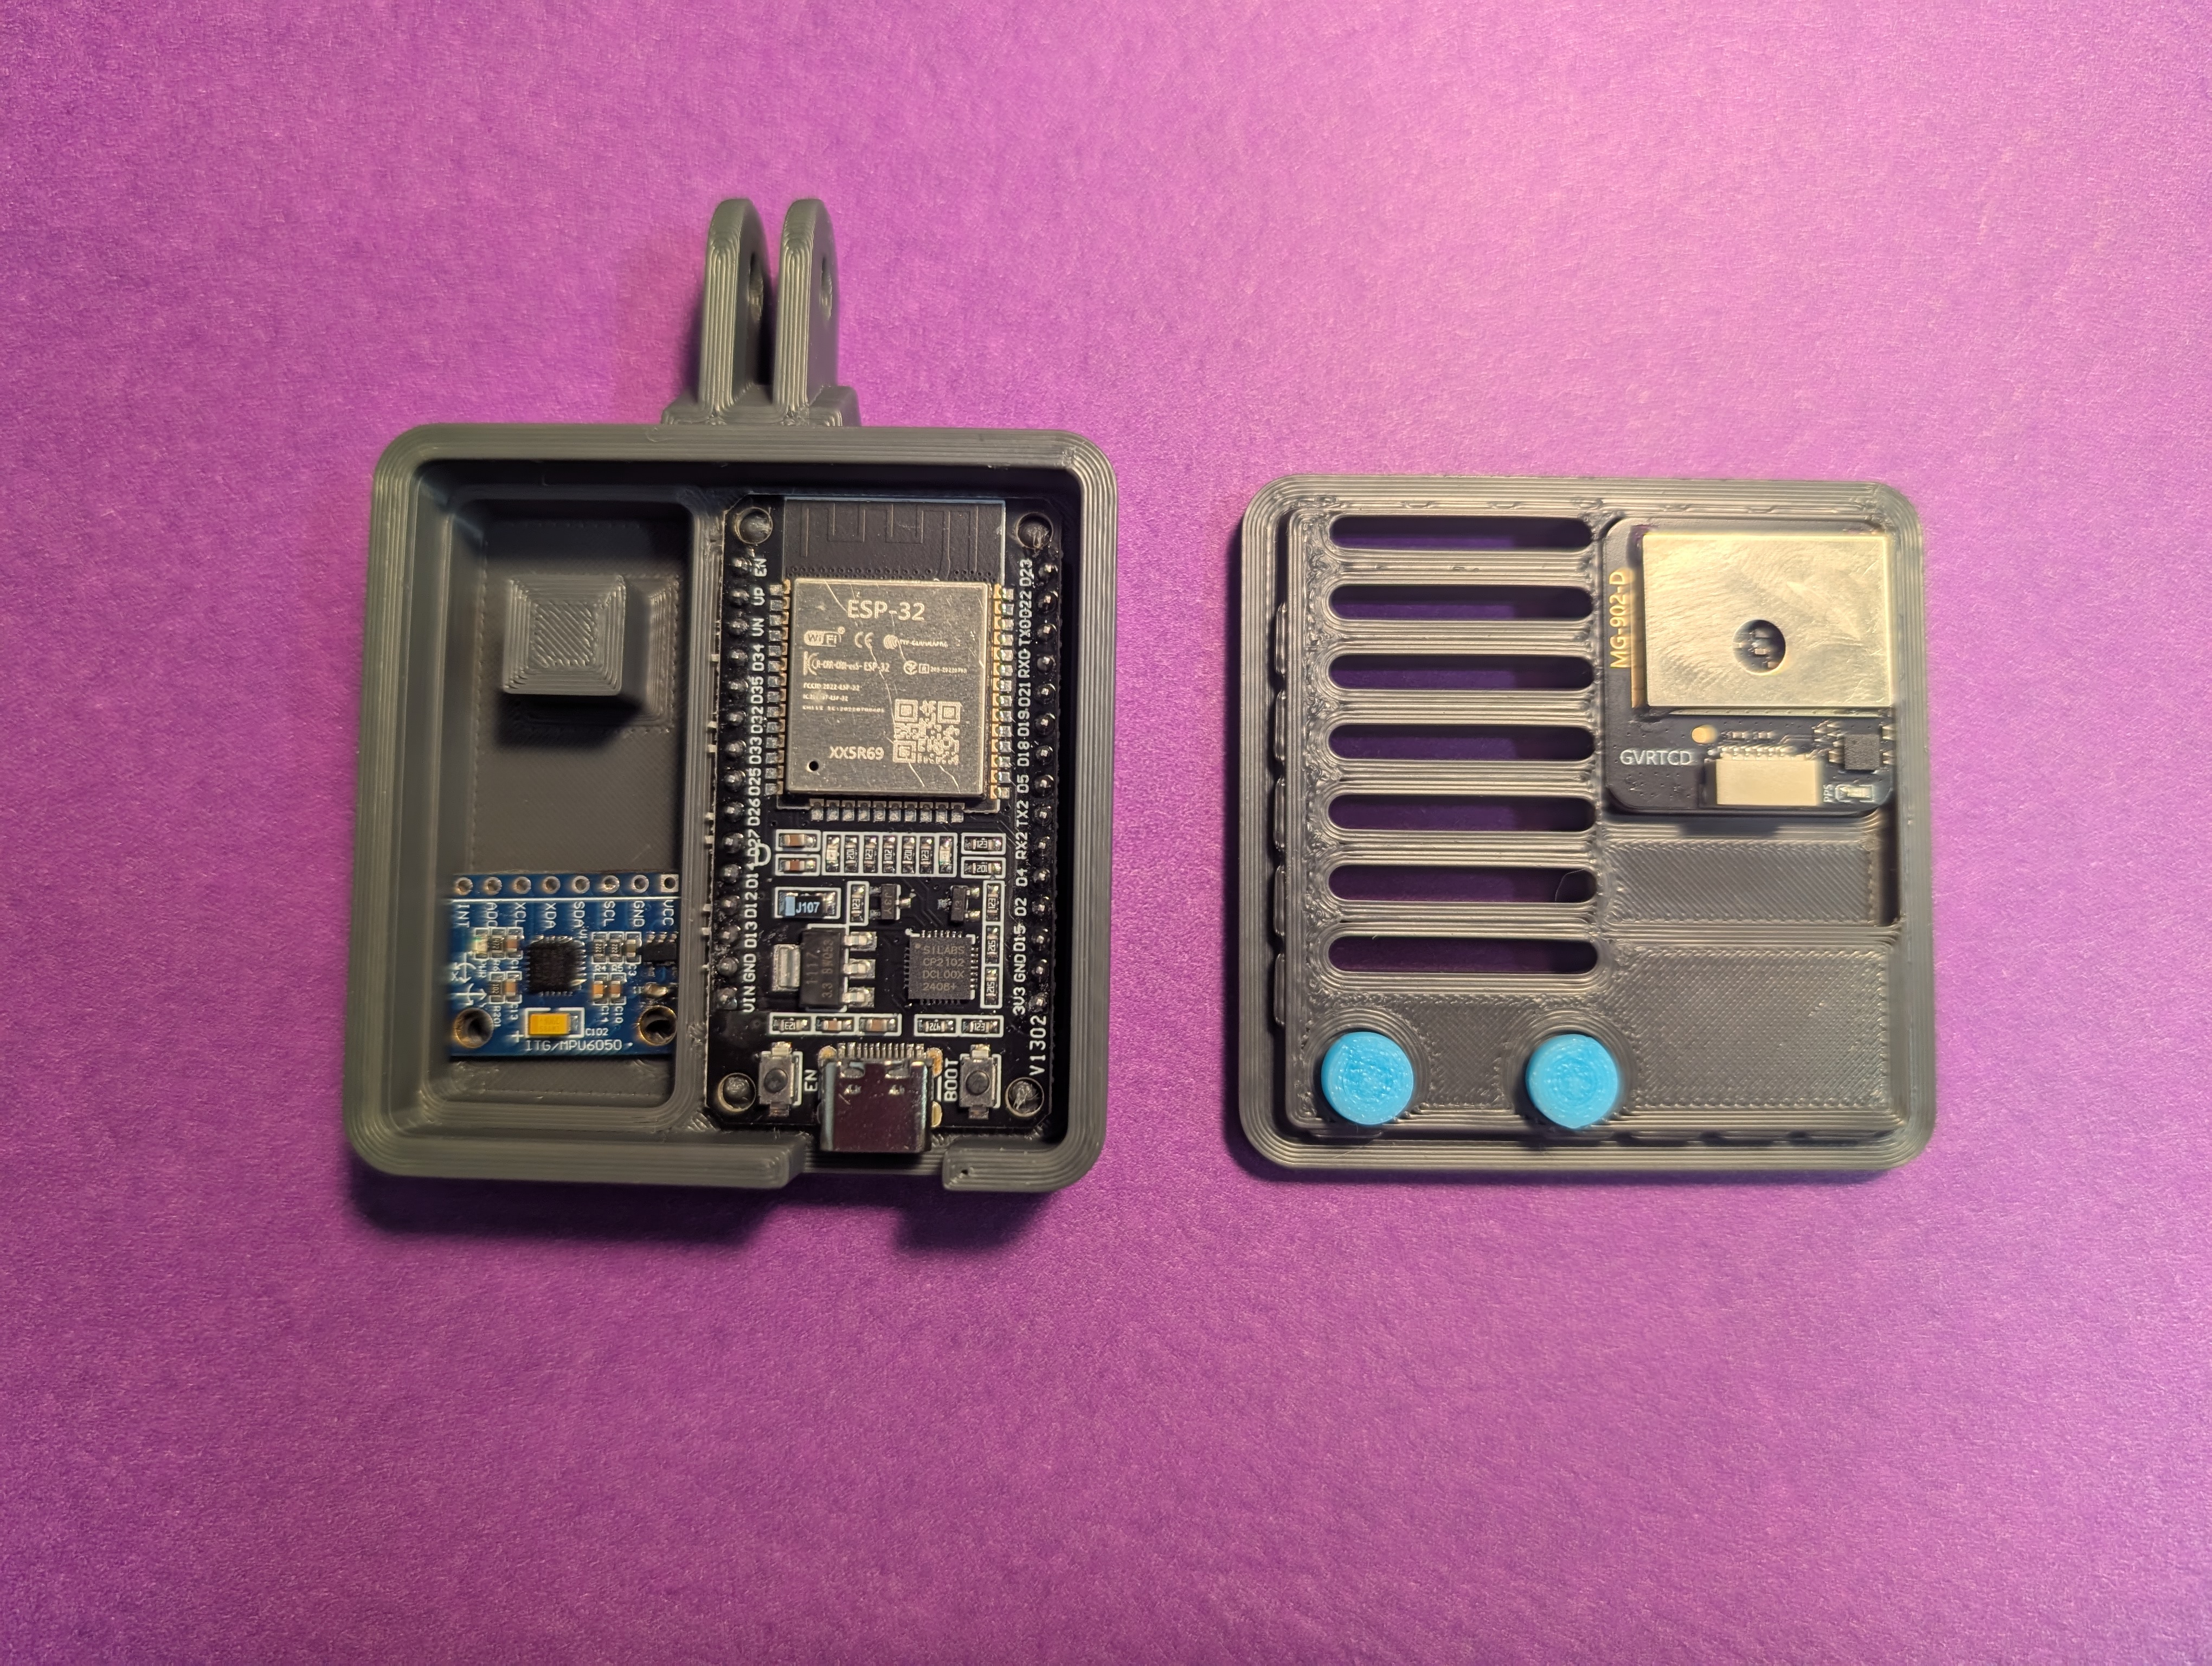
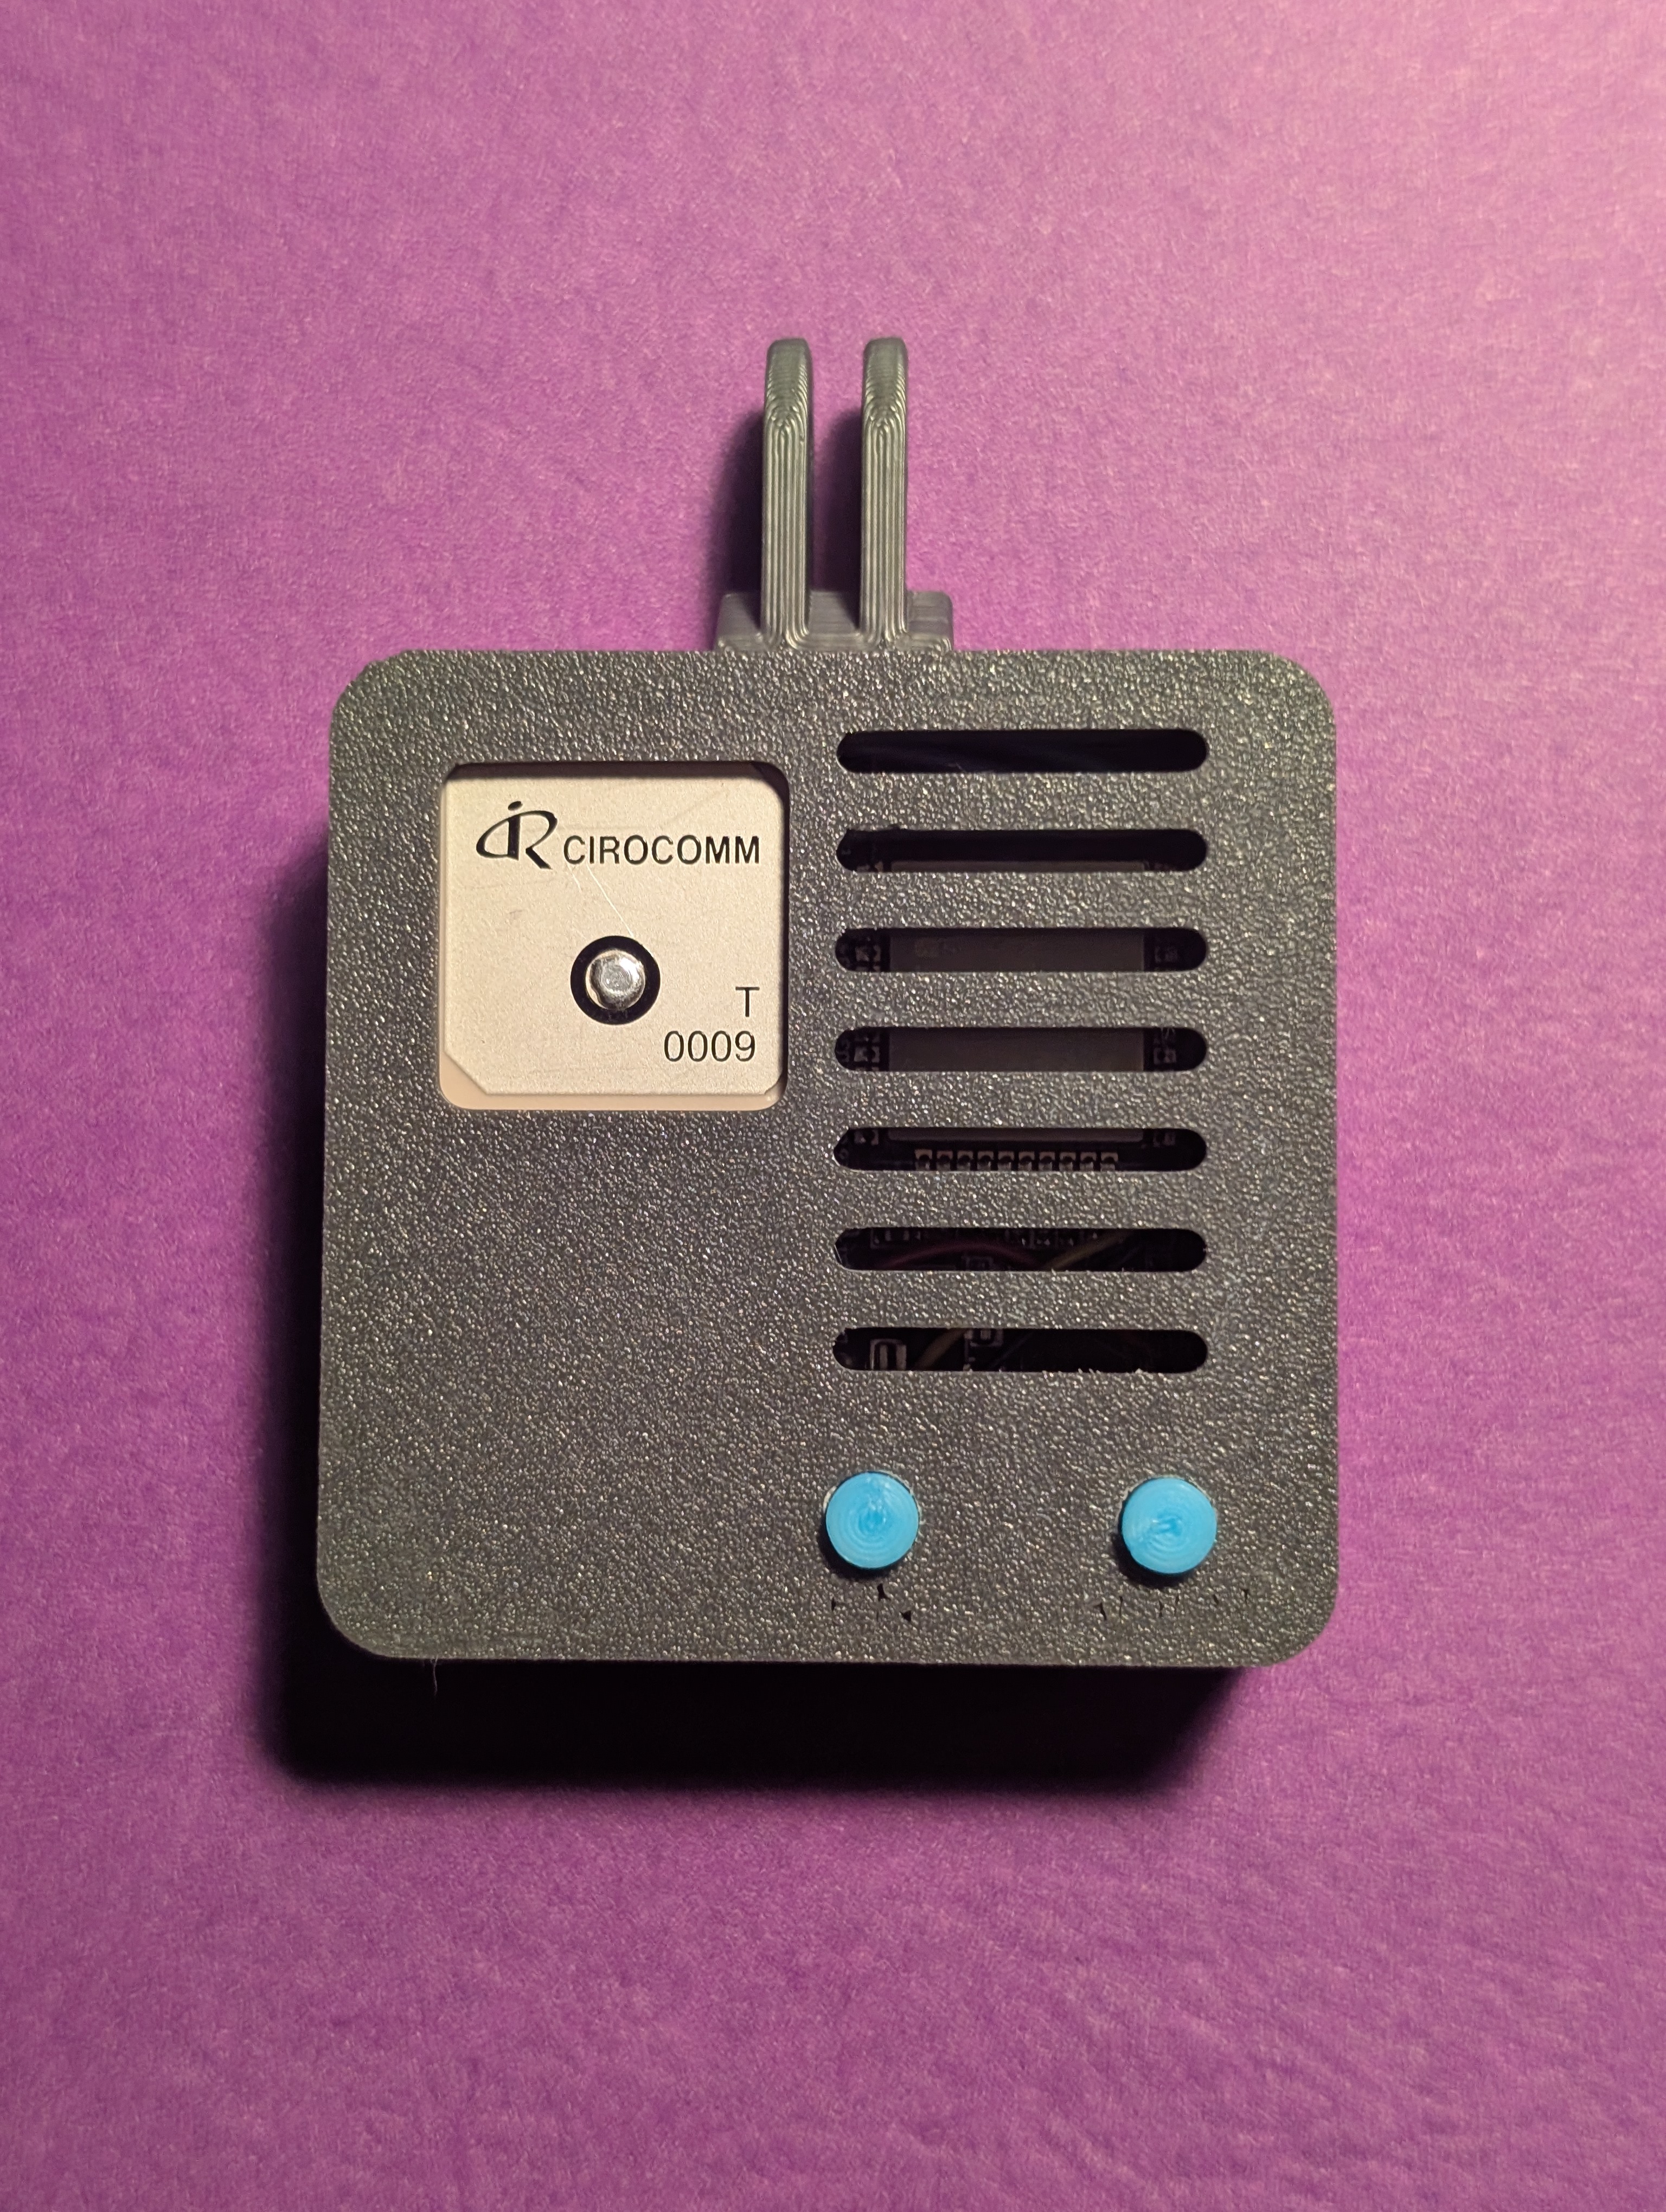
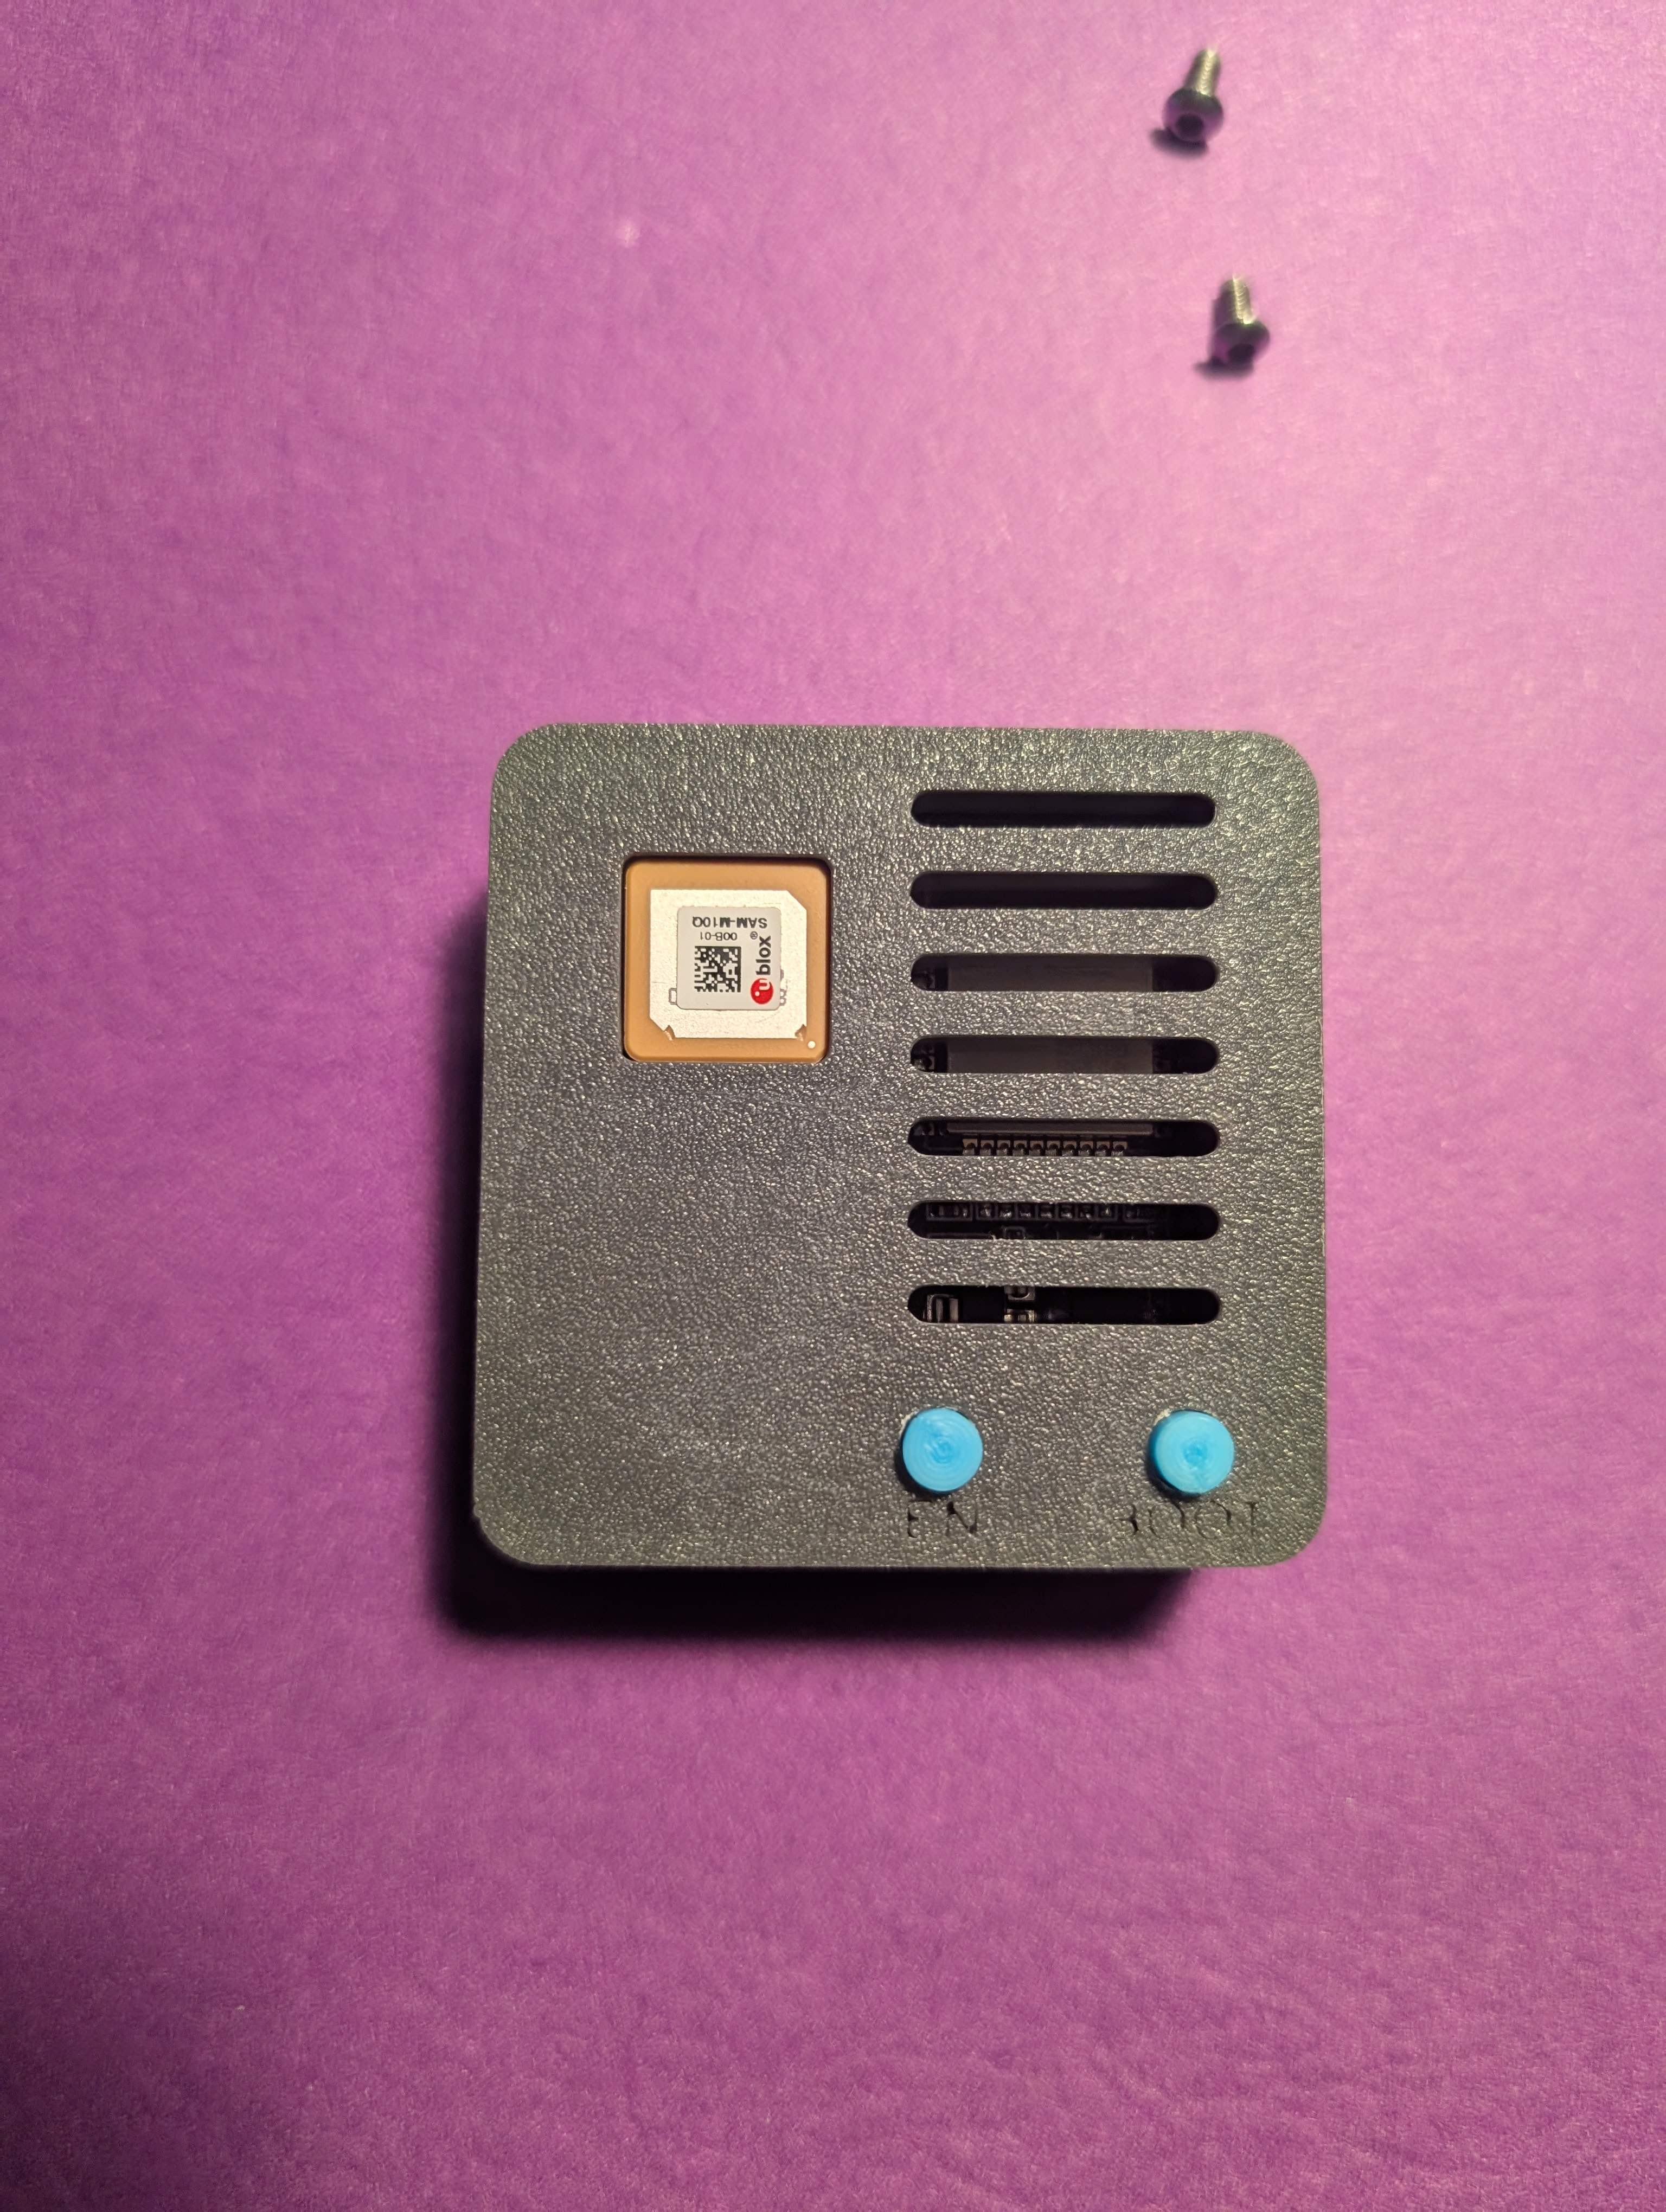
The device is designed to be housed in a custom 3D-printed enclosure, with design files included in this repository.
[!TIP] Other Hardware Options
Check Out The Mods Folder For Other Hardware Options. For new builds, check out the PCB version.
±8g) and 3-axis gyroscope (±500 deg/s) data from the MPU6050.To build this project, you'll need the following components:
ESP32 Development Board: (https://a.co/d/fTThpTl)
U-blox GNSS Module:
Any M10 based U-blox modules should work, the output rate may vary but you should be able to get 25hz with just GPS enabled. But YMMV.
MPU6050 Accelerometer/Gyroscope Module: (https://a.co/d/dCMwffg or similar)
24AWG Hook-up Wire/Jumper Wires or just use the wiring that comes with GNSS module, its perfect for this application.
M3x6 Screws (2)
Soldering Iron & Solder
USB-C or Micro-USB Cable (Depending on your ESP32 board, But USB-C all the things)
3D Printer & ABS Filament
The electronics should cost under 40$.
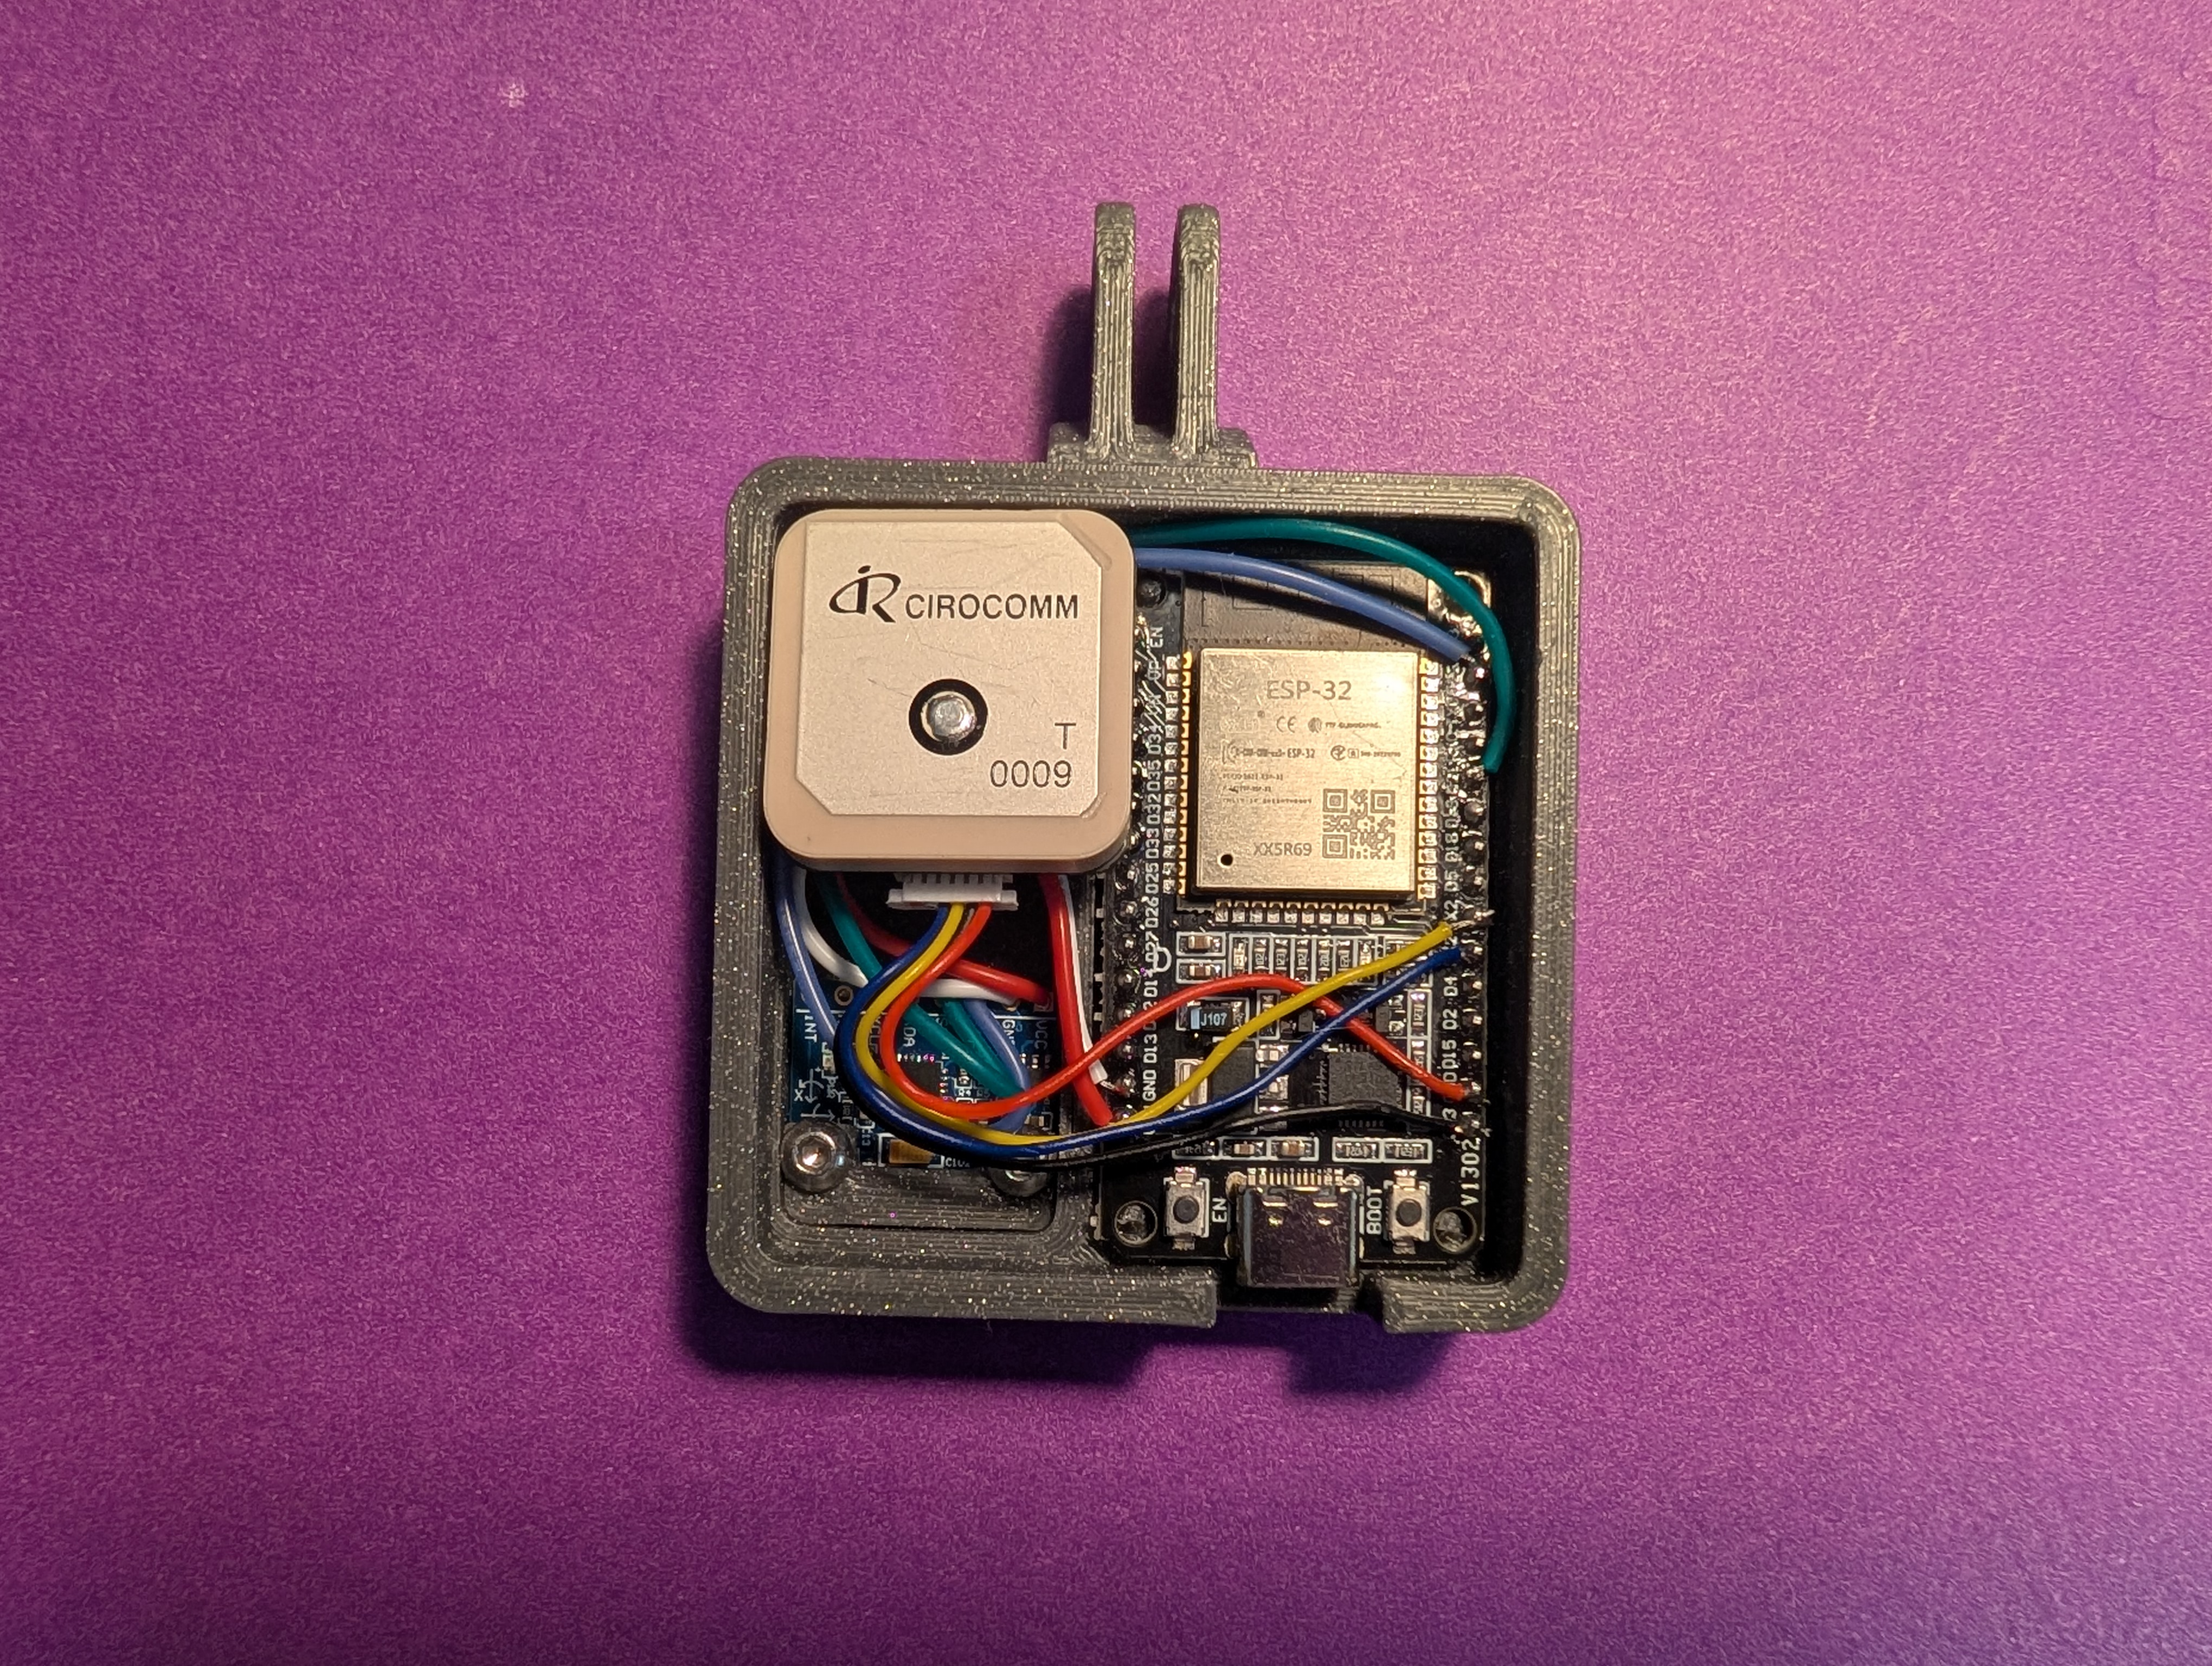
ESP32 <--> U-blox GNSS Module:
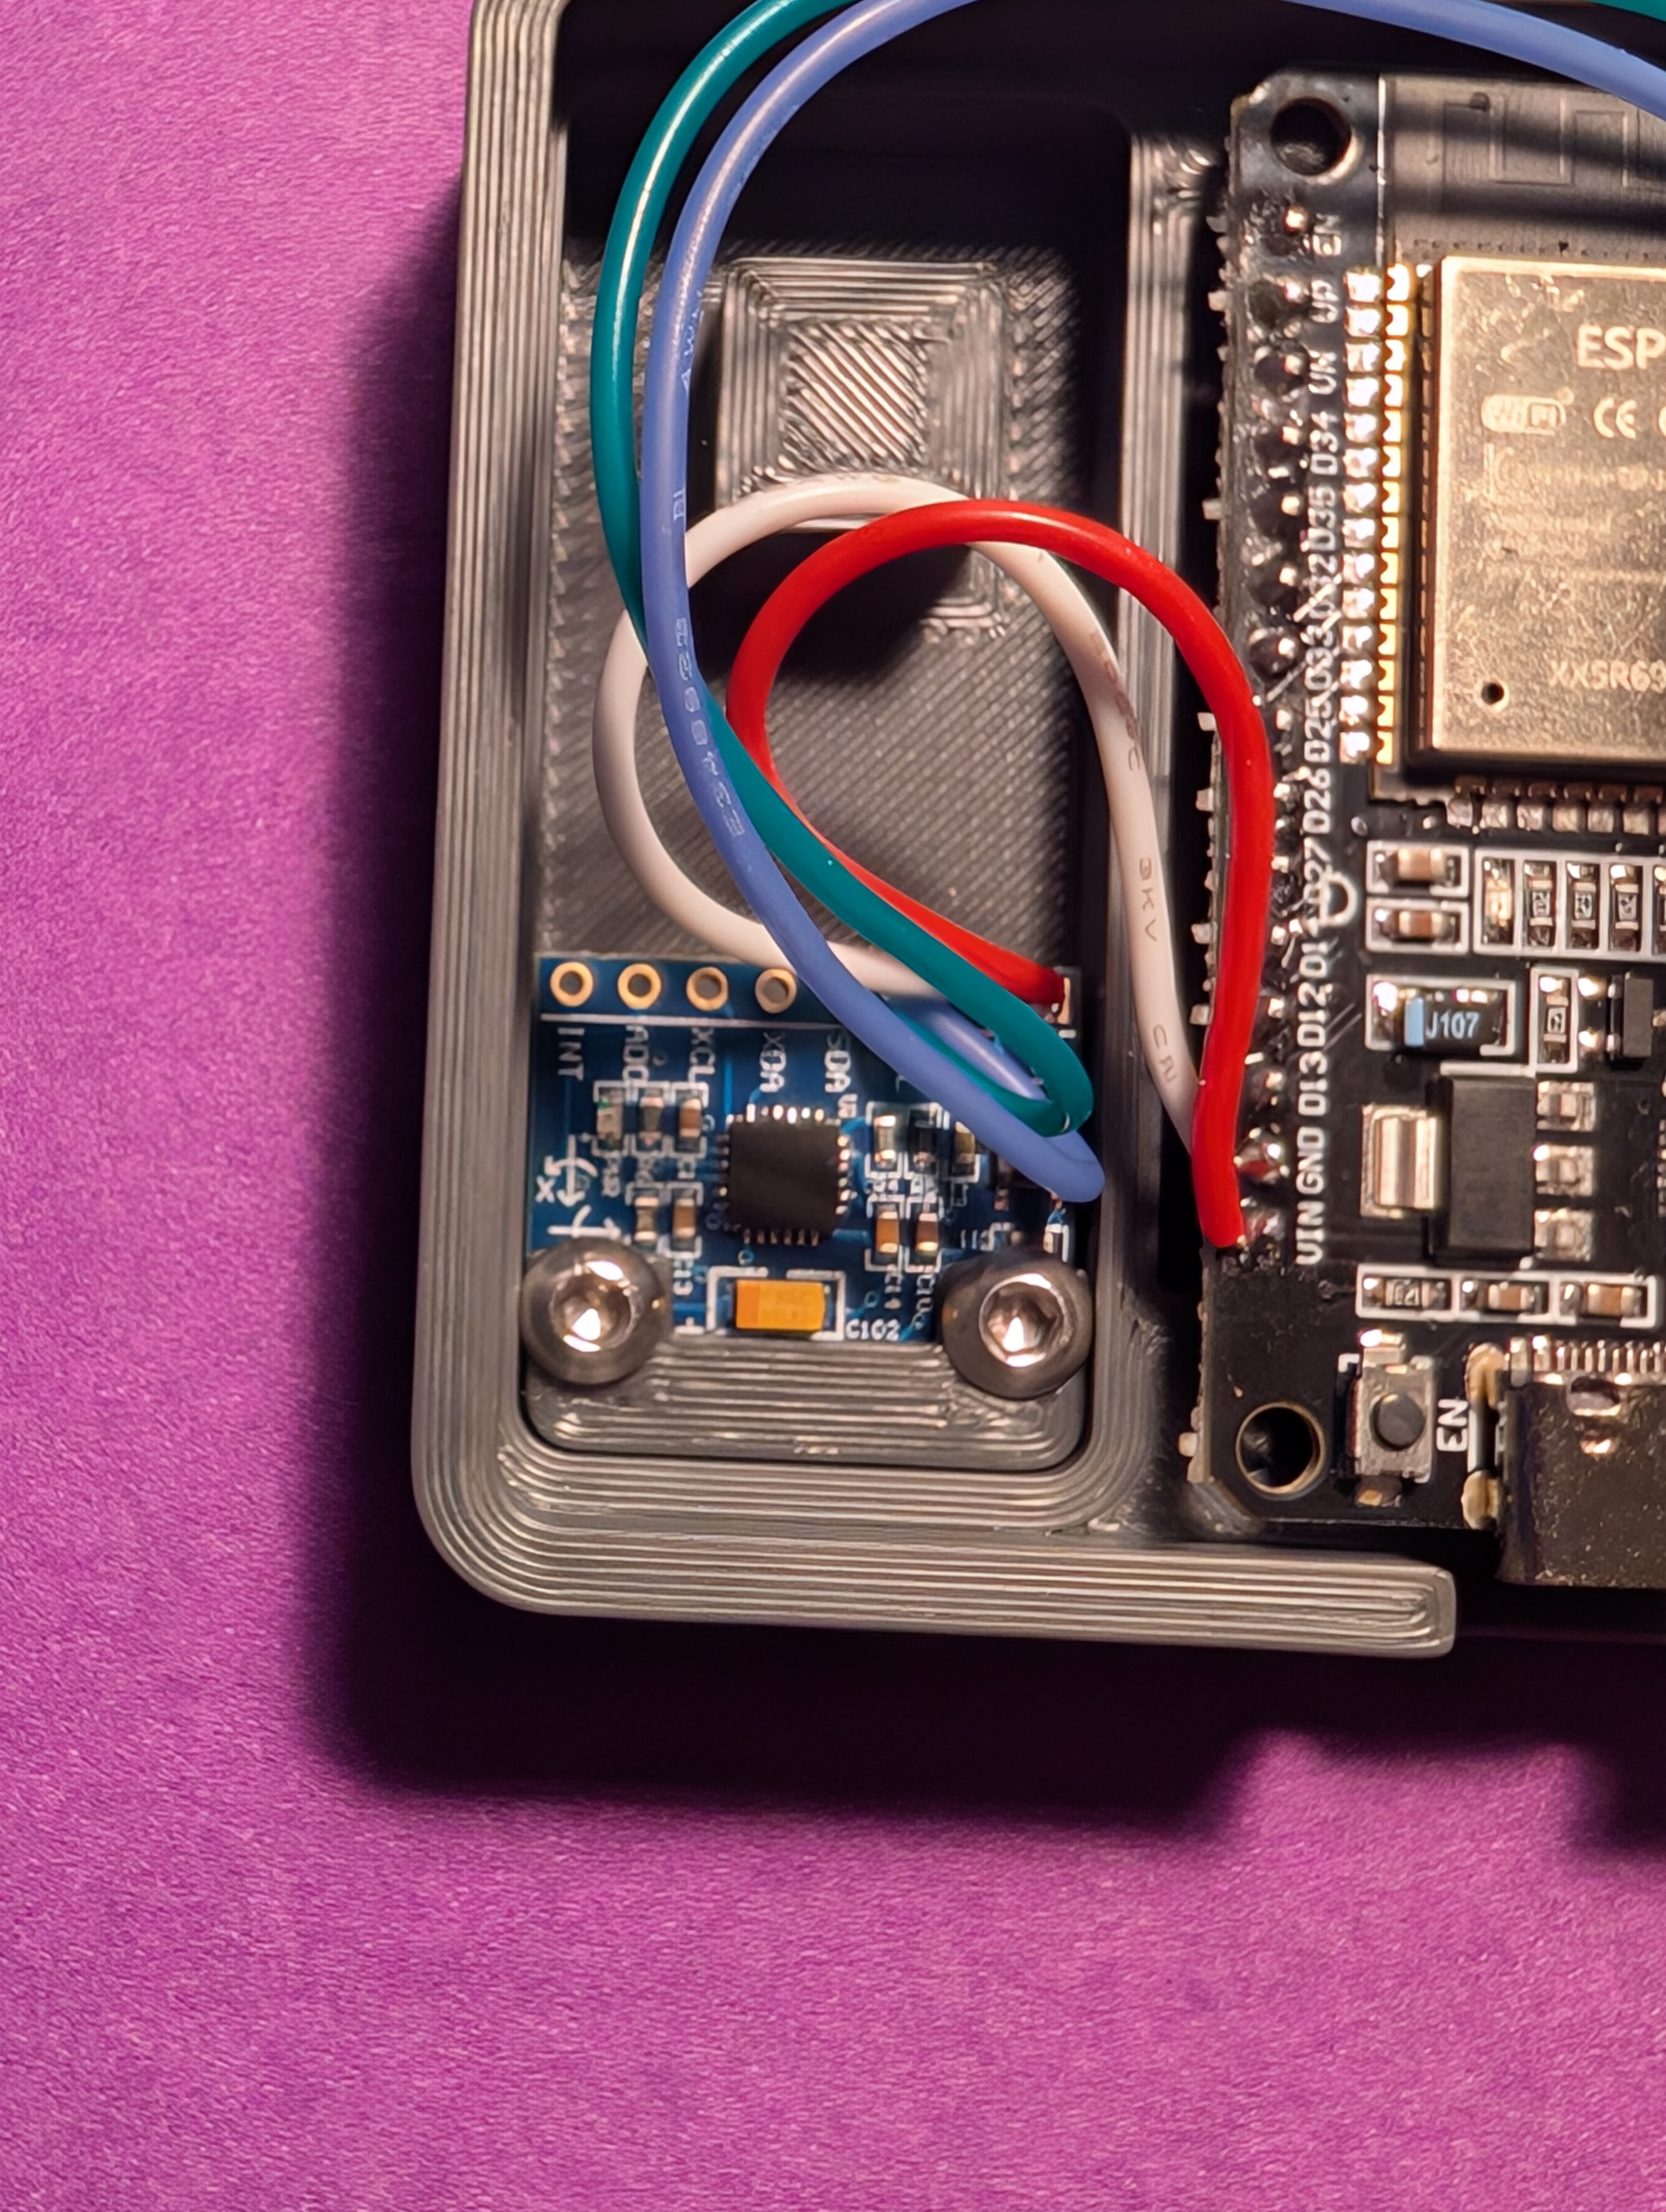
ESP32 <--> MPU6050:
Download from the official Arduino website.
Update the GNSS constellations to use(lines 26-31).
https://app.qzss.go.jp/GNSSView/gnssview.html This could help you pick which constellations to pick.
OPTIONAL – You may update the 10-digit number in the deviceName on line 33 to personalize your device.
ID Limit: If you intend to use this with the RaceBox App, The number must be less than 4000000000. The RaceBox app will not connect to devices with an ID of 4000000000 or higher.
Prefix Requirement: Make sure to keep the "RaceBox Mini " prefix unchanged—only change the numbers.
✅ Correct:
String deviceName = "RaceBox Mini 3999999999";
❌ Incorrect (Prefix changed):
String deviceName = "MY GPS 6942069420";
❌ Incorrect (Number too high):
String deviceName = "RaceBox Mini 4000000000";
Click the Upload button (the right arrow icon) in the Arduino IDE to compile and upload the code to your ESP32.
If upload fails, try this sequence while the output shows "Connecting....":
Open the Serial Monitor to verify startup. Initialization is complete when you see:
BLE Packet Rate: 0.00 Hz | GNSS Update Rate: 25.00 Hz
printed every 5 seconds.
The repository includes *.3mf files for the custom 3D-printed enclosure designed specifically for the components in the BOM.
Theres a Accelerometer blank included if you have a different accelerometer to create your own mount.
Once the firmware is uploaded and the device is powered on:
Feel free to open issues or submit pull requests if you have suggestions, improvements, or bug fixes.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 3 | 470 | Resistor_SMD:R_0603_1608Metric | R3, R4, R5 |
| 1 | 100 | Resistor_SMD:R_0603_1608Metric | R1 |
| 1 | 100k | Resistor_SMD:R_0603_1608Metric | R2 |
| 1 | AO3401A | Package_TO_SOT_SMD:SOT-23 | Q1 |
| 1 | LOGO | LOGO | G*** |
| 1 | MountingHole_Pad | MountingHole:MountingHole_3.2mm_M3_DIN965_Pad | H1 |
| 1 | SAM-M10Q-00B | SAM-M10Q-00B:XCVR_SAM-M10Q-00B | U1 |
| 1 | SolderJumper_2_Bridged | Jumper:SolderJumper-2_P1.3mm_Bridged_Pad1.0x1.5mm | JP1 |
| 1 | XIAO-nRF52840-SMD | seeed_studio:XIAO-nRF52840-SMD | U2 |
nasheed-x/aether
Aether is a versatile flight computer for testing flight hardware and software, focusing on sensor fusion to monitor rocket states and interface with on-board systems.

yedidiaSch/FalconDrone
[IN PROGRESS] High-performance flight controller for quadcopters, providing real-time stabilization and attitude control using FreeRTOS and C++ on STM32

bobberdolle1/SkySweep32
Open-source passive multi-band RF monitoring system | 855–925 MHz, 2.4 GHz, 5.8 GHz | Rev C first prototype

JGAguado/LIA
Low-power pet tracking platform built around Meshtastic and LoRa mesh networking

Terrapin-Rocket-Team/SRAD-Avionics
Code and PCBs for the avionics subteam for the SRAD flight computer and side projects


bassammorsy/stm32-flight-controller
Custom 4-layer STM32F405RGTx quadcopter flight controller PCB designed in KiCad. Betaflight compatible, 4S–6S LiPo input, SMT assembled by JLCPCB.

takuhoTech/LagopusSystem-2023
Avionics for Human-Powered Aircraft, Including Bike Power Meter project.
It measures 47.5 × 21 mm and has 2 copper layers, 1.6 mm thick.
11 parts, built around the SAM-M10Q-00B and AO3401A. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the anchit92/Open-Source-RaceBox-mini-Emulator repository on GitHub, at the commit this page was made from: the board is Mods/anchit92/PCB_version/PCB_files/seeed_studio_GNSS/seeed_studio_GNSS.kicad_pcb and its schematic Mods/anchit92/PCB_version/PCB_files/seeed_studio_GNSS/seeed_studio_GNSS.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).