2 layers44.5 × 72.7 mm
OSO SWAT C1-jig
joeycastillo/Sensor-Watch
A board replacement for the classic Casio F-91W wristwatch
28 parts2.1k

 Amigo10101/AAR65
Full stack robotic arm development for a student project.
V1.1ar is an open-source printed circuit board by Amigo10101, from the Amigo10101/AAR6 repository on GitHub. It is a 2-layer board of 100 × 100 mm with 28 parts on 157 nets, routed with 111 tracks and 0 vias.
Its parts include 6 resistors, 1 IC and 1 connector.
AAR6 is a 6-DOF (Degrees of Freedom) desktop robotic arm ecosystem. This project integrates motion control, custom hardware design, and interactive 3D visualization into a unified platform. It is based on the open-source PAROL6 design by Source Robotics, heavily modified with custom electronics and a robust QP-based differential controller.
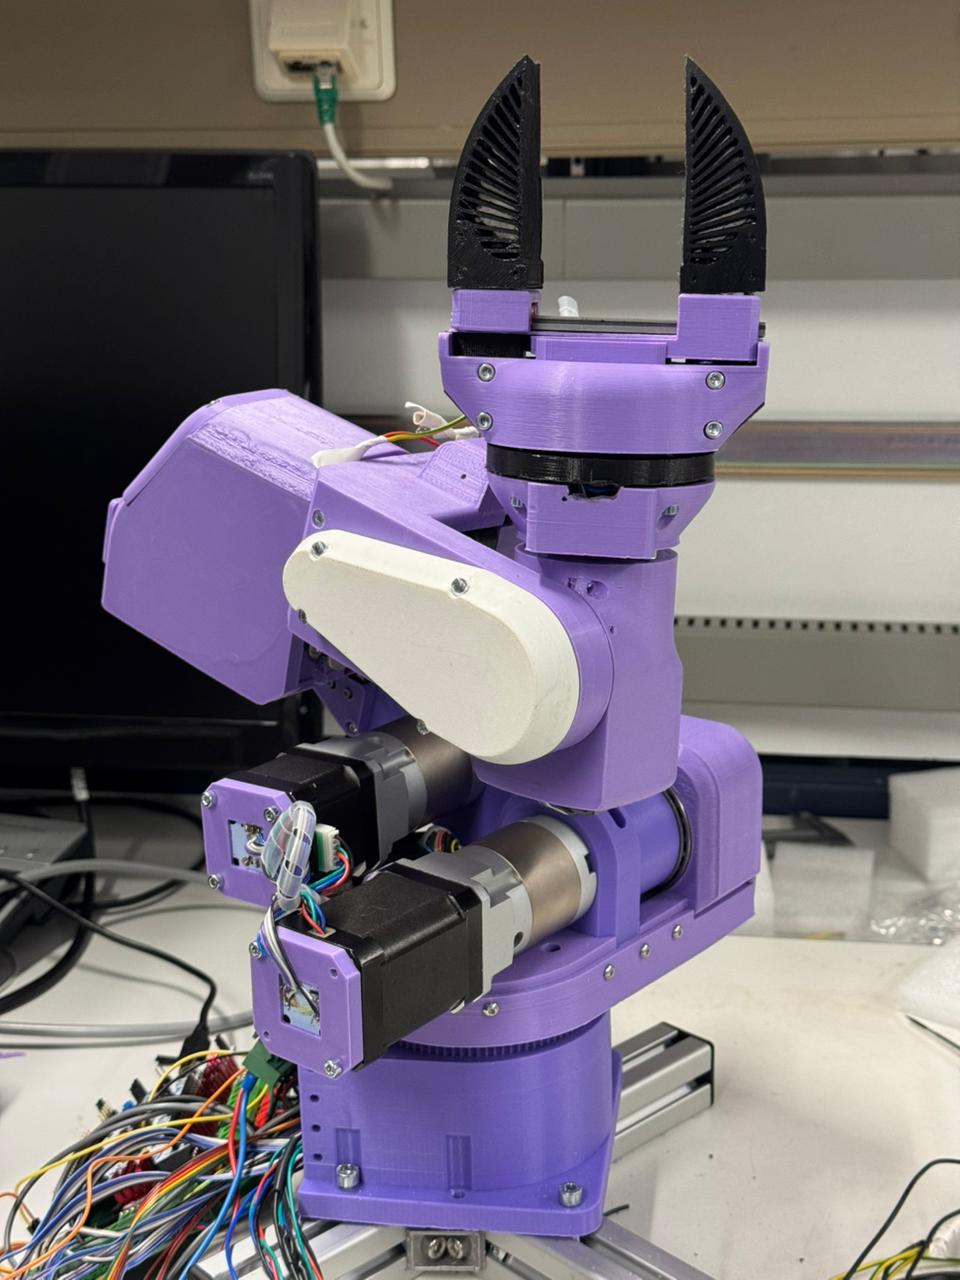
This repository is organized as a monorepo containing all sub-systems of the AAR6 robot:
The low-level "brain" of the robot, running on an STM32F446 microcontroller.
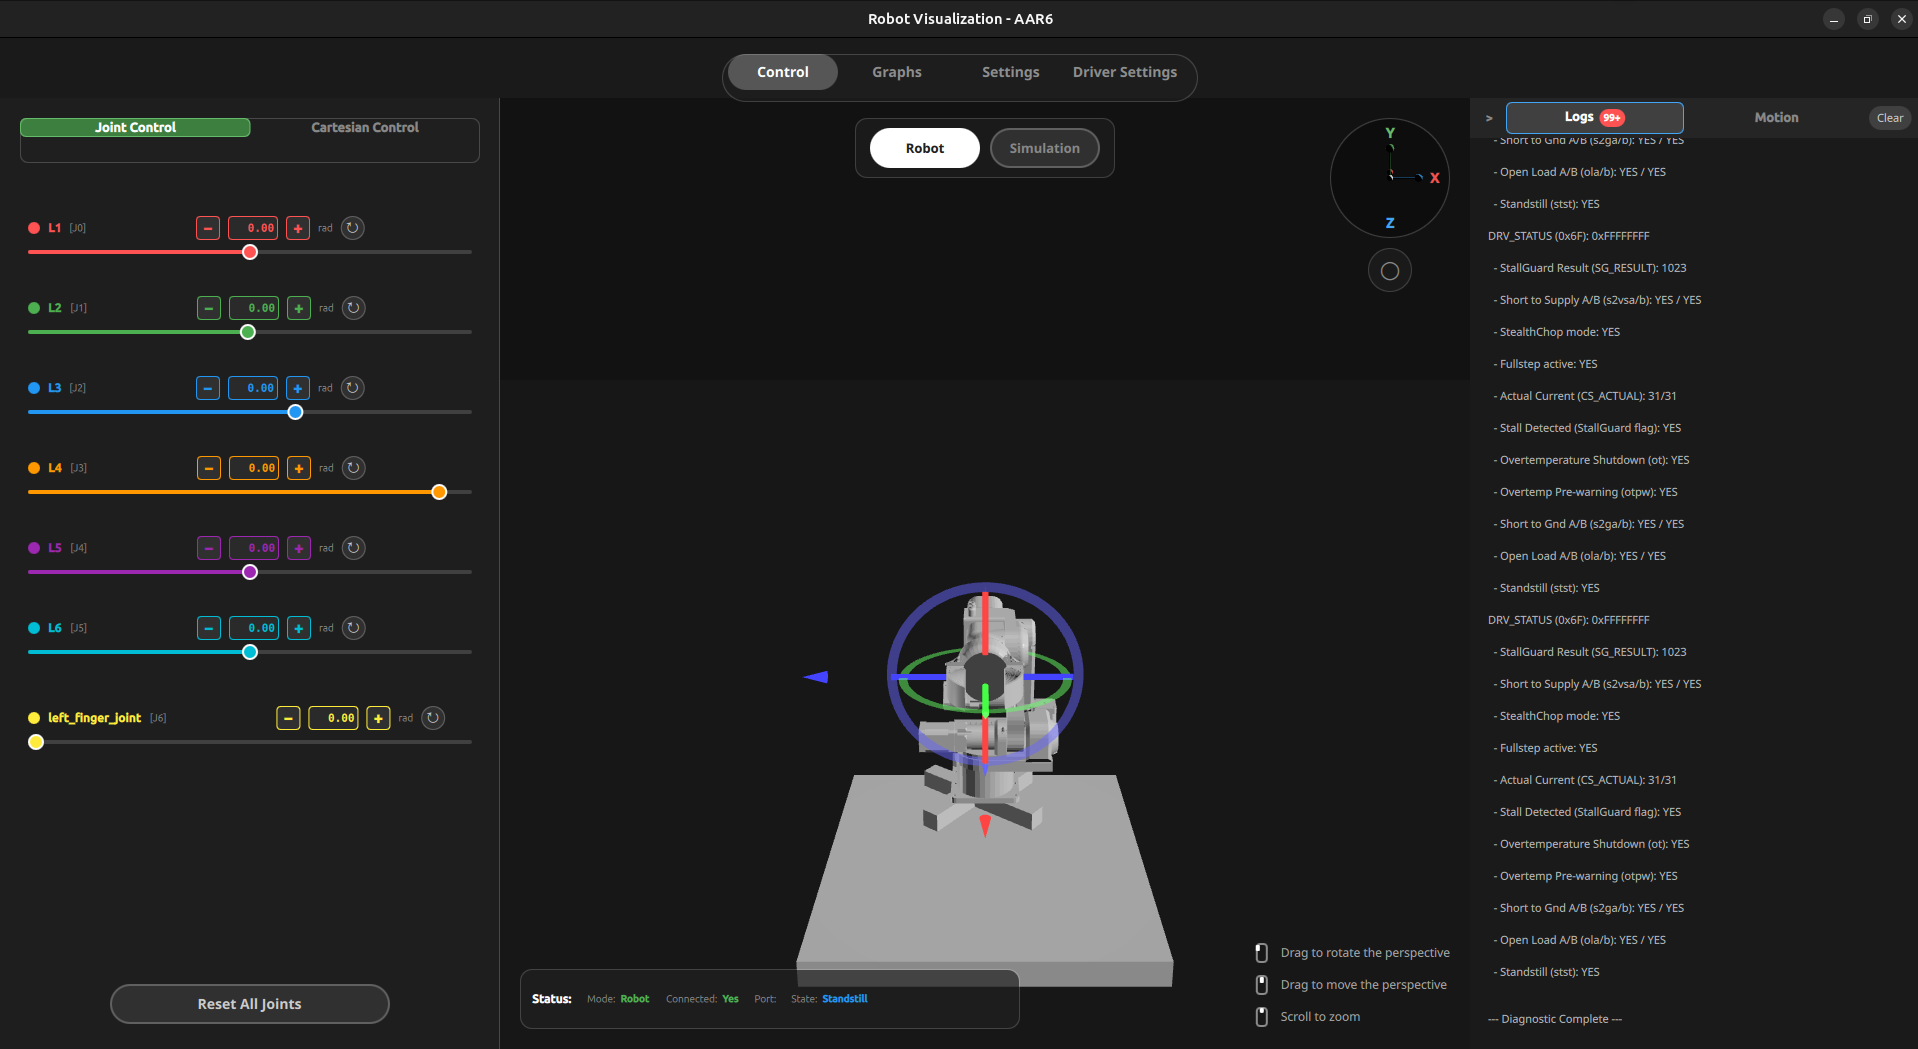 The advanced kinematic engine and 3D visualization suite.
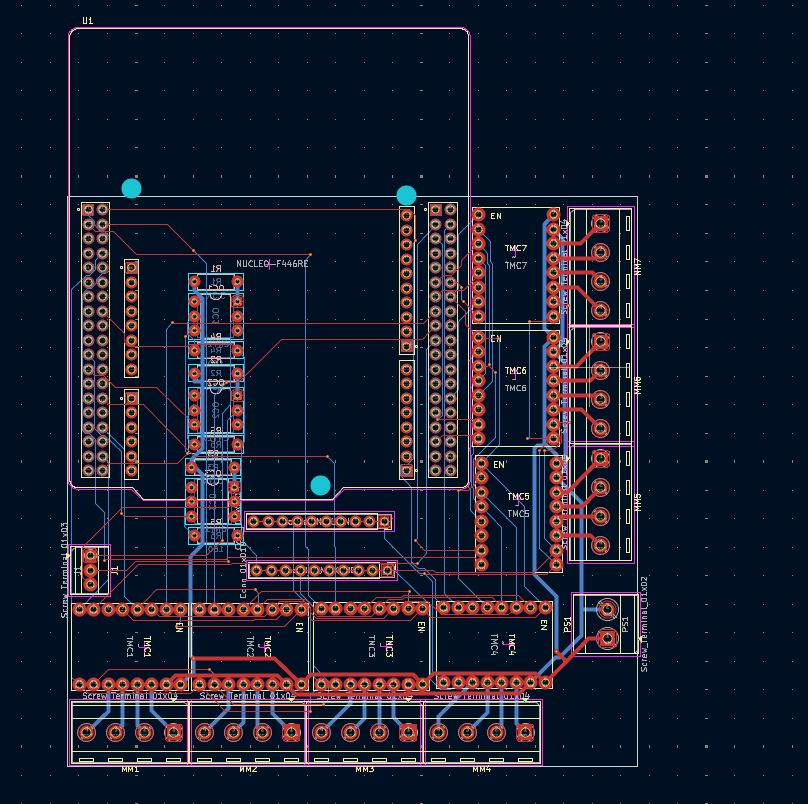 Custom PCB design (KiCad) that integrates all electronic components.
Integration layer for the Robot Operating System (ROS 2 Jazzy).
Technical reports, schematics, and academic documentation.
| Component | Technology | Detail |
|---|---|---|
| Microcontroller | STM32F446RET6 | ARM Cortex-M4 @ 180MHz |
| Motor Drivers | TMC5160 | 32 microsteps, StallGuard support |
| GUI Framework | Qt 6 / QML | Hardware-accelerated 3D rendering |
| Optimization | OSQP | Convex Quadratic Programming solver |
| Communication | USB-CDC | Custom binary protocol with CRC |
| Qty | Value | Footprint | References |
|---|---|---|---|
| 7 | Screw_Terminal_01x04 | TerminalBlock_RND:TerminalBlock_RND_205-00289_1x04_P5.08mm_Horizontal | MM1, MM2, MM3, MM4, MM5, MM6, MM7 |
| 7 | ~ | boards:tmc5160 | TMC1, TMC2, TMC3, TMC4, TMC5, TMC6, TMC7 |
| 3 | 160 | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R4, R5, R6 |
| 3 | 3.3K | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R1, R2, R3 |
| 3 | CNY17 | Package_DIP:DIP-6_W7.62mm | OC1, OC2, OC3 |
| 1 | Conn_01x010 | Connector_PinHeader_2.54mm:PinHeader_1x10_P2.54mm_Vertical | Encoder_MUX_VIO1 |
| 1 | Conn_01x010 | Connector_PinSocket_2.54mm:PinSocket_1x10_P2.54mm_Vertical | Encoder_MUX_GND1 |
| 1 | NUCLEO-F446RE | boards:MODULE_NUCLEO-F446RE | U1 |
| 1 | Screw_Terminal_01x02 | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-3-2-5.08_1x02_P5.08mm_Horizontal | PS1 |
| 1 | Screw_Terminal_01x03 | TerminalBlock:TerminalBlock_Xinya_XY308-2.54-3P_1x03_P2.54mm_Horizontal | J1 |
It measures 100 × 100 mm and has 2 copper layers, 1.6 mm thick.
28 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Amigo10101/AAR6 repository on GitHub, at the commit this page was made from: the board is control_board/v1/v1.1ar.kicad_pcb and its schematic control_board/v1/v1.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask Amigo10101 before reusing the design.
joeycastillo/Sensor-Watch
A board replacement for the classic Casio F-91W wristwatch

TalismanDesign/PocketMage_PDA
An E-Ink PDA device using the ESP32 S3.

rusefi/rusefi
rusefi - GPL internal combustion engine control unit

hackclub/OnBoard
💡 Join 1,000 teenagers and make your first PCB with a $100 grant!

asterics/esp32_mouse_keyboard
ESP32 implementation for HID over GATT Keyboard and Mouse (Bluetooth Low Energy). Including serial API for external modules (similar to Adafruit EZKey HID)


Luos-io/luos_engine
Open-source and real-time orchestrator for cyber-physical-systems, to easily design, test and deploy embedded applications and digital twins.

Chrismettal/EleLab_v2
Cheap DIY lab system for hobbyists and the tinkering folk