4 layers30.5 × 30.5 mm
Merlyn435
YeetTheAnson/Merlyn435-Flight-Stack
Successor to the Merlyn411 25mm flight controller. The flight stack includes a 3in1 20mm flight controller and a 20mm ESC.
106 parts6

 YeetTheAnson/Merlyn435-Flight-Stack6
Successor to the Merlyn411 25mm flight controller. The flight stack includes a 3in1 20mm flight controller and a 20mm ESC.
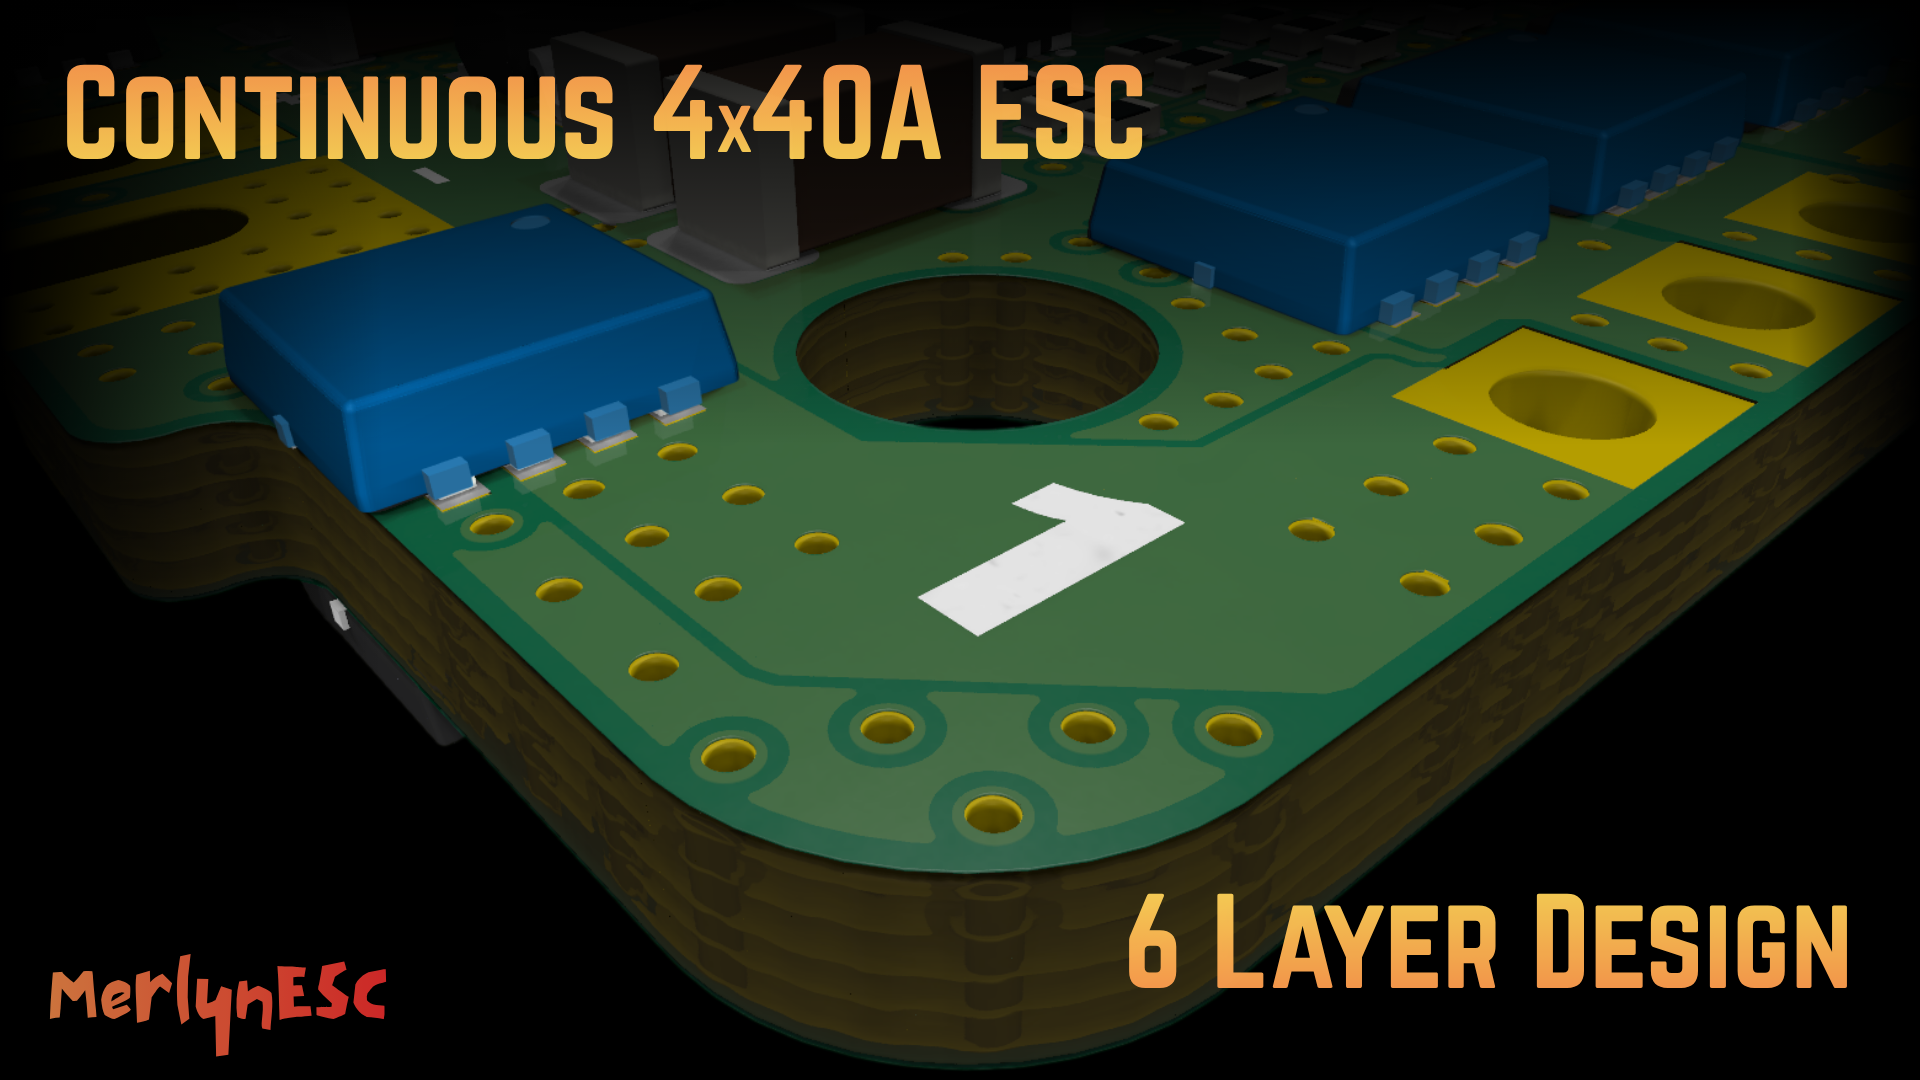
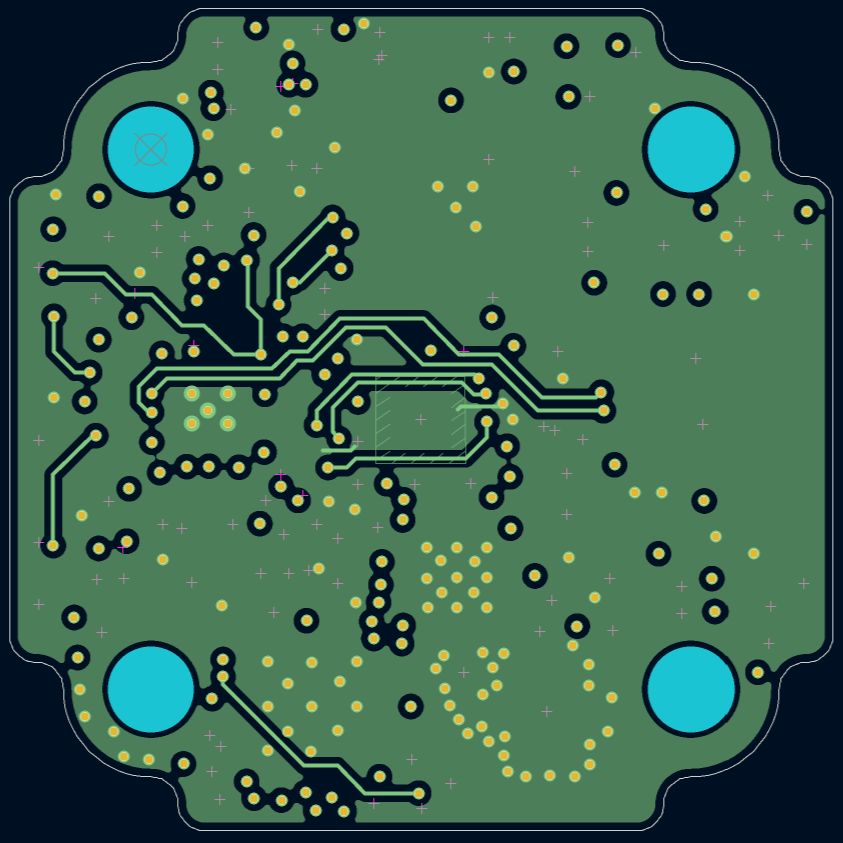
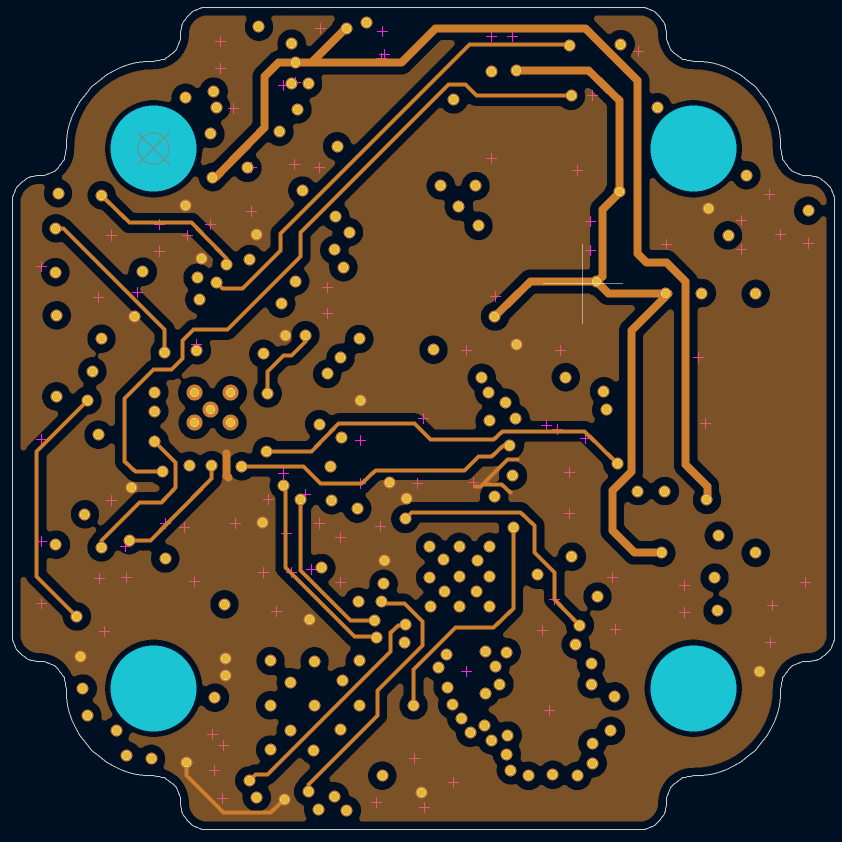
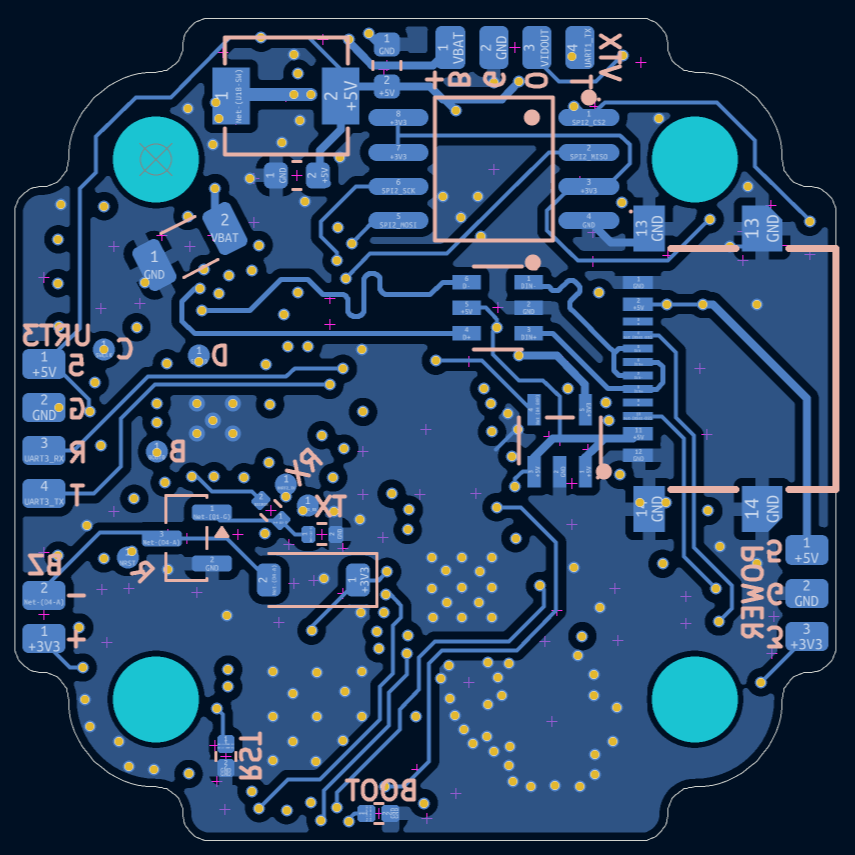
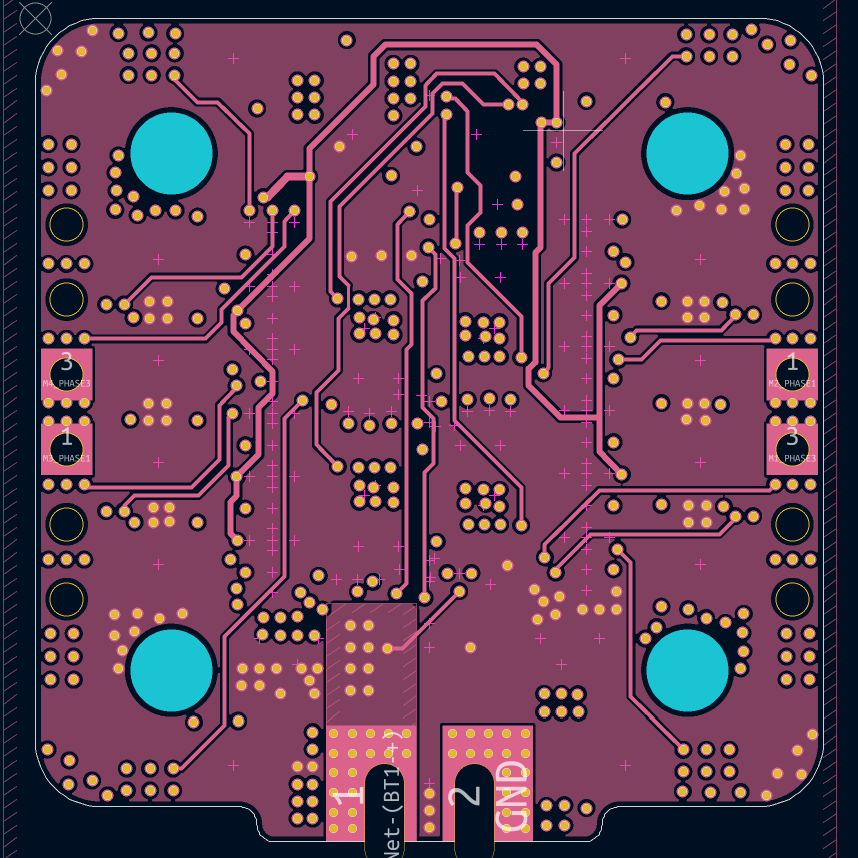
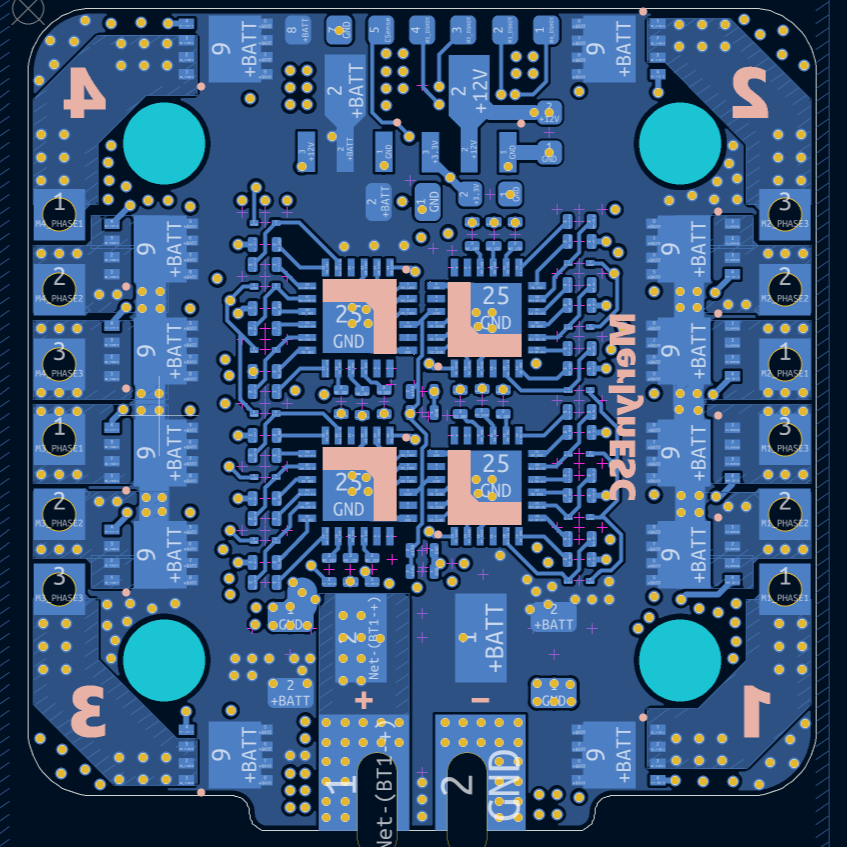
MerlynESC is an open-source printed circuit board by YeetTheAnson, from the YeetTheAnson/Merlyn435-Flight-Stack repository on GitHub. It is a 6-layer board of 30.5 × 31.9 mm with 163 parts on 164 nets, routed with 1,223 tracks and 447 vias.
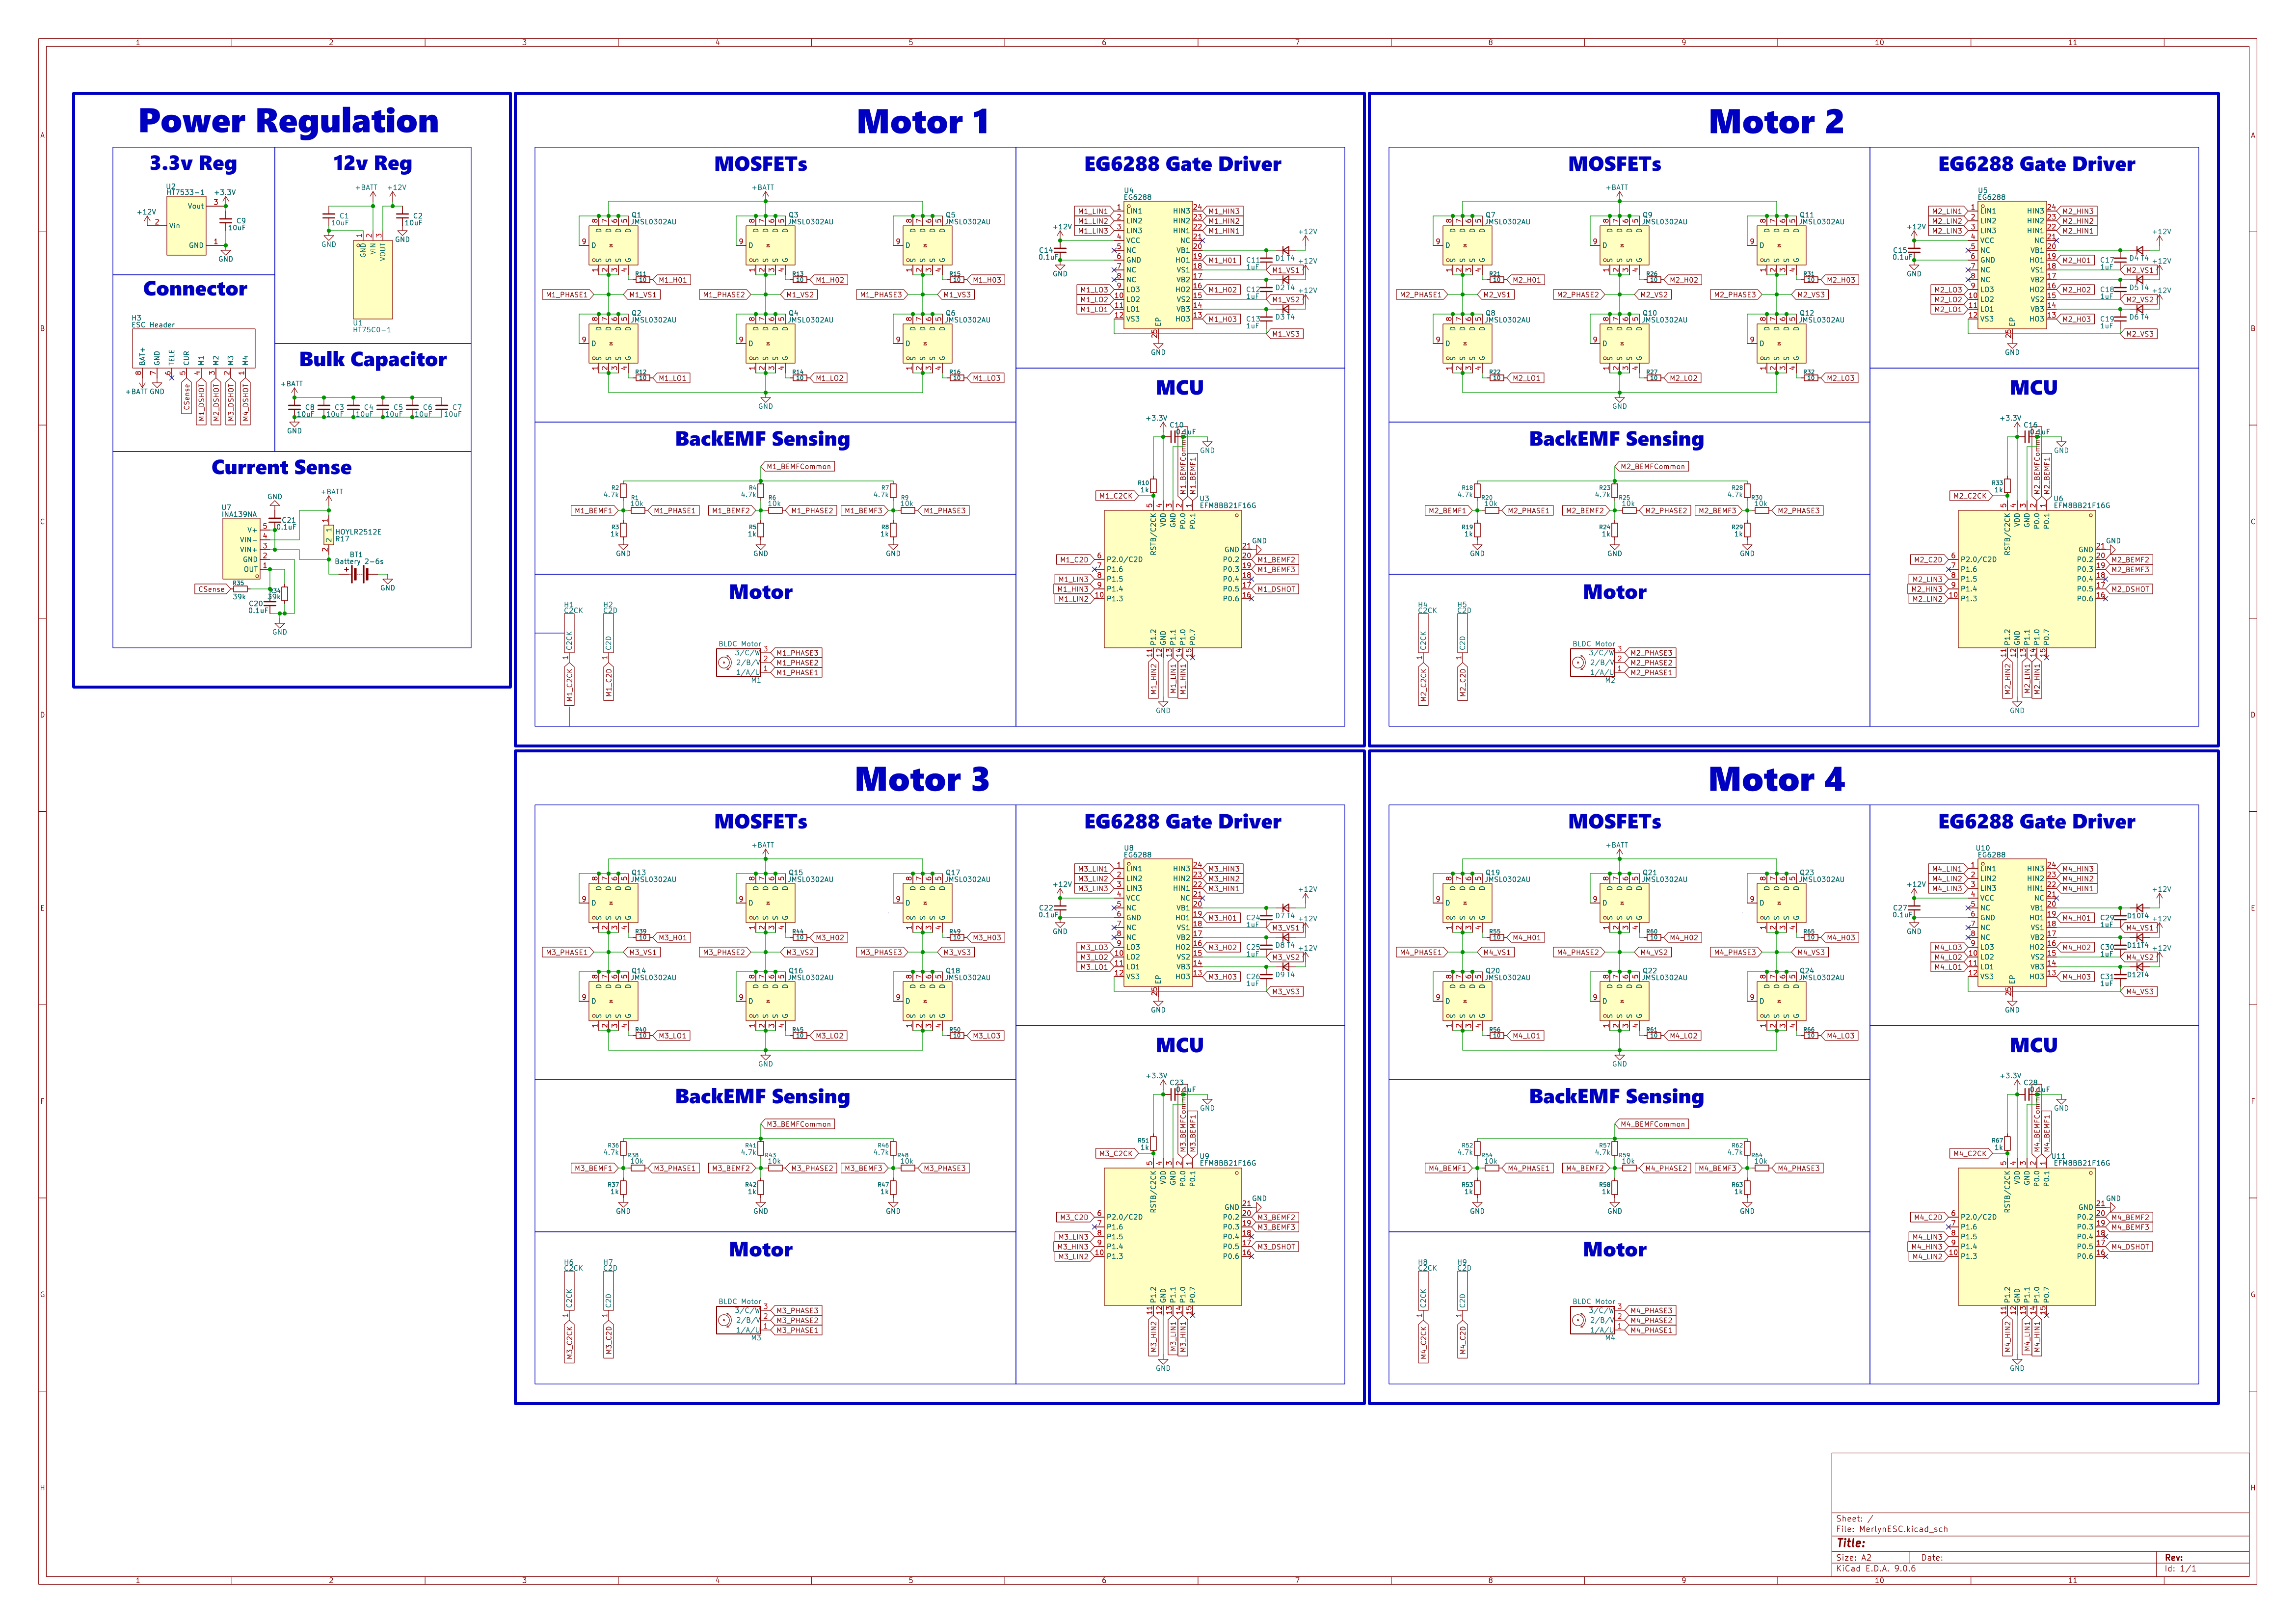
It is built around the EFM8BB21F16G-C-QFN20R, EG6288 and INA139NA/3K, with the HT7533-1, HT75C0-1 and JMSL0302AU among its other parts. Its parts include 67 resistors, 31 capacitors, 24 transistors, 12 diodes and 11 ICs. It belongs with the robots and motor control boards and the Silicon Labs (EFR32, EFM) boards of this library.


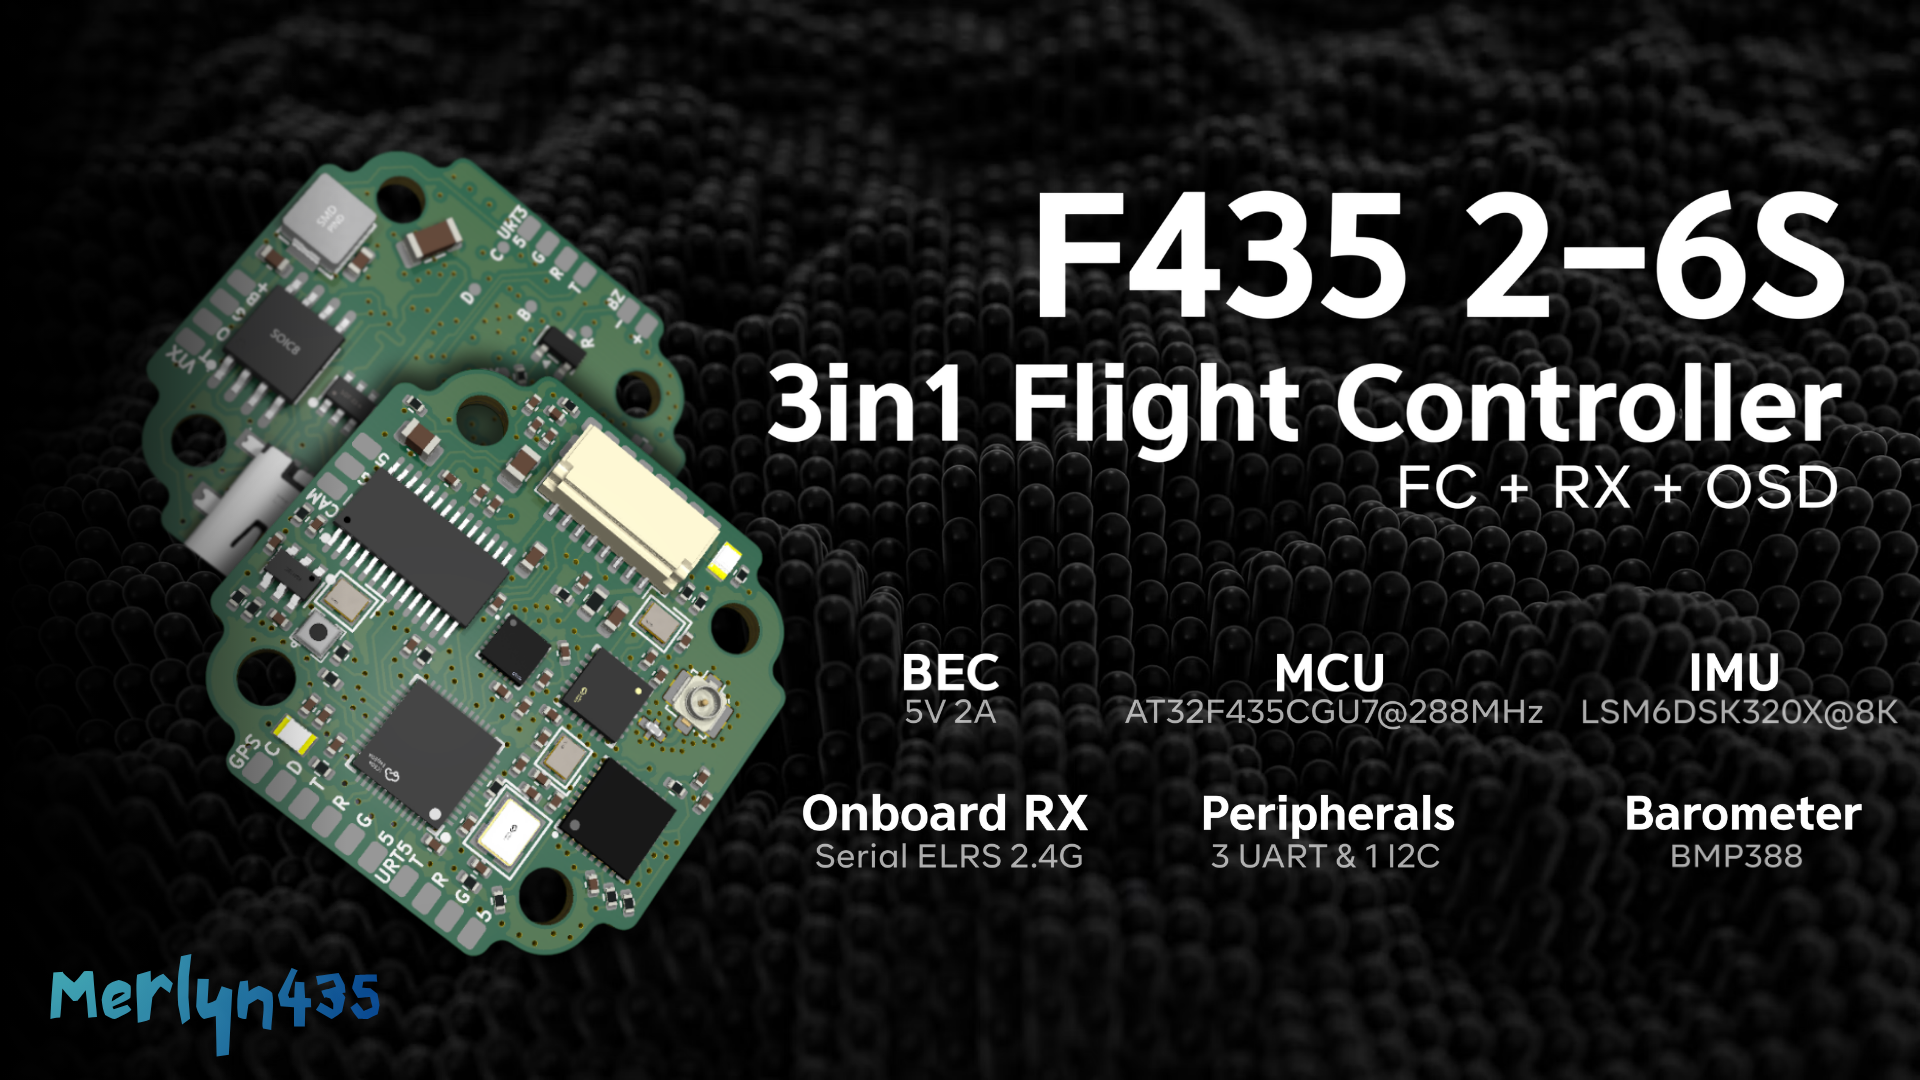
This is my custom Merlyn435 Flight Stack! This project was made as a successor to my previous Merlyn411 flight controller due to several limitations. It lacked in its processing power and free UART ports. Its mounting pattern was also unconventional at 25mm, making its mounting incompatible with any ESCs on the market. By upgrading to the AT32F435@288MHz, the new Merlyn435 easily handles 8k8 PID loop and advanced autonomous flights with 3 spare UART ports.
The Merlyn435 also upgrades the IMU from the MPU6500 to the LSM6DSK320X, which provides significantly better vibration noise rejection at $3.8\ \mathrm{mdps}/\sqrt{\mathrm{Hz}}$ compared to $10\ \mathrm{mdps}/\sqrt{\mathrm{Hz}}$. This results in cooler motors and more stable flights with fewer gyro filters, preventing issues such as mid throttle oscillation and flyaways.
The Merlyn435 flight controller is designed for a wide battery voltage ranging from 2 to 6 cells. This flight controller can also be mounted in various sizes of drones from 2" to as big as it can get.
It is a 3 in 1 flight controller offers features such as an integrated 2.4GHz ExpressLRS receiver and an OSD to overlay telemetry directly in the video feed. Furthermore, it has 16MB of flash memory for blackbox logging to assist in flight tuning.
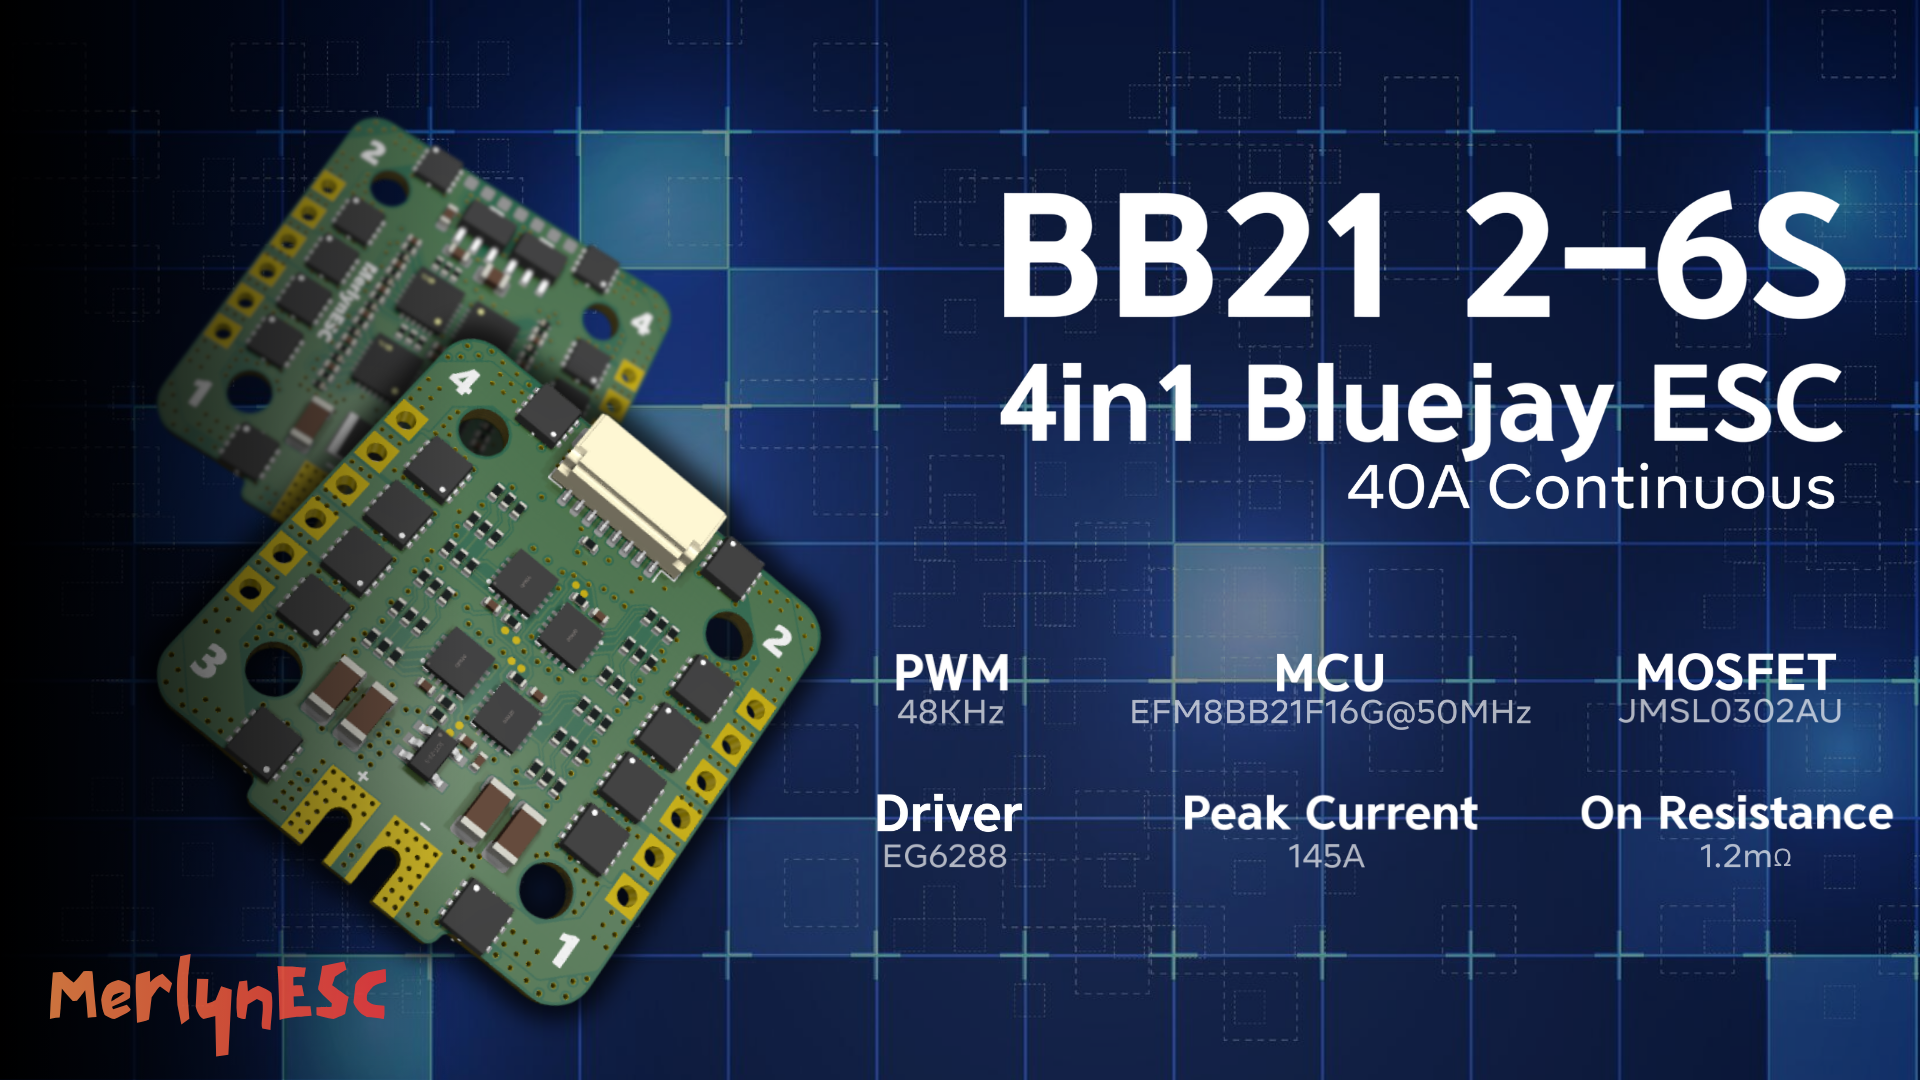
The MerlynESC is a 4 in 1 ESC which runs on Bluejay firmware and also operates from 2 to 6s battery voltages. Its maximum continuous current is 40A per motor and peaks up to 55A for a maximum duration of 10 seconds.
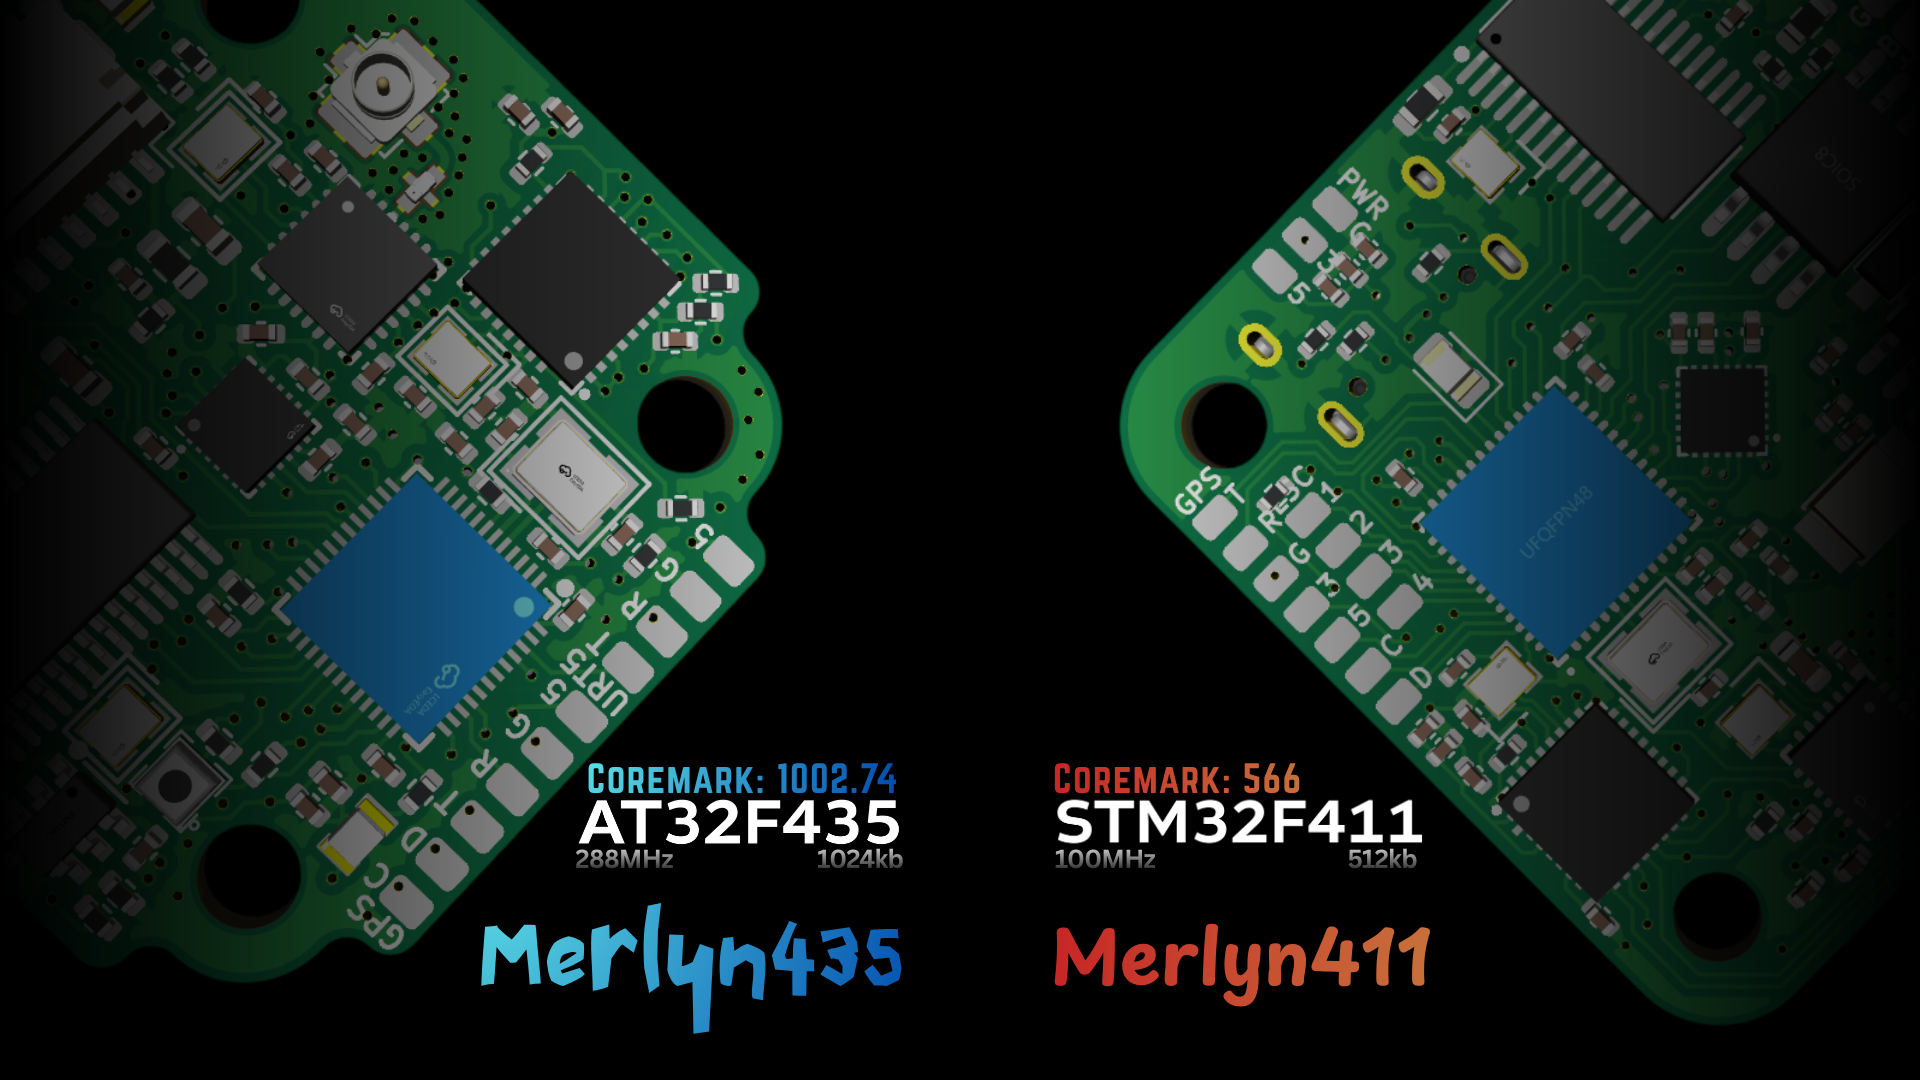
| Feature | Merlyn435 | Merlyn411 |
|---|---|---|
| MCU | AT32F435CGU7 @ 288MHz | STM32F411CEU6 @ 100MHz |
| MCU Flash Size | 1024kB | 512kB |
| UART Interfaces | 5 Hardware UART (2 internal, 3 free) | 2 Hardware UART + 1 SoftSerial (1 internal, 1 softserial, 1 free) |
| IMU | LSM6DSK320X (SPI) | MPU6500 (SPI) |
| Barometer | BMP388 (I2C) | None |
| OSD | AT7456E (SPI) | AT7456E (SPI) |
| Blackbox Flash | 16MB (SPI) | 16MB (SPI) |
| Integrated Receiver | Serial ExpressLRS 2.4GHz | Serial ExpressLRS 2.4GHz |
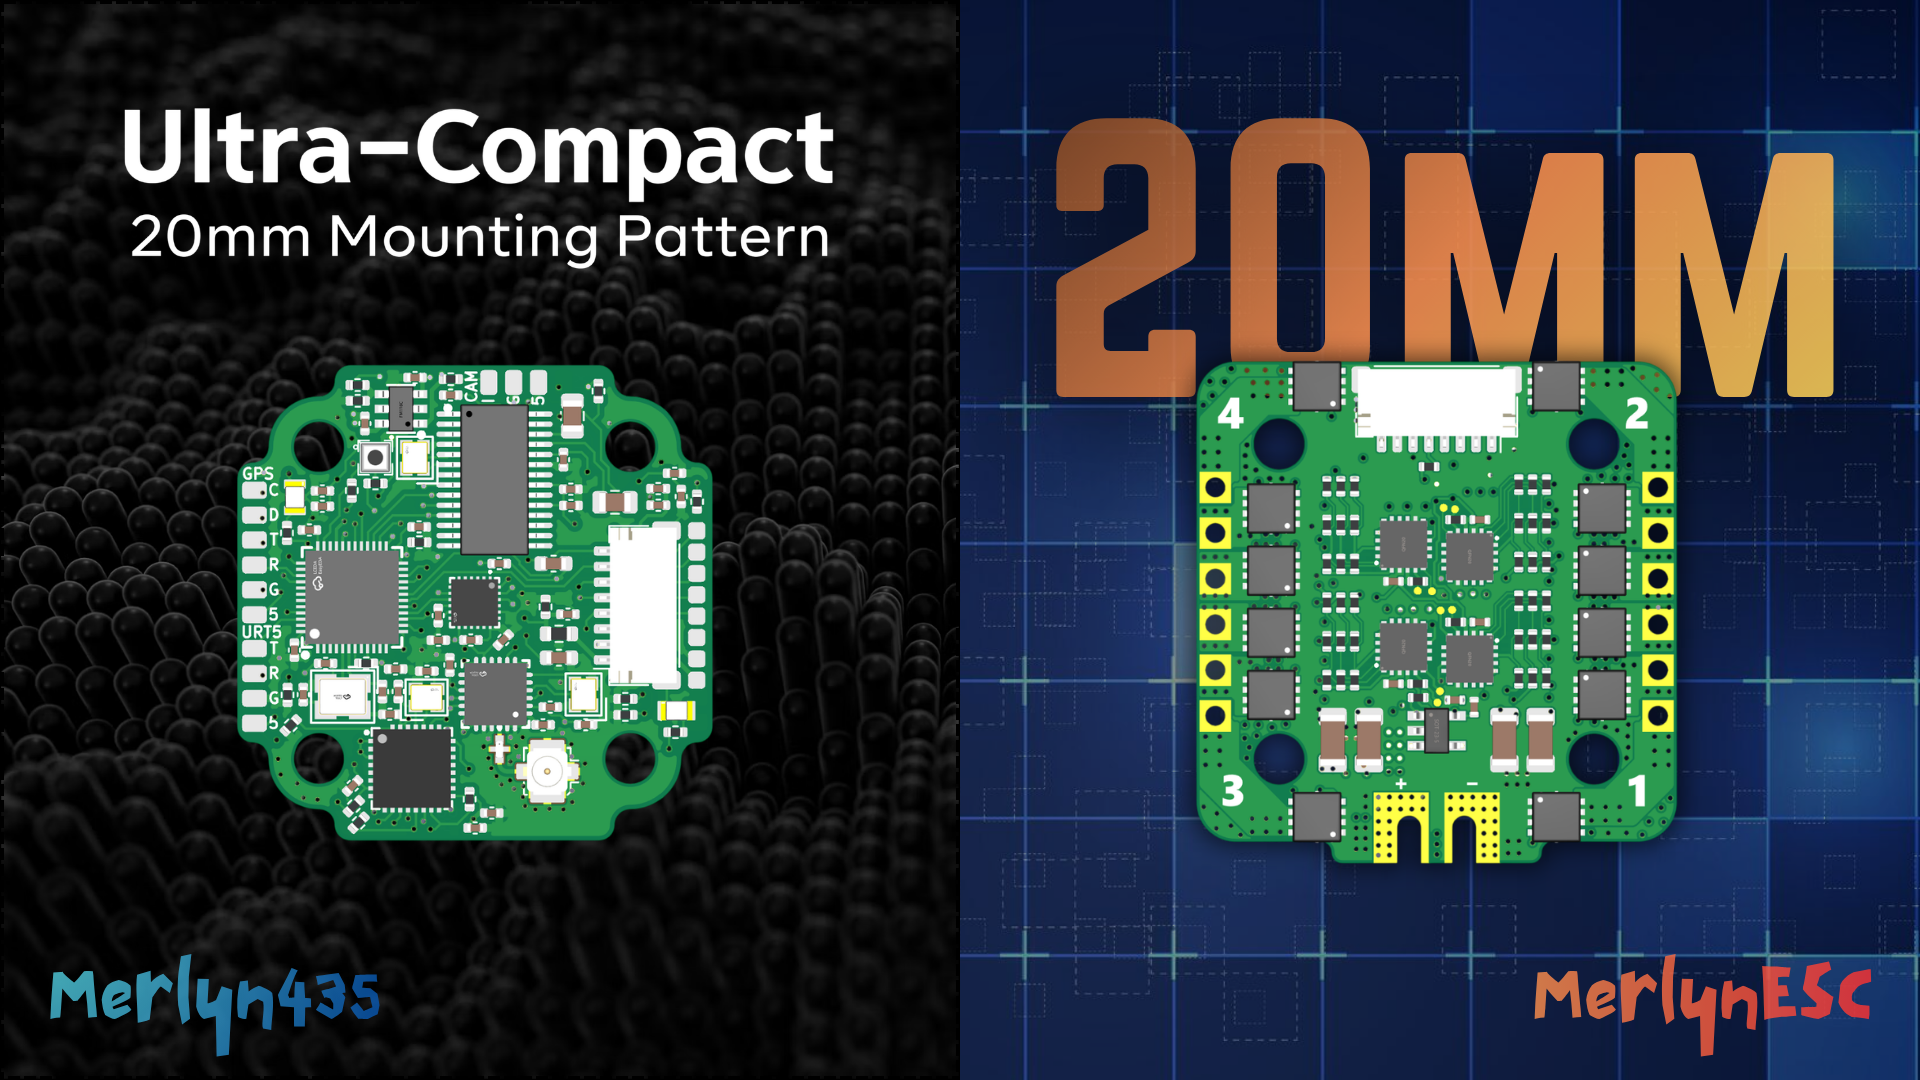
| Mounting Size | M2 20x20mm | M2 25.5x25.5mm |
| BEC | 5V 2A @ 1.1MHz Synchronous | 5V 2A @ 150kHz Asynchronous |
| ESC Connection | 8 pin JST-SH (Betaflight standard) | Direct solder pads |
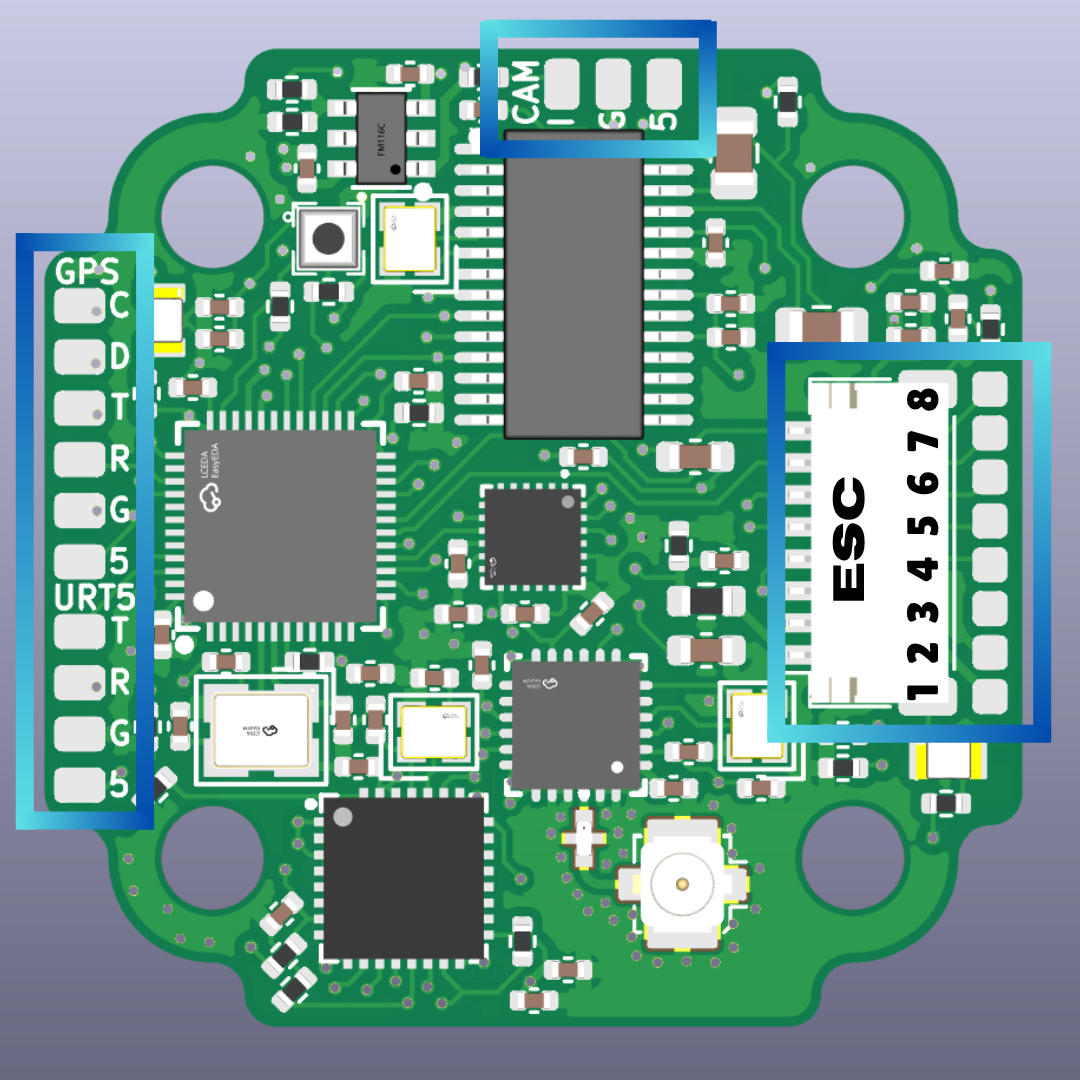
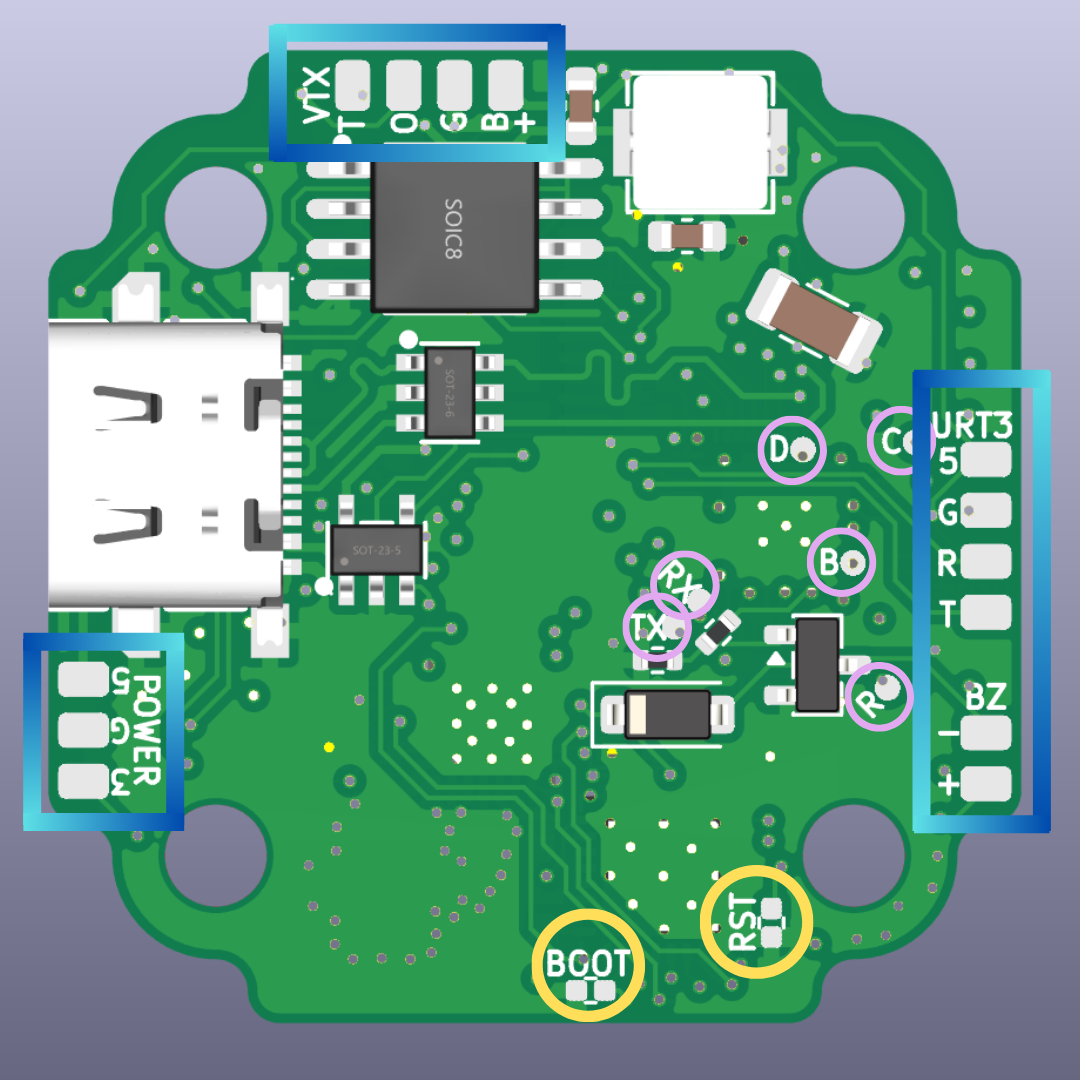
| Header | Pin name | AT32 Pin | Description |
|---|---|---|---|
| ESC | (1)BAT+ | - | Battery Positive Input from ESC |
(2)GND | - | Ground | |
(3)NC | - | No Connection | |
(4)CURR | PA1 | Current Sense Input | |
(5)M1 | PB6 | Motor 1 Signal Output | |
(6)M2 | PB7 | Motor 2 Signal Output | |
(7)M3 | PB0 | Motor 3 Signal Output | |
(8)M4 | PB1 | Motor 4 Signal Output | |
| GPS | C | PH2 | I2C SCL (Internal BMP388 & External Magnetometer) |
D | PH3 | I2C SDA (Internal BMP388 & External Magnetometer) | |
T | PB4 | UART7 TX | |
R | PB3 | UART7 RX | |
G | - | Ground | |
5 | - | 5V Power Output | |
| URT5 | T | PB9 | UART5 TX |
R | PB8 | UART5 RX | |
G | - | Ground | |
5 | - | 5V Power Output | |
| CAM | I | - | Analog Video Input |
G | - | Ground | |
5 | - | 5V Power Output | |
| URT3 | 5 | - | 5V Power Output |
G | - | Ground | |
R | PB11 | UART3 RX | |
T | PB10 | UART3 TX | |
| VTX | T | PA9 | UART1 TX (IRC Tramp / SmartAudio) |
O | - | Analog Video Output (OSD Overlay) | |
G | - | Ground | |
B+ | - | Battery Output for VTX | |
| BZ | - | PC15 | Beeper MOSFET Pin |
+ | - | 5V Power Output | |
| POWER | 3 | - | 3.3V Power Input/Output |
| G | - | Ground | |
5 | - | 5V Power Input/Output | |
| Test Points | RX | PA2 | UART2 TX (ExpressLRS RX) |
TX | PA3 | UART2 RX (ExpressLRS TX) | |
D | PA13 | SWDIO (Debug & Flash) | |
C | PA14 | SWCLK (Debug & Flash) | |
R | NRST | NRST (Debug & Flash) | |
B | BOOT0 | BOOT0 (Debug & Flash) | |
| Jumpers | BOOT | ESP8285 GPIO0 | Bridge to enter ExpressLRS bootloader mode |
RST | ESP8285 CHIP_EN | Bridge to disable internal ExpressLRS receiver |

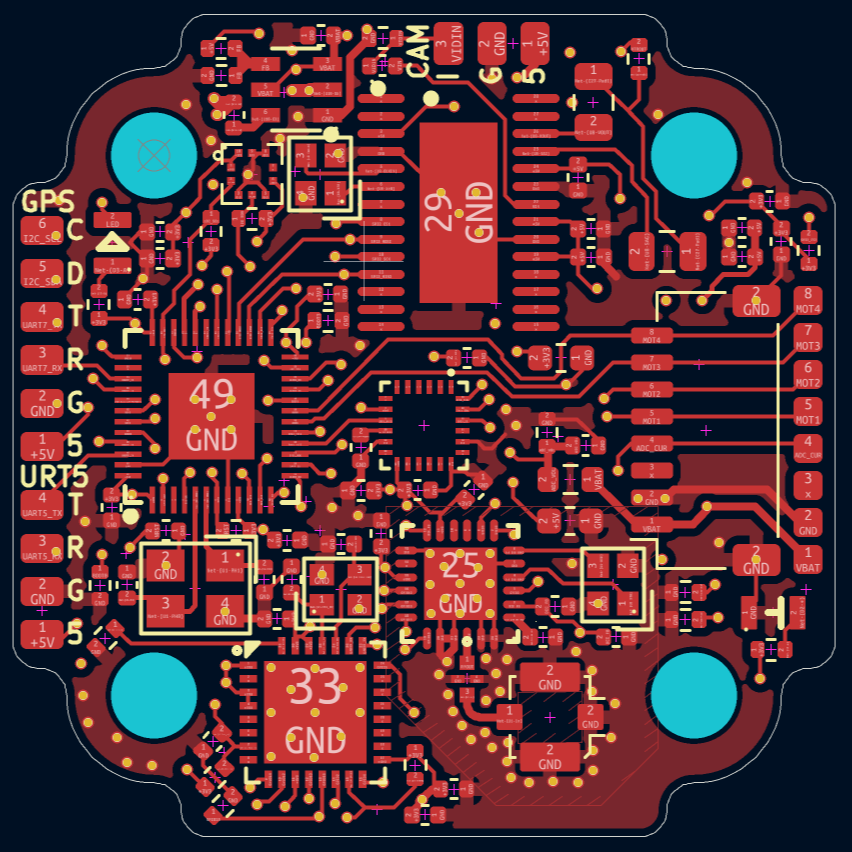
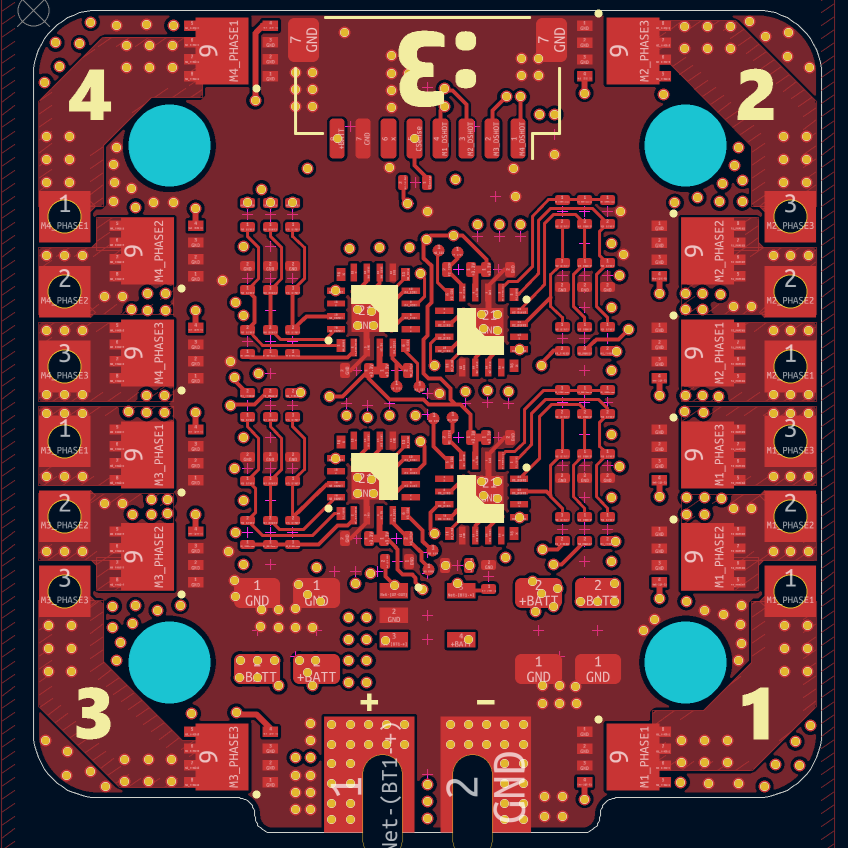
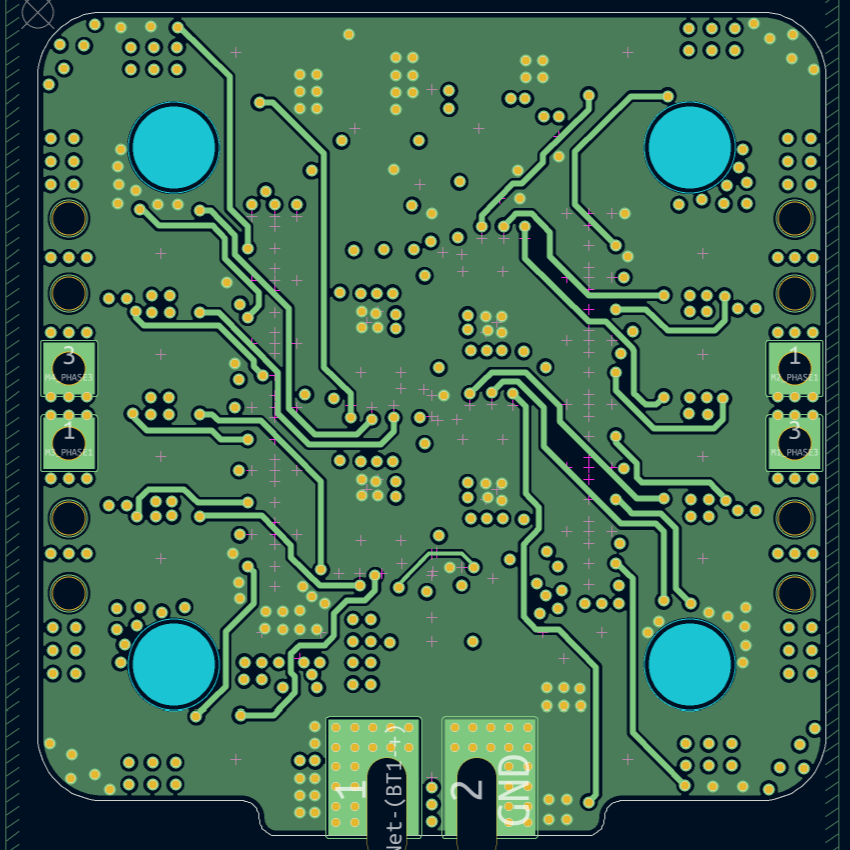
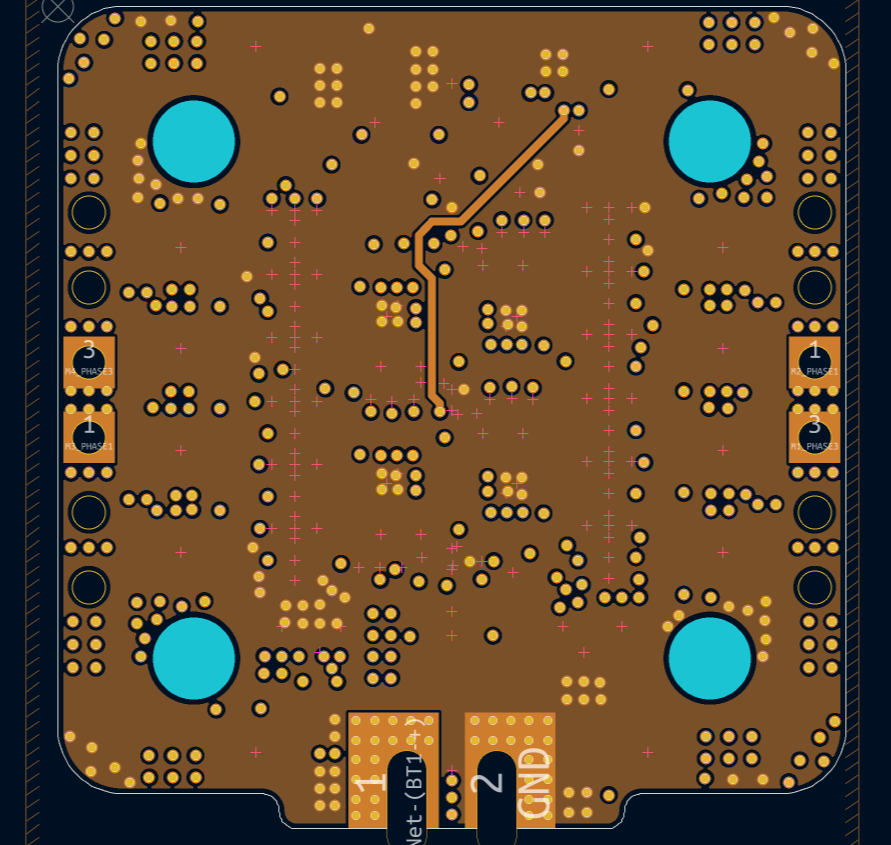
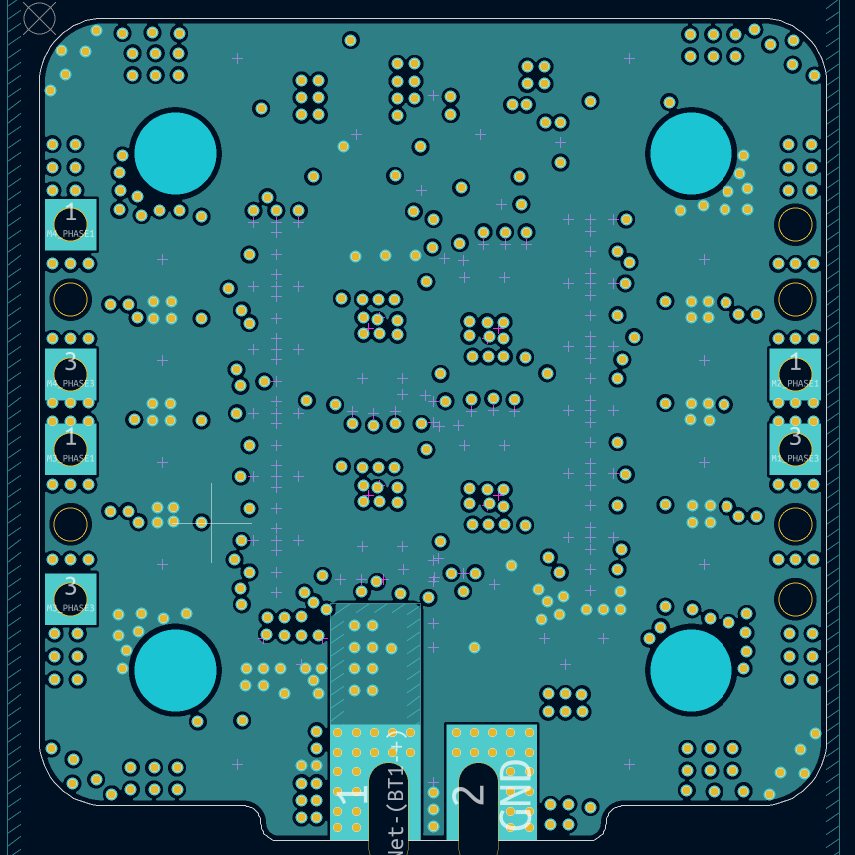
Because the Merlyn435 is a custom hardware layout with no existing Betaflight targets, you must compile Betaflight using the custom target definitions in /firmware/source/betaflight or use the pre compiled firmware of your preferred Betaflight version in /firmware/binaries
[!IMPORTANT] The LSM6DSK320X was officially added in v2026.6. The same Betaflight configuration can be used to compile your binary for both 2025.12 and 2026.6 without any issues. However, 2025.12 does not support or detect the LSM6DSK320X, so the LSM6DSK320X IMU will only function when running 2026.6 or later.
make configs (install any required GCC toolchain if asked)MERLYN435 and paste config.h in the new directoryMERLYN435 directory inside "ANSN"make MERLYN435 and the .hex file should appear in betaflight/objgit checkout 9.1.0build in the root directory and another named MERLYN435 in /src/main/targetCMakeLists.txt, target.c and target.h into the MERLYN435 directory from /firmware/source/inavbuild directorycmake .. (install any required GCC toolchain if asked)make MERLYN435 and the .hex file should appear in /buildB test point to 3.3v and plug in the USB C cable. Open Betaflight Configurator (applicable for iNav), select your compiled local .hex file, and click Flash Firmware.B, D and C test points (R is optional) and flash the compiled binary with STM32CubeProgrammer.The internal ESP8285 ExpressLRS receiver is wired to the AT32 via UART2. It uses the BETAFPV 2.4GHz Lite RX firmware target. The firmware binaries can be obtained from the ELRS site or from this repository in /firmware/binaries. There are two way to flash the receiver:
Note that Betaflight must be installed and configured before passthrough works.
Bridge the BOOT pad
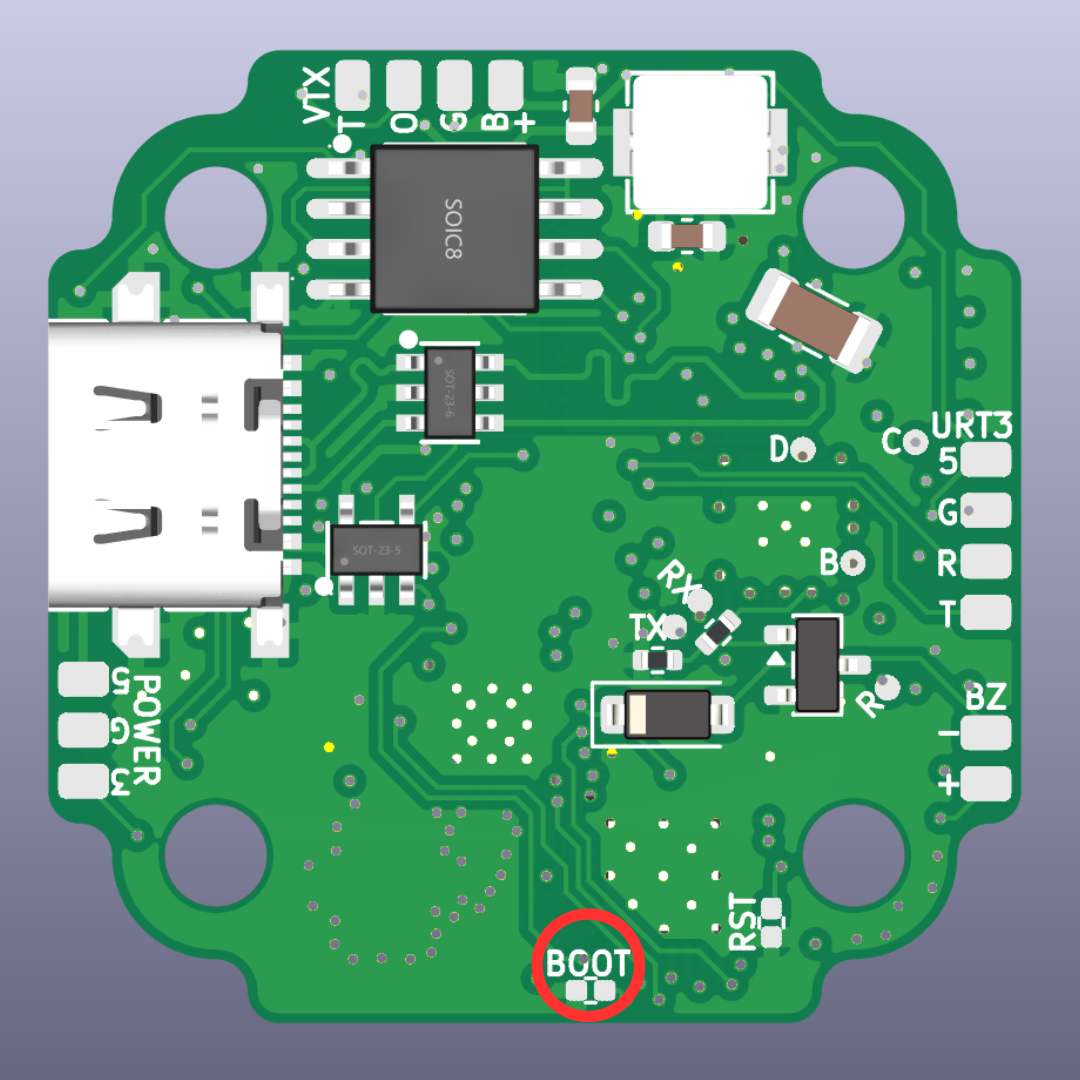
Connect the FC via USB
Open the ExpressLRS Configurator web flasher or app
Select Receiver
Select your preferred firmware version and the BETAFPV 2.4GHz Lite RX target and press next
[OPTIONAL] Enter your bind phrase
Select the Betaflight Passthrough flashing method, press next and follow the steps
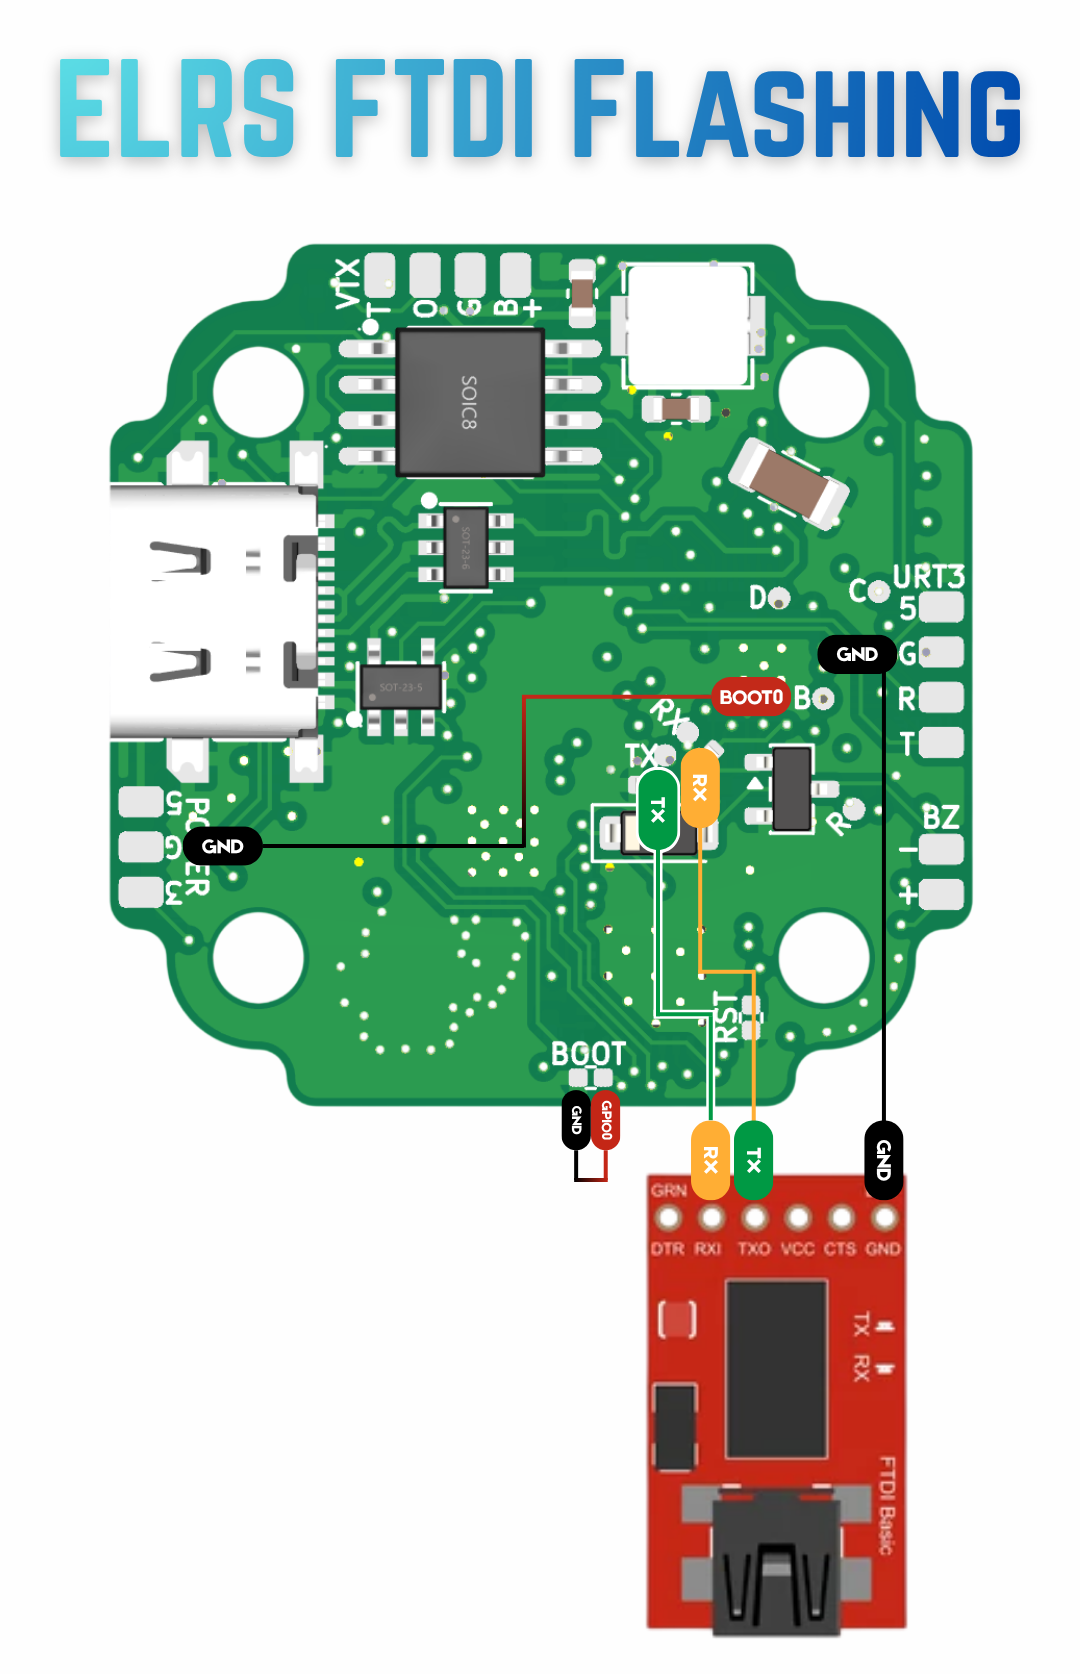
If the ESP8285 is bricked or passthrough fails, you can flash it directly using an FTDI adapter or another ESP8285/ESP8286/ESP32 or even an Arduino. Bridge R to GND as well as the BOOT jumper and connect the FTDI TX to RX and FTDI RX to TX
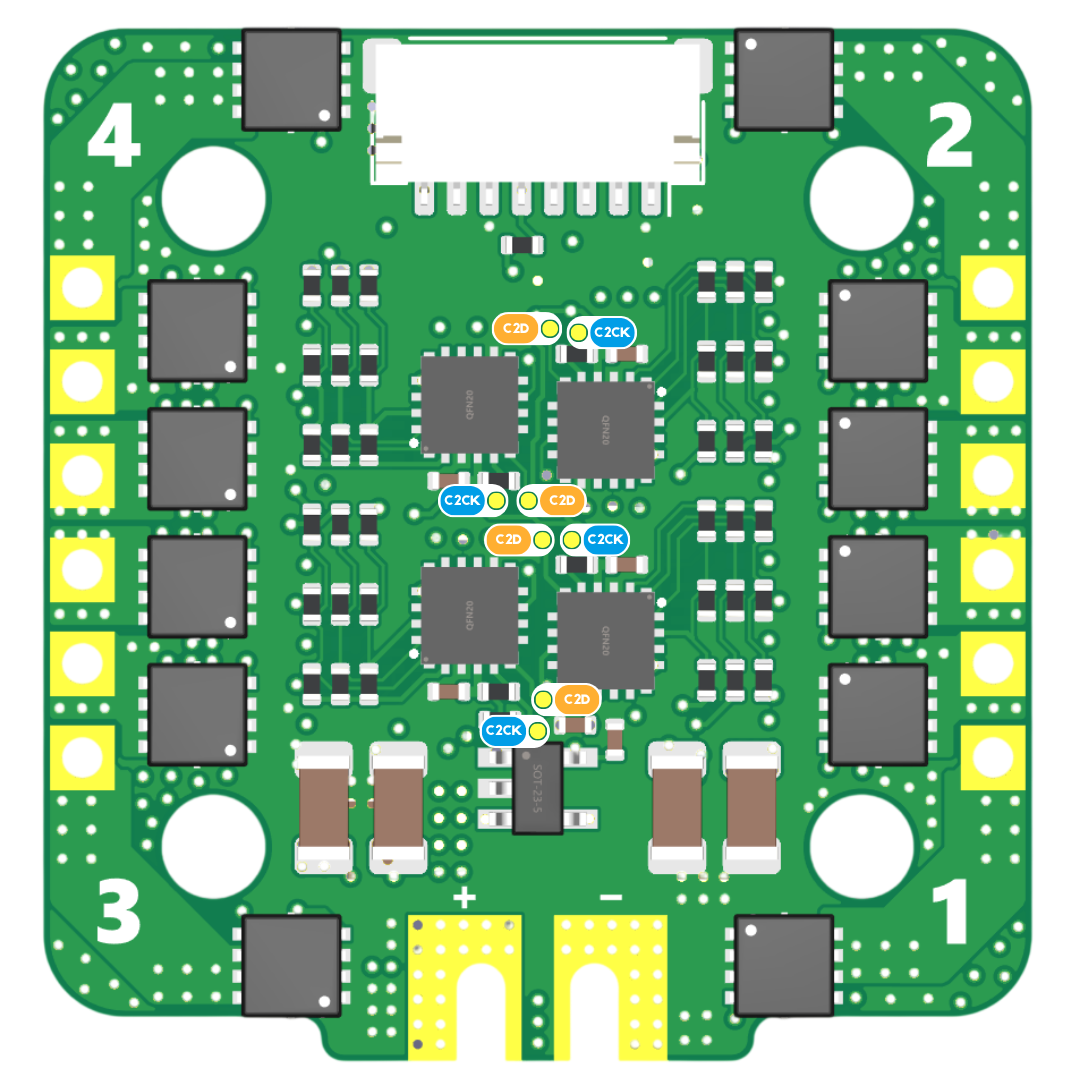
The MerlynESC is a 4 in 1 ESC that runs Bluejay firmware target A, MCU type H, 30x20.4ns deadtime and 48KHz PWM frequency. The firmware files can be found in /firmware/binaries or the official Bluejay repository. You can flash the EFM8BB21 chips using the C2 programming pads with a makeshift arduino programmer.
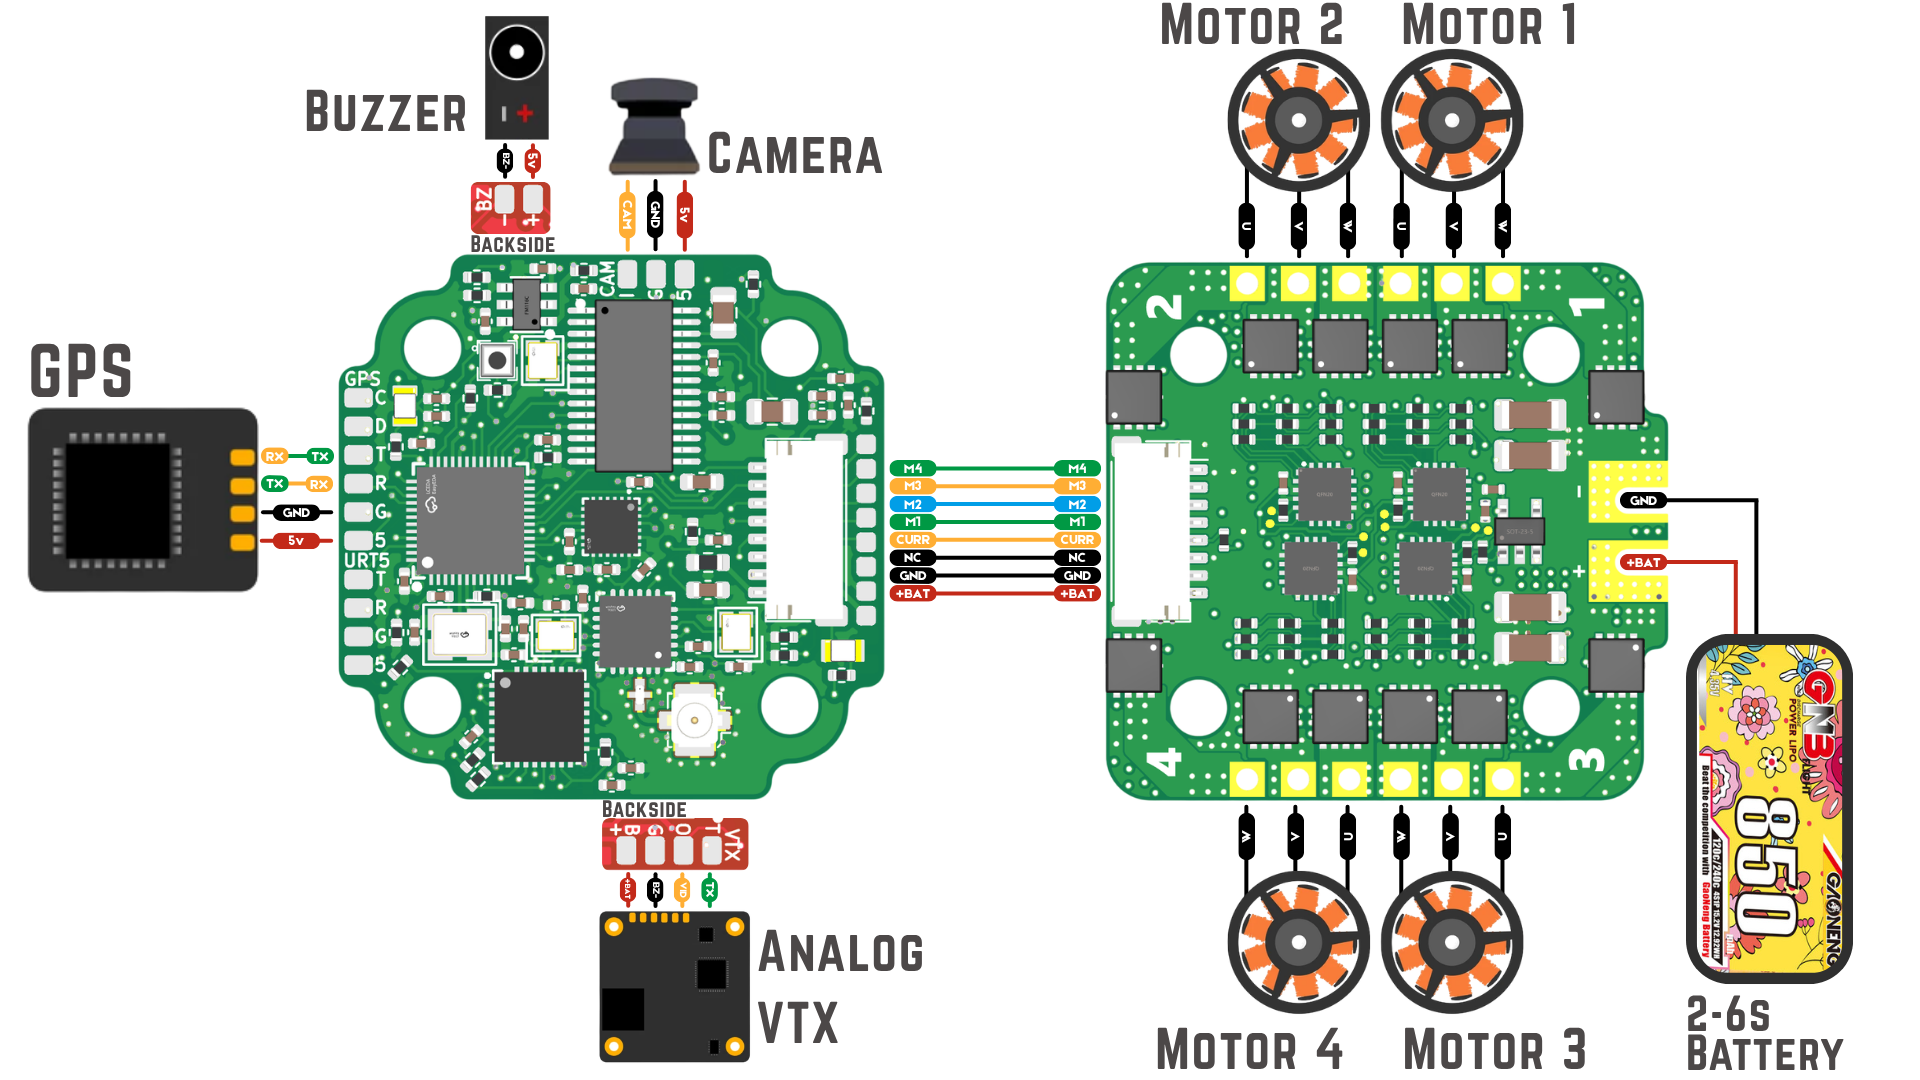
While this project is mainly focused on the Merlyn435 + MerlynESC flight stack, I also designed a high performance 3 inch freestyle FPV drone. If you want to recreate the full build, below is the component breakdown:
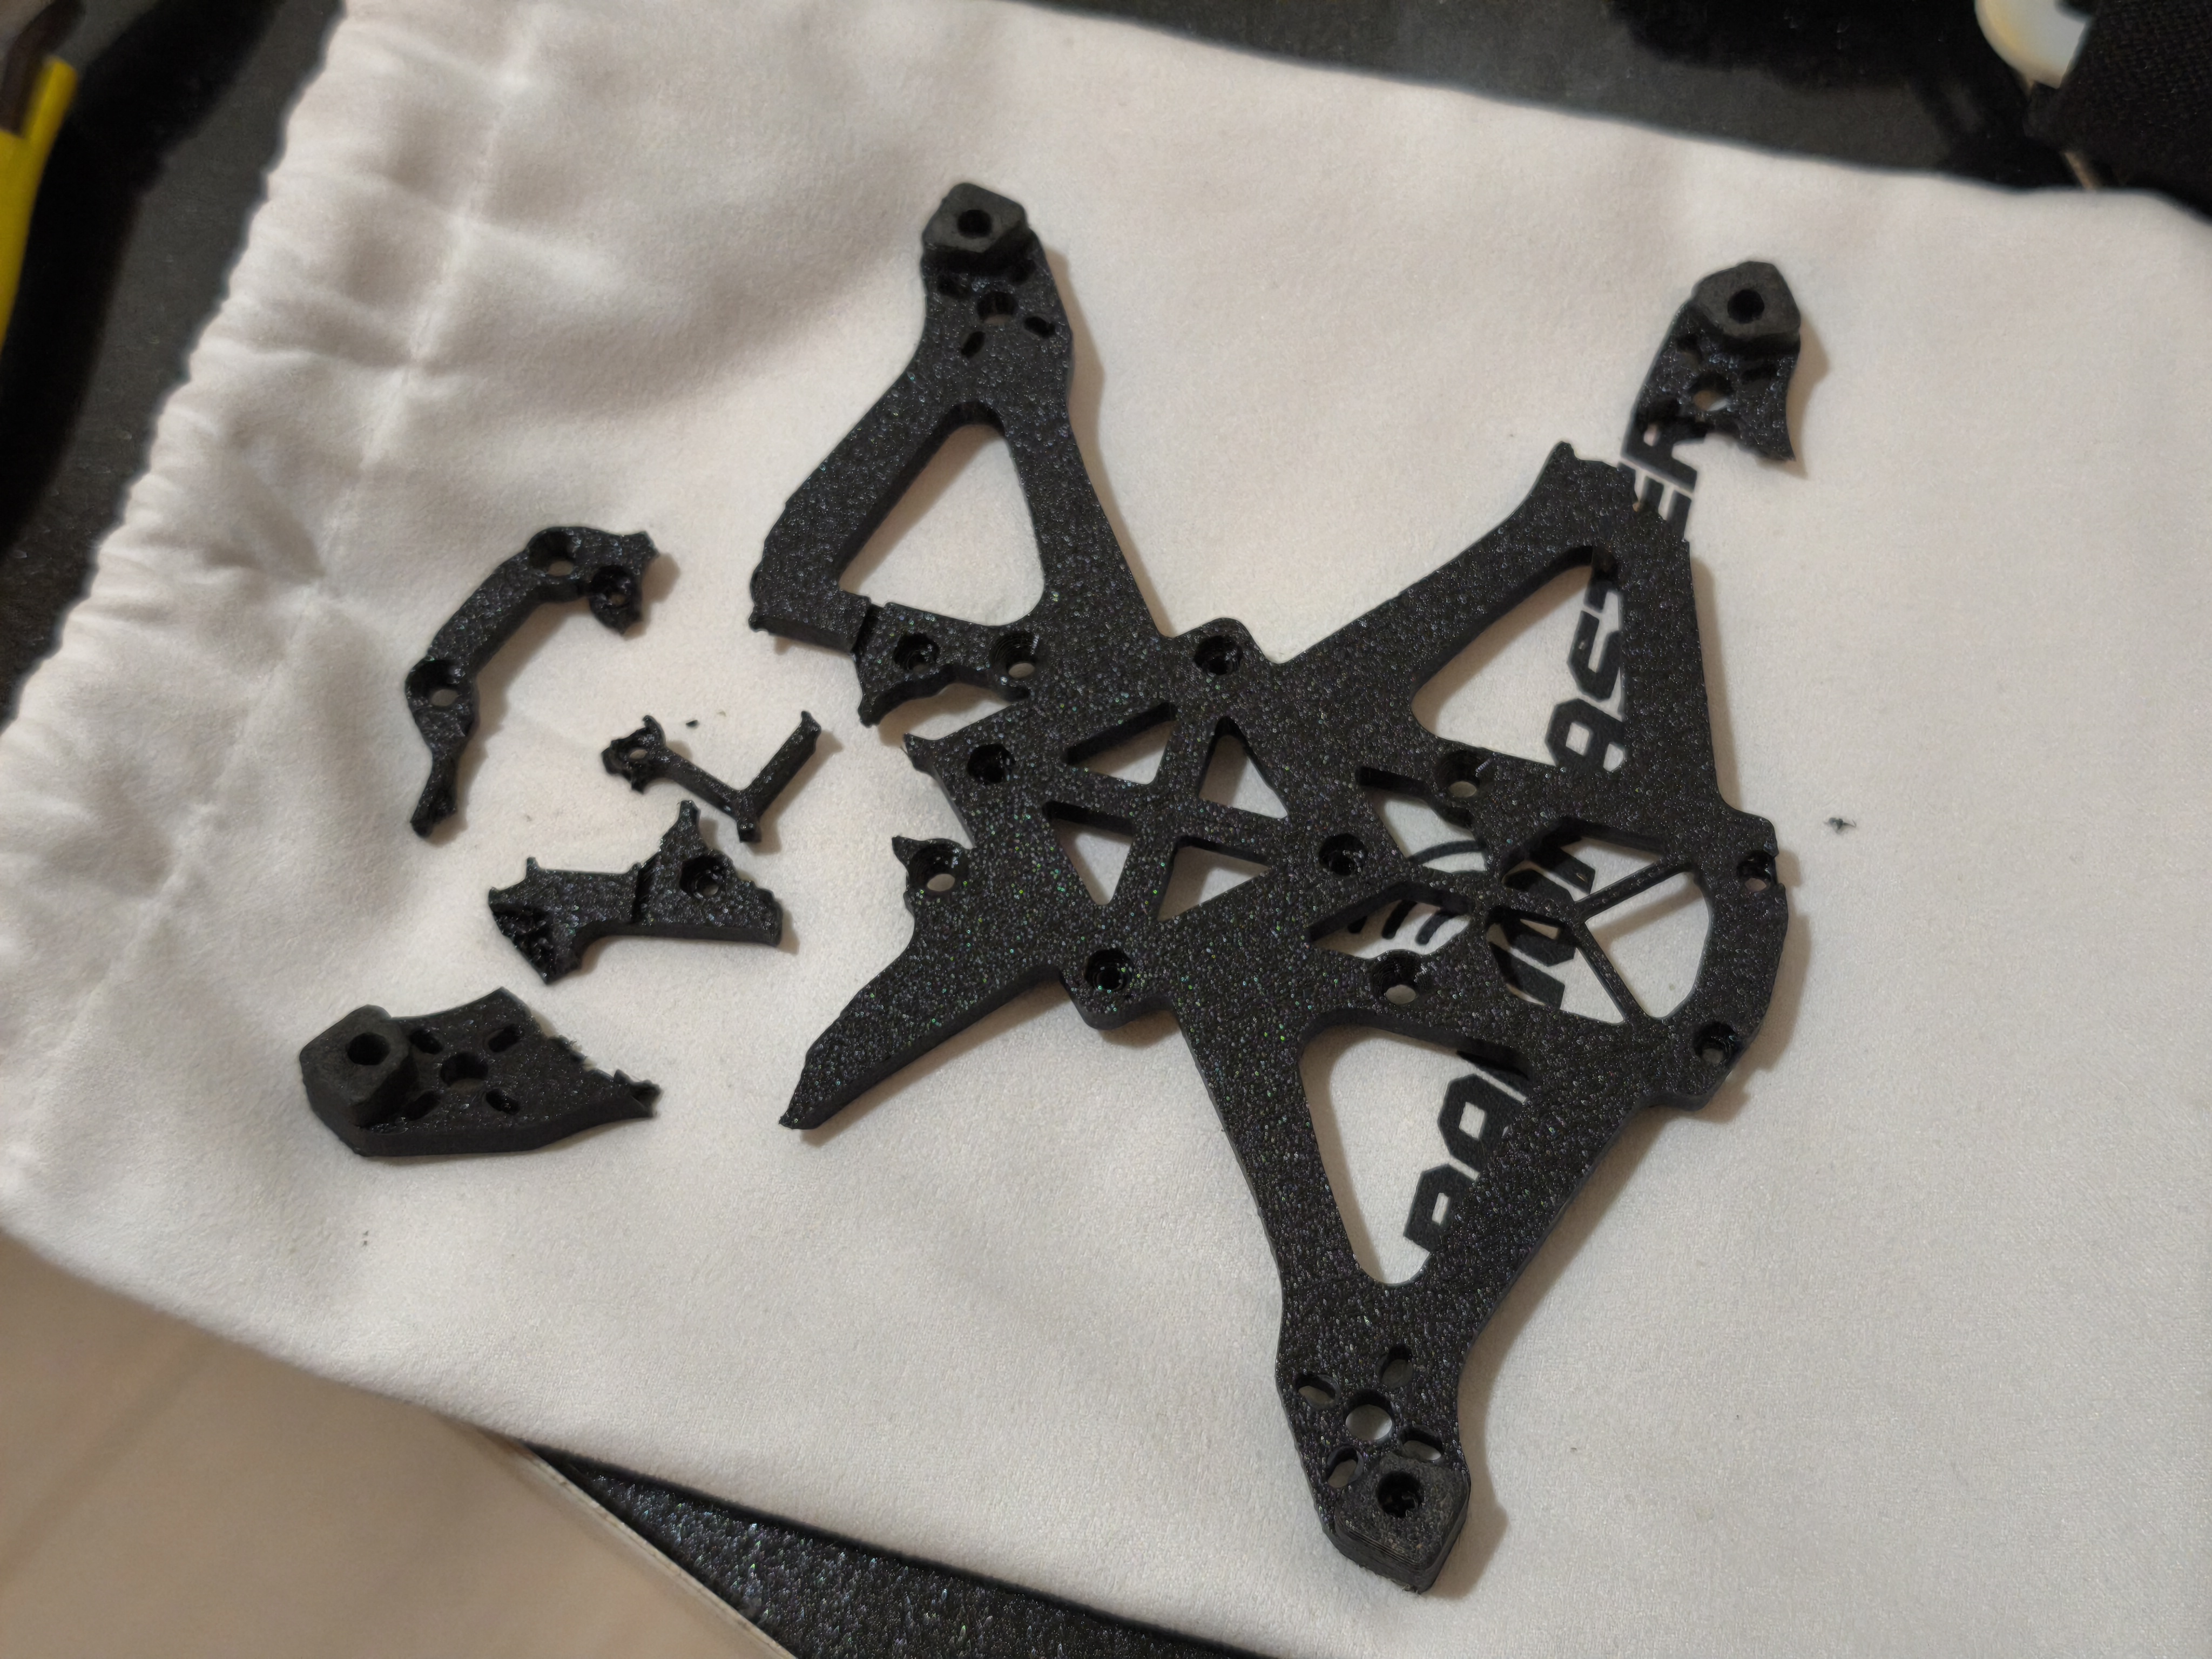
I advise against 3D printing your frame. On my previous build, a 100 percent infill PETG frame shattered from a very light fall. More importantly, 3D printed frames flex and resonate which causes excessive gyro noise and leads to deteriorated flight performance.
https://github.com/user-attachments/assets/90db9ad2-082e-437a-b4b3-71ebe933a74a
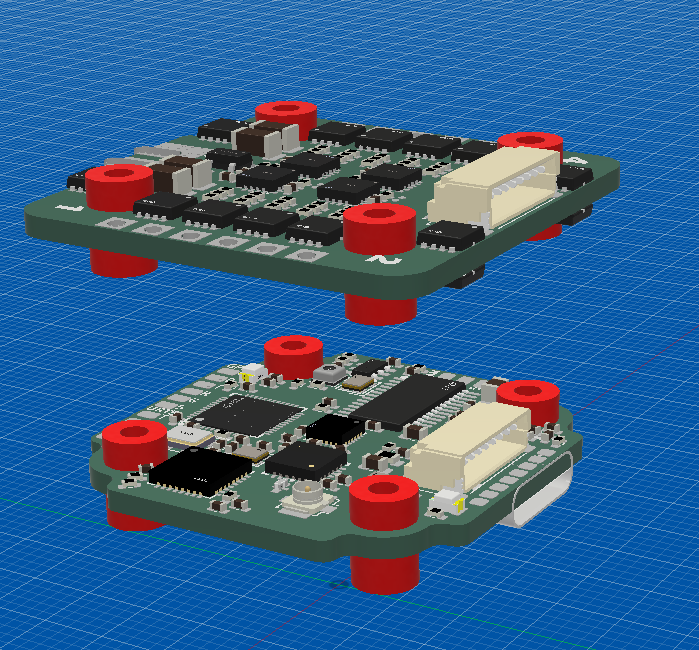
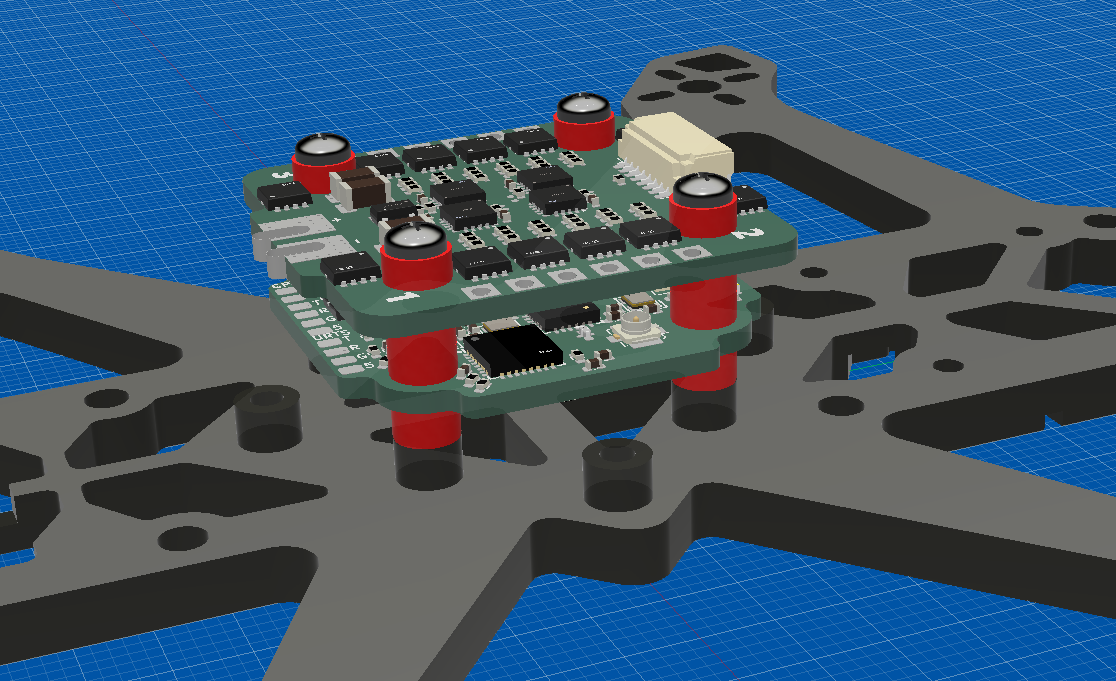
The Merlyn435 and ESC uses standard 20x20mm mounting hole distance.
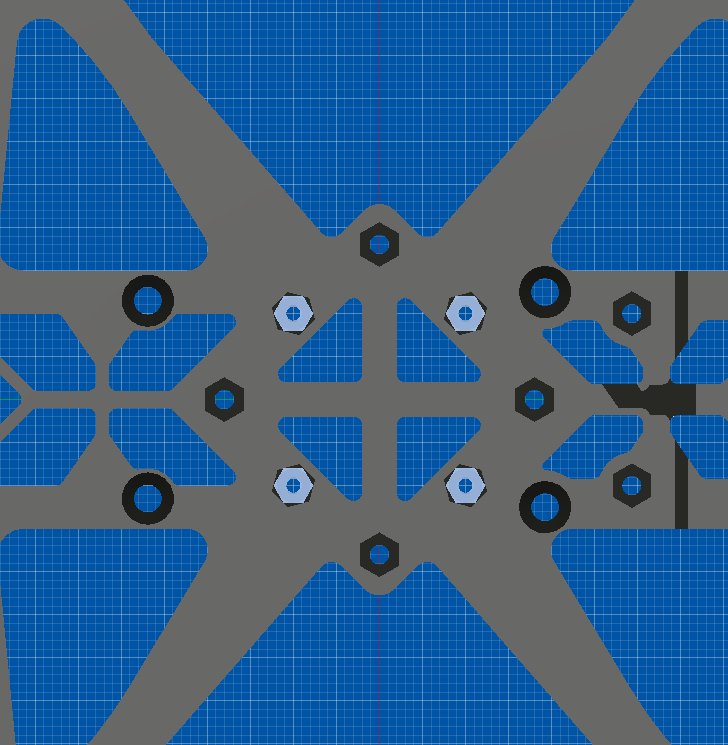
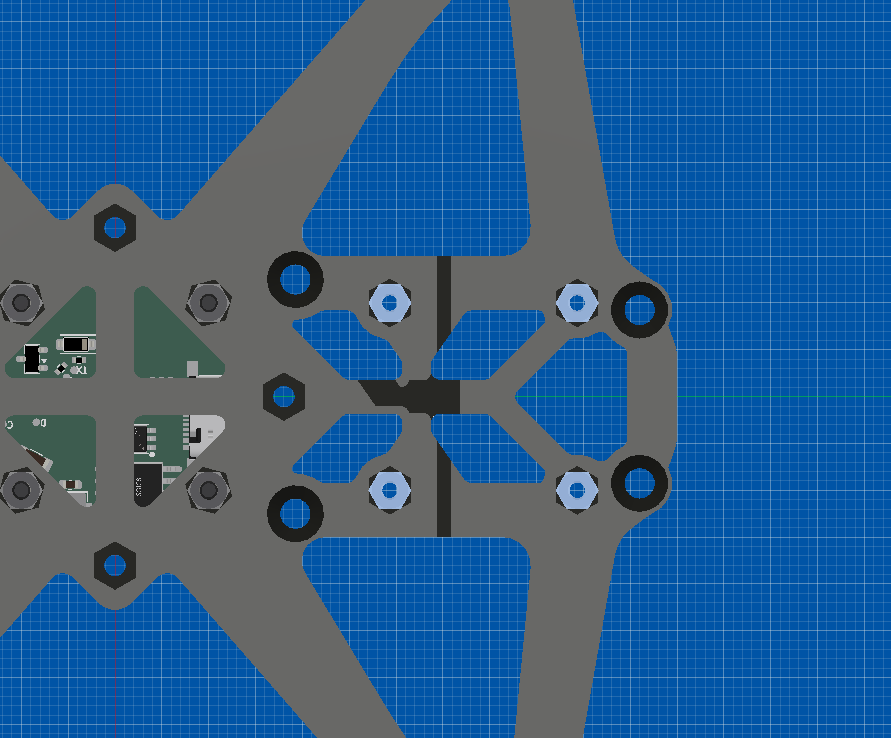
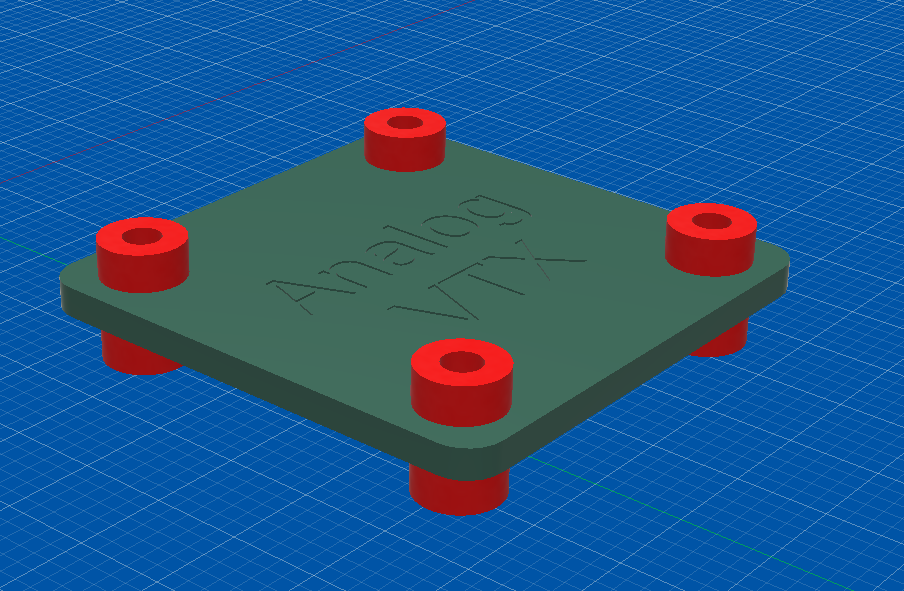
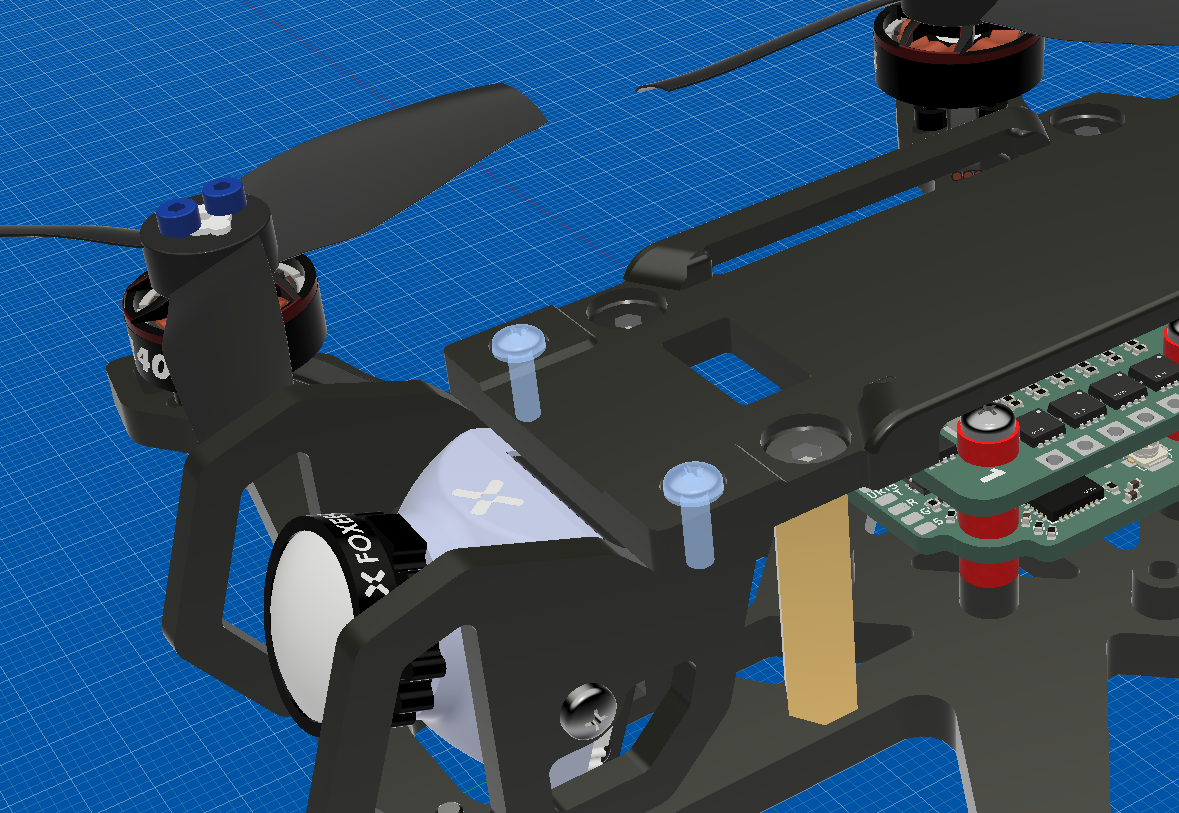
The VTX mounts to the rear of the frame.
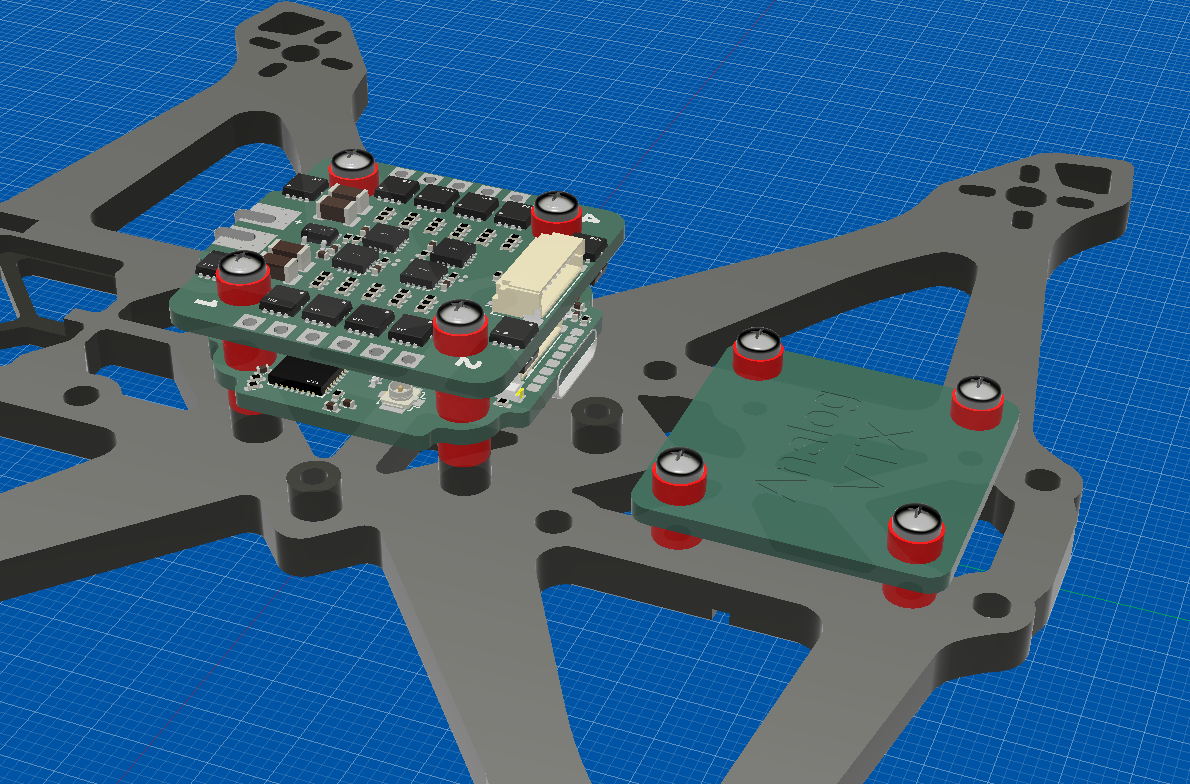
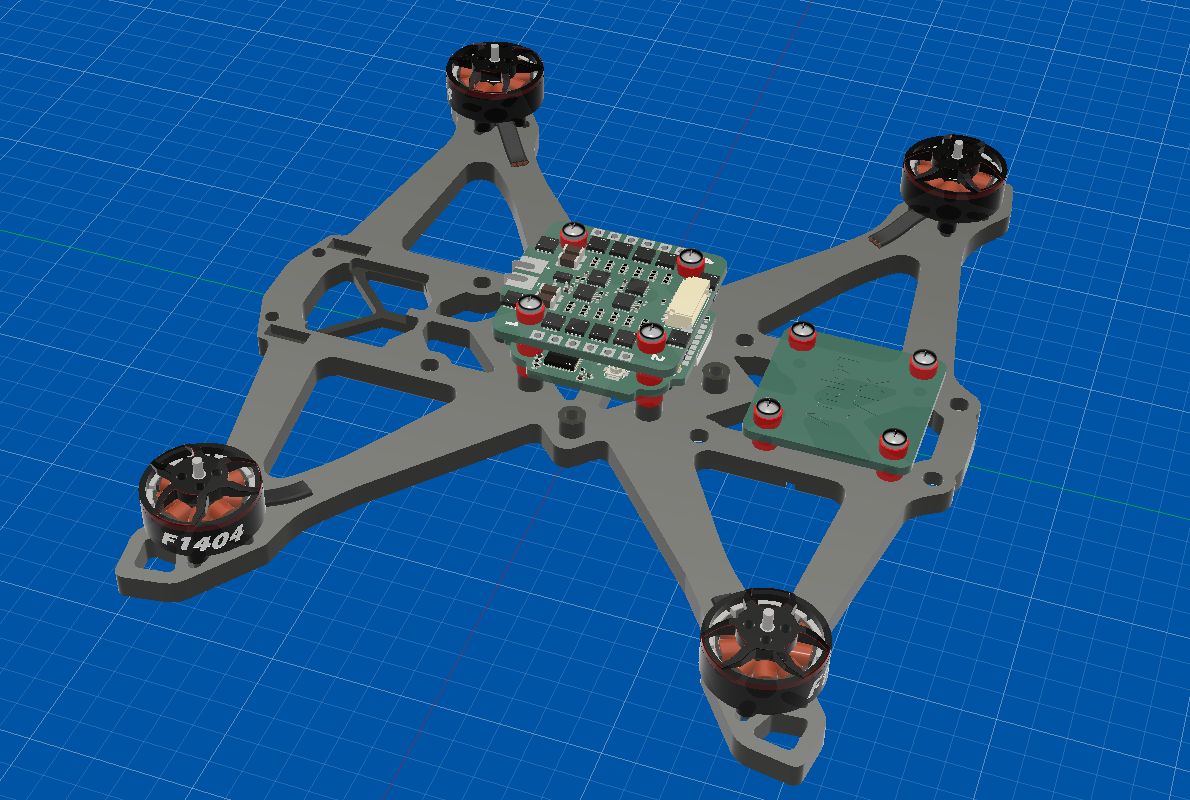
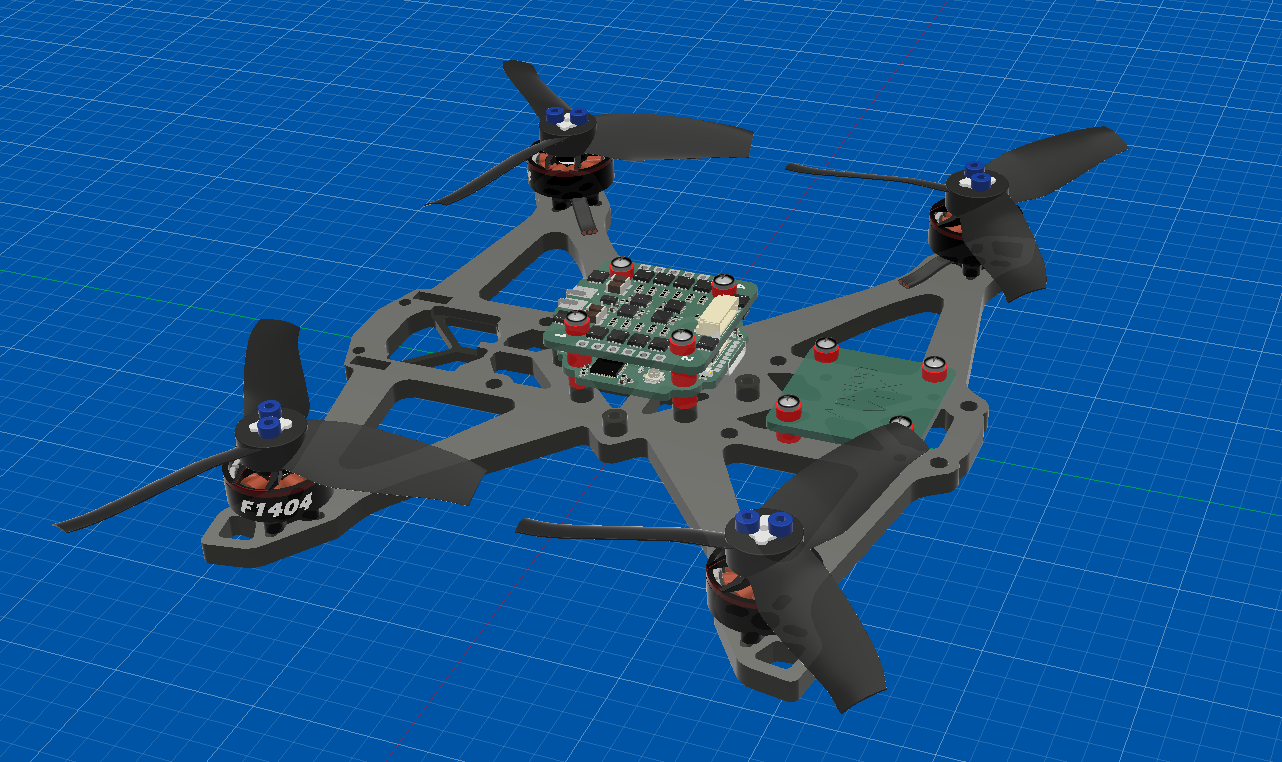
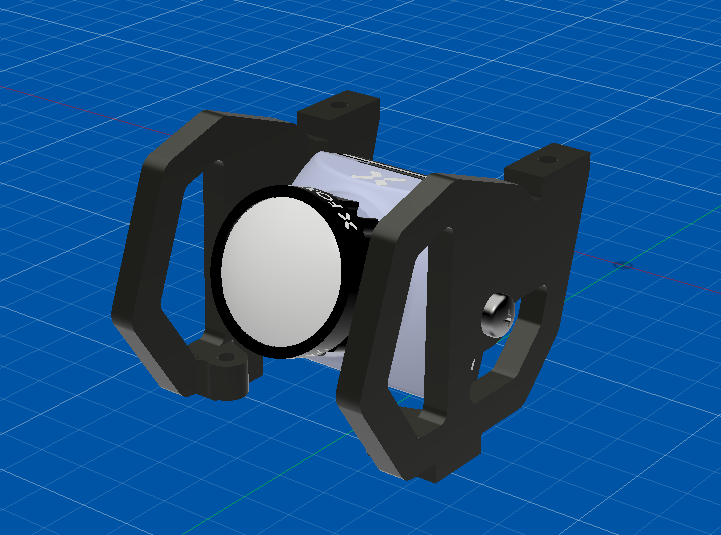
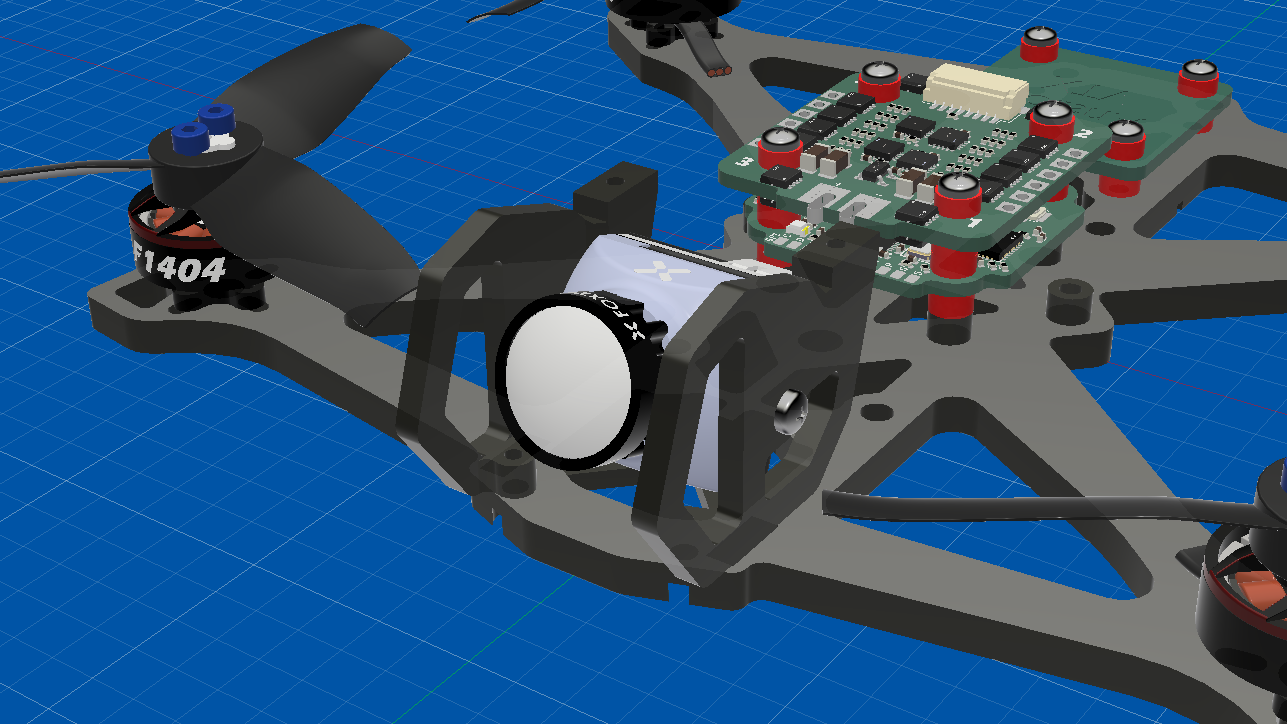
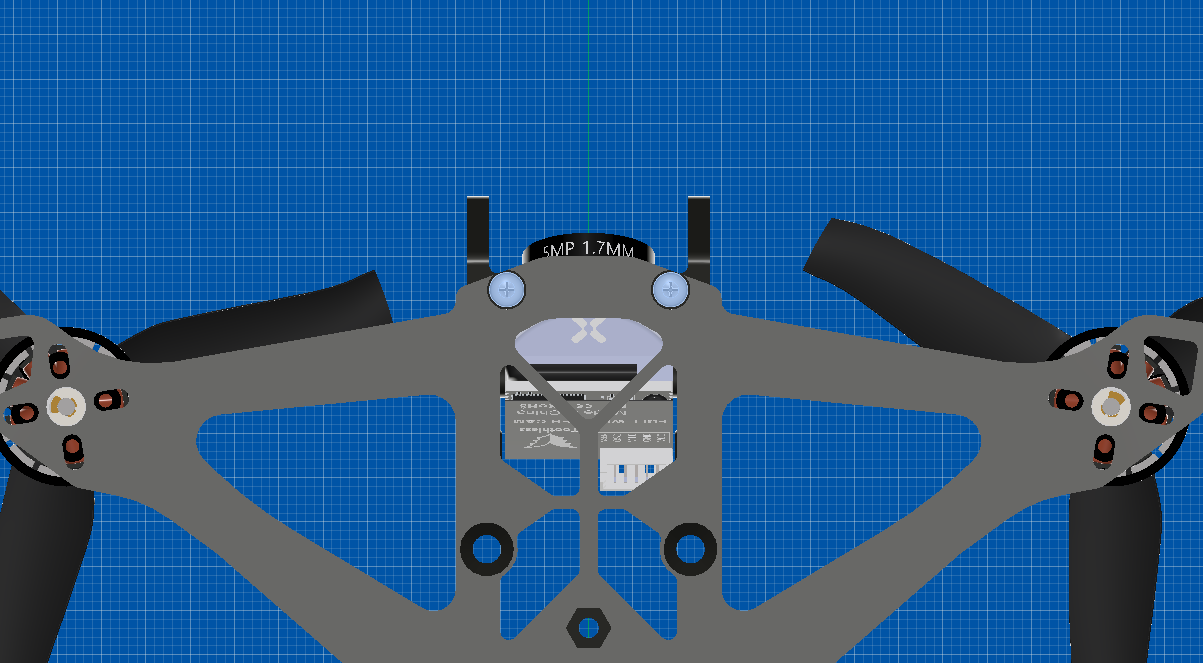
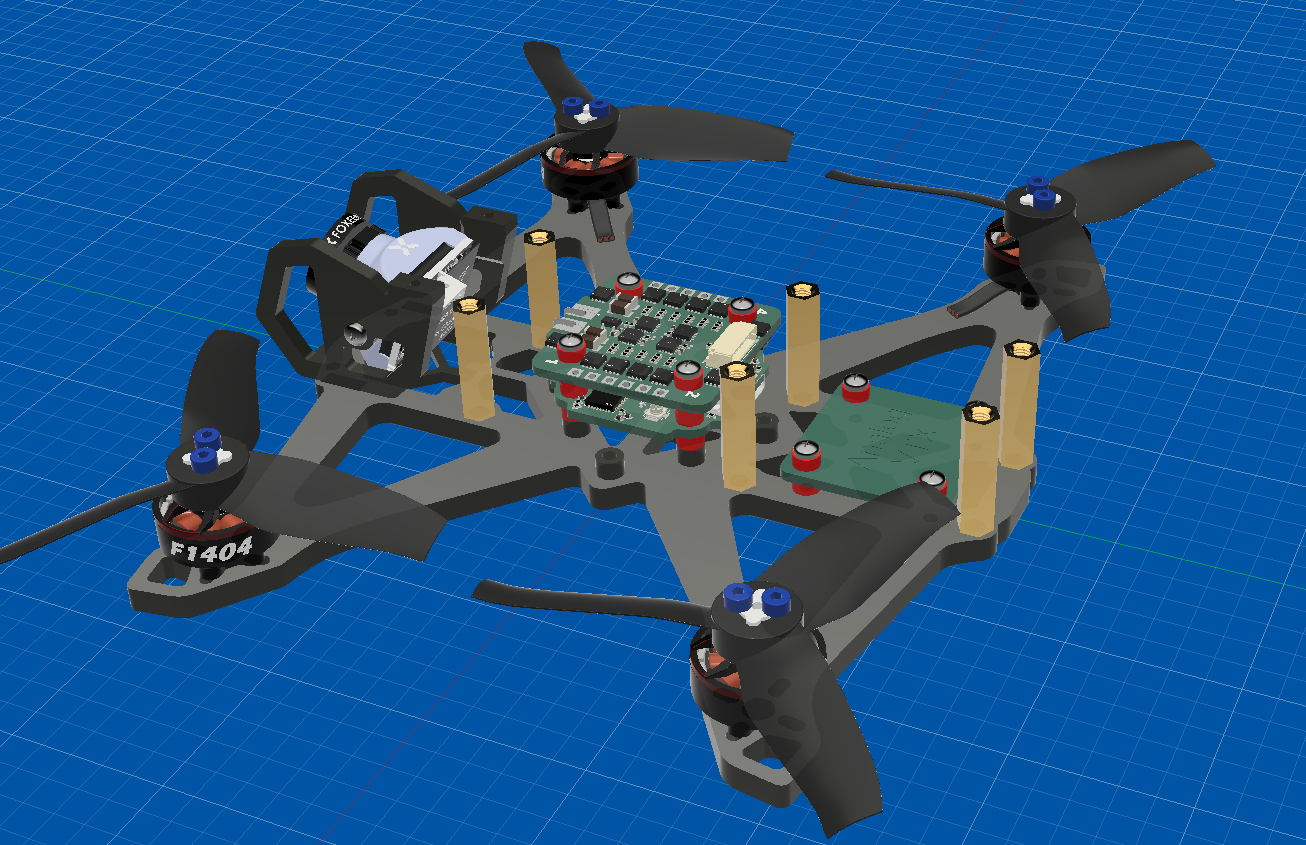
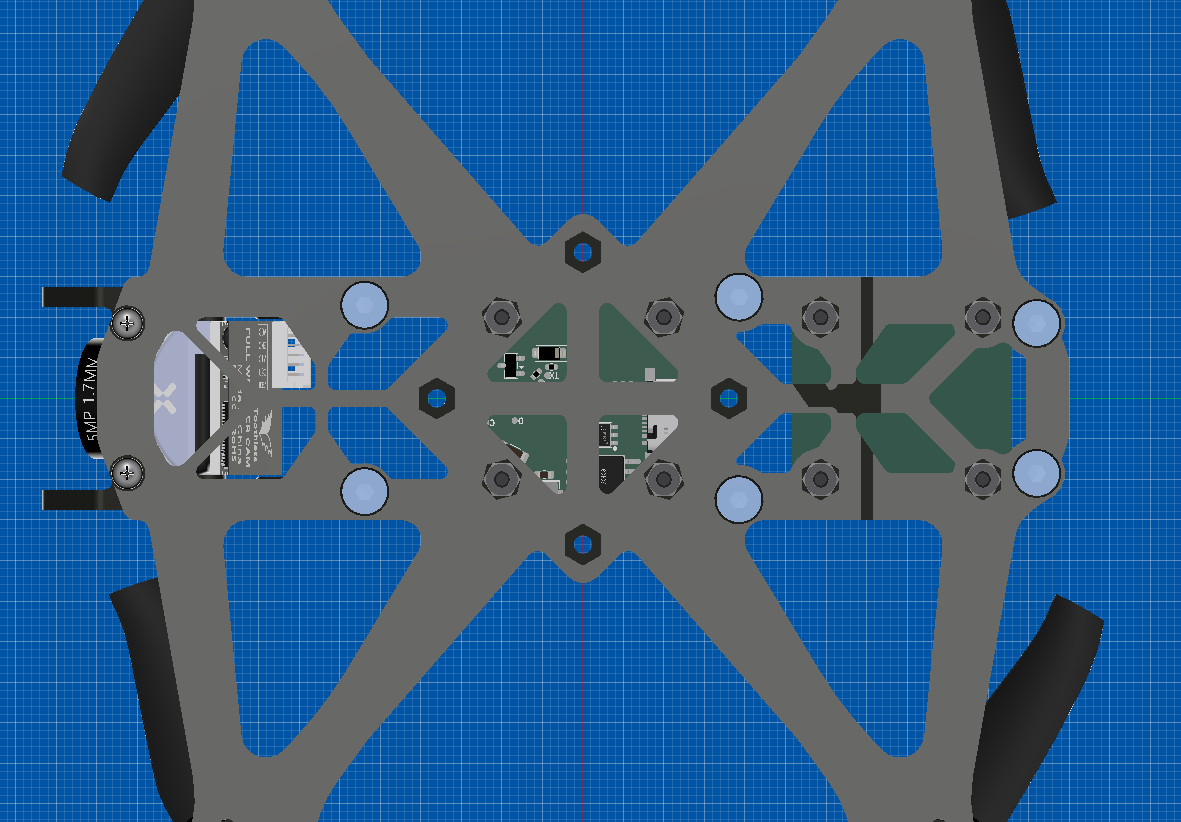
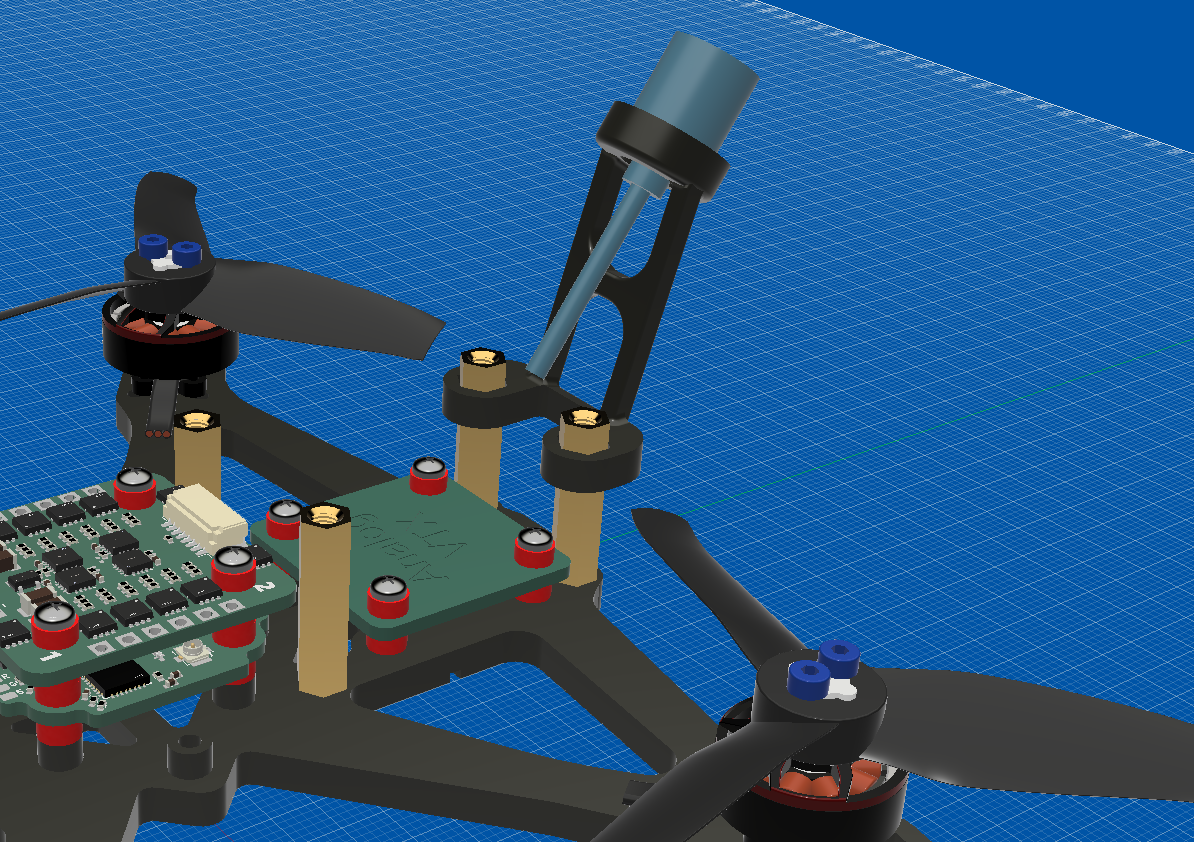
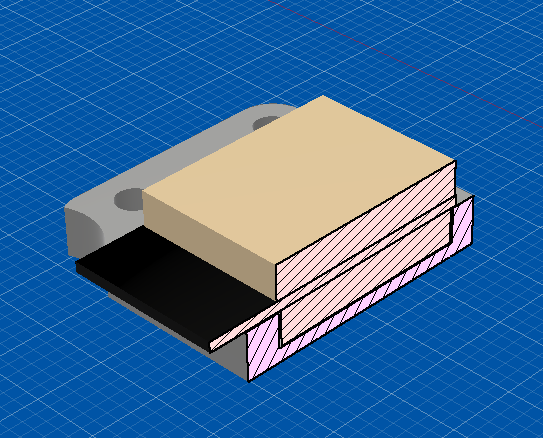
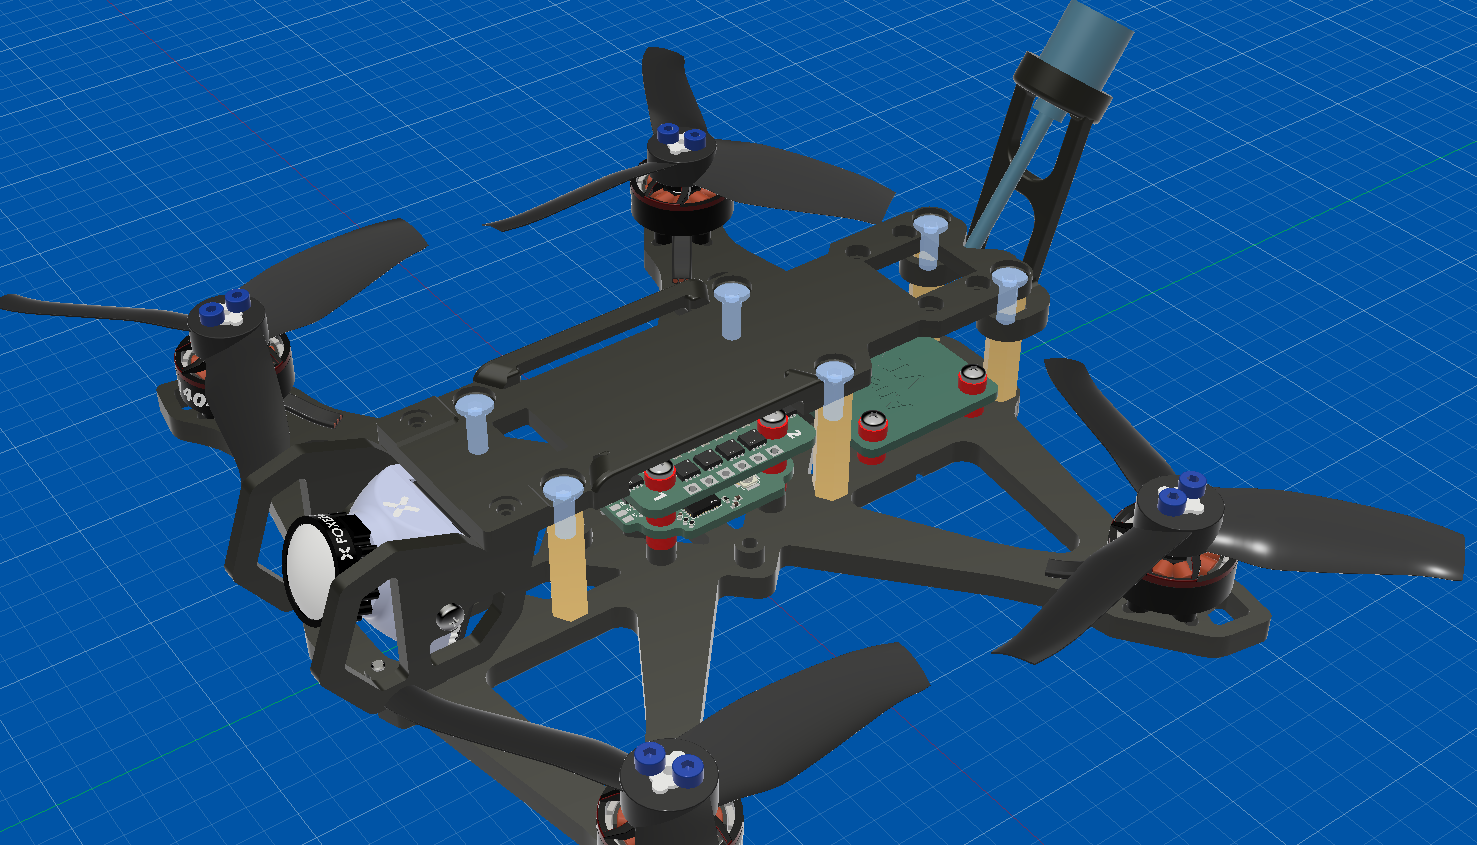
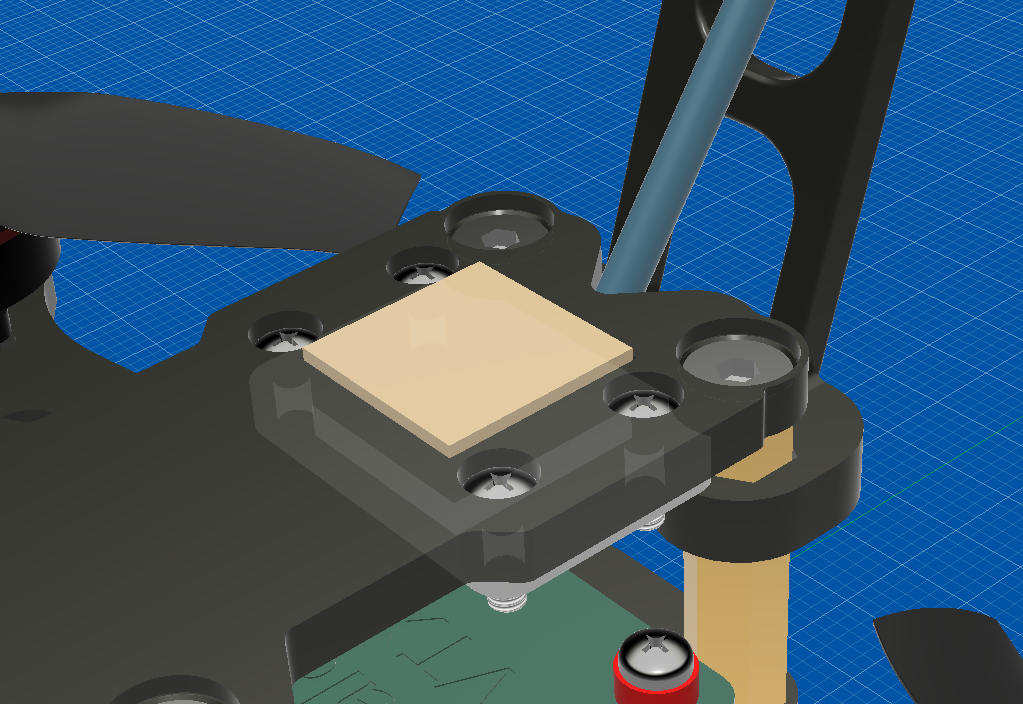
Note: The prices in USD are converted as of 22 August 2026 and may fluctuate. Promo codes will be applied before checkout to bring the costs down. And yes, the costs of separate components are cheaper than JLCPCB assembly.
| Category | Item Name | Description | Link | Vendor | Quantity | Total Price (USD) |
|---|---|---|---|---|---|---|
| Flight Controller | TAXM8M4RDBCCT2T | 8 MHz crystal | link | LCSC | 5 | 0.73 |
| Flight Controller | 7D027000I01 | 27 MHz crystal | link | LCSC | 5 | 0.50 |
| Flight Controller | XL7EL89CMI-111YLC-26M | 26 MHz crystal | link | LCSC | 5 | 0.44 |
| Flight Controller | XC21M4-52.000-F10NNHPL | 52 MHz crystal | link | LCSC | 5 | 0.68 |
| Flight Controller | TYPE-C 16P QTWT | USB C Connector SMT | link | LCSC | 10 | 0.75 |
| Flight Controller | LMR51420YDDCR | Buck converter | link | LCSC | 2 | 1.96 |
| Flight Controller | AT7456E | Video overlay OSD | link | LCSC | 2 (Two because there's a deal on LCSC that lets me get both for free) | 7.49 |
| Flight Controller | SPX3819M5-L-3-3/TR | 3.3v LDO regulator | link | LCSC | 10 | 2.19 |
| Flight Controller | APH0420T4R7M | 4.7uH inductor | link | LCSC | 5 | 0.45 |
| Flight Controller | USBLC6-2SC6 | USB ESD protection | link | LCSC | 5 | 0.92 |
| Flight Controller | BWU.FL-IPEX1 | U.FL connector | link | LCSC | 10 | 0.42 |
| Flight Controller | 0402WGF1202TCE | 12k 0402 resistor | link | LCSC | 100 | 0.69 |
| Flight Controller | 0402WGF1501TCE | 1.5k 0402 resistor | link | LCSC | 100 | 0.50 |
| Flight Controller+ESC | CL10A106MA8NRNC | 10uF 0603 capacitor | link | LCSC | 20 | 1.60 |
| Flight Controller | 1206B475K500NT | 4.7uF 1206 capacitor | link | LCSC | 10 | 2.72 |
| Flight Controller | W25Q128JVSIQ | 16MB flash chip | link | LCSC | 1 | 2.62 |
| Flight Controller | HC-1.0-8PWT | JST SH 8p connector | link | LCSC | 5 | 0.67 |
| Flight Controller | LSM6DSK320XTR | LSM6 series IMU | link | LCSC | 1 | 9.18 |
| Flight Controller | PCB | PCB | - | JLCPCB | 1 | 7.00 |
| Flight Controller | Partial PCB Assembly | Partial PCB Assembly | - | JLCPCB | 1 | 47.91 |
| ESC | GRM21BR61H106KE43L | 10uF 0805 capacitor | link | LCSC | 5 | 1.25 |
| ESC | CL31A106KBHNNNE | 10uF 1206 capacitor | link | LCSC | 20 | 5.63 |
| ESC | CL05B104KB54PNC | 0.1uF 0402 capacitor | link | LCSC | 100 | 0.93 |
| ESC | CL05A105KA5NQNC | 1uF 0402 capacitor | link | LCSC | 50 | 0.61 |
| ESC | 1SS400CMT2R | SOD923 diode | link | LCSC | 40 | 1.02 |
| ESC | JMSL0302AU | N channel MOSFET | link | LCSC | 25 | 7.07 |
| ESC | 0402WGF1002TCE | 10k 0402 resistor | link | LCSC | 100 | 0.19 |
| ESC | 0402WGF4701TCE | 4.7k 0402 resistor | link | LCSC | 100 | 0.50 |
| ESC | 0402WGF1001TCE | 1k 0402 resistor | link | LCSC | 100 | 0.67 |
| ESC | 0402WGF100JTCE | 10R 0402 resistor | link | LCSC | 100 | 0.58 |
| ESC | HoYLR2512E-3W-0.5mR-1% | 0.5mR 2512 shunt resistor | link | LCSC | 10 | 0.60 |
| ESC | 0402WGF3902TCE | 39k 0402 resistor | link | LCSC | 100 | 0.69 |
| ESC | HT75C0-1 | 12v LDO regulator | link | LCSC | 5 | 0.99 |
| ESC | HT7533-1 | 3.3v LDO regulator | link | LCSC | 5 | 0.71 |
| ESC | EFM8BB21F16G-C-QFN20R | ESC MCU | link | LCSC | 5 | 6.33 |
| ESC | EG6288 | Gate driver | link | LCSC | 10 | 3.06 |
| ESC | INA139NA/3K | Current sensor | link | LCSC | 2 | 1.12 |
| ESC | PCB | PCB | - | JLCPCB | 1 | 2.00 |
| Flight Controller + ESC | Shipping | EPOST shipping | - | JLCPCB | 1 | 6.49 |
| Flight Controller + ESC | Shipping | LCSC | - | LCSC | 1 | 4.92 |
| Drone Parts | RATE 1505 4300kv motor | Motors | link | TaoBao | 4 | 28.75 |
| Drone Parts | RATE S30 Pro frame | Carbon fiber frame | link | TaoBao | 1 | 23.06 |
| Drone Parts | RATE analog antenna | Right hand circular polarized 5.8GHz antenna | link | TaoBao | 1 | 5.80 |
| Drone Parts | RATE 90mm ELRS antenna | Linear polarized dipole 2.4GHz antenna | link | TaoBao | 1 | 0.95 |
| Drone Parts | RATE beeper/buzzer | Active piezo buzzer | link | TaoBao | 1 | 0.64 |
| Drone Parts | HQPROP T3x3x3 | 2 Pairs 3 inch propeller | link | TaoBao | 1 | 1.88 |
| Drone Parts | RATE XT30 + Cable | Connector and cable | link | TaoBao | 1 | 0.64 |
| Drone Parts | RATE Rubber Grommets | 10pcs soft mounting rubber grommet | link | TaoBao | 1 | 0.48 |
| Drone Parts | RATE M10 GPS | Nano size gps module with battery | link | TaoBao | 1 | 8.80 |
| Drone Parts | 470uF low ESR capacitor | Capacitor for MOSFET protection | link | TaoBao | 1 | 0.42 |
| Drone Parts | Cyclone 1W VTX | 5.8GHz analog video transmitter | link | TaoBao | 1 | 14.00 |
| Drone Parts | TaoBao Tax | Fees | - | TaoBao | 1 | 10.05 |
| Drone Parts | TaoBao Shipping | Shipping | - | TaoBao | 1 | 4.05 |
| Drone Parts | CADDX Ratel 2 + Tax | 19mm Analog camera | link | AliExpress | 1 | 28.64 |
| Drone Parts | AliExpress Shipping | Shipping | - | AliExpress | 1 | 0.99 |
| Drone Parts | GNB LiHV 4S 850mAh | 4S LiHV battery | link | Shopee | 1 | 20.10 |
| Qty | Value | Footprint | References |
|---|---|---|---|
| 24 | 10 | easyeda2kicad:R_0402_1005Metric | R11, R12, R13, R14, R15, R16, R21, R22, R26, R27, R31, R32, R39, R40, R44, R45 +8 |
| 24 | JMSL0302AU | easyeda2kicad:DFN-8_L3.2-W3.1-P0.65-LS3.4-BL | Q1, Q2, Q10, Q11, Q12, Q13, Q14, Q15, Q16, Q17, Q18, Q19, Q20, Q21, Q22, Q23 +8 |
| 16 | 1k | easyeda2kicad:R_0402_1005Metric | R3, R5, R8, R10, R19, R24, R29, R33, R37, R42, R47, R51, R53, R58, R63, R67 |
| 12 | 10k | easyeda2kicad:R_0402_1005Metric | R1, R6, R9, R20, R25, R30, R38, R43, R48, R54, R59, R64 |
| 12 | 1uF | easyeda2kicad:C_0402_1005Metric | C11, C12, C13, C17, C18, C19, C24, C25, C26, C29, C30, C31 |
| 12 | 4.7k | easyeda2kicad:R_0402_1005Metric | R2, R4, R7, R18, R23, R28, R36, R41, R46, R52, R57, R62 |
| 12 | T4 | easyeda2kicad:D_SOD-923 | D1, D2, D3, D4, D5, D6, D7, D8, D9, D10, D11, D12 |
| 10 | 0.1uF | easyeda2kicad:C_0402_1005Metric | C10, C14, C15, C16, C20, C21, C22, C23, C27, C28 |
| 6 | 10uF | easyeda2kicad:C_1206_3216Metric | C3, C4, C5, C6, C7, C8 |
| 4 | BLDC Motor | easyeda2kicad:MotorPad | M1, M2, M3, M4 |
| 4 | C2CK | easyeda2kicad:TestPoint | H1, H4, H6, H8 |
| 4 | C2D | easyeda2kicad:TestPoint | H2, H5, H7, H9 |
| 4 | EFM8BB21F16G | easyeda2kicad:QFN-20_L3.0-W3.0-P0.50-BL-EP1.7_EFM8BB21F16G | U3, U6, U9, U11 |
| 4 | EG6288 | easyeda2kicad:QFN-24_L4.0-W4.0-P0.50-TL-EP2.6 | U4, U5, U8, U10 |
| 2 | 10uF | easyeda2kicad:C_0603_1608Metric | C2, C9 |
| 2 | 39k | easyeda2kicad:R_0402_1005Metric | R34, R35 |
| 1 | 10uF | easyeda2kicad:C_0805_2012Metric | C1 |
| 1 | Battery 2-6s | easyeda2kicad:PowerPad | BT1 |
| 1 | ESC Header | easyeda2kicad:ESC Header | H3 |
| 1 | HOYLR2512E | easyeda2kicad:R2512 | R17 |
| 1 | HT7533-1 | easyeda2kicad:SOT-89-3_L4.5-W2.5-P1.50-LS4.2-BR | U2 |
| 1 | HT75C0-1 | easyeda2kicad:SOT-89-3_L4.5-W2.5-P1.50-LS4.2-BR | U1 |
| 1 | INA139NA | easyeda2kicad:SOT-23-5_L3.0-W1.7-P0.95-LS2.8-BR | U7 |
The 159 most common of 163 parts.
YeetTheAnson/Merlyn435-Flight-Stack
Successor to the Merlyn411 25mm flight controller. The flight stack includes a 3in1 20mm flight controller and a 20mm ESC.

anticitizn/p4eregrine
All-in-one ESP32 P4-based drone ESC, flight controller, and video processor

ImbaNagibator/slot-car-ecom
This repo contains a KiCad design, documentation and ancillary artifacts for a slot car brushless motor electronic commutator or "eCom", also known as an Electronic Speed Controller (ESC).


crteensy/yolo-fc_1-3S
1-3S capable variant of the Yolo flight controller


hackclub/OnBoard
💡 Join 1,000 teenagers and make your first PCB with a $100 grant!

jackw01/scanlight
A better light source for scanning color negative film
It measures 30.5 × 31.9 mm and has 6 copper layers, 1.6 mm thick.
163 parts, built around the EFM8BB21F16G-C-QFN20R, EG6288, INA139NA/3K and HT7533-1. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the YeetTheAnson/Merlyn435-Flight-Stack repository on GitHub, at the commit this page was made from: the board is PCB/ESC/MerlynESC.kicad_pcb and its schematic PCB/ESC/MerlynESC.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask YeetTheAnson before reusing the design.