

2 layers22.9 × 20.3 mm
 ProjInt2/deltarobot
Delta Robot Controller - Hardware, software, report
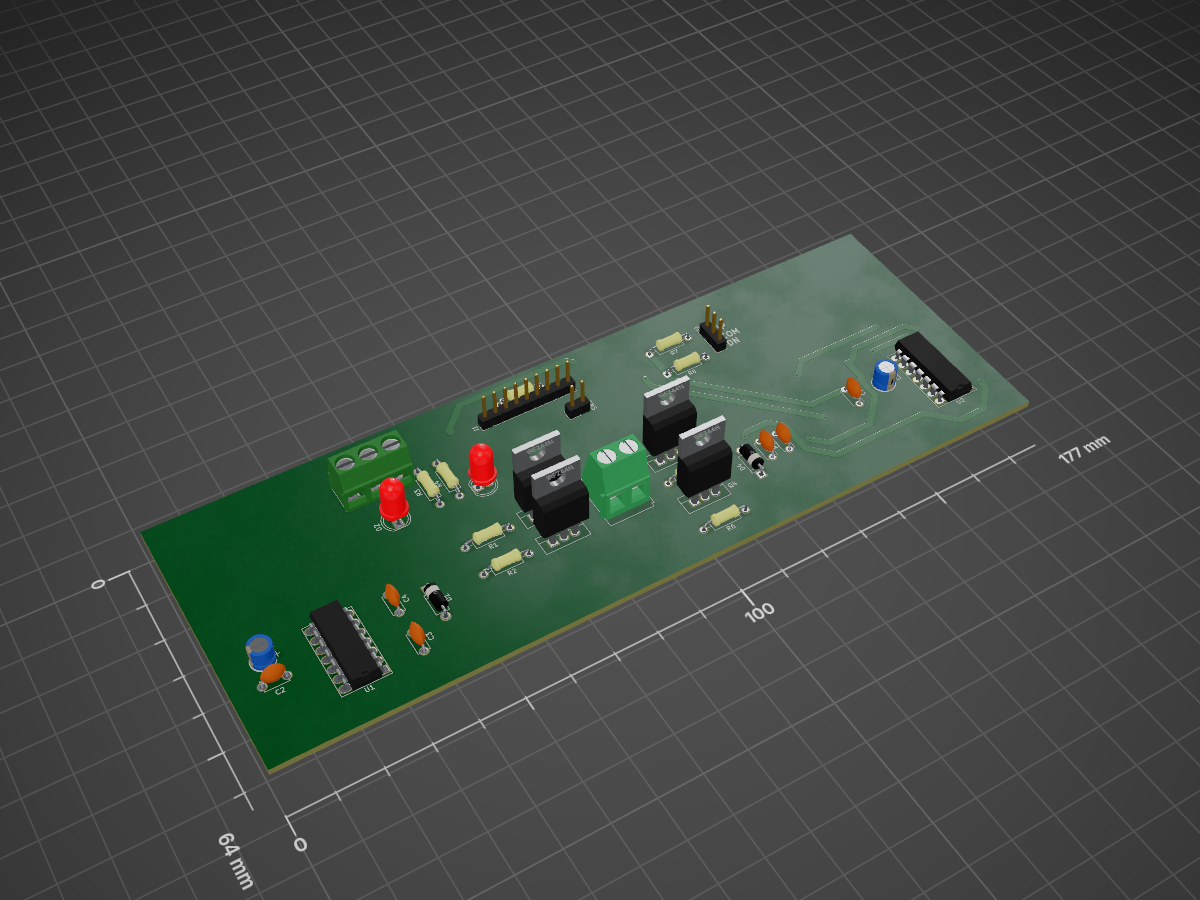
Deltarobot driver is an open-source printed circuit board by ProjInt2, from the ProjInt2/deltarobot repository on GitHub. It is a 2-layer board with 32 parts on 25 nets, routed with 332 tracks and 12 vias.
It is built around the IR2010PBF and IRFZ44N. Its parts include 9 resistors, 8 capacitors, 4 diodes, 4 transistors and 2 ICs. It belongs with the robots and motor control boards of this library.
by Lucas Camargo, Soly Waltrick, and Willian Kenji Nishizawa
This project consists in the development of a driving and control solution for a standard delta robot. It does not concern the development of the robot itself, or its actuators. It focuses on driving the actuators, control mechanisms, and required transducers (sensors).
The deliverables are organized in the following directories:
TODO: insert backref link to post
| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | 0R | Resistors_ThroughHole:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R1, R2, R5, R6 |
| 4 | IRFZ44N | TO_SOT_Packages_THT:TO-220-3_Vertical | Q1, Q2, Q3, Q4 |
| 3 | 10k | Resistors_ThroughHole:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R7, R8, R9 |
| 2 | .1uF | Capacitors_ThroughHole:C_Disc_D5.0mm_W2.5mm_P5.00mm | C2, C7 |
| 2 | .47uF | Capacitors_ThroughHole:CP_Radial_D5.0mm_P2.50mm | C1, C8 |
| 2 | 100u | Capacitors_ThroughHole:C_Disc_D5.0mm_W2.5mm_P5.00mm | C4, C5 |
| 2 | 2.2u | Capacitors_ThroughHole:C_Disc_D5.0mm_W2.5mm_P5.00mm | C3, C6 |
| 2 | D | Diodes_ThroughHole:D_A-405_P7.62mm_Horizontal | D1, D4 |
| 2 | IR2010 | Housings_DIP:DIP-14_W7.62mm_Socket_LongPads | U1, U2 |
| 2 | R | Resistors_ThroughHole:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R3, R4 |
| 1 | CONN_PWR | Terminal_Blocks:TerminalBlock_bornier-3_P5.08mm | J2 |
| 1 | CONN_SIG | Pin_Headers:Pin_Header_Straight_1x09_Pitch2.54mm | J1 |
| 1 | LED_vcc | LEDs:LED_D5.0mm | D2 |
| 1 | LED_vdd | LEDs:LED_D5.0mm | D3 |
| 1 | Motor_DC | Terminal_Blocks:TerminalBlock_Altech_AK300-2_P5.00mm | M1 |
| 1 | Rotary_Encoder | Pin_Headers:Pin_Header_Straight_1x03_Pitch2.54mm | SW1 |
| 1 | SW_STOP | Pin_Headers:Pin_Header_Straight_1x02_Pitch2.54mm | SW2 |


maanavkoladia/BoostConverter
This project is a high-efficiency 24V to 48V boost converter designed for an electric bike motor. Built using a TI F280049C microcontroller, the system delivers precise control and optimized power conversion for…


NikodemBartnik/Mini-Mars-Rover
Educational robotic platform made to look like a mini mars rover


NikodemBartnik/Pico-Watering-System
Raspberry Pi Pico based automated watering system for your garden

BenjamimKrug/robo_humanoide
Repositorio para arquivos gerais necessários para o desenvolvimento do Robô humanoide

2technology/g-board
ESP32 IoT Home automation PCB - 1 * 12V relay, 4 * input button connector with HW debounce, 4 * ws2812b output
32 parts, built around the IR2010PBF and IRFZ44N. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the ProjInt2/deltarobot repository on GitHub, at the commit this page was made from: the board is hw/deltarobot-driver/deltarobot-driver.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask ProjInt2 before reusing the design.