

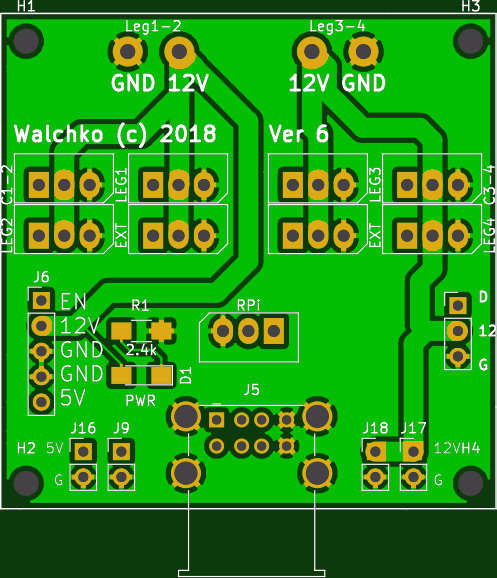
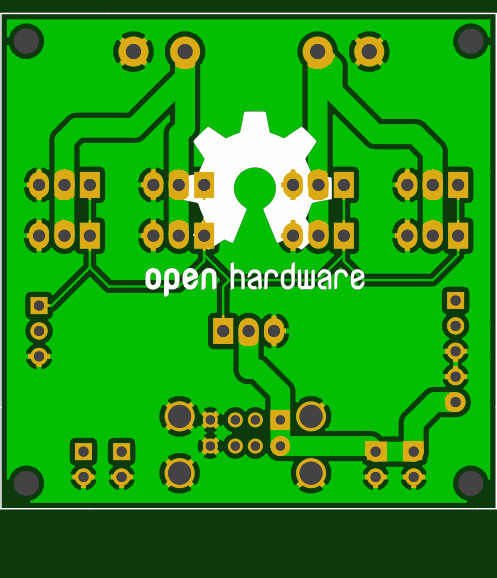
2 layers49.5 × 49.5 mm

Robot is an open-source printed circuit board by MultipedRobotics, from the MultipedRobotics/quadruped-AX12 repository on GitHub, published under the MIT licence. It is a 2-layer board of 42.5 × 15.2 mm with 10 parts on 10 nets, routed with 121 tracks and 17 vias.
It is built around the BSS138. Its parts include 5 connectors, 2 resistors, 2 ICs and 1 transistor. It belongs with the robots and motor control boards of this library.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 2 | 10k | Resistors_SMD:R_1206_HandSoldering | R2, R3 |
| 2 | i2c | Pin_Headers:Pin_Header_Straight_1x04_Pitch2.54mm | J1, J4 |
| 1 | 12V/Data | Connectors_Molex:Molex_SPOX-5267_22-03-5035_03x2.54mm_Straight | J3 |
| 1 | 5V/Data | Connectors_Molex:Molex_SPOX-5267_22-03-5035_03x2.54mm_Straight | J6 |
| 1 | 74L-125 | TO_SOT_Packages_SMD:SOT-23-5_HandSoldering | U2 |
| 1 | 74L-126 | TO_SOT_Packages_SMD:SOT-23-5_HandSoldering | U3 |
| 1 | BSS138 | TO_SOT_Packages_SMD:SOT-23 | Q1 |
| 1 | Pi Header | Pin_Headers:Pin_Header_Straight_2x05_Pitch2.54mm | J2 |

StuckAtPrototype/Racer
These are structured into their own files. I could have used submodules, but decided against it.

willem-pennings/balancing-cube
A cube that balances itself in a corner or edge using reaction wheels

abhishek-kakkar/BeagleLogic
A Software Suite that implements a logic analyzer with the PRU on the BeagleBone / BeagleBone Black.


lachlanA/eagle-to-kicad
Eagle SCH/LIB to KiCad SCH/LIB ULP conversion script

No0ne/ps2x2pico
USB keyboard/mouse to PS/2 interface converter using a Raspberry Pi Pico

StuckAtPrototype/AirCube
Works standalone out of the box. Pairs with Home Assistant in minutes. Other platforms are supported through community-contributed extensions.

It measures 42.5 × 15.2 mm and has 2 copper layers, 1.6 mm thick.
10 parts, built around the BSS138. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the MultipedRobotics/quadruped-AX12 repository on GitHub, at the commit this page was made from: the board is electrical/rpi/robot.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).