
2 layers51.8 × 41.7 mm
PayloadPrototypeBoard
Case-Rocket-Team/PayloadPrototypeBoard2021
Prototype Payload Board for the 2021 ESRA Payload using Parafoil Guidance. KiCad Project
84 parts2

 Mew463/Project-l0ckcr4ck3r66
I've always wanted to build a robot that actually decodes locks while maintaining a cool desk toy vibe! I am quite happy with the user-oriented design and doubles as a nice fidgety-toy-thing to play with.
L0ckcr4ck3r is an open-source printed circuit board by Mew463, from the Mew463/Project-l0ckcr4ck3r repository on GitHub, published under the MIT licence. It is a 2-layer board of 53.3 × 81.3 mm with 19 parts on 39 nets, routed with 87 tracks and 12 vias.
It is built around the TMC2208SILENTSTEPSTICK and LD1085V50. Its parts include 6 ICs, 2 capacitors, 1 diode and 1 connector. It belongs with the AVR (ATmega, ATtiny) boards of this library.


This robot is a true creation of the idea many years ago brought on by Samy Kamkar's robot that "utilized" his algorithm for cracking combination locks. Samy Kamkar never demonstrated his robot actually performing the algorithm, though he implied multiple times that it does do it.
I've always wanted to build a robot that actually decodes locks while maintaining a cool desk toy vibe! I am quite happy with the user-oriented design and doubles as a nice fidgety-toy-thing to play with.
This robot is able to decode the majority of locks that don't have much wear and tear on it and usually takes ~40 seconds.

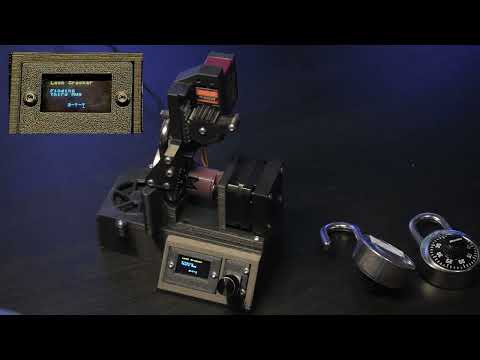
First number: Turn dial Counter Clockwise while incrementally adding more and more force to the shackle until it suddenly stops. Round down to the nearest whole number and add 14. That is the first number in the combo.
Third number:
Second number: Guess and check until the lock opens, though it follows a pattern of being (FirstNum % 4) + a multiple of 4.
I found that this video really helped me when trying to program the algorithm.
A TMC2208 Trinamic driver drives a stepper motor & magnetic encoder. These components turn the dial and can detect when the stepper motor stalls.

With this method, any desired number can easily be input into the lock and the lock can be "felt" for it's geometries.

Meanwhile a servo powers a rack and pinion gear which allows precise control of the shackle.

Since I modified the servo with an analog Feedback wire, we can pull up on the shackle and use this to check whether the lock has been opened or not.

Custom PCB powered by a 12V USB C input. An Arduino Nano is the brain and a 5V regulator gives the neccessary voltage for the servo.


KiCAD files are included in the github.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 2 | 10uF | Capacitor_THT:CP_Radial_D6.3mm_P2.50mm | C1, C2 |
| 1 | 1N4002 | Diode_THT:D_DO-41_SOD81_P7.62mm_Horizontal | D1 |
| 1 | AS5600 | Connector_PinSocket_2.54mm:PinSocket_1x04_P2.54mm_Vertical | U5 |
| 1 | Arduino_Nano_v3.x | Module:Arduino_Nano | A1 |
| 1 | Encoder | Connector_PinSocket_2.54mm:PinSocket_1x05_P2.54mm_Vertical | U3 |
| 1 | Fan | Connector_PinSocket_2.54mm:PinSocket_1x02_P2.54mm_Vertical | M2 |
| 1 | LD1085V50 | LD1085:TO220V | U4 |
| 1 | Motor_Servo | Connector_PinSocket_2.54mm:PinSocket_1x03_P2.54mm_Vertical | M3 |
| 1 | OLED Display | Connector_PinSocket_2.54mm:PinSocket_1x04_P2.54mm_Vertical | U6 |
| 1 | PowerIn | Library:PowerPads | U1 |
| 1 | Servo Feedback | Connector_PinSocket_2.54mm:PinSocket_1x01_P2.54mm_Vertical | J1 |
| 1 | Spare | Connector_PinSocket_2.54mm:PinSocket_1x03_P2.54mm_Vertical | M4 |
| 1 | Stepper_Motor_bipolar | Connector_PinSocket_2.54mm:PinSocket_1x04_P2.54mm_Vertical | M1 |
| 1 | TMC2208_SILENTSTEPSTICK | TMC2208_SILENTSTEPSTICK:MODULE_TMC2208_SILENTSTEPSTICK | U2 |
The 15 most common of 19 parts.
Case-Rocket-Team/PayloadPrototypeBoard2021
Prototype Payload Board for the 2021 ESRA Payload using Parafoil Guidance. KiCad Project


ibsal/LERT
LERT will launch humans to space in 2 months, please give me 10 trillion dollars pls

sirihallqvist/PlantBreakoutBoard
Run the following commands to update and download dependencies.

Starman3787/flightSimBuildB738
Project to build parts of a flight simulator for a Boeing 737-800


LesKaribous/Karibous-2024-PAMI
Hardware pour les Petits Automates Mobiles Indépendants de la Coupe de France de Robotique 2024
It measures 53.3 × 81.3 mm and has 2 copper layers, 1.6 mm thick.
19 parts, built around the TMC2208SILENTSTEPSTICK and LD1085V50. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Mew463/Project-l0ckcr4ck3r repository on GitHub, at the commit this page was made from: the board is l0ckcr4ck3r pcb/l0ckcr4ck3r.kicad_pcb and its schematic l0ckcr4ck3r pcb/l0ckcr4ck3r.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).