2 layers54 × 54 mm
Shaker Module DevKit
MRSD-APEXLabs/Shaker-Module
Contains PCB files and simple REST API for controlling PWM.
19 parts
 MRSD-APEXLabs/Shaker-Module
Contains PCB files and simple REST API for controlling PWM.
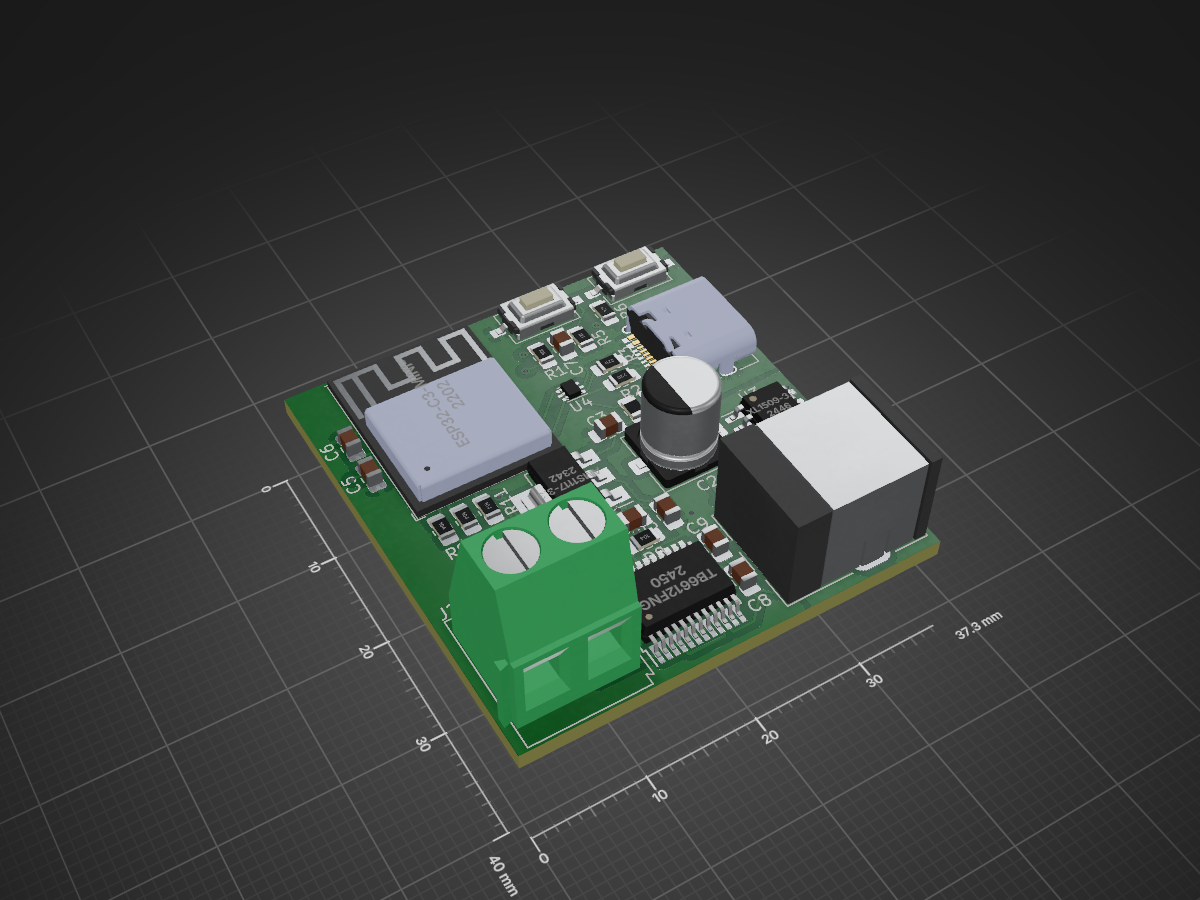
Shaker Module is an open-source printed circuit board by MRSD-APEXLabs, from the MRSD-APEXLabs/Shaker-Module repository on GitHub. It is a 2-layer board of 37.3 × 40 mm with 35 parts on 57 nets, routed with 285 tracks and 26 vias.
It is built around the ESP32-C3-MINI-1, XL1509-3.3 and AMS1117-3.3, with the USBLC6-2P6 and SS32 among its other parts. Its parts include 11 resistors, 10 capacitors, 5 ICs, 3 connectors and 2 switches. It belongs with the ESP32 and RISC-V boards of this library.


This repository contains the code for the REST server running on the Shaker PCB. It also contains two PCBs, one that could not be verified and the one that is used in the project "DevKit".
| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | 100k | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R8, R9, R10, R11 |
| 2 | 0.1uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C8, C10 |
| 2 | 100nF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C6, C7 |
| 2 | 10uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C5, C9 |
| 2 | 120R | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R5, R6 |
| 2 | 2.2uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C3, C4 |
| 2 | 22 | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R2, R3 |
| 1 | 0 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R7 |
| 1 | 10K | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R1 |
| 1 | 2A | Fuse:Fuse_1206_3216Metric_Pad1.42x1.75mm_HandSolder | F1 |
| 1 | 330uf | Capacitor_SMD:CP_Elec_6.3x7.7 | C2 |
| 1 | 470uf | Capacitor_SMD:CP_Elec_6.3x7.7 | C1 |
| 1 | 47uh / 2A | Inductor_SMD:L_Bourns_SRP7028A_7.3x6.6mm | L1 |
| 1 | 5.1k | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R4 |
| 1 | 500m | Fuse:Fuse_0805_2012Metric_Pad1.15x1.40mm_HandSolder | F2 |
| 1 | AMS1117-3.3 | Package_TO_SOT_SMD:SOT-223-3_TabPin2 | U5 |
| 1 | BOOT | Button_Switch_SMD:SW_Tactile_SPST_NO_Straight_CK_PTS636Sx25SMTRLFS | SW2 |
| 1 | Barrel_Jack_MountingPin | Connector_BarrelJack:BarrelJack_CUI_PJ-063AH_Horizontal | J1 |
| 1 | ESP32-C3-MINI-1 | EspressIf:ESP32-C3-MINI-1 | U1 |
| 1 | RST | Button_Switch_SMD:SW_Tactile_SPST_NO_Straight_CK_PTS636Sx25SMTRLFS | SW1 |
| 1 | SS32 | Diode_SMD:D_SMA | D1 |
| 1 | Screw_Terminal_01x02 | TerminalBlock:TerminalBlock_Altech_AK300-2_P5.00mm | J2 |
| 1 | TB6612FNG | Package_SO:SSOP-24_5.3x8.2mm_P0.65mm | U2 |
| 1 | USBLC6-2P6 | Package_TO_SOT_SMD:SOT-666 | U4 |
| 1 | USB_C_Plug_USB2.0 | Connector_USB:USB_C_Receptacle_HRO_TYPE-C-31-M-12 | P2 |
| 1 | XL1509-3.3 | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U3 |
MRSD-APEXLabs/Shaker-Module
Contains PCB files and simple REST API for controlling PWM.

ggarciabaez/titanrio
A RoboRIO-Inspired Expansion board for Robotics. Mostly for funsies + learning.


mekanii/ESU
Below is the output scope from the sense circuit, where the pad resistance values are 5Ω, 200Ω, 1kΩ, and High Impedance.


evezor/tobor_v00
Tobor (robot spelled backwards), was built to be the most versatile open-source robotics system

MarkJB/ESP32_Plotter_Controller
An ESP32/TMC2130 based 2 axis controller designed for pen plotters

It measures 37.3 × 40 mm and has 2 copper layers, 1.6 mm thick.
35 parts, built around the ESP32-C3-MINI-1, XL1509-3.3, AMS1117-3.3 and USBLC6-2P6. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the MRSD-APEXLabs/Shaker-Module repository on GitHub, at the commit this page was made from: the board is pcb_files/Shaker Module/Shaker Module.kicad_pcb and its schematic pcb_files/Shaker Module DevKit/Shaker Module DevKit.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask MRSD-APEXLabs before reusing the design.