2 layers50.8 × 47.2 mm
Testmoteur
Lazorme/Ludz-le-chat
The Lidar and motor drivers are in drvLIDAR and drvMotor, respectively.
41 parts

 Lazorme/Ludz-le-chat
The Lidar and motor drivers are in drvLIDAR and drvMotor, respectively.
Kyttiludzinator is an open-source printed circuit board by Lazorme, from the Lazorme/Ludz-le-chat repository on GitHub. It is a 4-layer board of 90 × 70 mm with 116 parts on 109 nets, routed with 624 tracks and 116 vias.
It is built around the STM32G070RBT6, ZXBM5210-S and MP1475DJ-LF-P, with the IIM-20670 and MIC5317-3.3YM5-TR among its other parts. Its parts include 33 capacitors, 27 resistors, 14 diodes, 10 connectors and 7 ICs. It belongs with the STM32 boards of this library.


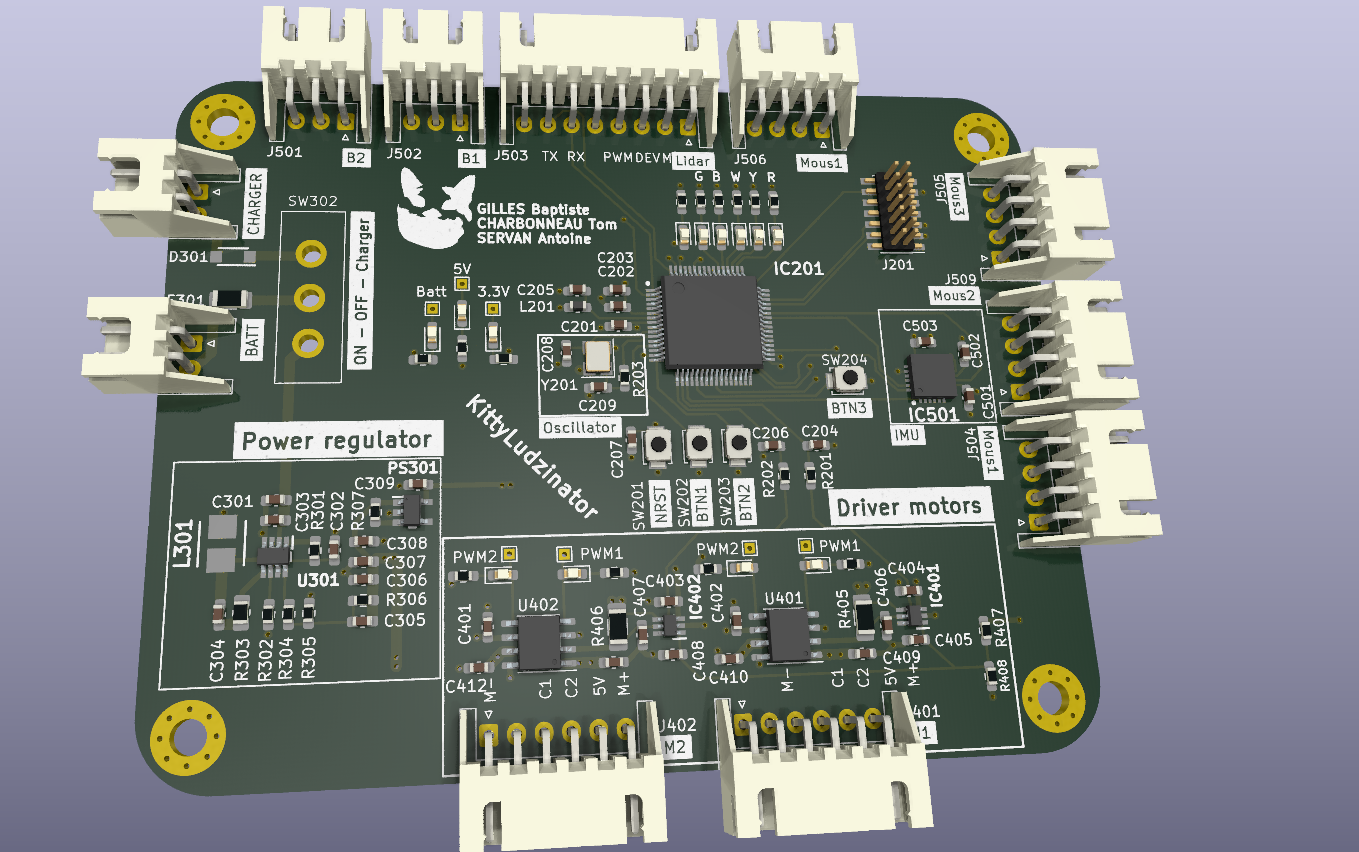
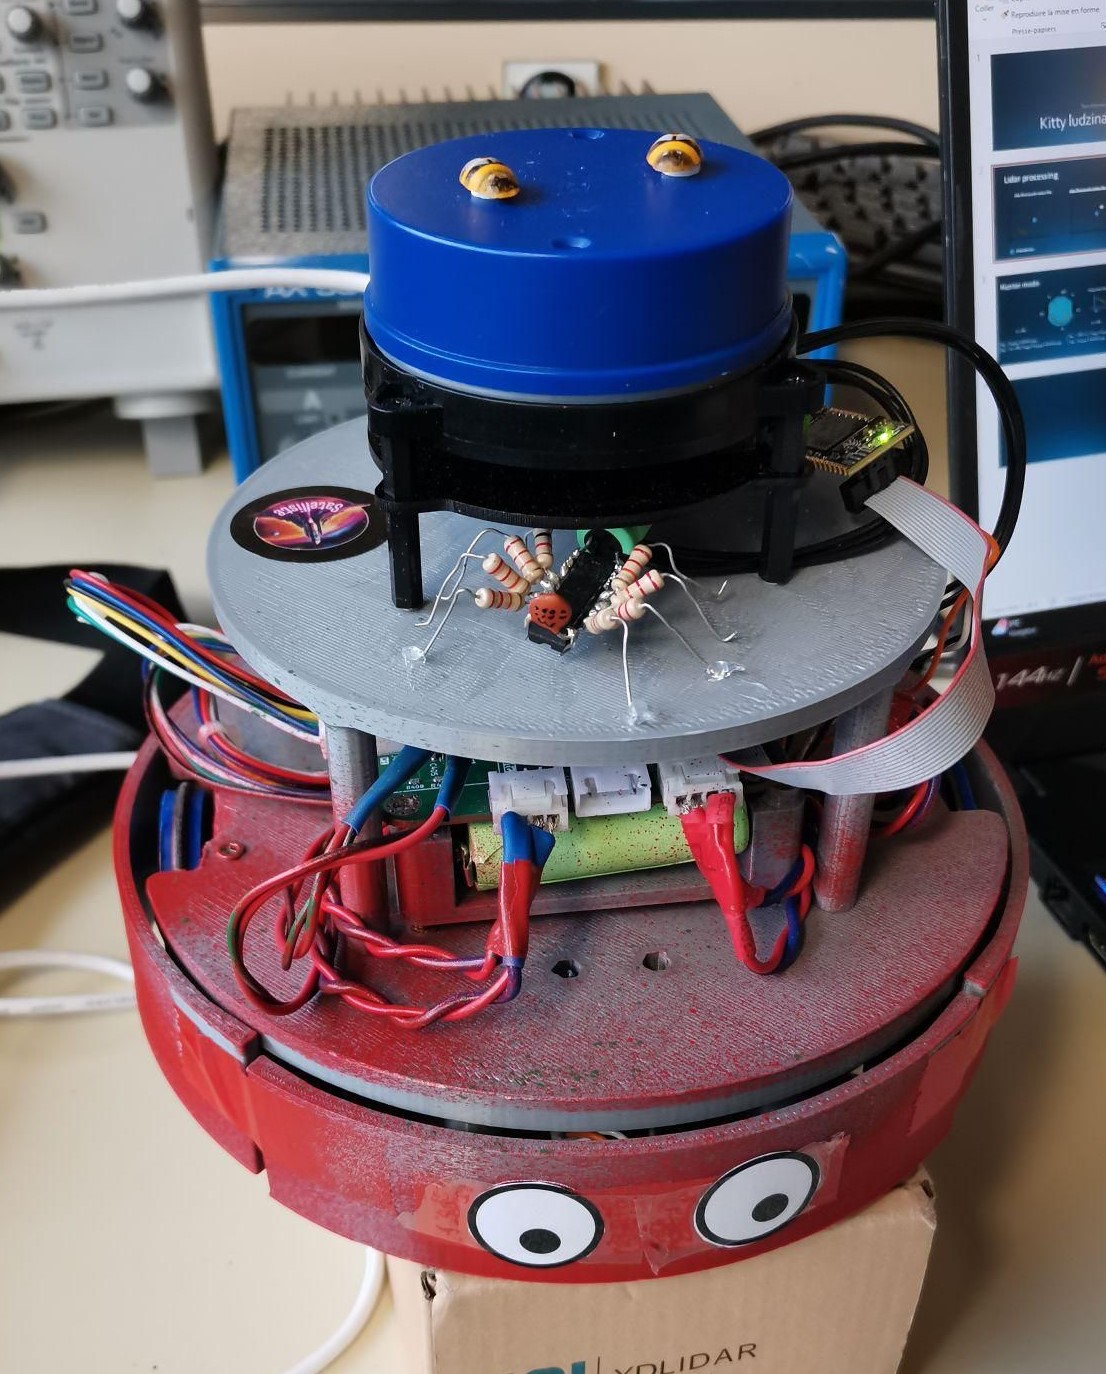
The KittyLudzinator Project is focused on developing a playful autonomous robot equipped with an array of sensors including IMUs, Lidar, and motion detectors. It engages in a game of TAG, showcasing its ability to navigate and interact within its environment.
CHARBONENAU TOM
SERVAN Antoine
GILLES Baptiste
Refer to the PCB directory for detailed component tables , PCB info and setup documentation. The software setup is managed through STM32CubeMX configurations (Ludz_le_chat.ioc),
The source code is located in Code_Chat_V4.0 with core functions in Core.
The Lidar and motor drivers are in drv_LIDAR and drv_Motor, respectively.
Strategies for robot behavior in different modes are implemented as follows:
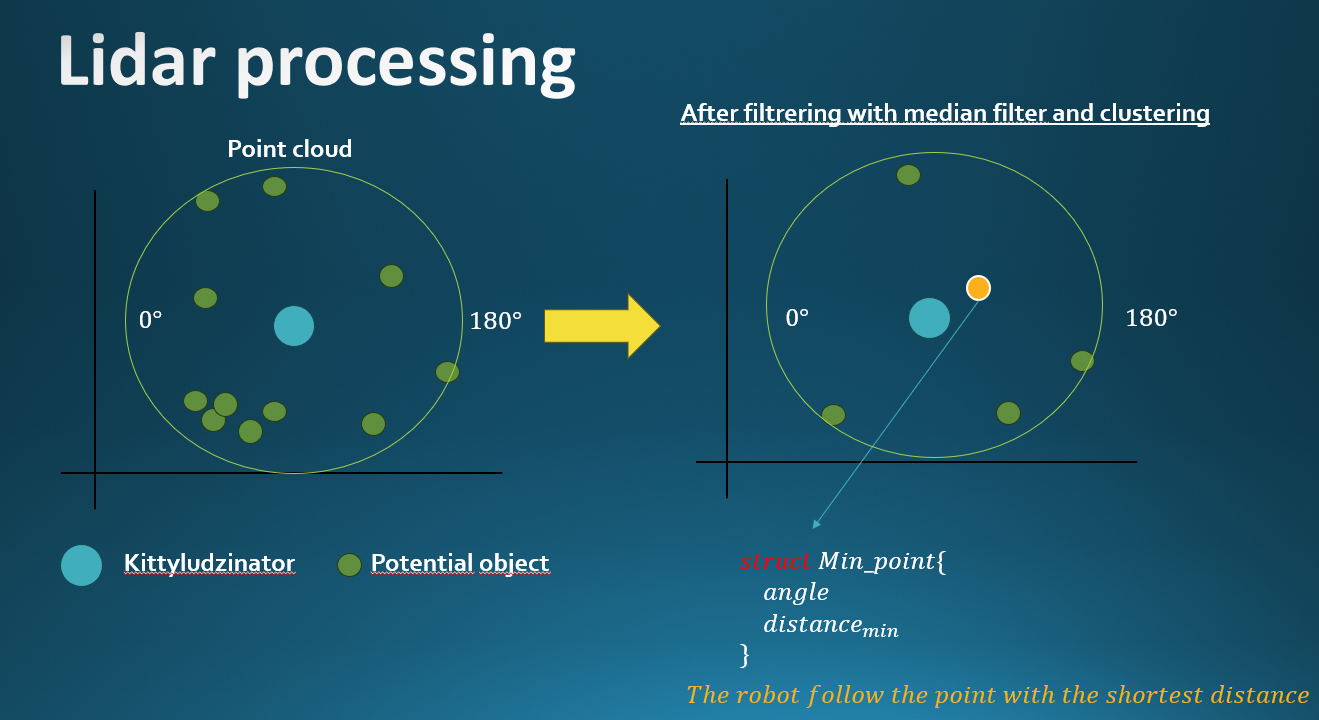
Processes Lidar sensor data to track objects. Details are in the script LIDAR_Receive_clusters.py.
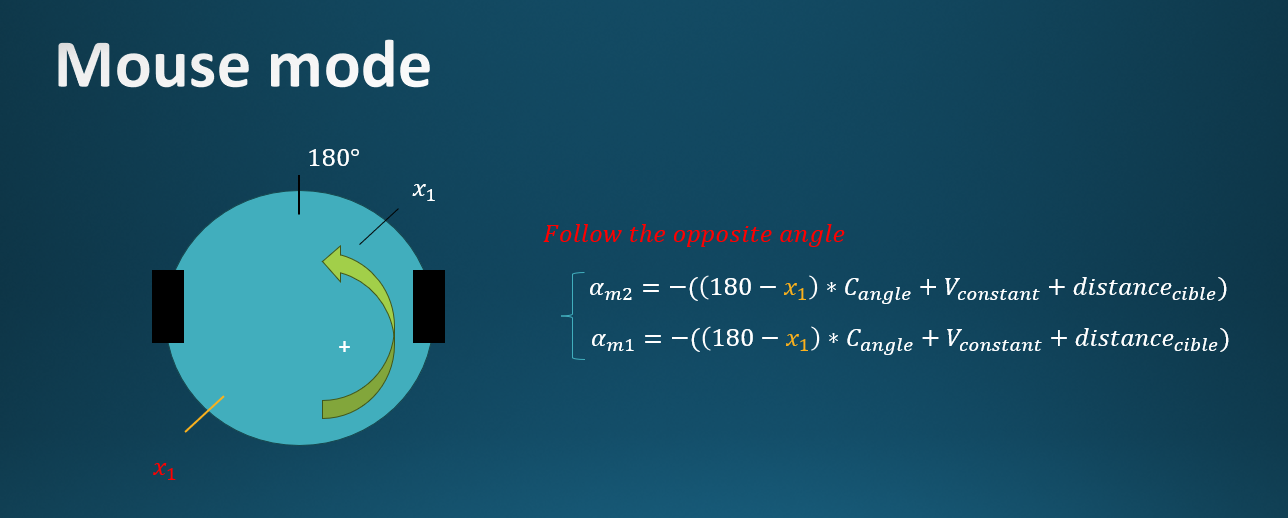
The robot moves away from the tagger, inversely proportional to the angle of the tagger's approach.
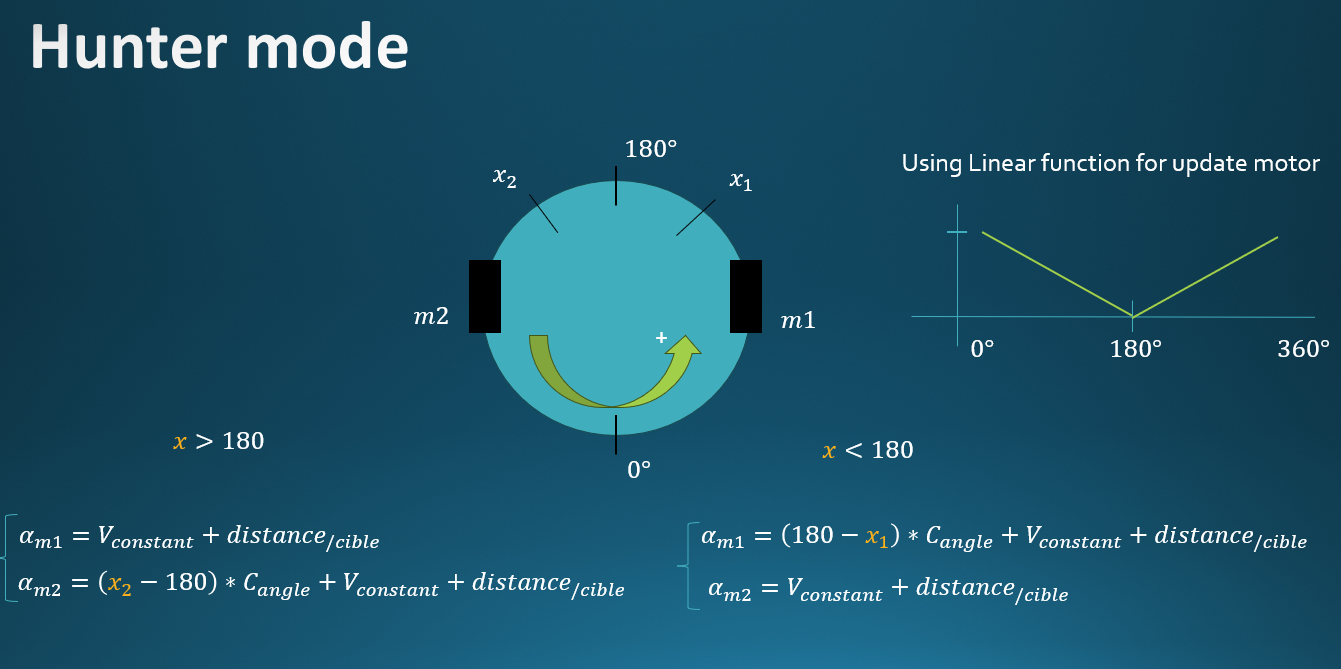
The 'it' robot aggressively seeks the nearest robot, adjusting its motor speed using a linear function.
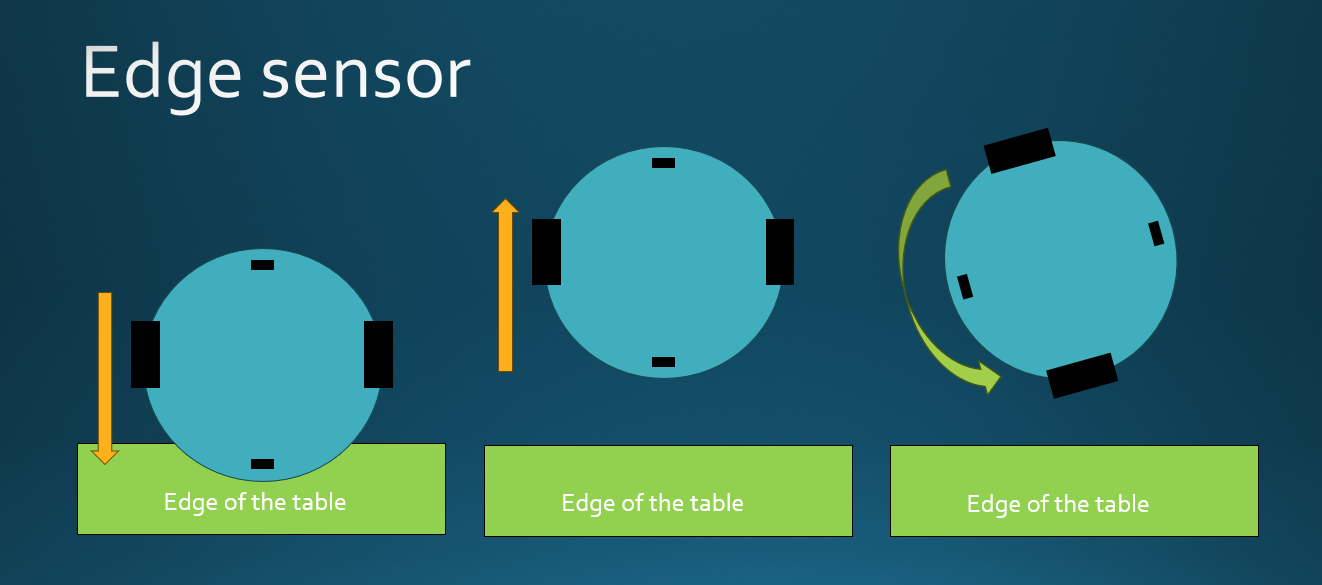
Edge detection prevents the robot from falling off ledges.
IIMU :This file includes instructions for operating the IIM2070 device, as detailed in the script code 'IIM2070_SPI
The project is under the MIT License.
Thanks to contributors and the open-source community.
Contact the maintainer at . tom.charbonneau2001@gmail.com | baptiste.gilles01@gmail.com | servan.antoine@gmail.com
| Qty | Value | Footprint | References |
|---|---|---|---|
| 10 | 100nF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C201, C202, C205, C207, C403, C404, C405, C408, C502, C503 |
| 8 | 1uF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C308, C309, C401, C402, C409, C410, C411, C412 |
| 8 | RED | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D202, D401, D402, D403, D404, D404, D404, D404 |
| 6 | 3.3k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R204, R205, R206, R207, R208, R209 |
| 5 | 100k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R301, R302, R307, R407, R408 |
| 4 | 390R | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R401, R402, R403, R404 |
| 4 | Conn_01x04 | Connector_JST:JST_XH_S4B-XH-A_1x04_P2.50mm_Horizontal | J504, J506, J509, locked |
| 4 | SW_Push | Button_Switch_SMD:SW_SPST_B3U-1000P | SW201, SW202, SW203, SW204 |
| 3 | 0.1uF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C302, C303, C304 |
| 3 | 22uF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C301, C306, C307 |
| 3 | 390 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R404, R404, R404 |
| 2 | 0.015 | Resistor_SMD:R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R405, R406 |
| 2 | 10k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R201, R202 |
| 2 | 10pF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C208, C209 |
| 2 | 10uF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C406, C407 |
| 2 | 5pF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C204, C206 |
| 2 | Conn_01x02 | Connector_JST:JST_XH_S2B-XH-A-1_1x02_P2.50mm_Horizontal | Alim_batterie301, Alim_charger301 |
| 2 | Conn_01x03 | Connector_JST:JST_XH_S3B-XH-A_1x03_P2.50mm_Horizontal | J501, J502 |
| 2 | Conn_01x06 | Connector_JST:JST_XH_S6B-XH-A_1x06_P2.50mm_Horizontal | J401, J402 |
| 2 | NCS199A2RSQT2G | Library:SOT65P210X110-6N | IC401, IC402 |
| 2 | ZXBM5210-S | Package_SO:SOIC-8-1EP_3.9x4.9mm_P1.27mm_EP2.62x3.51mm_ThermalVias | U401, U402 |
| 1 | 1.5KExxA | Library:SODFL3718X108N | D301 |
| 1 | 10R | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R203 |
| 1 | 10nF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C501 |
| 1 | 15pF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C305 |
| 1 | 16MHz | Crystal:Crystal_SMD_3225-4Pin_3.2x2.5mm | Y201 |
| 1 | 16k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R304 |
| 1 | 20 | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R303 |
| 1 | 4.7uF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C203 |
| 1 | 4.7uH | Library:INDPM4141X210N | L301 |
| 1 | 40.2k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R306 |
| 1 | 6uH | Inductor_SMD:L_0603_1608Metric_Pad1.05x0.95mm_HandSolder | L201 |
| 1 | 7.36k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R305 |
| 1 | BLUE | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D204 |
| 1 | Conn_01x08 | Connector_JST:JST_XH_S8B-XH-A_1x08_P2.50mm_Horizontal | J503 |
| 1 | Conn_02x07_Odd_Even | Connector_PinHeader_1.27mm:PinHeader_2x07_P1.27mm_Vertical_SMD | J201 |
| 1 | GREEN | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D206 |
| 1 | IIM-20670 | Library:IMU | IC501 |
| 1 | LED_ON | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D201 |
| 1 | LOGO | Library:logo_ensea | G*** |
| 1 | LOGO | Library:beluga | G*** |
| 1 | MIC5317-3.3YM5-TR | Library:SOT95P280X145-5N | PS301 |
| 1 | MP1475DJ-LF-P | Library:SOT65P280X100-8N | U301 |
| 1 | MountingHole_3.2mm_M3_Pad_Via | MountingHole:MountingHole_3.2mm_M3_Pad_Via | REFe |
| 1 | Polyfuse | Fuse:Fuse_1206_3216Metric | F301 |
| 1 | STM32G070RBT6 | Library:QFP50P1200X1200X160-64N | IC201 |
| 1 | Switch | Library:Switch-3 | SW302 |
| 1 | WHITE | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D205 |
| 1 | Yellow | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D203 |
The 106 most common of 116 parts.
Lazorme/Ludz-le-chat
The Lidar and motor drivers are in drvLIDAR and drvMotor, respectively.


Artpel1805/Beerator
Le but du projet est de réaliser intégralement un robot capable de se déplacer, de chercher et d’attraper une canette (de bière ? 😶), relever sa couleur, puis de la déposer dans la zone de couleur correspondante.

Groupe-Projet-ESE/BeerRobot
Chelsea COMLAN - Alix HAVRET - Loïcia KOEHL - Quentin SIMON

vito-pp/FlightComputer-SRAD-2026
HW and SW documentation of a Student Researched And Developed (SRAD) flight computer in charge of telemetry for ITBA's rocketry team 2026


ezer-soltani/HellKitty-Autonomous-Robot
Professional firmware and hardware design for an autonomous mobile robot using STM32G431 and FreeRTOS. Features Lidar perception, ToF safety algorithms, and PID motor control.

It measures 90 × 70 mm and has 4 copper layers, 1.6 mm thick.
116 parts, built around the STM32G070RBT6, ZXBM5210-S, MP1475DJ-LF-P and IIM-20670. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Lazorme/Ludz-le-chat repository on GitHub, at the commit this page was made from: the board is PCB/Kyttiludzinator/Kyttiludzinator.kicad_pcb and its schematic PCB/Kyttiludzinator/Charger.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask Lazorme before reusing the design.