2 layers102.4 × 98.6 mm

 ISU-MAVRIC/MAVRIC_Arm1
MAVRIC arm control board and firmware
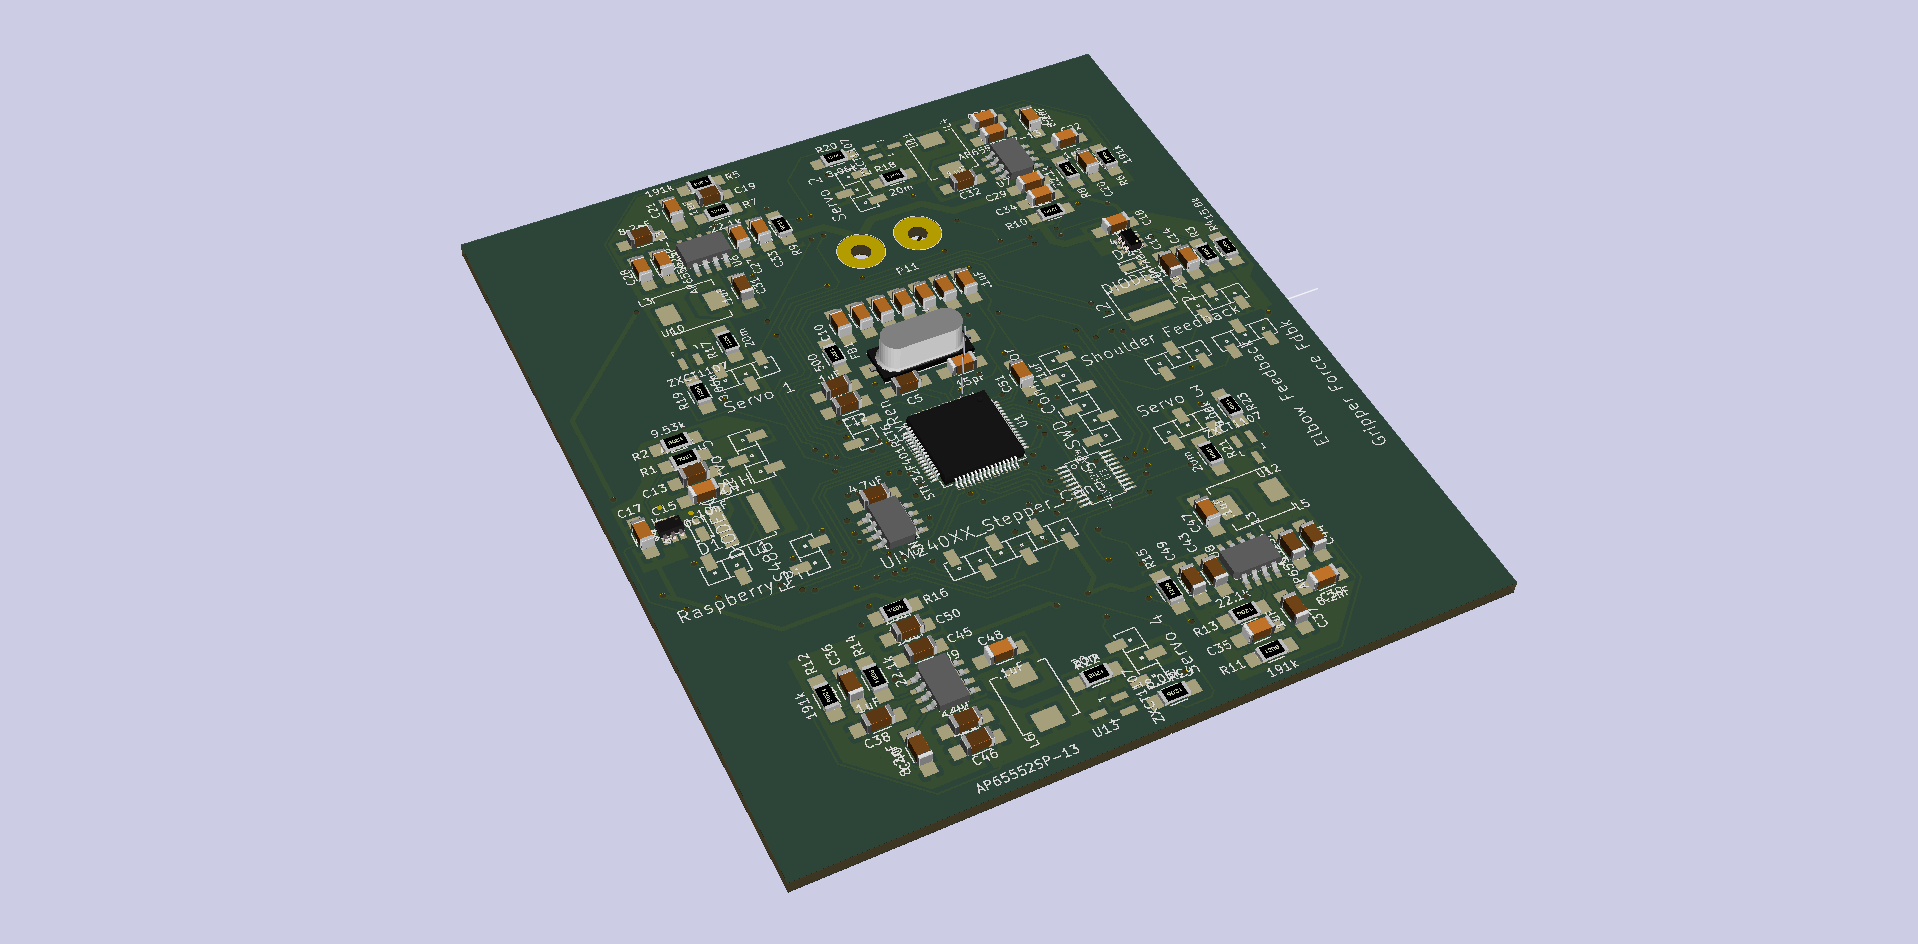
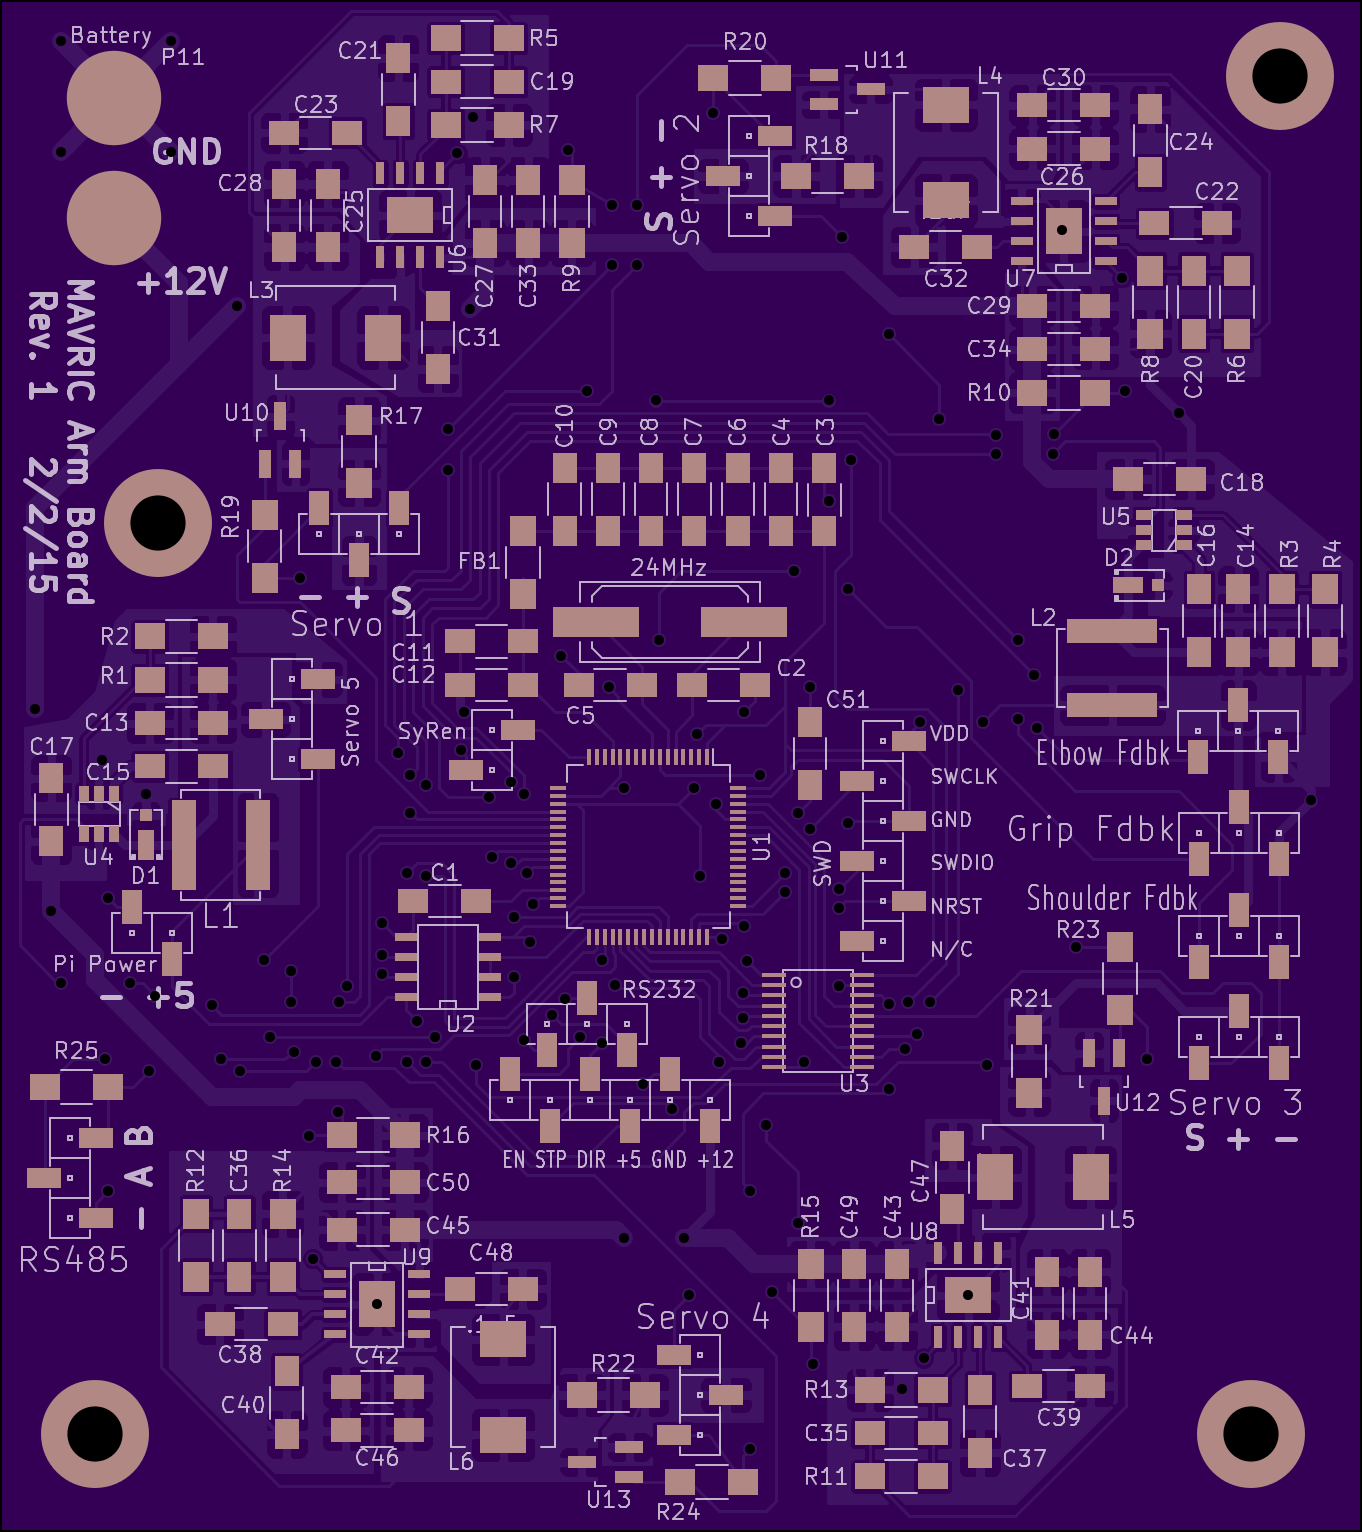
Arm Control Board is an open-source printed circuit board by ISU-MAVRIC, from the ISU-MAVRIC/MAVRIC_Arm repository on GitHub. It is a 2-layer board of 86.4 × 97.2 mm with 118 parts on 103 nets, routed with 1,066 tracks and 154 vias.
It is built around the STM32F401RCT6, 74LVCH244APW and RS485, with the ZXCT1107SA, AOZ1280CI and SN75176BDRG among its other parts. Its parts include 51 capacitors, 25 resistors, 15 connectors, 13 ICs and 6 inductors. It belongs with the STM32 boards of this library.


The MAVRIC Arm consists of a rotating base (stepper motor), 'shoulder' actuator (with feedback), 'elbow' actuator (with feedback), and an end effector. The end effector is modular but at its maximum contains a rotation servo, horizontal servo, vertical servo, and gripping servo. This board interfaces with the MAVRIC main board, receiving control packets and sending back status packets.
Features
| Qty | Value | Footprint | References |
|---|---|---|---|
| 12 | .1uF | Capacitors_SMD:C_1206_HandSoldering | C3, C4, C6, C8, C9, C10, C11, C31, C32, C47, C48, C51 |
| 10 | 10uF | Capacitors_SMD:C_1206_HandSoldering | C13, C14, C27, C29, C33, C34, C43, C45, C49, C50 |
| 8 | 22uF | Capacitors_SMD:C_1206_HandSoldering | C25, C26, C28, C30, C41, C42, C44, C46 |
| 5 | 1uF | Capacitors_SMD:C_1206_HandSoldering | C12, C21, C22, C37, C38 |
| 4 | 100k | Resistors_SMD:R_1206_HandSoldering | R9, R10, R15, R16 |
| 4 | 18pF | Capacitors_SMD:C_1206_HandSoldering | C19, C20, C35, C36 |
| 4 | 191k | Resistors_SMD:R_1206_HandSoldering | R5, R6, R11, R12 |
| 4 | 20m | Resistors_SMD:R_1206_HandSoldering | R17, R18, R21, R22 |
| 4 | 22.1k | Resistors_SMD:R_1206_HandSoldering | R7, R8, R13, R14 |
| 4 | 3.3uH | Inductors_NEOSID:Neosid_Inductor_SM-PIC0612H | L3, L4, L5, L6 |
| 4 | 4.7uF | Capacitors_SMD:C_1206_HandSoldering | C1, C7, C17, C18 |
| 4 | 8.06k | Resistors_SMD:R_1206_HandSoldering | R19, R20, R23, R24 |
| 4 | 8.2nF | Capacitors_SMD:C_1206_HandSoldering | C23, C24, C39, C40 |
| 4 | AP65552SP-13 | SMD_Packages:SOIC-8-N-1EP | U6, U7, U8, U9 |
| 4 | VAL** | MAVRIC_footprints:PlatedMountingHole_3-5mm | MountingHole_3-5mm, MountingHole_3-5mm, MountingHole_3-5mm, MountingHole_3-5mm |
| 4 | ZXCT1107 | Housings_SOT-23_SOT-143_TSOT-6:SOT23_Transistor_Handsoldering_RevB_14Mar2014 | U10, U11, U12, U13 |
| 2 | 10nF | Capacitors_SMD:C_1206_HandSoldering | C15, C16 |
| 2 | 15pF | Capacitors_SMD:C_1206_HandSoldering | C2, C5 |
| 2 | 2.2uH | MAVRIC_footprints:Yuden_SMD_Power_Inductor_6060 | L1, L2 |
| 2 | 49.9k | Resistors_SMD:R_1206_HandSoldering | R1, R3 |
| 2 | AOZ1280CI | SMD_Packages:SOT-23-6 | U4, U5 |
| 2 | DIODESCH | MAVRIC_footprints:Diode_MicroSMP | D1, D2 |
| 1 | 100 | Resistors_SMD:R_1206_HandSoldering | R25 |
| 1 | 15.8k | Resistors_SMD:R_1206_HandSoldering | R4 |
| 1 | 24MHz | Crystals_Oscillators_SMD:Q_49U3HMS | X1 |
| 1 | 50O | Resistors_SMD:R_1206_HandSoldering | FB1 |
| 1 | 74LVCH244APW | MAVRIC_footprints:AB2_TSSOP20 | U3 |
| 1 | 9.53k | Resistors_SMD:R_1206_HandSoldering | R2 |
| 1 | Battery | MAVRIC_footprints:SolderWirePad_2x_2-5mmDrill | P11 |
| 1 | Elbow Fdbk | MAVRIC_footprints:1x3_SMD_header | P5 |
| 1 | Grip Fdbk | MAVRIC_footprints:1x3_SMD_header | P14 |
| 1 | Pi Power | MAVRIC_footprints:1x2_SMD_header | P13 |
| 1 | RS232 | MAVRIC_footprints:1x3_SMD_header | P15 |
| 1 | RS485 | MAVRIC_footprints:1x3_SMD_header | P7 |
| 1 | SN75176BDR | SMD_Packages:SOIC-8-W | U2 |
| 1 | STM32F401RCT6 | Housings_QFP:LQFP-64_10x10mm_Pitch0.5mm | U1 |
| 1 | SWD | MAVRIC_footprints:1x6_SMD_header | P8 |
| 1 | Servo 1 | MAVRIC_footprints:1x3_SMD_header | P1 |
| 1 | Servo 2 | MAVRIC_footprints:1x3_SMD_header | P3 |
| 1 | Servo 3 | MAVRIC_footprints:1x3_SMD_header | P4 |
| 1 | Servo 4 | MAVRIC_footprints:1x3_SMD_header | P6 |
| 1 | Servo 5 | MAVRIC_footprints:1x3_SMD_header | P9 |
| 1 | Shoulder Fdbk | MAVRIC_footprints:1x3_SMD_header | P2 |
| 1 | SyRen | MAVRIC_footprints:1x2_SMD_header | P12 |
| 1 | UIM240XX_Stepper_Conn | MAVRIC_footprints:1x6_SMD_header | P10 |

zhbi98/ODriveX
【无刷电机FOC驱动器】双通道 FOC 无刷电机驱动套件,最高电压 60V 单通道电流可达 100A,可以驱动 1.2kW 以内 BLDC 或 PMSM(有中文注释)。

tomrodinger/servomotor
Open-source NEMA-17 integrated servomotor (motor + closed-loop driver + controller + encoder). RS-485, Python/Arduino libraries, MCP server for AI control. Hardware, firmware and software.

zhbi98/Motor42
【小型 42mm 伺服电机】支持 RS485 和 CAN 协议的闭环功能的步进电机,支持功率和通信级联(节点串联连接),适用于 3D 打印机,舵机,小型机械臂

jakepoz/jpbms
JPBms is a simple BMS for solar charging and balancing a 3-cell lithium ion battery.


It measures 86.4 × 97.2 mm and has 2 copper layers, 1.6 mm thick.
118 parts, built around the STM32F401RCT6, 74LVCH244APW, RS485 and ZXCT1107SA. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the ISU-MAVRIC/MAVRIC_Arm repository on GitHub, at the commit this page was made from: the board is Hardware/Arm Control Board/Arm Control Board.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask ISU-MAVRIC before reusing the design.