2 layers
Display arm101
Gordon-coder/Robotic-Arm-Fallen-2026
Robotic Arm project for Hack Club's Fallen Event 2026
31 parts

 Gordon-coder/Robotic-Arm-Fallen-2026
Robotic Arm project for Hack Club's Fallen Event 2026
Robotic Arm PCB MAIN is an open-source printed circuit board by Gordon-coder, from the Gordon-coder/Robotic-Arm-Fallen-2026 repository on GitHub. It is a 2-layer board of 60 × 55 mm with 36 parts on 62 nets, routed with 160 tracks and 16 vias.
It is built around the ESP32-WROOM-32, PCA9685PW and AMS1117-3.3. Its parts include 16 resistors, 11 connectors, 3 ICs, 2 capacitors and 2 diodes. It belongs with the ESP32 boards of this library.


This is the github repo for the Robotic Arm Project in Hack Club's Fallen 2026.
We have decided to make seperate pcbs for the different parts of the robotic arm to increaase modularity and speed up development. the modules are connected either through a uart line or the ESP-NOW protocol.
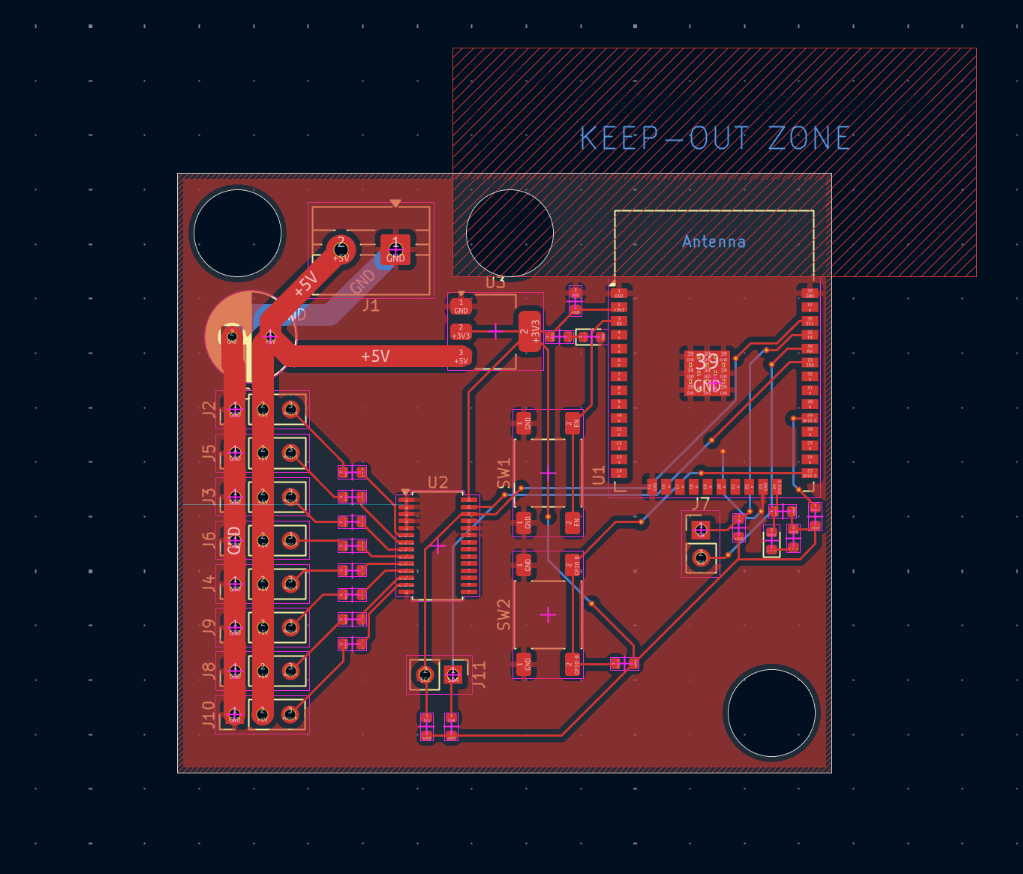 PCB for the main arm
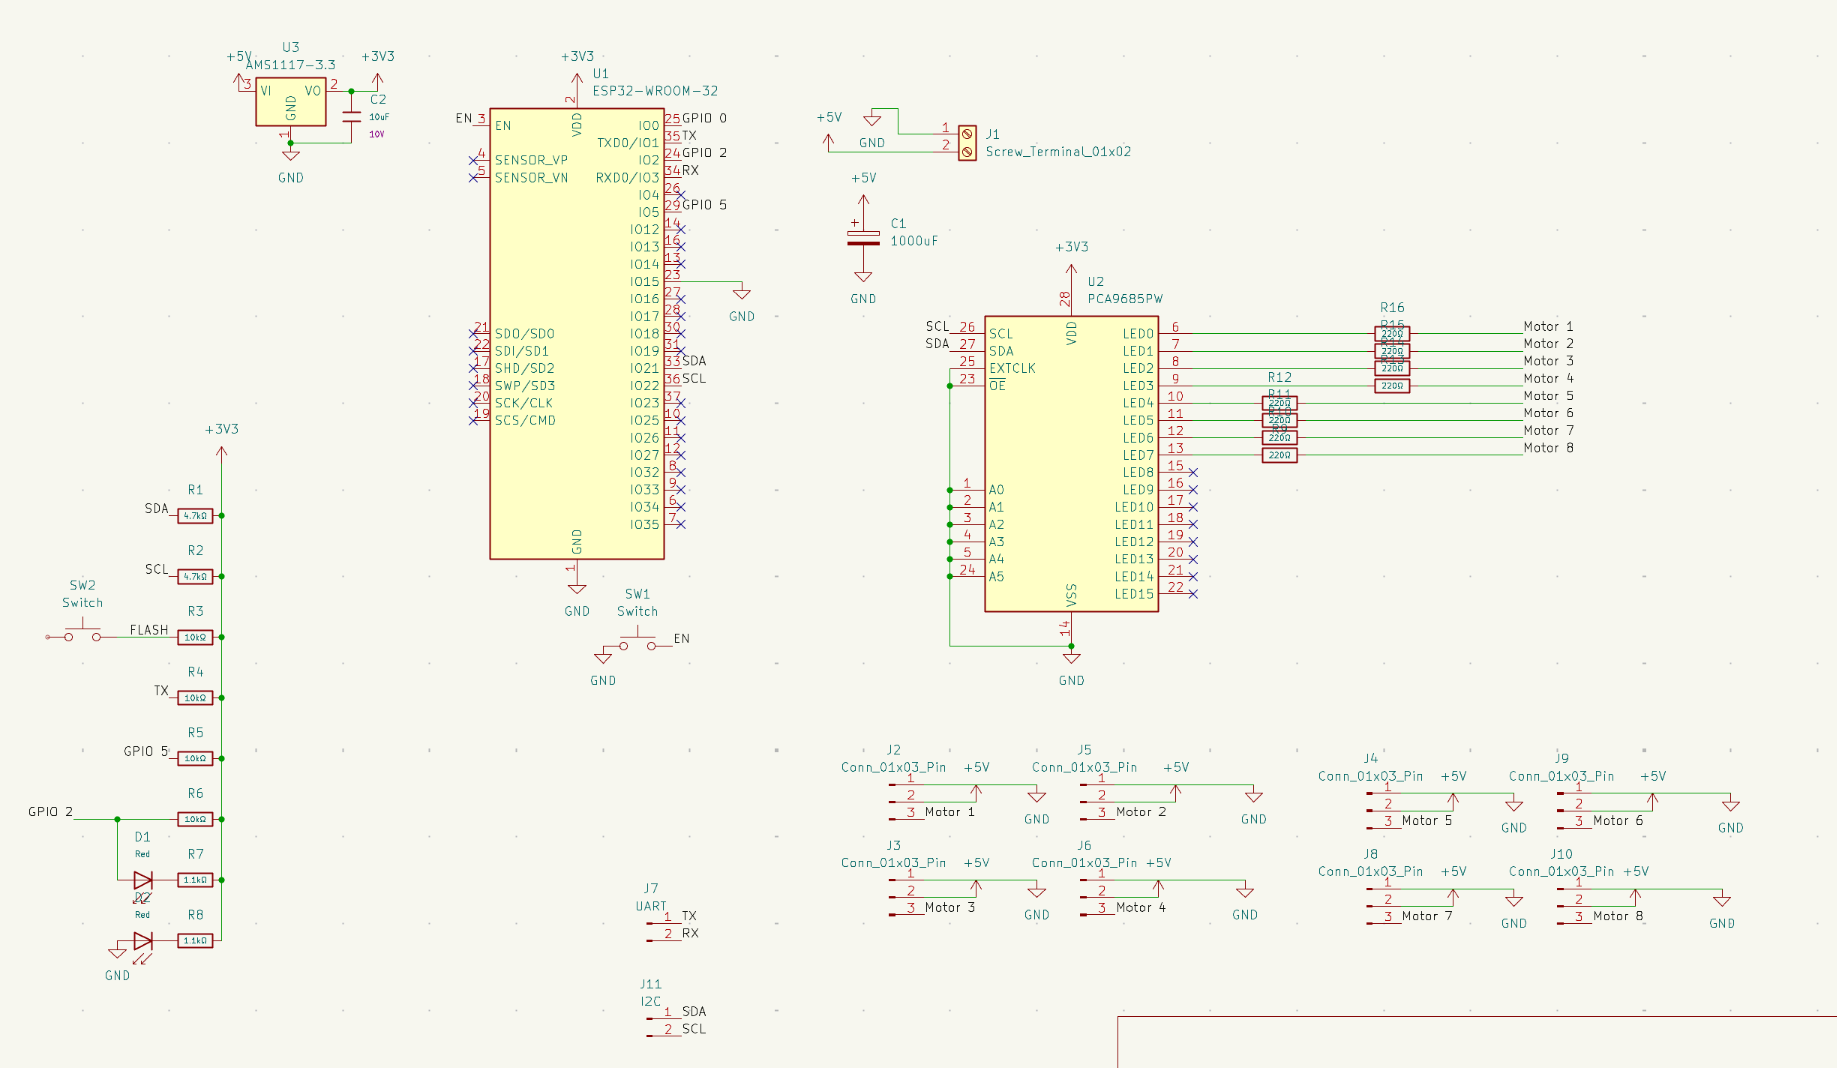 Schematic for the main arm
| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | 220Ω | PCM_JLCPCB:R_0603 | R9, R10, R11, R12, R13, R14, R15, R16 |
| 8 | Conn_01x03_Pin | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J2, J3, J4, J5, J6, J8, J9, J10 |
| 4 | 10kΩ | PCM_JLCPCB:R_0603 | R3, R4, R5, R6 |
| 2 | 1.1kΩ | PCM_JLCPCB:R_0603 | R7, R8 |
| 2 | 4.7kΩ | PCM_JLCPCB:R_0603 | R1, R2 |
| 2 | Red | PCM_JLCPCB:D_0603 | D1, D2 |
| 2 | Switch | Button_Switch_SMD:SW_Push_1P1T_NO_E-Switch_TL3301NxxxxxG | SW1, SW2 |
| 1 | 1000uF | Capacitor_THT:CP_Radial_D8.0mm_P3.50mm | C1 |
| 1 | 10uF | PCM_JLCPCB:C_0603 | C2 |
| 1 | AMS1117-3.3 | Package_TO_SOT_SMD:SOT-223-3_TabPin2 | U3 |
| 1 | ESP32-WROOM-32 | RF_Module:ESP32-WROOM-32 | U1 |
| 1 | I2C | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J11 |
| 1 | PCA9685PW | Package_SO:TSSOP-28_4.4x9.7mm_P0.65mm | U2 |
| 1 | Screw_Terminal_01x02 | TerminalBlock:TerminalBlock_MaiXu_MX126-5.0-02P_1x02_P5.00mm | J1 |
| 1 | UART | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J7 |
Gordon-coder/Robotic-Arm-Fallen-2026
Robotic Arm project for Hack Club's Fallen Event 2026

Acliad/WALL-E-Software
Software and some hardware files for a custom WALL-E robot.


klaus-liebler/sensact
Es gibt vier Namespaces für Nachrichten "REQUEST" und "RESPONSE", "EVENT" und "ACKNOWLEDGE". Dies wird mit den beiden LSB des Versions-Namespace-Bytes erklärt (Somit bleiben 64 Versionierungsmöglichkeiten) Alle vier…

Brobiwann/ESP-spider
The ESP-Spider is a quadruped robot inspired by the miniKame (https://github.com/JavierIH/miniKame) . Like the miniKame, it uses sinusoidal functions to control servo positions, but the design and code were developed…

laurigates/mcu-tinkering-lab
This repository contains projects for various embedded platforms (ESP32, Arduino, STM32).

havrak/UAV-project
Building a UAV as part of my final year on high school, now my hobby project

rland93/ollyfc
A small rust-embedded flight computer. RTIC, FrSky protocols, and STM32F4 hardware.

zhangshua1/PenguinBotV3
PenguinBot V3.0 — 桌面轮足机器人 | ESP32-S3 定制PCB | ICM-42688-P SPI | TOF防跌落 | 离线唤醒词 | 自动充电坞 | BLE App | ¥589 BOM
It measures 60 × 55 mm and has 2 copper layers, 1.6 mm thick.
36 parts, built around the ESP32-WROOM-32, PCA9685PW and AMS1117-3.3. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Gordon-coder/Robotic-Arm-Fallen-2026 repository on GitHub, at the commit this page was made from: the board is Robotic-Arm/PCB/Robotic-Arm-PCB-MAIN/Robotic-Arm-PCB-MAIN.kicad_pcb and its schematic Modules/Controller/Display arm101/Display arm101.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask Gordon-coder before reusing the design.