
2 layers48.3 × 66 mm
Temp Module
ECE-4961-Capstone-Team-1-Spring-Fall-22/Autonomous-Crawlspace-Inspection-Robot
Tennessee Tech ECE 4961 Capstone Project Autonomous Crawlspace Inspection Robot
14 parts10MIT

Tennessee Tech ECE 4961 Capstone Project Autonomous Crawlspace Inspection Robot
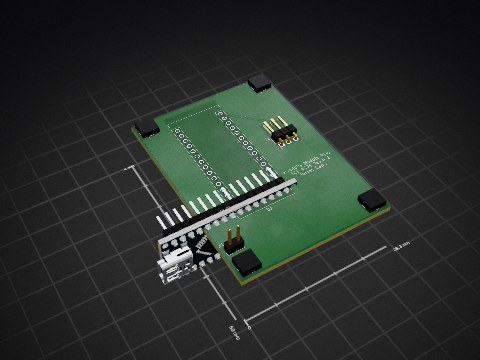
MC Probe is an open-source printed circuit board by ECE-4961-Capstone-Team-1-Spring-Fall-22, from the ECE-4961-Capstone-Team-1-Spring-Fall-22/Autonomous-Crawlspace-Inspection-Robot repository on GitHub, published under the MIT licence. It is a 2-layer board of 48.3 × 66 mm with 29 parts on 39 nets, routed with 88 tracks and 0 vias.
It is built around the TBL009-254-02GY-2GY, TBL009-254-06GY-2GY and TBL009-254-08GY-2GY. Its parts include 10 resistors, 5 transistors, 4 connectors, 1 capacitor and 1 IC. It belongs with the sensors and measurement boards and the AVR (ATmega, ATtiny) boards of this library.
This GitHub contains all relevant files used during development. For a comprehensive guide to the repository set up see the bottom of the document.
Crawl spaces grant convenient access to the plumbing, duct work, and electrical wiring of a house, but they often present unique dangers to maintenance professionals and residents alike. Exposure to harsh breathing conditions, hanging obstacles, uncomfortable working positions, and even animals can cause non-ideal conditions. This capstone project will focus on the design and assembly of a robot prototype that can perform these inspections autonomously. The end product will be an autonomous, mobile robot that can be left unattended in a crawlspace by an inspector. It will navigate through the space, create a map and model of the space, compile an image of the entire crawlspace ceiling, and collect sensor data. This sensor data will include humidity, temperature, and wood moisture content.
The first iteration of the project focused on setting up the hardware systems. Sensors, microcontrollers, motors, and power circuits were designed and implemented as part of a larger multi-group project. The following details the current capabilities of the robot.
For more detail on current designs, see files in sub-system directories
Although this project includes lofty long-term goals, many exceptional systems were able to be incorporated in the first iteration of the project.
The final system demo in the crawlspace can be found here
A picture of the final system can also be found below

James (Jim) Camp - Senior Electrical Engineering Major, Mechatronics Concentration - Environmental Sensor Subsystem Developer - Delegator
John-Caleb (JC) Williams - Senior Electrical Engineering Major, Electromagnetics Concentration - Navigation Subsystem Developer - Treasurer
John Harris - Senior Electrical Engineering Major, Controls Concentration - Power Subsystem Developer - Secretary
Joseph Thomas - Senior Electrical Engineering Major, Power Concentration - Movement Subsystem Developer - Social
Mr. Jesse Roberts - Professor and Faculty Advisor
Project Stakeholders - This project was developed for anyone who needs to inspect their crawlspace. This includes homeowners, building inspectors, and renovators. The system is also a great solution for anyone experiencing issues with mold or unsafe crawlspace conditions.
This repository contains the entirety of the Autonomous Crawlspace Inspection Robot’s REV1 design files. The folder breakdown is as follows
| Qty | Value | Footprint | References |
|---|---|---|---|
| 5 | 4.7k | Resistor_SMD:R_1206_3216Metric | R6, R7, R8, R9, R10 |
| 5 | PNP | Package_TO_SOT_THT:TO-92 | Q1, Q2, Q3, Q4, Q5 |
| 4 | , , , | ||
| 1 | 100nF | Capacitor_SMD:C_1206_3216Metric | C1 |
| 1 | 10G | Resistor_SMD:R_1206_3216Metric | R5 |
| 1 | 4.7M | Resistor_SMD:R_1206_3216Metric | R2 |
| 1 | 470M | Resistor_SMD:R_1206_3216Metric | R4 |
| 1 | 47M | Resistor_SMD:R_1206_3216Metric | R3 |
| 1 | 820k | Resistor_SMD:R_1206_3216Metric | R1 |
| 1 | Arduino_Nano_v2.x | Capstone_Library:Arduino_Nano_WithMountingHoles | U1 |
| 1 | Conn_01x02_Female | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J1 |
| 1 | TBL009-254-02GY-2GY | Screw_Terminals:CUI_TBL009-254-02GY-2GY | J2 |
| 1 | TBL009-254-06GY-2GY | Screw_Terminals:CUI_TBL009-254-06GY-2GY | J4 |
| 1 | TBL009-254-08GY-2GY | Screw_Terminals:CUI_TBL009-254-08GY-2GY | J3 |
The 25 most common of 29 parts.
ECE-4961-Capstone-Team-1-Spring-Fall-22/Autonomous-Crawlspace-Inspection-Robot
Tennessee Tech ECE 4961 Capstone Project Autonomous Crawlspace Inspection Robot
ECE-4961-Capstone-Team-1-Spring-Fall-22/Autonomous-Crawlspace-Inspection-Robot
Tennessee Tech ECE 4961 Capstone Project Autonomous Crawlspace Inspection Robot


cdint/decoder-breakout
High-speed optical decoder breakout board with an I2C interface

gusmanb/logicanalyzer
24 channel, 100Msps logic analyzer hardware and software

VoronDesign/Voron-Hardware
Cool Hardware designed by the Voron Design group

hoglet67/RGBtoHDMI
Bare-metal Raspberry Pi project that provides pixel-perfect sampling of Retro Computer RGB/YUV video and conversion to HDMI

hackclub/OnBoard
💡 Join 1,000 teenagers and make your first PCB with a $100 grant!

OLIMEX/DIY-LAPTOP
Do It Yourself Open Source Hardware and Software Modular Hacker's Friendly Laptop

UtilitechAS/amsreader-firmware
ESP8266 and ESP32 compatible firmware to read, interpret and publish data to MQTT from smart electrical meters, both DLMS and DSMR is supported
It measures 48.3 × 66 mm and has 2 copper layers, 1.6 mm thick.
29 parts, built around the TBL009-254-02GY-2GY, TBL009-254-06GY-2GY and TBL009-254-08GY-2GY. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the ECE-4961-Capstone-Team-1-Spring-Fall-22/Autonomous-Crawlspace-Inspection-Robot repository on GitHub, at the commit this page was made from: the board is Environmental Sensing/MC_PCB/MC_Probe/MC_Probe.kicad_pcb and its schematic Environmental Sensing/Humidity_PCB/Humidity_Module/Humidity_Module.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).