
4 layers65 × 70 mm
 Ding-Jeremy/Self-Balancing-Bot
This repo contains the code regarding the Bachelor Work "Self-Balancing-Bot"
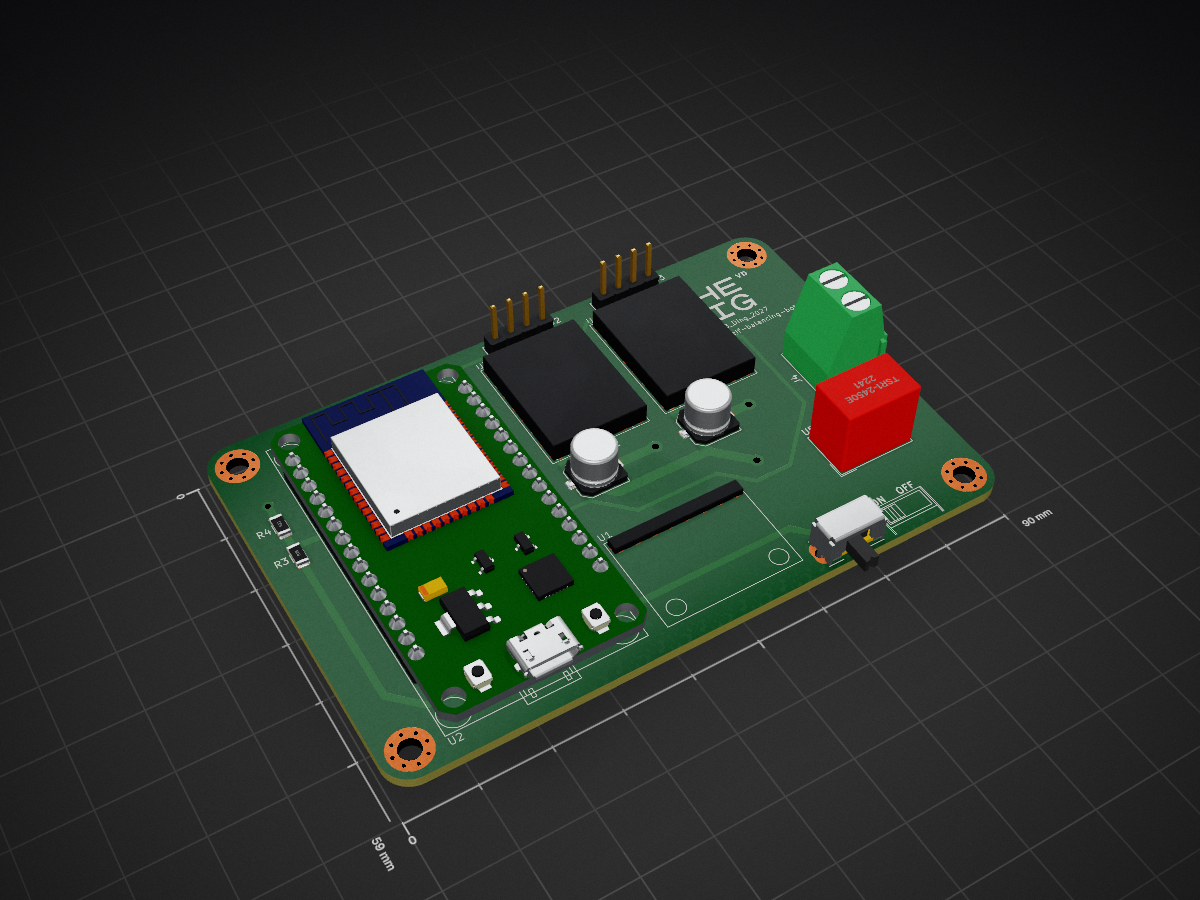
Self Balancing Bot V0 is an open-source printed circuit board by Ding-Jeremy, from the Ding-Jeremy/Self-Balancing-Bot repository on GitHub. It is a 4-layer board of 90 × 59 mm with 18 parts on 48 nets, routed with 156 tracks and 4 vias.
It is built around the TSR 1-2450E. Its parts include 5 ICs, 3 resistors, 3 connectors, 2 capacitors and 1 switch.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 2 | 100uF | Capacitor_SMD:C_Elec_6.3x5.8 | C1, C2 |
| 2 | Conn_01x04_Pin | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J2, J3 |
| 2 | ~ | Project_Lib:TMC2130 | U3, U4 |
| 1 | 10k | Resistor_SMD:R_1206_3216Metric | R4 |
| 1 | 1k | Resistor_SMD:R_1206_3216Metric | R1 |
| 1 | 61k | Resistor_SMD:R_1206_3216Metric | R3 |
| 1 | SW_SPDT | Button_Switch_THT:SW_Slide_SPDT_Angled_CK_OS102011MA1Q | SW1 |
| 1 | Screw_Terminal_01x02 | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-2_1x02_P5.00mm_Horizontal | J4 |
| 1 | TSR1-2450E | Converter_DCDC:Converter_DCDC_TRACO_TSR1-xxxxE_THT | U5 |
| 1 | ~ | Project_Lib:MPU6050 | U1 |
| 1 | ~ | Project_Lib:ESP32_DEVKITC_30P | U2 |
The 14 most common of 18 parts.

Ayan-nova/Design-of-a-Raspberry-PICO-Iot-Device-on-4-Layer-PCB-Design-With-Sensor-And-More
Design a Raspberry Pi Pico W-based Industrial IoT Gateway and Edge Controller using Kicad software.

baloghr/usonic
KiCad 9 project gp2026 (hardware revision 1.01): schematic, PCB, custom footprints (Library.pretty) and 3D models (packages3D).

ismailEngineer/omniwheel-robot
a small protoype to educate the control system of 3 OmniWheel Robot


Unimakers/CDR-2027
Ce repo est un site de documentation réalisé par l'équipe des première et deusième années pré-ingénieur de l'école Unilasalle-Amiens, membre de l'association de robotique Unimaker, dans le cadre de leur participation à…


It measures 90 × 59 mm and has 4 copper layers, 1.6 mm thick.
18 parts, built around the TSR 1-2450E. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Ding-Jeremy/Self-Balancing-Bot repository on GitHub, at the commit this page was made from: the board is C_Fabrication/V0/A_Circuit/A_Kicad/Self_Balancing_Bot_V0/Self_Balancing_Bot_V0.kicad_pcb and its schematic C_Fabrication/V0/A_Circuit/A_Kicad/Self_Balancing_Bot_V0/Self_Balancing_Bot_V0.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask Ding-Jeremy before reusing the design.