2 layers17.8 × 27.9 mm
DEBUGEDGE BREAKOUT
CYMOTIVE/CYMOCAN
Low cost USB to CAN-FD (Controller Area Network - Flexible Data rate) interface.
4 parts20

 CYMOTIVE/CYMOCAN20
Low cost USB to CAN-FD (Controller Area Network - Flexible Data rate) interface.
CYMOCAN G0 is an open-source printed circuit board by CYMOTIVE, from the CYMOTIVE/CYMOCAN repository on GitHub. It is a 2-layer board of 63.5 × 36.8 mm with 39 parts on 84 nets, routed with 453 tracks and 27 vias.
It is built around the TJA1051T/3/1, AP2112K-3.3 and USBLC6-2P6. Its parts include 13 resistors, 8 connectors, 6 diodes, 5 capacitors and 5 ICs. It belongs with the interfaces and adapters boards and the STM32 boards of this library.


CYMOCAN is a low cost USB to CAN-FD (Controller Area Network - Flexible Data rate) interface.
Using the CandleLight firmware CYMOCAN can work with Windows(WCID USB) and Linux(SocketCAN over gs_usb).
CYMOCAN_G0 has:
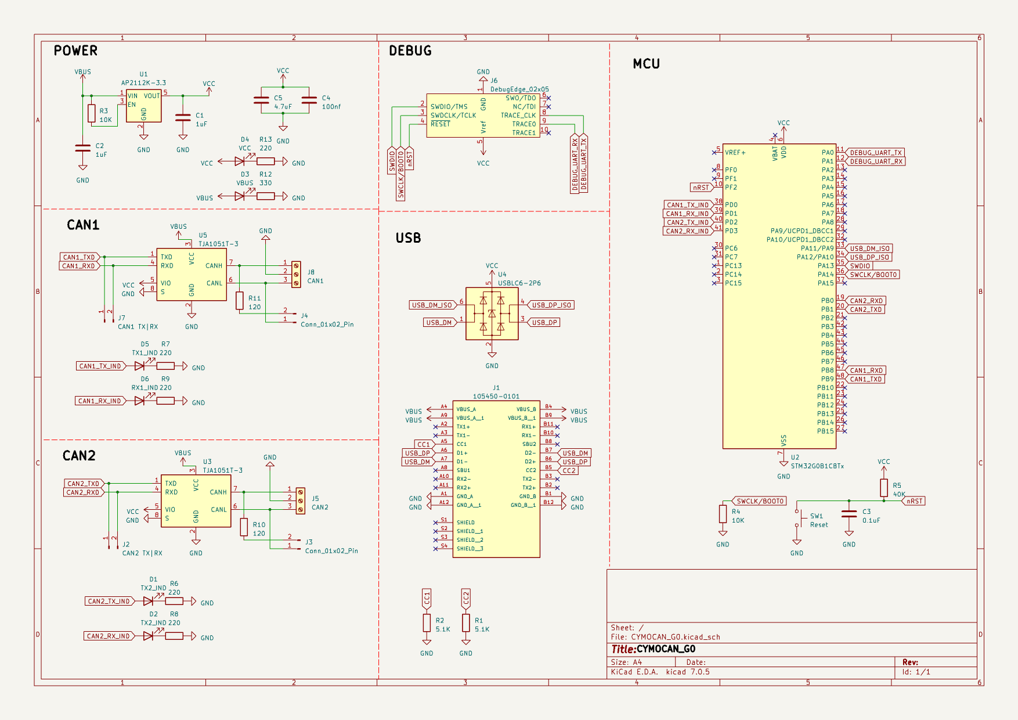
CYMOCAN_G0 BOM
| Reference | Description | Quantity |
|---|---|---|
| C1, C2 | 0603 1uF Capacitor | 2 |
| C3 | 0603 0.1uF Capacitor | 1 |
| C4 | 0603 100nf Capacitor | 1 |
| C5 | 0603 4.7uF Capacitor | 1 |
| D1, D2, D3, D4, D5, D6 | 0603 LED | 6 |
| J1 | Molex 105450-0101 USB-C socket | 1 |
| J2, J3, J4, J7 | 01x02 Pin Header | 4 |
| J5, J8 | 3 Pin TerminalBlock Bornier 5.08mm | 2 |
| R1, R2 | 0603 5.1K Resistor | 2 |
| R3, R4 | 0603 10K Resistor | 2 |
| R5 | 0603 40K Resistor | 1 |
| R6, R7, R8, R9, R13 | 0603 220 Resistor | 5 |
| R10, R11 | 0603 120 Resistor | 2 |
| R12 | 0603 330 Resistor | 1 |
| SW1 | Push switch 6mm THT | 1 |
| U1 | AP2112K-3.3 LDO regulator | 1 |
| U2 | STM32G0B1CBT6 Microcontroller | 1 |
| U3, U5 | TJA1051T-3 CAN transceiver | 2 |
| U4 | USBLC6-2P6 USB ESD protection diodes | 1 |
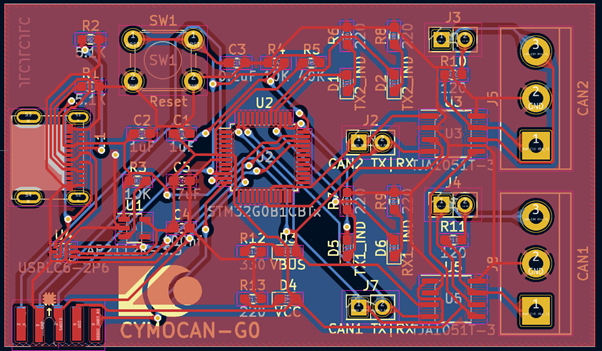
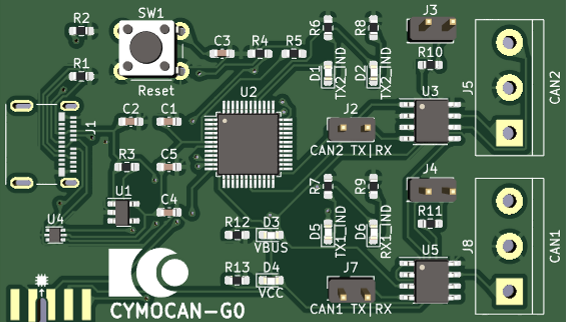
You Do not need this in order to flash and use the CYMOCAN board. This breakout is only necessary if you wish to debug the board during development.
After assembling the device follow the flashing instructions in the CandleLight firmware Repo.
For now use the PR https://github.com/candle-usb/candleLight_fw/pull/139 and the nucleo_g0b1re target.
You will need to compile a kernel version 5.18 or above for GS_USB CAN-FD support. The flags you must enable are:
After compiling and installing the Kernel the CYMOCAN will appear as a standard SocketCAN device.
To setup the device for classic CAN use the following commands
sudo ip link set can0 qlen 1000
sudo ip link set can0 up type can bitrate 500000
Subsitute can0 for the channel you are using. Now you can use the device with any SocketCAN compatible software.
TODO
| Qty | Value | Footprint | References |
|---|---|---|---|
| 5 | 220 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R6, R7, R8, R9, R13 |
| 2 | 10K | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R3, R4 |
| 2 | 120 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R10, R11 |
| 2 | 1uF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C1, C2 |
| 2 | 5.1K | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R1, R2 |
| 2 | Conn_01x02_Pin | Connector_PinHeader_2.54mm:PinHeader_2x01_P2.54mm_Vertical | J3, J4 |
| 2 | TJA1051T-3 | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U3, U5 |
| 2 | TX2_IND | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D1, D2 |
| 1 | 0.1uF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C3 |
| 1 | 100nf | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C4 |
| 1 | 105450-0101 | SnapEDA Library:MOLEX_105450-0101 | J1 |
| 1 | 330 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R12 |
| 1 | 4.7uF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C5 |
| 1 | 40K | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R5 |
| 1 | AP2112K-3.3 | Package_TO_SOT_SMD:SOT-23-5 | U1 |
| 1 | CAN1 | TerminalBlock:TerminalBlock_bornier-3_P5.08mm | J8 |
| 1 | CAN1 TX|RX | Connector_PinHeader_2.54mm:PinHeader_2x01_P2.54mm_Vertical | J7 |
| 1 | CAN2 | TerminalBlock:TerminalBlock_bornier-3_P5.08mm | J5 |
| 1 | CAN2 TX|RX | Connector_PinHeader_2.54mm:PinHeader_2x01_P2.54mm_Vertical | J2 |
| 1 | DebugEdge_02x05 | DebugEdge:DebugEdge_2x05_Target | J6 |
| 1 | LOGO | LOGO | G*** |
| 1 | RX1_IND | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D6 |
| 1 | Reset | Button_Switch_THT:SW_PUSH_6mm | SW1 |
| 1 | STM32G0B1CBTx | Package_QFP:LQFP-48_7x7mm_P0.5mm | U2 |
| 1 | TX1_IND | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D5 |
| 1 | USBLC6-2P6 | Package_TO_SOT_SMD:SOT-666 | U4 |
| 1 | VBUS | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D3 |
| 1 | VCC | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D4 |
CYMOTIVE/CYMOCAN
Low cost USB to CAN-FD (Controller Area Network - Flexible Data rate) interface.

sikaxn/FRC-Custom-CAN-Sensor
If you are looking for IronMaple ESP32‐FRC‐devkit resources, please switch branch to dev-board.

maximus64/opendiag-hardware
OpenDIAG - Open Source OBD2 Interface (Hardware)

Tai-Min/Robo-Bus
Modular series of MCUs and hardware boards designed for robotics, providing a unified bus system for seamless and reliable communication between robotic components

byui-formula-hybrid/legacy-Cooling-Pump-Board
BYUI Cooling pump CAN control board


sihyun-noh/zephyr_485toSDI12
Zephyr RTOS 기반 Dajilog MCU 장비의 firmware, custom board 정의, 공통 component, KiCad hardware source를 함께 관리하는 repository입니다.


It measures 63.5 × 36.8 mm and has 2 copper layers, 1.6 mm thick.
39 parts, built around the TJA1051T/3/1, AP2112K-3.3 and USBLC6-2P6. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the CYMOTIVE/CYMOCAN repository on GitHub, at the commit this page was made from: the board is hardware/CYMOCAN_G0/CYMOCAN_G0.kicad_pcb and its schematic hardware/CYMOCAN_G0/CYMOCAN_G0.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask CYMOTIVE before reusing the design.