
2 layers70 × 100.1 mm
Loliwrapper
CCHS-Melbourne/LoliBot
Welcome to the 2018 linux.conf.au Open Hardware Project. You can see information about this and other MiniConfs at .
10 parts13

 CCHS-Melbourne/LoliBot13
Welcome to the 2018 linux.conf.au Open Hardware Project. You can see information about this and other MiniConfs at .
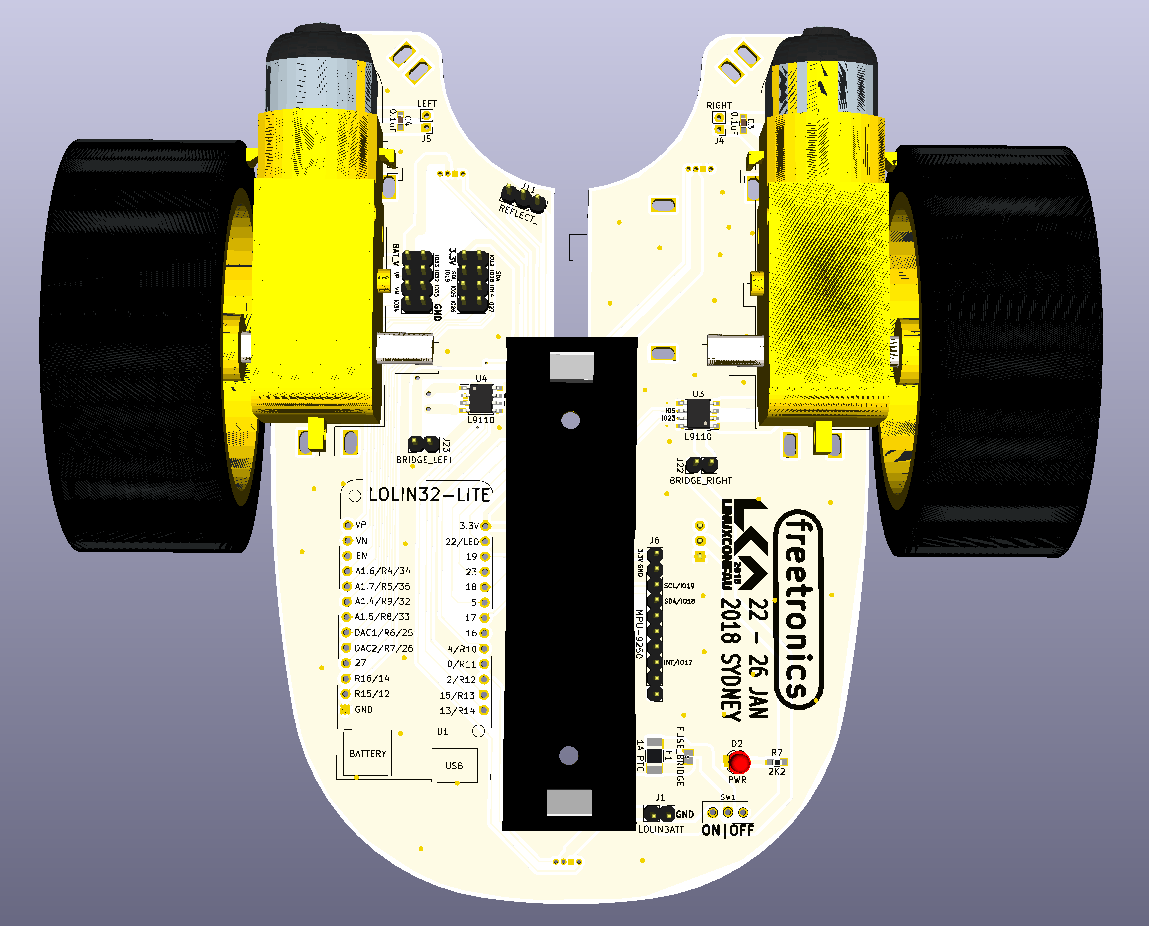
LoliBot is an open-source printed circuit board by CCHS-Melbourne, from the CCHS-Melbourne/LoliBot repository on GitHub. It is a 2-layer board of 146 × 100 mm with 42 parts on 56 nets, routed with 575 tracks and 97 vias.
It is built around the MPU-9250. Its parts include 30 connectors, 3 resistors, 3 ICs, 2 capacitors and 1 diode.
Quick links ...
Welcome to the 2018 linux.conf.au Open Hardware Project. You can see information about this and other MiniConfs at http://www.openhardwareconf.org/wiki/Main_Page.
If you're attending the assembly workshop at Linux.conf.au 2018, the place to start is http://www.openhardwareconf.org/wiki/LoliBot
This year's project is called the Lolibot, and is a simple robot is designed to chase and kick a Ping Pong ball around.
It features a Lolin32-lite ESP32 based chip as it's primary microprocessor and includes a MPU6050 6 axis accelerometer.
In order to reduce complexity and to be a bit more flexible with our design this years project is a platform with discrete components. Those of you who are looking forward to the smell of melting solder won't be disappointed though, there are many headers, LEDS and switches to keep you busy.
Assembly instructions for the kit are at http://www.openhardwareconf.org/wiki/LoliBot-Assembly
All the usual ESP32 development options apply to the LoliBot ...
We've chosen to focus on using microPython to provide a simple, yet capable entry point for newcomers to robotics and embedded computers.
The software sub-directory has instructions on installing and developing software for the LoliBot.
Licensed under the TAPR Open Hardware License (http://www.tapr.org/OHL). The "license" sub-folder also contains a copy of this license in plain text format.
Copyright John Spencer, Angus Gratton, Andy Gelme, Jon Oxer, Mark Wolfe 2017
| Qty | Value | Footprint | References |
|---|---|---|---|
| 12 | MECH | Mounting_Holes:MountingHole_3.2mm_M3_Pad | J12, J13, J14, J15, J16, J17, J18, J19, J25, J26, J27, J28 |
| 3 | APA106 | libs:LED_8MM_APA-106 | J2, J7, J8 |
| 2 | 0.1uF | Capacitors_SMD:C_0603_HandSoldering | C3, C4 |
| 2 | 4K7 | Resistors_SMD:R_0603_HandSoldering | R1, R2 |
| 2 | CONN_01X08 | Pin_Headers:Pin_Header_Straight_2x04_Pitch2.54mm | J20, J21 |
| 2 | L9110 | Housings_SOIC:SOIC-8_3.9x4.9mm_Pitch1.27mm | U3, U4 |
| 1 | 1A PTC | Resistors_SMD:R_1210_HandSoldering | F1 |
| 1 | 2K2 | Resistors_SMD:R_0603_HandSoldering | R7 |
| 1 | BATTERY | libs:BH-18650 | BT1 |
| 1 | BRIDGE_LEFT | Pin_Headers:Pin_Header_Straight_1x02_Pitch2.54mm | J23 |
| 1 | BRIDGE_RIGHT | Pin_Headers:Pin_Header_Straight_1x02_Pitch2.54mm | J22 |
| 1 | FREETRONICS_LOGO | libs:LOGO_FREETRONICS_33mm | J32 |
| 1 | FUSE_BRIDGE | libs:bridge | J24 |
| 1 | LCA_LOGO | libs:LCA2018_LOGO | J31 |
| 1 | LEFT | Pin_Headers:Pin_Header_Straight_1x02_Pitch2.00mm | J5 |
| 1 | LEFT-MOTOR | libs:DC-Motor | J10 |
| 1 | LOLIN32-LITE | libs:lolin32-lite | U1 |
| 1 | LOLINBATT | Pin_Headers:Pin_Header_Straight_1x02_Pitch2.54mm | J1 |
| 1 | MPU-9250 | Pin_Headers:Pin_Header_Straight_1x10_Pitch2.54mm | J6 |
| 1 | ON|OFF | libs:SS12D00 | SW1 |
| 1 | PWR | LEDs:LED_D3.0mm | D2 |
| 1 | REFLECT_ | Pin_Headers:Pin_Header_Straight_1x03_Pitch2.54mm | J11 |
| 1 | RIGHT | Pin_Headers:Pin_Header_Straight_1x02_Pitch2.00mm | J4 |
| 1 | RIGHT-MOTOR | libs:DC-Motor | J9 |
| 1 | SERVO1 | Pin_Headers:Pin_Header_Angled_1x03_Pitch2.54mm | J3 |
CCHS-Melbourne/LoliBot
Welcome to the 2018 linux.conf.au Open Hardware Project. You can see information about this and other MiniConfs at .

Jeija/esp8266-smartwatch
ESP8266 DIY WiFi Smartwatch with MPU-9250, RTC, OLED, FT232, ...


crnicholson/StratoSoar-MK2
StratoSoar is an engineering project that aims to be able to fly a glider (dropped from a high-altitude balloon), down to any selected coordinates.

squarewavedot/ledcubeelectronics
LEDCube battery and masterboard electronics

Kamilake/FineMotion-Tracker
ESP8266 Motion Capture Full-Body Tracker for SlimeVR


It measures 146 × 100 mm and has 2 copper layers, 1.6 mm thick.
42 parts, built around the MPU-9250. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the CCHS-Melbourne/LoliBot repository on GitHub, at the commit this page was made from: the board is LoliBot/LoliBot.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask CCHS-Melbourne before reusing the design.