
2 layers48.1 × 48 mm

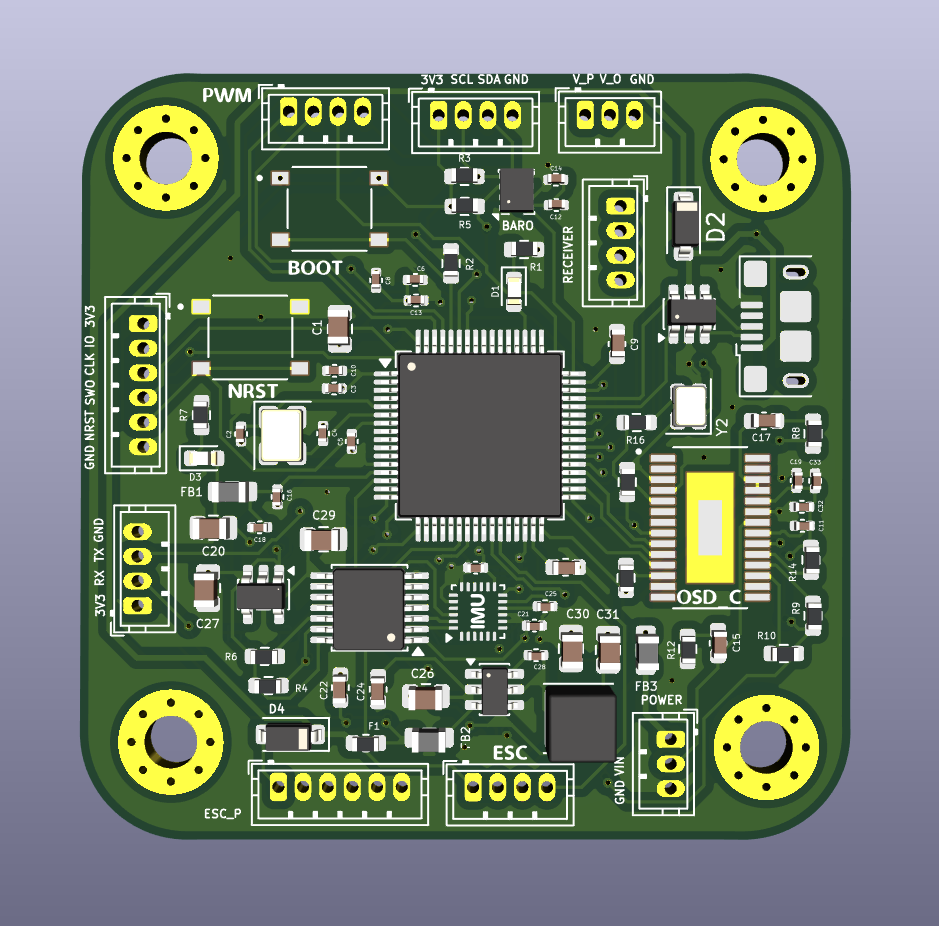
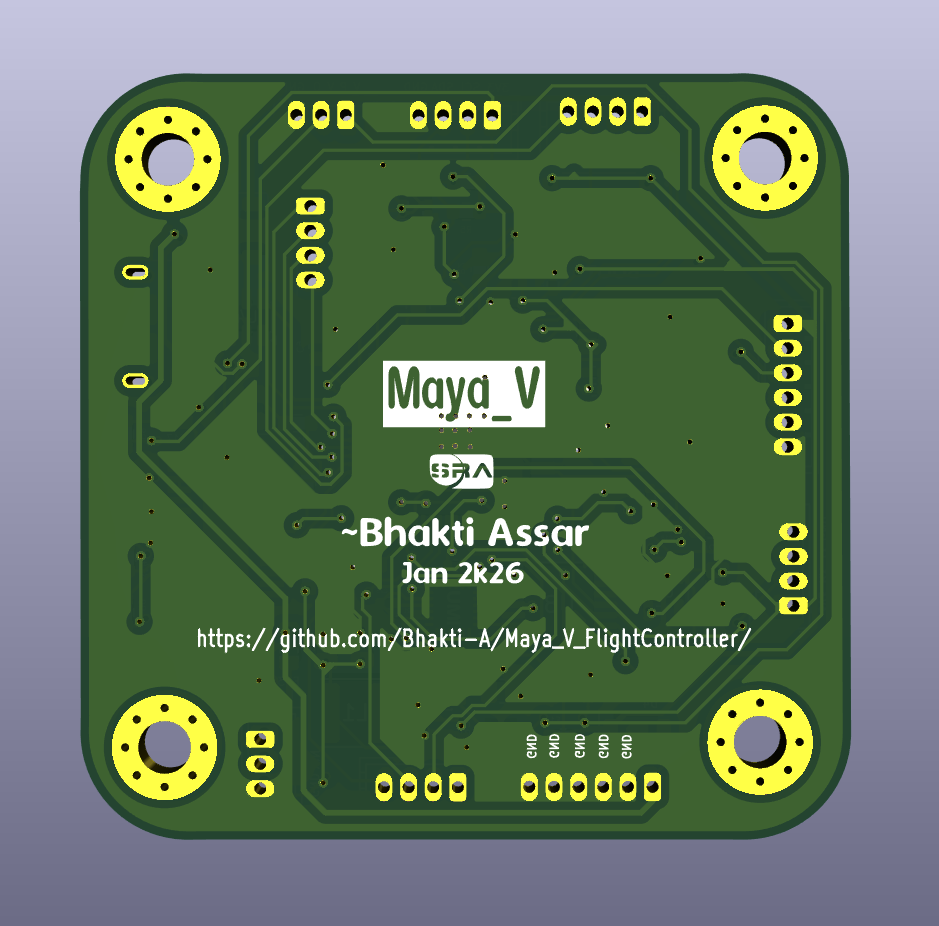
This is a custom flight controller PCB designed for drones.
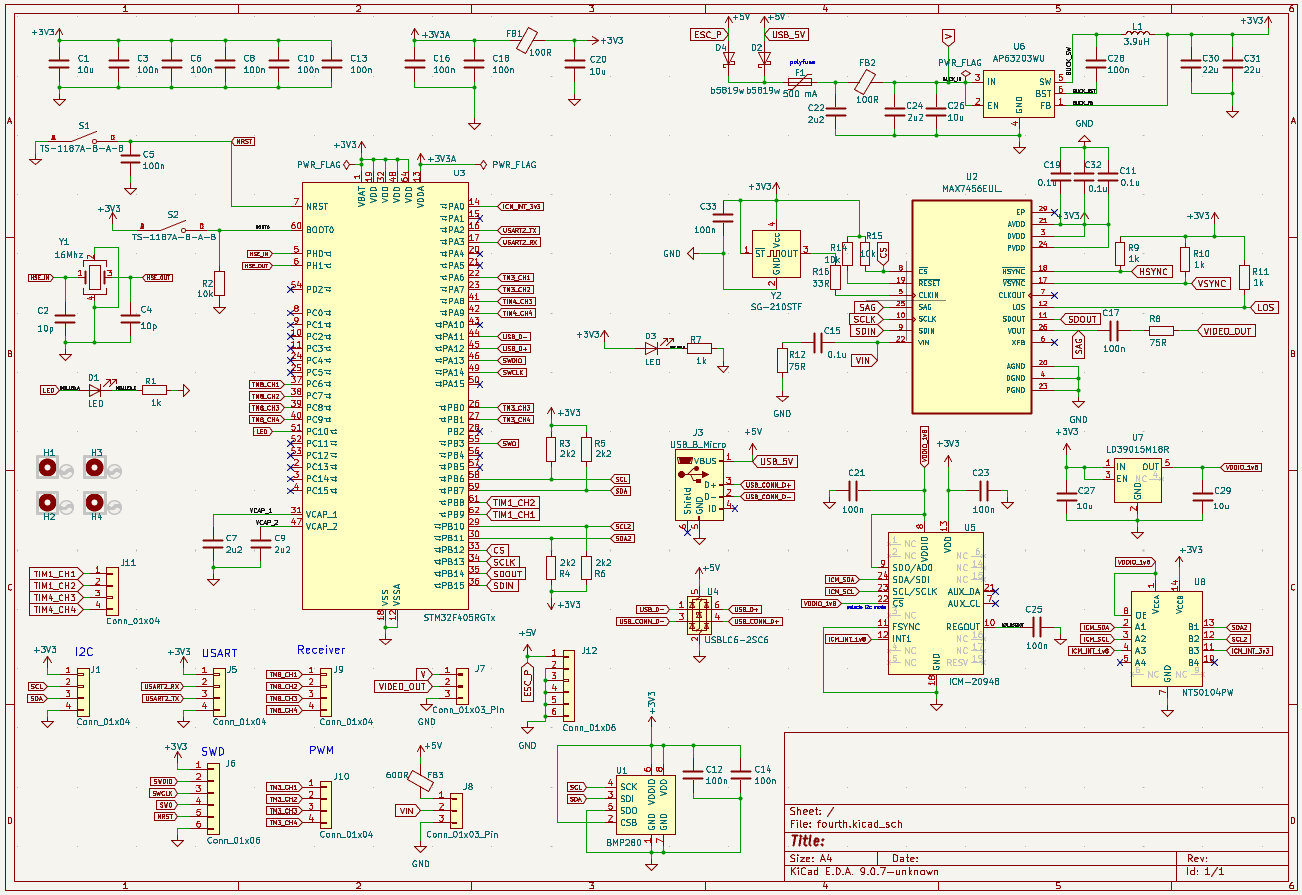
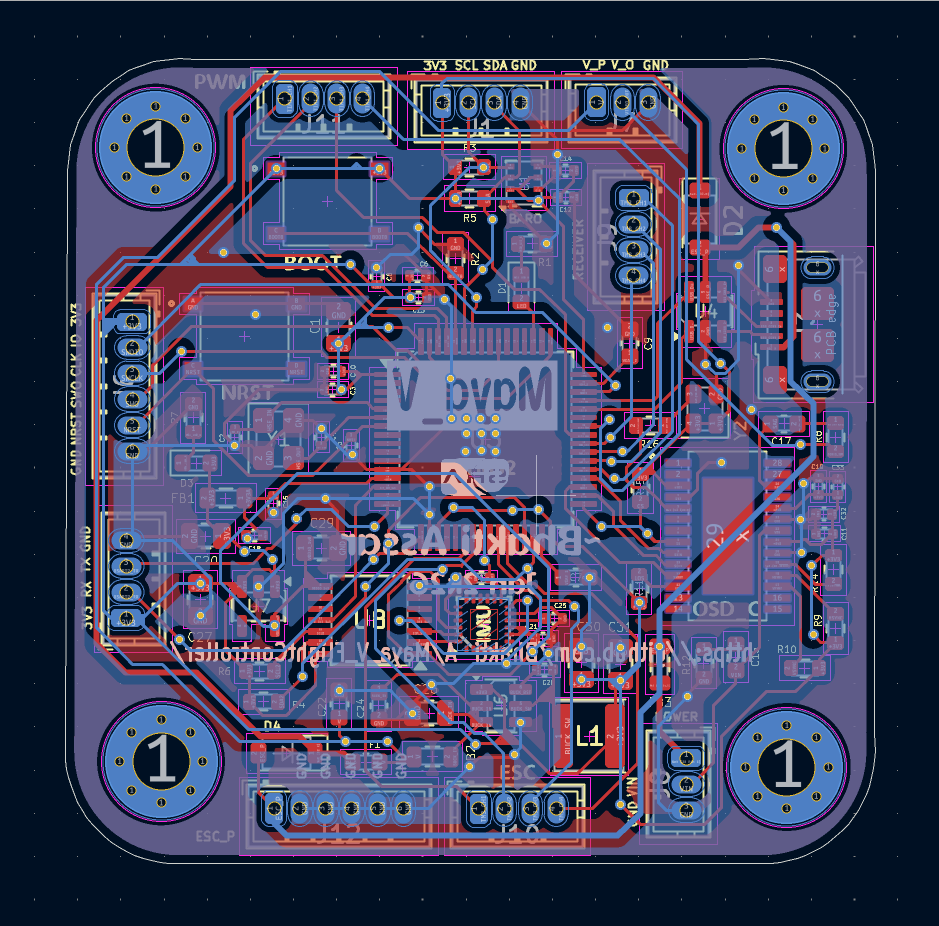
Fourth is an open-source printed circuit board by Bhakti-A, from the Bhakti-A/Maya_V_FlightController repository on GitHub. It is a 2-layer board of 46.9 × 46.6 mm with 84 parts on 113 nets, routed with 1,175 tracks and 106 vias.
It is built around the AP63203WU, BMP280 and MAX7456EUI, with the ICM-20948, LD39015M18R and NTS0104PW among its other parts. Its parts include 33 capacitors, 15 resistors, 10 connectors, 8 ICs and 4 diodes. It belongs with the STM32 boards of this library.


This is a custom flight controller PCB designed for drones.
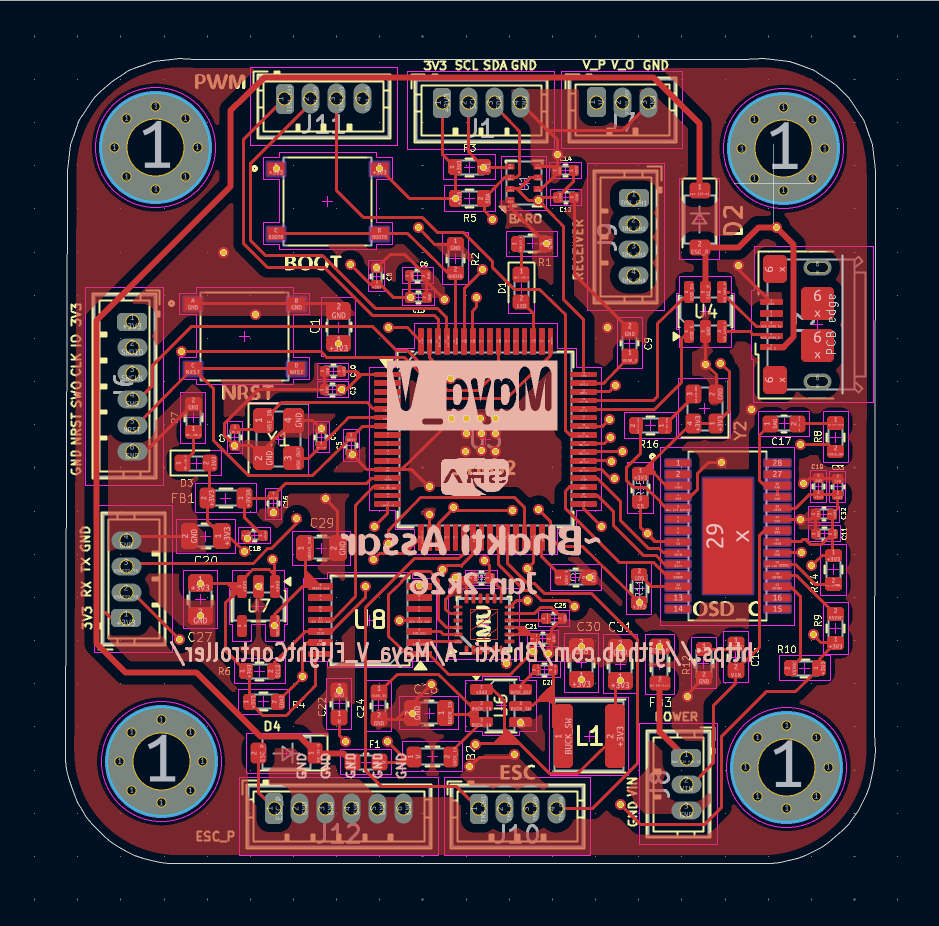
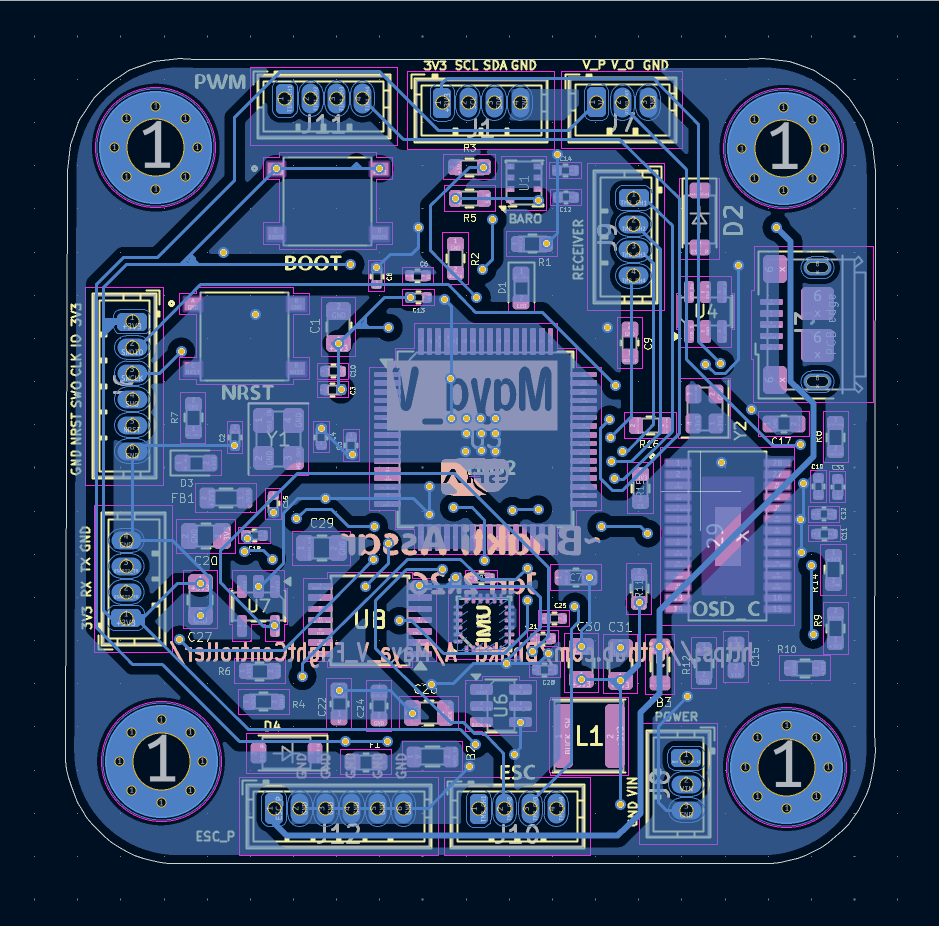
| Qty | Value | Footprint | References |
|---|---|---|---|
| 15 | 100n | Capacitor_SMD:C_0402_1005Metric | C3, C5, C6, C8, C10, C12, C13, C14, C16, C18, C21, C23, C25, C28, C33 |
| 5 | 10u | Capacitor_SMD:C_0805_2012Metric | C1, C20, C26, C27, C29 |
| 5 | 1k | Resistor_SMD:R_0603_1608Metric | R1, R7, R9, R10, R11 |
| 5 | Conn_01x04 | Connector_JST:JST_ZH_B4B-ZR_1x04_P1.50mm_Vertical | J1, J5, J9, J10, J11 |
| 4 | 2k2 | Resistor_SMD:R_0603_1608Metric | R3, R4, R5, R6 |
| 4 | 2u2 | Capacitor_SMD:C_0603_1608Metric | C7, C9, C22, C24 |
| 4 | MountingHole | MountingHole:MountingHole_3.2mm_M3_Pad_Via | H1, H2, H3, H4 |
| 3 | 0.1u | Capacitor_SMD:C_0402_1005Metric | C11, C19, C32 |
| 3 | 10k | Resistor_SMD:R_0603_1608Metric | R2, R14, R15 |
| 2 | 100R | Inductor_SMD:L_0805_2012Metric | FB1, FB2 |
| 2 | 10p | Capacitor_SMD:C_0402_1005Metric | C2, C4 |
| 2 | 22u | Capacitor_SMD:C_0805_2012Metric | C30, C31 |
| 2 | 75R | Resistor_SMD:R_0603_1608Metric | R8, R12 |
| 2 | Conn_01x03_Pin | Connector_JST:JST_ZH_B3B-ZR_1x03_P1.50mm_Vertical | J7, J8 |
| 2 | Conn_01x06 | Connector_JST:JST_ZH_B6B-ZR_1x06_P1.50mm_Vertical | J6, J12 |
| 2 | LED | LED_SMD:LED_0603_1608Metric | D1, D3 |
| 2 | TS-1187A-B-A-B | TS-1187A-B-A-B:SW_TS-1187A-B-A-B | S1, S2 |
| 2 | b5819w | Diode_SMD:D_SOD-123 | D2, D4 |
| 1 | 0.1u | Capacitor_SMD:C_0603_1608Metric | C15 |
| 1 | 100n | Capacitor_SMD:C_0603_1608Metric | C17 |
| 1 | 16Mhz | Crystal:Crystal_SMD_3225-4Pin_3.2x2.5mm | Y1 |
| 1 | 3.9uH | Inductor_SMD:L_Sunlord_SWPA4030S | L1 |
| 1 | 33R | Resistor_SMD:R_0603_1608Metric | R16 |
| 1 | 500 mA | Fuse:Fuse_0603_1608Metric | F1 |
| 1 | 600R | Inductor_SMD:L_0805_2012Metric | FB3 |
| 1 | AP63203WU | Package_TO_SOT_SMD:TSOT-23-6 | U6 |
| 1 | BMP280 | Package_LGA:Bosch_LGA-8_2x2.5mm_P0.65mm_ClockwisePinNumbering | U1 |
| 1 | ICM-20948 | Sensor_Motion:InvenSense_QFN-24_3x3mm_P0.4mm | U5 |
| 1 | LD39015M18R | Package_TO_SOT_SMD:SOT-23-5 | U7 |
| 1 | LOGO | logo:sra_logo | G*** |
| 1 | MAX7456EUI_ | MAX7456EUI_:SOP65P637X110-28N | U2 |
| 1 | NTS0104PW | Package_SO:TSSOP-14_4.4x5mm_P0.65mm | U8 |
| 1 | SG-210STF | Oscillator:Oscillator_SMD_SeikoEpson_SG210-4Pin_2.5x2.0mm | Y2 |
| 1 | STM32F405RGTx | Package_QFP:LQFP-64_10x10mm_P0.5mm | U3 |
| 1 | USBLC6-2SC6 | Package_TO_SOT_SMD:SOT-23-6 | U4 |
| 1 | USB_B_Micro | Connector_USB:USB_Micro-B_Amphenol_10118193-0001LF_Horizontal | J3 |

LtBrain/astrum
A control system board/robot for Science Olympiads Robot Tour. It will have 2 brushed motor drivers, at least 2 encoder inputs, and support for ultrasonic and TOF sensors, all in a compact package.

alexander-armitage/AURA-Hardware
AURA is a set of modular PCBs designed in KiCad for versatile robotics and aerospace applications — from drones and quadrupeds to rockets.

Pingu207/ROCKET
Designing and building a TVC rocket controlled by a custom PCB wired to a ESP32-WROOM board


FujiNetWIFI/fujinet-hardware
Schematics and design files for FujiNet hardware

CircuitGuy943/Sabre-Integrated-flight-controller
(🚧) A "Jack of all trades" custom flight controller board. With support for both power and control and the ability for custom firmware

It measures 46.9 × 46.6 mm and has 2 copper layers, 1.6 mm thick.
84 parts, built around the AP63203WU, BMP280, MAX7456EUI and ICM-20948. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Bhakti-A/Maya_V_FlightController repository on GitHub, at the commit this page was made from: the board is pcb/hardware/fourth.kicad_pcb and its schematic pcb/hardware/fourth.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask Bhakti-A before reusing the design.