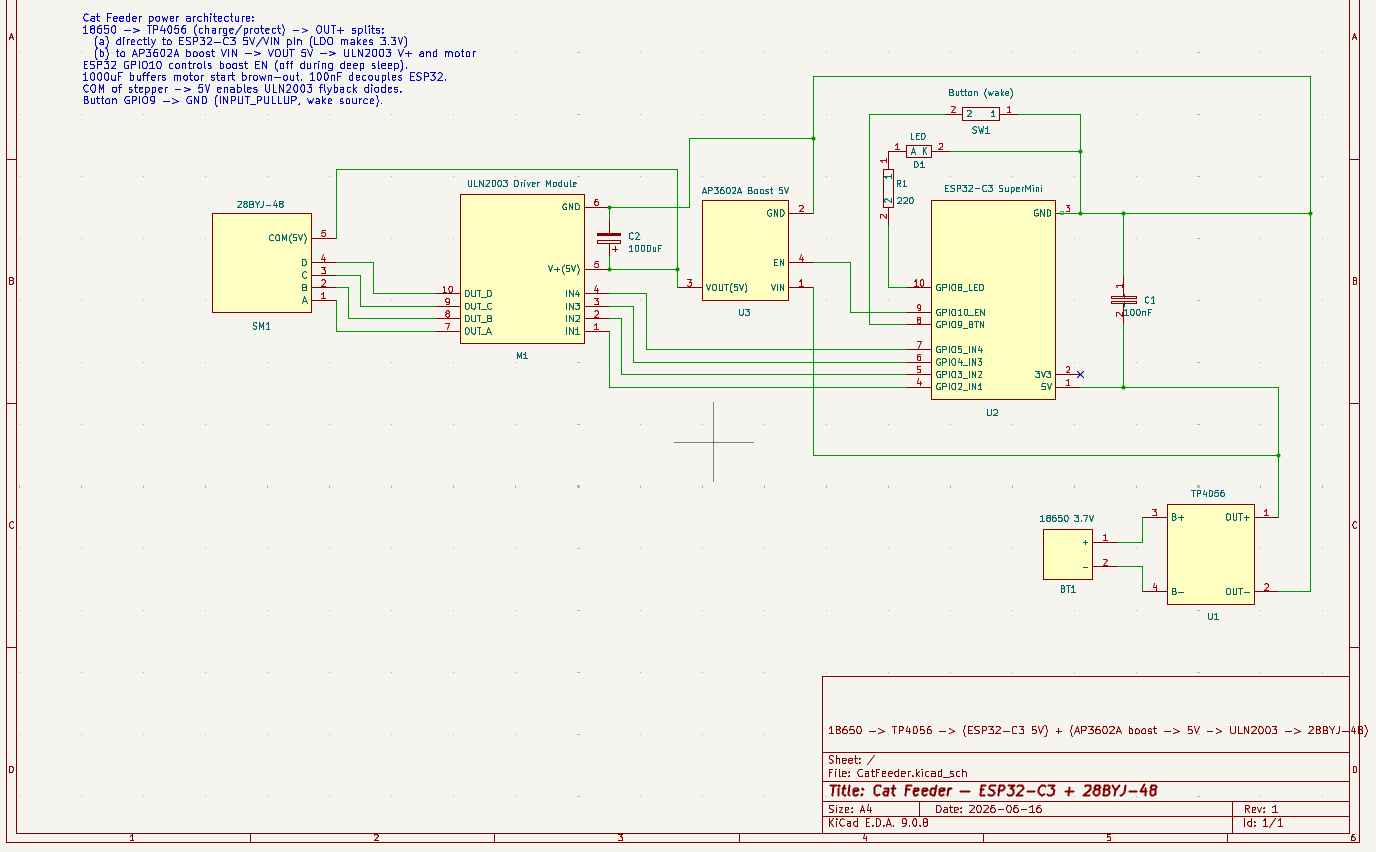
CatFeeder is an open-source printed circuit board by 12romis, from the 12romis/CatFeeder repository on GitHub. It is a 2-layer board with 11 parts on 15 nets.
It is built around the TP4056. Its parts include 3 ICs, 2 capacitors, 1 resistor, 1 diode and 1 switch. It belongs with the ESP32 and RISC-V boards of this library.
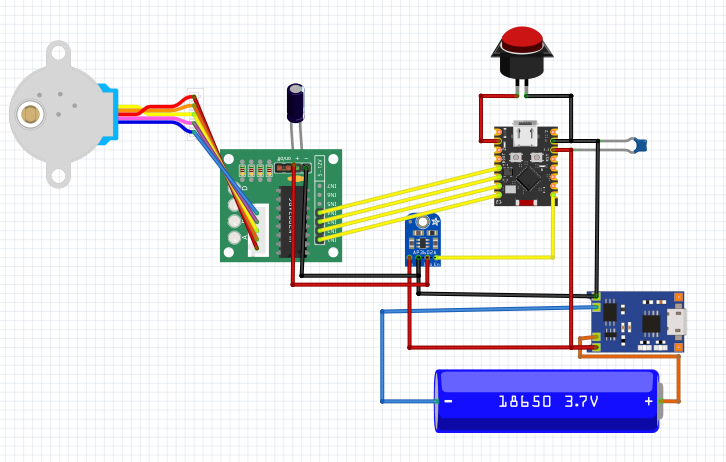
Automatic dry food dispenser. An ESP32-C3 SuperMini drives a 28BYJ-48 stepper motor
through a ULN2003 module, turning a 3D-printed auger screw that dispenses food pellets.
Feeding is triggered by a time schedule or by a physical button press.
The device runs from a single 18650 cell and sleeps between events.
USB cable (the C3 SuperMini uses native USB — port appears as /dev/ttyACM0 on Linux)
Build and flash
Open the CatFeeder/ folder in VS Code (it is the PlatformIO project root).
Select the environment:
c3 — ESP32-C3 SuperMini (production target)
s3 — ESP32-S3 DevKitC-1 (breadboard test; same GPIO numbers)
Click Upload in the PlatformIO toolbar, or run:
bash
pio run -e c3 --target upload
Open the Serial Monitor at 115200 baud:
bash
pio device monitor -e c3
Flash mode on C3 SuperMini: if the board doesn't enter download mode automatically,
hold BOOT (GPIO 9) while pressing RESET, then release RESET.
First-run configuration via Serial console
All configuration is done by typing commands in the PlatformIO Serial Monitor
(line ending: \n or \r\n).
1. Configure Wi-Fi for automatic time sync (one-time setup)
The device has no RTC chip. On every cold boot (power-on after battery removed or
discharged) it connects to Wi-Fi, fetches UTC time from NTP, then immediately
disconnects. Wi-Fi is never used after deep-sleep wakes — only on cold boot.
text
WIFI_SSID MyNetwork
WIFI_PASS mypassword
Credentials are saved to flash and never need to be entered again.
If Wi-Fi is unavailable, the device falls back to manual time entry:
text
SET_TIME 1750420800
Get the current Unix epoch in your terminal:
bash
date +%s
2. Set the feeding schedule
Times are in UTC. Up to 8 entries, space-separated.
text
SCHED 07:00 18:30
The schedule is saved to flash (NVS) and survives power-off.
Between scheduled feeds the device is in deep sleep. It wakes automatically at each
scheduled time, runs the motor, then sleeps until the next entry.
Scheduled feed limits (config.h):
Limit
Default
Description
MAX_PORTIONS_PER_DAY
4
Max scheduled feeds per day; extras are skipped
MIN_INTERVAL_SEC
1800 s
Min gap between scheduled feeds (30 min)
These limits apply only to the schedule. Button press and FEED serial command
are always allowed regardless of how recently the motor ran.
3. Calibrate portion size
Portion size is defined in stepper steps, not time. Calibrate by weighing:
text
CAL 512       ← run motor 512 steps; weigh the dispensed food
CAL 768       ← try a different value
SAVE          ← commit the chosen step count to flash
Repeat CAL until the dispensed amount matches the desired portion weight.
SAVE must be sent explicitly — until then the new value is not persisted.
4. Verify
text
STATUS        ← show time, steps, portionsToday, schedule with next feed countdown
FEED          ← manual feed (no limits)
RESET_DAY     ← zero portionsToday and lastFeedEpoch (for testing)
All Serial commands
Command
Description
WIFI_SSID <ssid>
Save Wi-Fi network name to flash
WIFI_PASS <pass>
Save Wi-Fi password to flash
WIFI_SYNC
Connect and sync time via NTP now
SET_TIME <epoch>
Set wall clock manually (Unix seconds UTC)
SCHED HH:MM [HH:MM ...]
Set feeding schedule (UTC, up to 8 entries)
CAL <steps>
Run motor N steps without counting as a feed
SAVE
Save the last CAL step count to flash
FEED
Dispense one portion (no limits)
STATUS
Print current device state incl. schedule and Wi-Fi SSID
RESET_DAY
Zero portionsToday and lastFeedEpoch
Button behaviour
Press
Action
Short press
Dispense one portion
Double click (gap < 300 ms)
Dispense two portions
Long press ≥ 2 s
Enter deep sleep immediately without feeding
Power notes
The device enters deep sleep between feeds. Wake sources: button or RTC timer.
The 5 V motor rail (boost converter) is switched on only during a dose, then cut.
Always-on current in deep sleep: ~50–100 µA (ESP32-C3 + LDO quiescent).
Expected battery life on 3000 mAh 18650 with 4 feeds/day: several months.
11 parts, built around the TP4056. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
Where can I download the CatFeeder KiCad files?
From the 12romis/CatFeeder repository on GitHub, at the commit this page was made from: the board is schema/KiCad/CatFeeder.kicad_pcb and its schematic schema/KiCad/CatFeeder.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Can I use the CatFeeder design in my own project?
Its repository states no licence, so its author keeps all rights: ask 12romis before reusing the design.
The Smart Plant is a board that can be plugged directly on the soil, close to the plant, that allows the measurement of the environment (soil moisture, environment temperature & illuminance), and presents the…