This thesis addresses the critical need for efficient data management and operational control in fixed-wing UAVs, targeting the gaps in current commercial flight controllers.
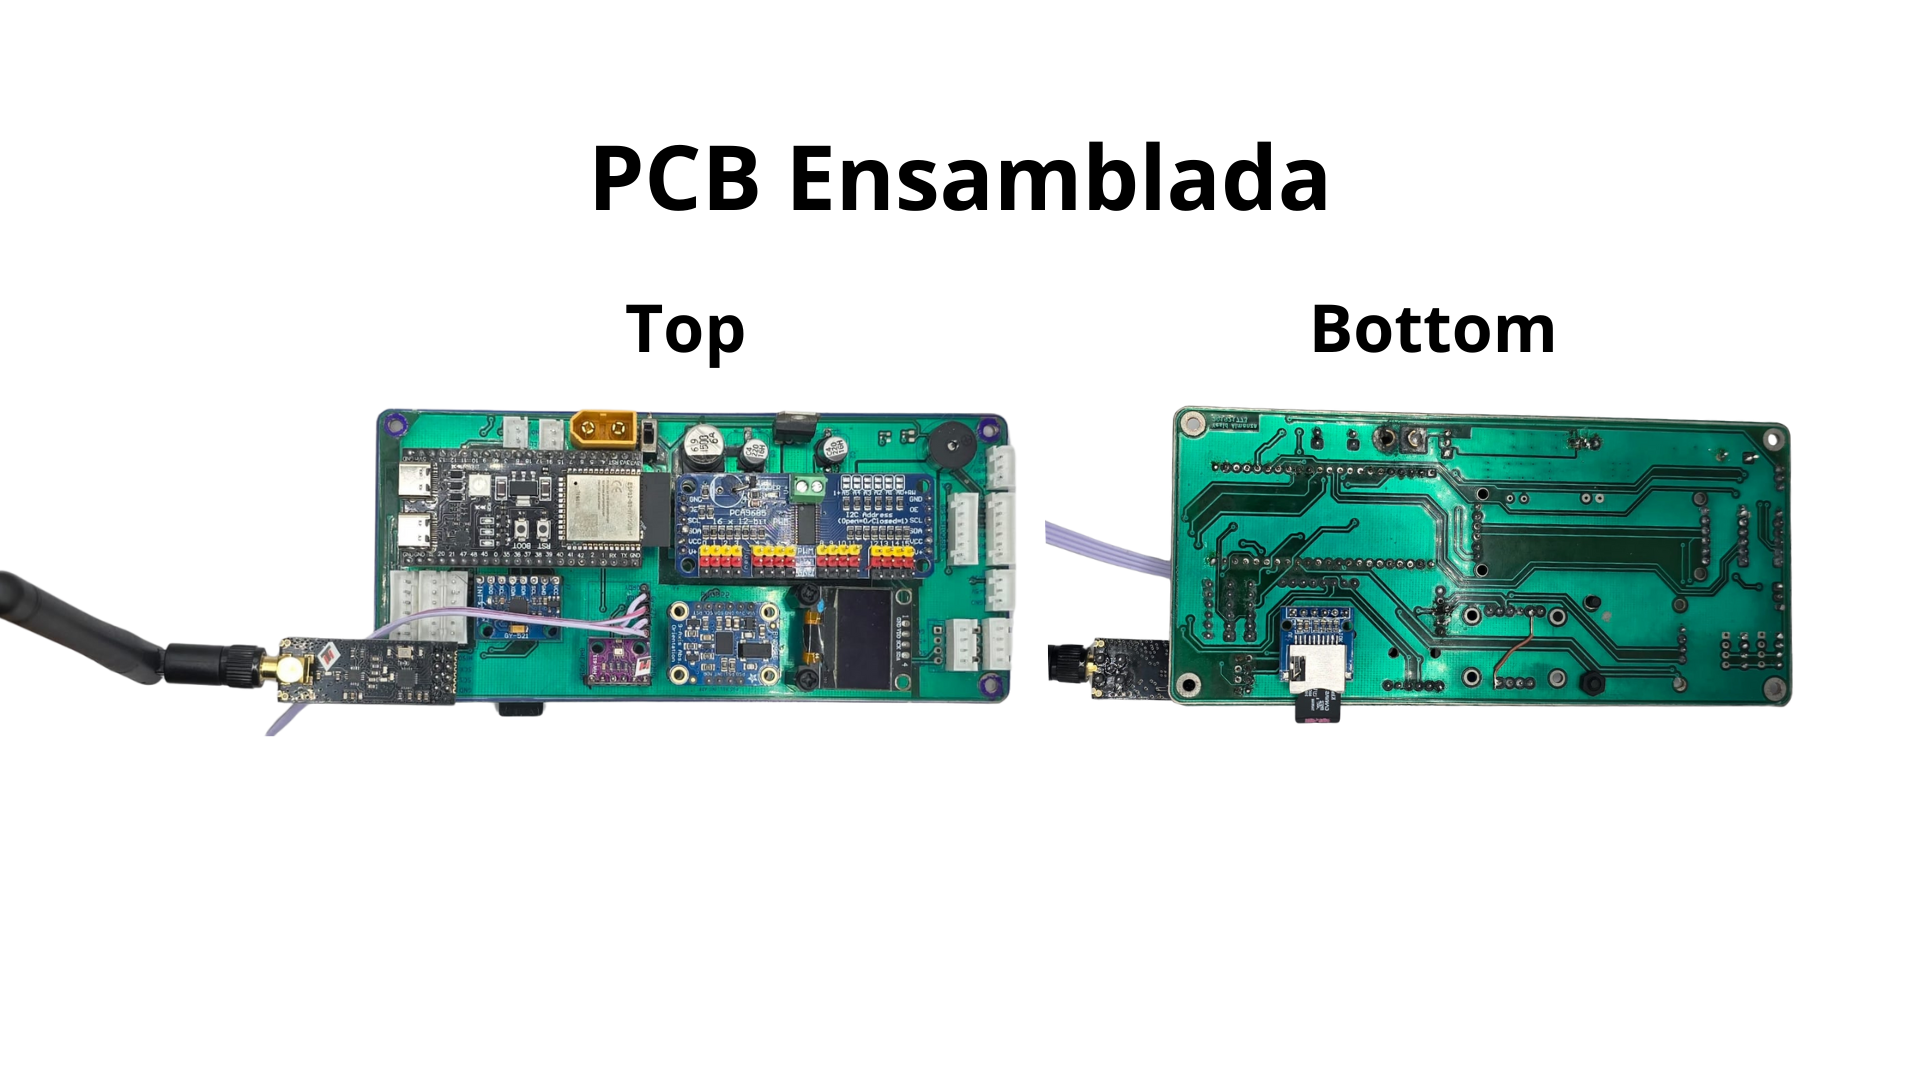
DELTA 1.0 is an open-source printed circuit board by YesidAlmanzaGamba, from the YesidAlmanzaGamba/Thesis-Flight-Controller-Fixed-Wing repository on GitHub. It is a 2-layer board of 156.4 × 71.6 mm with 39 parts on 54 nets, routed with 339 tracks and 26 vias.
It is built around the V7805-1000, PCA9685PW and BNO055, with the XT60-M among its other parts. Its parts include 10 connectors, 4 resistors, 4 diodes, 3 capacitors and 2 ICs. It belongs with the ESP32 boards of this library.
Flight Controller and Ground Control Station for a Fixed-Wing UAV
Bachelor's thesis (Proyecto de Grado), Electronic Engineering, Universidad de los Andes
Author: Yesid Camilo Almanza Gamba · Advisor: Prof. Alba Ávila Bernal
This project covers the design, build and flight testing of a custom flight controller for fixed-wing UAVs based on the ESP32-S3 (replacing the usual STM32 architecture), along with a desktop ground control station (GCS) that shows telemetry in real time and reconstructs the flight path from GPS and altitude data.
Video
Features
Custom PCB (KiCad) built around the ESP32-S3 DevKitC-1, with a 3D-printed enclosure.
Sensor suite: BNO055 and MPU6050 IMUs, BMP280 barometer, MS4525 differential-pressure airspeed sensor, NEO-6M GPS and HMC5883L magnetometer.
Actuation: PCA9685 16-channel PWM driver for servos and ESC, driven by a FlySky receiver over iBus/PPM.
Telemetry link: nRF24L01 2.4 GHz radio from the aircraft to a ground receiver.
Onboard logging: flight data is written to a microSD card.
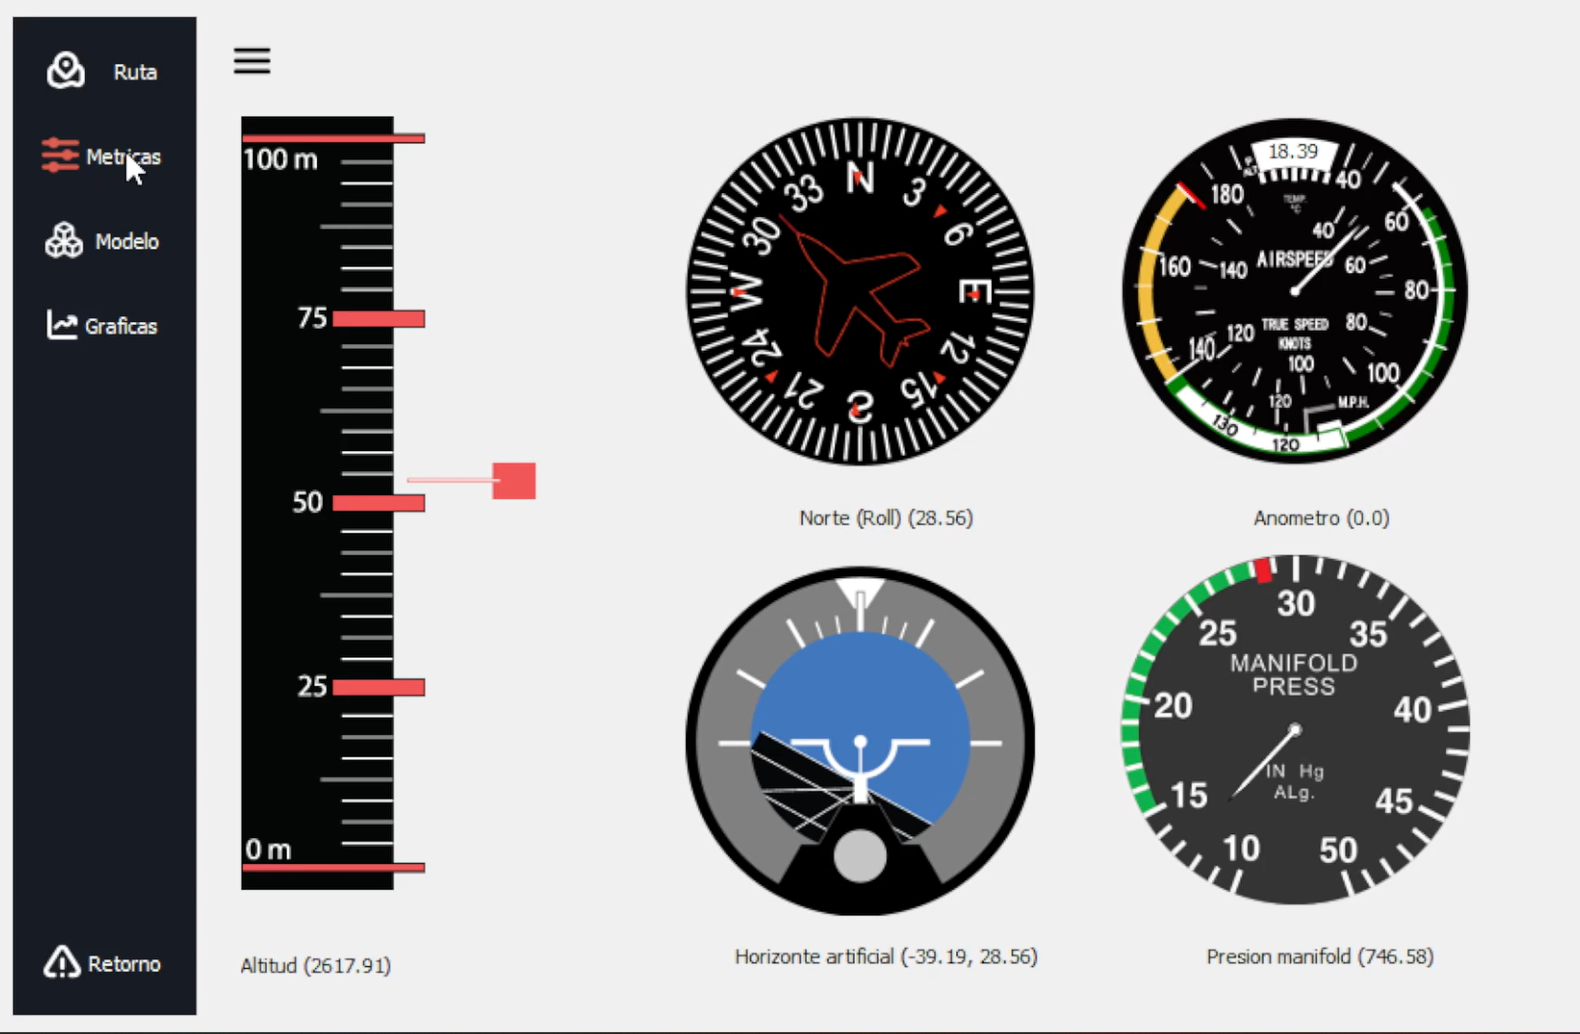
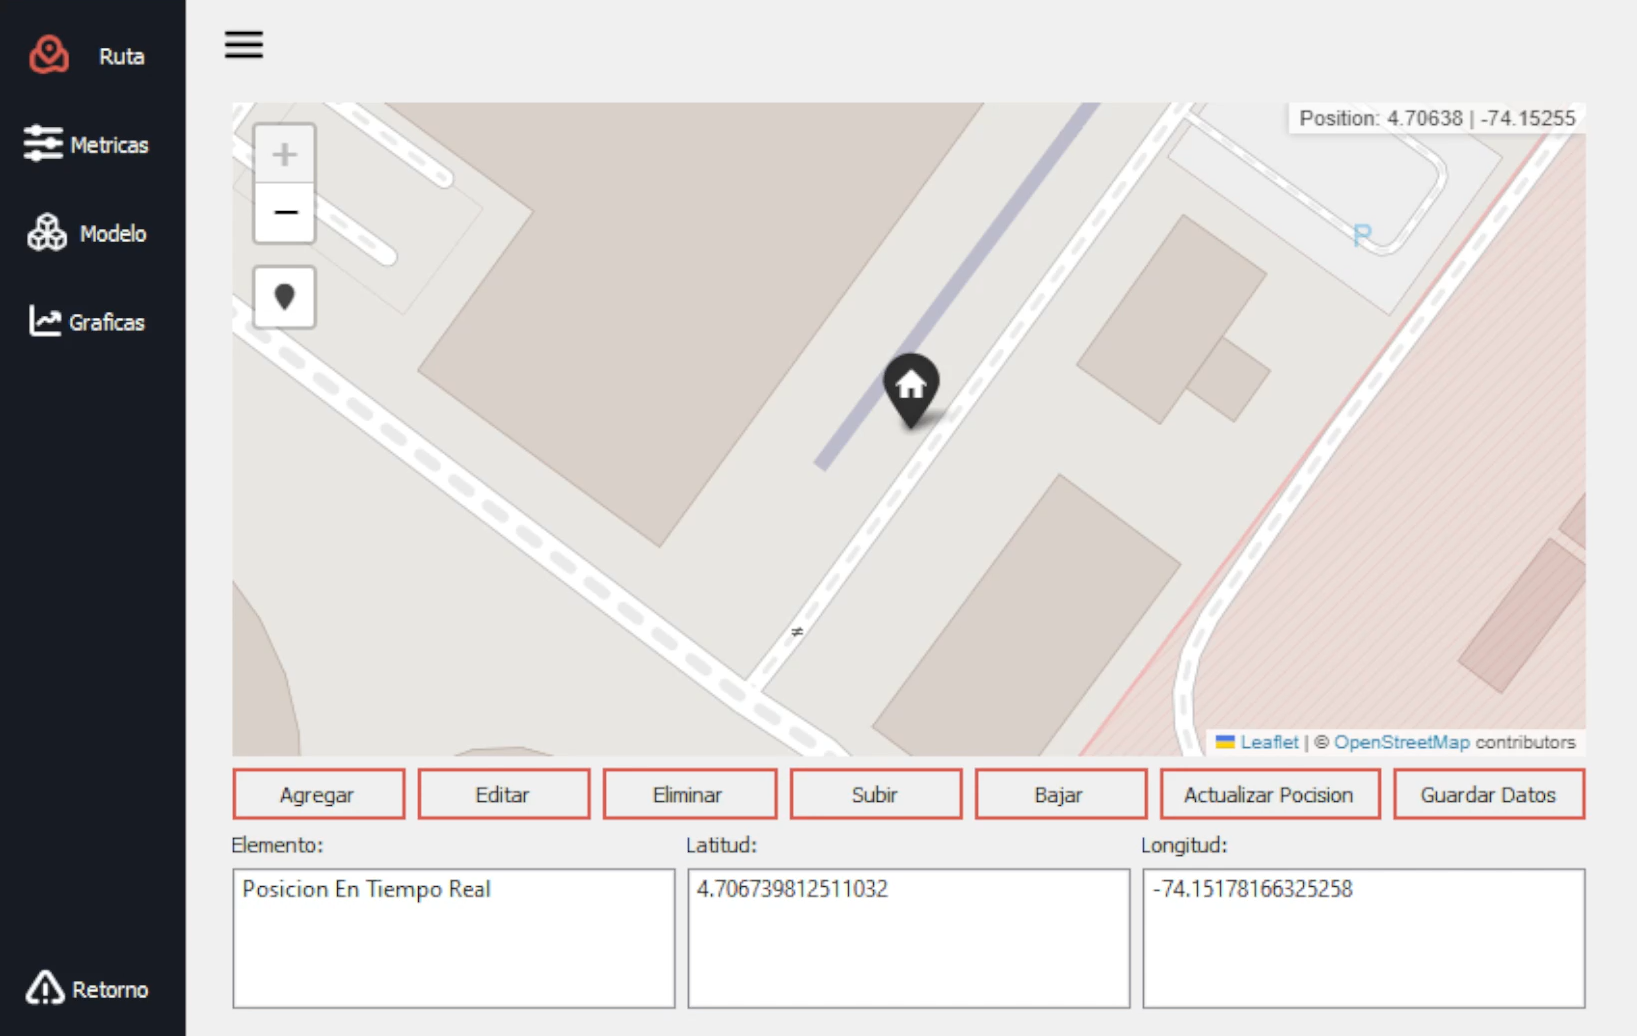
Ground control station (Python + PyQt5): artificial horizon, heading, 3D aircraft model, live plots, a live map (Folium) and data export to JSON/CSV.
Post-flight analysis scripts that produce plots and 2D/3D trajectory maps from logged flights.
Onboard flight-controller program (see Building the firmware)
src/recepcion.cpp
Ground receiver program (nRF24 → serial / SD)
src/archivosDePrueba/
Standalone test sketches for individual sensors
src/interfazWave/
Ground control station (Python / PyQt5)
test/graphs_files/
Post-flight analysis and plotting scripts
flight_tests/
Raw flight logs (CSV/JSON), generated plots and HTML maps
PCB/
KiCad projects (Delta 1.0, Delta 2.0), footprints, symbols, 3D models and fabrication outputs
Documento/
LaTeX source of the thesis plus the compiled PDF
Getting started
Building the firmware
Requirements: PlatformIO (VS Code extension or CLI). Library dependencies are listed in platformio.ini and download automatically on the first build.
PlatformIO compiles every .cpp file in src/, so only one program with setup()/loop() can be active at a time. The inactive ones are stored as .txt:
Ground receiver (default): src/recepcion.cpp is active.
Flight controller: rename src/recepcion.cpp → recepcion.txt and src/main.txt → main.cpp.
bash
# set upload_port in platformio.ini to your board's port first (COM10 by default)
pio run -t upload
pio device monitor     # 115200 baud
Running the ground control station
Requirements: Python 3.9+.
bash
cd src/interfazWave
pip install -r requirements.txt
python main.py         # pick the receiver's serial port, then the main window opens
Run it from inside src/interfazWave/, because the app loads images and saves data (datosGuardados/) through relative paths.
Analysing flight data
The scripts in test/graphs_files/ read the CSV logs in flight_tests/ and generate the plots and Folium maps stored there. They use pandas, matplotlib, numpy, scipy and folium.
Thesis document
The thesis (in Spanish, with an English abstract) is in Documento/. To rebuild it from source:
The controller was integrated into a real fixed-wing aircraft and flown. Orientation, altitude, pressure, temperature and GPS position were sent to the ground station, shown in real time and stored for later analysis. The flight tests showed some data loss and corruption over the nRF24L01 link (mostly altitude and pressure). The proposed next steps are:
A higher-bandwidth radio together with a protocol such as MAVLink for packet integrity.
A serial buffer in the GCS for smoother real-time display.
Merging all modules onto a single PCB with improved power regulation and protection.
See chapters Resultados and Conclusiones of the thesis for details.
Citation
bibtex
@thesis{almanza2024flightcontroller,
  author = {Almanza Gamba, Yesid Camilo},
  title  = {Desarrollo e implementación de un controlador de vuelo y estación de control de tierra para un UAV de ala fija},
  school = {Universidad de los Andes},
  type   = {Bachelor's thesis},
  year   = {2024}
}
Acknowledgements
Thanks to Prof. Alba Ávila Bernal for advising this project, and to @simonpine for contributions to the firmware and the GCS.
This thesis addresses the critical need for efficient data management and operational control in fixed-wing UAVs, targeting the gaps in current commercial flight controllers.
This thesis addresses the critical need for efficient data management and operational control in fixed-wing UAVs, targeting the gaps in current commercial flight controllers.
Complete flight control system designed from scratch. Hardware designed with KiCad.
215 parts1kBSD-3-Clause
Questions
How big is the DELTA 1.0 PCB?
It measures 156.4 × 71.6 mm and has 2 copper layers, 1.6 mm thick.
What parts does the DELTA 1.0 use?
39 parts, built around the V7805-1000, PCA9685PW, BNO055 and XT60-M. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
Where can I download the DELTA 1.0 KiCad files?
From the YesidAlmanzaGamba/Thesis-Flight-Controller-Fixed-Wing repository on GitHub, at the commit this page was made from: the board is src/pcb/DELTA 1.0/C1/C1.kicad_pcb and its schematic PCB/Delta 1.0/C1.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Can I use the DELTA 1.0 design in my own project?
Its repository states no licence, so its author keeps all rights: ask YesidAlmanzaGamba before reusing the design.