
2 layers40.6 × 110 mm
Europi surface mount
Allen-Synthesis/EuroPi
EuroPi: A reprogrammable Eurorack module based on the Raspberry Pi Pico
92 parts584CC0-1.0

 wojtekbab/self_balancing_robot
Master's thesis project 2024
Esp mpu6050 lis3mdl is an open-source printed circuit board by wojtekbab, from the wojtekbab/self_balancing_robot repository on GitHub. It is a 2-layer board of 109.2 × 48.3 mm with 18 parts on 44 nets, routed with 120 tracks and 0 vias.
It is built around the L7805. Its parts include 7 connectors, 3 ICs, 2 capacitors and 1 switch. It belongs with the ESP32 boards of this library.
Repository contains code for microcontroller ESP-32 with implemented control system with LQR regulator. Microcontroller connects to local network and acts like a web server, providing GUI on website to control vehicle. Matlab scripts were used to calculate mathematical model and simulink system was designed to veryficate close loop system.
Code was written in PlatformIO extension with arduino framework. FreeRTOS was used with hardware interrupts and tasks for:
main.cpp: main file for the ESP32.defines.cpp: file with defines.globals.cpp: file with global variables used by tasks.interrupts.cpp: interrupts service routines.utilities.cpp: some utility functions.tasks.cpp: file with FreeRTOS tasks.web_server.cpp: web server with html page.platformio.ini: configuration file used by PlatformIO extension.platformio.ini file into project.The MATLAB code is used to calculate mathematical model and simulate system.
s1_parameters.m: script with system parameters.s2_mathematical_model.m: script for calculate unlinear and linear model as state-space matrixes.sim1_unlinear_model_with_LQR.slx: simulink close loop system with LQR regulators2_mathematical_model.m to load parameters and calculate K matrix.sim1_unlinear_model_with_LQR.slx to test system output for given reference velocities or different initial state.In case when Matlab is not available, all necessary scripts were translated for python.
requirements.txt: contain all necessary python modules.parameters.py: contain dictionary with system parameters.p1_mathematical_model.ipynb: notebook for symbolic equations with sympy to obtain mathematical model.p2_closed_loop_system.ipynb: notebook to make simulations with closed loop system with LQR regulatorp1_mathematical_model.ipynb to obtain mathematical model.p2_closed_loop_system.ipynb to see result of system simulations.Image from Inventor project was included to repository. 3D model was created to design distribution of elements and to calculate parameters of vehicle inertia.
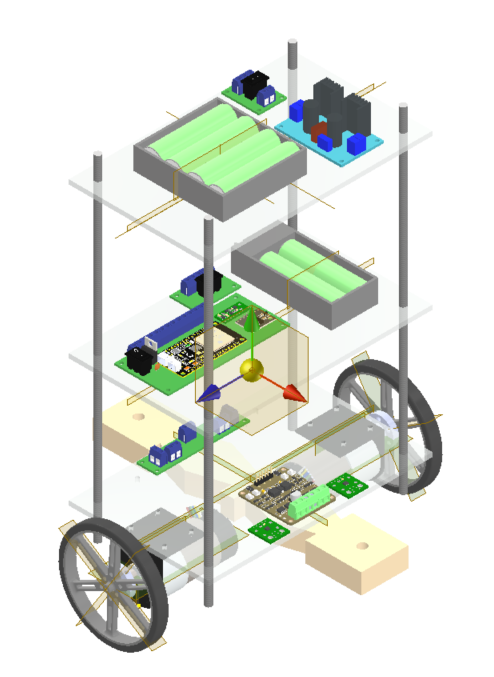
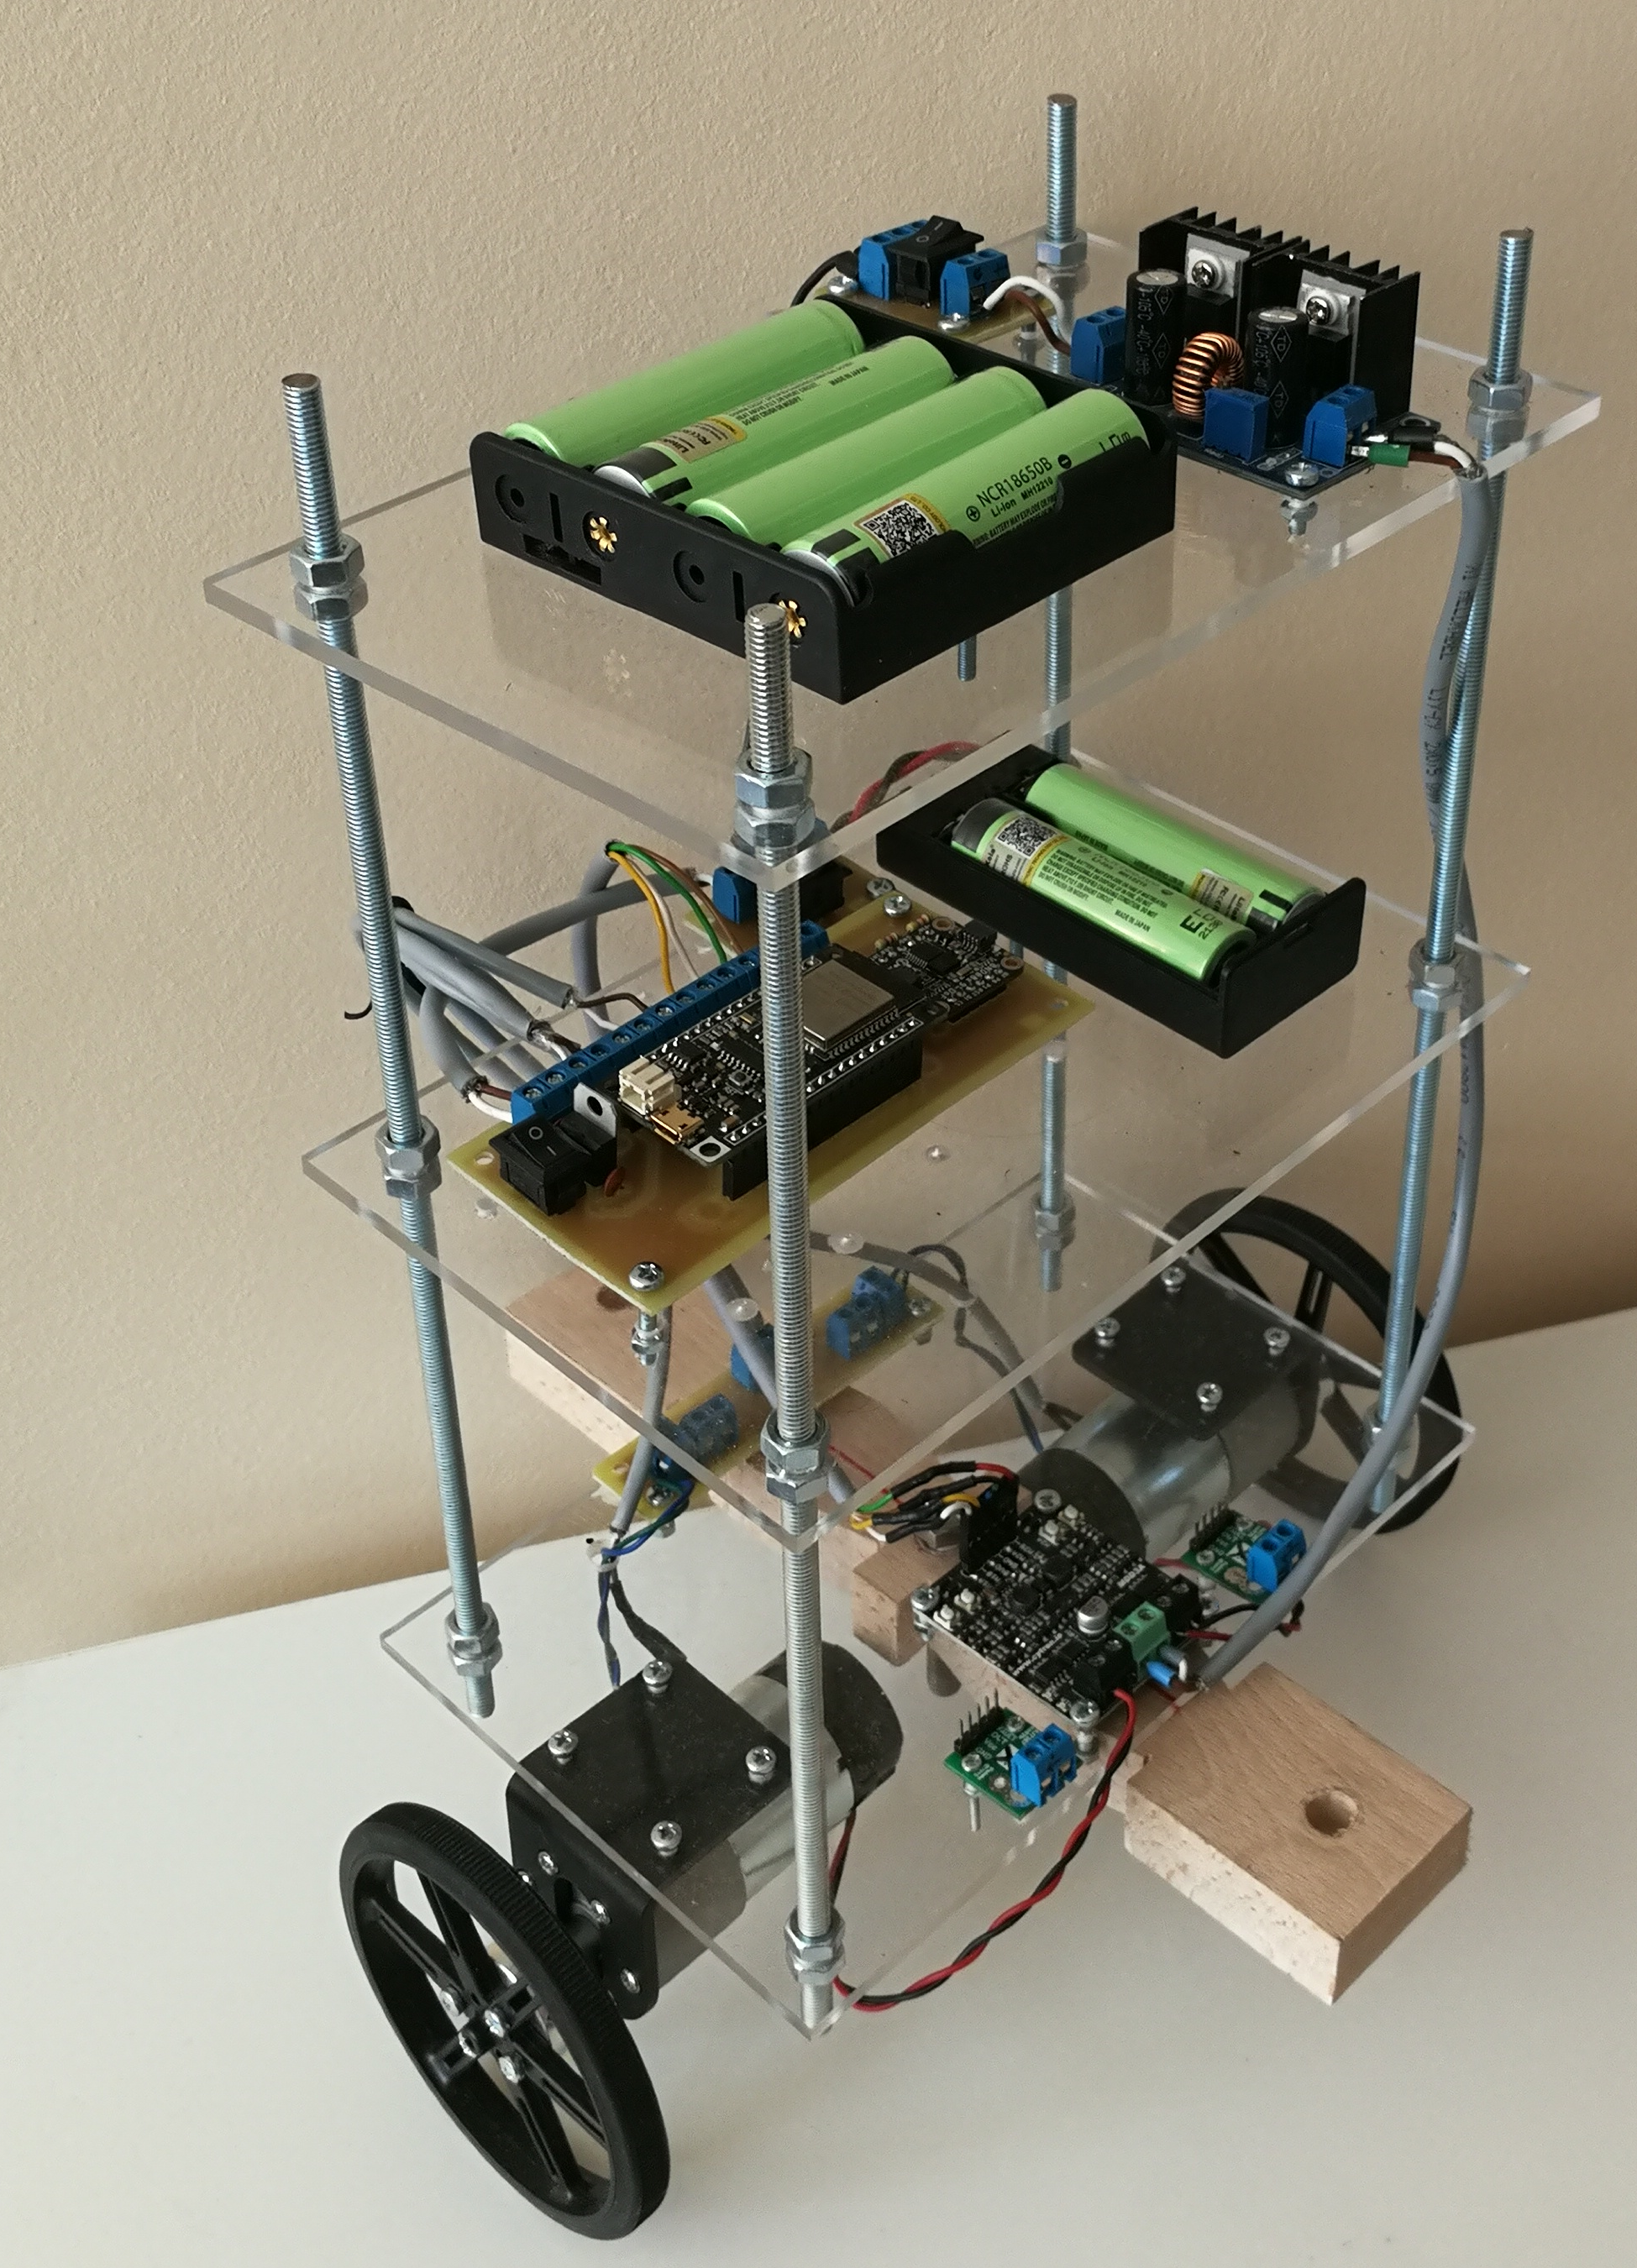
Figure 1: 3D model from Autodesk Inventor and real model.
Images from KiCad project was included to repository. PCB board was created for electronic parts from system to avoid EMI interferences from DC motors.
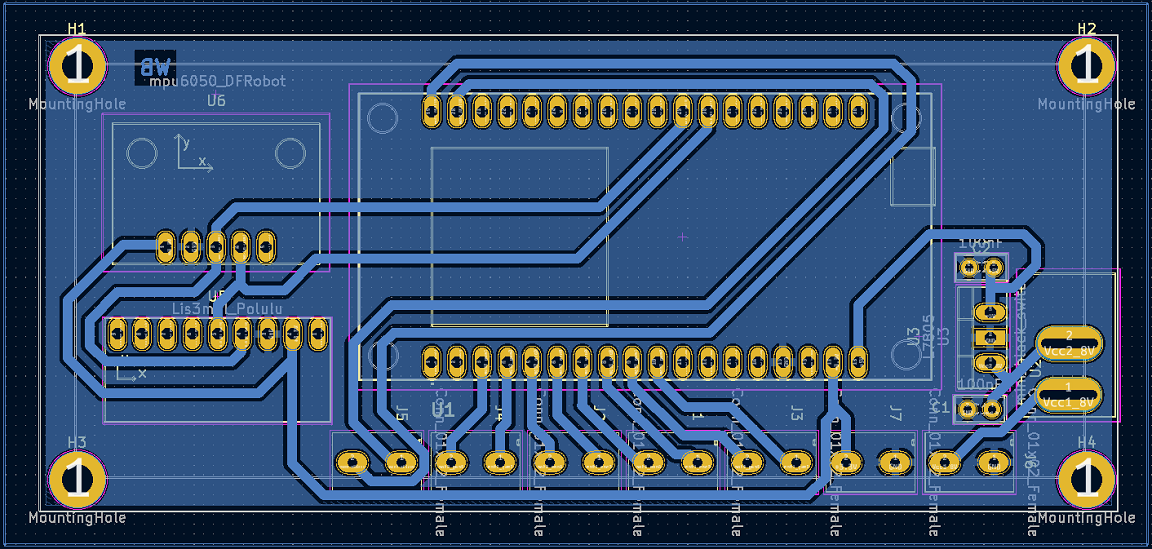
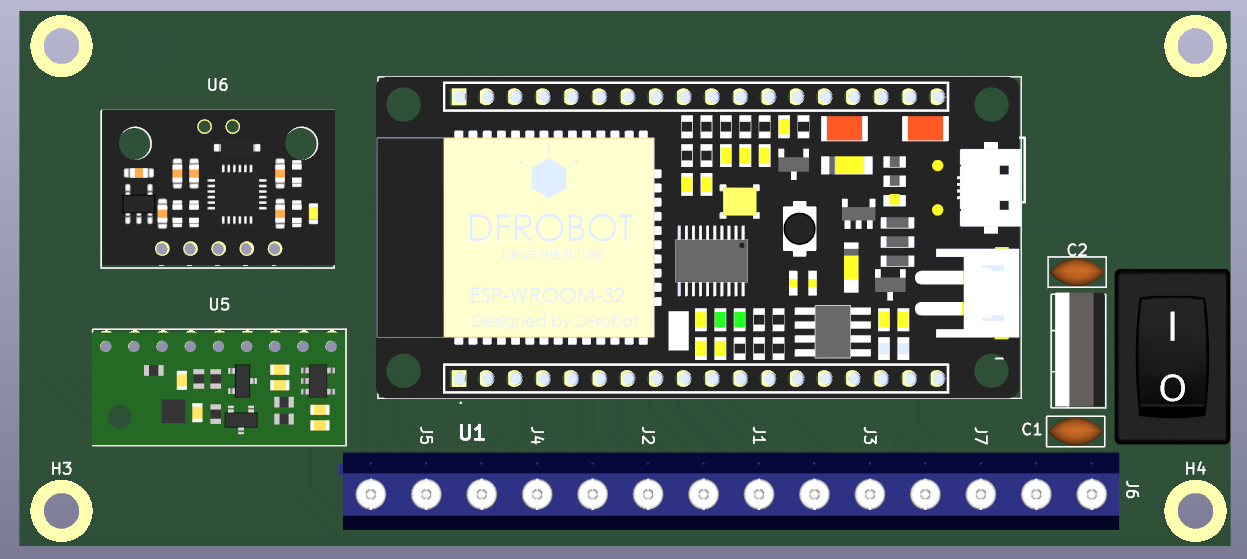
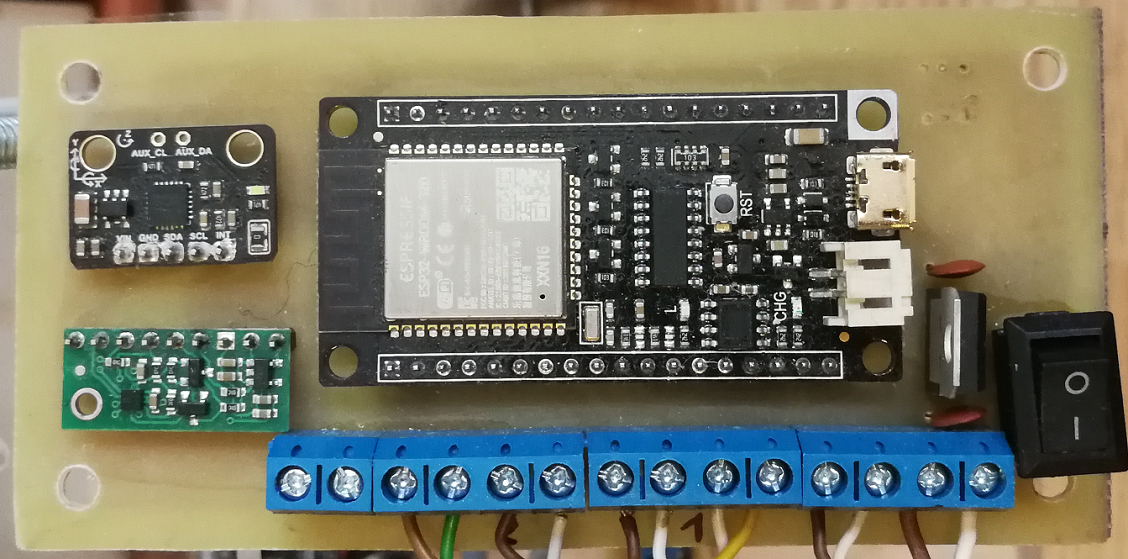
Figure 2: designed paths, visualization, home made board
Link to demo video: https://www.youtube.com/watch?v=7iqSqyg-NeA
| Qty | Value | Footprint | References |
|---|---|---|---|
| 7 | Conn_01x02_Female | MojaBibliotekaFootPrint1:zlacze ARK_2 | J1, J2, J3, J4, J5, J6, J7 |
| 4 | MountingHole | MountingHole:MountingHole_3.2mm_M3_DIN965_Pad | H1, H2, H3, H4 |
| 2 | 100nF | Capacitor_THT:C_Disc_D5.0mm_W2.5mm_P2.50mm | C1, C2 |
| 1 | ESP32-Firebeetle | MojaBibliotekaFootPrint1:FIREBEETLE_ESP32 | E1 |
| 1 | L7805 | MojaBibliotekaFootPrint1:LM78xx | U3 |
| 1 | Lis3mdl_Polulu | MojaBibliotekaFootPrint1:lis3mdl_Pololu | U5 |
| 1 | Toggle_switch | MojaBibliotekaFootPrint1:mini_black_switch | S1 |
| 1 | mpu6050_DFRobot | MojaBibliotekaFootPrint1:mpu6050_DFRobot | U6 |
Allen-Synthesis/EuroPi
EuroPi: A reprogrammable Eurorack module based on the Raspberry Pi Pico

peterheinrich/InternetOverSpaghetti
Transmitting IP packages over a pair of spaghetti thus demonstrating how media independent IP really is.


Tircown/ERCF-easy-brd
More informations on how to reset for flashing:\ https://wiki.seeedstudio.com/Seeeduino-XIAO/#enter-bootloader-mode

matthewcieplak/super-sixteen
Code and schematics for the Super Sixteen Eurorack sequencer

NikodemBartnik/Mini-Mars-Rover
Educational robotic platform made to look like a mini mars rover

starlightk7/OpenSFC
OSHW Reproduction Parts related to the Super Famicom / Super Nintendo game console

Redherring32/OpenTendo-TopLoader
An Open Source HardWare (OSHW) recreation of the 1993 toploading NES motherboard (Also known as NES-101)
It measures 109.2 × 48.3 mm and has 2 copper layers, 1.6 mm thick.
18 parts, built around the L7805. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the wojtekbab/self_balancing_robot repository on GitHub, at the commit this page was made from: the board is pcb_kicad/esp_mpu6050_lis3mdl.kicad_pcb and its schematic pcb_kicad/esp_mpu6050_lis3mdl.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask wojtekbab before reusing the design.