
2 layers116.8 × 30 mm
Type d
google/mozc-devices
Circuit diagrams and firmware source code for Gboard DIY keyboards
14 parts3kApache-2.0

Autonomous Ground Vehicles Self-Guided Formation Control
Omni DC is an open-source printed circuit board by warrenbocphet, from the warrenbocphet/TriOmniwheel-Formation-Control repository on GitHub. It is a 2-layer board of 87 × 101.6 mm with 14 parts on 131 nets, routed with 265 tracks and 9 vias.
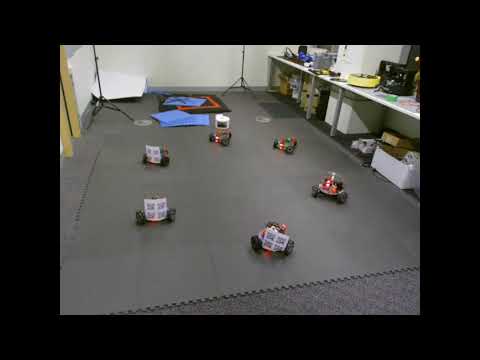
This project developed by students in the University of Adelaide during the Summer Research project 2018-2019, which developed a 3WD rover platform for autonomous multi-agent systems.
The distributed system will contain multiple agents. Each agent can make its own decision. However, the four agents still need to communicate with each other about the velocity, the current position, the destination and the angle of the agent. This allows an agreement to be made to achieve the desired formation.
Motor: 251RPM DC geared (43.7:1) motor w/ ecoder.
Encoder: 64 resolution => 2797 count per rotation.
Control board: Arduino Due for controlling, Arduino MKR1000 for WiFi communication.
Real data feedback and put into simulation

Real demo. Noticed how the position of the rovers and the feedback position is not entirely the same. Overtime, the system introduce more and more error. Since the system is self guidance, there's no correction during performance.

Generate path to form a triangle formation. Connected circle represent rover with radius, dash circle represent the safety distance (collision avoicedance is not implement in the GIF below).

The same triangle formation with different starting position. Noticed how the formation is rotated with these starting positions. The algorithm [1] does not try to get to a specific coordinate but rather a formation (i.e, a triangle, circle or any arbitrary topology).

The collision avoidance will be explained further down, let's first have a look at the simulation and the result:


[1] Fathian, Kaveh & Safaoui, Sleiman & Summers, Tyler & Gans, Nicholas. (2018). Robust Distributed Planar Formation Control for Higher-Order Holonomic and Nonholonomic Agents. Link: https://www.researchgate.net/publication/326696917_Robust_Distributed_Planar_Formation_Control_for_Higher-Order_Holonomic_and_Nonholonomic_Agents
The author's website: https://sites.google.com/view/kavehfathian/home?authuser=0
| Qty | Value | Footprint | References |
|---|---|---|---|
| 1 | 12V input | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J8 |
| 1 | Arduino_Due_Shield | Arduino (Alarm Silent Github):Arduino_Due_Shield | XA1 |
| 1 | Conn to Driver 1 | Connector_PinHeader_2.54mm:PinHeader_1x08_P2.54mm_Vertical | J5 |
| 1 | Conn to Driver0 | Connector_PinHeader_2.54mm:PinHeader_1x08_P2.54mm_Vertical | J3 |
| 1 | Header_MKR_left | Connector_PinHeader_2.54mm:PinHeader_1x14_P2.54mm_Vertical | J2 |
| 1 | Header_MKR_right | Connector_PinHeader_2.54mm:PinHeader_1x14_P2.54mm_Vertical | J4 |
| 1 | MKR_1010 | MKR1010:MKR_1010 | J1 |
| 1 | Motor_conn0 | Connector_PinHeader_2.54mm:PinHeader_2x03_P2.54mm_Vertical | J6 |
| 1 | Motor_conn1 | Connector_PinHeader_2.54mm:PinHeader_2x03_P2.54mm_Vertical | J13 |
| 1 | Motor_conn2 | Connector_PinHeader_2.54mm:PinHeader_2x03_P2.54mm_Vertical | J15 |
| 1 | Plus_minus 0 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J7 |
| 1 | Plus_minus 1 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J14 |
| 1 | Plus_minus 2 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J16 |
| 1 | Polulu Voltage Regulator | Connector_PinHeader_2.54mm:PinHeader_1x05_P2.54mm_Vertical | J9 |
google/mozc-devices
Circuit diagrams and firmware source code for Gboard DIY keyboards


hackclub/OnBoard
💡 Join 1,000 teenagers and make your first PCB with a $100 grant!


Twotoz/C5VRX
Ultra-minimal, zero-CPU 5.8 GHz analog FPV video receiver using ESP32-C5 Wi-Fi 6 PHY MODEM_DIAG, BitScrambler WBFM demodulation & resistor DAC CVBS


It measures 87 × 101.6 mm and has 2 copper layers, 1.6 mm thick.
14 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the warrenbocphet/TriOmniwheel-Formation-Control repository on GitHub, at the commit this page was made from: the board is Omni_DC_PCB/Omni_DC.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask warrenbocphet before reusing the design.