
0
Vigia board v1
VortexJer/AISight
Design and review tools built for AI agents: 3D CAD, PCB, shaders, textures, and animation — code in, renders + machine-readable reports out.
8 parts10MIT
 VortexJer/AISight10
Design and review tools built for AI agents: 3D CAD, PCB, shaders, textures, and animation — code in, renders + machine-readable reports out.
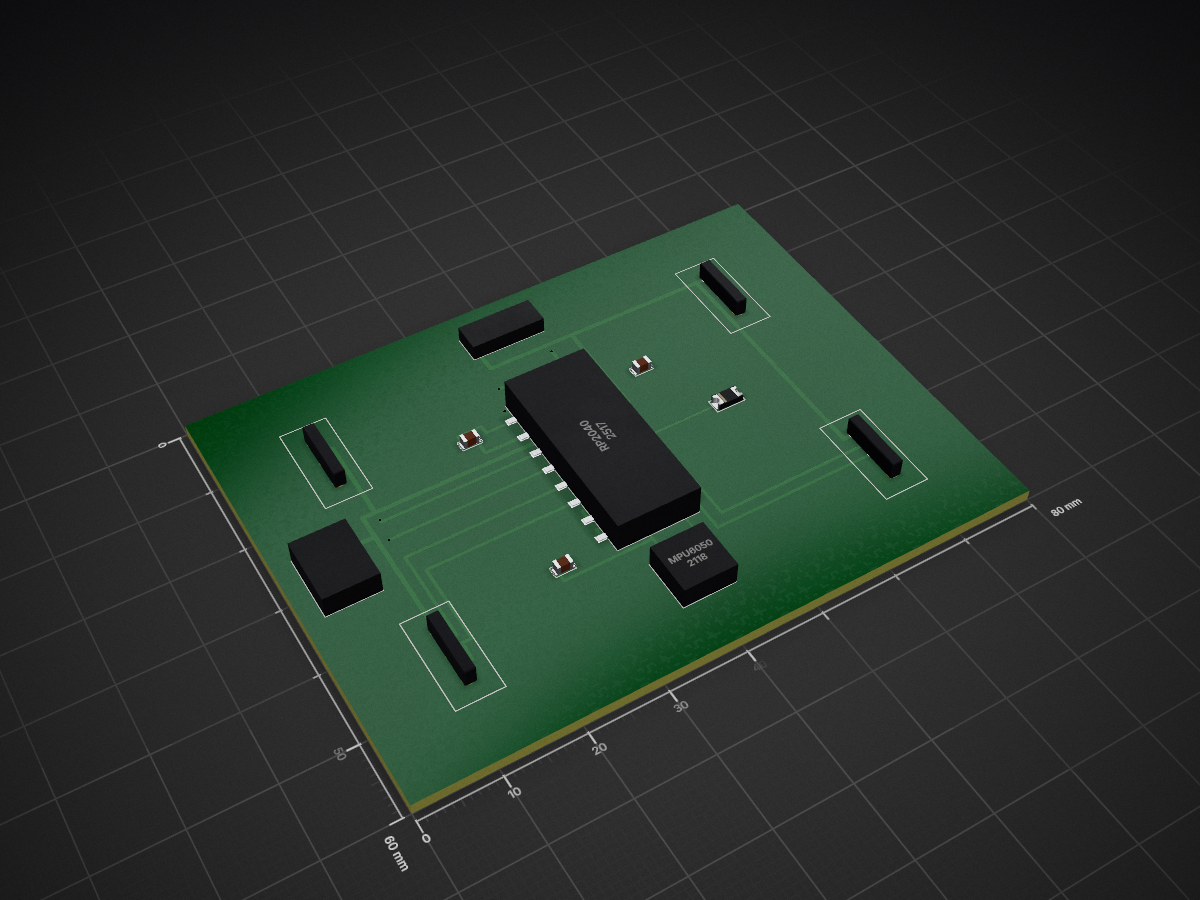
Rover clean is an open-source printed circuit board by VortexJer, from the VortexJer/AISight repository on GitHub, published under the MIT licence. It is a board of 80 × 60 mm with 12 parts on 14 nets, routed with 113 tracks and 27 vias.
It is built around the RP2040. Its parts include 6 connectors, 3 capacitors, 2 ICs and 1 diode. It belongs with the robots and motor control boards and the RP2040 boards of this library.
The complex example: a real rover board — MCU (RP2040), IMU (MPU6050), four motor connectors, a battery entry, a USB-C data pair, a status LED, three decoupling caps — 14 nets, 13 components. Built twice, the way solidsight's engine block is:
rover_blind.kicad_pcb is routed the way a fresh agent would with
only the netlist and no way to SEE the copper: short diagonals laid
between pads it cannot tell are in the way. It ships the defects that
come from being blind.rover_clean.kicad_pcb is the same board taken to zero
findings — routed by a real 2-layer maze router that reads each
pad's actual position from pcbsight and keeps a clearance halo around
everything it lays down.python make_rover.py
pcbsight inspect rover_blind.kicad_pcb # FAILED
pcbsight inspect rover_clean.kicad_pcb # OK
pcbsight diff rover_blind.kicad_pcb rover_clean.kicad_pcb
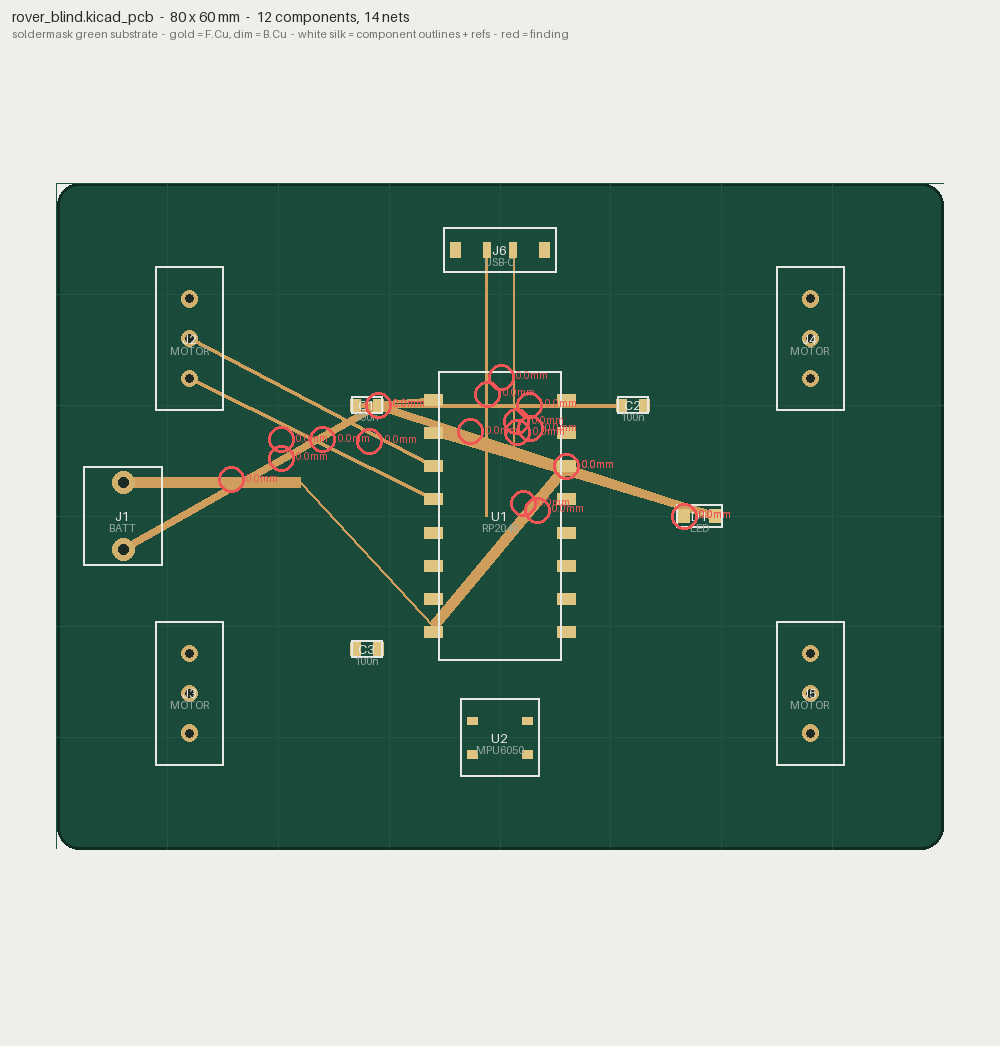
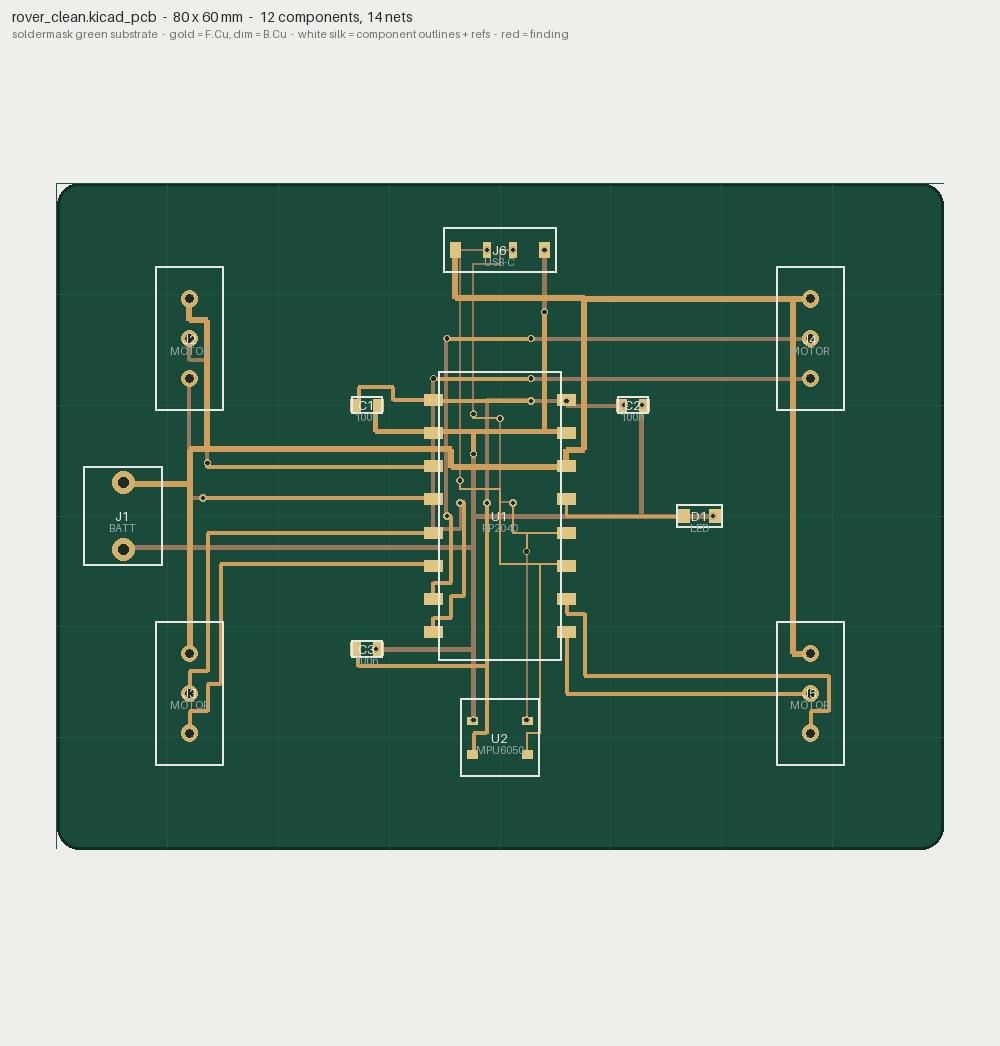
left: routed blind — diagonals crossing pads, findings circled in red, three motors and the IMU never reached. right: a clean 2-layer route, every net closed. Same components, same nets.
The blind board is not a strawman — it is exactly what routing without sight produces: 12 of 14 nets left open, 26 clearance violations, the USB pair swapped and unmatched, the battery rail necked to 0.25 mm. None of it is visible as "wrong" without measuring the copper.
pcbsight diff rover_blind.kicad_pcb rover_clean.kicad_pcb
  tracks: 12 -> 113          vias: 0 -> 27
  net 'GND':    6 island(s) -> 1
  net 'USB_DP': 4 island(s) -> 1
  net 'USB_DM': 4 island(s) -> 1
  net 'M2_A' .. 'M4_B':      2 island(s) -> 1   (each motor pair reached)
  clearance findings: 26 -> 0
... every net-open and clearance finding GONEEvery component carries its silkscreen body, reference (U1, J2, D1...) and value (RP2040, MOTOR, LED...); the substrate is the real Edge.Cuts outline; gold is the front copper, dim gold the back. That is the point of the render overhaul — a PCB review has to look like a PCB, or the findings float in the void.
The clean side is genuinely routed, not decorated: _router.py is a
small Lee/BFS maze router (two layers, vias, a clearance halo) so the
"after" is a board that actually connects — the same standard the
family holds everywhere: the fixed reference must really be fixed.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 1 | 100n | ex:C1 | C1 |
| 1 | 100n | ex:C3 | C3 |
| 1 | 100n | ex:C2 | C2 |
| 1 | BATT | ex:J1 | J1 |
| 1 | LED | ex:D1 | D1 |
| 1 | MOTOR | ex:J5 | J5 |
| 1 | MOTOR | ex:J3 | J3 |
| 1 | MOTOR | ex:J4 | J4 |
| 1 | MOTOR | ex:J2 | J2 |
| 1 | MPU6050 | ex:U2 | U2 |
| 1 | RP2040 | ex:U1 | U1 |
| 1 | USB-C | ex:J6 | J6 |
It measures 80 × 60 mm.
12 parts, built around the RP2040. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the VortexJer/AISight repository on GitHub, at the commit this page was made from: the board is pcbsight/examples/02-rover/rover_clean.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
VortexJer/AISight
Design and review tools built for AI agents: 3D CAD, PCB, shaders, textures, and animation — code in, renders + machine-readable reports out.

VortexJer/AISight
Design and review tools built for AI agents: 3D CAD, PCB, shaders, textures, and animation — code in, renders + machine-readable reports out.


Fr4nkFletcher/ESP32-Marauder-Cheap-Yellow-Display
ESP32Marauder Cheap Yellow Display


shanteacontrols/OpenDeck
A platform for building interactive control and sensing devices using MIDI and OSC built with Zephyr RTOS.


polpo/picogus
Emulation of ISA sound cards and CD-ROM on Raspberry Pi Pico (GUS, SB/Adlib, MPU-401, Tandy, CMS, Panasonic CD-ROM) with USB mouse/joystick support
