2 layers150 × 97 mm
InversorPMSM
VectorLabsTechnology/Pegasus-Motor-Controller
Projeto de um inversor para um motor PMSM com FOC
229 parts2MIT

 VectorLabsTechnology/Pegasus-Motor-Controller2
Projeto de um inversor para um motor PMSM com FOC
MCU Comms Control is an open-source printed circuit board by VectorLabsTechnology, from the VectorLabsTechnology/Pegasus-Motor-Controller repository on GitHub, published under the MIT licence. It is a 4-layer board of 72.1 × 97 mm with 62 parts on 76 nets, routed with 493 tracks and 111 vias.
It is built around the SN65HVD230D, W25Q128JVSIQ and AMS1117-3.3, with the EL817, L7805 and SRV05-4 among its other parts. Its parts include 16 capacitors, 11 resistors, 8 diodes, 7 ICs and 7 connectors. It belongs with the robots and motor control boards and the STM32 boards of this library.


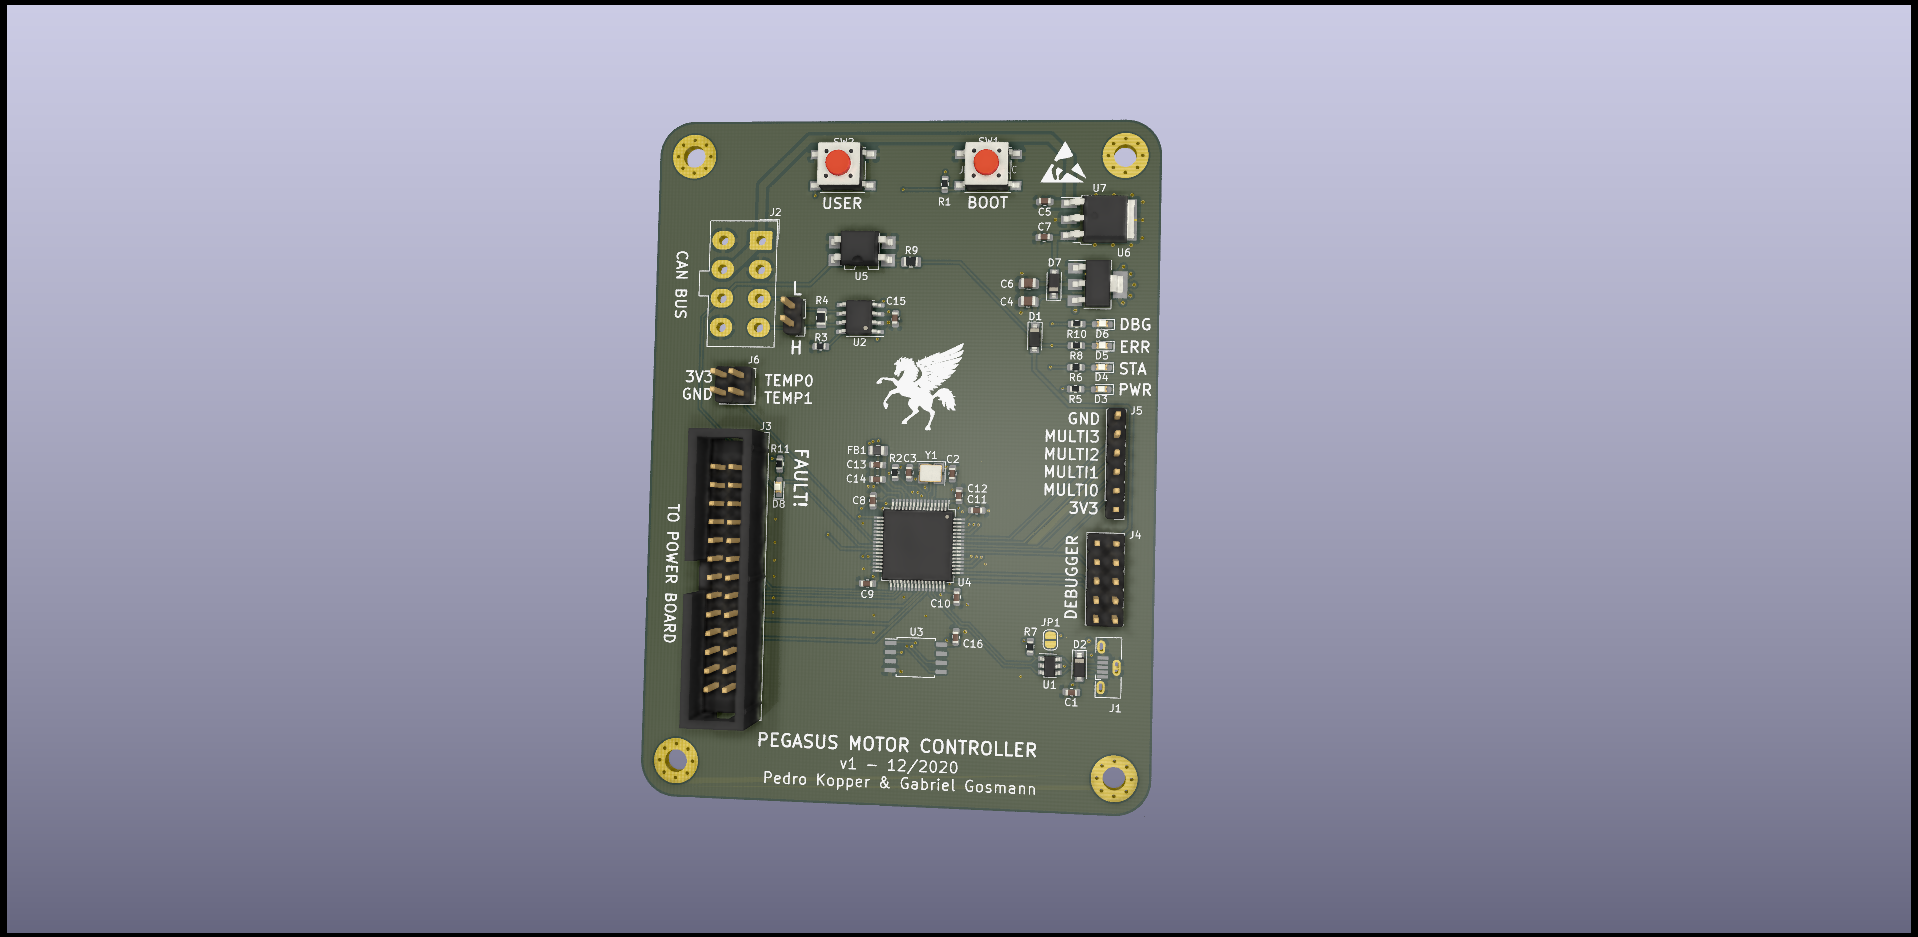
Essa placa é responsável por realizar o acionamento e controle dos motores. Utilizando um STM32F303, ela é capaz de medir a corrente ou força eletromotriz reversa de cada fase, possibilitando a comutação das bobinas. Além disso, possui entradas para sensores Hall, permitindo o uso de motores sensorados.
Além do acionamento do motor, a placa realiza a comunicação com o resto do carro via barramento CAN, possibilitando o ajuste remoto de torque. Também possui uma entrada para o barramento de falha do carro, que desativa automaticamente a saída em caso de pane em qualquer um dos sistemas. Entradas para termistores permitem o monitoramento contínuo da temperatura da ponte do inversor, possibilitando o desarme em caso de sobreaquecimento. O monitoramento da tensão da bateria permite que as saídas sejam desligadas em caso de sobre/subtensão.
Com fim de telemetria, a placa conta com uma memória flash de 128Mbits, que pode ser lida através de conexão USB para possibilitar a caracterização da performance do inveersor e do motor, diagnosticar panes, entre outros.
Esse design é hardware livre e é disponibilizado através da licença CERN-OHL-S v2 (fortemente recíproca), disponível em inglês aqui.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 9 | 100nF | Capacitor_SMD:C_0603_1608Metric | C1, C7, C9, C10, C11, C12, C14, C15, C16 |
| 6 | 1k5 | Resistor_SMD:R_0603_1608Metric | R5, R6, R7, R8, R10, R11 |
| 3 | 1N5819 | Diode_SMD:D_SOD-123 | D1, D2, D7 |
| 3 | 4.7uF | Capacitor_SMD:C_0603_1608Metric | C5, C8, C13 |
| 2 | 120 | Resistor_SMD:R_0805_2012Metric | R4, R9 |
| 2 | 12pF | Capacitor_SMD:C_0603_1608Metric | C2, C3 |
| 2 | 22uF | Capacitor_SMD:C_0805_2012Metric | C4, C6 |
| 2 | 4k7 | Resistor_SMD:R_0603_1608Metric | R1, R2 |
| 2 | FAULT | LED_SMD:LED_0603_1608Metric_Castellated | D5, D8 |
| 1 | 0 | Resistor_SMD:R_0603_1608Metric | R3 |
| 1 | 12MHz | Crystal:Crystal_SMD_3225-4Pin_3.2x2.5mm | Y1 |
| 1 | AMS1117-3.3 | Package_TO_SOT_SMD:SOT-223-3_TabPin2 | U6 |
| 1 | BOOT | Button_Switch_SMD:SW_SPST_PTS645 | SW1 |
| 1 | BUTTON | Button_Switch_SMD:SW_SPST_PTS645 | SW2 |
| 1 | CAN | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J7 |
| 1 | CAN BUS | Connector_Molex:Molex_Mini-Fit_Jr_5566-08A_2x04_P4.20mm_Vertical | J2 |
| 1 | DEBUG | LED_SMD:LED_0603_1608Metric_Castellated | D6 |
| 1 | EL817 | Package_DIP:SMDIP-4_W7.62mm | U5 |
| 1 | Ferrite | Inductor_SMD:L_0805_2012Metric | FB1 |
| 1 | L7805 | Package_TO_SOT_SMD:TO-252-3_TabPin2 | U7 |
| 1 | LOGO | Custom:pegasus_large | G*** |
| 1 | LOGO | Custom:repo_qrcode | G*** |
| 1 | MULTI | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | J5 |
| 1 | Mini-Debugging | Connector_PinHeader_2.54mm:PinHeader_2x05_P2.54mm_Vertical | J4 |
| 1 | PWR | LED_SMD:LED_0603_1608Metric_Castellated | D3 |
| 1 | SN65HVD230 | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U2 |
| 1 | SRV05-4 | Package_TO_SOT_SMD:SOT-23-6 | U1 |
| 1 | STATUS | LED_SMD:LED_0603_1608Metric_Castellated | D4 |
| 1 | STM32F303RCTx | Package_QFP:LQFP-64_10x10mm_P0.5mm | U4 |
| 1 | TEMP | Connector_PinHeader_2.54mm:PinHeader_2x02_P2.54mm_Vertical | J6 |
| 1 | TO_POWER_BOARD | Connector_IDC:IDC-Header_2x13_P2.54mm_Vertical | J3 |
| 1 | USB PULL | Jumper:SolderJumper-2_P1.3mm_Open_RoundedPad1.0x1.5mm | JP1 |
| 1 | USB_B_Mini | Connector_USB:USB_Micro-B_Molex-105133-0001 | J1 |
| 1 | W25Q128JVS | Package_SO:SOIC-8_5.23x5.23mm_P1.27mm | U3 |
The 56 most common of 62 parts.
VectorLabsTechnology/Pegasus-Motor-Controller
Projeto de um inversor para um motor PMSM com FOC

VectorLabsTechnology/Pegasus-Motor-Controller
Projeto de um inversor para um motor PMSM com FOC


klaus-liebler/sensact
Es gibt vier Namespaces für Nachrichten "REQUEST" und "RESPONSE", "EVENT" und "ACKNOWLEDGE". Dies wird mit den beiden LSB des Versions-Namespace-Bytes erklärt (Somit bleiben 64 Versionierungsmöglichkeiten) Alle vier…


7903555032/AERIS-H743-PCB
A 6-layer STM32H743-based embedded development and flight-control/data-logging PCB designed as a practical hardware-design and PCB-layout project.

It measures 72.1 × 97 mm and has 4 copper layers, 1.6 mm thick.
62 parts, built around the SN65HVD230D, W25Q128JVSIQ, AMS1117-3.3 and EL817. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the VectorLabsTechnology/Pegasus-Motor-Controller repository on GitHub, at the commit this page was made from: the board is hw/MCU_Comms_Control/MCU_Comms_Control.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).