2 layers83.3 × 65.3 mm
SimonShield
github-linguist/linguist
Language Savant. If your repository's language is being reported incorrectly, send us a pull request!
46 parts14kMIT

 tomstraka01-git/RoboticDog
DYI robotic dog made for statis hackathon
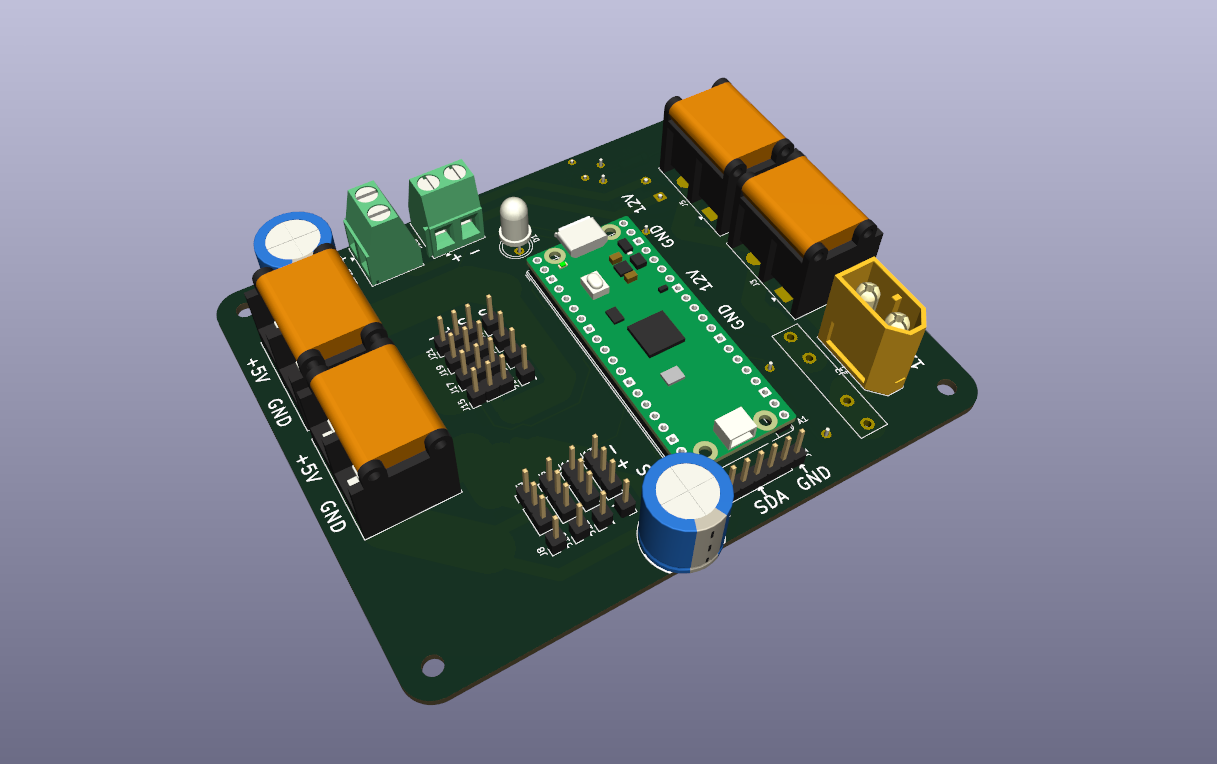
StatisHackathonRobotDog is an open-source printed circuit board by tomstraka01-git, from the tomstraka01-git/RoboticDog repository on GitHub, published under the MIT licence. It is a 2-layer board of 104 × 83.8 mm with 46 parts on 47 nets, routed with 239 tracks and 0 vias.
Its parts include 24 connectors, 12 capacitors, 3 resistors, 1 diode and 1 fuse. It belongs with the RP2040 boards of this library.
Robotic Dog is a dyi robotic dog, that can walk, stand, sit, turn, etc. It is almost fully made out of 3D printed pla plastic. It is controlled with wifi from any device capable of using wifi access points.
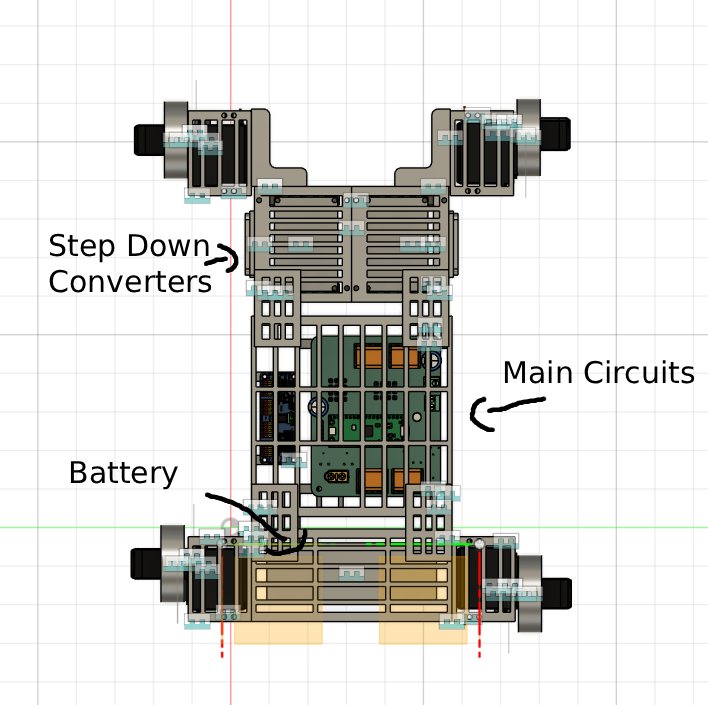
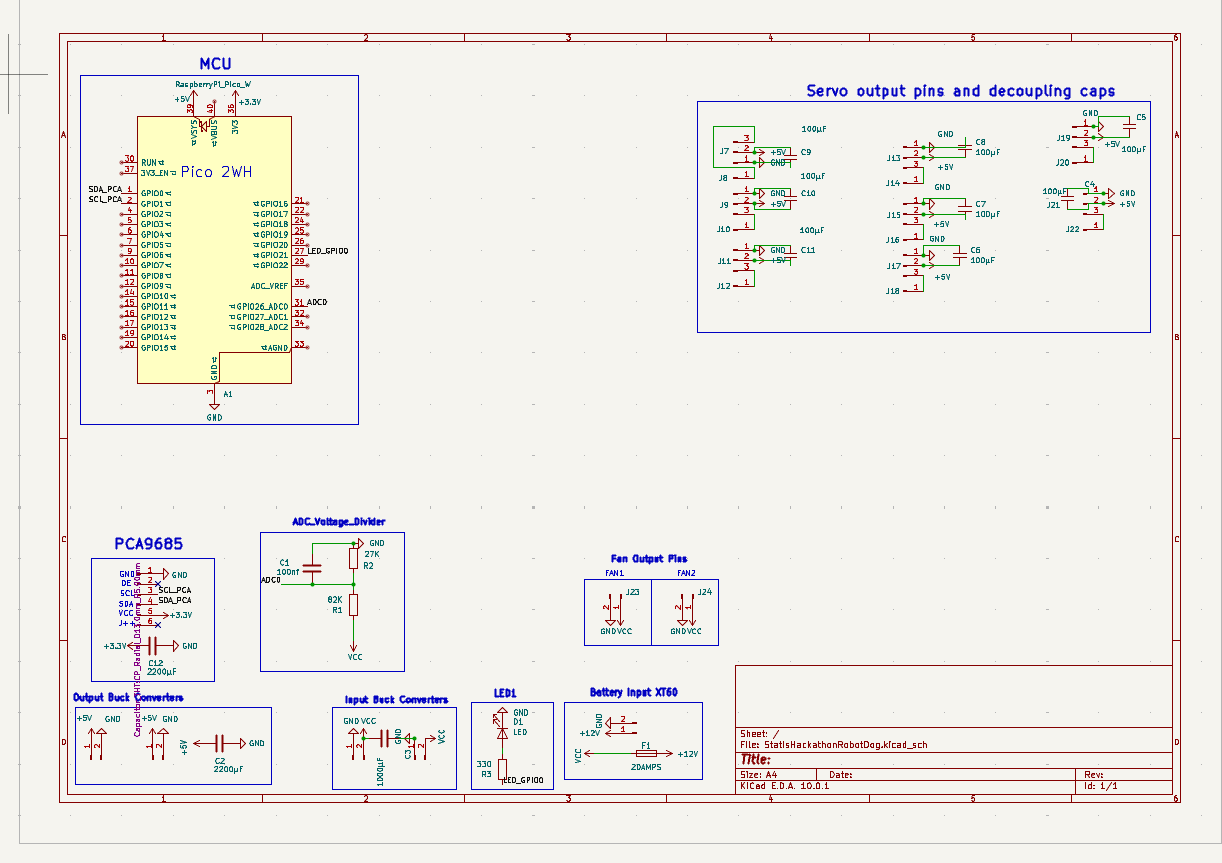
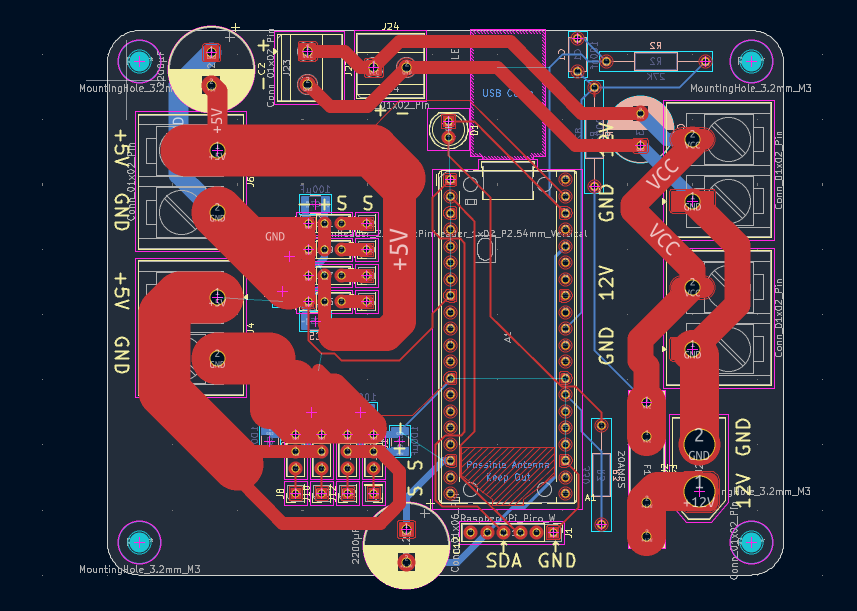
This project uses a custom pcb, the files for it are in this github repo. The pcb connects all the mesy components into a smaller board, and makes it easier to work with. For the main source of power i use 12v lipo battery, wich goes thorugh a fast fuse for safety into 2 terminals on the pcb. Then it goes through the output terminals into 2 stepdown converters wich convert it to 5v and more current. Then it goes to the servo power pins. I use decoupling capacitors in my design and few capacitors to keep power stable. I also use a signaling led and adc voltage divider battery voltage reader. I also use PCA9685 servo motor driver, wich can transform 12c commands into 16 channels max pwm output signals. I also use two fans in my design to cool the converters.

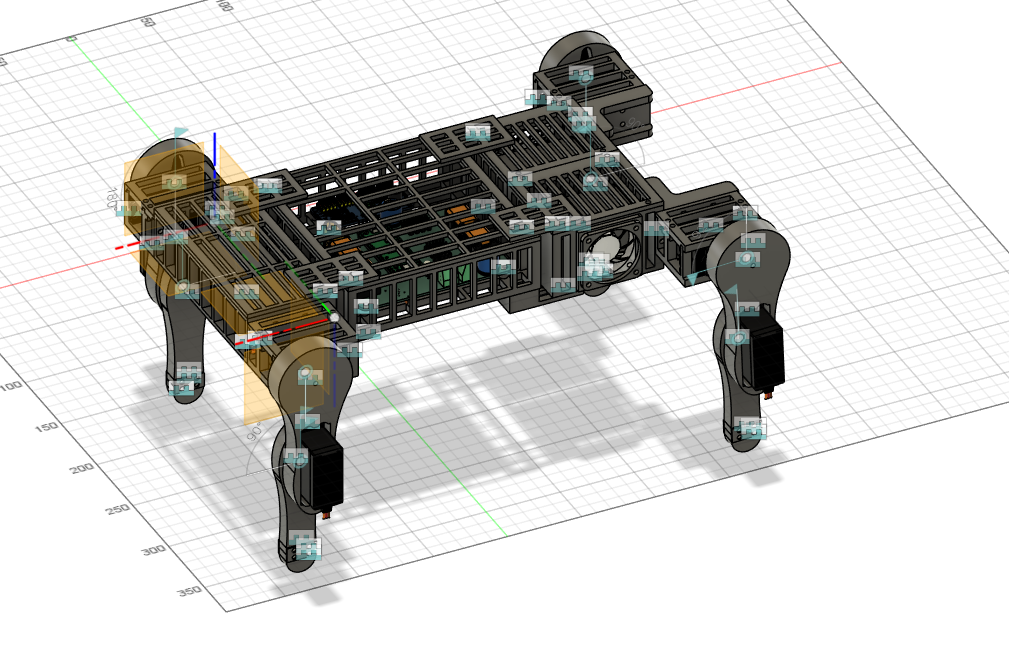
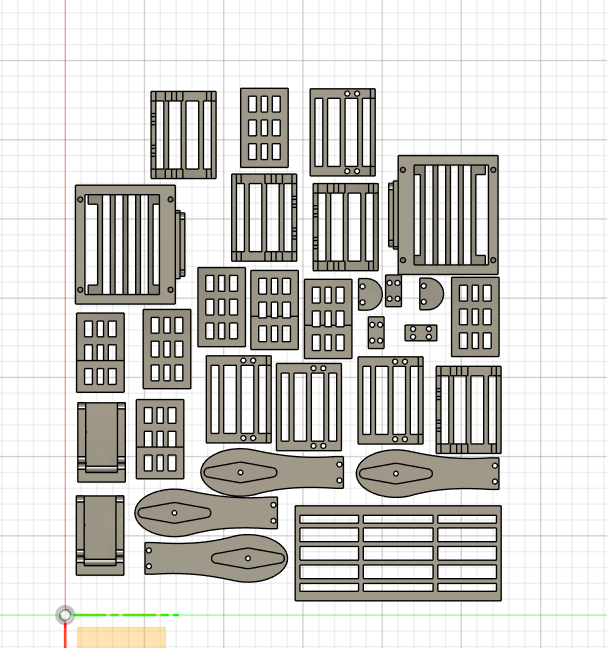
I wanted to 3D print it on my schools large 3D printer, but the files were too big so i split it into two smaller print files. It would take to print about over 1 day with a big enough 3D printer. The robotic dog has 4 legs, each one has two movable joins/servos.
I have always liked robots and robotic dogs and i always wondered if i could maybe someday build that. Then i found out about this hackathon and decided to join it. It is also a great learning opportunity, because for this project, i had to learn more about fusion 360 and completely kicad and pcb design. I had never done that before and now i have learned something about it. It is also practical, when i want to move something, i can use the robot dog to move things for me. For now it doesnt have any robotic arm or gripper but mayber later i will add some complexity if it works. I also have a dog and thought that it could be like a friend to my dog.
Total estimated cost: $112.47
| Name | Purpose | Qty | Cost (USD) | Link |
|---|---|---|---|---|
| Terminal Block HB9500M 2-pin 9.5mm | Buck In / Buck Out / Fan connections | 10 | $1.42 | C601239 |
| Terminal Block HB9500M 2-pin 9.5mm | Battery XT60 Input | 2 | $0.76 | C5334533 |
| Electrolytic Cap 2200µF 25V | 5V output rail decoupling | 5 | $0.70 | C44598 |
| Electrolytic Cap 1000µF 25V | Input buck decoupling | 10 | $0.84 | C10750 |
| Electrolytic Cap 2200µF 25V | PCA9685 3.3V rail decoupling | 5 | $0.70 | C44598 |
| Ceramic Cap 100nF 50V | ADC decoupling | 10 | $0.60 | C110282 |
| Resistor 330Ω ¼W | LED current limiting | 50 | $0.46 | C433729 |
| Resistor 27kΩ ¼W | ADC voltage divider (high side) | 50 | $0.43 | C70804 |
| Resistor 82kΩ ¼W | ADC voltage divider (low side) | 50 | $0.22 | C1367404 |
| LED 5mm Red Clear | Power indicator | 20 | $0.69 | C87271 |
| Fuse Holder 5×20mm PCB mount | Holds the main fuse | 5 | $0.39 | C3131 |
| Fuse 20A Fast-Blow 5×20mm | Main power circuit protection | 20 | $0.75 | C13567 |
| Terminal Block Phoenix 5.08mm 2-pin | Fan output connections | 6 | $2.92 | C5183929 |
| Pin Header 1×6 2.54mm | PCA9685 I2C connection | 10 | $0.44 | C37208 |
| Pin Header 1×3 2.54mm | Servo signal / VCC / GND connection | 20 | $0.62 | C2337 |
| SMD Cap 100µF 1210 HandSolder | Servo power decoupling | 24 | $2.04 | C15008 |
| Socket 20-pos 2.54mm Single Row TH | Raspberry Pi Pico socket | 5 | $1.47 | C41417332 |
LCSC subtotal: $15.70 (+ $13.00 shipping)
| Name | Purpose | Qty | Cost (USD) | Link |
|---|---|---|---|---|
| Buck Converter XL4016E1 8A 200W | Steps down battery voltage for electronics | 2 | $6.12 | Dratek |
| Servo Motor MG996R 13kg/cm | Drives the robot dog joints | 8 | $47.13 | Dratek |
| DuPont Cable M-F 40x 40cm | Servo cable extensions | 1 | $2.72 | Dratek |
| Fan 40×10mm 12VDC | Cooling for buck converters | 2 | $6.30 | Dratek |
Dratek subtotal: $62.27 (+ $4.00 shipping)
| Supplier | Shipping Cost | Notes |
|---|---|---|
| Dratek.cz | $4.00 | Standard shipping |
| JLCPCB | $10.00 | Europacket, best balance of cost and delivery time |
| LCSC | $16.00 | 15 business days standard delivery |
| Category | Cost |
|---|---|
| LCSC Components | $15.70 |
| Dratek Components | $62.27 |
| JLCPCB PCB | $7.50 |
| Shipping (all) | $30.00 |
| Total | $112.47 |
| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | 100µF | Capacitor_SMD:C_1210_3225Metric_Pad1.33x2.70mm_HandSolder | C4, C5, C6, C7, C8, C9, C10, C11 |
| 8 | Conn_01x01_Pin | Connector_PinHeader_2.54mm:PinHeader_1x01_P2.54mm_Vertical | J8, J10, J12, J14, J16, J18, J20, J22 |
| 8 | Conn_01x03_Pin | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J7, J9, J11, J13, J15, J17, J19, J21 |
| 3 | Conn_01x02_Pin | TerminalBlock_Ningbo-Kagnex:TerminalBlock_Ningbo-Kagnex_HB9500M_1x02_P9.5mm | J3, J5, J6 |
| 2 | 2200µF | Capacitor_THT:CP_Radial_D13.0mm_P5.00mm | C2, C12 |
| 2 | Conn_01x02_Pin | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-2-5.08_1x02_P5.08mm_Horizontal | J23, J24 |
| 1 | 1000µF | Capacitor_THT:CP_Radial_D10.0mm_P5.00mm | C3 |
| 1 | 100nf | Capacitor_THT:C_Disc_D5.0mm_W2.5mm_P5.00mm | C1 |
| 1 | 20AMPS | Fuse:Fuseholder_Littelfuse_445_030_series_5x20mm | F1 |
| 1 | 27K | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P15.24mm_Horizontal | R2 |
| 1 | 330 | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P15.24mm_Horizontal | R3 |
| 1 | 82K | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P15.24mm_Horizontal | R1 |
| 1 | Conn_01x02_Pin | Connector_AMASS:AMASS_XT60-M_1x02_P7.20mm_Vertical | J2 |
| 1 | Conn_01x06_Pin | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | J1 |
| 1 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | TerminalBlock_Ningbo-Kagnex:TerminalBlock_Ningbo-Kagnex_HB9500M_1x02_P9.5mm | J4 |
| 1 | LED | LED_THT:LED_D5.0mm_Clear | D1 |
| 1 | RaspberryPi_Pico_W | Module:RaspberryPi_Pico_Common_THT | A1 |
The 42 most common of 46 parts.
It measures 104 × 83.8 mm and has 2 copper layers, 1.6 mm thick.
46 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the tomstraka01-git/RoboticDog repository on GitHub, at the commit this page was made from: the board is PCB/StatisHackathonRobotDog.kicad_pcb and its schematic PCB/StatisHackathonRobotDog.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
github-linguist/linguist
Language Savant. If your repository's language is being reported incorrectly, send us a pull request!

byrantech/laptop
anyon_e, a highly integrated, high end, open source laptop. Attempt the impossible.

VoronDesign/Voron-Hardware
Cool Hardware designed by the Voron Design group


hackclub/OnBoard
💡 Join 1,000 teenagers and make your first PCB with a $100 grant!


OLIMEX/DIY-LAPTOP
Do It Yourself Open Source Hardware and Software Modular Hacker's Friendly Laptop