
4 layers8.3 × 5 mm
DRV8311 on motor driver
techy-robot/Mighty-Micro-Motors
Tiny drone motors with a high reduction gearbox, a precise mangetic encoder, and a FOC controller
22 parts13CERN-OHL-S-2.0

 techy-robot/CACKLE-Driver-DRV8311_Motor_Driver
This is a single brushless motor driver based on the DRV8311 Texas Instruments chip. It is capable of 5 amps current in a voltage range of 3 to 24 volts. It has integrated current sense amplifiers and protection logic.
DRV8311 Motor Driver is an open-source printed circuit board by techy-robot, from the techy-robot/CACKLE-Driver-DRV8311_Motor_Driver repository on GitHub. It is a 4-layer board of 15 × 15 mm with 29 parts on 18 nets, routed with 105 tracks and 62 vias.
It is built around the DRV8311HRRWR. Its parts include 11 connectors, 10 capacitors, 3 resistors and 1 IC. It belongs with the robots and motor control boards of this library.
[!TIP] This board is part of a larger modular control board ecosystem, CACKLE
This is a single brushless motor driver based on the DRV8311 Texas Instruments chip. It is capable of 5 amps current in a voltage range of 3 to 24 volts. It has integrated current sense amplifiers and protection logic. It supports up to 200khz PWM frequency.
The chip has 3 current sense outputs, tied to all three ADC pins. The motor output is through a Molex Picoblade (1.25mm pitch) 3-pin connector.
The module is a 4-layer PCB with additional exposed traces for the power and ground to add solder for more current carrying capability. I designed it to carry 10 amps with 1 oz outer copper and 0.5oz inner copper, which can be increased to 20 amps current by adding solder. This was the cheapest method to go with, since 2 oz copper would add an additional 30$ per 5 boards.
3D model
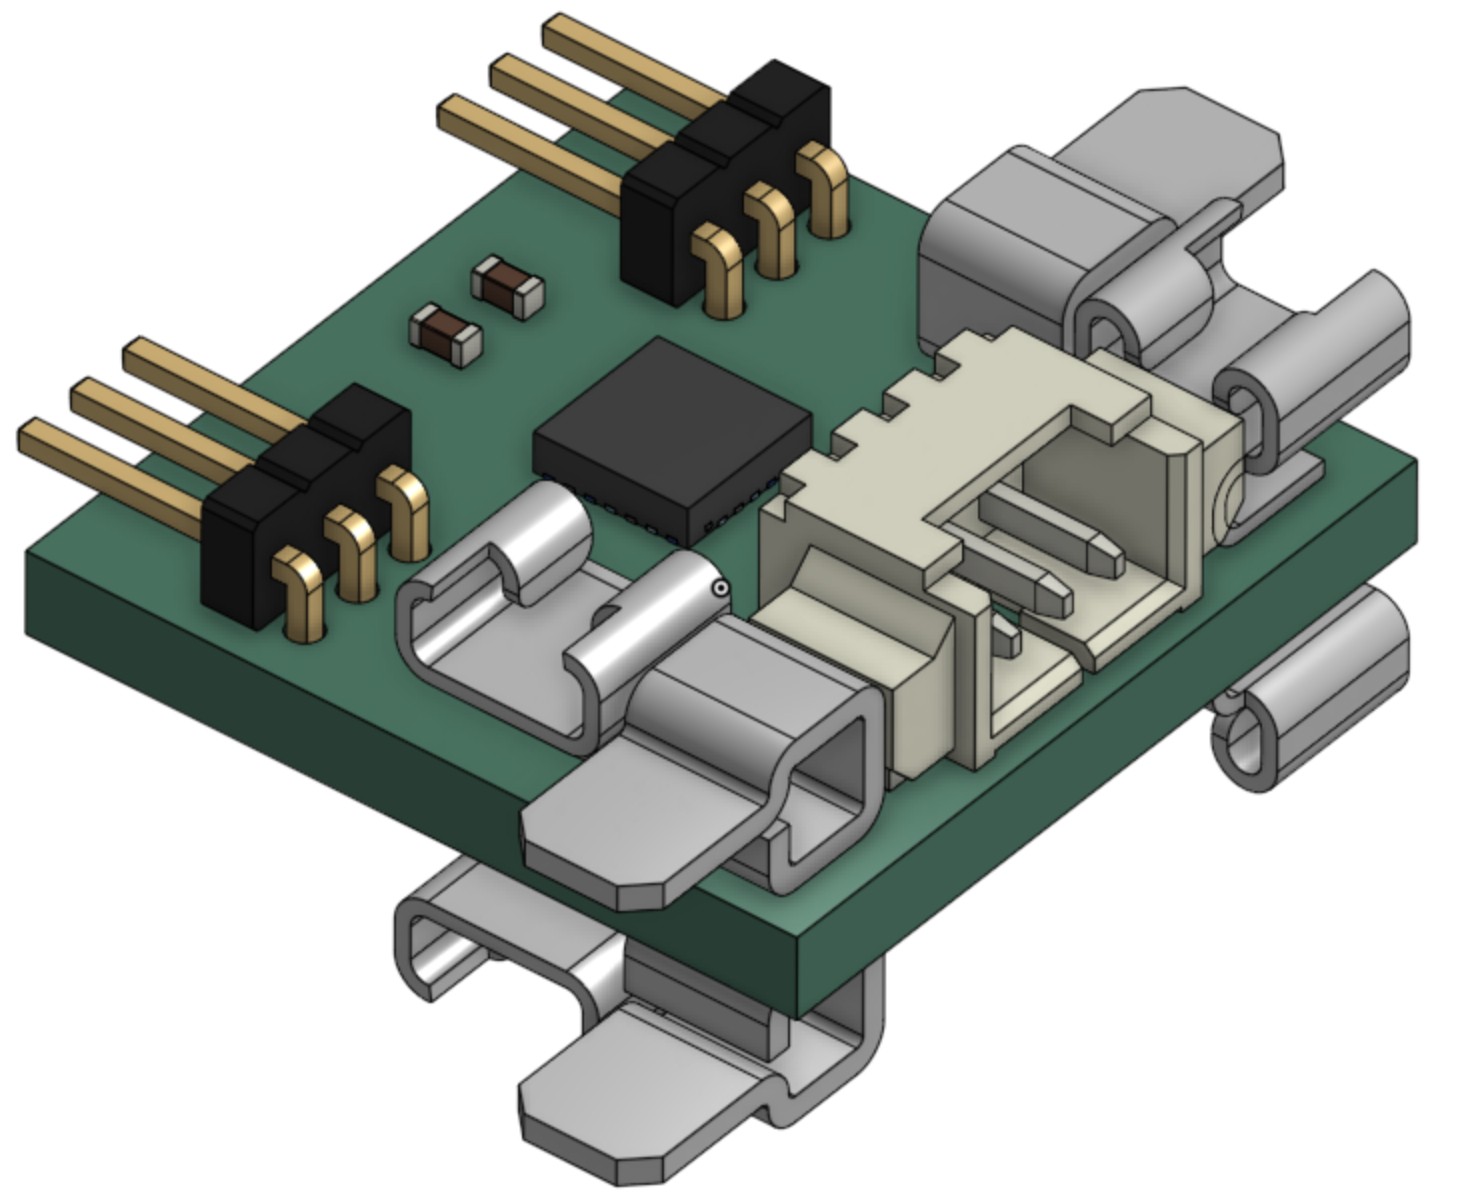
| Qty | Value | Footprint | References |
|---|---|---|---|
| 5 | 10uF, 16v | Capacitor_SMD:C_0603_1608Metric | C4, C5, C8, C9, C10 |
| 4 | Keystone 3569 | custom_Connector:Keystone_3569_half | J5, J6, J8, J10 |
| 4 | Keystone 3579 | custom_Connector:Keystone_3579 | J3, J7, J9, J11 |
| 2 | 1.27mm pin header | Connector_PinHeader_1.27mm:PinHeader_1x03_P1.27mm_Horizontal | J1, J2 |
| 2 | 100nF, 16v | Capacitor_SMD:C_0402_1005Metric | C3, C7 |
| 2 | 100nF, 16v | Capacitor_SMD:C_0603_1608Metric | C2, C6 |
| 1 | 100k | Resistor_SMD:R_0402_1005Metric | R2 |
| 1 | 3.3v | TestPoint:TestPoint_Pad_D1.0mm | TP5 |
| 1 | 300k | Resistor_SMD:R_0402_1005Metric | R1 |
| 1 | 4.7uF, 10v | Capacitor_SMD:C_0402_1005Metric | C1 |
| 1 | 47k | Resistor_SMD:R_0402_1005Metric | R3 |
| 1 | DRV8311HRRWR | custom_Driver_Motor:DRV8311_0.3mmVias | U1 |
| 1 | Fault | TestPoint:TestPoint_Pad_D1.0mm | TP3 |
| 1 | GND | TestPoint:TestPoint_Pad_D1.0mm | TP4 |
| 1 | Molex Picoblade | Connector_Molex:Molex_PicoBlade_53048-0310_1x03_P1.25mm_Horizontal | J4 |
| 1 | NetTie_2 | custom_Connector:NetTie-2_SMD_Pad0.2mm | NT1 |
techy-robot/Mighty-Micro-Motors
Tiny drone motors with a high reduction gearbox, a precise mangetic encoder, and a FOC controller

HeyPCB/knuckle
35 mm round FOC driver for a GBM2804 gimbal motor that answers on the Open Duck Mini's servo bus as an STS3215. 6-layer KiCad 10 board plus printed standoff, cover and horn adapter.

JacobBanghart/clickdeck
Custom Stream Deck-style USB controller: per-key images, micro switches, haptic knobs


sedlak477/owl-hardware
Hardware design files and build instructions for the OWL platform

punkfab/pcb-corpus
235 real KiCad boards from open-source hardware repositories, prepared as a placement and routing benchmark
It measures 15 × 15 mm and has 4 copper layers, 1.6 mm thick.
29 parts, built around the DRV8311HRRWR. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the techy-robot/CACKLE-Driver-DRV8311_Motor_Driver repository on GitHub, at the commit this page was made from: the board is DRV8311 Motor Driver.kicad_pcb and its schematic DRV8311 Motor Driver.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask techy-robot before reusing the design.