
2 layers48.8 × 50.4 mm
 techno-robocup/robocup2027-pcb-data
Our board data.
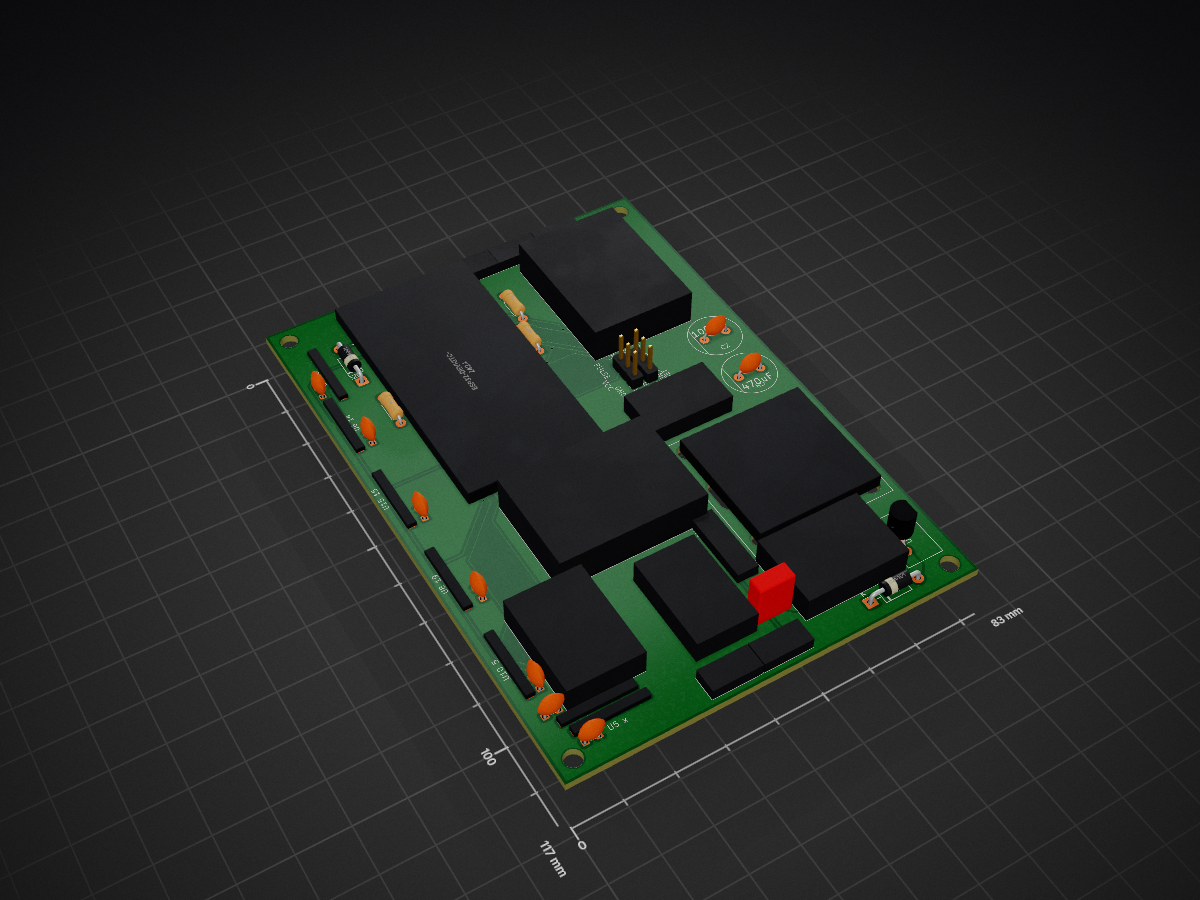
Robocup2027-pcb data is an open-source printed circuit board by techno-robocup, from the techno-robocup/robocup2027-pcb-data repository on GitHub, published under the GPL-3.0 licence. It is a 4-layer board of 83 × 117 mm with 46 parts on 69 nets, routed with 209 tracks and 10 vias.
It is built around the ESP32-DEVKITC-32E. Its parts include 16 ICs, 9 capacitors, 3 resistors, 2 diodes and 2 switches. It belongs with the ESP32 boards of this library.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 7 | 0.1uF | robo:2.54mm_capacitor | C1, C3, C4, C5, C6, C7, C9 |
| 7 | ~ | robo:VL53L1X-ToF | U5 x, U6 14, U7 18, U8 19, U9 23, U10 5, U15 15 |
| 6 | ~ | robo:sts3032 | M1, M2, M3, M7, M8, M9 |
| 4 | , , , | ||
| 2 | 1N4001 | Diode_THT:D_DO-41_SOD81_P10.16mm_Horizontal | D1, D2 |
| 2 | 8.4k | robo:Resister | R1, R2 |
| 2 | Motor_Servo | robo:servo_motor_3 | M5, M6 |
| 2 | tactile switch | robo:CW-SB11KKFF | S1, S2 |
| 2 | ~ | robo:AE-HX711 | U4, U12 |
| 1 | 1000uF | robo:capacitor | C2 |
| 1 | 100k | robo:Resister | R3 |
| 1 | 470uF | robo:capacitor | C8 |
| 1 | ESP32-DEVKITC-32E | robo:MODULE_ESP32-DEVKITC-32E | U1 |
| 1 | Fuse | robo:5.08mm_capacitor_1 | F1 |
| 1 | ~ | robo:AE-BNO055-BO | U14 |
| 1 | ~ | robo:LiPo | L1 |
| 1 | ~ | robo:DCDC-LTC3111 | U11 |
| 1 | ~ | robo:PKM13EPYH4000-A0 | U17 |
| 1 | ~ | robo:fe-urt-2 | U13 |
| 1 | ~ | robo:DCDC-M78AR033-0.5 | U16 |
| 1 | ~ | robo:voltmeter | U3 |

AnotherBuildCorner/Pickup_Winder
A DIY pickup winder with CNC capability, from mostly off the shelf parts

OSHE-Github/Smart-BREAD
Creating an HMI for the BREAD Ecosystem, as well as a conveyor belt to be paired with the improved computation capabilities of the BREAD system.

virgile-tchidehou/smart-soja
An autonomous IoT-based mobile system for soybean pre-processing, integrating embedded systems, industrial automation, solar energy and cloud connectivity.


Aryan-swag/VentSense
VentSense: 2-of-3 gas/temperature/voltage early warning and per-cell isolation for small Li-ion packs. Vishwakarma Awards 2026-27 Stage 2 (VK26-IITH-SE-0279)

BryanFarras/Desain-Proyek-2
Autonomous Evacuation Rover (AER) is an integrated mobile robotics platform developed for autonomous exploration, mapping, hazard detection, and evacuation assistance in unknown or hazardous indoor environments.
It measures 83 × 117 mm and has 4 copper layers, 1.6 mm thick.
46 parts, built around the ESP32-DEVKITC-32E. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the techno-robocup/robocup2027-pcb-data repository on GitHub, at the commit this page was made from: the board is robocup2027-pcb-data.kicad_pcb and its schematic robocup2027-pcb-data.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).