2 layers97.8 × 58.3 mm
 Simonhajd/Triton-Float
Float Repo for the 2026 Triton Float
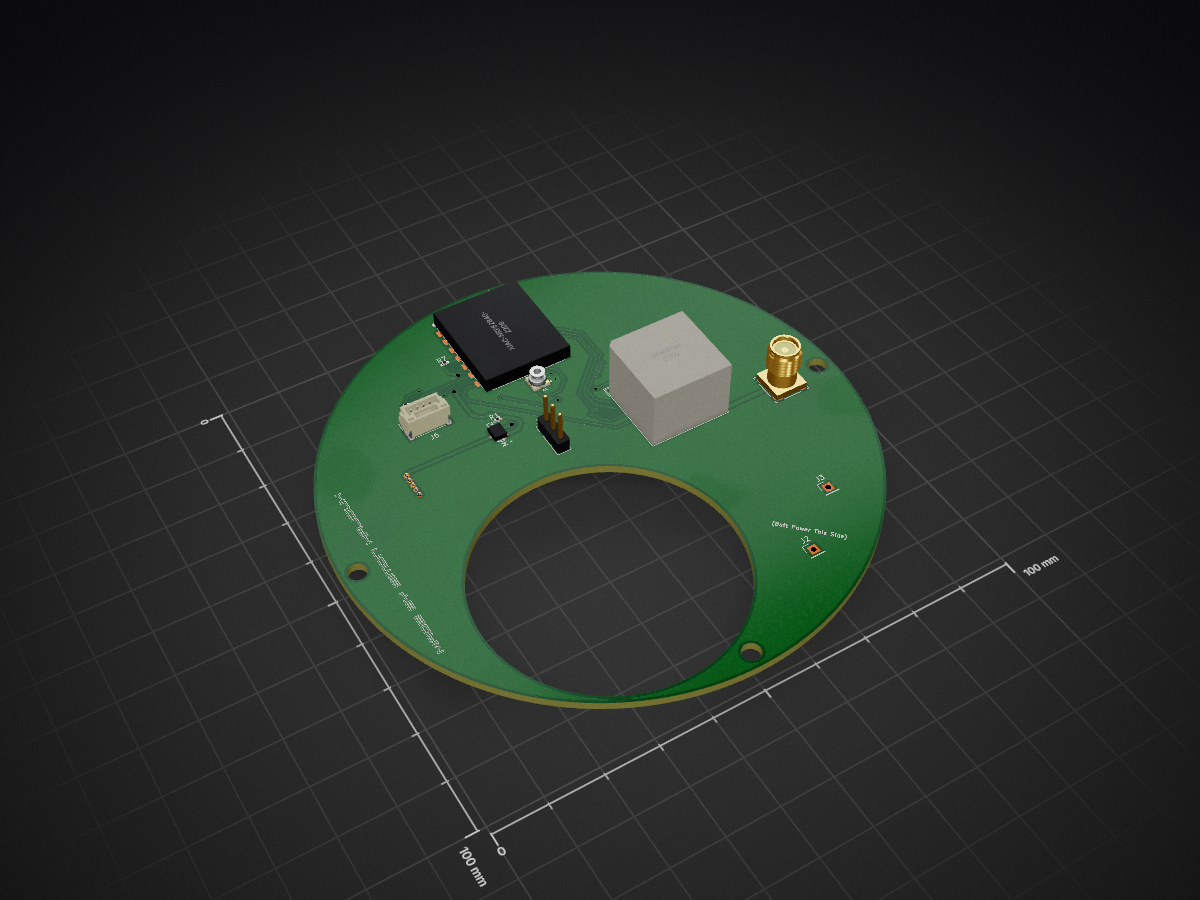
FlightController is an open-source printed circuit board by Simonhajd, from the Simonhajd/Triton-Float repository on GitHub. It is a 2-layer board of 97 × 95.7 mm with 19 parts on 24 nets, routed with 257 tracks and 13 vias.
It is built around the MS583702BA01-50, RFM95W and DMP3068L-7. Its parts include 8 resistors, 6 connectors and 2 ICs. It belongs with the robots and motor control boards and the nRF52 and nRF5x boards of this library.


Development repository for the 2026 Triton Robotics Float.
The Triton Float is being developed for the 2026 MATE ROV Pioneer competition (Newfoundland). This design iteration is approximately 33% smaller than last year's model, while targeting more than 2× performance improvements in speed and significantly increased precision through layered redundancy and sensor feedback systems. It also includes a dedicated LoRa radio as opposed to last year's 4cm wire antenna, which will increase the reliability and robustness of the system.
Dimensions: 200mm x 4 in diameter. Buoyancy system: PWM pump ranging from 220mL/min to -220mL/min.
Accuracy Strategy:
Microcontroller: XIAO nRF52840 Sense
Sensors:
Power System:
Custom voltage regulation system controlled via relay and magnetic hall-effect sensor on a secondary accessory PCB
PCB Revisions:
R2 completed, R3 in development
Fusion / CAD link: 🔗 View Fusion 360 CAD
Notes:
Cylindrical housing designed to fit within a 4 in diameter constraint
Internal layout arranged to allow operation in the case of flooding (up to ~50-75% of internal volume) while maintaining core electronic functionality.
PCB mounted using tight-tolerance standoffs to prevent movement under vibration and ease serviceability
Layer system used to keep the float intact when the top flange and shell is removed.
Limited internal volume required careful routing of wiring and tubing
Added solderable vias for power, in order to have a secure connection to the battery.
Accessory PCB used to isolate power regulation from main control logic
R3 revision addresses footprint issues and uses a different simpler power system for a working prototype.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 5 | 4.7k | Resistor_SMD:R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R1, R2, R5, R6, R7 |
| 2 | DMP3068L-7 | DMP3068L_7:SOT-23_DMP3068L_DIO | MOSFET1, MOSFET2 |
| 1 | 0.1uF | Resistor_SMD:R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R3 |
| 1 | 10k | Resistor_SMD:R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R8 |
| 1 | 10uF | Resistor_SMD:R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R4 |
| 1 | 530470510 | 530470510:MOLEX_530470510 | J8 |
| 1 | BATT IN | Connector_PinHeader_2.54mm:PinHeader_1x01_P2.54mm_Vertical | J2 |
| 1 | BATT OUT | Connector_PinHeader_2.54mm:PinHeader_1x01_P2.54mm_Vertical | J3 |
| 1 | BATT Reg IC | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J4 |
| 1 | MS583702BA01-50 | MS583702BA01_50:XDCR_MS583702BA01-50 | A1 |
| 1 | Pressure sensor | Connector_JST:JST_GH_BM04B-GHS-TBT_1x04-1MP_P1.25mm_Vertical | J6 |
| 1 | RFM95W | RF_Module:HOPERF_RFM9XW_THT | U2 |
| 1 | SMA Connector | SMAv2:CONN_RF2-04A-T-00-50-G_ADM | J1 |
| 1 | XIAO-nRF52840-DIP | Seeed Studio XIAO Series Library:XIAO-nRF52840-DIP | U1 |
It measures 97 × 95.7 mm and has 2 copper layers, 1.6 mm thick.
19 parts, built around the MS583702BA01-50, RFM95W and DMP3068L-7. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Simonhajd/Triton-Float repository on GitHub, at the commit this page was made from: the board is PCB/FlightController/FlightController.kicad_pcb and its schematic ACC PCBs/HallPCB/HallPCB.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask Simonhajd before reusing the design.


arraym/ESP8266Tetris
Tetris game with ESP8266 (ESP-12F) and WS2812B (128 RGB LEDs) - KiCAD schematic and PCB


CodeByMika/technikerarbeit2026-hardwarepruefadapter
Im Schuljahr 2025/2026 wurde im Rahmen der Ausbildung zum staatlich geprüften Techniker diese Technikerarbeit in Zusammenarbeit mit der Gottlieb Daimler Schule 2 in Sindelfingen sowie der SOTEC GmbH & Co KG in…


StanZalewski/Autonomous-remote-monitoring-system-based-on-the-LoRaWAN-protocol
Solar-powered LoRaWAN weather station — 3 custom PCBs, bare-metal STM32, 4.3 km verified link
