2 layers134.6 × 101.6 mm
JamieMotorControl
shareresearchteam/SAMI-Robot
Software and Hardware resources and development of the SAMI humanoid robot
43 parts5MIT
 shareresearchteam/SAMI-Robot5
Software and Hardware resources and development of the SAMI humanoid robot
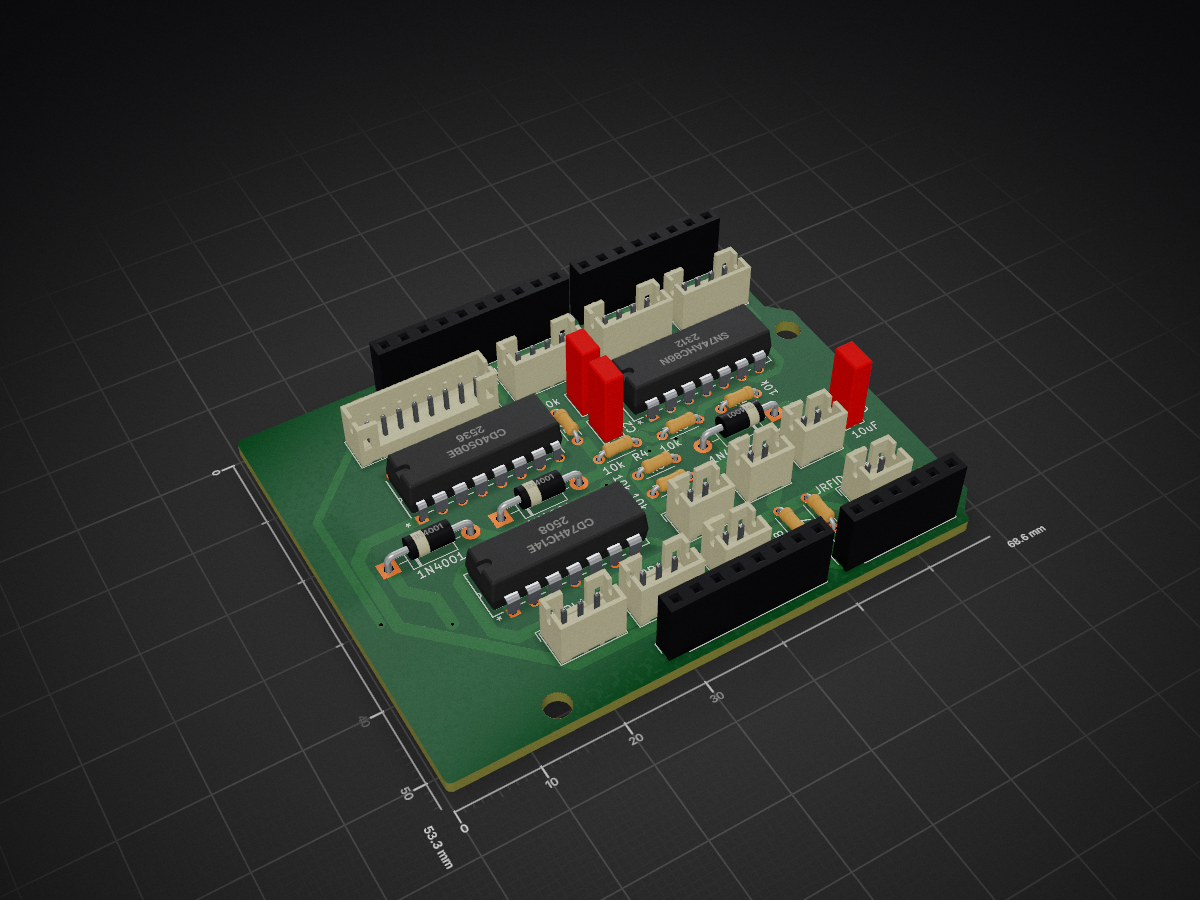
SensorArduinoHat is an open-source printed circuit board by shareresearchteam, from the shareresearchteam/SAMI-Robot repository on GitHub, published under the MIT licence. It is a 2-layer board of 68.6 × 53.3 mm with 36 parts on 53 nets, routed with 436 tracks and 28 vias.
It is built around the CD4050BE, CD74HC14E and SN74AHC86N. Its parts include 8 resistors, 4 connectors, 3 capacitors, 3 ICs and 3 diodes.


Driver board for the servo bus motors. Includes connection for LED eyes, serial control for bus servo motors, and power control for bus servo motors, with mounting spot for microcontroller dev board.
This BoM includes all items necessary to populate this particular PCB. It does not include all items necessary for the entire robot, which can be found here. The parts listed are standalone items you need, as well as a consolidated list of all items you can purchase as a group from DigiKey.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | 10k | Resistor_THT:R_Axial_DIN0204_L3.6mm_D1.6mm_P5.08mm_Horizontal | R1, R2, R3, R4, R5, R6, R7, R8 |
| 5 | Conn_01x02 | Connector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | JBtn1, JBtn2, JBtn3, JPwr1, JRFID_SWITCH1 |
| 4 | MountingHole_3.2mm | Arduino_MountingHole:MountingHole_3.2mm | MH1, MH2, MH3, MH4 |
| 3 | 10uF | Capacitor_THT:C_Rect_L4.0mm_W2.5mm_P2.50mm | C1, C2, C3 |
| 3 | 1N4001 | Diode_THT:D_DO-41_SOD81_P10.16mm_Horizontal | D1, D2, D3 |
| 3 | Conn_01x04 | Connector_JST:JST_PH_B4B-PH-K_1x04_P2.00mm_Vertical | JUltrasonicL1, JUltrasonicM1, JUltrasonicR1 |
| 2 | Conn_01x03 | Connector_JST:JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | JPIRL1, JPIRR1 |
| 1 | Analog | Connector_PinSocket_2.54mm:PinSocket_1x06_P2.54mm_Vertical | J3 |
| 1 | CD4050BE | CD4050BE:N16 | U2 |
| 1 | CD74HC14E | CD74HC14E:N14 | U1 |
| 1 | Conn_01x08 | Connector_JST:JST_PH_B8B-PH-K_1x08_P2.00mm_Vertical | JRFID1 |
| 1 | Digital/PWM | Connector_PinSocket_2.54mm:PinSocket_1x10_P2.54mm_Vertical | J2 |
| 1 | Digital/PWM | Connector_PinSocket_2.54mm:PinSocket_1x08_P2.54mm_Vertical | J4 |
| 1 | Power | Connector_PinSocket_2.54mm:PinSocket_1x08_P2.54mm_Vertical | J1 |
| 1 | SN74AHC86N | CD74HC14E:N14 | U3 |
shareresearchteam/SAMI-Robot
Software and Hardware resources and development of the SAMI humanoid robot


jrlomas/OctoPix
An extension board for additional Neopixels for the Octopus boards

adham404/Open8-VGA
An 8-bit computer from 74HC logic: microcoded CPU, VGA, PS/2, on-board editor and assembler. Play it in your browser.


koolcat6666/Engine-Simulator-2.0
Engine simulator for ECU testing based on ESP32-32U DevKitC. The system connects to the ECU through the standard Speeduino 40-pin IDC connector and generates signals to simulate real engine operation.


It measures 68.6 × 53.3 mm and has 2 copper layers, 1.6 mm thick.
36 parts, built around the CD4050BE, CD74HC14E and SN74AHC86N. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the shareresearchteam/SAMI-Robot repository on GitHub, at the commit this page was made from: the board is hardware/Electrical/SensorArduinoHat/SensorArduinoHat.kicad_pcb and its schematic hardware/Electrical/JamieMotorControl/JamieMotorControl.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).