
2 layers390 × 37 mm
ButtonsLEDs
shanteacontrols/OpenDeck
A platform for building interactive control and sensing devices using MIDI and OSC built with Zephyr RTOS.
100 parts960Apache-2.0
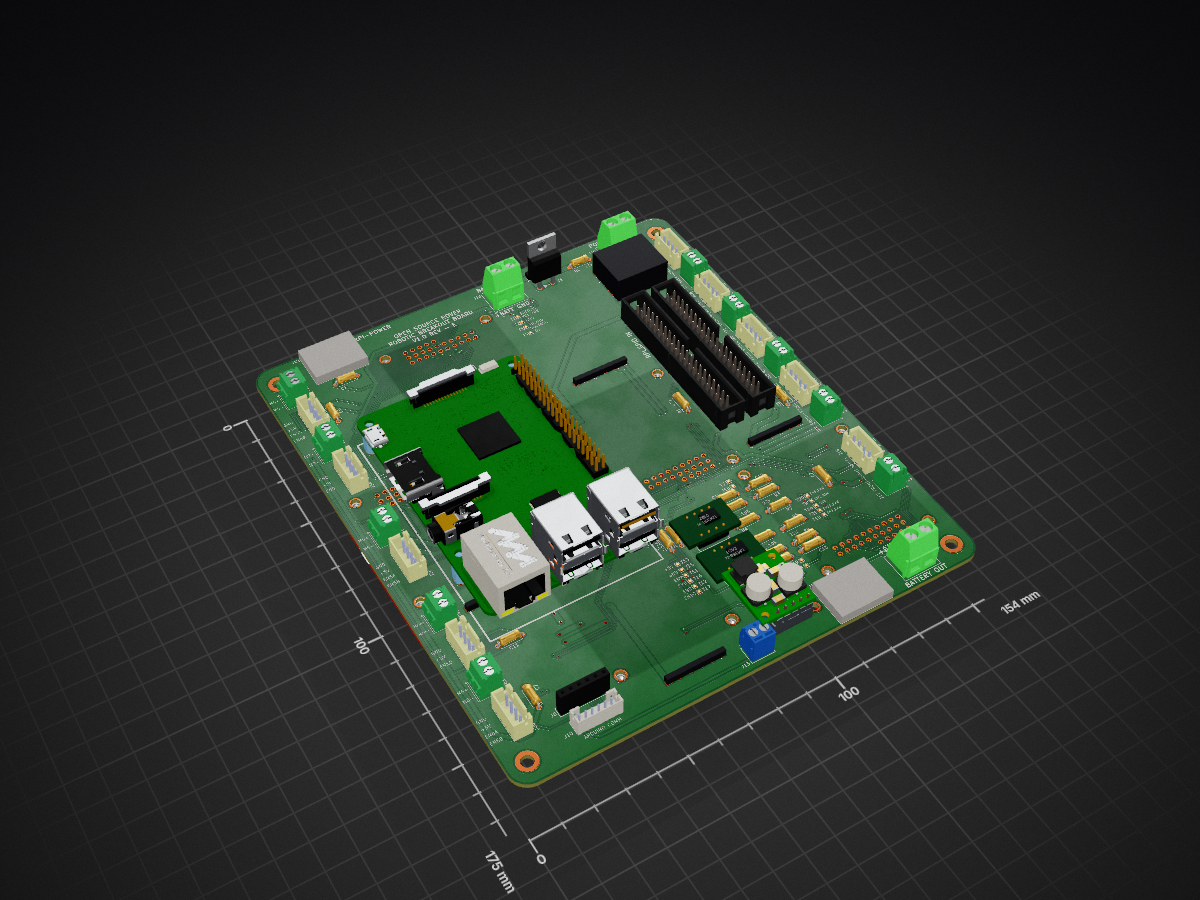
 SeniorDesignJPL/JPL-PCB
The PCB from the latest release of the JPL project
Control Board is an open-source printed circuit board by SeniorDesignJPL, from the SeniorDesignJPL/JPL-PCB repository on GitHub. It is a 2-layer board of 154 × 175 mm with 100 parts on 190 nets, routed with 1,439 tracks and 151 vias.
It is built around the LM358N011. Its parts include 37 connectors, 17 capacitors, 10 resistors, 2 ICs and 1 diode.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 21 | test_point | TestPoint:TestPoint_Pad_1.0x1.0mm | T1, T2, T3, T4, T10, T11, T12, T13, T14, T15, T16, T17, T18, T19, T20, T21 +5 |
| 12 | 100nf | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | C2, C3, C4, C5, C6, C7, C8, C9, C10, C11, C16, C17 |
| 10 | Conn_01x02 | TerminalBlock_Phoenix:TerminalBlock_Phoenix_PT-1,5-2-3.5-H_1x02_P3.50mm_Horizontal | J17, J19, J21, J23, J25, J27, J29, J31, J33, J35 |
| 10 | Conn_01x04 | Connector_JST:JST_B4B-XH-A(LF)(SN) | J18, J20, J22, J24, J26, J28, J30, J32, J34, J36 |
| 5 | 10K | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R2, R4, R6, R8, R10 |
| 5 | ED2627-ND | JPL Robotics:ED2627-ND | J1, J2, J3, J4, J5 |
| 5 | RoboClaw | JPL Robotics:Roboclaw Mount | RC1, RC2, RC3, RC4, RC5 |
| 4 | #6THRU-HOLE | JPL Robotics:#6THRU-HOLE | MH1, MH2, MH3, MH4 |
| 4 | 100nF | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | C12, C13, C14, C15 |
| 4 | 22K | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R3, R5, R7, R9 |
| 3 | ED2580-ND | JPL Robotics:ED2580-ND | J15, J16, J37 |
| 2 | ED2989-ND-USB | JPL Robotics:ED2989-ND USB Conn | J12, J14 |
| 2 | LM358-N | JPL Robotics:AE9986-ND | U1, U2 |
| 2 | S9175-ND | JPL Robotics:S9175-ND | J6, J7 |
| 1 | 0.1mF | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | C1 |
| 1 | 4.7K | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R1 |
| 1 | 6posheader | JPL Robotics:6x1 Header Pin 0.1 Pitch | J8 |
| 1 | 6posheader | JPL Robotics:455-1708-ND | J10 |
| 1 | D | JPL Robotics:497-2738-5-ND | D1 |
| 1 | ED1501-ND | JPL Robotics:ED1501-ND | J13 |
| 1 | Fuse | JPL Robotics:507-1937-1-ND | F1 |
| 1 | Mounting_Holes | JPL Robotics:Raspberry pi footprint | M1 |
| 1 | S7038-ND | JPL Robotics:S7038-ND | J9 |
| 1 | S7038-ND | JPL Robotics:D24V22F12 Regulator | J11 |
| 1 | rover_silkscreen | JPL Robotics:rover_image | y1 |
shanteacontrols/OpenDeck
A platform for building interactive control and sensing devices using MIDI and OSC built with Zephyr RTOS.

Redherring32/OpenTendo
An Open-Source HardWare (OSHW) recreation of the original 1985 front-loading NES Motherboard


vsfteam/vsf
Versaloon Software Framework -- a tiny preemptive-capable event-driven incremental software framework for embedded systems


cnlohr/cnhardware
My dumping grounds for all my kicad projects and random hardware bringup.

It measures 154 × 175 mm and has 2 copper layers, 1.6 mm thick.
100 parts, built around the LM358N011. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the SeniorDesignJPL/JPL-PCB repository on GitHub, at the commit this page was made from: the board is Control Board.kicad_pcb and its schematic Control Board.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask SeniorDesignJPL before reusing the design.